4 layers42 × 50 mm
SimpleFC G
wangyeee/OpenHardware
Collections of hardware design related to my drone project.
134 parts10BSD-3-Clause

 wangyeee/OpenHardware10
Collections of hardware design related to my drone project.
LoRaModem is an open-source printed circuit board by wangyeee, from the wangyeee/OpenHardware repository on GitHub, published under the BSD-3-Clause licence. It is a 2-layer board of 24 × 36 mm with 48 parts on 58 nets, routed with 295 tracks and 41 vias.
It is built around the RA-02, 74AHC1G86SE and SPX3819S, with the TJA1050 among its other parts. Its parts include 17 capacitors, 9 diodes, 8 resistors, 6 ICs and 3 connectors. It belongs with the robots and motor control and radio and wireless boards and the STM32 boards of this library.


The SimpleFCv2 with integrated GPS receiver. Together with its 10 DoF IMU, it has full navigation capability.
WARNING: The PCB design has not been fabricated, Use with caution!
SimpleFC was originally designed to run modified version of AutoQuad, the source can be found in my fork of AutoQuad. In additional, port for PaparazziUAV is in progress. It will make SimpleFC support both fixwing and rotorcraft.
The following table summarizes usage of the MCU, details such as pinout and DMA allocation can be found in the STM32CubeMX design file SimpleFCv2.ioc in the SimpleFCv2 folder.
| MCU Peripheral | Usage |
|---|---|
| ADC1 | battery monitor and two analog inputs |
| CAN2 | CAN bus |
| I2C1 | MMC5883MA magnetometer and EEPROM |
| SDIO | TF card slot |
| SPI1 | ICM20689 gyroscope/accelerometer and MS5611 barometer |
| TIM3, TIM4, TIM12 | 8 channel PWM output |
| UART4, USART2 | RC input, support serial, S.Bus or PPM |
| USART1 | telemetry |
| USART3 | GPS receiver |
| USB | DFU or CDC telemetry |
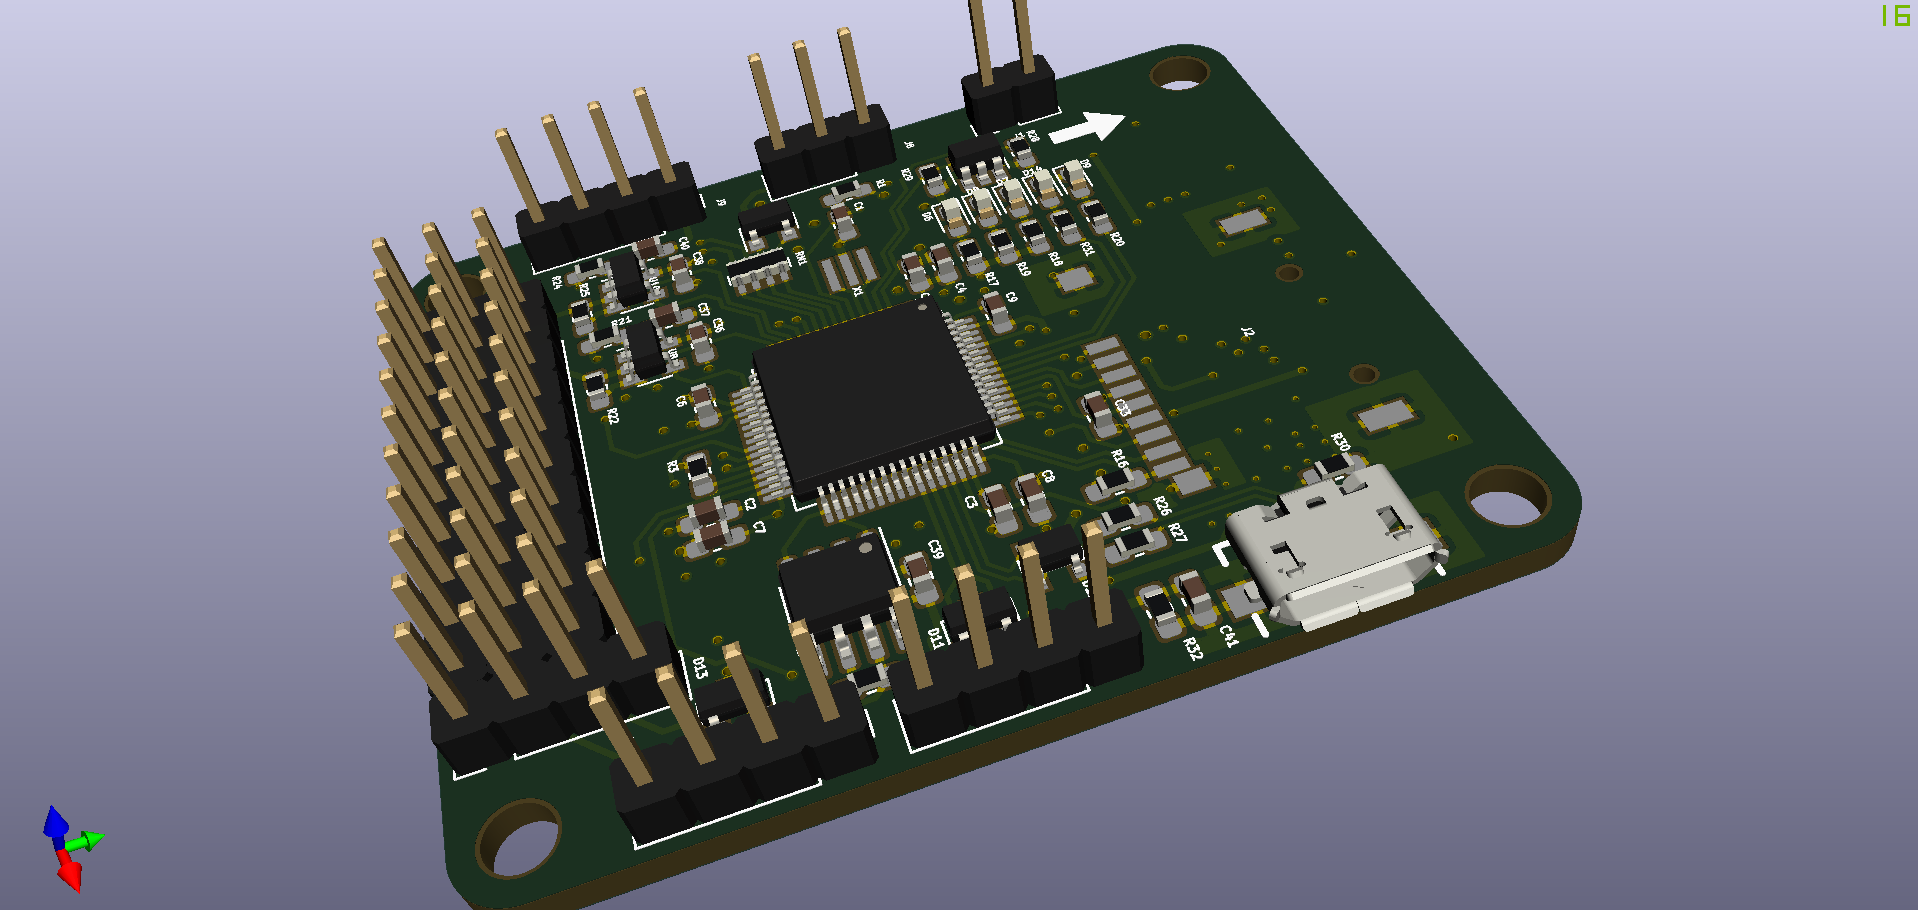
Front
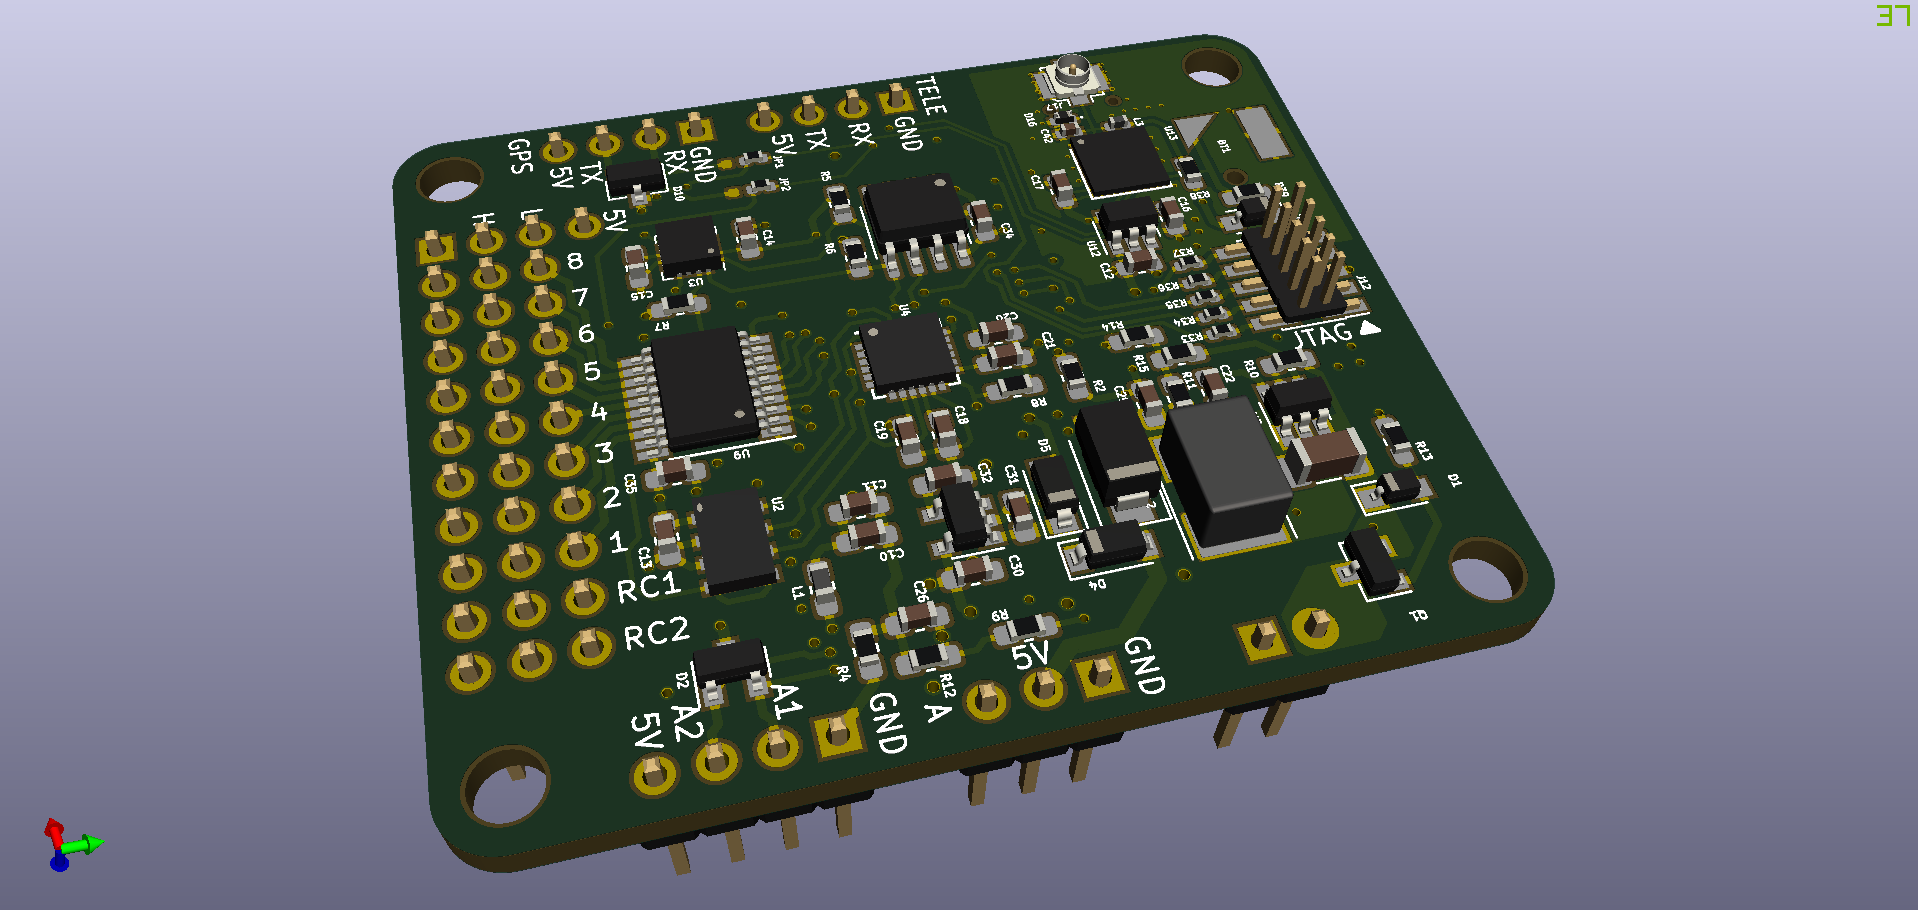
Back
| Qty | Value | Footprint | References |
|---|---|---|---|
| 10 | 100nF | STD_SMD:C_0603_HandSoldering | C1, C3, C4, C8, C10, C11, C12, C13, C15, C17 |
| 3 | 1A | Diodes_SMD:D_SOD-123 | D1, D8, D9 |
| 3 | 470 | STD_SMD:R_0603_HandSoldering | R5, R6, R7 |
| 2 | 10K | STD_SMD:R_0603_HandSoldering | R2, R3 |
| 2 | 10nF | STD_SMD:C_0603_HandSoldering | C6, C16 |
| 2 | 2.2uF | STD_SMD:C_0603_HandSoldering | C5, C7 |
| 2 | CONN_01X04 | Connector:M04_SMD | J1, J3 |
| 1 | 1.5K | STD_SMD:R_0603_HandSoldering | R8 |
| 1 | 10uF | STD_SMD:C_0603_HandSoldering | C9 |
| 1 | 120 | STD_SMD:R_0603_HandSoldering | R4 |
| 1 | 1uF | STD_SMD:C_0603_HandSoldering | C14 |
| 1 | 22uF | STD_SMD:C_0805_HandSoldering | C2 |
| 1 | 47K | STD_SMD:R_0603_HandSoldering | R1 |
| 1 | 74AHC1G86 | TO_SOT_Packages_SMD:SOT-23-5 | U6 |
| 1 | 8MHz | MurataResonators:CERALOCK-CSTCE | Y1 |
| 1 | BLUE | LEDs:LED_0603 | D5 |
| 1 | CONN_01X03 | Connector:M03 | J2 |
| 1 | GREEN | LEDs:LED_0603 | D6 |
| 1 | Jumper | PCB_Misc:JUMPER_SMALL | JP1 |
| 1 | PESD3V3 | TO_SOT_Packages_SMD:SOT-23 | D2 |
| 1 | PESD3V3 | Diodes_SMD:D_SOD-323_HandSoldering | D3 |
| 1 | PESDCAN | TO_SOT_Packages_SMD:SOT-23 | D7 |
| 1 | RED | LEDs:LED_0603 | D4 |
| 1 | Ra-02 | LCC:RA0x-LCC16 | U1 |
| 1 | SPX3819 | TO_SOT_Packages_SMD:SOT-23-5 | U4 |
| 1 | STM32F103CBTx | Housings_QFP:LQFP-48_7x7mm_Pitch0.5mm | U3 |
| 1 | SWCLK | PCB_Misc:TESTPAD_SMALL | TP2 |
| 1 | SWDIO | PCB_Misc:TESTPAD_SMALL | TP1 |
| 1 | SWO | PCB_Misc:TESTPAD_SMALL | TP3 |
| 1 | TJA1050 | Housings_SOIC:SOIC-8_3.9x4.9mm_Pitch1.27mm | U5 |
| 1 | W25X40 | Housings_SOIC:SOIC-8_3.9x4.9mm_Pitch1.27mm | U2 |
It measures 24 × 36 mm and has 2 copper layers, 1.6 mm thick.
48 parts, built around the RA-02, 74AHC1G86SE, SPX3819S and TJA1050. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the wangyeee/OpenHardware repository on GitHub, at the commit this page was made from: the board is LoRaModem/LoRaModem.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the BSD-3-Clause licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
wangyeee/OpenHardware
Collections of hardware design related to my drone project.

wangyeee/OpenHardware
Collections of hardware design related to my drone project.

wangyeee/OpenHardware
Collections of hardware design related to my drone project.

wangyeee/OpenHardware
Collections of hardware design related to my drone project.

wangyeee/OpenHardware
Collections of hardware design related to my drone project.

wangyeee/OpenHardware
Collections of hardware design related to my drone project.

wangyeee/OpenHardware
Collections of hardware design related to my drone project.

wangyeee/OpenHardware
Collections of hardware design related to my drone project.


skorokithakis/A6-ESP8266-breakout
A breakout board that includes an ESP8266 and an A6 GSM module, for easily making GSM-enabled applications (mirror)


PCBench/PCBench
resolution = [0.5, 0.5] pcbfolder = '../PCBs/' pcbnames = ["1Bitsy1bitsy"] iters = 30 env = PCBRoutingEnv(resolution=resolution, pcbfolder=pcbfolder, pcbnames=pcbnames) obs, info = env.reset() for in range(iters): act =…

shaun-lloyd/dev-ardupilot-obal
ArduPi is an open hardware Raspberry Pi hat to run Ardupilot.
