2 layers65 × 56.5 mm
Boards in 28 GitHub repositories, designed in KiCad, that use the DWM1000 by DecaWave (SMD RF Modules ROHS). See how each wires it, with its parts, size, README and files; the DWM1000’s symbol, footprint and pinout are on its own page.


jh247247/DW1000-fan-video
Using UWB to make an indoor location system, to get a fan to point at me.


repowered-electronics/UWB_Module_Hardware
Hardware files for our DWM1000 based localization module

JEB12345/DWM100_Breakout
A Breakout board to mount a DWM1000 module onto SUPERball's XBee WiFi slot on the Sensor Board

Kmshanley/MiniRobots
Firmware and PCB desgin for mini robots with UWB localization and lidar mapping

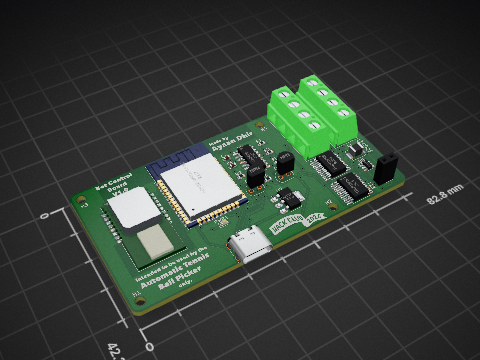
AAPythonCode/TBP
It's summer break, and I want to create something cool! Since I play tennis on a daily basis, I thought of creating something related to it.


Fugate-A/ChairGuru
ChairGuru - A project mainly designed for classroom teachers but has applications in all areas concerning chair management! We have designed a chair system that allows an end-user to create a layout from their computer…


Project-Emerge/rover-circuit
The Rover Circuit is a comprehensive controller board designed for robotics applications, specifically targeted at robot rovers.


Sakhiyuvio/Any-Screen-to-Touch-Screen
Making any screen of any device to become touch-screen. Utilizing UWB transceivers for location distinction with triangulation and TWR algorithms. Our pen enclosure communicates to host device via Bluetooth HID.


weblerson/v2v
Placa de 2 camadas, 70 × 60 mm, FR4 1,6 mm, que carrega os três módulos do protótipo. Todo o mapeamento de pinos vem de firmware/src/config.h — ver docs/PLANDWM1000.md para as decisões de projeto do firmware.


