4 layers25.9 × 62.3 mm
 CIDCO-dev/Poseidon11
Hydrographic surveying platform operating system
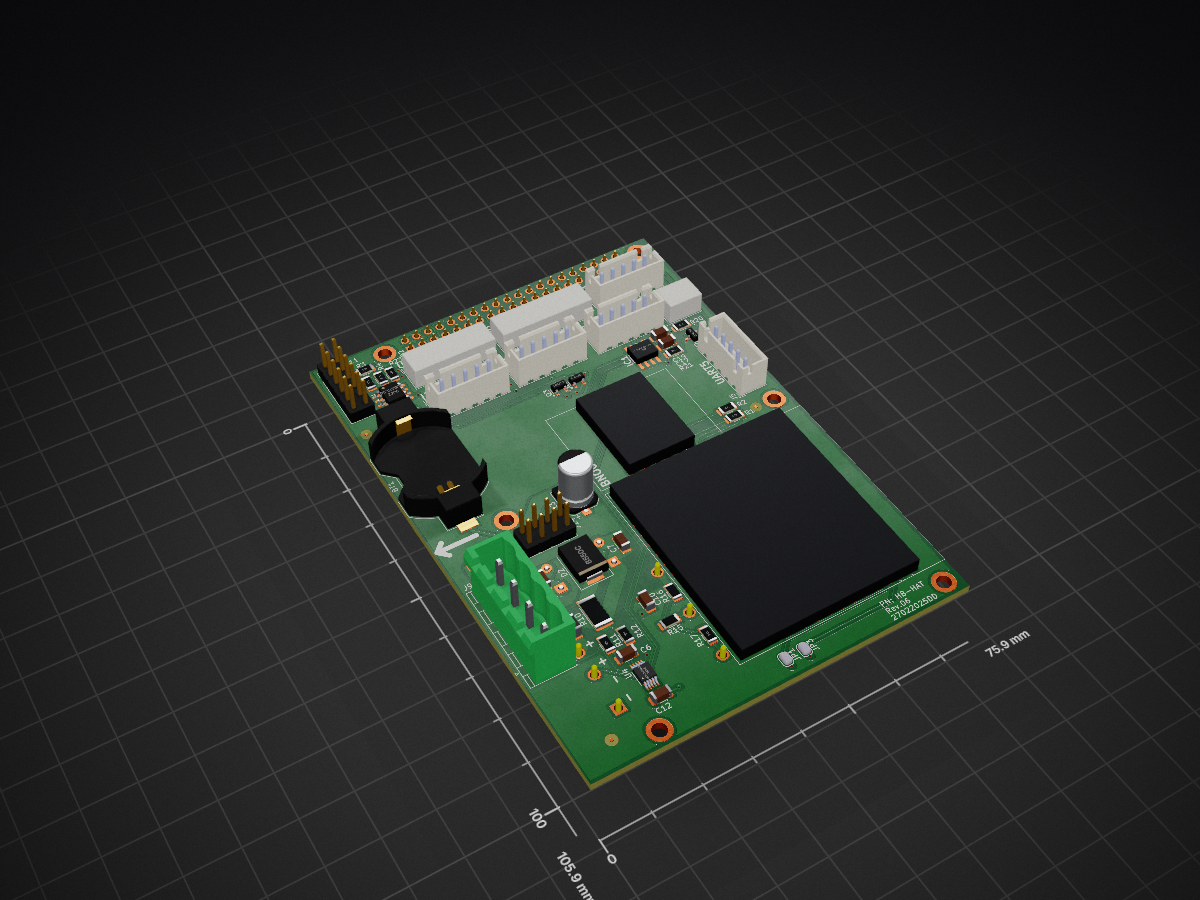
HydroBall is an open-source printed circuit board by CIDCO-dev, from the CIDCO-dev/Poseidon repository on GitHub, published under the MIT licence. It is a 4-layer board of 75.9 × 105.9 mm with 65 parts on 60 nets, routed with 458 tracks and 25 vias.
It is built around the HIH8130-021-001, INA238AIDGSR and DS3231MZ/V+, with the B550C among its other parts. Its parts include 14 resistors, 12 connectors, 10 capacitors, 5 ICs and 3 transistors.


Hydrographic surveying platform operating system (ROS Noetic).
/opt: sudo chown $USER:$USER /opt && cd /opt && git clone --recursive <repo>install/rpi4-noetic.sh (RPi4 target).cd /opt/Poseidon/src/workspace && catkin_make -j1 -DCATKIN_BLACKLIST_PACKAGES="mavros;inertial_sense;velodyne;ins_piksi;velodyne_pointcloud;velodyne_driver;velodyne_laserscan;gnss_mosaic_x5;tf"source /opt/ros/noetic/setup.bash then source /opt/Poseidon/src/workspace/devel/setup.bash.roslaunch launch/Simulator/dummy_simulator_virtual-machine.launch, then open the web UI at http://localhost.Full documentation lives in doc/ (Markdown):
doc/README.md: overview, build, run, testsdoc/install.md: installation with dependencies (RPi4, Ubuntu 20.04, ROS Noetic)doc/nodes.md: list of ROS nodesdoc/web.md: list of web UI pagesdoc/web/*.md: per-page details (index, status, diagnostics, data, map, settings, calibration, goal)doc/nodes/*.md: per-node details with inputs/outputs/paramscatkin_make run_tests -j1 -DCATKIN_BLACKLIST_PACKAGES="ins_piksi;libmavconn;echoboat_odometry;mavros_msgs;mavros;mavros_extras;test_mavros;gnss_mosaic_x5;imu_bno055;sonar_imagenex852;inertial_sense;raspberrypi_vitals;imu_null;sonar_dummy;gnss_dummy;lidar_filtering"cd www/webroot/js && npm test --coverageroslaunch launch/Echoboat/rosbag_replay.launch bag_filename:=rosbag.bag./devel/lib/logger/lidarGeoreferencer -h (supports filtering options)| Qty | Value | Footprint | References |
|---|---|---|---|
| 6 | Fiducial | Fiducial:Fiducial_0.75mm_Mask2.25mm | FID1, FID2, FID3, FID4, FID5, FID6 |
| 6 | MountingHole | MountingHole:MountingHole_2.7mm_M2.5_ISO7380_Pad | H1, H2, H3, H4, H5, H6 |
| 4 | 1k | Resistor_SMD:R_1206_3216Metric | R3, R4, R20, R21 |
| 4 | 4.7k | Resistor_SMD:R_1206_3216Metric | R1, R2, R22, R23 |
| 4 | Conn_01x05 | Connector_JST:JST_XH_B5B-XH-AM_1x05_P2.50mm_Vertical | J3, J4, J6, J7 |
| 3 | 2N7002 | Package_TO_SOT_SMD:SOT-23 | Q1, Q2, Q3 |
| 2 | 100r | Resistor_SMD:R_1206_3216Metric | R11, R12 |
| 2 | LOGO | cidco:logo cidco | logo1, logo1 |
| 2 | SolderJumper_2_Open | Jumper:SolderJumper-2_P1.3mm_Open_RoundedPad1.0x1.5mm | JP1, JP3 |
| 1 | 0.033R/2W | Resistor_SMD:R_2512_6332Metric | R10 |
| 1 | 0.1uf /50v | Capacitor_SMD:C_1206_3216Metric | C6 |
| 1 | 0.22uF | Capacitor_SMD:C_1206_3216Metric | C19 |
| 1 | 0R | Resistor_SMD:R_1206_3216Metric | R15 |
| 1 | 100nF | Capacitor_SMD:C_1206_3216Metric | C17 |
| 1 | 100nf | Capacitor_SMD:C_1206_3216Metric | C12 |
| 1 | 10uf/50v | Capacitor_SMD:C_1206_3216Metric | C8 |
| 1 | 150uf/50v | Capacitor_THT:CP_Radial_D10.0mm_P5.00mm | C5 |
| 1 | 169K | Resistor_SMD:R_1206_3216Metric | R17 |
| 1 | 22uH/4A | Inductor_SMD:L_1210_3225Metric | L1 |
| 1 | 2A | Fuse:Fuse_1206_3216Metric | F1 |
| 1 | 4.7nf/2kv | Capacitor_SMD:C_1206_3216Metric | C10 |
| 1 | 47uf/50v | Capacitor_THT:CP_Radial_D10.0mm_P5.00mm | C9 |
| 1 | B550C | Diode_SMD:D_SMC | D2 |
| 1 | Battery_Cell | Battery:BatteryHolder_Keystone_1058_1x2032 | BT1 |
| 1 | Conn_01x03 | Connector_Phoenix_MSTB:PhoenixContact_MSTBVA_2,5_4-G-5,08_1x04_P5.08mm_Vertical | J9 |
| 1 | Conn_01x05 | Connector_JST:JST_XH_B6B-XH-AM_1x06_P2.50mm_Vertical | J1 |
| 1 | Conn_01x06 | Connector_JST:JST_XH_B2B-XH-AM_1x02_P2.50mm_Vertical | J13 |
| 1 | Conn_01x06 | Connector_JST:JST_XH_B5B-XH-AM_1x05_P2.50mm_Vertical | J5 |
| 1 | Conn_01x07 | Connector_JST:JST_XH_B7B-XH-AM_1x07_P2.50mm_Vertical | J2 |
| 1 | Conn_02x04_Counter_Clockwise | Connector_PinHeader_2.54mm:PinHeader_2x04_P2.54mm_Vertical | J14 |
| 1 | Conn_02x05_Top_Bottom | Connector_PinHeader_2.54mm:PinHeader_2x06_P2.54mm_Vertical | J11 |
| 1 | DNP | Resistor_SMD:R_1206_3216Metric | R16 |
| 1 | DNP | Capacitor_SMD:C_1206_3216Metric | C7 |
| 1 | DNP | Capacitor_SMD:CP_Elec_6.3x9.9 | C13 |
| 1 | DS3231MZ | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U8 |
| 1 | HIH8130-021-001 | KiCad:SOIC127P600X206-8N | IC1 |
| 1 | INA238AIDGSR | Desktop:SOP50P490X110-10N | U4 |
| 1 | REC20K-2405SZ | Desktop:CONV_PDQE20-Q24-S5-D | PS1 |
| 1 | Raspberry_Pi_2_3 | Connector_PinSocket_2.54mm:PinSocket_2x20_P2.54mm_Vertical | J8 |
| 1 | ~ | imu:bno055 | U2 |
| 1 | ~ | gps-rtk:zed-f9p | U1 |
It measures 75.9 × 105.9 mm and has 4 copper layers, 1.6 mm thick.
65 parts, built around the HIH8130-021-001, INA238AIDGSR, DS3231MZ/V+ and B550C. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the CIDCO-dev/Poseidon repository on GitHub, at the commit this page was made from: the board is docs/PCB Design/HB-HAT/HydroBall.kicad_pcb and its schematic docs/PCB Design/HB-BP/PwrBypass.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).


JunKimmmy/USBPowerMeter
A compact USB-C passthrough power meter that displays real-time voltage, current, and power on an integrated 128×64 OLED screen.


nathanfraske/CEC-Platform
ONE board file, kept current by the wave (owner directive 2026-07-25: "the current best should be placed into a candidate folder per board and kept current with only one board ideally so we have a reference").

misko/prompt2device
The separate vNext PCB skill and orchestrator package is available alongside the reference workflow below; existing projects keep their accepted toolchain until an explicit migration.

jayis1/hacker-devices
Full-cycle hardware designs for security research devices — each device is a subfolder with its own README, schematics, PCB layout, and software stack

Tinkerbug-Robotics/TinkerRocket
Model rocket flight computer, ground station, iOS app, and simulation

Michael-Manning/E-Paper-Climate-Logger
Firmware, PCB, and enclosure for the Weathergotchi E-Paper climate logger.