Servomotor3 is an open-source printed circuit board by tomrodinger, from the tomrodinger/servomotor repository on GitHub, published under the MIT licence. It is a 2-layer board of 37.8 × 44.4 mm with 79 parts on 53 nets, routed with 550 tracks and 330 vias.
It is built around the SIT3088ETK, KTH3101-TO3 and ATD5833QNN, with the LM321, ME6211C33M5G-N and TS3735PA 250GF 030 among its other parts. Its parts include 38 capacitors, 21 resistors, 8 ICs, 7 connectors and 2 diodes. It belongs with the robots and motor control and interfaces and adapters boards and the STM32 boards of this library.
Gearotons M17 — an open-source servomotor you can talk to
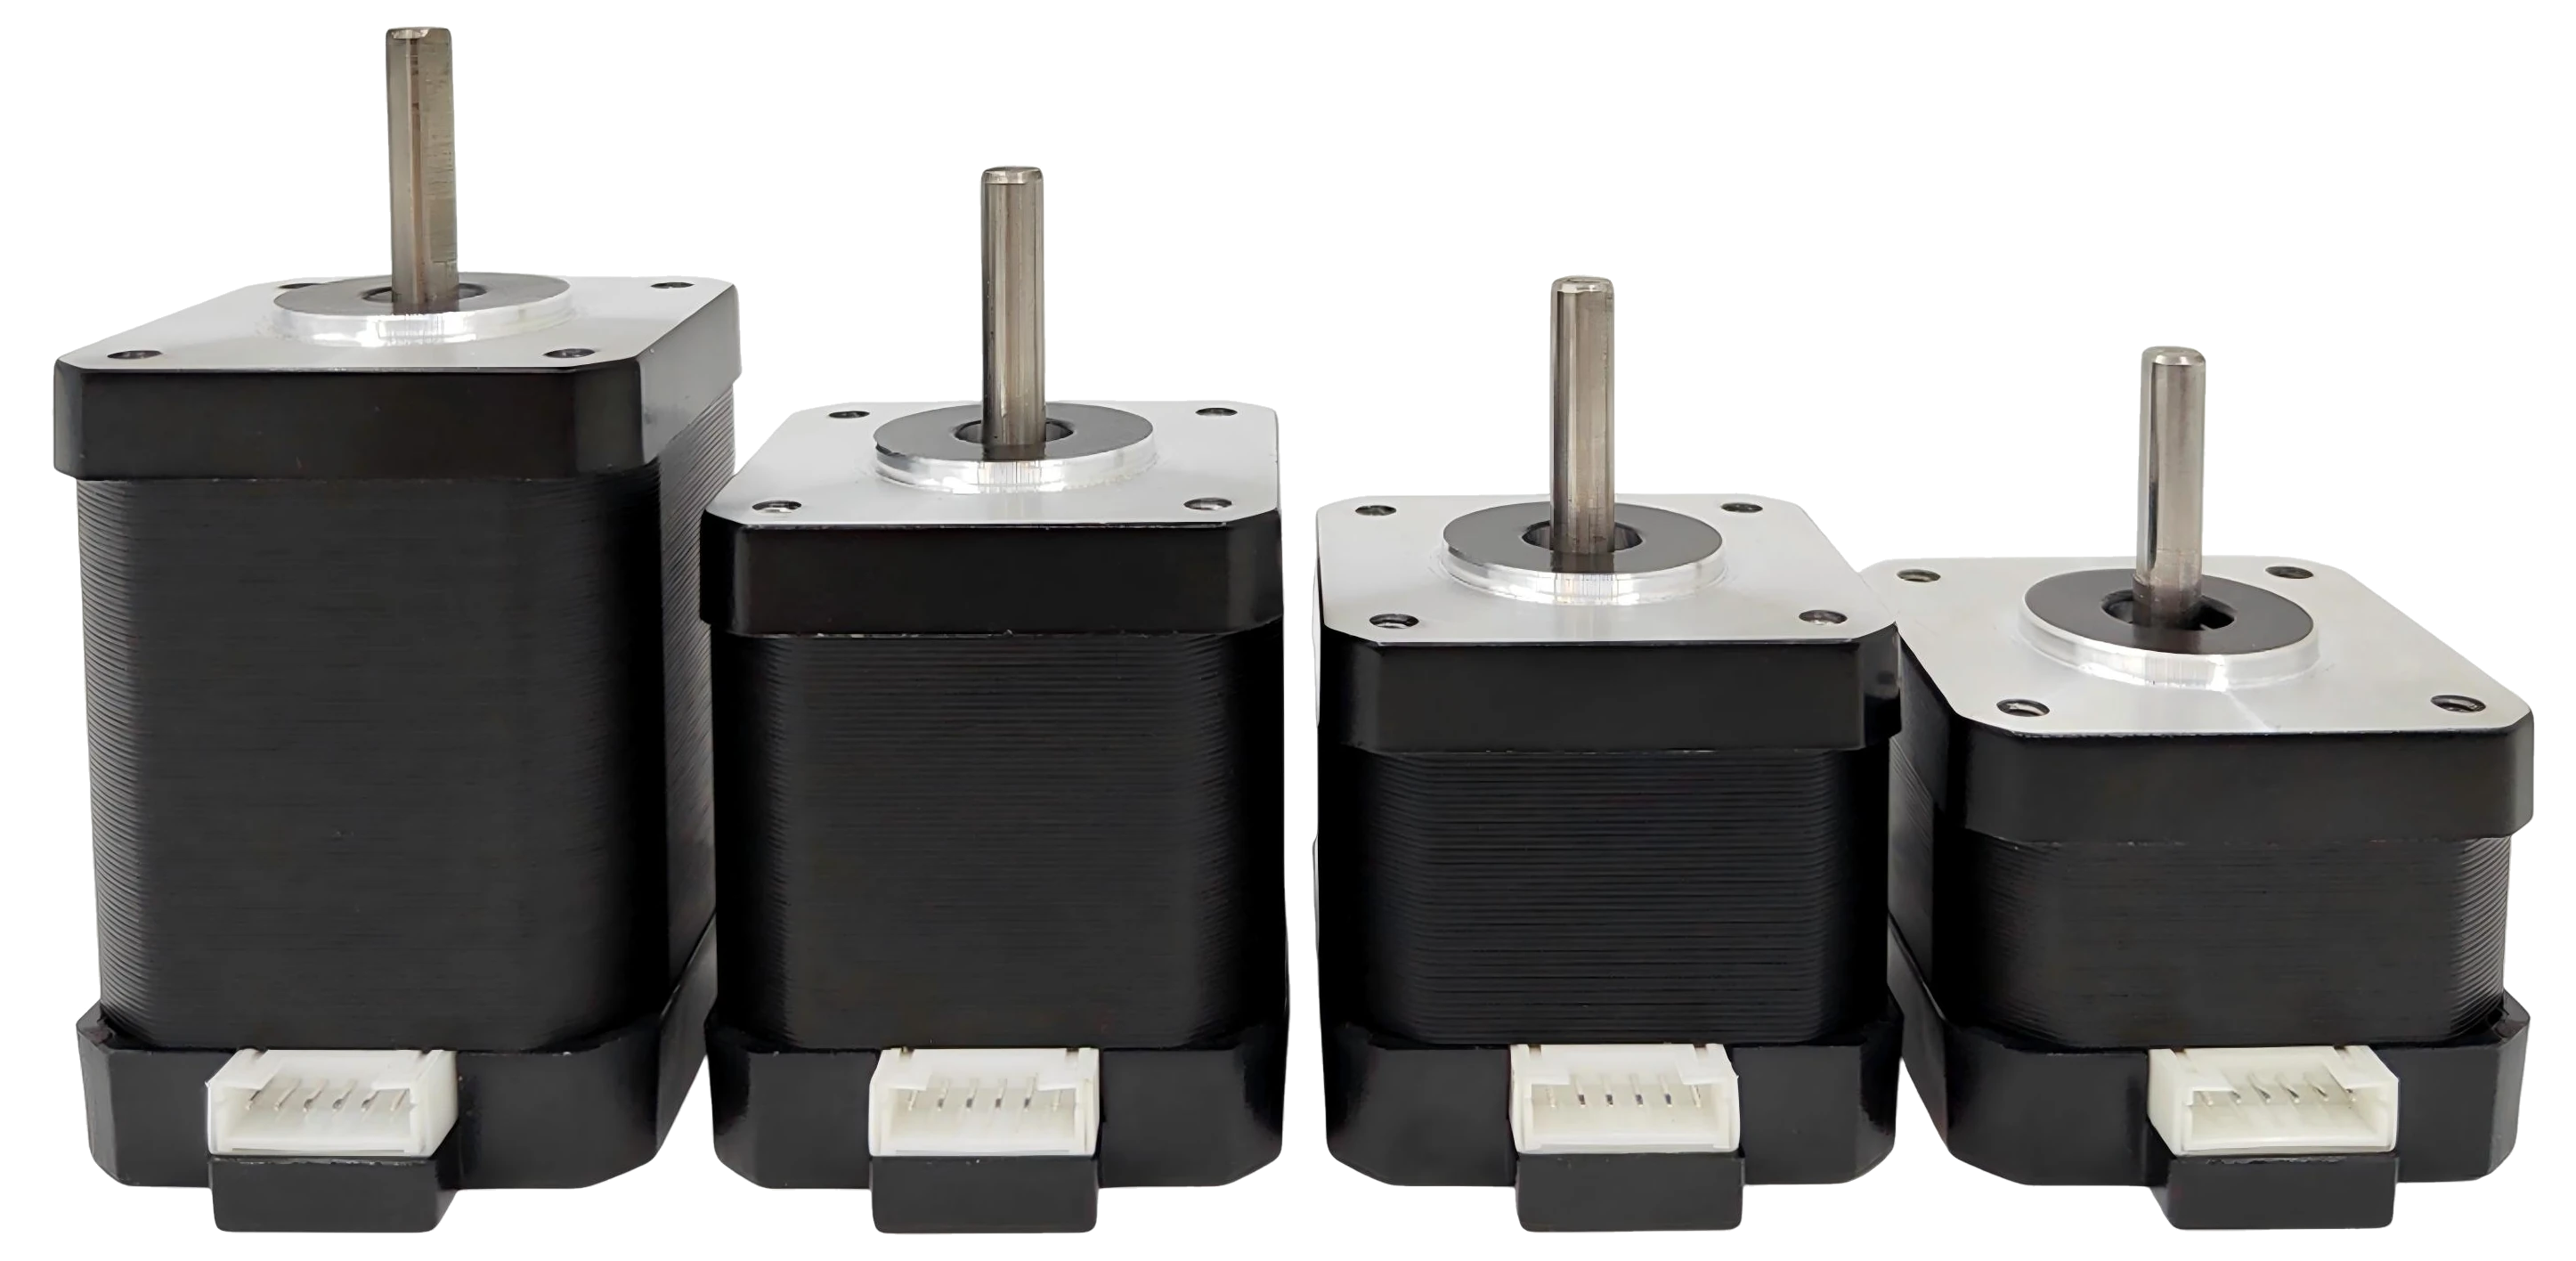
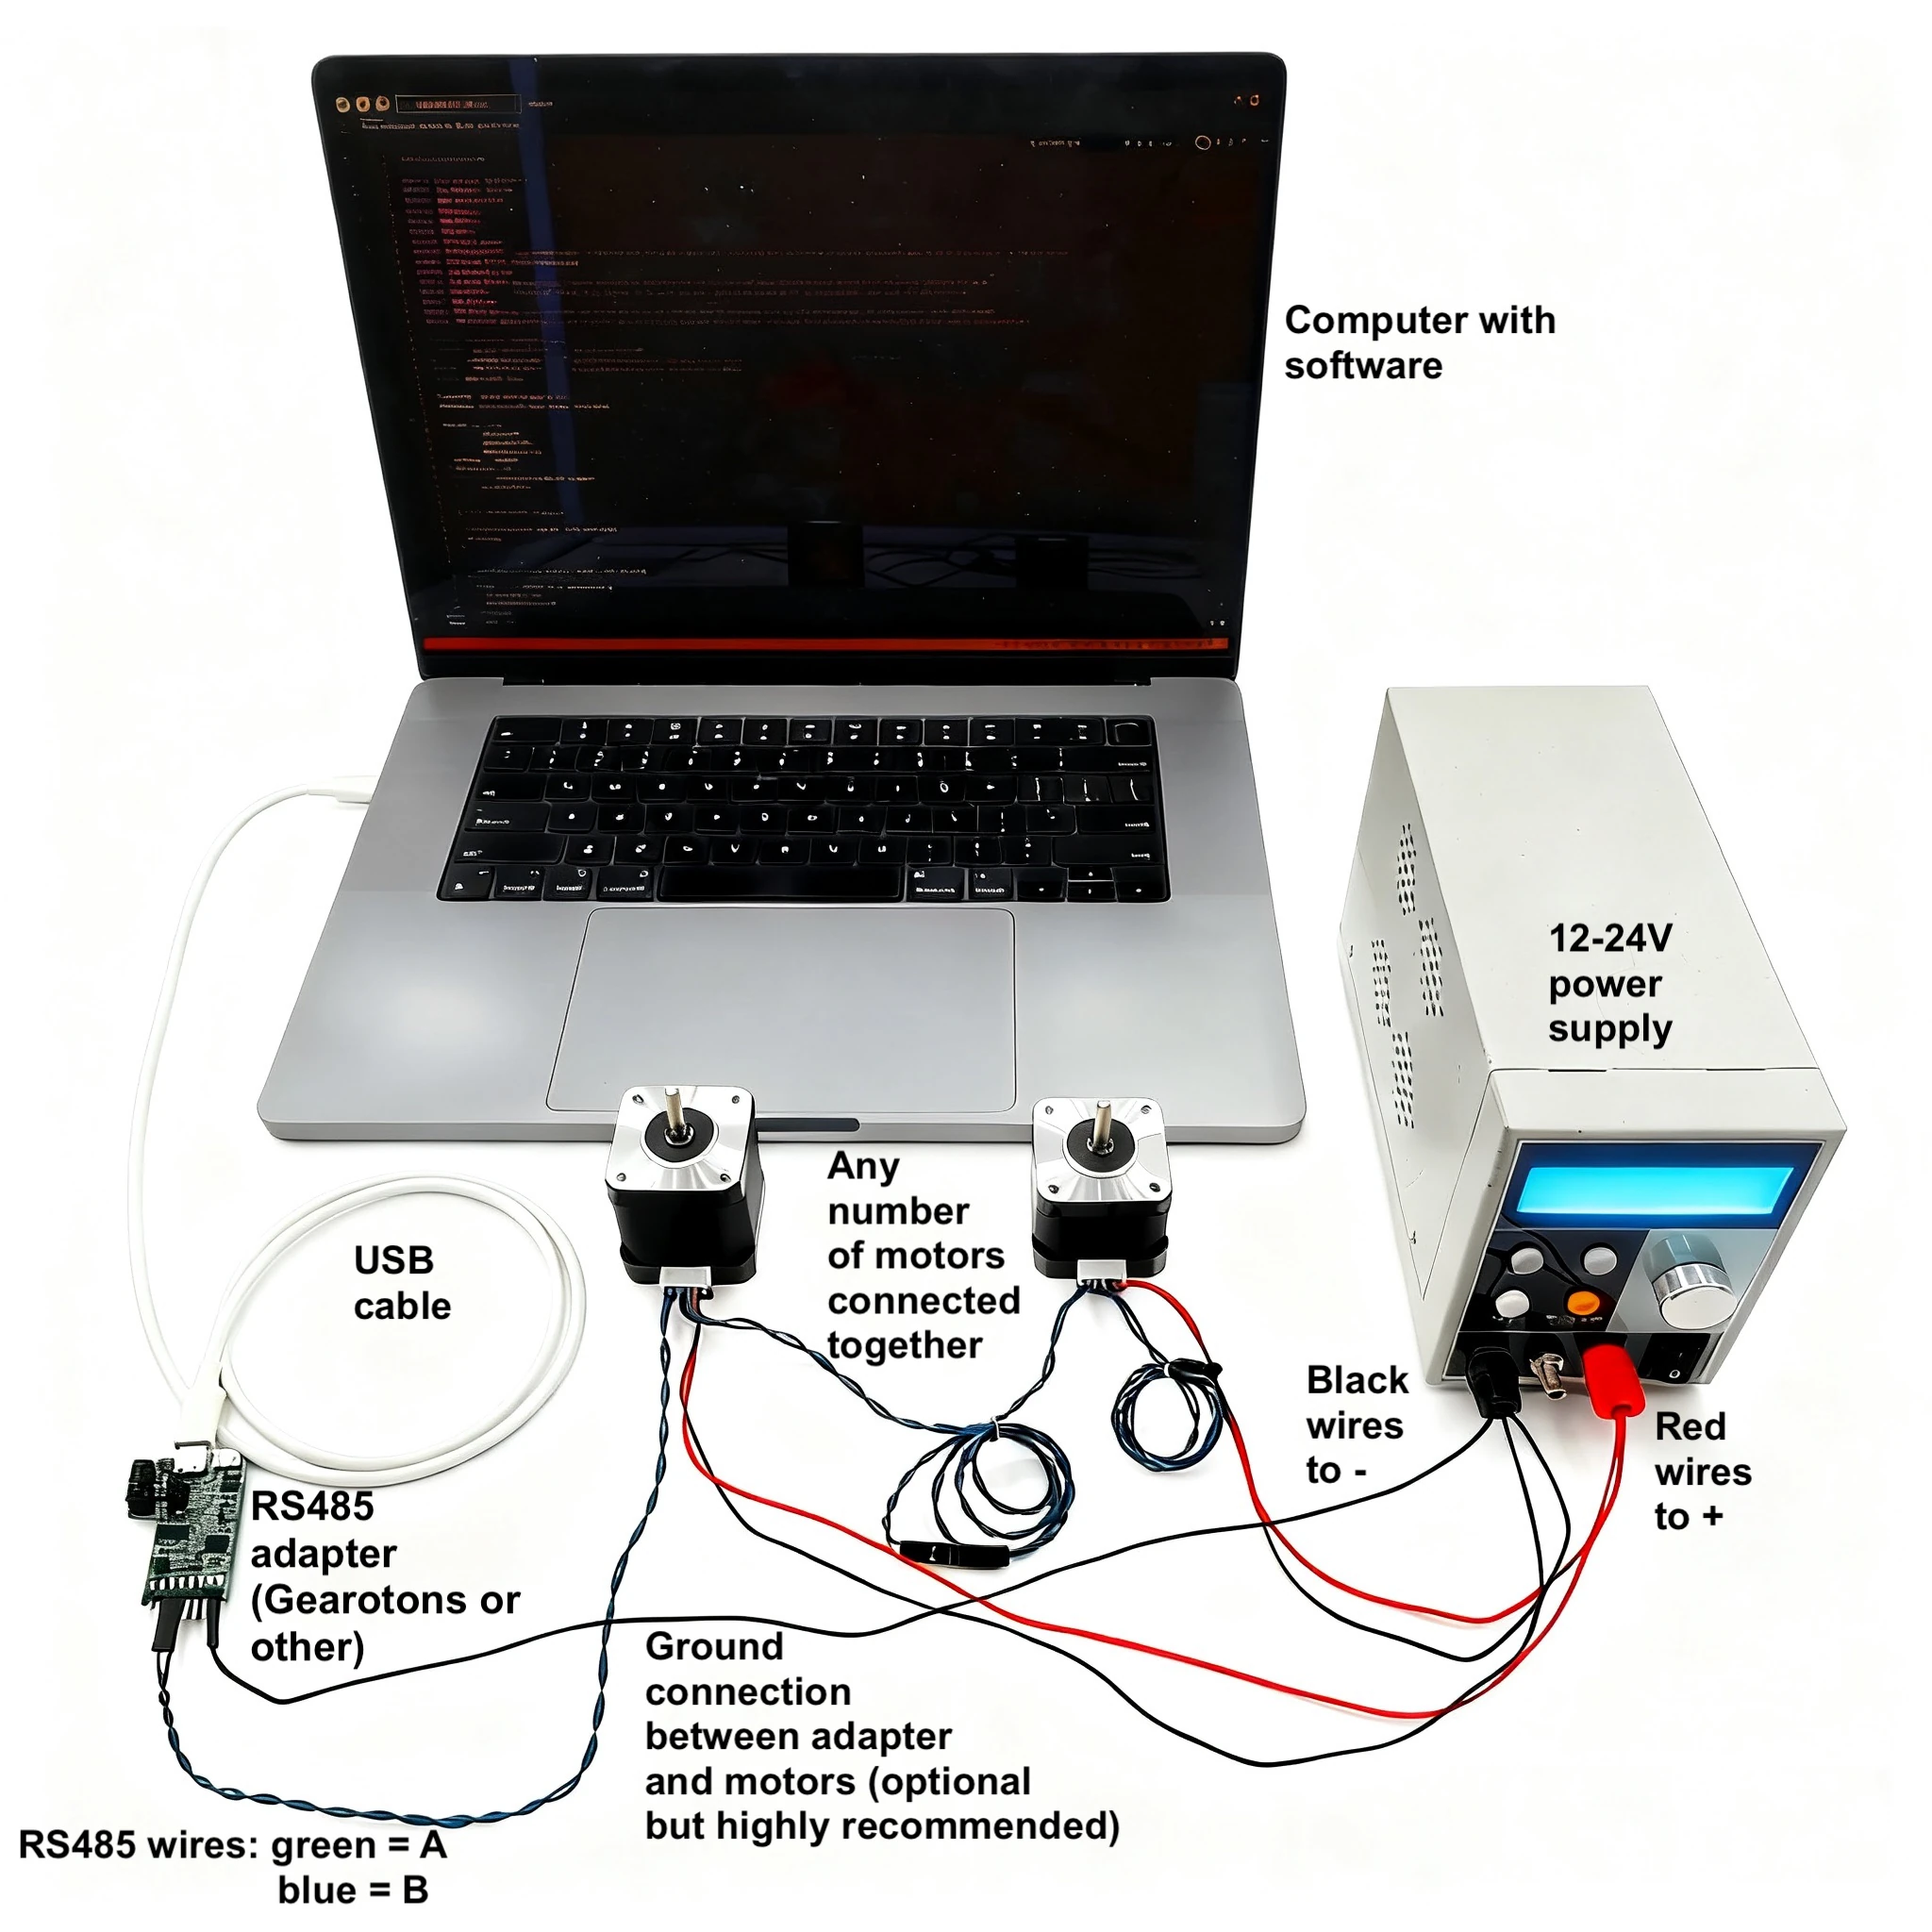
The M17 is a NEMA-17 integrated servomotor: motor, closed-loop driver, motion controller and
magnetic encoder in one unit. It daisy-chains over RS-485, ships with Python and Arduino libraries,
and has a first-party MCP server so an AI assistant
(Claude Desktop, Claude Code, Cursor, …) can drive real motors from plain English.
Hardware, firmware and software are all in this repository under the MIT license.
M17-34
M17-40
M17-48
M17-60
Length
33.5 mm
40.1 mm
48.7 mm
59.7 mm
Holding torque
0.28 N·m
0.42 N·m
0.55 N·m
0.65 N·m
Weight
210 g
285 g
360 g
470 g
All sizes: 12–24 V, up to ~1.1 A, up to 560 RPM, closed-loop 32 kHz control, RS-485 at 230400 baud,
64-bit unique ID + one-byte alias per motor, standard NEMA-17 mount. Indoor use (IP20).
import time, servomotor
servomotor.open_serial_port()# prompts for the USB–RS-485 adapter the first time
m = servomotor.M3("X", time_unit="seconds", position_unit="shaft_rotations")
m.enable_mosfets()
m.trapezoid_move(1.0, 1.0)# one full turn, in one second
time.sleep(1.1)
m.disable_mosfets()
servomotor.close_serial_port()
That is python_programs/example_trapezoid_move.py.
Units are yours to choose (degrees, rotations, radians, encoder counts; seconds or milliseconds) —
the library converts. No STEP/DIR timing, no microstep configuration.
Quick start (Arduino / ESP32)
Install the Servomotor library by Gearotons from the Arduino Library Manager, or from
Arduino_library/. Wire the board's UART to an RS-485 transceiver, then:
cpp
#include <Servomotor.h>
void setup(){
Servomotor motor('X', Serial1); // alias 'X'; the port opens on first use
motor.setPositionUnit(PositionUnit::SHAFT_ROTATIONS);
motor.setTimeUnit(TimeUnit::SECONDS);
motor.enableMosfets();
motor.trapezoidMove(2.0f, 3.0f); // two rotations over three seconds
delay(4000);
Serial.println(motor.getPosition()); // where it actually is, from the encoder}void loop(){}
uvx --from servomotor-mcp servomotor-mcp # runs with a simulated motor if no hardware is attached
Add it to Claude Desktop or run claude mcp add gearotons-motor -- uvx --from servomotor-mcp servomotor-mcp,
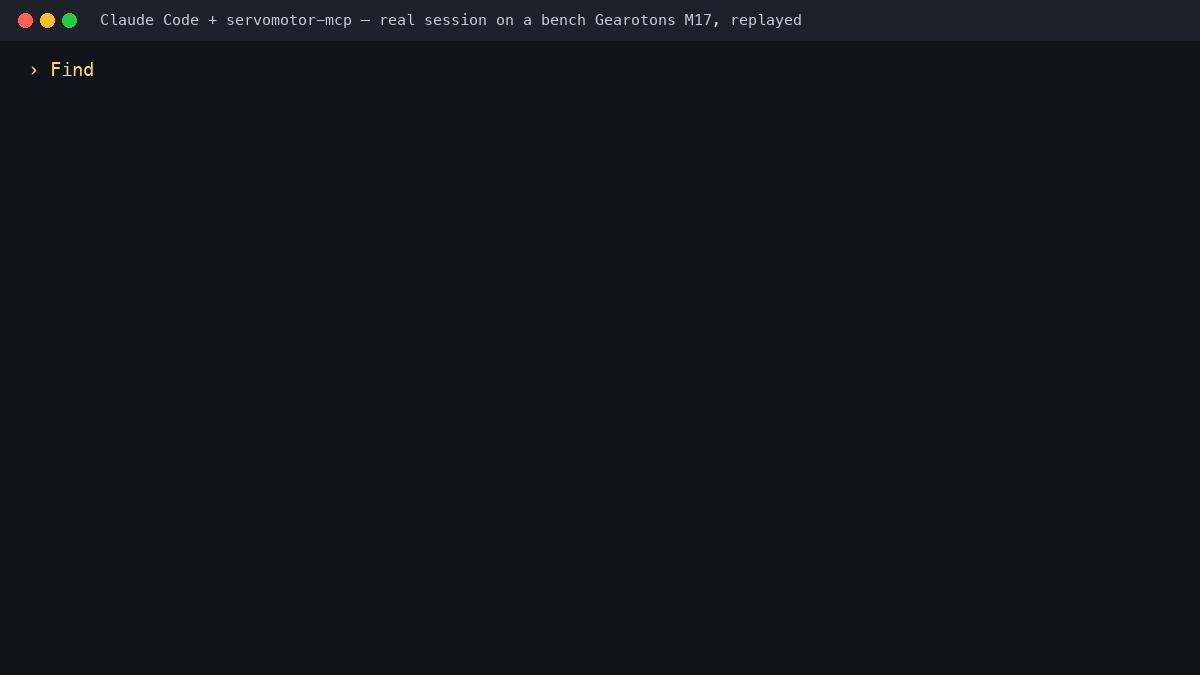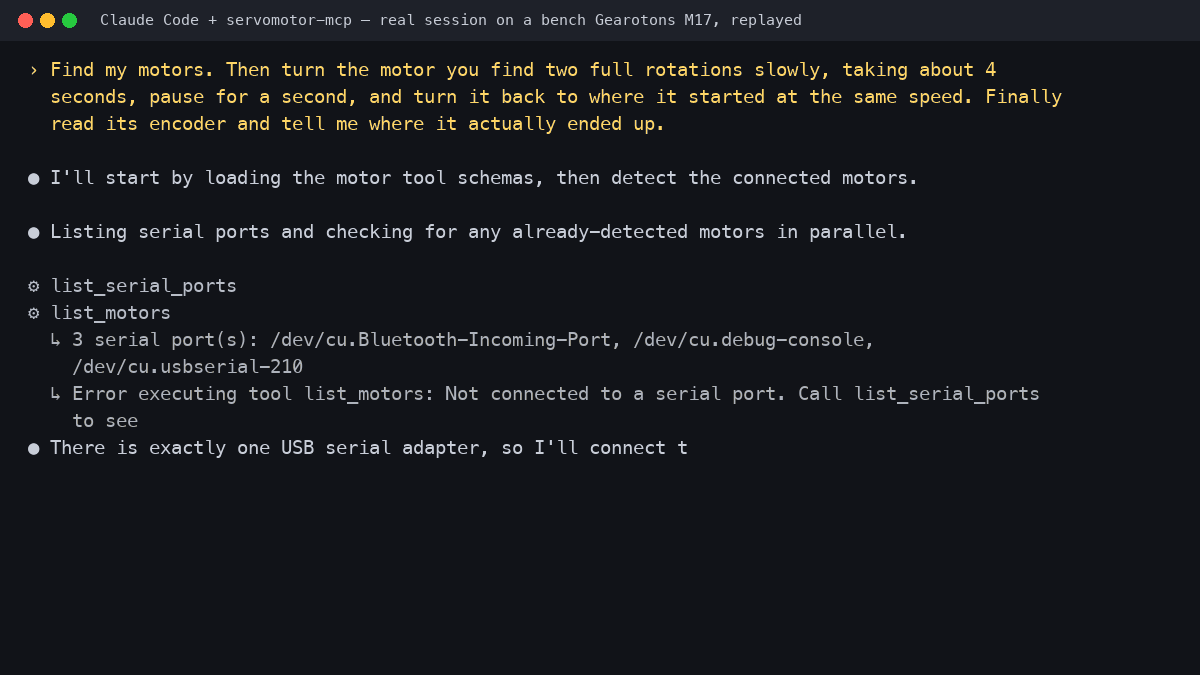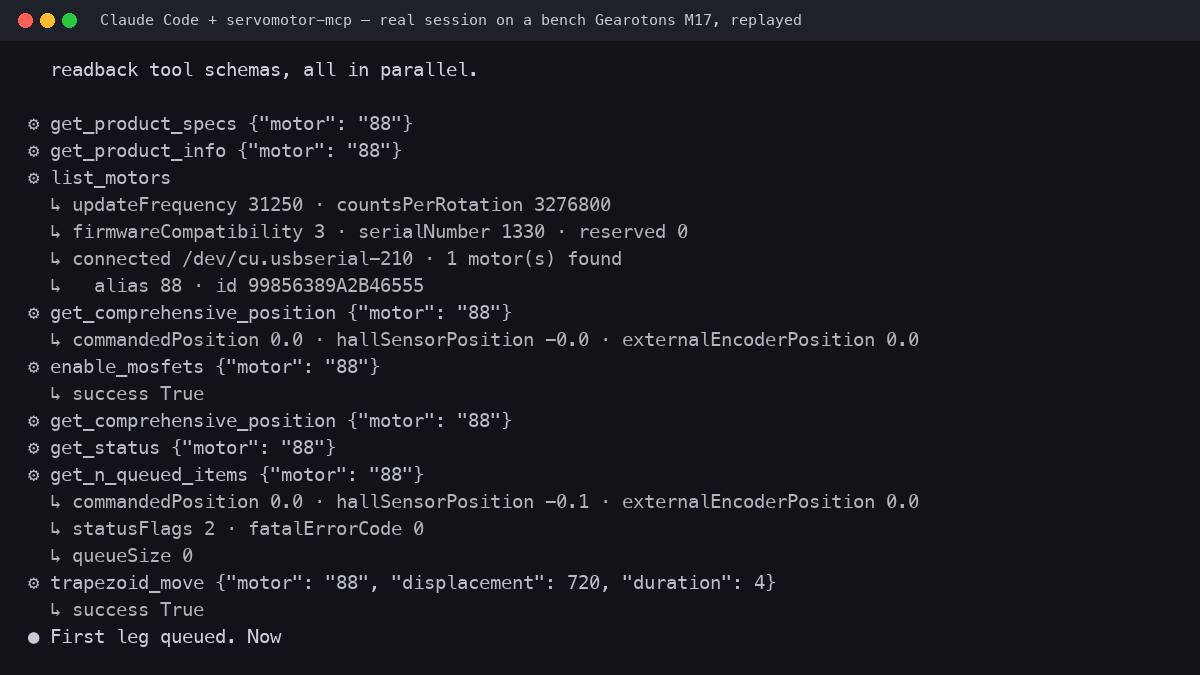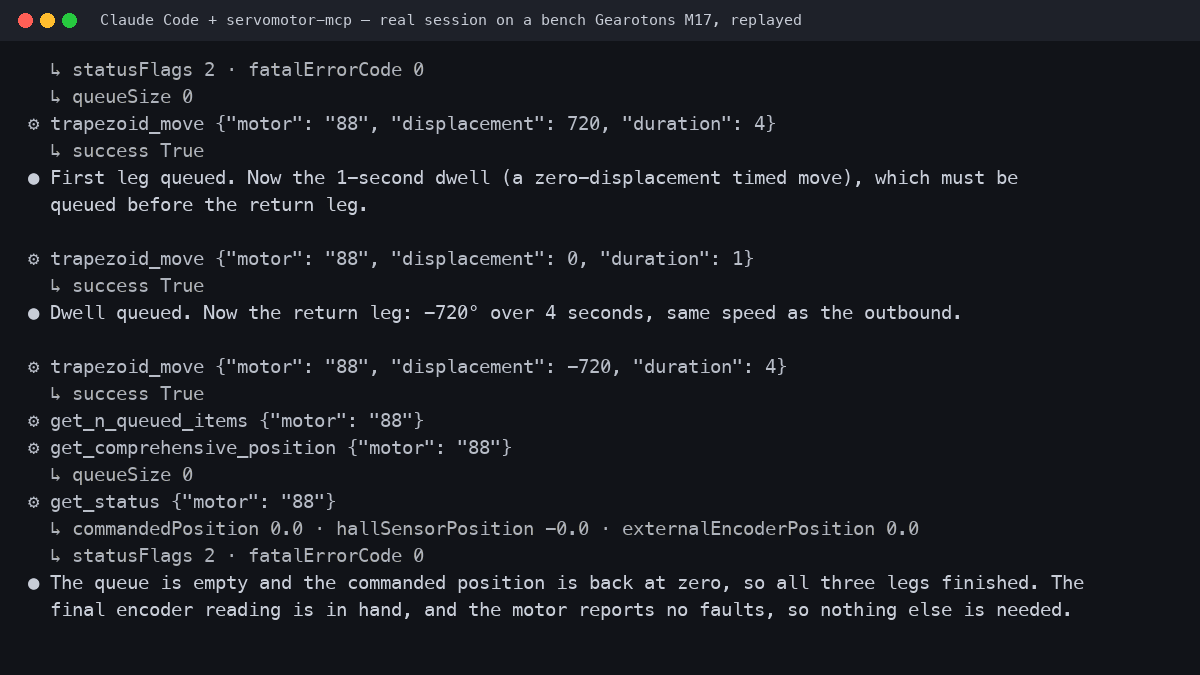
then ask: "Find my motors, then move the one on the bench to 90 degrees and tell me where it ended up."
Details and the full tool list: Gearotons/servomotor-mcp.
The command set is data-driven: every firmware command is defined once in
motor_commands.json and the Python library, the Arduino library and the MCP server are generated
from it, so they always agree.
Firmware 0.16.0.0
This backward-compatible M17 release adds Get PID constants (command 48).
It returns the configured raw P, I and D values without changing controller or
motion state. With the updated Python bindings in this repository:
python
p, i, d = m.get_pid_constants()
The release image targets M17 hardware 1.5, software compatibility code 3.
See the release notes
for the wire contract, upgrade/rollback commands, client requirements and test evidence.
Where the M17 is not the right tool
Direct-drive torque tops out at 0.65 N·m (gear it or go up a frame size for more), it is IP20 and
indoor-only, and it is not a STEP/DIR drop-in for an existing 3D-printer board — it wants a serial
bus and a host that sends it moves. We would rather you know that before you buy.
Community and support
Questions and builds: GitHub Discussions ·
email info@gearotons.com. Issues and pull requests welcome — the whole
stack is here to be read, modified and improved.
Built and assembled by Gearotons in Shenzhen. MIT license — see LICENSE.
Open-source controller for 150 g antweight combat robots: RP2354A, 2x DRV8231A, 2-4S, ELRS/CRSF/SBUS/iBUS/PPM input, IMU. KiCad 10, CERN-OHL-S-2.0.
90 partsCERN-OHL-S-2.0
Questions
How big is the Servomotor3 PCB?
It measures 37.8 × 44.4 mm and has 2 copper layers, 0.8 mm thick.
What parts does the Servomotor3 use?
79 parts, built around the SIT3088ETK, KTH3101-TO3, ATD5833QNN and LM321. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
Where can I download the Servomotor3 KiCad files?
From the tomrodinger/servomotor repository on GitHub, at the commit this page was made from: the board is PCB/Servomotor3/1.5/1.5.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Can I use the Servomotor3 design in my own project?
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).