4 layers65 × 30.9 mm
Elec RPI Robot HAT
armature-ai-labs/indieduck
Open robot prototype: editable FreeCAD CAD, printable parts and fit-test documentation. Adapted from Open Duck Mini.
132 partsApache-2.0

 modewang/elec_RPI_Robot_HAT
The RPIRobotHAT can be power from 5 to 28V. It is designed to use of the motor connector as an power input.
Elec RPI Robot HAT is an open-source printed circuit board by modewang, from the modewang/elec_RPI_Robot_HAT repository on GitHub, published under the Apache-2.0 licence. It is a 4-layer board of 65 × 30.9 mm with 127 parts on 95 nets, routed with 914 tracks and 107 vias.
It is built around the SIT3088ETK, SN74LVC1G125DBV and SN74LVC1G126DBVR-TP, with the AP63205WU, PAM8406DR and TLV320AIC3104IRHBR among its other parts. Its parts include 44 capacitors, 40 resistors, 12 connectors, 11 ICs and 3 diodes. It belongs with the robots and motor control boards of this library.


"RPI_Robot_HAT" is a raspberry pi HAT designed for small/medium size robots. It has an IMU, Dynamixel connectors and audio. Its size fits a Raspberry PI zero.
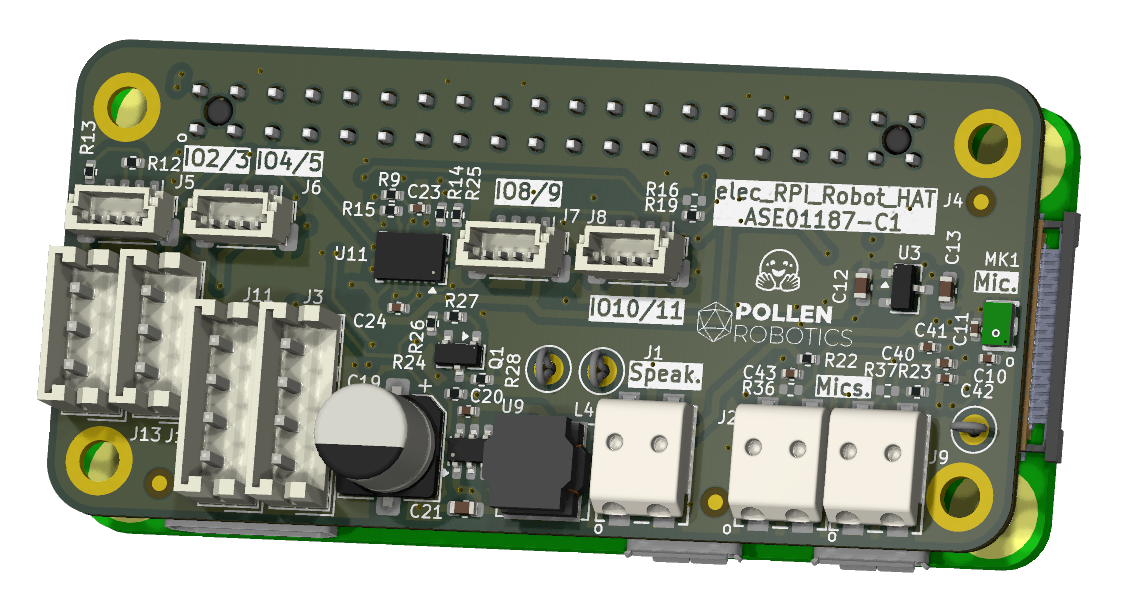
The RPI_Robot_HAT gathers:
The RPI_Robot_HAT can be power from 5 to 28V. It is designed to use of the motor connector as an power input.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 19 | 10k | Resistor_SMD:R_0402_1005Metric | R1, R2, R12, R13, R20, R21, R22, R23, R24, R26, R27, R29, R31, R32, R34, R35 +3 |
| 15 | 1u | Capacitor_SMD:C_0402_1005Metric | C1, C2, C3, C4, C6, C10, C27, C29, C31, C33, C35, C40, C41, C42, C43 |
| 12 | 100n | Capacitor_SMD:C_0402_1005Metric | C11, C14, C15, C16, C17, C18, C26, C28, C30, C32, C36, C38 |
| 11 | 0R | Resistor_SMD:R_0402_1005Metric | R3, R4, R5, R7, R9, R14, R15, R18, R19, R25, R40 |
| 5 | 10u | Capacitor_SMD:C_0603_1608Metric | C5, C7, C12, C13, C37 |
| 4 | JST SH | Connector_JST:JST_SH_BM04B-SRSS-TB_1x04-1MP_P1.00mm_Vertical | J5, J6, J7, J8 |
| 3 | 100n 6V3 | Capacitor_SMD:C_0402_1005Metric | C23, C24, C39 |
| 3 | DNP Fiducial | Fiducial:Fiducial_1mm_Mask2mm | FID1, FID2, FID3 |
| 3 | DNP-0R | Resistor_SMD:R_0402_1005Metric | R16, R17, R41 |
| 3 | TestPoint | TestPoint:TestPoint_Loop_D2.50mm_Drill1.0mm_LowProfile | TP2, TP3, TP4 |
| 3 | Wago-2 | LCSC_parts_lib:Wago_2059-302_998-403 | J1, J2, J9 |
| 2 | 10n | Capacitor_SMD:C_0402_1005Metric | C34, C44 |
| 2 | 220n | Capacitor_SMD:C_0402_1005Metric | C8, C9 |
| 2 | 22u 6V3 | Capacitor_SMD:C_0603_1608Metric | C21, C22 |
| 2 | 2A - 120R@100MHz | Inductor_SMD:L_0402_1005Metric | FB2, FB3 |
| 2 | DNP-10k | Resistor_SMD:R_0402_1005Metric | R10, R11 |
| 2 | DNP-1M | Resistor_SMD:R_0402_1005Metric | R36, R37 |
| 2 | Dynamixel-3 | Connector_JST:JST_EH_B3B-EH-A_1x03_P2.50mm_Vertical | J13, J14 |
| 2 | Dynamixel-4 | Connector_JST:JST_EH_B4B-EH-A_1x04_P2.50mm_Vertical | J3, J11 |
| 1 | 1.3A 600R@100MHz | Inductor_SMD:L_0402_1005Metric | FB1 |
| 1 | 100R | Resistor_SMD:R_0402_1005Metric | R8 |
| 1 | 100R thermistor | Resistor_SMD:R_0603_1608Metric | TH1 |
| 1 | 100n 50V | Capacitor_SMD:C_0402_1005Metric | C20 |
| 1 | 10u 63V | Capacitor_SMD:CP_Elec_6.3x7.7 | C19 |
| 1 | 12 MHz | Oscillator:Oscillator_SMD_Abracon_ASDMB-4Pin_2.5x2.0mm | Y1 |
| 1 | 150R | Resistor_SMD:R_0402_1005Metric | R33 |
| 1 | 20k | Resistor_SMD:R_0402_1005Metric | R28 |
| 1 | 3V3 Zener Diode | Diode_SMD:D_SOD-123 | D2 |
| 1 | 5V1 | Diode_SMD:D_SOD-323 | D4 |
| 1 | 6,8u 2A | Inductor_SMD:L_Bourns_SRN6045TA | L4 |
| 1 | 74LVC1G08 | Package_TO_SOT_SMD:SOT-23-5 | U5 |
| 1 | AP63205 | Package_TO_SOT_SMD:TSOT-23-6 | U9 |
| 1 | BAT54W | Package_TO_SOT_SMD:SOT-323_SC-70 | D1 |
| 1 | BMI088 | Package_LGA:Bosch_LGA-16_4.5x3mm_P0.5mm_LayoutBorder7x1y_ClockwisePinNumbering | U11 |
| 1 | DNP Logo Pollen 2021 | Library_Pollen:Logo_Pollen_2021_sq | H3 |
| 1 | DNP-100n | Capacitor_SMD:C_0402_1005Metric | C25 |
| 1 | DNP-CAT24C32HU4 | LCSC_parts_lib:TDFN-8_L3.0-W2.0-P0.50-BL-EP | U4 |
| 1 | Female Header 2x20 SMD | Library_Pollen:PinHeader_2x20_P2.54mm_Vertical_with_rasp_HAT_zero_SMD_connector | J4 |
| 1 | LM5050-1 | Package_TO_SOT_SMD:TSOT-23-6 | U10 |
| 1 | Logo HF 2025 | Library_Pollen:Logo_HF_2025 | H2 |
| 1 | MMBT3906 | Package_TO_SOT_SMD:SOT-23 | Q1 |
| 1 | Microphone_MEMS | LCSC_parts_lib:MIC-SMD_4P-L2.8-W1.9-P1.84-TL | MK1 |
| 1 | PAM8406D | Package_SO:SOIC-16_3.9x9.9mm_P1.27mm | U1 |
| 1 | SI2312CDS-T1-GE3 | Package_TO_SOT_SMD:TSOT-23 | Q2 |
| 1 | SIT3088E | Package_SO:MSOP-8-1EP_3x3mm_P0.65mm_EP1.5x1.8mm | U8 |
| 1 | SN74LVC1G125DBV | Package_TO_SOT_SMD:SOT-23-5 | U6 |
| 1 | SN74LVC1G126DBVR | Package_TO_SOT_SMD:SOT-23-5 | U7 |
| 1 | TLV320AIC3104IRHBR | Package_DFN_QFN:VQFN-32-1EP_5x5mm_P0.5mm_EP3.5x3.5mm | U2 |
| 1 | XC6206P182MR | Package_TO_SOT_SMD:SOT-23-3 | U3 |
armature-ai-labs/indieduck
Open robot prototype: editable FreeCAD CAD, printable parts and fit-test documentation. Adapted from Open Duck Mini.

pollen-robotics/elec_grabette
Set of electronic boards for Grabette/Gripette

justinlindh/digits
Encrypted retro phone network — private VoIP over vintage desk phones

jyg9/microduck-community-kit
补充microduck缺少的硬件电路和固件,另外配套一些测试工具。imu_to_dxl;banana_pcb;microduck复刻


Kaiser041224/HPM5361-RMCS_Slave-Pro
HPM5361-RMCSSlave-V1.0 是一个基于 KiCad 9 的硬件工程,核心主控为 HPM5361ICB1。从顶层框图、层级原理图和关键器件选型来看,这块板更像一块面向机器人/运动控制场景的从控板,用于通信汇聚、PWM 外设输出、姿态感知、板载存储和基础人机交互。


dataehora/beatconfused
A small web studio of fast, elegant, install-free music tools. Every tool is plain HTML, CSS and vanilla JavaScript with the Web Audio API — no build step, no dependencies, no accounts, works offline after first load.
It measures 65 × 30.9 mm and has 4 copper layers, 1 mm thick.
127 parts, built around the SIT3088ETK, SN74LVC1G125DBV, SN74LVC1G126DBVR-TP and AP63205WU. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the modewang/elec_RPI_Robot_HAT repository on GitHub, at the commit this page was made from: the board is elec_RPI_Robot_HAT.kicad_pcb and its schematic audio.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the Apache-2.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).