2 layers27.1 × 30.2 mm

 yilv1982/duck-robot
Imu to dxl 10p is an open-source printed circuit board by yilv1982, from the yilv1982/duck-robot repository on GitHub. It is a 2-layer board of 141.9 × 72.9 mm with 897 parts on 71 nets, routed with 5,920 tracks and 1,220 vias.
It is built around the GD32F303CCT6, SN74LVC1G125DBV and SN74LVC1G126DBVR-TP, with the LSM6DSV16XTR, ME6211C18M5G-N and LAIL-PZ2.54-4P-L among its other parts. Its parts include 330 resistors, 200 capacitors, 60 ICs, 60 connectors and 20 diodes. It belongs with the sensors and measurement boards of this library.


"dxl_hub" 固定在机器鸭身体中舵机上方的板子。用于把电池电力分配到左右腿、头部和IMU。对单总线串口数据信号进行合并。
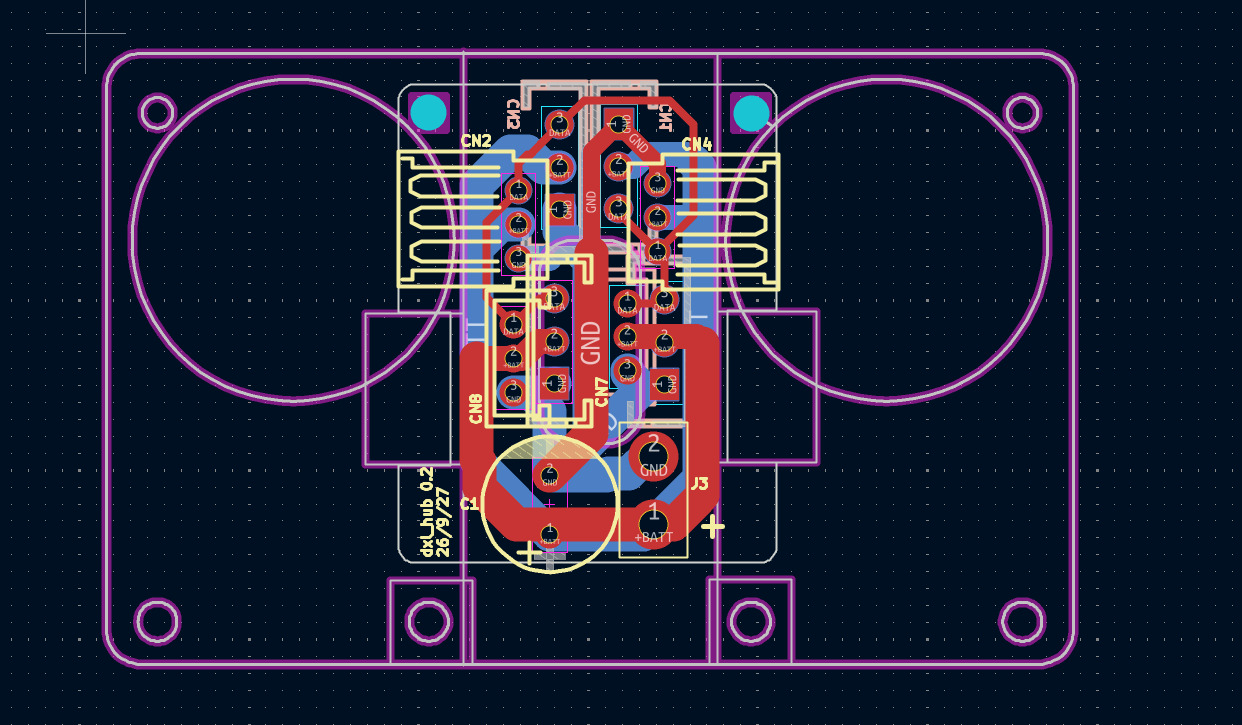
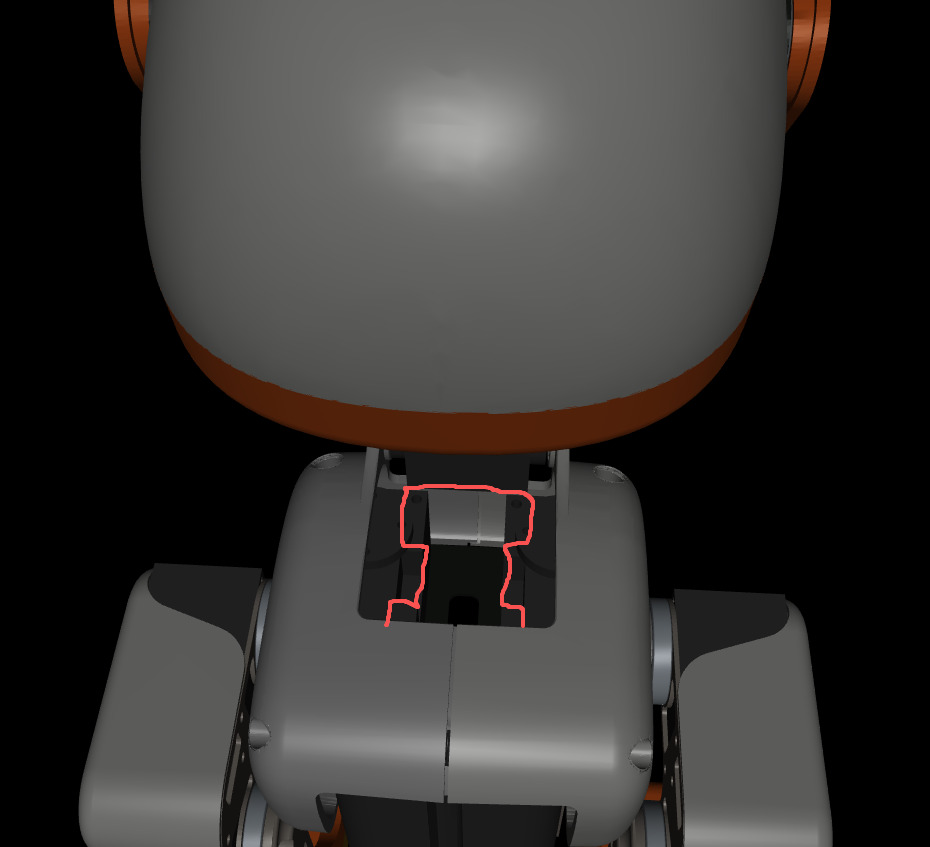
| Qty | Value | Footprint | References |
|---|---|---|---|
| 140 | 51R | microduck:R0402 | R10, R10, R10, R10, R10, R10, R10, R10, R10, R10, R11, R11, R11, R11, R11, R11 +124 |
| 110 | 100nF/16V | microduck:C0402 | C12, C12, C12, C12, C12, C12, C12, C12, C12, C12, C13, C13, C13, C13, C13, C13 +94 |
| 50 | 10K | microduck:R0402 | R15, R15, R15, R15, R15, R15, R15, R15, R15, R15, R16, R16, R16, R16, R16, R16 +34 |
| 40 | 1.8mm螺丝孔 | microduck:pad | J1, J1, J1, J1, J1, J1, J1, J1, J1, J1, J2, J2, J2, J2, J2, J2 +24 |
| 40 | 10k | microduck:R0402 | R27, R27, R27, R27, R27, R27, R27, R27, R27, R27, R28, R28, R28, R28, R28, R28 +24 |
| 30 | 27pF/50V | microduck:C0402 | C10, C10, C10, C10, C10, C10, C10, C10, C10, C10, C11, C11, C11, C11, C11, C11 +14 |
| 20 | 0R | microduck:R0402 | R9, R9, R9, R9, R9, R9, R32, R32, R32, R32, R32, R32, R32, R32, R32, R32 +4 |
| 20 | 1uF/10V | microduck:C0402 | C20, C20, C20, C20, C20, C20, C20, C20, C20, C20, C21, C21, C21, C21, C21, C21 +4 |
| 20 | LAIL-PZ2.54-4P-L | microduck:pad-4 | H1, H1, H1, H1, H1, H1, H1, H1, H1, H1, H3, H3, H3, H3, H3, H3 +4 |
| 10 | 0R | microduck:R0402_Jumper | R33, R33, R33, R33, R33, R33, R33, R33, R33, R33 |
| 10 | 100K | microduck:R0402 | R3, R3, R3, R3, R3, R3, R3, R3, R3, R3 |
| 10 | 100R | microduck:R0603 | R5, R5, R5, R5, R5, R5, R5, R5, R5, R5 |
| 10 | 100p | microduck:C0402 | C1, C1, C1, C1, C1, C1, C1, C1, C1, C1 |
| 10 | 10uF/50V | microduck:C0805 | C6, C6, C6, C6, C6, C6, C6, C6, C6, C6 |
| 10 | 10uH/920mA | microduck:IND-SMD_L3.0-W3.0_SWPA3010S | L1, L1, L1, L1, L1, L1, L1, L1, L1, L1 |
| 10 | 1K | microduck:R0402 | R14, R14, R14, R14, R14, R14, R14, R14, R14, R14 |
| 10 | 1nF/50V | microduck:C0402 | C22, C22, C22, C22, C22, C22, C22, C22, C22, C22 |
| 10 | 20k | microduck:R0402 | R29, R29, R29, R29, R29, R29, R29, R29, R29, R29 |
| 10 | 22uF/6.3V | microduck:C0603 | C5, C5, C5, C5, C5, C5, C5, C5, C5, C5 |
| 10 | 24K | microduck:R0402 | R6, R6, R6, R6, R6, R6, R6, R6, R6, R6 |
| 10 | 3.3V ESD | microduck:SOD-323_L1.7-W1.3-LS2.5-BI | D2, D2, D2, D2, D2, D2, D2, D2, D2, D2 |
| 10 | 30K | microduck:R0402 | R4, R4, R4, R4, R4, R4, R4, R4, R4, R4 |
| 10 | 75K | microduck:R0402 | R1, R1, R1, R1, R1, R1, R1, R1, R1, R1 |
| 10 | B3B-EH-A (LF)(SN) | microduck:CONN-TH_B3B-EH-A-LF-SN | CN1, CN1, CN1, CN1, CN1, CN1, CN1, CN1, CN1, CN1 |
| 10 | B3B-PH-K-S(LF)(SN) | microduck:CONN-TH_B3B-PH-K-S | CN2, CN2, CN2, CN2, CN2, CN2, CN2, CN2, CN2, CN2 |
| 10 | ETA2845S2G_C22362741 | microduck:SOT-23-6_L2.9-W1.6-P0.95-LS2.8-BR | U1, U1, U1, U1, U1, U1, U1, U1, U1, U1 |
| 10 | GD32F303CCT6 | microduck:LQFP-48_L7.0-W7.0-P0.50-LS9.0-BL | U2, U2, U2, U2, U2, U2, U2, U2, U2, U2 |
| 10 | LSM6DSV16XTR | microduck:LGA-14_L3.0-W2.5-P0.50-BR | U3, U3, U3, U3, U3, U3, U3, U3, U3, U3 |
| 10 | ME6211C18M5G-N | microduck:SOT-23-5_L3.0-W1.7-P0.95-LS2.8-BR | U6, U6, U6, U6, U6, U6, U6, U6, U6, U6 |
| 10 | MMBT3906 | Package_TO_SOT_SMD:SOT-23 | Q1, Q1, Q1, Q1, Q1, Q1, Q1, Q1, Q1, Q1 |
| 10 | PTC(40R) | microduck:F0603 | F1, F1, F1, F1, F1, F1, F1, F1, F1, F1 |
| 10 | PZ254V-11-05P | microduck:pad-5 | H2, H2, H2, H2, H2, H2, H2, H2, H2, H2 |
| 10 | SMAJ24A | microduck:SMA_L4.4-W2.6-LS5.0-RD | D1, D1, D1, D1, D1, D1, D1, D1, D1, D1 |
| 10 | SN74LVC1G125DBV | Package_TO_SOT_SMD:SOT-23-5 | U5, U5, U5, U5, U5, U5, U5, U5, U5, U5 |
| 10 | SN74LVC1G126DBVR | Package_TO_SOT_SMD:SOT-23-5 | U4, U4, U4, U4, U4, U4, U4, U4, U4, U4 |
| 10 | XL2EL89CSI-111YLC-12M | microduck:CRYSTAL-SMD_4P-L3.2-W2.5-BL | X1, X1, X1, X1, X1, X1, X1, X1, X1, X1 |
The 740 most common of 897 parts.


jyg9/microduck-community-kit
补充microduck缺少的硬件电路和固件,另外配套一些测试工具。imu_to_dxl;banana_pcb;microduck复刻

armature-ai-labs/indieduck
Open robot prototype: editable FreeCAD CAD, printable parts and fit-test documentation. Adapted from Open Duck Mini.

pollen-robotics/elec_grabette
Set of electronic boards for Grabette/Gripette

modewang/elec_RPI_Robot_HAT
The RPIRobotHAT can be power from 5 to 28V. It is designed to use of the motor connector as an power input.


OHNope/ESP32-P4X_MIPI_Camera_Sub_V1.1_KiCAD
The KiCAD project for ESP32-P4_FUNCTION_EV_BOARD_MIPI_Camera_Sub_V1.1_20240529

PaulBichl/vibepcb-smu
VibePCB example: 4-quadrant SMU (+-30 V / +-1 A, USB-C PD, Ethernet) designed with an LLM
It measures 141.9 × 72.9 mm and has 2 copper layers, 1.6 mm thick.
897 parts, built around the GD32F303CCT6, SN74LVC1G125DBV, SN74LVC1G126DBVR-TP and LSM6DSV16XTR. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the yilv1982/duck-robot repository on GitHub, at the commit this page was made from: the board is references/microduck-community-kit/hardware/imu_to_dxl/imu_to_dxl_10p.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask yilv1982 before reusing the design.