2 layers149 × 141 mm

 havrak/UAV-project5
Building a UAV as part of my final year on high school, now my hobby project
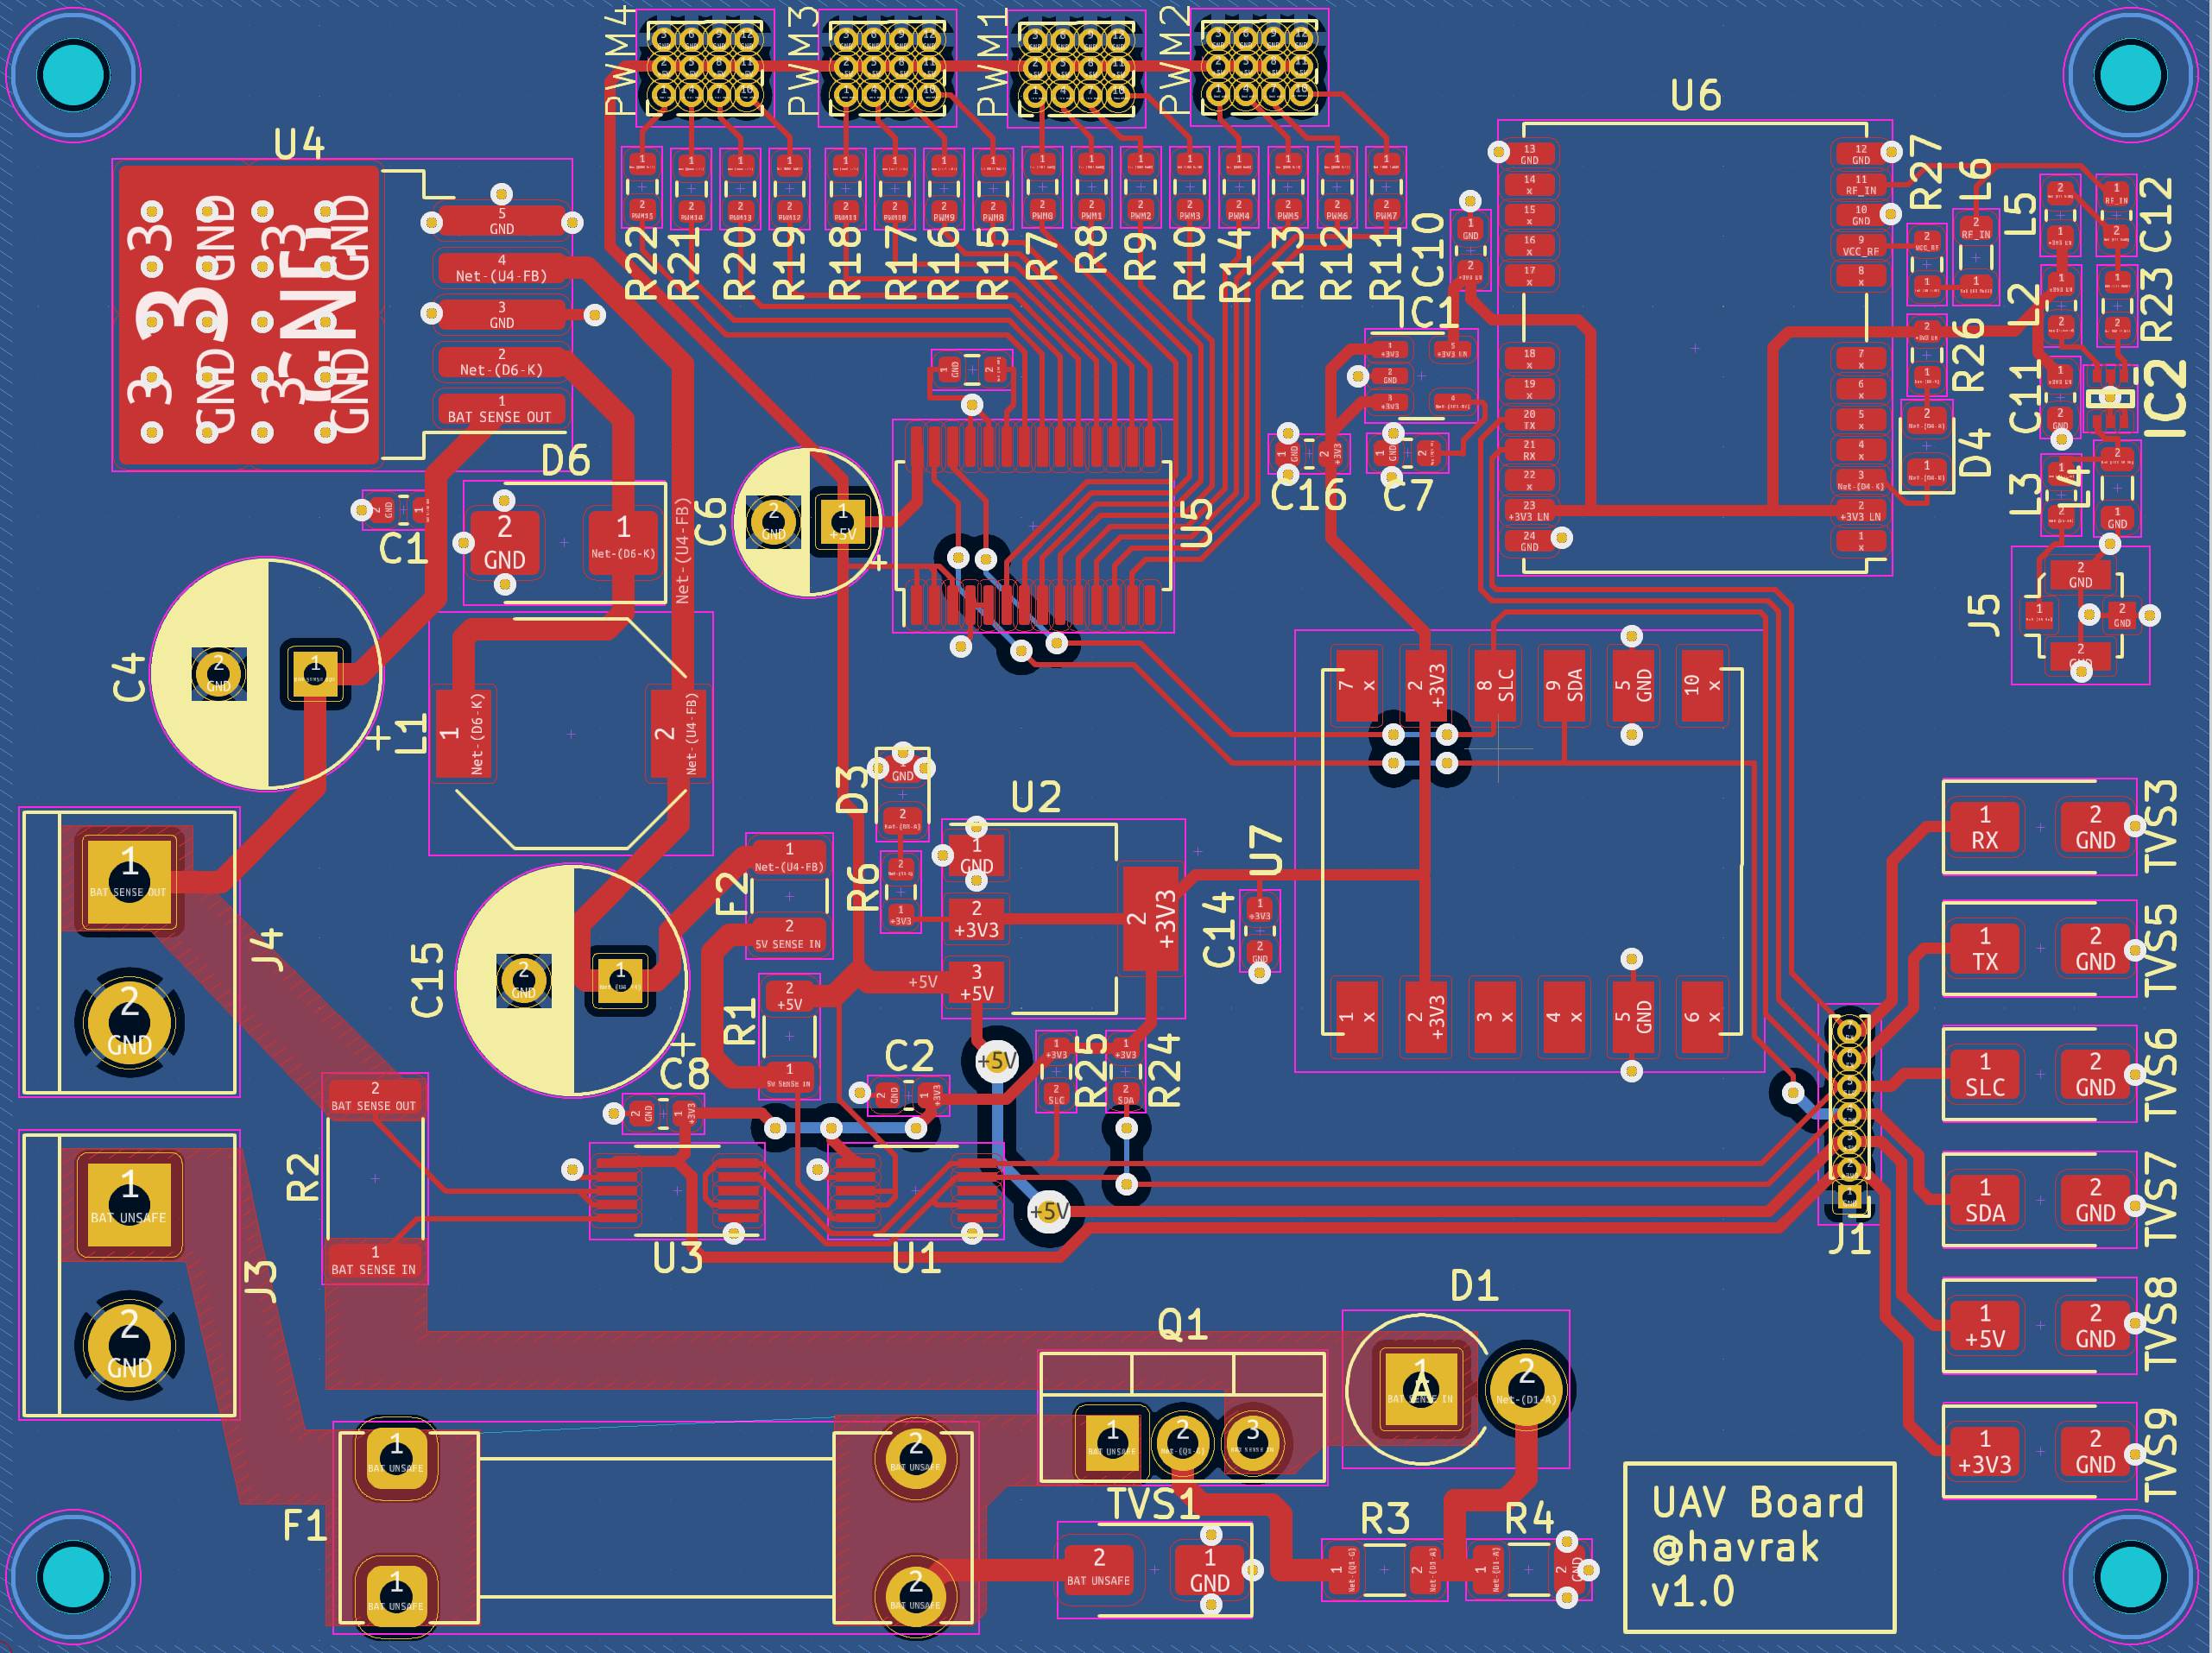
UAV project is an open-source printed circuit board by havrak, from the havrak/UAV-project repository on GitHub, published under the MIT licence. It is a 2-layer board of 80 × 60 mm with 80 parts on 83 nets, routed with 635 tracks and 92 vias.
It is built around the LM2596S-5.0, PCA9685PW and AMS1117-3.3, with the RT9193-33GB, SMAJ30CA and SS210 among its other parts. Its parts include 27 resistors, 12 capacitors, 9 ICs, 6 inductors and 4 diodes. It belongs with the robots and motor control boards of this library.


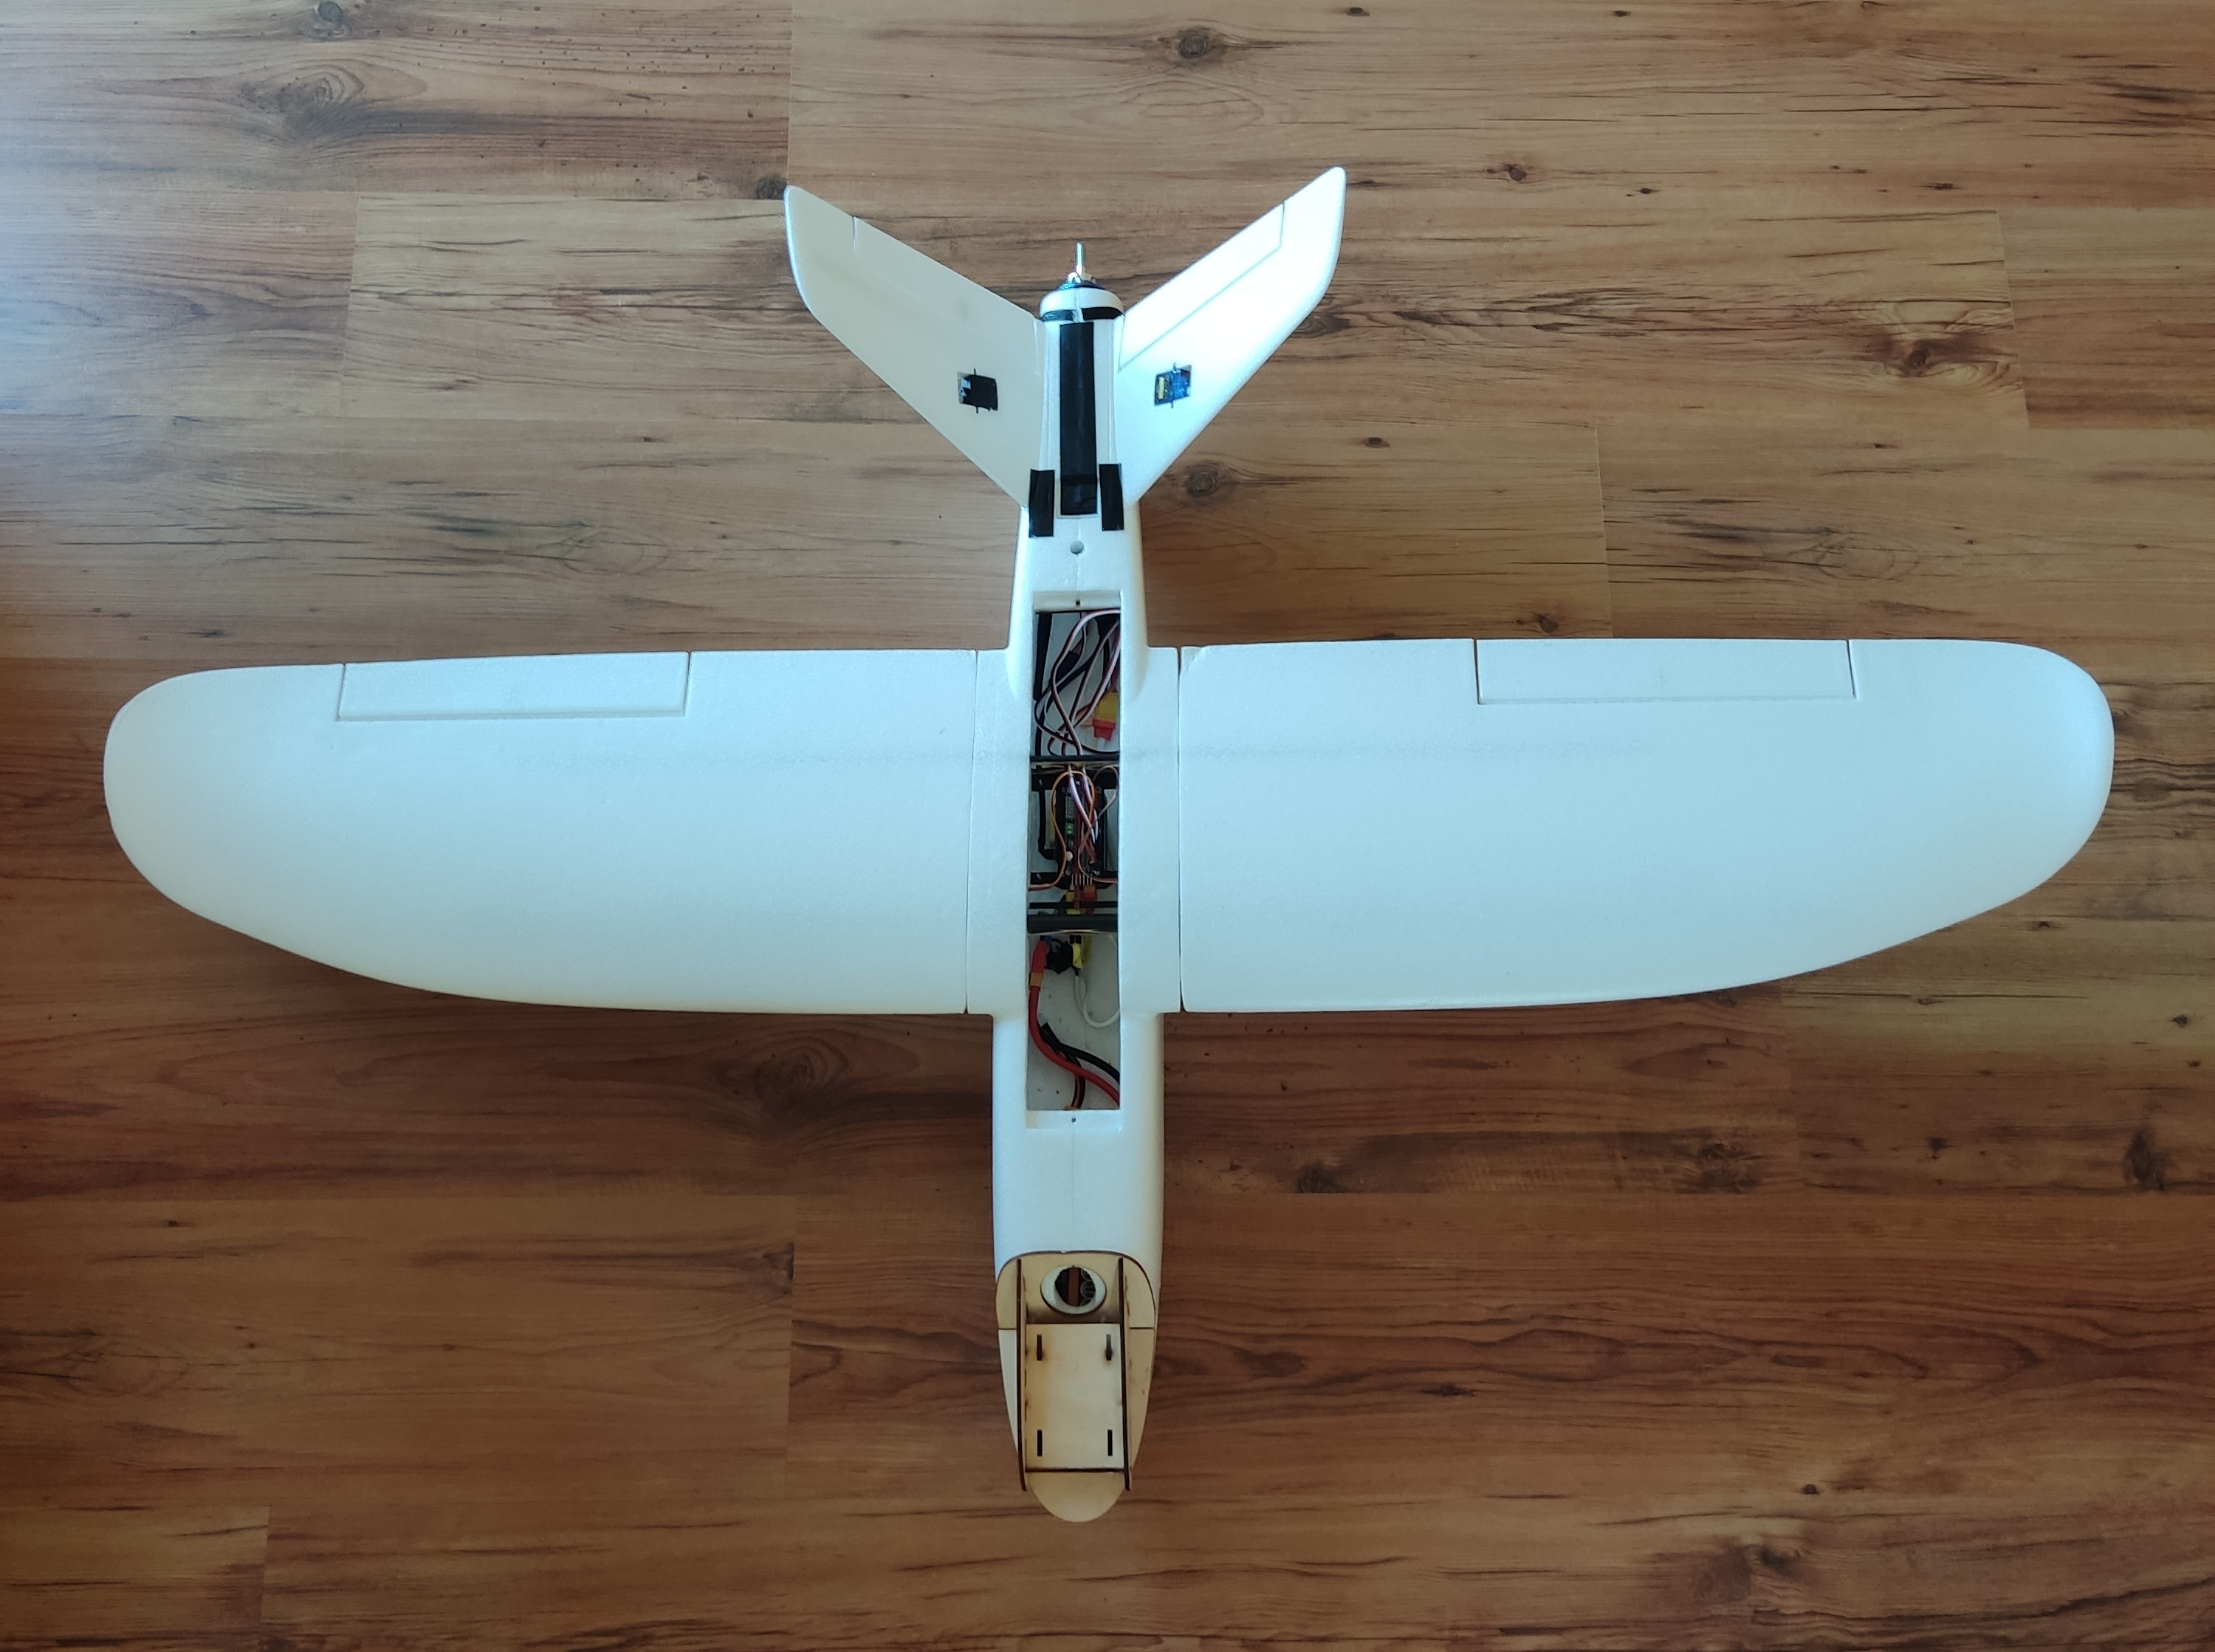
This repository contains all resource that comprised my final thesis for my senior year in high school. Main purpose was to create UAV platform based on Raspberry Pi.
Codebase is this project is rather bad by my current standards and is heavily impacted by the fact it was essentially my first hardware related project. Not to mention my experience with C++ was rather limited at the time.
Desktop client is written in C++ using Gtk3 and is used to control the drone and display telemetry data. UI wise it's really bad, and code itself doesn't land much in a way for easy rewrite.
Drone side might fare a bit better, but it's still not great. Usage of threads is rather questionable and OOP design patterns were a hip new thing for me at the time and not something I was able to use properly.
Thus some parts of codebase are overengineered and some lack any flexibility and don't deserve much other than deletion.
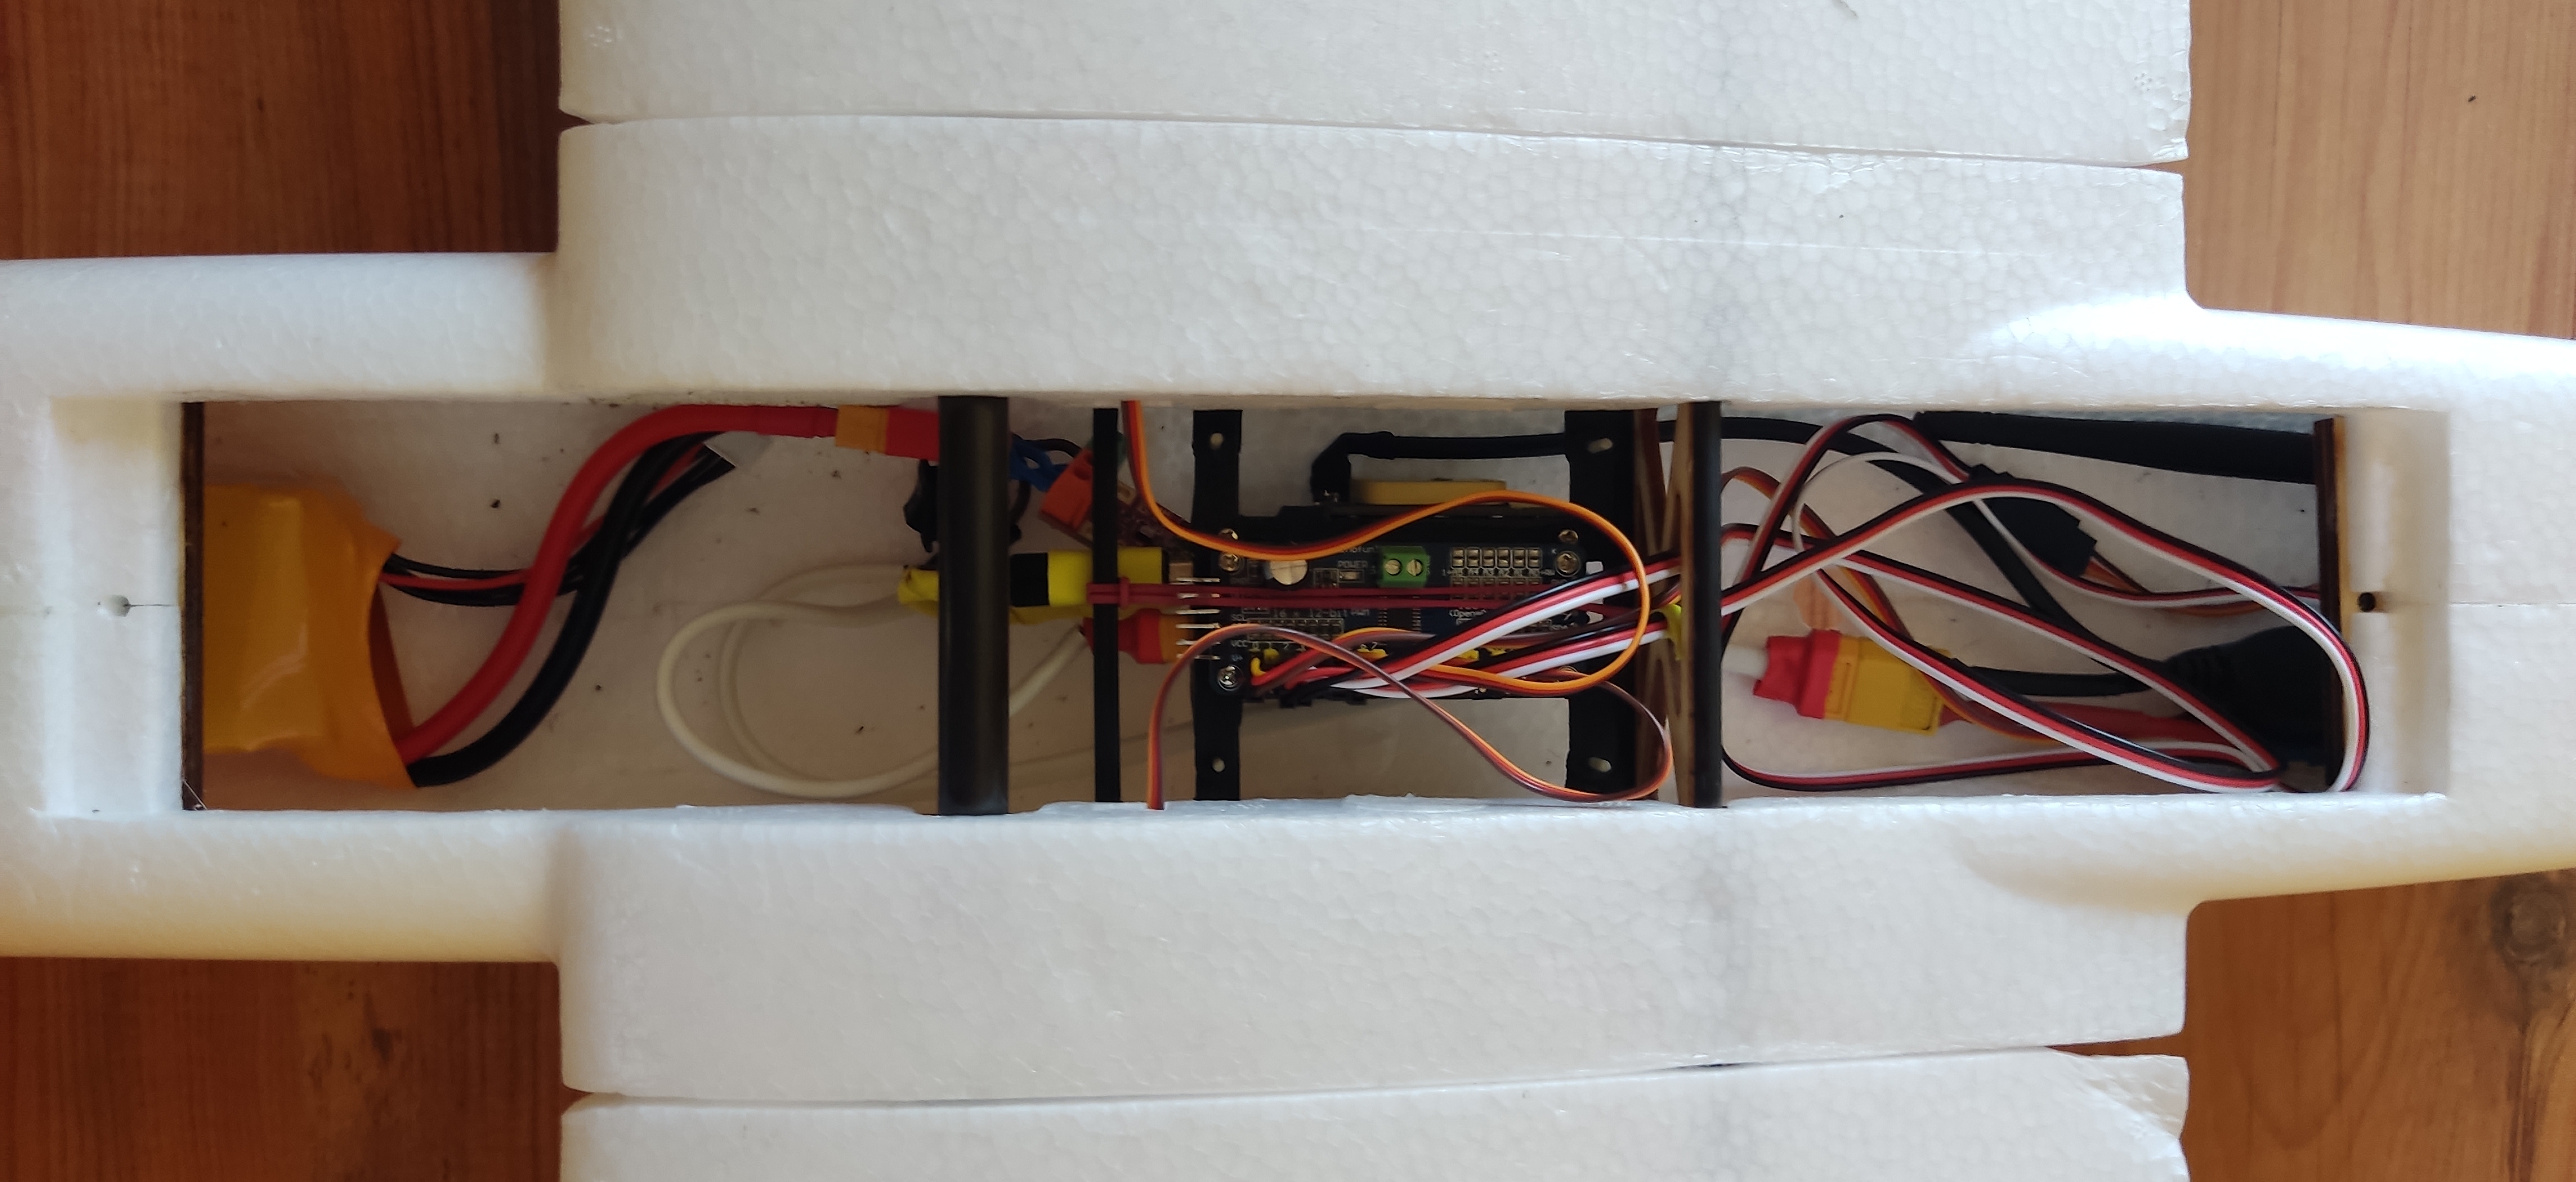
In my 3rd semester of university I've made addition to this project in a shape of proper custom PCB to house drone electronics.
I might rewrite this project in the future, but time is a limited resource and school+work take priority. Though if rewrite happens, it will be wholly different project.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 16 | 220 | Resistor_SMD:R_0603_1608Metric | R7, R8, R9, R10, R11, R12, R13, R14, R15, R16, R17, R18, R19, R20, R21, R22 |
| 7 | SMAJ30CA | Diode_SMD:D_SMA | TVS1, TVS3, TVS5, TVS6, TVS7, TVS8, TVS9 |
| 6 | 100n | Capacitor_SMD:C_0603_1608Metric | C1, C2, C7, C8, C11, C14 |
| 4 | MountingHole | MountingHole:MountingHole_2.2mm_M2 | H1, H2, H3, H4 |
| 4 | conn_03x04_Pin | Custom_Footprints:PinHeader_3x04 | PWM1, PWM2, PWM3, PWM4 |
| 2 | 10 | Resistor_SMD:R_0603_1608Metric | R23, R27 |
| 2 | 100u | Capacitor_THT:CP_Radial_D8.0mm_P3.50mm | C4, C15 |
| 2 | 18n | Inductor_SMD:L_0805_2012Metric | L4, L6 |
| 2 | 1p | Capacitor_SMD:C_0603_1608Metric | C10, C16 |
| 2 | 4.7k | Resistor_SMD:R_0603_1608Metric | R24, R25 |
| 2 | 470 | Resistor_SMD:R_0603_1608Metric | R6, R26 |
| 2 | 8.7n | Inductor_SMD:L_0603_1608Metric | L2, L3 |
| 2 | INA226 | Package_SO:VSSOP-10_3x3mm_P0.5mm | U1, U3 |
| 2 | LED | LED_SMD:LED_0805_2012Metric | D3, D4 |
| 1 | 100 | Resistor_SMD:R_1206_3216Metric | R3 |
| 1 | 100p | Capacitor_SMD:C_0603_1608Metric | C12 |
| 1 | 10k | Resistor_SMD:R_1206_3216Metric | R4 |
| 1 | 10k | Resistor_SMD:R_0603_1608Metric | R5 |
| 1 | 1N53xxB | Diode_THT:D_DO-201_P3.81mm_Vertical_AnodeUp | D1 |
| 1 | 20m | Resistor_SMD:R_2512_6332Metric | R2 |
| 1 | 20m | Resistor_SMD:R_1206_3216Metric | R1 |
| 1 | 33u | Capacitor_THT:CP_Radial_D5.0mm_P2.50mm | C6 |
| 1 | 47n | Inductor_SMD:L_0603_1608Metric | L5 |
| 1 | 47u | Inductor_SMD:L_Bourns-SRU8043 | L1 |
| 1 | AMS1117-3.3 | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U2 |
| 1 | Bat IN Terminal | TerminalBlock:TerminalBlock_bornier-2_P5.08mm | J3 |
| 1 | Bat OUT Terminal | TerminalBlock:TerminalBlock_bornier-2_P5.08mm | J4 |
| 1 | Conn_01x07 | Connector_PinHeader_1.00mm:PinHeader_1x07_P1.00mm_Vertical | J1 |
| 1 | Conn_Coaxial | Connector_Coaxial:U.FL_Molex_MCRF_73412-0110_Vertical | J5 |
| 1 | Fuse | Fuse:Fuseholder_Clip-5x20mm_Littelfuse_111_Lateral_P18.80x5.00mm_D1.17mm_Horizontal | F1 |
| 1 | LM2596S-5 | Package_TO_SOT_SMD:TO-263-5_TabPin3 | U4 |
| 1 | NEO-M7N | RF_GPS:ublox_NEO | U6 |
| 1 | NJG1130KA1-TE1 | Imported_Footprints:SOTFL50P160X60-6N | IC2 |
| 1 | PCA9685PW | Package_SO:TSSOP-28_4.4x9.7mm_P0.65mm | U5 |
| 1 | PMOS | Package_TO_SOT_THT:TO-220-3_Vertical | Q1 |
| 1 | Polyfuse | Fuse:Fuse_1210_3225Metric | F2 |
| 1 | RT9193-33GB | Package_TO_SOT_SMD:SOT-23-5 | IC1 |
| 1 | SS210 | Diode_SMD:D_SMB | D6 |
| 1 | WT901B | Custom_Footprints:WT901B | U7 |

Queens-Rocket-Engineering-Team/av-power
QRET Avionics PCBs and firmware for delivering power to SRAD PCBs

ilomon10/embedded-totalizer-hour-meter
ESP32 engine hour meter & totalizer: firmware, SensorFrame protocol, Node host tools, KiCad PCB and a Deno device simulator

mosyrf/Oxygen-Monitoring-System
This was my second year project as an electrical engineering student, and it was quite difficult because it used an STM32 controller, which I was not familiar with.


Dheemanth0207/Electronic-Conference-Badge
This project investigates the design and development of a smart, energy-efficient electronic conference badge intended to replace traditional printed name tags used at events and meetings.


NHuang58/Piano_Hand_Electronics
API using Music 21 and MIDI to convert midi files and piano notes to coordinates for a piano hand
It measures 80 × 60 mm and has 2 copper layers, 1.57 mm thick.
80 parts, built around the LM2596S-5.0, PCA9685PW, AMS1117-3.3 and RT9193-33GB. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the havrak/UAV-project repository on GitHub, at the commit this page was made from: the board is board/uav_project.kicad_pcb and its schematic board/gps_module.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).