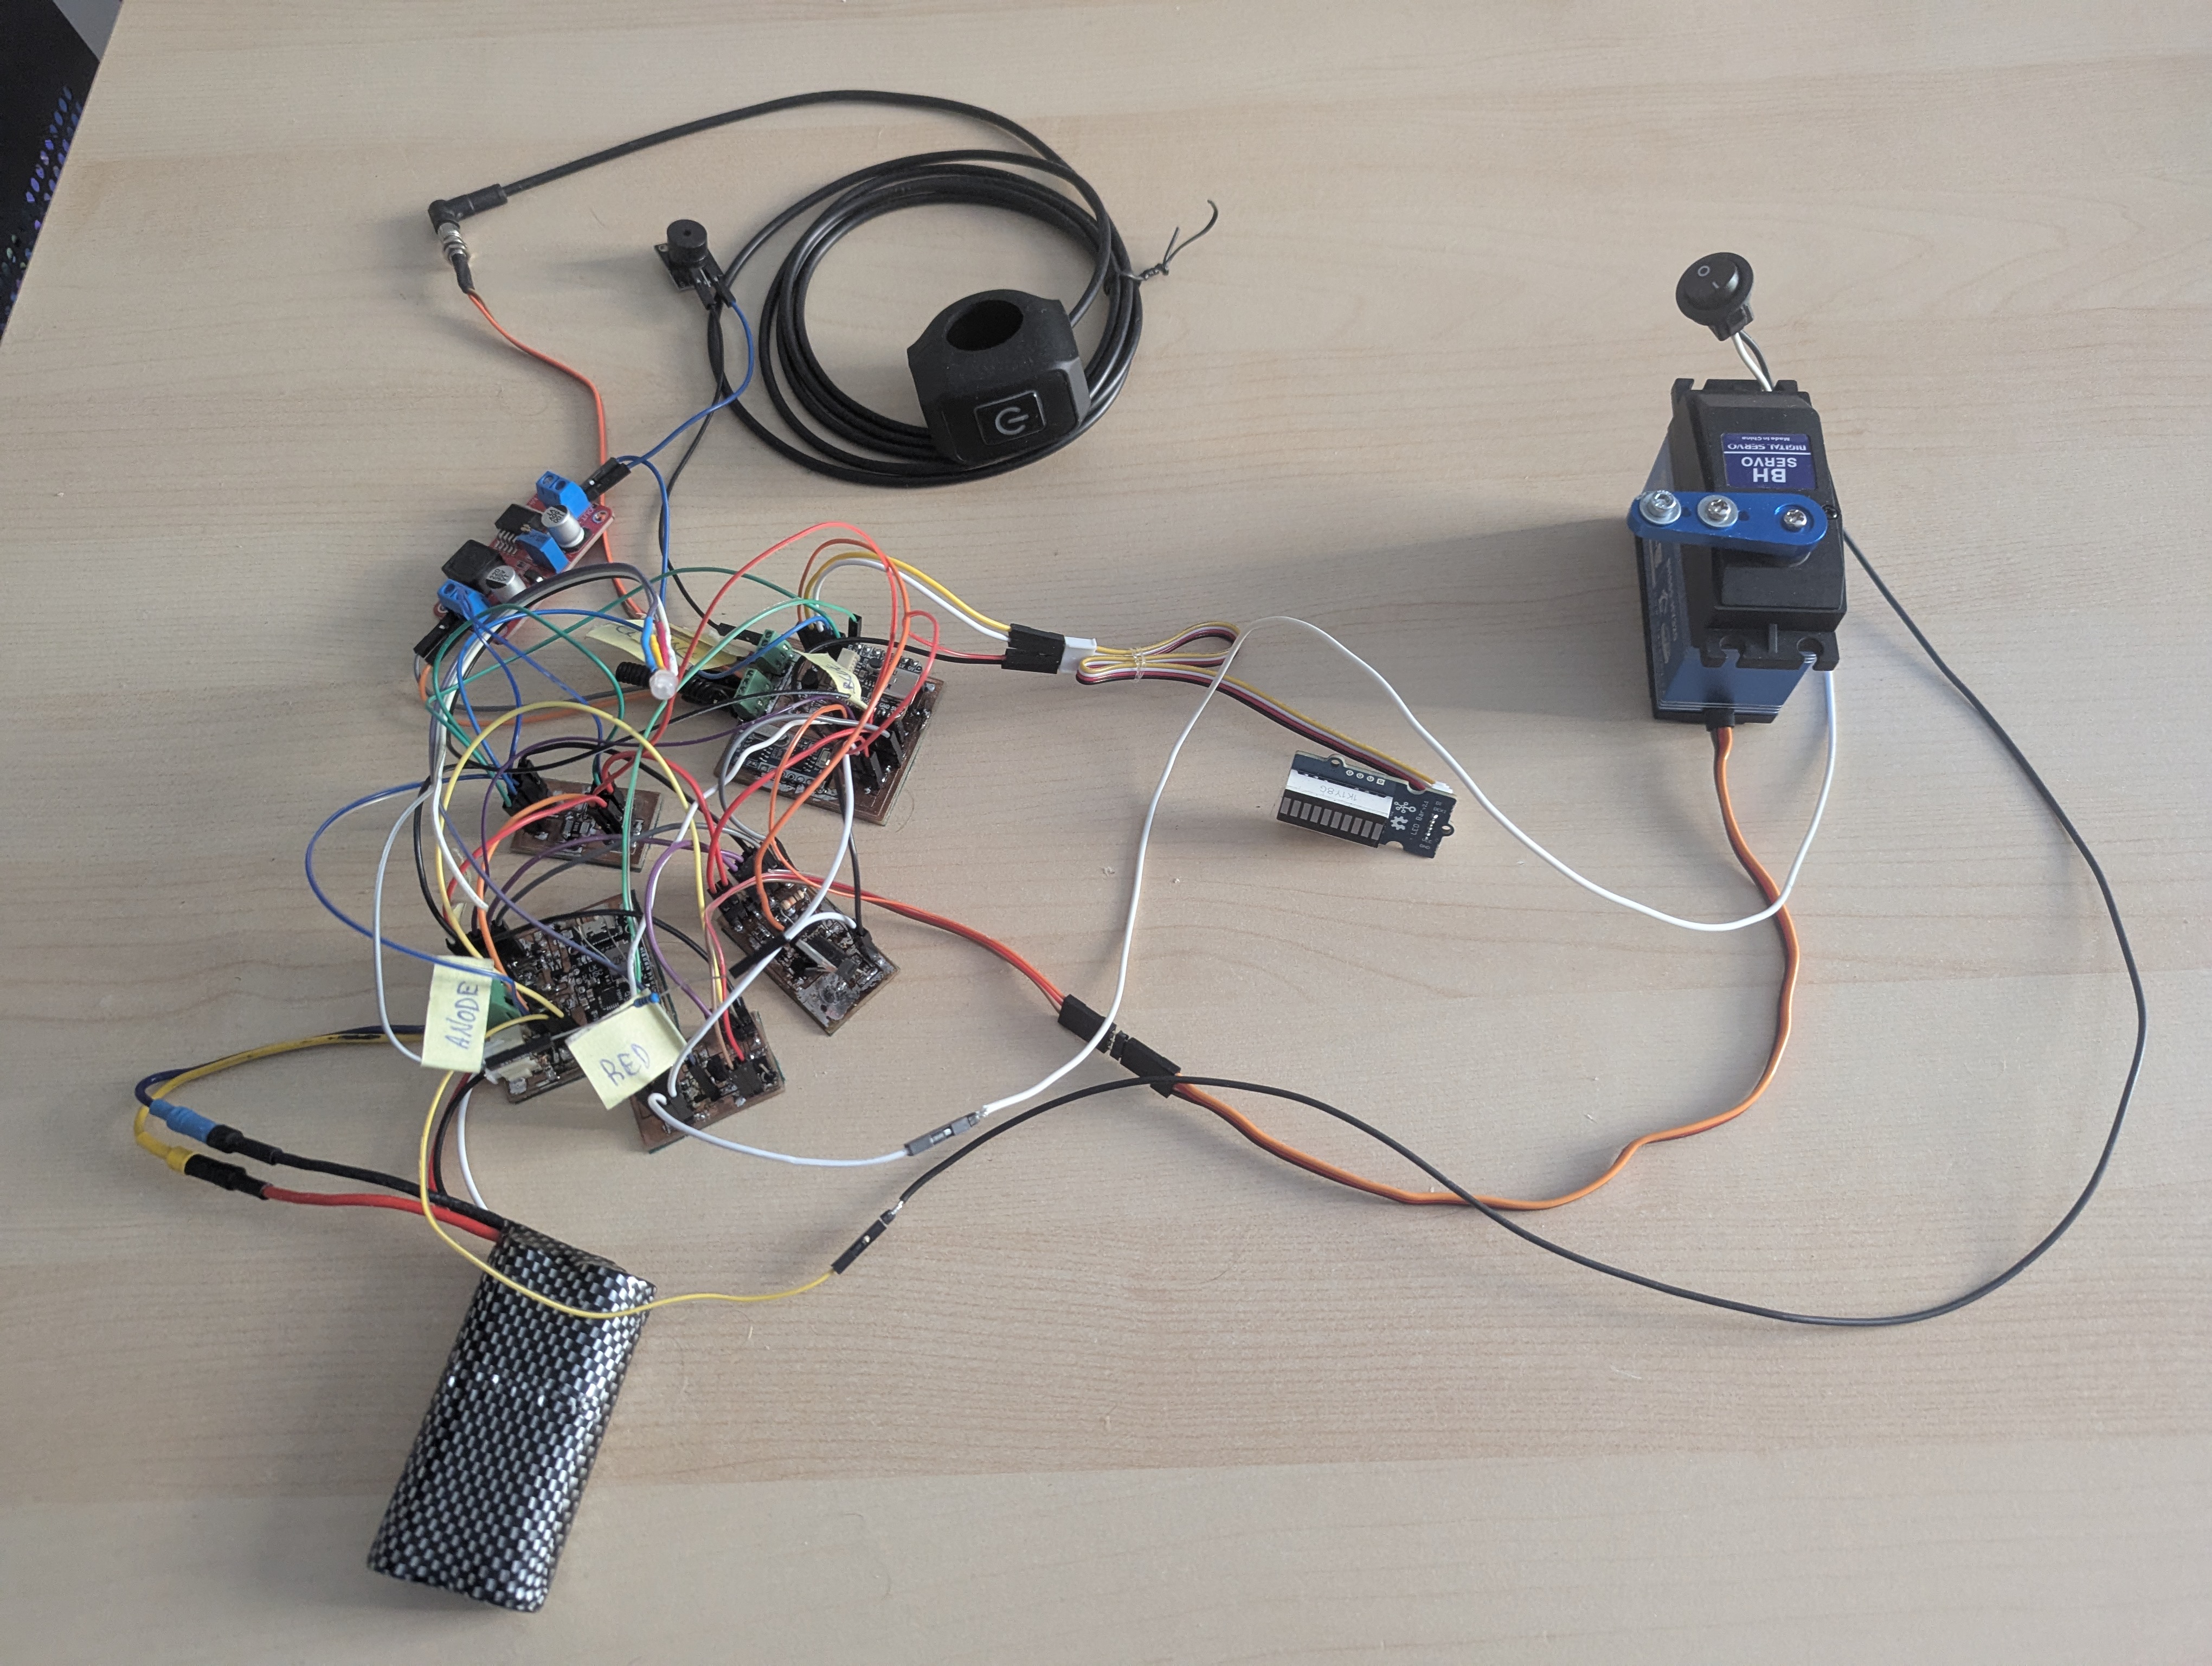
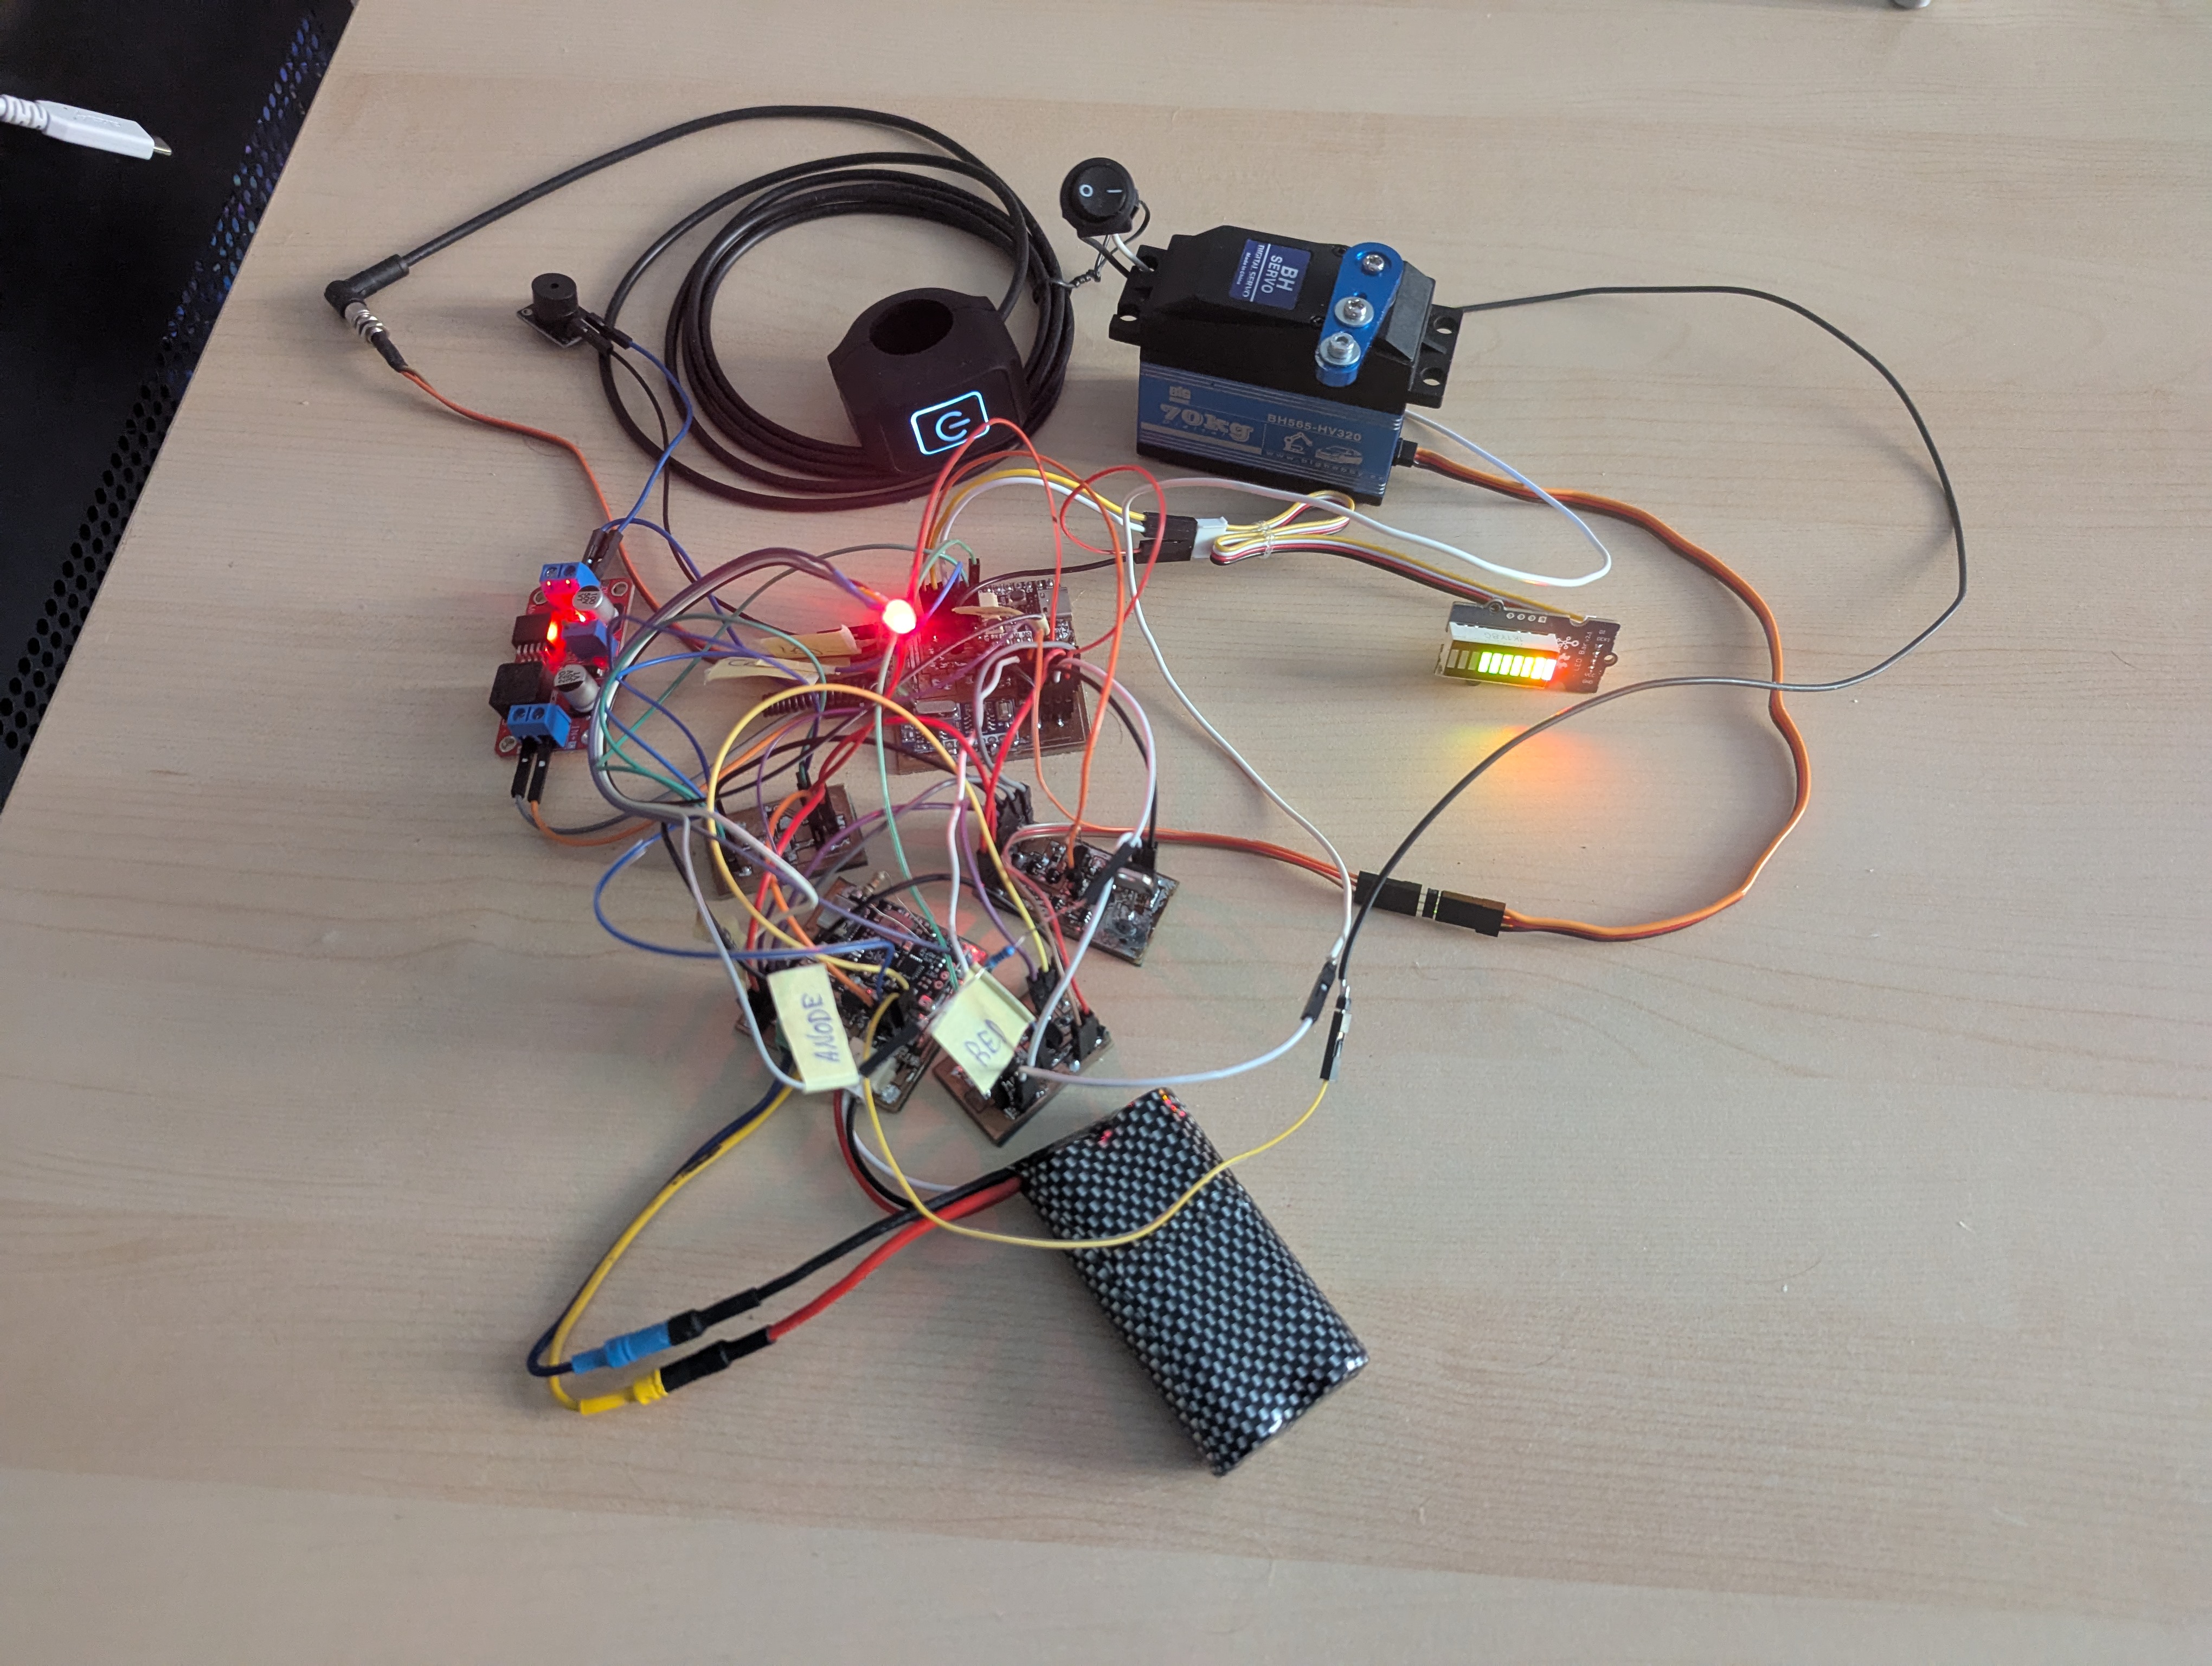
AccelSensor
electronic system to control breaks on handbikes remotely
- Size
- 21 × 16 mm
- Copper layers
- 11
- Thickness
- 1.6 mm
- Parts
- 15
- Nets
- 50
- Pads
- 61
- Tracks, vias
- 0, 0
- Routed
- Not yet
- KiCad
- KiCad 8.99 (file 20241010)
- Created
- 12 Sep 2024
- Updated
- 10 Sep 2025
Overview
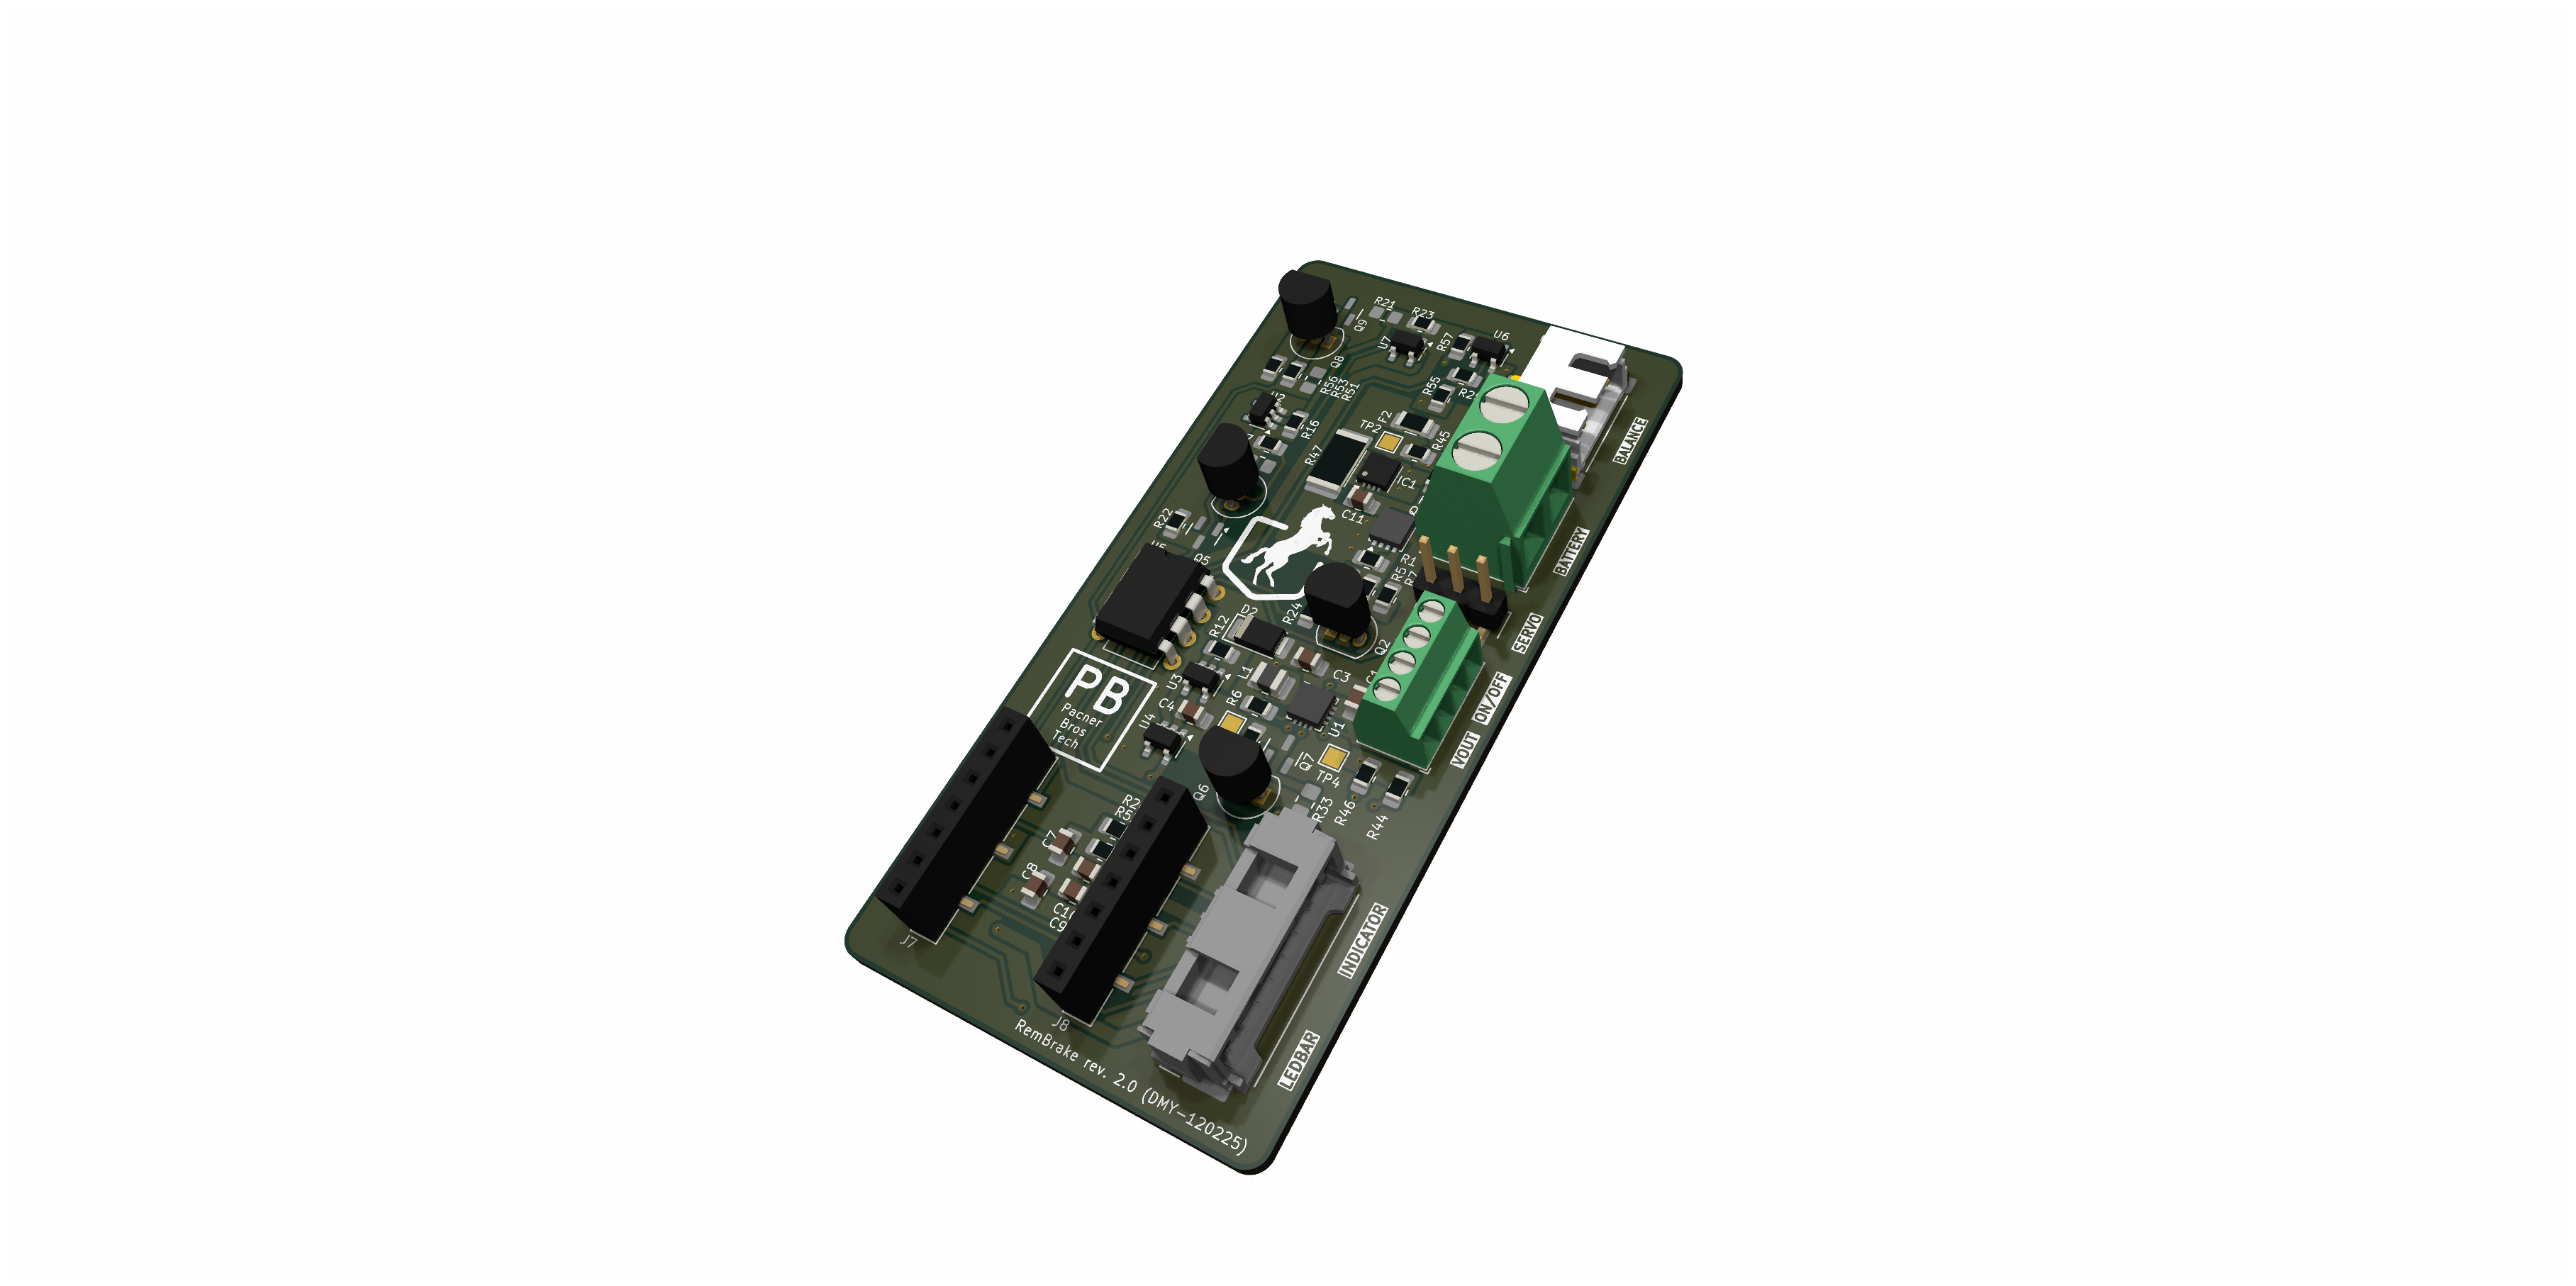
AccelSensor is an open-source printed circuit board by dodotronix, from the dodotronix/RemBrake repository on GitHub. It is an 11-layer board of 21 × 16 mm with 15 parts on 50 nets.
It is built around the MPU-6050. Its parts include 7 capacitors, 4 resistors, 2 ICs, 1 diode and 1 connector. It belongs with the radio and wireless and robots and motor control boards of this library.
Main components
1README
README.mdRemBrake - remote brake system for handbikes

Introduction
- TODO explain what the RemBrake, why we decided to create this project
Assembling RemBrake
- TODO explain how to use the kicad data
- TODO how to solder the modules on the RemBrake PCB
- TODO how to connect the wires
Prepare the module
- load the circuitpython to the QT Py RP2040
- press and hold BOOT button and then press RST button
- you should see now RPI partition mounted to your PC
- download CircuitPython bootloader (.uf2 file) from circuitpython.org
- drag and drop the file onto the partition
- it takes few moments and you should see your partition name turn to CIRCUITPYTHON
Upload RemBrake files + necessary modules
- go to the folder fw folder
- run $ make prepare
- move the folder target to your CIRCPITPYTHON partition
Features
- TODO how the PCB behaves (charging, running, error)
- TODO what the different colors mean
Possible further development
- Bidirectional remote contoller that the assistant can see the battery status
- Accelerometer feedback, to adjust braking power according to the situation
- Using hydraulic piston actuator to move with the brake directly, which could shrink significantly the size of the package
- designing custom usb-c charger to avoid the hustle with unprecise power management of the chinese module
Development

Parts
15| Qty | Value | Footprint | References |
|---|---|---|---|
| 6 | C | Capacitor_SMD:C_0603_1608Metric | C1, C2, C3, C4, C5, C6 |
| 4 | R | Resistor_SMD:R_0603_1608Metric | R1, R2, R3, R4 |
| 1 | C | Capacitor_Tantalum_SMD:CP_EIA-3216-10_Kemet-I | C7 |
| 1 | Conn_01x08 | Connector_PinHeader_2.54mm:PinHeader_1x08_P2.54mm_Vertical | J1 |
| 1 | LED | LED_SMD:LED_0603_1608Metric | D1 |
| 1 | MPU-6050 | Sensor_Motion:InvenSense_QFN-24_4x4mm_P0.5mm | U2 |
| 1 | TC1017-xCT | Package_TO_SOT_SMD:SOT-23-5 | U1 |
Questions
How big is the AccelSensor PCB?
It measures 21 × 16 mm and has 11 copper layers, 1.6 mm thick.
What parts does the AccelSensor use?
15 parts, built around the MPU-6050. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
Where can I download the AccelSensor KiCad files?
From the dodotronix/RemBrake repository on GitHub, at the commit this page was made from: the board is hw/AccelSensor/AccelSensor.kicad_pcb and its schematic hw/AccelSensor/AccelSensor.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Can I use the AccelSensor design in my own project?
Its repository states no licence, so its author keeps all rights: ask dodotronix before reusing the design.
More from dodotronix/RemBrake
6- 2 layers40 × 80 mm

- 2 layers143.8 × 99.6 mm

- 11 layers31 × 18 mm

- 11 layers42 × 24 mm

- 11 layers28.3 × 12.3 mm

- 11 layers50 × 28 mm

Similar boards
- 2 layers23 × 120 mm

- 4 layers95 × 50 mm

Control board
ZhuYanzhen1/MM32_CLion
本项目是全国大学生智能车竞赛GDUT 2022年极速越野组的项目文件。采用了LQR控制器和多速率卡尔曼融合算法,并在单片机上实现。This project is the project document for the GDUT 2022 Extreme Off-Road Category of the National Student Intelligent Vehicle Competition.
129 parts58AGPL-3.0 - 2 layers50 × 66 mm

- 2 layers36 × 43 mm

Asac fc rev a
victorhook/asac-fc
asac fc is an rp2040 based flight controller made for FPV drone flying
119 parts52GPL-3.0 - 4 layers305 × 208.3 mm

- 2 layers98.5 × 17.8 mm

- 2 layers36.2 × 36.2 mm

- 2 layers26 × 21.3 mm

PModBoard
pms67/PModlet
PMOD PCB with USB-to-UART converter and IMU (MPU-6050, I2C) for FPGAs.
19 parts15MIT