2 layers41 × 30 mm
V35 ref
Scienceche/microduck-journal
对 fanhao375/microduck-replica / OSHWhub imutoservo 团购板 的复刻实作记录: 一块自己焊的 IMU 总线板(STM32G031 + LSM6DSV16X + SN74LVC2G241)、一个 Radxa Zero 3W 主控、 15 颗飞特 HD1910、自训 RL 步态策略,以及把这一切调通的全部血泪。
58 parts
 Scienceche/microduck-journal
对 fanhao375/microduck-replica / OSHWhub imutoservo 团购板 的复刻实作记录: 一块自己焊的 IMU 总线板(STM32G031 + LSM6DSV16X + SN74LVC2G241)、一个 Radxa Zero 3W 主控、 15 颗飞特 HD1910、自训 RL 步态策略,以及把这一切调通的全部血泪。
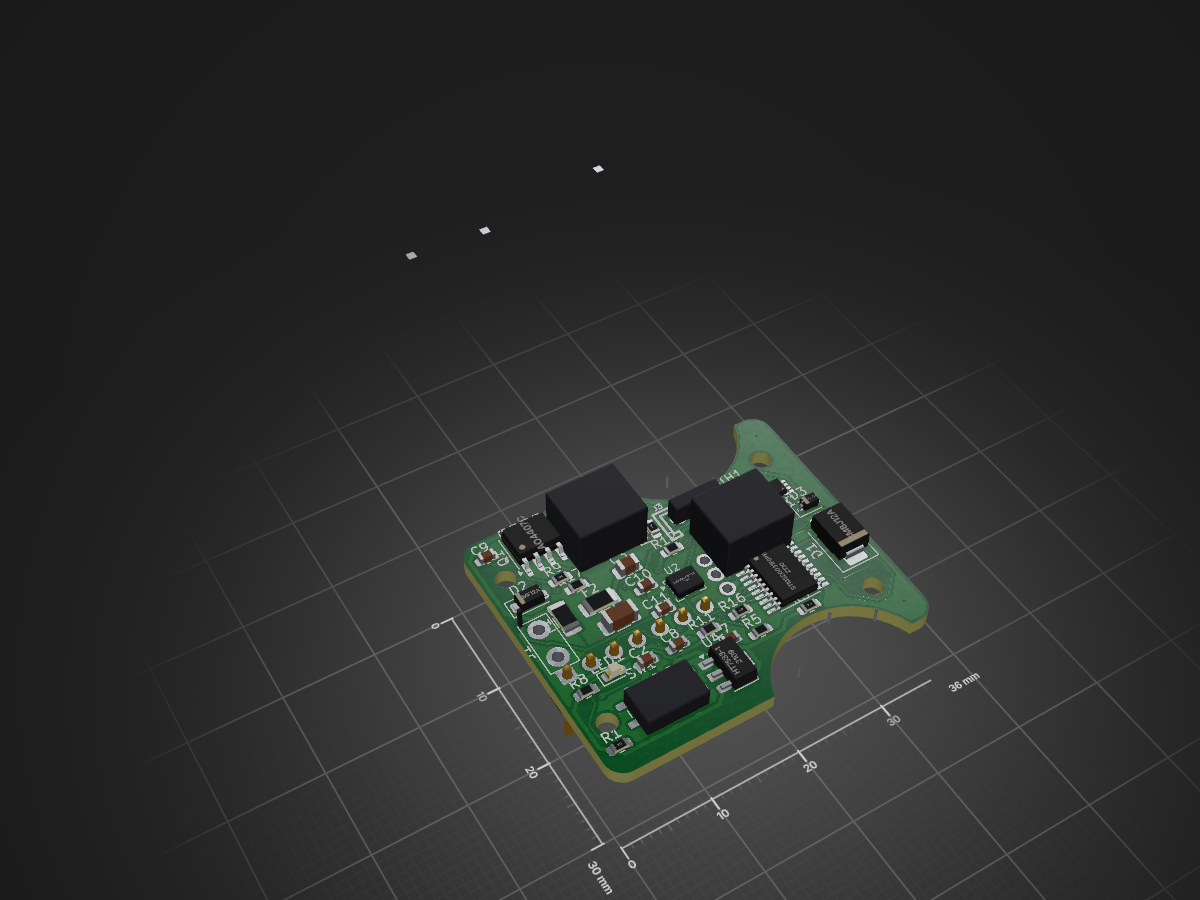
Imu to ttl is an open-source printed circuit board by Scienceche, from the Scienceche/microduck-journal repository on GitHub. It is a 2-layer board of 36 × 30 mm with 60 parts on 36 nets, routed with 407 tracks and 59 vias.
It is built around the STM32G031F8P6, HT7533-1 and LSM6DSV16XTR, with the AO4407C, BLM18AG601SN1D and BZT52C5V1 among its other parts. Its parts include 17 resistors, 16 capacitors, 6 connectors, 4 ICs and 4 diodes. It belongs with the sensors and measurement boards and the STM32 boards of this library.


对 fanhao375/microduck-replica / OSHWhub imu_to_servo 团购板 的复刻实作记录: 一块自己焊的 IMU 总线板(STM32G031 + LSM6DSV16X + SN74LVC2G241)、一个 Radxa Zero 3W 主控、 15 颗飞特 HD1910、自训 RL 步态策略,以及把这一切调通的全部血泪。
私人仓库 · 每日自动同步自工作目录
E:\c1349\复刻microduck
| 子系统 | 状态 |
|---|---|
| IMU 板(总线从机 ID 200 @1Mbps,FT6 协议) | ✅ 完全工作,装向四元数实测校准至 0.00° |
| 固件栈 | ✅ kissqy 官方栈 robotd 0.15.1(control.43)+ 三轮交叉编译热修复 |
| 总线质量 | ✅ 丢包 6-9% → 0.004%(ID12/13、ID34→10 两处时隙碰撞已断开) |
| 整机标定 | ✅ 15 舵机零位/方向/限位(标定台 :8085,robotd 桥接) |
| RL 训练(mjlab/MuJoCo Warp) | ✅ walk5 前进 0.19m/s;VelStand 抗扰站立 99% 存活(未部署) |
| 仿真保真 | ✅ 936g 整机质量 + 202g 电池(含碰撞盒 70×38×35mm,2026-11-06 起) |
| 步态/站立(kissqy 自训模型) | ✅ 满电+校向后 10 次冲击(翻滚/前冲/侧切/旋转)不倒 |
| 起身恢复 | ⏳ 测试中:门卫链路已打通,待满电跑 5 次推倒统计 |
| 摄像头(IMX219 CSI) | ✅ 单帧验证通过;mediad WebRTC 待装 GStreamer 栈 |
| 电源 | ⚠️ 2S 软包(7.72V@今晨);峰值曾拉穿电压致整机重启,起身测试需满电 |
docs/        调试记录(最重要的文件——完整故障树与修复过程)
firmware/    imu-to-ttl 固件(STM32G031 裸机,make g031-dxl)
hardware/    KiCad 复刻工程 + 元件手册
panel/       中控面板 duck_panel(旧栈)+ calib-panel 标定台(:8085,robotd 桥接)
sync.sh 每日同步脚本(工作目录 → 本仓库 → GitHub)| Qty | Value | Footprint | References |
|---|---|---|---|
| 9 | 100nF 50V | C_0603_1608Metric | C2, C4, C6, C7, C9, C10, C11, C13, C14 |
| 6 | 10k | R_0603_1608Metric | R2, R3, R7, R14, R15, R16 |
| 4 | M2 | MountingHole_2.1mm_M2 | M1, M2, M3, M4 |
| 3 | 0R | R_0603_1608Metric | R4, R5, R6 |
| 2 | 22uF 16V X5R | C_1210_3225Metric | C15, C16 |
| 1 | +3V3 | TestPoint_Pad_D1.0mm | TP3 |
| 1 | 0R (jumper) | R_0603_1608Metric | R17 |
| 1 | 100k | R_0603_1608Metric | R9 |
| 1 | 10k ALT DNP | R_0603_1608Metric | R12 |
| 1 | 10uF 10V | C_0603_1608Metric | C5 |
| 1 | 10uF 25V X7R | C_0805_2012Metric | C3 |
| 1 | 10uF 25V X7R | C_1206_3216Metric | C1 |
| 1 | 150R | R_0603_1608Metric | R13 |
| 1 | 1M | R_0603_1608Metric | R10 |
| 1 | 1k | R_0603_1608Metric | R1 |
| 1 | 1uF 25V X7R | C_0603_1608Metric | C12 |
| 1 | 2.2k FIT | R_0603_1608Metric | R8 |
| 1 | 4.7k ALT DNP | R_0603_1608Metric | R11 |
| 1 | 4.7uF 10V X7R | C_0603_1608Metric | C8 |
| 1 | AO4407C | SOIC-8_3.9x4.9mm_P1.27mm | Q1 |
| 1 | BATT IN 2.54 2P | BattPad_1x02_P3.60mm_Drill1.2mm | J1 |
| 1 | BLM18AG601SN1D | L_0603_1608Metric | FB1 |
| 1 | BZT52C5V1 | D_SOD-323 | D3 |
| 1 | FUSE 5A 2512 | Fuse_1206_3216Metric | F1 |
| 1 | GND | TestPoint_Pad_D1.0mm | TP2 |
| 1 | HT7533-1 | SOT-89-3 | U4 |
| 1 | J_HEAD | CONN-TH_B3B-PH-K-S | J6 |
| 1 | J_L | CONN-TH_S3B-PH-K-S | J4 |
| 1 | J_NECK | CONN-TH_B3B-PH-K-S | J3 |
| 1 | J_R | CONN-TH_S3B-PH-K-S | J5 |
| 1 | LED 0603 | LED_0603_1608Metric | LED1 |
| 1 | LSM6DSV16XTR | ST_LGA14_3x2.5_P0.5_LSM6DSV16X_TN0018 | U2 |
| 1 | PPTC 200mA | Fuse_1206_3216Metric | F2 |
| 1 | PRG18BB101MB1RB | R_0603_1608Metric | TH1 |
| 1 | SMBJ12A | D_SMB | D1 |
| 1 | SMF12A | D_SOD-123F | D2 |
| 1 | SN74LVC2G241DCUR | VSSOP-8_2.3x2mm_P0.5mm | U3 |
| 1 | STM32G031F8P6 | TSSOP-20_4.4x6.5mm_P0.65mm | U1 |
| 1 | SW SPDT MSK12C02 | SW_SPDT_Shouhan_MSK12C02 | SW1 |
| 1 | SWD+UART+NRST | PinHeader_1x07_P2.54mm_Vertical | J2 |
| 1 | VBAT | TestPoint_Pad_D1.0mm | TP1 |
Scienceche/microduck-journal
对 fanhao375/microduck-replica / OSHWhub imutoservo 团购板 的复刻实作记录: 一块自己焊的 IMU 总线板(STM32G031 + LSM6DSV16X + SN74LVC2G241)、一个 Radxa Zero 3W 主控、 15 颗飞特 HD1910、自训 RL 步态策略,以及把这一切调通的全部血泪。

Scienceche/microduck-journal
对 fanhao375/microduck-replica / OSHWhub imutoservo 团购板 的复刻实作记录: 一块自己焊的 IMU 总线板(STM32G031 + LSM6DSV16X + SN74LVC2G241)、一个 Radxa Zero 3W 主控、 15 颗飞特 HD1910、自训 RL 步态策略,以及把这一切调通的全部血泪。


OpenModbus/OM-64DO
A compact industrial-grade 64-channel Modbus RTU output module.


Celnardur/rfc_tackle_sensor
Open a git bash terminal in the directory of your choosing and call the following command:


will-tm/gbc-cm4-aio
This project is a drop-in replacement board that fits and Gameboy Color shell and use the same IPS display as used in GBC kits.

It measures 36 × 30 mm and has 2 copper layers, 1.6 mm thick.
60 parts, built around the STM32G031F8P6, HT7533-1, LSM6DSV16XTR and AO4407C. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Scienceche/microduck-journal repository on GitHub, at the commit this page was made from: the board is hardware/imu-to-ttl/imu_to_ttl.kicad_pcb and its schematic hardware/imu-to-ttl/01_power.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask Scienceche before reusing the design.