
2 layers132.1 × 100.7 mm
Relaybox indicator leds
Full-Blue-Racing/FBR24-Electronics
This repo houses all the code the car needs to run, separated into steering wheel, telemetry, and CAN bus files.
57 parts
This repo houses all the code the car needs to run, separated into steering wheel, telemetry, and CAN bus files.
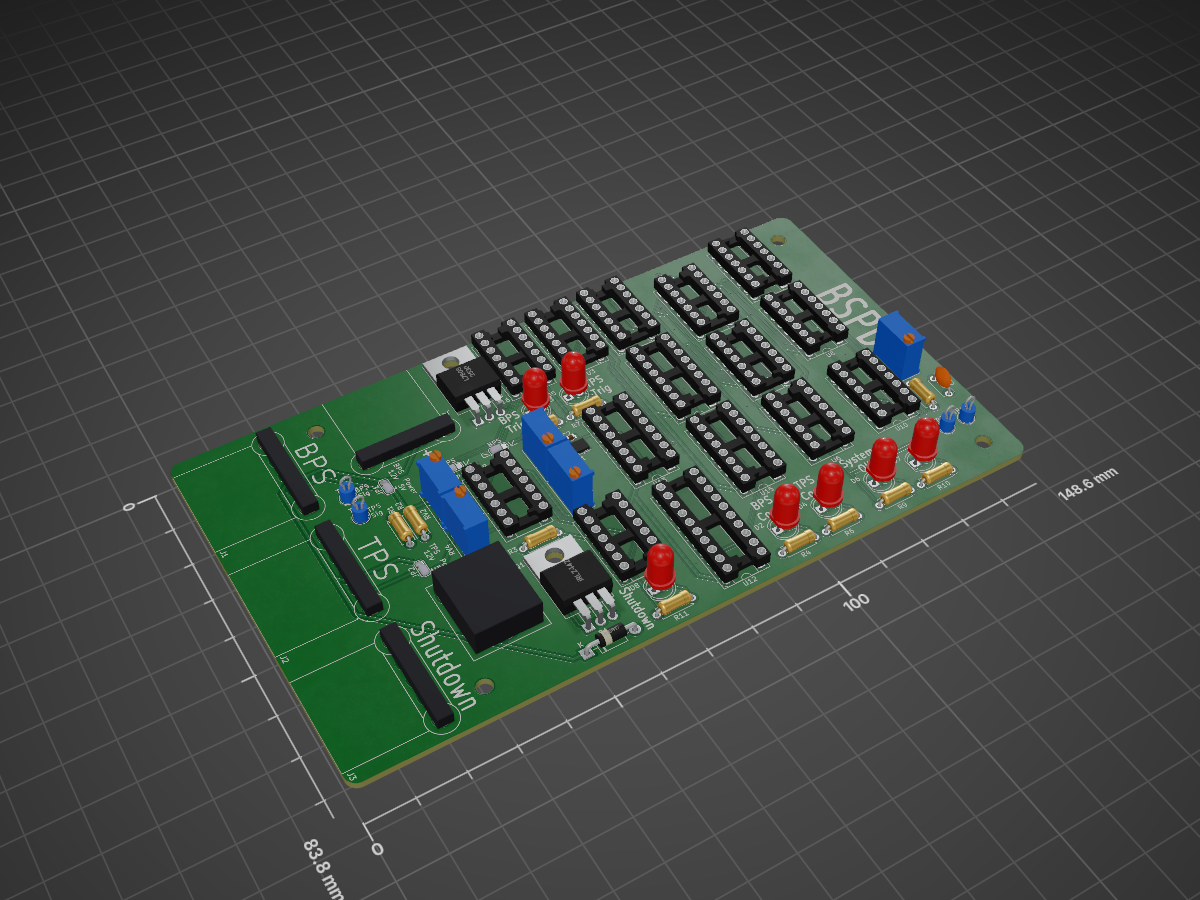
New BSPD is an open-source printed circuit board by Full-Blue-Racing, from the Full-Blue-Racing/FBR24-Electronics repository on GitHub. It is a 2-layer board of 148.6 × 83.8 mm with 62 parts on 118 nets, routed with 510 tracks and 40 vias.
It is built around the LM2901, 74LS573PC and L7805, with the ASZKDV-32.768KHZ-H-T3, IRLZ44ZPBF and MCCMA51-S-DC12V-C among its other parts. Its parts include 16 ICs, 11 resistors, 8 diodes, 4 connectors and 2 capacitors.


This repo houses all the code the car needs to run, separated into steering wheel, telemetry, and CAN bus files.
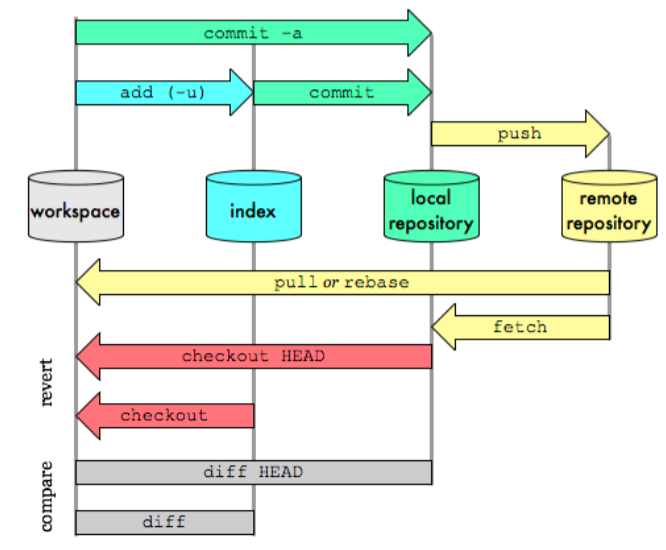
Git can be separated into remote and local repository (repo), how it works is that you can clone a repo to your local machine, add files you would like git to track, commit your changes to your local branch, pull changes by others from the remote repo, and push your own local changes. Locally git can be separated into three areas:
Untracked files -> tracked files -> staging area
Untracked files are usually not part of the project and will not be added to the
repo. Tracked files are project files, and files in here will have status shown
(i.e. new file/changed/renamed...). The staging area is files that are ready to
be committed, and tracked files needs to be added by git add.
These are the only commands I would recommend using on the command line/IDE, for more complex commands (such as creating pull requests for merging branches) use the web interface.
No direct pushing/committing on the master branch
Each of the following tasks are on a separate branch, please work on the branch relevant to your task. If multiple people are on the same branch please make sub-branches from the main task branch
e.g.
steering-wheel -> steering-wheel-warninglights
               -> steering-wheel-RPM-lights
We will merge them into the main steering-wheel branch when you make a merge request to the task branch.
Commit every time you've implemented a feature - it allows easy rollback to previous version without too much code loss if things go wrong (and they WILL go wrong).
git config --global user.name <display name> - sets your name on your commits to the repo
git clone <path/to/directory> - clones a local copy of the repo to your
machine so you can make changes.
git pull origin <name of branch> - pulls any changes others have
published on the remote branch of the said name since your last update/ initial
clone
git add <file to be added> - adds file to the staging area to be included
in the next commit.
git commit -m "Commit message here" - commits file to the local branch
with the commit message - please make the commit message meaningful so it is
easier to backtrack (Not Add new file)
git push origin <name of branch> - push your local commits to the remote
repo on the named branch. Note that on the first push git may require you to
set the upstream branch with git branch --set-upstream-to <name of head branch>
git remote update origin --prune - updates branches and removes merged branches
on your local machine.
Each function to be made are described in respective folders' README,
please edit the README with your name if you are currently working on the
task, and remove it if not. If someone is already working on one and you want
to join, contact them and see if you can help before writing your own code.
Otherwise just write your name down and contact me (Will) for any
questions/purchasing.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | 4011 | Package_DIP:DIP-14_W7.62mm_Socket | U1, U2, U3, U4, U5, U6, U7, U8 |
| 7 | 220R | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R4, R5, R6, R7, R9, R10, R11 |
| 7 | LED | LED_THT:LED_D5.0mm | D2, D3, D4, D5, D6, D7, D8 |
| 4 | 10k | Potentiometer_THT:Potentiometer_Bourns_3296Y_Vertical | RV1, RV2, RV3, RV4 |
| 4 | MountingHole_3.2mm_M3 | MountingHole:MountingHole_3.2mm_M3 | MNT1, MNT2, MNT3, MNT4 |
| 4 | SolderJumper_3_Open | Jumper:SolderJumper-3_P1.3mm_Open_RoundedPad1.0x1.5mm | JP1, JP2, JP3, JP4 |
| 4 | TestPoint | TestPoint:TestPoint_THTPad_D3.0mm_Drill1.5mm | TP1, TP2, TP3, TP4 |
| 3 | 4040 | Package_DIP:DIP-16_W7.62mm_Socket | U13, U14, U15 |
| 3 | Conn_01x03 | BSPD_footprints:ATF13-3P-BM03 | J1, J2, J3 |
| 2 | 5Meg | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R1, R2 |
| 2 | LM2901 | Package_DIP:DIP-14_W7.62mm_Socket | U9, U10 |
| 1 | 100n | Capacitor_THT:C_Disc_D5.0mm_W2.5mm_P5.00mm | C1 |
| 1 | 10u | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C2 |
| 1 | 1M | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R8 |
| 1 | 1N5817 | Diode_THT:D_DO-41_SOD81_P10.16mm_Horizontal | D1 |
| 1 | 4.7k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R3 |
| 1 | 4012 | Package_DIP:DIP-14_W7.62mm_Socket | U11 |
| 1 | 74LS573 | Package_DIP:DIP-20_W7.62mm_Socket | U12 |
| 1 | ASZKDV-32.768KHz | Oscillator:Oscillator_SMD_Abracon_ASE-4Pin_3.2x2.5mm | X1 |
| 1 | IRLZ44Z | Package_TO_SOT_THT:TO-220-3_Horizontal_TabDown | Q1 |
| 1 | L7805 | Package_TO_SOT_THT:TO-220-3_Horizontal_TabDown | U16 |
| 1 | LOGO | BSPD_footprints:FBR_Logo_.9in | G*** |
| 1 | MCCMA51-S-DC12V-C | Additional Footprints:MCCMA51-S-DC12V-C | K1 |
| 1 | R_Potentiometer | Potentiometer_THT:Potentiometer_Bourns_3296Y_Vertical | RV5 |
| 1 | Screw_Terminal_01x02 | BSPD_footprints:ATF13-2P-BM03 | J4 |
Full-Blue-Racing/FBR24-Electronics
This repo houses all the code the car needs to run, separated into steering wheel, telemetry, and CAN bus files.

Full-Blue-Racing/FBR24-Electronics
This repo houses all the code the car needs to run, separated into steering wheel, telemetry, and CAN bus files.

Full-Blue-Racing/FBR24-Electronics
This repo houses all the code the car needs to run, separated into steering wheel, telemetry, and CAN bus files.

Full-Blue-Racing/FBR24-Electronics
This repo houses all the code the car needs to run, separated into steering wheel, telemetry, and CAN bus files.


rdoetjes/tuts
Assembly of random tutorials, that can be referenced in videos and YT comments

FabianGmeiner/BMW_E30_SI_Board
Reverse engineering and improving the BMW E30 service indicator board

damienmaguire/MG-EV-Inverter
Reverse engineering of the drive motor and inverter used in MG Electric Vehicles

RobertGawron/HardwareDataLogger
Data logger shield based on STM32+ESP32. Has: LCD, keyboard, WIFi, UART and SD card for data storage. Input is as pulse counter and UART communication.


PE1RGU/hf-antenna-switch
Remote HF antenna switch: 3 radios x 4 antennas (path to 8), outdoor relay unit with a hardware safety chain, controlled over Cat6 from a shack interface. KiCad 10, open hardware, designed together with an AI.
It measures 148.6 × 83.8 mm and has 2 copper layers, 1.6 mm thick.
62 parts, built around the LM2901, 74LS573PC, L7805 and ASZKDV-32.768KHZ-H-T3. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Full-Blue-Racing/FBR24-Electronics repository on GitHub, at the commit this page was made from: the board is Loom/New BSPD/New BSPD.kicad_pcb and its schematic Loom/Brake System Plausability Device/BSPD.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask Full-Blue-Racing before reusing the design.