2 layers114.3 × 99.1 mm
ECB
tne-lab/OSCAR
An open-source controller for animal research Report Bug · Request Feature
43 parts1MIT

 tne-lab/OSCAR1
An open-source controller for animal research Report Bug · Request Feature
OSCAR is an open-source printed circuit board by tne-lab, from the tne-lab/OSCAR repository on GitHub, published under the MIT licence. It is a 4-layer board of 155.6 × 120 mm with 139 parts on 253 nets, routed with 1,464 tracks and 203 vias.
It is built around the LTV-247 and ULN2003A. Its parts include 112 resistors, 16 ICs, 8 connectors and 2 capacitors. It belongs with the AVR (ATmega, ATtiny) boards of this library.


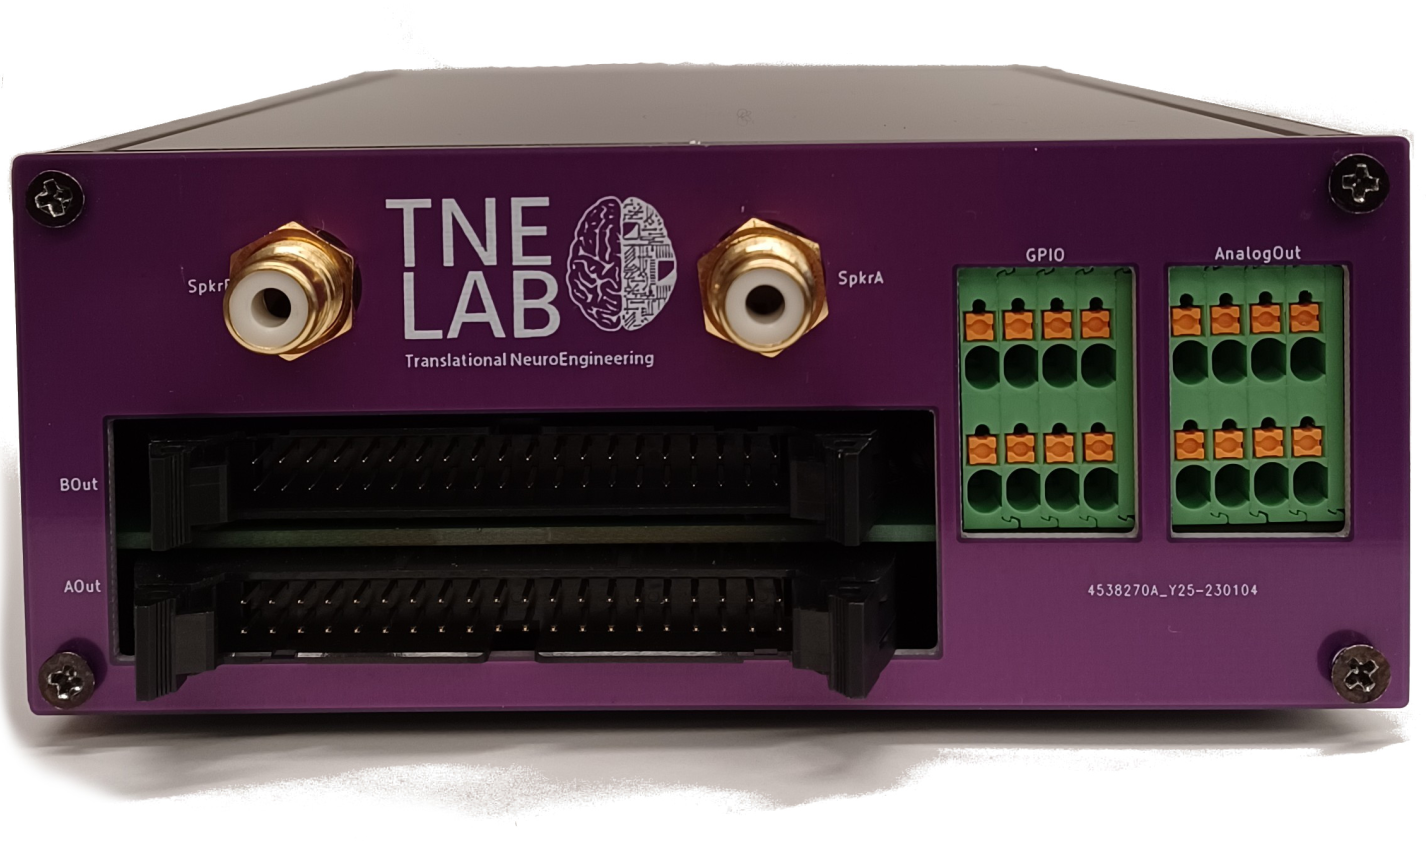
An open-source controller for animal research
Report Bug
·
Request Feature
OSCAR is an open-source controller for animal research that enables flexible control of a variety of industry standard hardware with platform-independent software. OSCAR offers millisecond latency with a flexible array of inputs and outputs at a fraction of the cost of commercial options. These features position OSCAR as a valuable option for improving consistency of behavioral experiments across studies.
Check out the paper on bioRxiv. Cite:
@article {Dastin-van Rijn2023.02.03.527033, author = {Evan M. Dastin-van Rijn and Elizabeth Sachse and Francesca Iacobucci and Megan Mensinger and Alik S. Widge}, title = {OSCAR: an open-source controller for animal research}, elocation-id = {2023.02.03.527033}, year = {2023}, doi = {10.1101/2023.02.03.527033}, publisher = {Cold Spring Harbor Laboratory}, abstract = {Operant animal behavior training and monitoring is fundamental to scientific inquiry across fields necessitating evaluation via controlled laboratory tasks. However, current commercial and open-source systems enforce particular hardware and software, limiting reproducibility and technique and data sharing across sites. To address this issue, we developed OSCAR: an open-source controller for animal research that enables flexible control of a variety of industry standard hardware with platform-independent software. OSCAR offers millisecond latency with a flexible array of inputs and outputs at a fraction of the cost of commercial options. These features position OSCAR as a valuable option for improving consistency of behavioral experiments across studies.Competing Interest StatementThe authors have declared no competing interest.}, URL = {https://www.biorxiv.org/content/early/2023/02/04/2023.02.03.527033}, eprint = {https://www.biorxiv.org/content/early/2023/02/04/2023.02.03.527033.full.pdf}, journal = {bioRxiv}}DAC8554 and digitalWriteFast libraries available through the library installer in the Arduino IDE. Ensure the board is set to the Mega 2560.To communicate with OSCAR's standard firmware over serial, we've provided a local server interface in oscar_server.py
that can handle network commands from user software. This server can be started by running the file or by modifying the
provided oscar.bat file. Alternatively, OSCAR has an integrated Source in the pybehave task development framework that
should streamline control of the hardware as well as task development.
If you encounter problems, take a look at the issues section of the GitHub and leave a new one if your problem hasn't been previously addressed.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 64 | 6.7kΩ | Resistor_SMD:R_0402_1005Metric | R2, R3, R10, R16, R17, R18, R19, R20, R21, R22, R23, R24, R25, R30, R31, R32 +48 |
| 32 | 383Ω | Resistor_SMD:R_0402_1005Metric | R1, R11, R12, R13, R14, R15, R26, R27, R28, R29, R39, R40, R41, R42, R51, R52 +16 |
| 10 | LTV-247 | Package_SO:SOP-16_4.4x10.4mm_P1.27mm | U1, U2, U3, U4, U7, U8, U9, U11, U13, U14 |
| 8 | 10kΩ | Resistor_SMD:R_0402_1005Metric | R97, R98, R99, R100, R101, R102, R103, R104 |
| 8 | 2670Ω | Resistor_SMD:R_0402_1005Metric | R105, R106, R107, R108, R109, R110, R111, R112 |
| 5 | ULN2003A | Package_SO:SOIC-16_3.9x9.9mm_P1.27mm | U5, U6, U10, U12, U44 |
| 2 | 40_Pin_Ribbon_Connector | TNEL:40 Pin Ribbon Connector | J3, J4 |
| 2 | Conn_02x04_Top_Bottom | TNEL:SPTD | J7, J8 |
| 2 | Speaker | Connector_Wire:SolderWire-0.1sqmm_1x02_P3.6mm_D0.4mm_OD1mm | J1, J2 |
| 1 | 0.1uF | Capacitor_SMD:C_0402_1005Metric | C1 |
| 1 | 150nF | Capacitor_SMD:C_0402_1005Metric | C2 |
| 1 | Arduino_Mega2560_Shield | Arduino:Arduino_Mega2560_Shield | XA1 |
| 1 | Barrel_Jack | Connector_BarrelJack:BarrelJack_Horizontal | J5 |
| 1 | Breaker | Connector_Wire:SolderWire-0.5sqmm_1x02_P4.6mm_D0.9mm_OD2.1mm | J6 |
| 1 | DAC8565 | Package_SO:TSSOP-16_4.4x5mm_P0.65mm | U45 |
tne-lab/OSCAR
An open-source controller for animal research Report Bug · Request Feature

Diegoapp55/Proyecto-Sistemas-Embebidos-Smash-Rows
Repositorio para el proyecto de Sistemas Embebidos 2022-2: Smash Rows


ADVecu/CANBoard-Carrier
An automotive-grade carrier board for the CANBoard-HW. This board adapts the system for reliable use in vehicles and motorcycles.


icl-rocketry/Ricardo-PickleRick
A more compact Ricardo classic featuring a new sensor array, 4 pyro channels and 4 servo channels. Includes Ricardo bus plug too.


ben-jacobson/RemoraNucleoHatPCB
Cost-effective, customisable LinuxCNC motion control unit.

It measures 155.6 × 120 mm and has 4 copper layers, 4.69 mm thick.
139 parts, built around the LTV-247 and ULN2003A. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the tne-lab/OSCAR repository on GitHub, at the commit this page was made from: the board is PCB/OSCAR_pcb_kicad/OSCAR.kicad_pcb and its schematic PCB/ECB/Coulbourn/ECB.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).