6 layers56.7 × 54.7 mm
Better md80
darshp848/bldc-controller-60v
60 V, 20 A / 80 A peak BLDC motor controller that fits the MD80 v3.0 mounting. KiCad 10, 6 layers.
144 parts1

 sujaygouda123/foc-control
BLDC field-oriented-control board for a humanoid robot actuator. KiCad 10, Ø80 mm, 8 layers, 1.6 mm.
Foc control is an open-source printed circuit board by sujaygouda123, from the sujaygouda123/foc-control repository on GitHub. It is an 8-layer board with 104 parts on 100 nets, routed with 621 tracks and 249 vias.
It is built around the STM32G474RET3, MCP2562FD-E/SN and LM5164DDAR, with the AS5047P-ATSM, DRV8353SRTAR and AP2112K-3.3 among its other parts. Its parts include 46 capacitors, 22 resistors, 7 ICs, 6 transistors and 5 connectors. It belongs with the robots and motor control boards and the STM32 boards of this library.


BLDC field-oriented-control board for a humanoid robot actuator. KiCad 10, Ø80 mm, 8 layers, 1.6 mm.
| Top | Bottom |
|---|---|
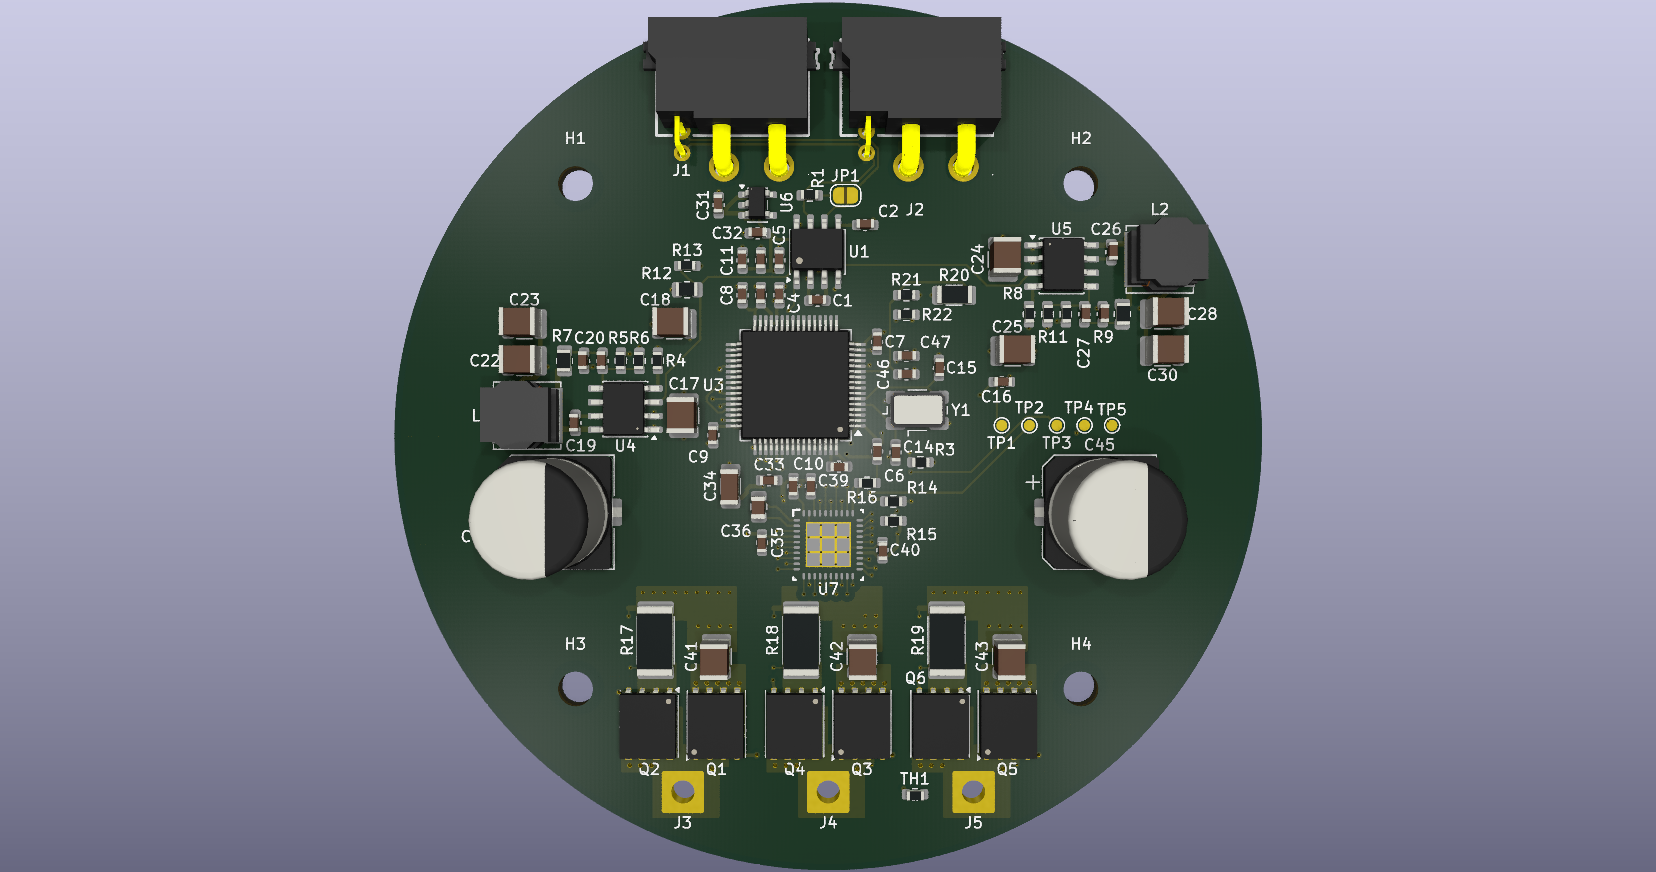 | 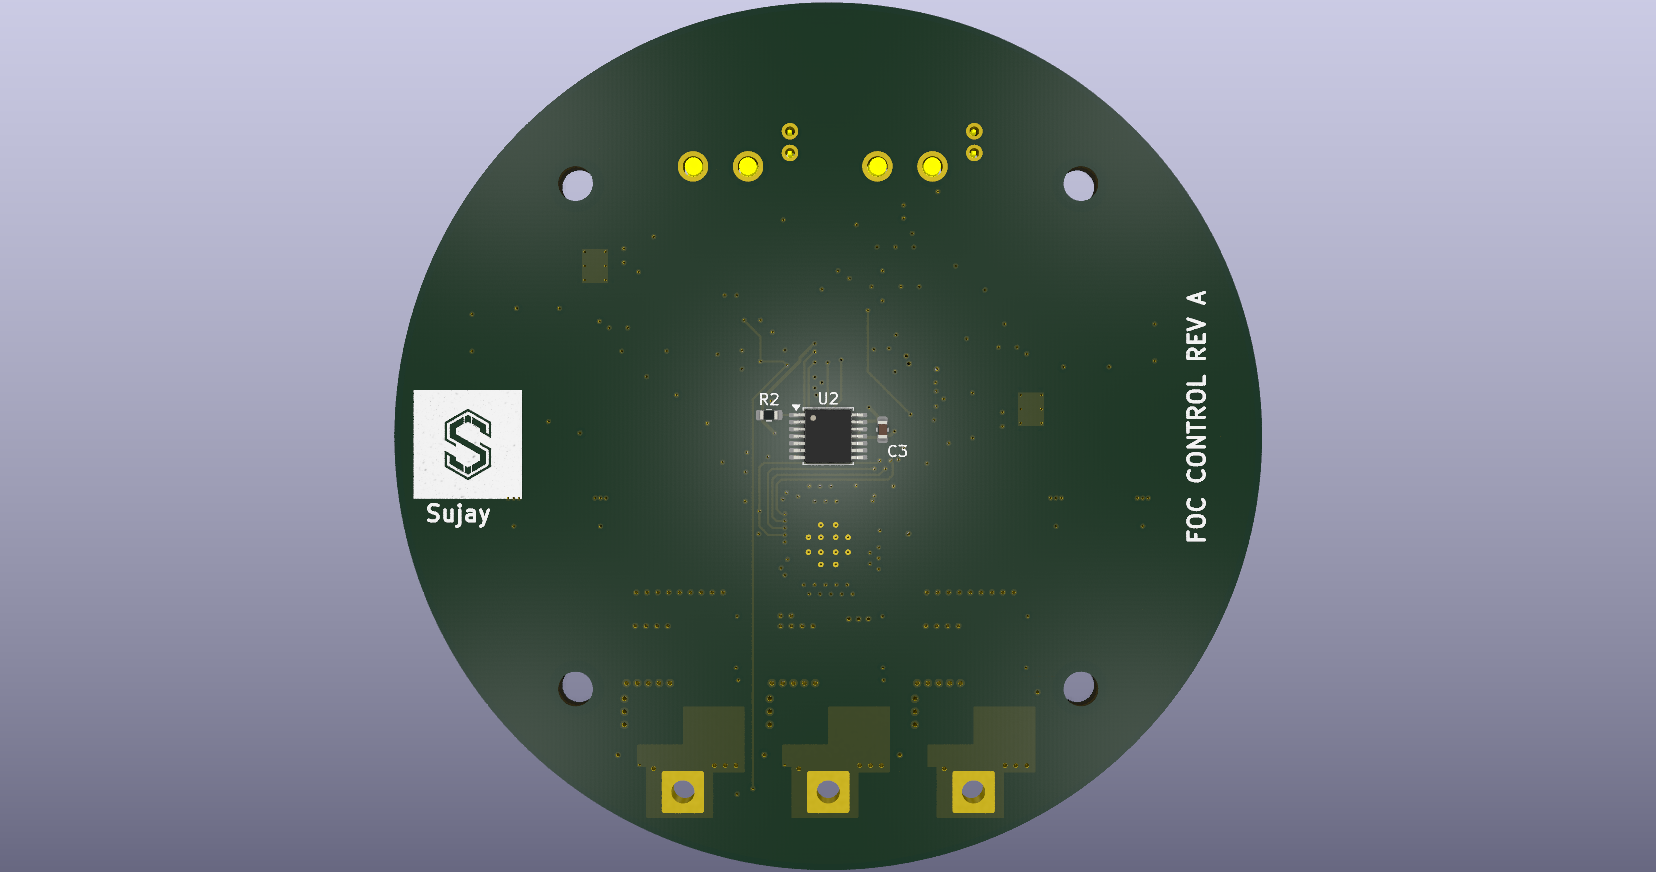 |
| Function | Part |
|---|---|
| MCU | STM32G474RET3 |
| Gate driver | DRV8353S |
| MOSFETs | 6 × BSC040N10NS5 (100 V, 4 mΩ) |
| Current sensing | 3 × 1 mΩ low-side shunts |
| Position | AS5047P magnetic encoder (bottom side) |
| CAN FD | MCP2562FD, 2 × XT30PW 2+2 (power + CAN) |
| Supplies | 2 × LM5164 (12 V, 5 V), AP2112K (3.3 V) |
| Layer | Use |
|---|---|
| F.Cu, 2 oz | Components, power pours |
| In1 | GND |
| In2 | Signals |
| In3 | VBUS |
| In4 | GND |
| In5 | Signals |
| In6 | GND |
| B.Cu, 2 oz | Phase pours, encoder |
Inner layers are 1 oz. Power runs on the 2 oz outer layers; every signal layer sits next to a plane.
| Rule | JLCPCB minimum (2 oz) | This board |
|---|---|---|
| Track / gap | 0.15 / 0.15 mm | 0.2 / 0.15 mm (0.15 mm only at fine-pitch pins) |
| Via diameter / hole | 0.25 / 0.15 mm | 0.45 / 0.2 mm |
| Copper to board edge | 0.2 mm | 0.5 mm |
| Net class | Width | Gap |
|---|---|---|
| Signals | 0.2 mm | 0.15 mm |
| Gate drive | 0.3 mm | 0.15 mm |
| High voltage (VBUS, phases) | 0.5 mm, power in pours | 0.2 mm |
| CAN pair | 0.2 mm | 0.2 mm between the pair |
foc-control/
├── foc-control.kicad_pro        KiCad 10 project (open this)
├── foc-control.kicad_sch        Root schematic (links the 6 sheets below)
├── can_connectors.kicad_sch     XT30 connectors, MCP2562FD CAN FD transceiver, termination
├── encoder.kicad_sch            AS5047P magnetic encoder
├── MCU.kicad_sch                STM32G474, clock, decoupling, reset/boot, SWD pads
├── power_rails.kicad_sch        12 V and 5 V bucks (LM5164), 3.3 V LDO
├── gate_driver.kicad_sch        DRV8353 gate driver
├── power_stage.kicad_sch        3 half-bridges, shunts, bus capacitors, VBUS sense, NTC
├── foc-control.kicad_pcb        Ø80 mm, 8-layer board layout
├── fp-lib-table                 Project footprint libraries (points to libs/)
├── sym-lib-table                Project symbol libraries (points to libs/)
├── libs/
│   ├── foc-control.kicad_sym    DRV8353 symbol
│   ├── DRV8353.pretty/          DRV8353 footprint (WQFN-40)
│   ├── XT30/                    XT30PW 2+2 symbol, footprint and 3D model
│   └── logo.pretty/             Board logo
├── bom/
│   └── foc-control.csv          Bill of materials
└── docs/
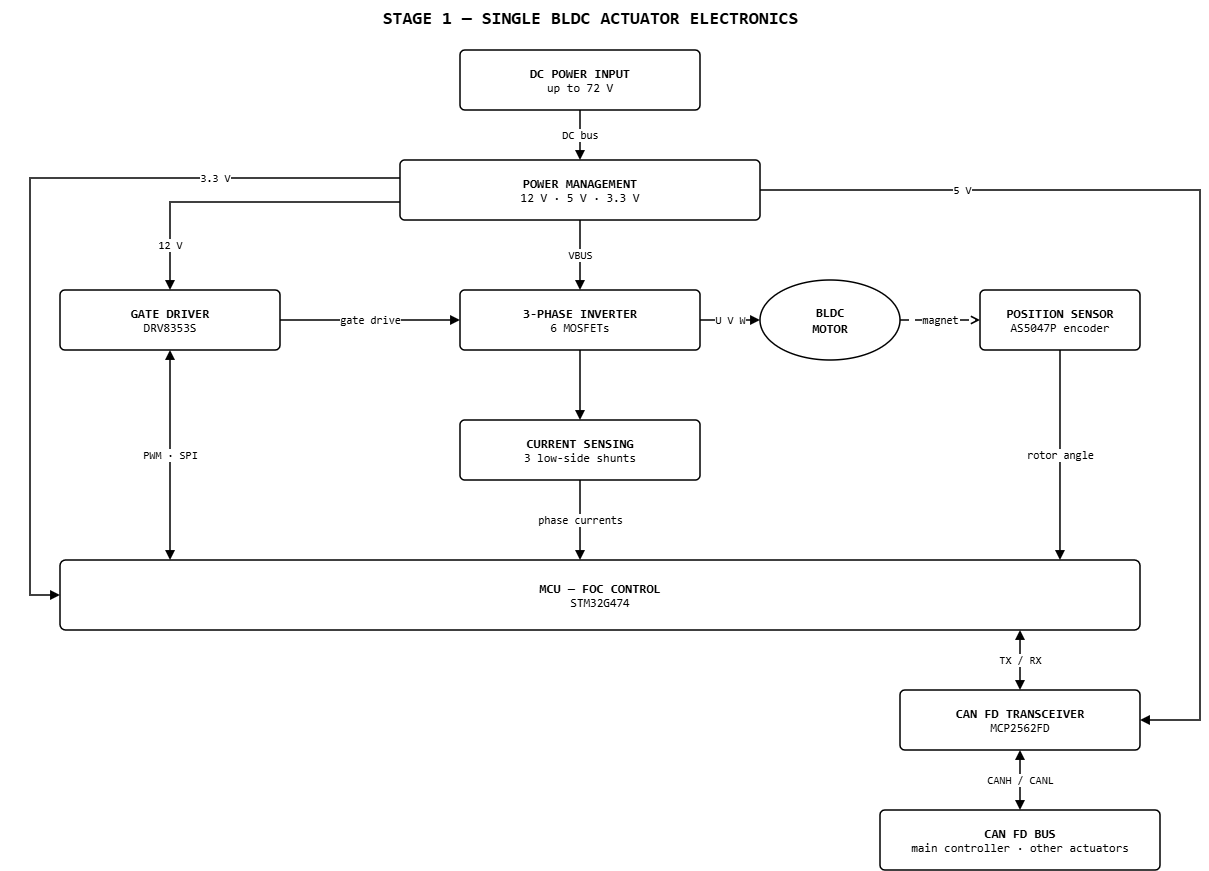
    ├── Stage1/Stage1.drawio.png Stage 1 block diagram (single actuator)
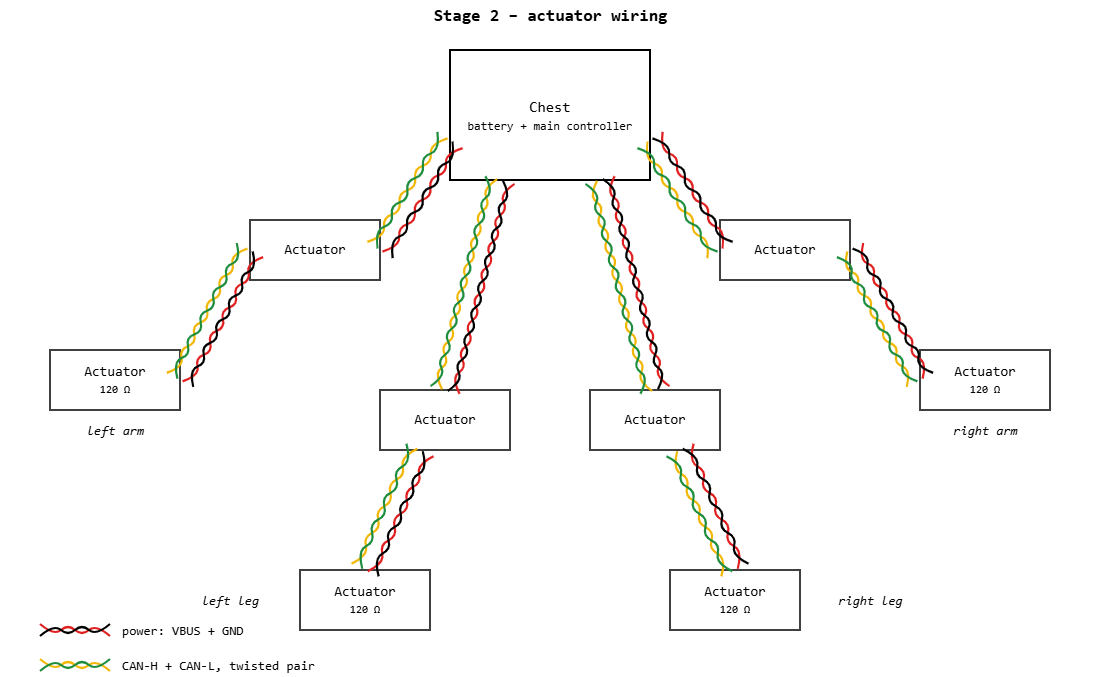
    ├── Stage2/Stage2.drawio.png Stage 2 wiring diagram (multiple actuators)
└── img/ 3D renders of the board (top, bottom)| Qty | Value | Footprint | References |
|---|---|---|---|
| 13 | 100 nF 16V X7R | Capacitor_SMD:C_0603_1608Metric | C1, C2, C3, C4, C6, C7, C8, C9, C10, C12, C16, C40, C47 |
| 7 | 1 µF 16V X7R | Capacitor_SMD:C_0603_1608Metric | C5, C13, C31, C32, C35, C38, C39 |
| 7 | 2.2 µF 100V X7R | Capacitor_SMD:C_1210_3225Metric | C17, C18, C24, C25, C41, C42, C43 |
| 6 | BSC040N10NS5ATMA1 | Package_TO_SOT_SMD:TDSON-8-1 | Q1, Q2, Q3, Q4, Q5, Q6 |
| 4 | 10 kΩ | Resistor_SMD:R_0603_1608Metric | R2, R3, R14, R15 |
| 4 | MountingHole_3.2mm_M3 | MountingHole:MountingHole_3.2mm_M3 | H1, H2, H3, H4 |
| 3 | 1mΩ 1W WSL25121L000FEA | Resistor_SMD:R_2512_6332Metric | R17, R18, R19 |
| 3 | NetTie_2 | NetTie:NetTie-2_SMD_Pad0.5mm | NT1, NT2, NT3 |
| 2 | 2.2 nF 50V X7R | Capacitor_SMD:C_0603_1608Metric | C19, C26 |
| 2 | 22 µF 16V X7R | Capacitor_SMD:C_1210_3225Metric | C28, C30 |
| 2 | 22 µF 25V X7R | Capacitor_SMD:C_1210_3225Metric | C22, C23 |
| 2 | 27 pF 50V C0G | Capacitor_SMD:C_0603_1608Metric | C14, C15 |
| 2 | 3.3 nF 50V X7R | Capacitor_SMD:C_0603_1608Metric | C20, C27 |
| 2 | 47 µF 100V | Capacitor_SMD:CP_Elec_10x10 | C44, C45 |
| 2 | 49.9 kΩ 1% | Resistor_SMD:R_0603_1608Metric | R6, R11 |
| 2 | 68 µH | Inductor_SMD:L_Bourns_SRN6045TA | L1, L2 |
| 2 | LM5164DDAR | Package_SO:HSOP-8-1EP_3.9x4.9mm_P1.27mm_EP2.41x3.1mm_ThermalVias | U4, U5 |
| 1 | +3V3 | TestPoint:TestPoint_Pad_D1.0mm | TP4 |
| 1 | 10 nF 16V X7R | Capacitor_SMD:C_0603_1608Metric | C46 |
| 1 | 10 µF 16V X5R | Capacitor_SMD:C_0603_1608Metric | C11 |
| 1 | 10 µF 25V X7R | Capacitor_SMD:C_1206_3216Metric | C34 |
| 1 | 100 nF 25V X7R | Capacitor_SMD:C_0603_1608Metric | C33 |
| 1 | 100k | Resistor_SMD:R_0603_1608Metric | R16 |
| 1 | 100k 1% | Resistor_SMD:R_0603_1608Metric | R4 |
| 1 | 100k 1% | Resistor_SMD:R_1206_3216Metric | R20 |
| 1 | 10k 1% | Resistor_SMD:R_0603_1608Metric | R22 |
| 1 | 120 Ω 1% | Resistor_SMD:R_0603_1608Metric | R1 |
| 1 | 158k 1% | Resistor_SMD:R_0603_1608Metric | R10 |
| 1 | 180 pF 50V C0G | Capacitor_SMD:C_0603_1608Metric | C29 |
| 1 | 1M 1% | Resistor_SMD:R_0805_2012Metric | R12 |
| 1 | 200k 1% | Resistor_SMD:R_0805_2012Metric | R9 |
| 1 | 3.3k 1% | Resistor_SMD:R_0603_1608Metric | R21 |
| 1 | 41.2k 1% | Resistor_SMD:R_0603_1608Metric | R8 |
| 1 | 453 kΩ 1% | Resistor_SMD:R_0603_1608Metric | R5 |
| 1 | 453k 1% | Resistor_SMD:R_0805_2012Metric | R7 |
| 1 | 47 nF 100V X7R | Capacitor_SMD:C_0805_2012Metric | C36 |
| 1 | 56 pF 50V C0G | Capacitor_SMD:C_0603_1608Metric | C21 |
| 1 | 82k 1% | Resistor_SMD:R_0603_1608Metric | R13 |
| 1 | ABM3B-8.000MHZ-B2-T | Crystal:Crystal_SMD_Abracon_ABM3B-4Pin_5.0x3.2mm | Y1 |
| 1 | AP2112K-3.3 | Package_TO_SOT_SMD:SOT-23-5 | U6 |
| 1 | AS5047P-ATSM | Package_SO:TSSOP-14_4.4x5mm_P0.65mm | U2 |
| 1 | BUS_IN | XT30:CONN-TH_4P-XT30PW-M | J1 |
| 1 | BUS_OUT | XT30:CONN-TH_4P-XT30PW-M | J2 |
| 1 | CAN_TERM | Jumper:SolderJumper-2_P1.3mm_Open_RoundedPad1.0x1.5mm | JP1 |
| 1 | DRV8353SRTAR | DRV8353:RTA0040B | U7 |
| 1 | GND | TestPoint:TestPoint_Pad_D1.0mm | TP5 |
| 1 | LOGO | logo:sujay_logo | G*** |
| 1 | MCP2562FD-E/SN | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U1 |
| 1 | MOTOR_A | Connector_Wire:SolderWire-1.5sqmm_1x01_D1.7mm_OD3.9mm | J3 |
| 1 | MOTOR_B | Connector_Wire:SolderWire-1.5sqmm_1x01_D1.7mm_OD3.9mm | J4 |
| 1 | MOTOR_C | Connector_Wire:SolderWire-1.5sqmm_1x01_D1.7mm_OD3.9mm | J5 |
| 1 | NRST | TestPoint:TestPoint_Pad_D1.0mm | TP1 |
| 1 | NTC 10k | Resistor_SMD:R_0603_1608Metric | TH1 |
| 1 | STM32G474RET3 | Package_QFP:LQFP-64_10x10mm_P0.5mm | U3 |
| 1 | SWCLK | TestPoint:TestPoint_Pad_D1.0mm | TP3 |
| 1 | SWDIO | TestPoint:TestPoint_Pad_D1.0mm | TP2 |
darshp848/bldc-controller-60v
60 V, 20 A / 80 A peak BLDC motor controller that fits the MD80 v3.0 mounting. KiCad 10, 6 layers.

magic-alt/fpga-servo
This directory preserves the ADS8588S legacy PCB, native project and custom rules from b0172a2f65902c7281cf4a8454f192dc791a9ef9.

kquinsland/modular-rack-mount-power-system
Hardware, firmware, and host tooling for a modular mini-rack power system.

ishaansalian/dash-motor-controller
Motor control PCB for the Dash humanoid robot project.


oiver12/VariometerV2
Paragliding variometer: custom KiCad PCBs, ESP32 firmware, sensor fusion, e-ink UI, and desktop flight replay.


nguyen-v/KiBot_Project_Test
A test project for the video tutorial using KDT_Hierarchical_KiBot template
104 parts, built around the STM32G474RET3, MCP2562FD-E/SN, LM5164DDAR and AS5047P-ATSM. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the sujaygouda123/foc-control repository on GitHub, at the commit this page was made from: the board is foc-control.kicad_pcb and its schematic MCU.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask sujaygouda123 before reusing the design.