Amulet controller
aidanbrzezinski/Prism-test
ΛMULET is a high-power brushless motor controller, compatible with the moteus firmware. It was specifically designed to be integrated in EPFL Xplore's Legged Robot actuators.

A test project for the video tutorial using KDT_Hierarchical_KiBot template
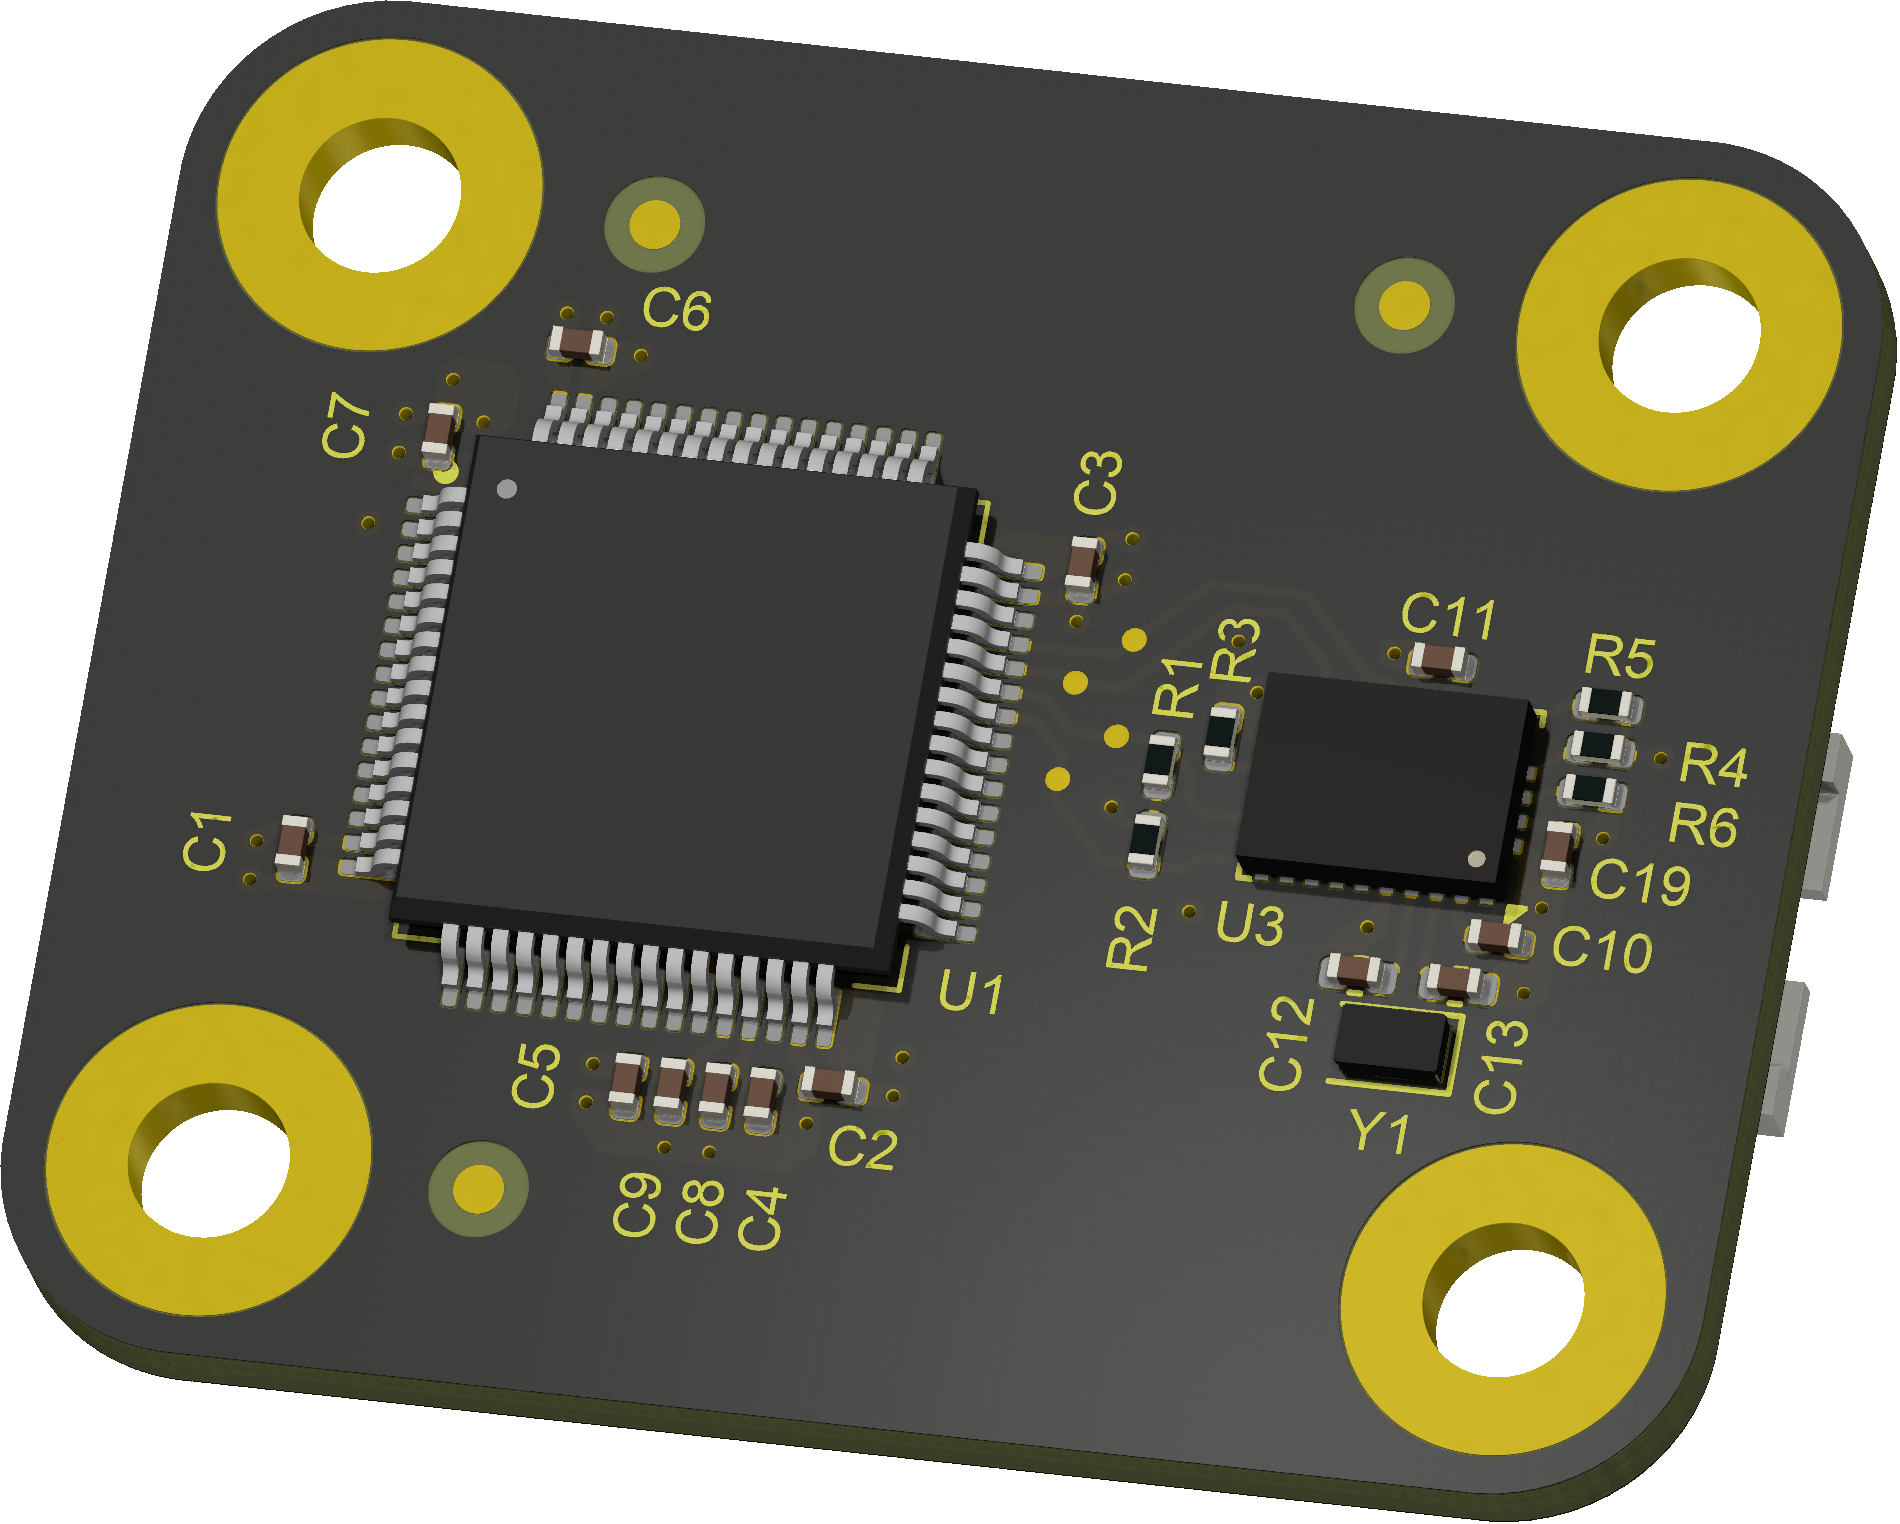
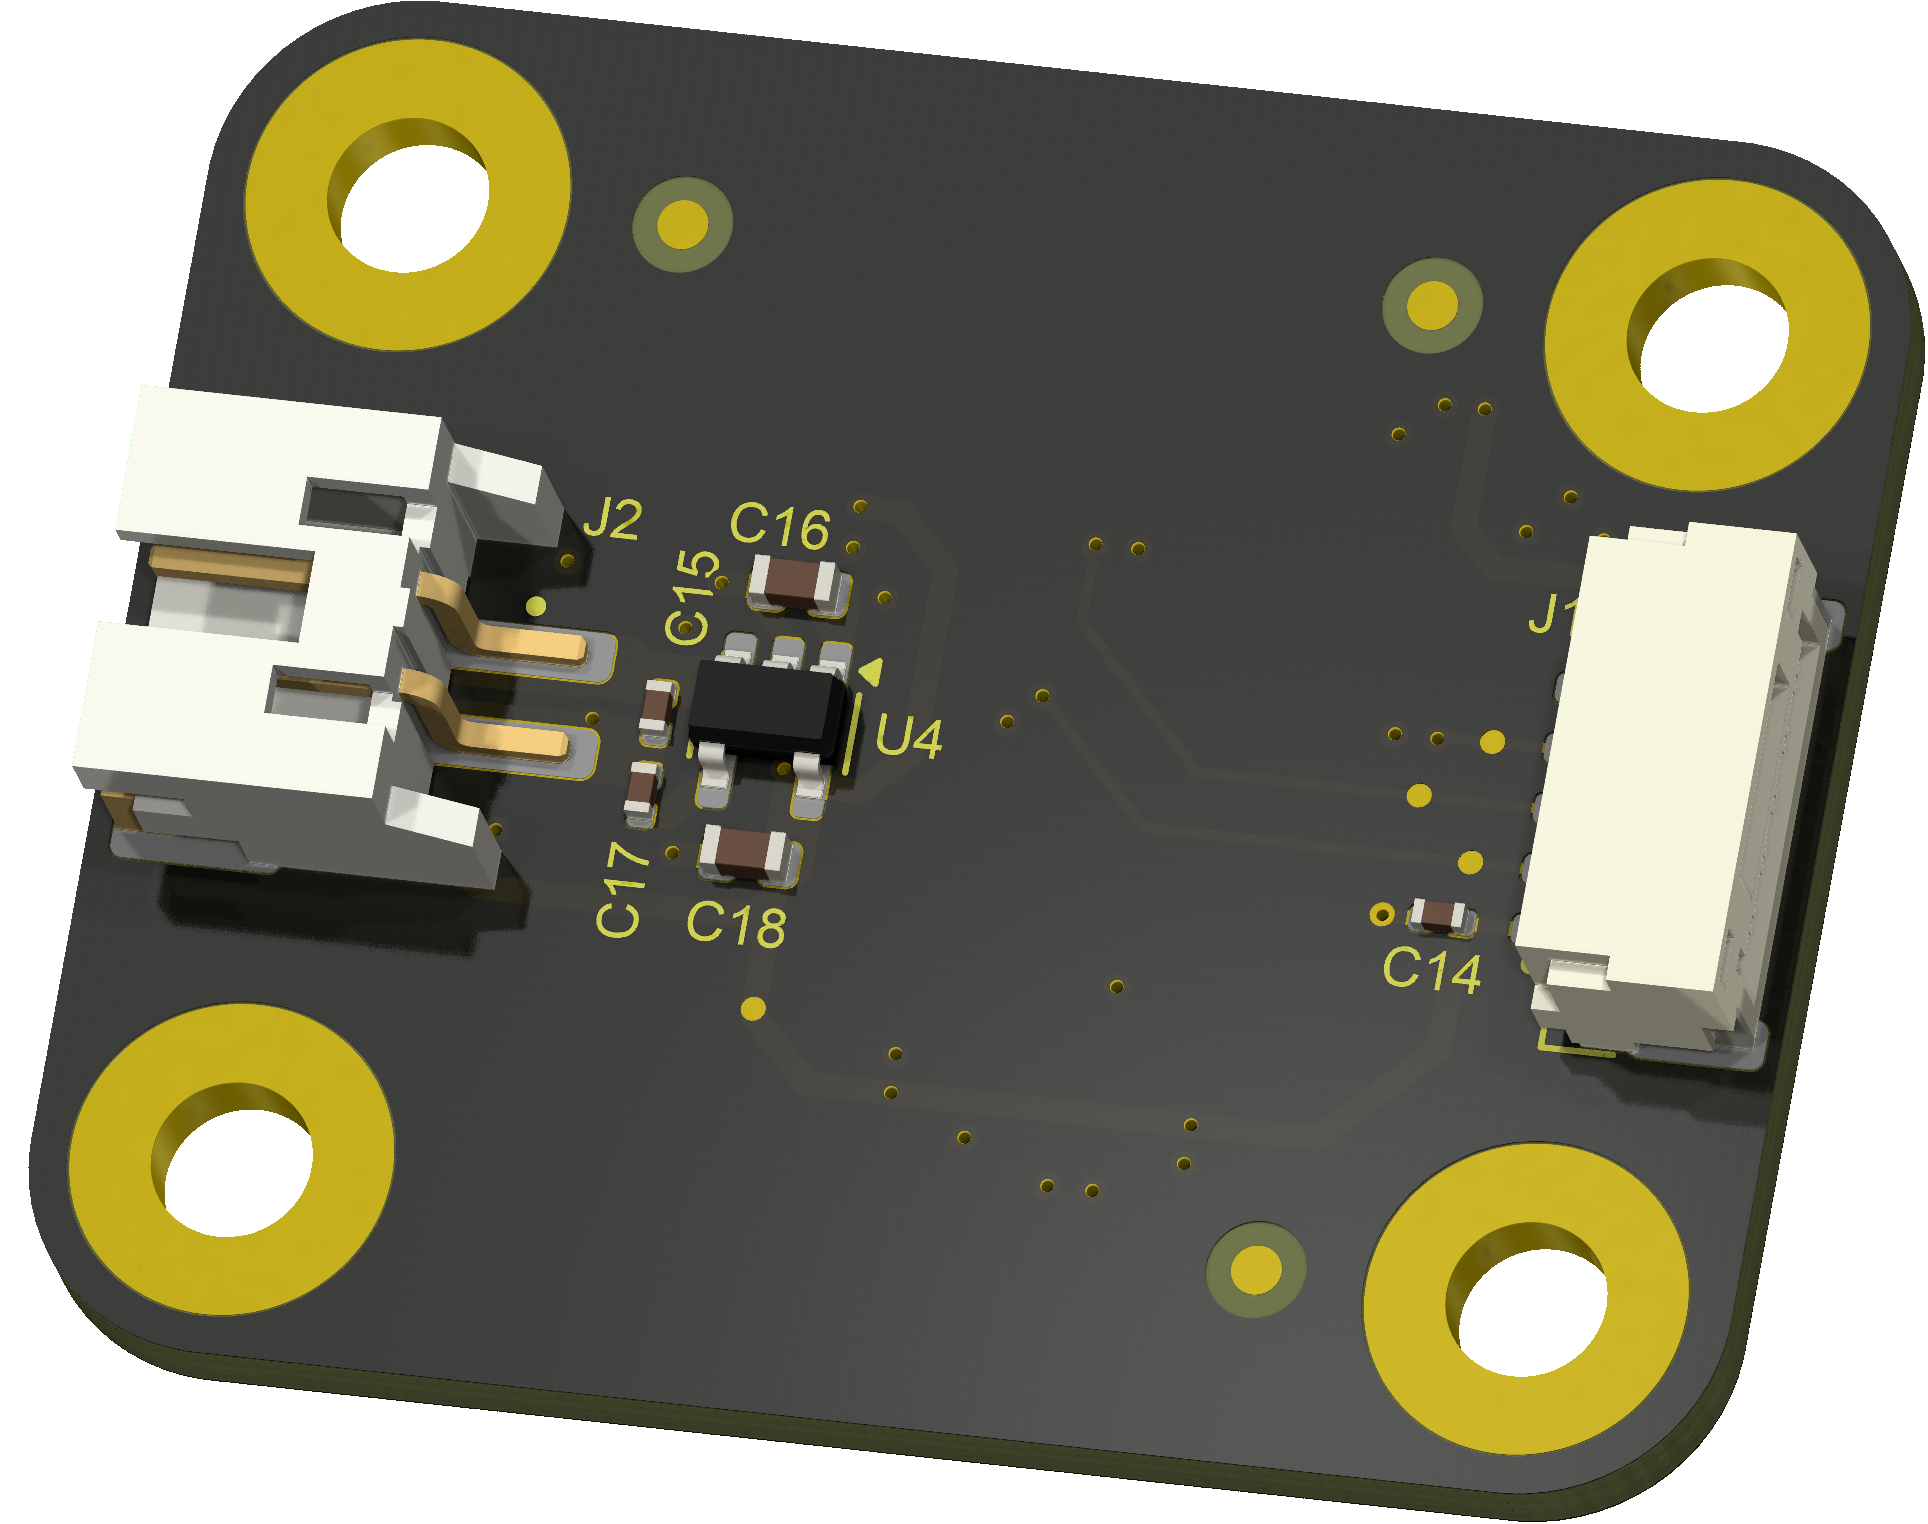
KiBot Project Test is an open-source printed circuit board by nguyen-v, from the nguyen-v/KiBot_Project_Test repository on GitHub, published under the MIT licence. It is a 4-layer board of 34 × 28 mm with 50 parts on 63 nets, routed with 172 tracks and 39 vias.
It is built around the STM32G474RET3, BNO055 and RT0402FRE0710KL, with the 500R07S3R9BV4T, HMR105B7103KV-F and TMK107AB7105KAHT among its other parts. Its parts include 19 capacitors, 6 resistors, 3 ICs, 2 connectors and 1 crystal. It belongs with the STM32 boards of this library.
| Parameter | Value |
|---|---|
| Dimensions | 34.0 × 28.0 mm |
.
├─ Computations # Misc calculations
├─ HTML # HTML files for generated webpage
├─ Images # Pictures and renders
│
├─ kibot_resources # External resources for KiBot
│ ├─ colors # Color theme for KiCad
│ ├─ fonts # Fonts used in the project
│ ├─ scripts # External scripts used with KiBot
│ └─ templates # Templates for KiBot generated reports
│
├─ kibot_yaml # KiBot YAML config files
├─ KiRI # KiRI (PCB diff viewer) files
│
├─ lib # KiCad footprint and symbol libraries
│ ├─ 3d_models # Component 3D models
│ ├─ lib_fp # Footprint libraries
│ └─ lib_sym # Symbol libraries
│
├─ Logos # Logos
│
├─ Manufacturing # Assembly and fabrication documents
│ ├─ Assembly # Assembly documents (BoM, pos, notes)
│ │| Qty | Value | Footprint | References |
|---|---|---|---|
| 11 | 100n X7R 50V | 0_capacitor_smd:C_0402_1005_DensityHigh | C1, C2, C3, C6, C8, C9, C10, C11, C14, C15, C19 |
| 9 | TestPoint | 0_testpoint:TestPoint_Pad_D0.5mm | TP1, TP2, TP3, TP4, TP5, TP6, TP7, TP8, TP9 |
| 6 | Fiducial | 0_fiducials:Fiducial_1mm_Mask2mm | FD1, FD2, FD3, FD4, FD5, FD6 |
| 4 | 10k 1% | 0_resistor_smd:R_0402_1005_DensityHigh | R3, R4, R5, R6 |
| 4 | M3 | MountingHole:MountingHole_3.2mm_M3_Pad | H1, H2, H3, H4 |
| 2 | 1u X7R 10V | 0_capacitor_smd:C_0402_1005_DensityHigh | C4, C7 |
| 2 | 2k 1% | 0_resistor_smd:R_0402_1005_DensityHigh | R1, R2 |
| 2 | 3.9pF | Capacitor_SMD:C_0402_1005Metric | C12, C13 |
| 1 | 10n X7R 100V | 0_capacitor_smd:C_0402_1005_DensityHigh | C17 |
| 1 | 1u X7R 25V | 0_capacitor_smd:C_0603_1608_DensityHigh | C16 |
| 1 | 4u7 X5R 25V | 0_capacitor_smd:C_0402_1005_DensityHigh | C5 |
| 1 | 4u7 X7R 16V | 0_capacitor_smd:C_0603_1608_DensityHigh | C18 |
| 1 | BNO055 | Package_LGA:LGA-28_5.2x3.8mm_P0.5mm | U3 |
| 1 | ECS-.327-7-12-C-TR9 | Crystal:Crystal_SMD_2012-2Pin_2.0x1.2mm | Y1 |
| 1 | LP2992IM5-3.3/NOPB | Package_TO_SOT_SMD:SOT-23-5 | U4 |
| 1 | S2B-PH-SM4-TB | 0_connectors:JST_PH_S2B-PH-SM4-TB_1x02-1MP_P2.00mm_Horizontal | J2 |
| 1 | SM05B-GHS-TB | 0_connectors:JST_GH_SM05B-GHS-TB_1x05-1MP_P1.25mm_Horizontal | J1 |
| 1 | STM32G474RET3 | 0_package_QFP:LQFP-64_10x10mm_P0.5mm | U1 |

aidanbrzezinski/Prism-test
ΛMULET is a high-power brushless motor controller, compatible with the moteus firmware. It was specifically designed to be integrated in EPFL Xplore's Legged Robot actuators.

EPFLXplore/XRE_LeggedRobot_HW
PCB designs for Xplore Research's robot dog project


mekiciepcas/ESC-Ai
100 × 80 mm, 4 katman; 38 elektriksel bileşen, 192 pad. 22 iz segmenti, 120 açık bağlantı, mevcut kurallarla DRC 0 ihlal. C1801–C1804 dijital bypass çiftleri MCU pinlerine bağlı.


sujaygouda123/foc-control
BLDC field-oriented-control board for a humanoid robot actuator. KiCad 10, Ø80 mm, 8 layers, 1.6 mm.

oresat/oresat-adcs-hardware
Controller PCB for OreSat reaction wheels, magnetorquers, IMU, and magnetometers
It measures 34 × 28 mm and has 4 copper layers, 1.65 mm thick.
50 parts, built around the STM32G474RET3, BNO055, RT0402FRE0710KL and 500R07S3R9BV4T. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the nguyen-v/KiBot_Project_Test repository on GitHub, at the commit this page was made from: the board is KiBot_Project_Test.kicad_pcb and its schematic Block Diagram.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).