4 layers82 × 82 mm
 someonelse20/Shadowfax
FPV Drone designed from scrach.
Flight controller is an open-source printed circuit board by someonelse20, from the someonelse20/Shadowfax repository on GitHub. It is a 4-layer board of 40 × 40 mm with 57 parts on 71 nets, routed with 401 tracks and 140 vias.
It is built around the BMP384, MMC5983MA and LSM6DSV, with the MIC5504-3.3YM5 among its other parts. Its parts include 25 capacitors, 9 connectors, 7 resistors, 5 ICs and 3 diodes. It belongs with the robots and motor control boards and the STM32 boards of this library.


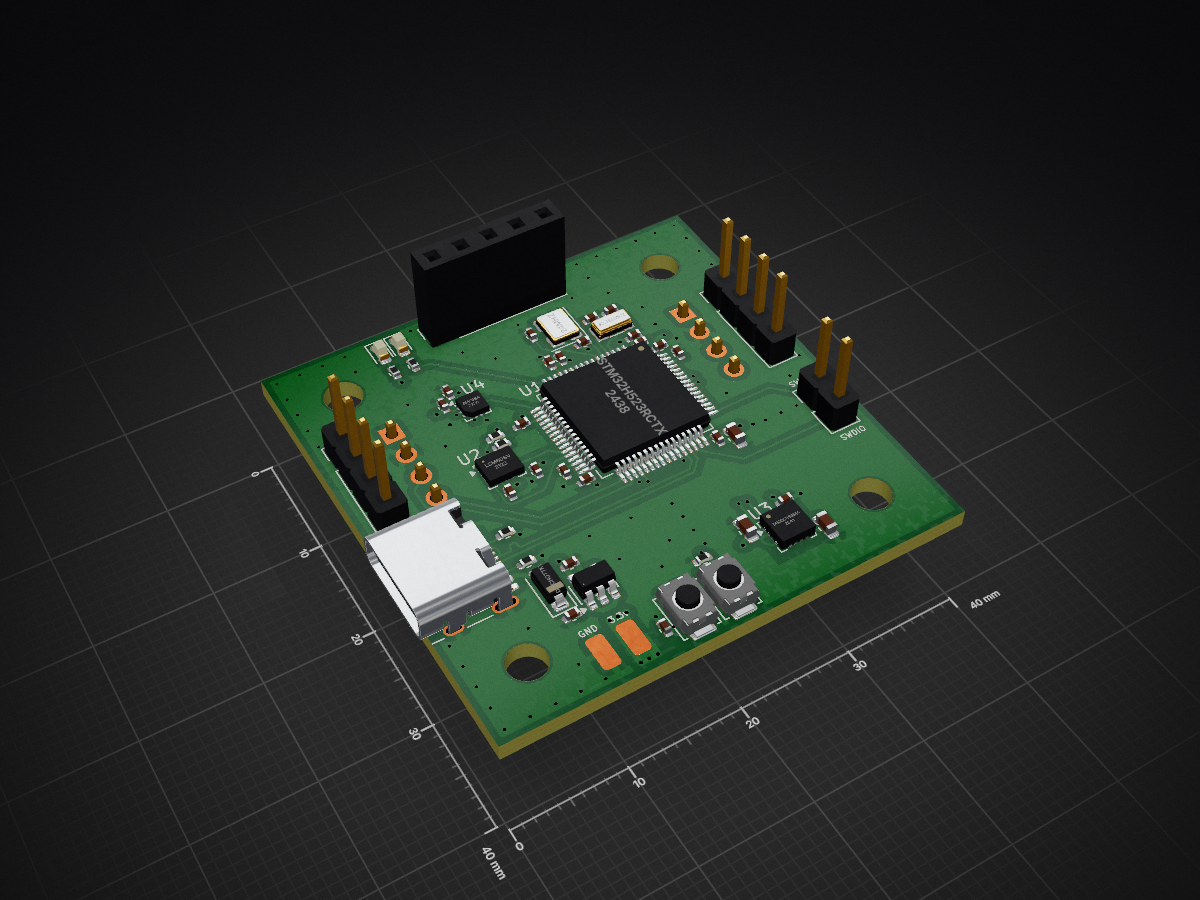
FPV Drone designed from scrach. This design isn't fully custom yet but will get there eventually. I started this project to make a cool drone and learn as much as I can about engineering.
The meat and potatios, the main computer for the drone.
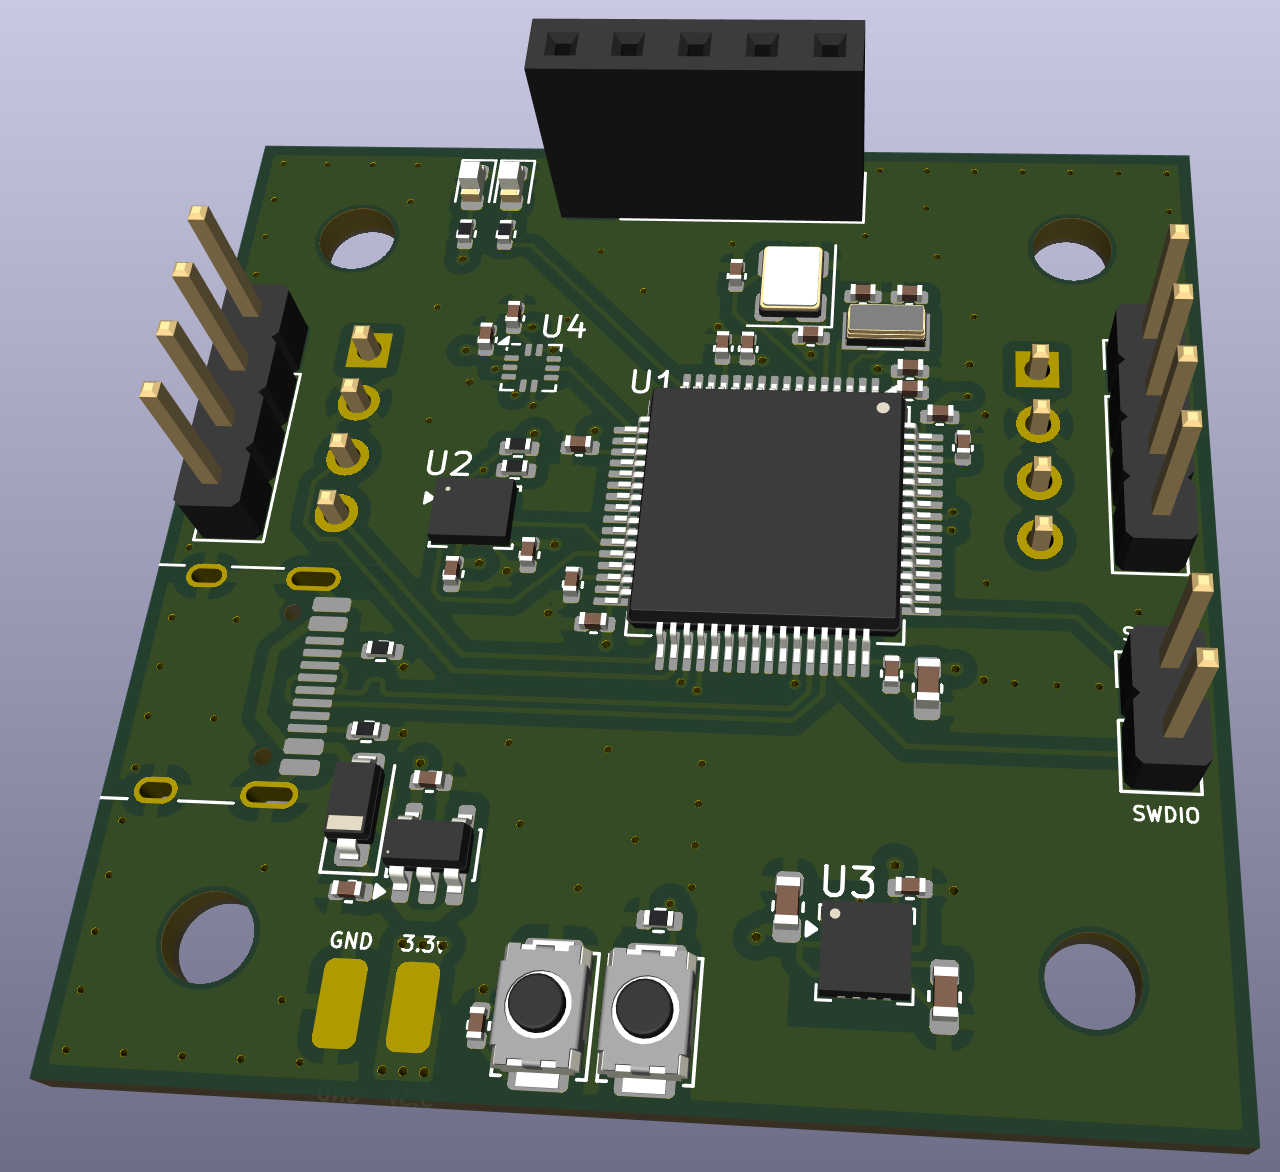
A low frequency radio to communicate with a remote controller.
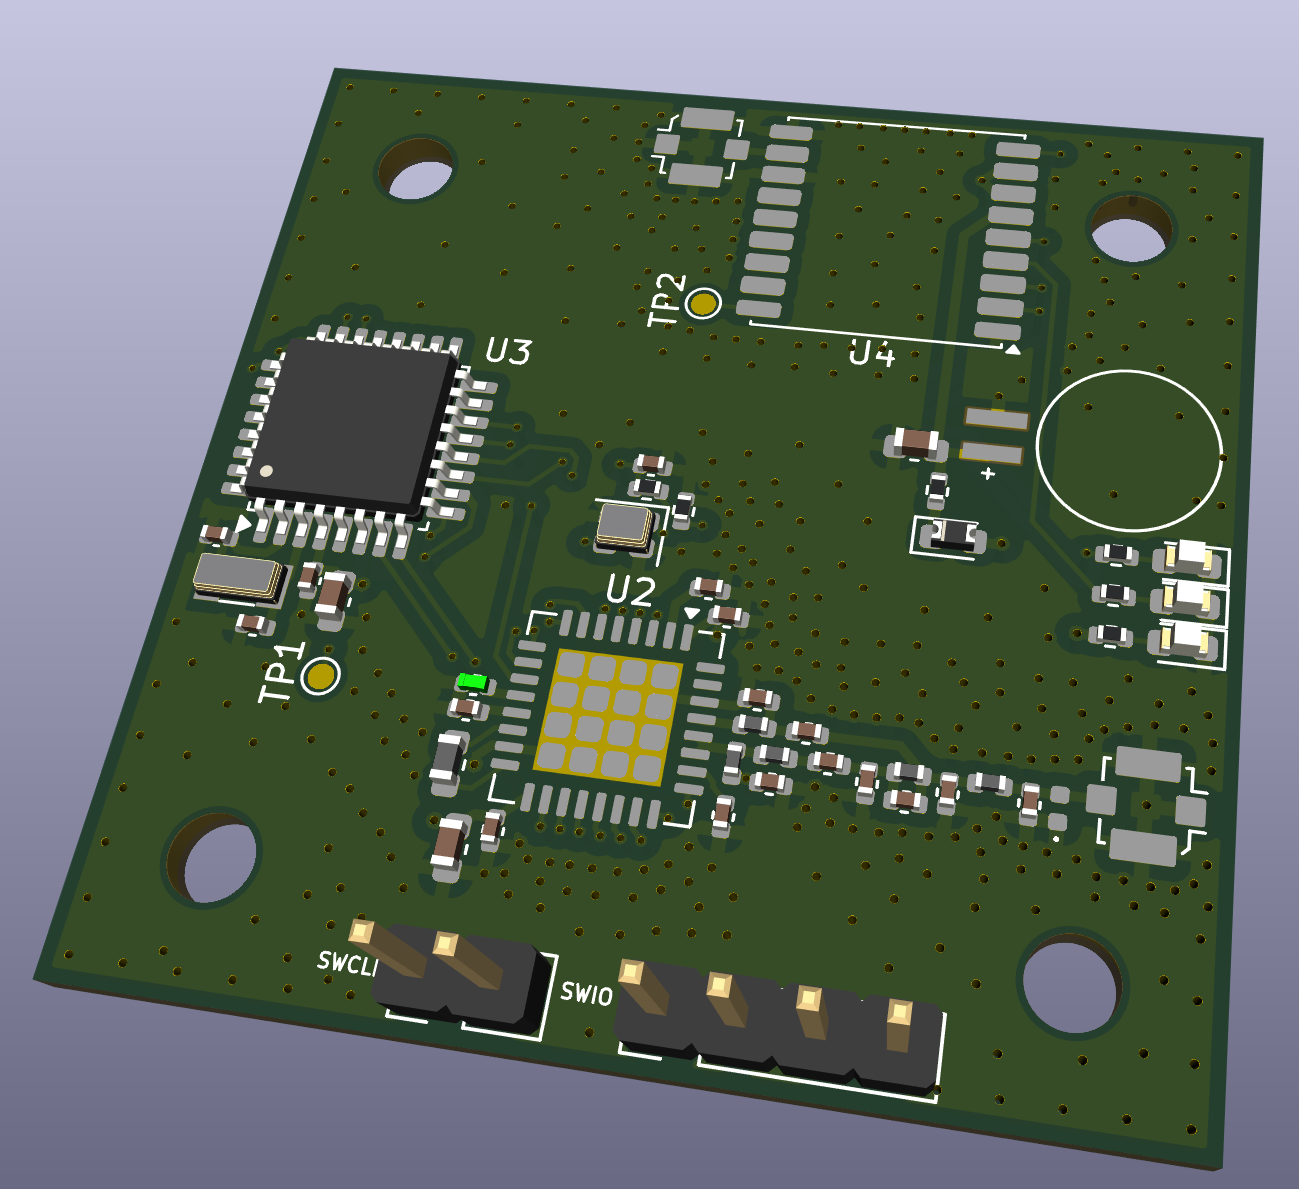
Controls the camera and captures videos and pictures with a high frequency radio for faster communication.
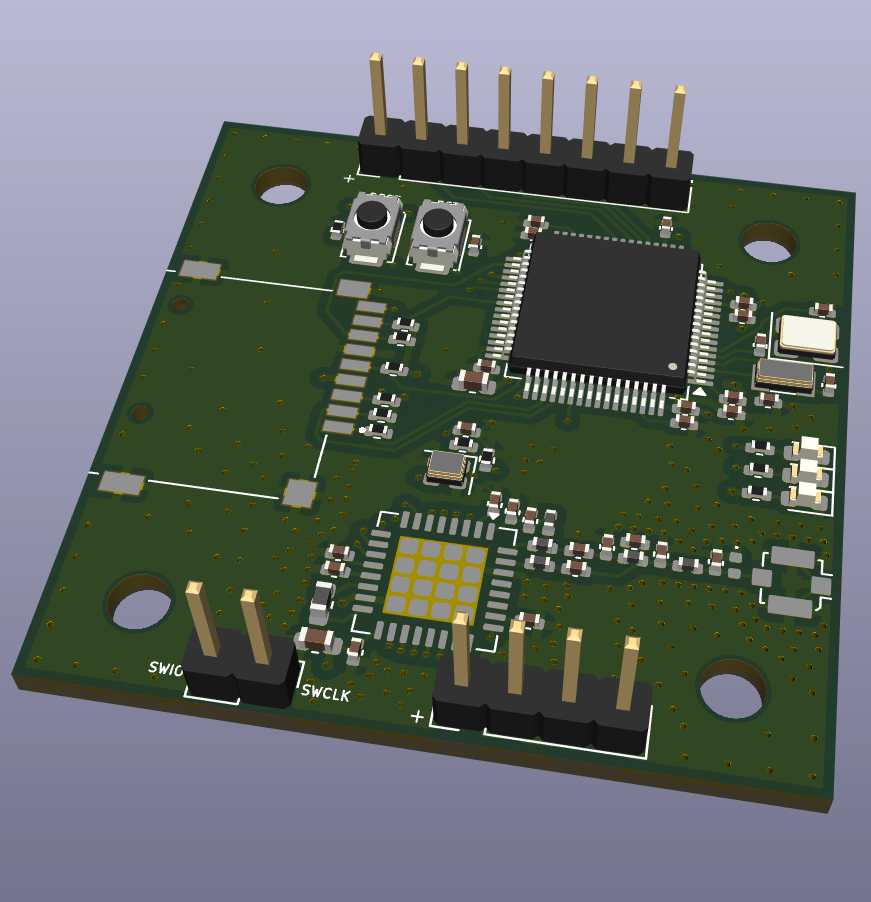
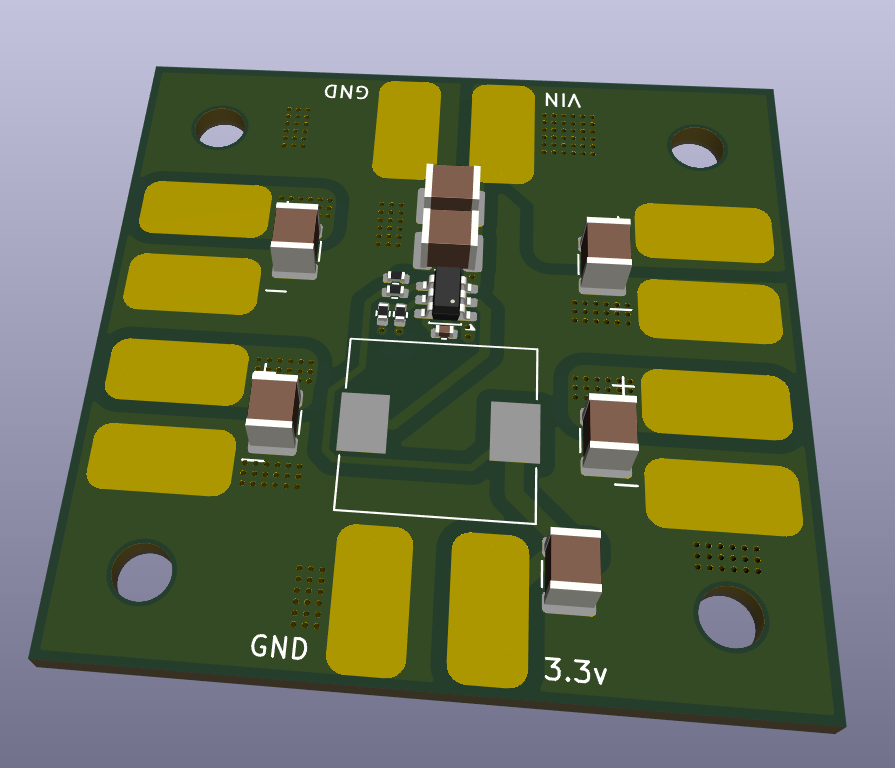
Powers the whole stack with 3.3v and connects the ESCs to the input voltage.
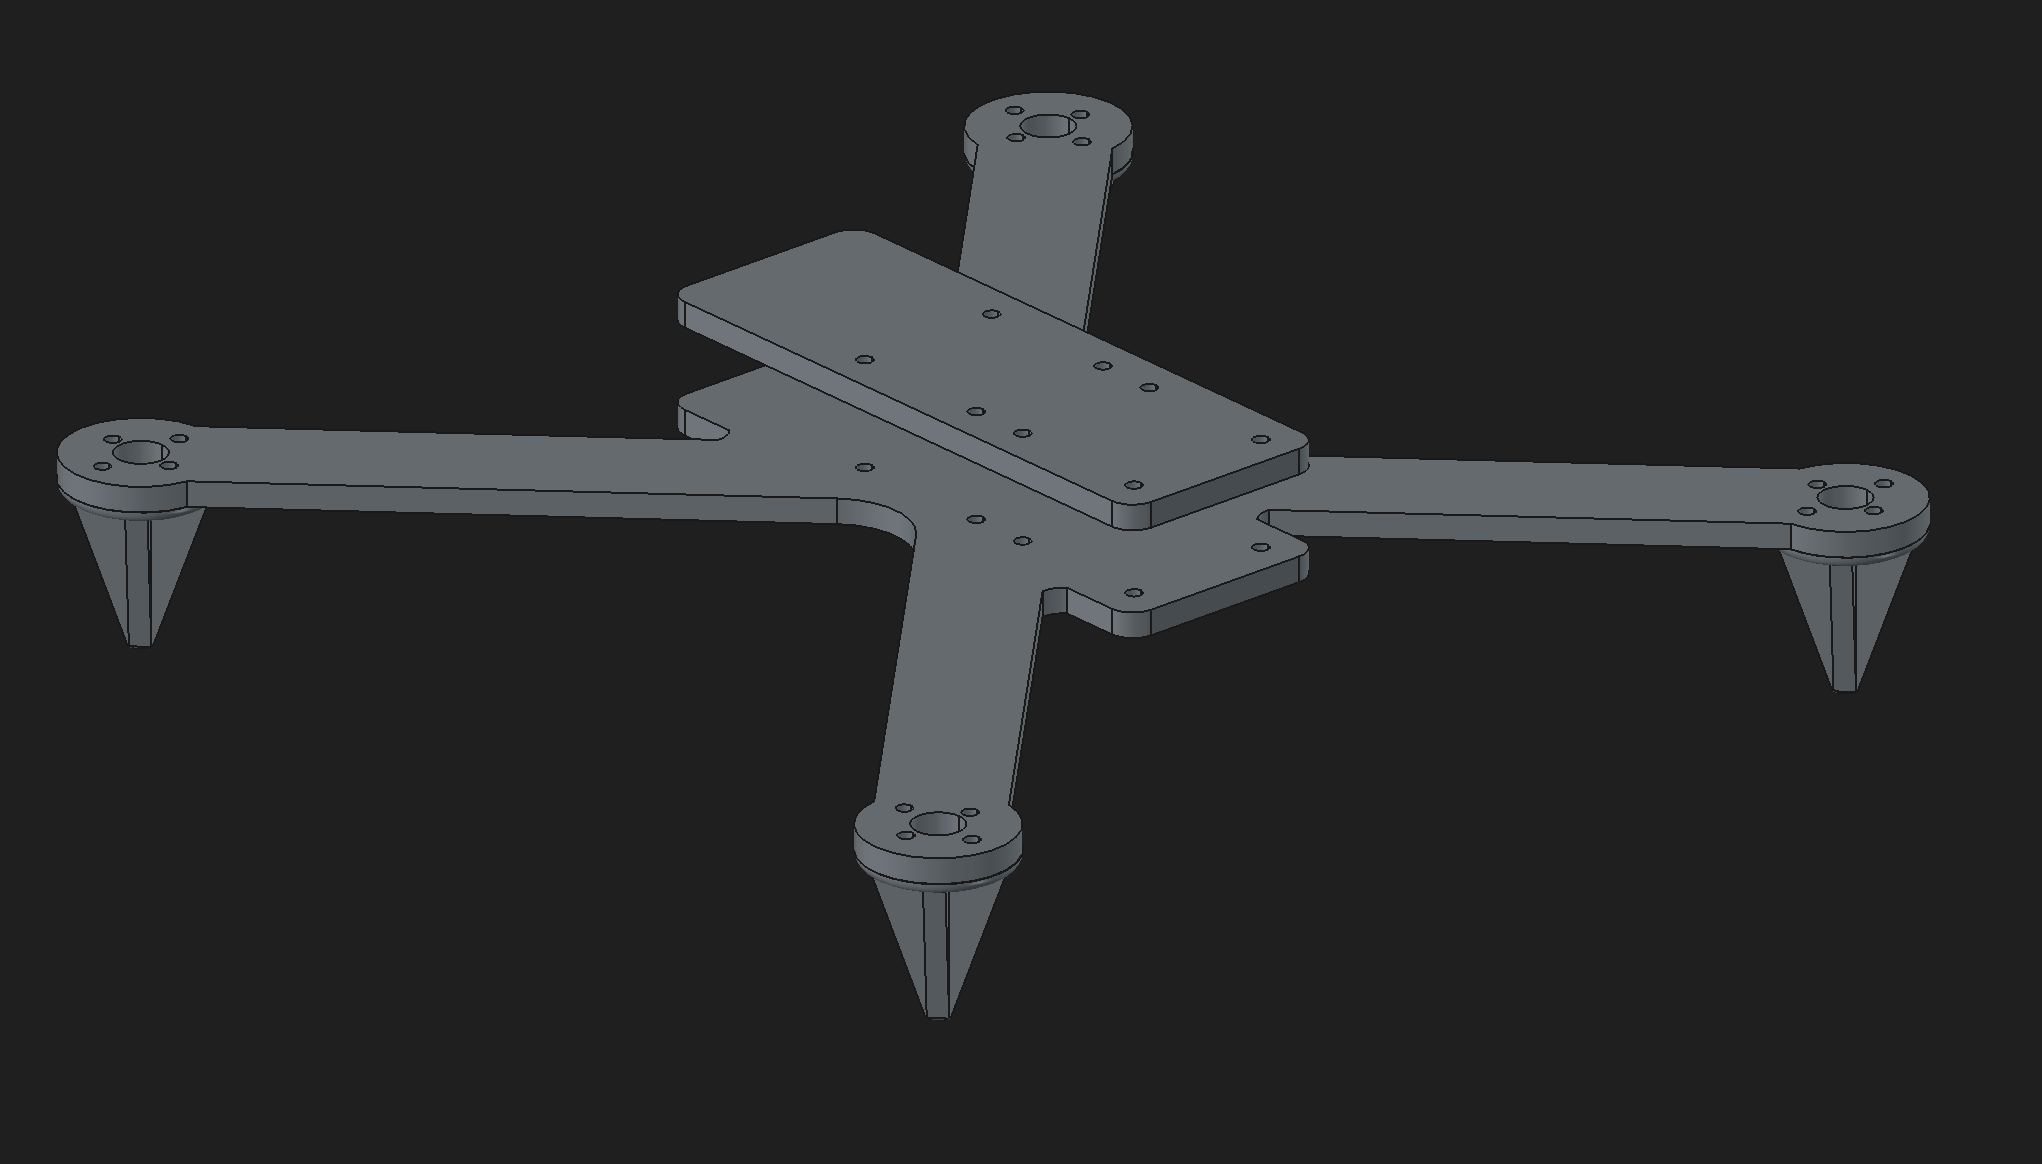
I made a custom frame to fit my custom boards and here it is.
| Name | Purpose | Quantity | Total Cost (USD) | Link | Distributor |
|---|---|---|---|---|---|
| Flight Controller Assembly | Assemble components for the flight controller | 2 | 42.44 | https://jlcpcb.com | JLCPCB |
| Flight Controller Board | The pcb for the flight controller | 5 | 2.00 | https://jlcpcb.com | JLCPCB |
| Power Board Assembly | Assemble components for the power board | 2 | 14.79 | https://jlcpcb.com | JLCPCB |
| Power Board | The pcb for the power board | 5 | 7.00 | https://jlcpcb.com | JLCPCB |
| Transceiver Assmebly | Assemble components for the board | 2 | 51.31 | https://jlcpcb.com | JLCPCB |
| Transceiver Board | The pcb for the transceiver | 5 | 7.00 | https://jlcpcb.com | JLCPCB |
| Camera Controller Assembly | Assemble components for the board | 2 | 34.63 | https://jlcpcb.com | JLCPCB |
| Camera Controller Board | The pcb for the camera controller | 5 | 7.00 | https://jlcpcb.com | JLCPCB |
| Qty | Value | Footprint | References |
|---|---|---|---|
| 12 | 100nF | Capacitor_SMD:C_0402_1005Metric | C4, C6, C7, C8, C11, C12, C18, C20, C24, C25, C27, C29 |
| 4 | 1uF | Capacitor_SMD:C_0402_1005Metric | C19, C21, C22, C23 |
| 4 | Conn_01x04 | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J2, J3, J4, J5 |
| 2 | 1.2K | Resistor_SMD:R_0402_1005Metric | R4, R5 |
| 2 | 15pF | Capacitor_SMD:C_0402_1005Metric | C10, C13 |
| 2 | 18pF | Capacitor_SMD:C_0402_1005Metric | C9, C14 |
| 2 | 1K | Resistor_SMD:R_0402_1005Metric | R13, R15 |
| 2 | 2.2uF | Capacitor_SMD:C_0402_1005Metric | C26, C28 |
| 2 | 5.1K | Resistor_SMD:R_0402_1005Metric | R1, R2 |
| 2 | Conn_01x01 | Connector_Wire:SolderWirePad_1x01_SMD_1.5x3mm | J8, J9 |
| 2 | LED | LED_SMD:LED_0603_1608Metric | D1, D2 |
| 2 | SW_Push | Button_Switch_SMD:SW_Push_SPST_NO_Alps_SKRK | BOOT1, RESET1 |
| 1 | 10K | Resistor_SMD:R_0402_1005Metric | R3 |
| 1 | 10uF | Capacitor_SMD:C_0603_1608Metric | C5 |
| 1 | 1uF | Capacitor_SMD:C_0603_1608Metric | C1 |
| 1 | 24MHz | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y2 |
| 1 | 32.768MHz | Crystal:Crystal_SMD_3215-2Pin_3.2x1.5mm | Y1 |
| 1 | 4.7uF | Capacitor_SMD:C_0603_1608Metric | C30 |
| 1 | BMP384 | Package_LGA:Rohm_MLGA010V020A_LGA-10_2x2mm_P0.45mm_LayoutBorder2x3y | U4 |
| 1 | Conn_01x02 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J7 |
| 1 | Conn_01x05 | Connector_PinSocket_2.54mm:PinSocket_1x05_P2.54mm_Vertical | J6 |
| 1 | D_Schottky | Diode_SMD:D_SOD-123 | D3 |
| 1 | LSM6DSV | Package_LGA:LGA-14_3x2.5mm_P0.5mm_LayoutBorder3x4y | U2 |
| 1 | MIC5504-3.3YM5 | Package_TO_SOT_SMD:SOT-23-5 | U5 |
| 1 | MMC5983MA | Package_LGA:LGA-16_3x3mm_P0.5mm | U3 |
| 1 | STM32H523RCTx | Package_QFP:LQFP-64_10x10mm_P0.5mm | U1 |
| 1 | USB_C_Receptacle_USB2.0_14P | Connector_USB:USB_C_Receptacle_HRO_TYPE-C-31-M-12 | J1 |
The 53 most common of 57 parts.
It measures 40 × 40 mm and has 4 copper layers, 1.6 mm thick.
57 parts, built around the BMP384, MMC5983MA, LSM6DSV and MIC5504-3.3YM5. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the someonelse20/Shadowfax repository on GitHub, at the commit this page was made from: the board is flight-controller/hardware/flight-controller.kicad_pcb and its schematic ESC/hardware/ESC.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask someonelse20 before reusing the design.


williamjroche/Drone_Flight_Controller
This is a GPS-Denied Autonomous Drone that uses computer vision to fly with radio transmission override. Autonomy is a work in progress.


CDonohoe-Designs/EdgeLink_S3_Cellular
EdgeLink S3 Cellular is a four-layer embedded hardware platform combining an ESP32-S3 controller, SIM7080G cellular/GNSS modem, USB-C, battery power management and environmental/motion sensing.


TwoCoolCole12/Half-Life-Week-1-PCB-AmbiSense
A portable environment sensor to sense ambient temperature, humidity, light, movement speed, and more!

danbrunski/canary
Four 25 F cells in series for CANary-PWR's LTC3350 hold-up, on a lead (design record: docs/CANary-PWR-Spec.md §P4). The board has no active parts: four cells, an NTC, two Kelvin net ties and a Micro-Fit 2 × 5 header.
