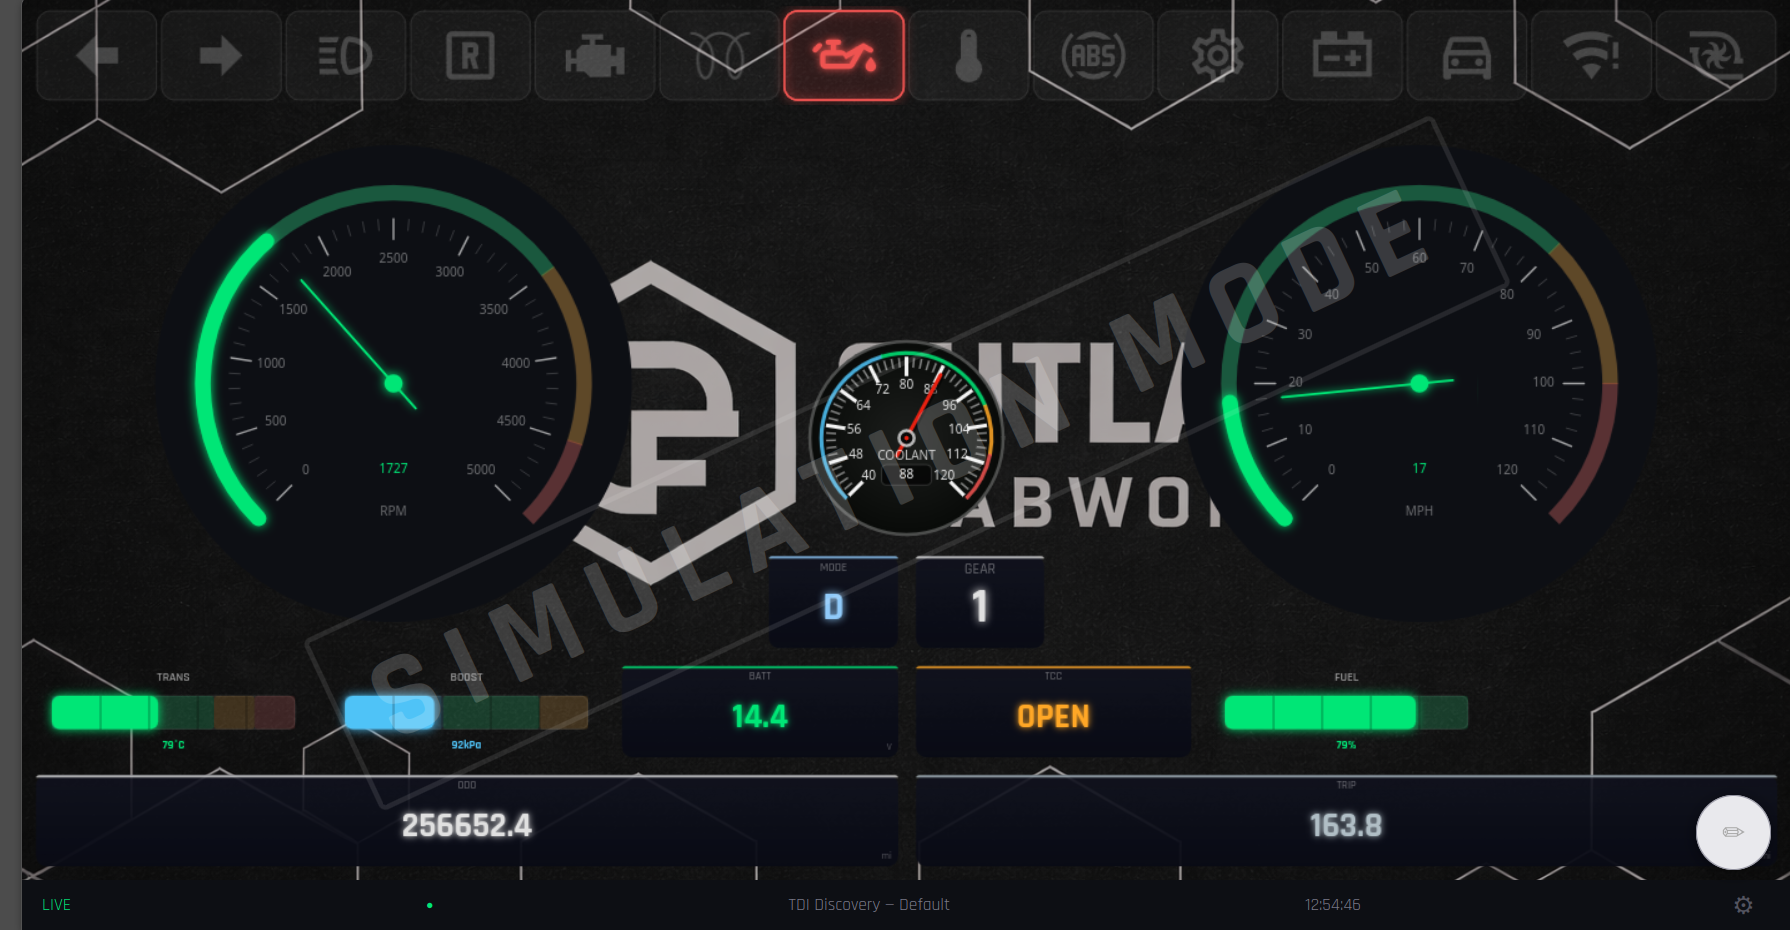
Open-source Raspberry Pi vehicle dashboard. Reads CAN (J1939), OBD-II, Megasquirt/Speeduino, GPS, and GPIO — streams to a canvas-based kiosk frontend with a visual no-code layout editor.
Pi dash input hat is an open-source printed circuit board by outlandfabworks, from the outlandfabworks/overdash repository on GitHub, published under the MIT licence. It is a 2-layer board of 100 × 56.5 mm with 68 parts on 61 nets, routed with 970 tracks and 27 vias.
It is built around the SMAJ15A, DMG2305UX and SB360, with the SMAJ36A among its other parts. Its parts include 25 resistors, 19 diodes, 9 ICs, 4 connectors and 2 capacitors. It belongs with the radio and wireless boards of this library.
Open-source digital dashboard for Raspberry Pi. Most commercial Pi-based dash solutions lock you into a single ECU brand and require paid third-party software licenses. Overdash doesn't: it speaks J1939 CAN, OBD-II K-line, ELM327, CAN OBD, GPS, and GPIO natively, so it works with engine swaps, custom builds, and vehicles that commercial options simply don't support.
A Python async backend reads from any combination of those sources simultaneously and streams everything over WebSocket to a Chromium kiosk frontend. Gauges are rendered on canvas, and the layout is fully editable in-browser with a visual no-code editor. No paid software required.
Built for a TDI-swapped Land Rover Discovery (J1939 engine + CompuShift Sport TCM + ZF4HP22EH), but config-driven; no code changes needed to adapt it to another vehicle.
Features
Multiple data sources: J1939 CAN, CompuShift TCM, OBD-II (K-line and ELM327), CAN OBD, Megasquirt/Speeduino USB serial, GPS (NMEA), analog ADC, frequency counter, GPIO inputs, and a mock source for development without hardware
Visual no-code layout editor: drag to move, resize handles, properties panel for zones/thresholds/colors, gauge palette, theme picker, save to server or export JSON
Gauge types: circular sweep (tach, speedo), vertical/horizontal bar, large numeric with value mapping, indicator lights, warning light strip with DTC panel
DTC monitoring: Mode 03 (stored) + Mode 07 (pending) codes, MIL status, tap any active warning light to open the fault code panel
Odometer: integrates vehicle speed into a persisted lifetime total and resettable trip counter
PWA: add to home screen on a tablet for fullscreen landscape kiosk mode
# Clone
git clone https://github.com/outlandfabworks/overdash.git
cd overdash

# Create a virtual environment and install dependencies
python3 -m venv .venv
.venv/bin/pip install -r requirements.txt

# Test with the mock vehicle source (no hardware required)
.venv/bin/python -m backend.main configs/vehicles/mock.yaml

# Open http://localhost:8080 in a browser
For full installation on a Raspberry Pi (CAN setup, systemd service, Chromium kiosk), see INSTALL.md.
Project structure
text
backend/
  main.py                     Entry point: wires sources, processors, servers
  data_bus.py                 In-memory signal store with asyncio pub/sub
  config.py                   YAML loader
  sources/
    base.py                   Abstract DataSource
    can_j1939.py              J1939 PGN/SPN decoder (python-can)
    can_compushift.py         CompuShift Sport TCM CAN messages
    can_obd.py                OBD-II over CAN (ISO 15765-4)
    obd_kline.py              ISO 9141-2 / KWP2000 K-line poller
    elm327.py                 ELM327 USB/Bluetooth OBD adapter
    megasquirt.py             Megasquirt 1/2/3 and Speeduino USB serial
    gps_nmea.py               GPS via NMEA serial stream
    analog_adc.py             Analog voltage/sensor via SPI ADC (MCP3xxx)
    frequency_counter.py      RPM/frequency via GPIO pulse counting
    gpio_inputs.py            Overdash Input HAT (turn signals, lights, reverse)
    mock_vehicle.py           Simulated signals for dev/testing
  processors/
    odometer.py               Integrates vehicle_speed → odometer + trip signals
  server/
    websocket.py              WebSocket broadcast server (30 Hz)
    http_api.py               HTTP API + frontend file serving (port 8080)

frontend/
Register it in backend/main.py: _SOURCE_TYPES['my_source'] = MySource.
Add a source entry in the vehicle YAML with type: my_source.
TDI Discovery: signal reference
Signal
Source
Notes
engine_rpm
J1939 PGN 61444 SPN 190
EEC1
coolant_temp
J1939 PGN 65262
ET1
intake_map
K-line PID 0x0B
Absolute kPa (doubles as boost)
vehicle_speed
J1939 PGN 65265
CCVS1
trans_current_gear_label
CompuShift CAN 0x3E0
P/R/N/D/3/2/1
trans_tcc_lockup
CompuShift CAN 0x3E0
0 = open, 1 = locked
trans_temp
CompuShift CAN 0x3E1
°C
battery_voltage
J1939 PGN 65271
VEP1
odometer
Processor
Persisted lifetime km
trip
Processor
Resettable trip km
CompuShift Sport CAN IDs
Default map derived from community reverse-engineering (Sport firmware ≥ 2.x).
Override via messages: in the vehicle YAML if your TCM uses different IDs.
A handheld SSTC project on PCB, designed for a large magic wand form factor, entirely powered from 8s 18650. Uses direct secondary feedback with gate driver and MOSFETs, and 555 interrupter
High-performance dual BLDC motor driver with FOC (Field-Oriented Control) algorithm support, designed for applications requiring precise motor control with simultaneous dual-motor operation.
130 parts1
Questions
How big is the Pi dash input hat PCB?
It measures 100 × 56.5 mm and has 2 copper layers, 1.6 mm thick.
What parts does the Pi dash input hat use?
68 parts, built around the SMAJ15A, DMG2305UX, SB360 and SMAJ36A. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
Where can I download the Pi dash input hat KiCad files?
From the outlandfabworks/overdash repository on GitHub, at the commit this page was made from: the board is hardware/pi-dash-input-hat/pi-dash-input-hat.kicad_pcb and its schematic hardware/pi-dash-input-hat/pi-dash-input-hat.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Can I use the Pi dash input hat design in my own project?
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).