2 layers136.6 × 116.9 mm

 OPRobots/DragonBot8
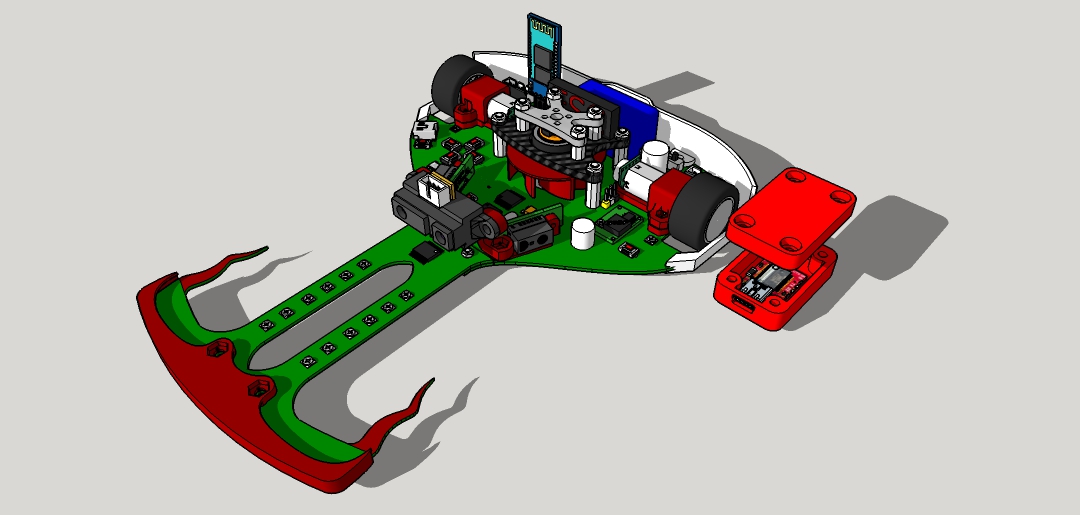
Robot siguelineas con succión centrifuga y STM32F1
Morro dragon is an open-source printed circuit board by OPRobots, from the OPRobots/DragonBot repository on GitHub, published under the GPL-2.0 licence. It is a 2-layer board of 99.8 × 99.6 mm with 71 parts on 52 nets, routed with 782 tracks and 45 vias.
It is built around the QRE1113, BSS83P and CD74HC4067M. Its parts include 21 resistors, 12 ICs, 9 capacitors, 4 connectors and 2 diodes.


Robot siguelineas con succión centrifuga y STM32F1

| Qty | Value | Footprint | References |
|---|---|---|---|
| 18 | 47 | Resistors_SMD:R_0805 | R1, R2, R3, R4, R5, R6, R7, R10, R11, R12, R14, R15, R16, R17, R18, R19 +2 |
| 12 | 51K | Potentiometers:Potentiometer_Trimmer-EVM3E | POT1, POT2, POT3, POT4, POT5, POT6, POT7, POT8, POT9, POT10, POT11, POT12 |
| 12 | QRE1113 | mods:QRE1113 | U1, U2, U3, U4, U5, U6, U7, U8, U9, U10, U11, U12 |
| 4 | MountingHole_3.2mm_M3 | Mounting_Holes:MountingHole_3.2mm_M3 | , , , |
| 3 | 100nF | Capacitors_SMD:C_0805 | C2, C4, C7 |
| 3 | 1uF | Capacitors_SMD:C_0805 | C1, C3, C6 |
| 3 | Conn_01x03 | Socket_Strips:Socket_Strip_Straight_1x03_Pitch2.54mm | J4, S_DER1, S_IZQ1 |
| 2 | 150 | Resistors_SMD:R_0805 | R13, R21 |
| 2 | C | Capacitors_SMD:C_0805 | C8, C9 |
| 2 | GS3 | Connectors:GS3 | ENB, J3 |
| 2 | LED | LEDs:LED_0805 | D1, D2 |
| 2 | LOGO | Librerias manu:opr1 | G***, G*** |
| 1 | Librerias manu:opr2 | ||
| 1 | 10k | Resistors_SMD:R_0805 | R20 |
| 1 | BSS83P | TO_SOT_Packages_SMD:SOT-23 | Q1 |
| 1 | CD74HC4067 | Housings_SSOP:TSSOP-24_4.4x7.8mm_Pitch0.65mm | MULTIPLEXADOR1 |
| 1 | CP1 | Capacitors_THT:CP_Radial_D4.0mm_P1.50mm | C5 |
| 1 | Conn_01x10_Female | Socket_Strips:Socket_Strip_Straight_1x10_Pitch1.27mm | J1 |
It measures 99.8 × 99.6 mm and has 2 copper layers, 1.6 mm thick.
71 parts, built around the QRE1113, BSS83P and CD74HC4067M. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the OPRobots/DragonBot repository on GitHub, at the commit this page was made from: the board is pcb_files/pcb_morro/Morro_dragon.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-2.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).


GadgetReboot/AVR_Programmer
Atmel AVR programmer based on Arduino Pro Micro, intended for development into ISP and HVSP using various AVR programming interfaces and protocols.


mlab-modules/BATDATUNIT01
Multiple parallel Li-ion 18650 battery cell module with BMS and data storage with MCU control.


mornepousse/KaSe_PCB
This repository contains the KiCad project and resources for the KaSe keyboard, a compact, column-staggered layout inspired by the Atreus62.

DiegoBriceno03/Portable-Biofeedback
Portable Biofeedback device for anxiety management