2 layers99.8 × 99.6 mm

 OPRobots/DragonBot8
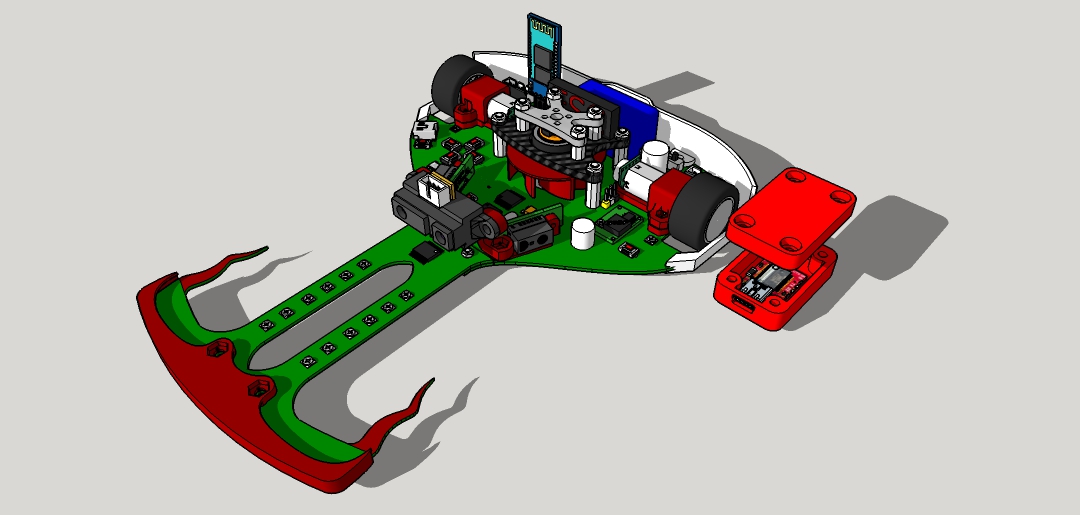
Robot siguelineas con succión centrifuga y STM32F1
DragonBot is an open-source printed circuit board by OPRobots, from the OPRobots/DragonBot repository on GitHub, published under the GPL-2.0 licence. It is a 2-layer board of 136.6 × 116.9 mm with 86 parts on 58 nets, routed with 1,272 tracks and 74 vias.
It is built around the STM32F103C8T6 and QRE1113. Its parts include 9 capacitors, 4 connectors, 2 diodes, 1 IC and 1 switch. It belongs with the STM32 boards of this library.


Robot siguelineas con succión centrifuga y STM32F1

| Qty | Value | Footprint | References |
|---|---|---|---|
| 17 | R | Resistors_SMD:R_0805 | 4K7R1, 4K7R2, 10K1, 10K2, 18k1, 20k1, 20k2, 36k1, 51k1, 75k1, 150k1, 150R1, 150R2, R150, RB1, RG1 +1 |
| 14 | MountingHole_3.2mm_M3 | Mounting_Holes:MountingHole_3.2mm_M3 | , , , , , , , , , , , , , |
| 7 | 0.1uf | Capacitors_SMD:C_0805 | C2, C4, C5, C6, C7, C8, C9 |
| 7 | SW_Push | Buttons_Switches_SMD:SW_DIP_x1_W8.61mm_Slide_LowProfile | BT1, BT2, BT3, BT4, RST1, RST2, SWP1 |
| 3 | 10uf | Capacitors_THT:CP_Radial_D4.0mm_P2.00mm | CE3, CE4, CE5 |
| 3 | C | Capacitors_SMD:C_0805 | 2C100n1, C1u1, C1uf1 |
| 3 | Conn_01x06 | Pin_Headers:Pin_Header_Straight_1x06_Pitch2.54mm | JGiro1, JM1, JM2 |
| 2 | 0.1uf | Capacitors_THT:C_Disc_D3.4mm_W2.1mm_P2.50mm | CM1, CM3 |
| 2 | C20p | Capacitors_SMD:C_0805 | 20p1, 20p2 |
| 2 | POT | Potentiometers:Potentiometer_Trimmer-EVM3E | 50KP1, 50KP2 |
| 2 | QRE1113 | mods:QRE1113 | RBTR1, RBTR2 |
| 1 | 1000uf | Capacitors_THT:CP_Radial_D10.0mm_P7.50mm | CE1 |
| 1 | 100K | Resistors_SMD:R_0805 | 100K1 |
| 1 | 100nf | Capacitors_SMD:C_0805 | 3C100n1 |
| 1 | 10nF | Capacitors_SMD:C_0805 | C10n1 |
| 1 | 4.7uF | Capacitors_SMD:C_0805 | C4.7u1 |
| 1 | 860uf | Capacitors_THT:CP_Radial_D8.0mm_P5.00mm | CE2 |
| 1 | Conn_01x02 | Pin_Headers:Pin_Header_Straight_1x02_Pitch2.54mm | J3 |
| 1 | Conn_01x02_Male | Pin_Headers:Pin_Header_Straight_1x02_Pitch2.54mm | JBAT1 |
| 1 | Conn_01x03 | Pin_Headers:Pin_Header_Straight_1x03_Pitch2.54mm | J2 |
| 1 | Conn_01x03_Male | Pin_Headers:Pin_Header_Straight_1x03_Pitch2.54mm | JVENT1 |
| 1 | Conn_01x04 | Pin_Headers:Pin_Header_Straight_1x04_Pitch2.54mm | STLINK1 |
| 1 | Conn_01x06_Female | Socket_Strips:Socket_Strip_Straight_1x06_Pitch2.54mm | FTID1 |
| 1 | Conn_01x10_Male | Pin_Headers:Pin_Header_Angled_1x10_Pitch1.27mm | J1 |
| 1 | Crystal | Crystals:Crystal_HC50_Vertical | Y2 |
| 1 | DIODE | Diodes_THT:D_A-405_P7.62mm_Horizontal | D1 |
| 1 | LED | LEDs:LED_0805_HandSoldering | LED_V1 |
| 1 | LED_RGB | LEDs:LED_RGB_5050-6 | D2 |
| 1 | LOGO | Librerias manu:opr4 | G*** |
| 1 | LOGO | Librerias manu:dragon | G*** |
| 1 | ON/OFF | Pin_Headers:Pin_Header_Straight_1x03_Pitch2.54mm | SW1 |
| 1 | STM32F103C8T6 | Housings_QFP:LQFP-48_7x7mm_Pitch0.5mm | U1 |
| 1 | Step_down_chino | Librerias manu:Step_down_chino | STEP1 |
| 1 | TB6612FNG | Librerias manu:SSOP-24_5.3x8.2mm_Pitch0.65mm | PH1 |
| 1 | USB_OTG | Connectors:USB_Mini-B | J4 |
It measures 136.6 × 116.9 mm and has 2 copper layers, 1.6 mm thick.
86 parts, built around the STM32F103C8T6 and QRE1113. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the OPRobots/DragonBot repository on GitHub, at the commit this page was made from: the board is pcb_files/pcb_principal/DragonBot.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-2.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).


fwachsmuth/Filmkorn-Raw-Scanner
The Filmkorn Raw Scanner, turning 8mm and 16mm films into lossless 12-bit CinemaDNG


OPRobots/Yokozunita
Robot minisumo con PCBs, motores fingertech, plomo fundido y stepUp.

project-neon/Esguicho
Neste repositório temos os principais arquivos que usamos para os 3 capítulos, Eletrônica, Mecânica e Software. Segue abaixo uma lista do que temos em cada uma das pastas:

vorlaxen-labs/AratMicro
High-performance, open-source micromouse robot platform built for Robosam and MEB Robot (Ministry of National Education Robotics Competition, Turkey).
