4 layers161 × 100 mm
Current3x3A Artiq
KLFAMO/current3x3A_Artiq
3 channel current driver (up to 3A each channel) compatible with Artiq
365 parts

 dridri/bcflight175
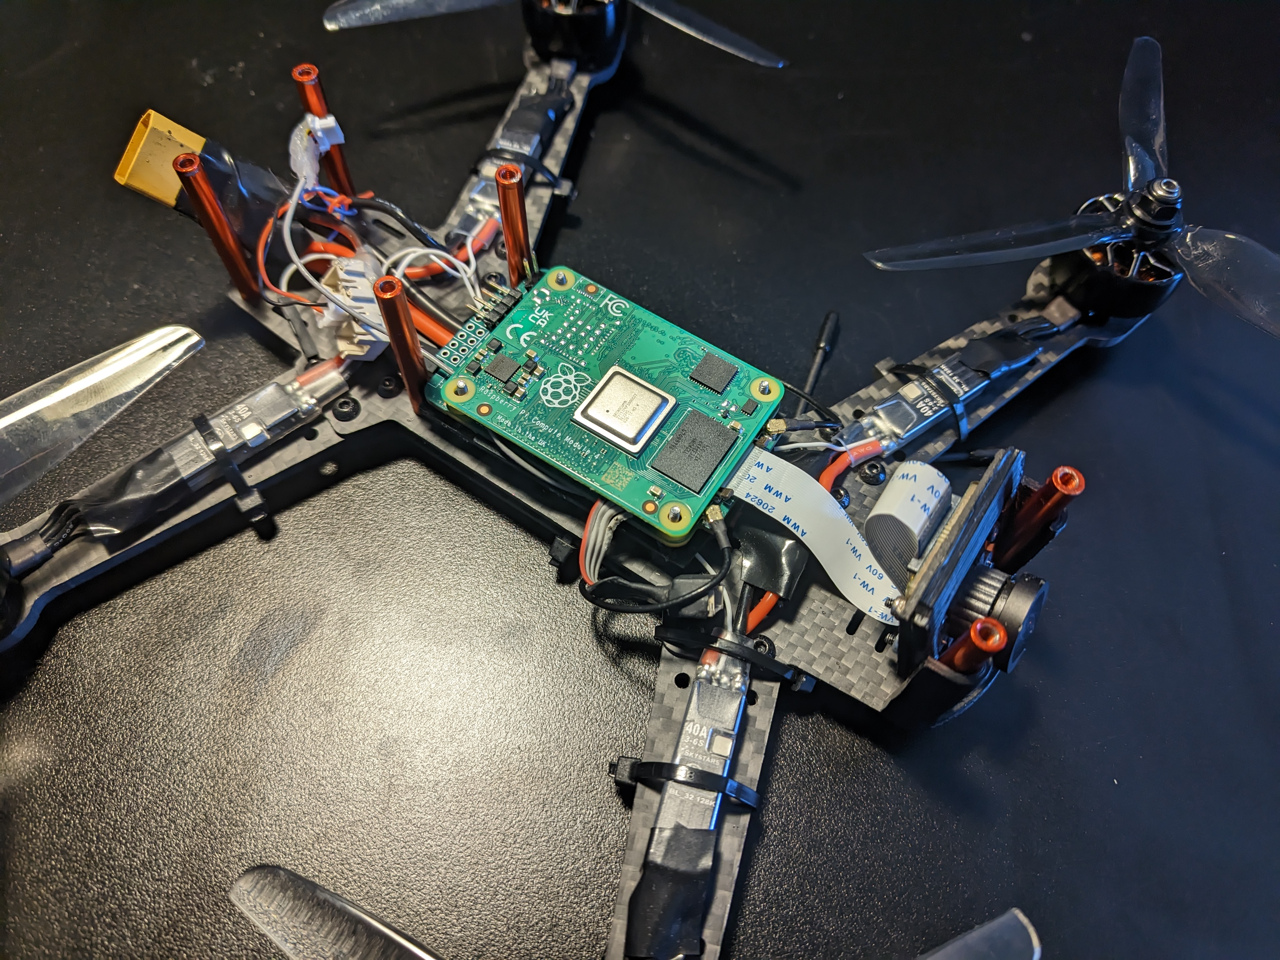
Raspberry Pi based drone flight controller and remote control
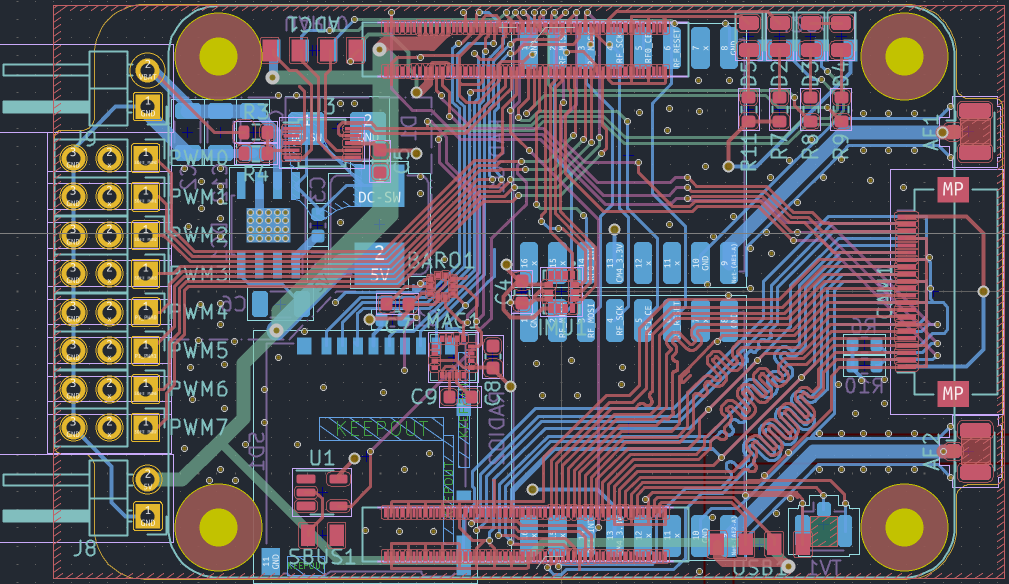
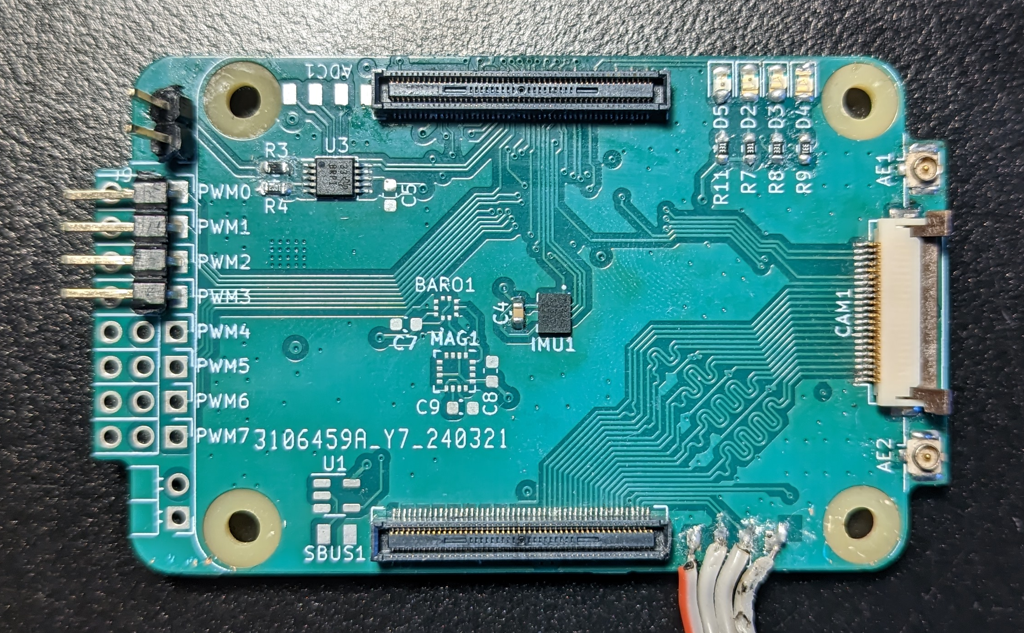
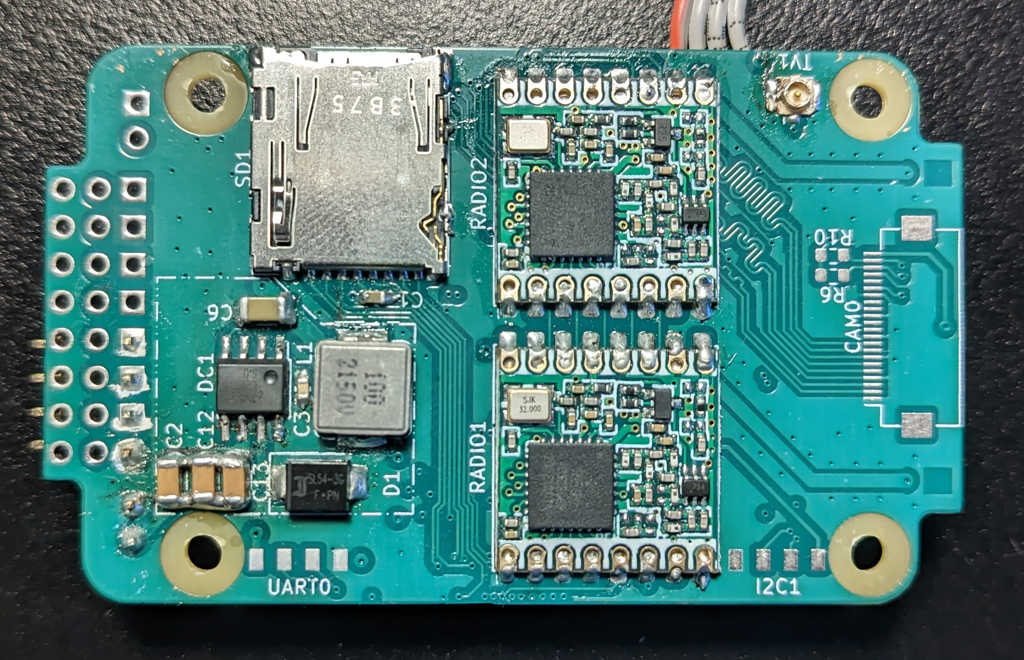
Cm4 drone is an open-source printed circuit board by dridri, from the dridri/bcflight repository on GitHub, published under the GPL-3.0 licence. It is a 4-layer board of 66.3 × 40.2 mm with 56 parts on 208 nets, routed with 1,773 tracks and 237 vias.
It is built around the ADS1115IDGS, BMP581 and IST8310, with the LM22676MR-5.0, 74LVC1G04Z and RFM95W-868S2 among its other parts. Its parts include 11 capacitors, 8 resistors, 6 diodes, 3 ICs and 2 connectors. It belongs with the robots and motor control and computers and single-board computers boards and the Raspberry Pi (Linux) boards of this library.


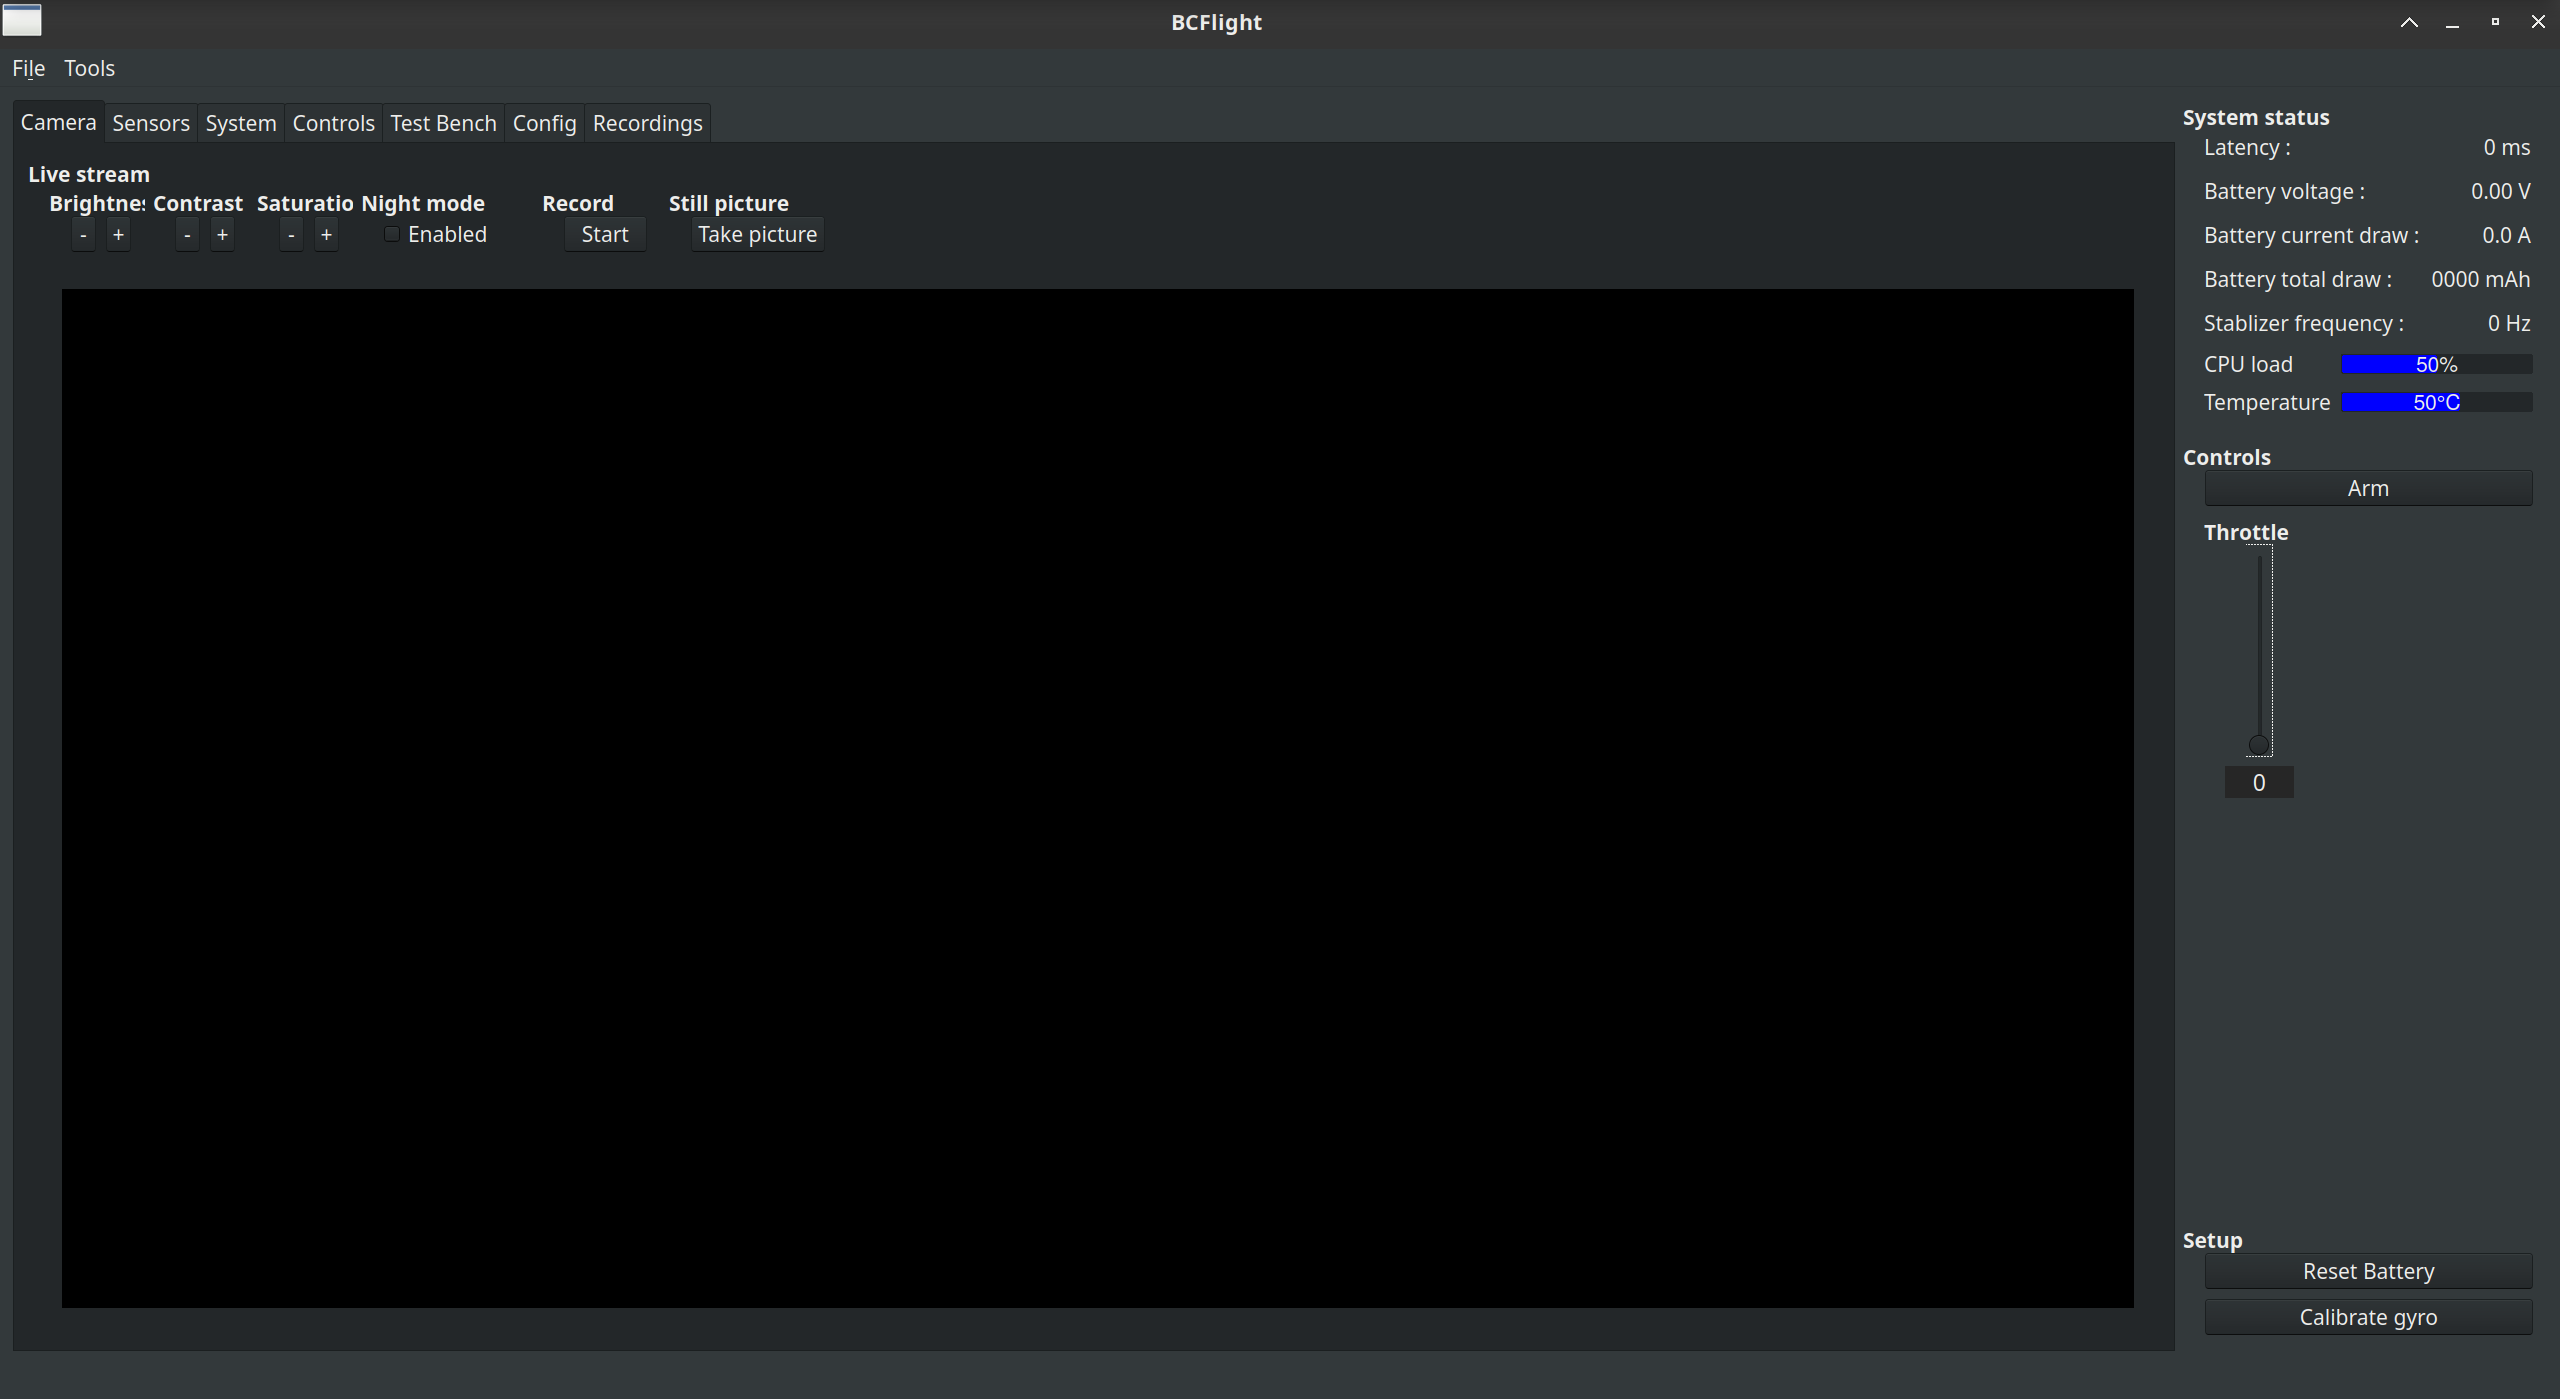
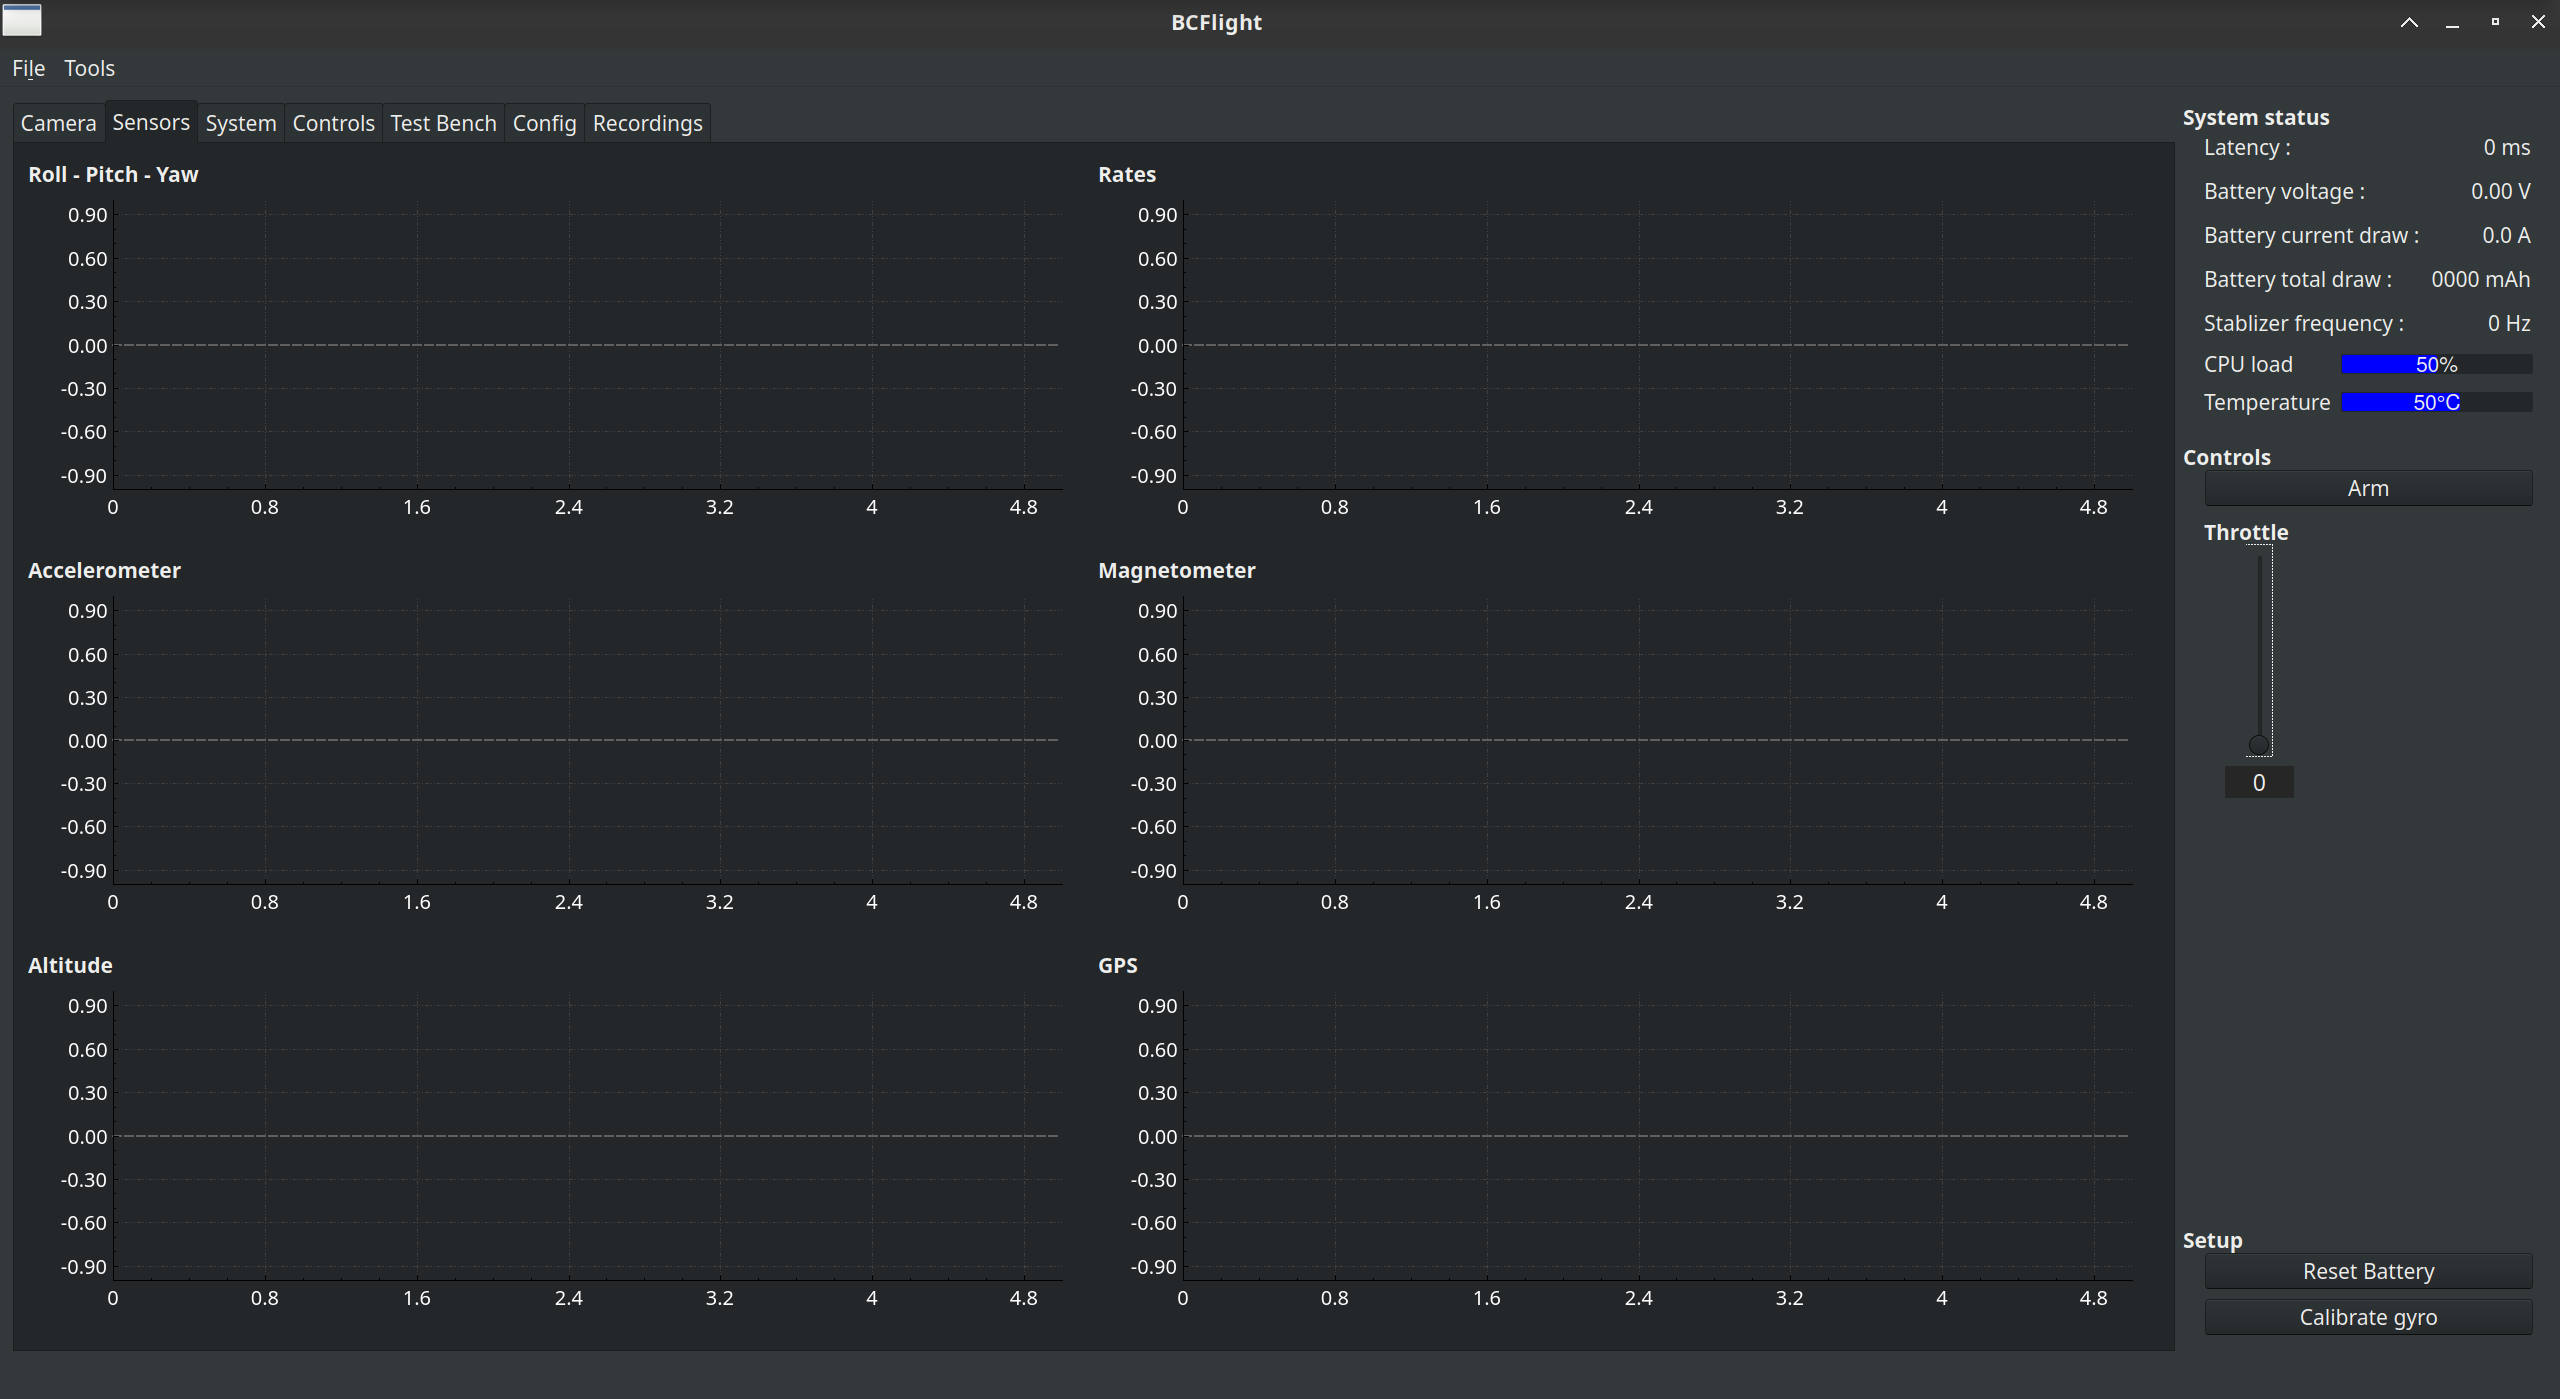
BCFlight is an open-source Linux-based Raspberry Pi drone and ground controller system, offering a complete solution for flight control, stabilization, and telemetry.
The project consists of three main components:
flight/ - Flight ControllerCore system managing:
controller_pc/ - PC InterfaceConfigurable GUI client for:
controller_rc/ - Remote ControlPortable control interface with:
Automatically generated images based on Raspbian:
root:bcflight by default| Image | Based on | DShot | Analog video |
|---|---|---|---|
| 2023-07-18-raspbian-bcflight.img | 2023-05-03-raspios-bullseye-armhf-lite | ✅¹ | ✅¹ |
¹ DShot and composite output can be enabled via /boot/config.txt and /var/flight/config.lua
# Dependencies
sudo apt-get install nasm qtmultimedia5-dev qtbase5-dev qtchooser qt5-qmake qtbase5-dev-tools libnl-3-dev libnl-genl-3-dev libnl-route-3-dev libiw-dev libfftw3-dev libqscintilla2-qt5-dev

# Build
git clone https://github.com/dridri/bcflight.git
cd bcflight/controller_pc
cmake -DCMAKE_BUILD_TYPE=Release -S . -B build
cd build && make -j$(nproc)
./controller_pc# Dependencies
sudo apt update
sudo apt install git pkg-config cmake make g++ libc6-dev libraspberrypi-dev libiw-dev libdrm-dev libgbm-dev libcamera-dev libgles2-mesa-dev libgps-dev libasound2-dev libcrypt-dev zlib1g-dev libpng-dev libshine-dev libavformat-dev libavutil-dev libavcodec-dev libpigpio-dev lua5.3 libfftw3-dev
# Build
git clone https://github.com/dridri/bcflight
cd bcflight/flight
cmake -Dboard=rpi -Ddebug=1 -S . -B build
cd build && make -j$(nproc)-- Frame configuration (quadcopter)
frame = Multicopter {
maxspeed = 1.0,
air_mode = {
trigger = 0.25,
speed = 0.15
},
motors = {
DShot( 4 ), DShot( 5 ), DShot( 6 ), DShot( 7 )
},
matrix = {
Vector( -1.0, 1.0, -1.0, 1.0 ),
Vector( 1.0, 1.0, 1.0, 1.0 ),
Vector( -1.0, -1.0, 1.0, 1.0 ),
Vector( 1.0, -1.0, -1.0, 1.0 )
}
}
-- IMU configuration
imu = IMU {
gyroscopes = { imu_sensor.gyroscope },
accelerometers = { imu_sensor.accelerometer },
filters = {
rates = { input = Vector( 80, 80, 80 ), output = Vector( 0.25, 0.25, 0.25 ) },More videos on YouTube @drichfpv
Features:
Contributions are welcome! The project is licensed under GPL v3.
This project is distributed under the GNU General Public License v3.0. See the LICENSE file for more details.
⚠️ Warning : This software is provided for educational and research purposes. Drone usage can be dangerous. Please respect local regulations and use at your own risk.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | Conn_01x03_Female | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | PWM0, PWM1, PWM2, PWM3, PWM4, PWM5, PWM6, PWM7 |
| 4 | 100nF | Capacitor_SMD:C_0603_1608Metric | C4, C5, C7, C8 |
| 4 | 330 | Resistor_SMD:R_0603_1608Metric | R7, R8, R9, R11 |
| 4 | Conn_01x04_Female | cm4_drone:Breakout_1x04_2mm_SMD | ADC1, I2C1, UART0, USB1 |
| 4 | LED | LED_SMD:LED_0805_2012Metric | D2, D3, D4, D5 |
| 3 | 10uF | Capacitor_SMD:C_1206_3216Metric | C2, C12, C13 |
| 2 | 1.8k | Resistor_SMD:R_0603_1608Metric | R6, R10 |
| 2 | Conn_01x02_Female | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Horizontal | J8, J9 |
| 2 | Conn_01x22_Female | Connector_FFC-FPC:Hirose_FH12-22S-0.5SH_1x22-1MP_P0.50mm_Horizontal | CAM0, CAM1 |
| 2 | RFM95W-868S2 | RF_Module:HOPERF_RFM9XW_SMD | RADIO1, RADIO2 |
| 1 | 100uF | Capacitor_SMD:C_1206_3216Metric | C6 |
| 1 | 10k | Resistor_SMD:R_0603_1608Metric | R4 |
| 1 | 10nF | Capacitor_SMD:C_0603_1608Metric | C3 |
| 1 | 10uF | Capacitor_SMD:C_0603_1608Metric | C1 |
| 1 | 4.7uF | Capacitor_SMD:C_0603_1608Metric | C9 |
| 1 | 74LVC1G04 | Package_TO_SOT_SMD:SOT-23-5 | U1 |
| 1 | 75k | Resistor_SMD:R_0603_1608Metric | R3 |
| 1 | ADS1115IDGS | Package_SO:TSSOP-10_3x3mm_P0.5mm | U3 |
| 1 | ANT0_uFL | Connector_Coaxial:U.FL_Hirose_U.FL-R-SMT-1_Vertical | AE1 |
| 1 | ANT1_uFL | Connector_Coaxial:U.FL_Hirose_U.FL-R-SMT-1_Vertical | AE2 |
| 1 | BMP581 | footprints:BMP581 | BARO1 |
| 1 | Compute_Module_4_Connectors | RPi_Compute_Module_4:Raspberry-Pi-4-Compute-Module | U5 |
| 1 | Conn_01x02_Female | Connector_Coaxial:U.FL_Hirose_U.FL-R-SMT-1_Vertical | TV1 |
| 1 | Conn_01x02_Female | cm4_drone:Breakout_1x02_2mm_SMD | SBUS1 |
| 1 | ICM-42605 | cm4_drone:PQFN50P300X250X97-14N | IMU1 |
| 1 | IST8310 | Package_LGA:LGA-16_3x3mm_P0.5mm | MAG1 |
| 1 | LM22676MR-5 | Package_SO:TI_SO-PowerPAD-8 | DC1 |
| 1 | Micro_SD_Card_Det | Connector_Card:microSD_HC_Hirose_DM3AT-SF-PEJM5 | SD1 |
| 1 | SL54-3G | Diode_SMD:D_SMB | D1 |
| 1 | SMAJ36A | Diode_SMD:D_SMA | D6 |
| 1 | SRP6030VA-100M | Inductor_SMD:L_Bourns_SRP7028A_7.3x6.6mm | L1 |
It measures 66.3 × 40.2 mm and has 4 copper layers, 1.6 mm thick.
56 parts, built around the ADS1115IDGS, BMP581, IST8310 and LM22676MR-5.0. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the dridri/bcflight repository on GitHub, at the commit this page was made from: the board is electronics/cm4_drone/cm4_drone.kicad_pcb and its schematic electronics/cm4_drone/cm4_conn.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
KLFAMO/current3x3A_Artiq
3 channel current driver (up to 3A each channel) compatible with Artiq

ARTS-Laboratory/SPECIES
Design and development of a deployable UAV smart penetrometer


biomimetics/MRIRobot_PCB
PC boards for MRI robogt control, specifically for STM32 motherboard


johnugbor/RoboSolar
SKiDL-generated draft v0.1. NOT FOR FABRICATION — see blockers below.
