2 layers50 × 66 mm

 ChladpavPy/Aero-Zero
I started this project, because I wanted to build fully autonomous ai drone. When I looked at the flight controllers available on the market, they were full of hardware that I just do not need or just that I could not…
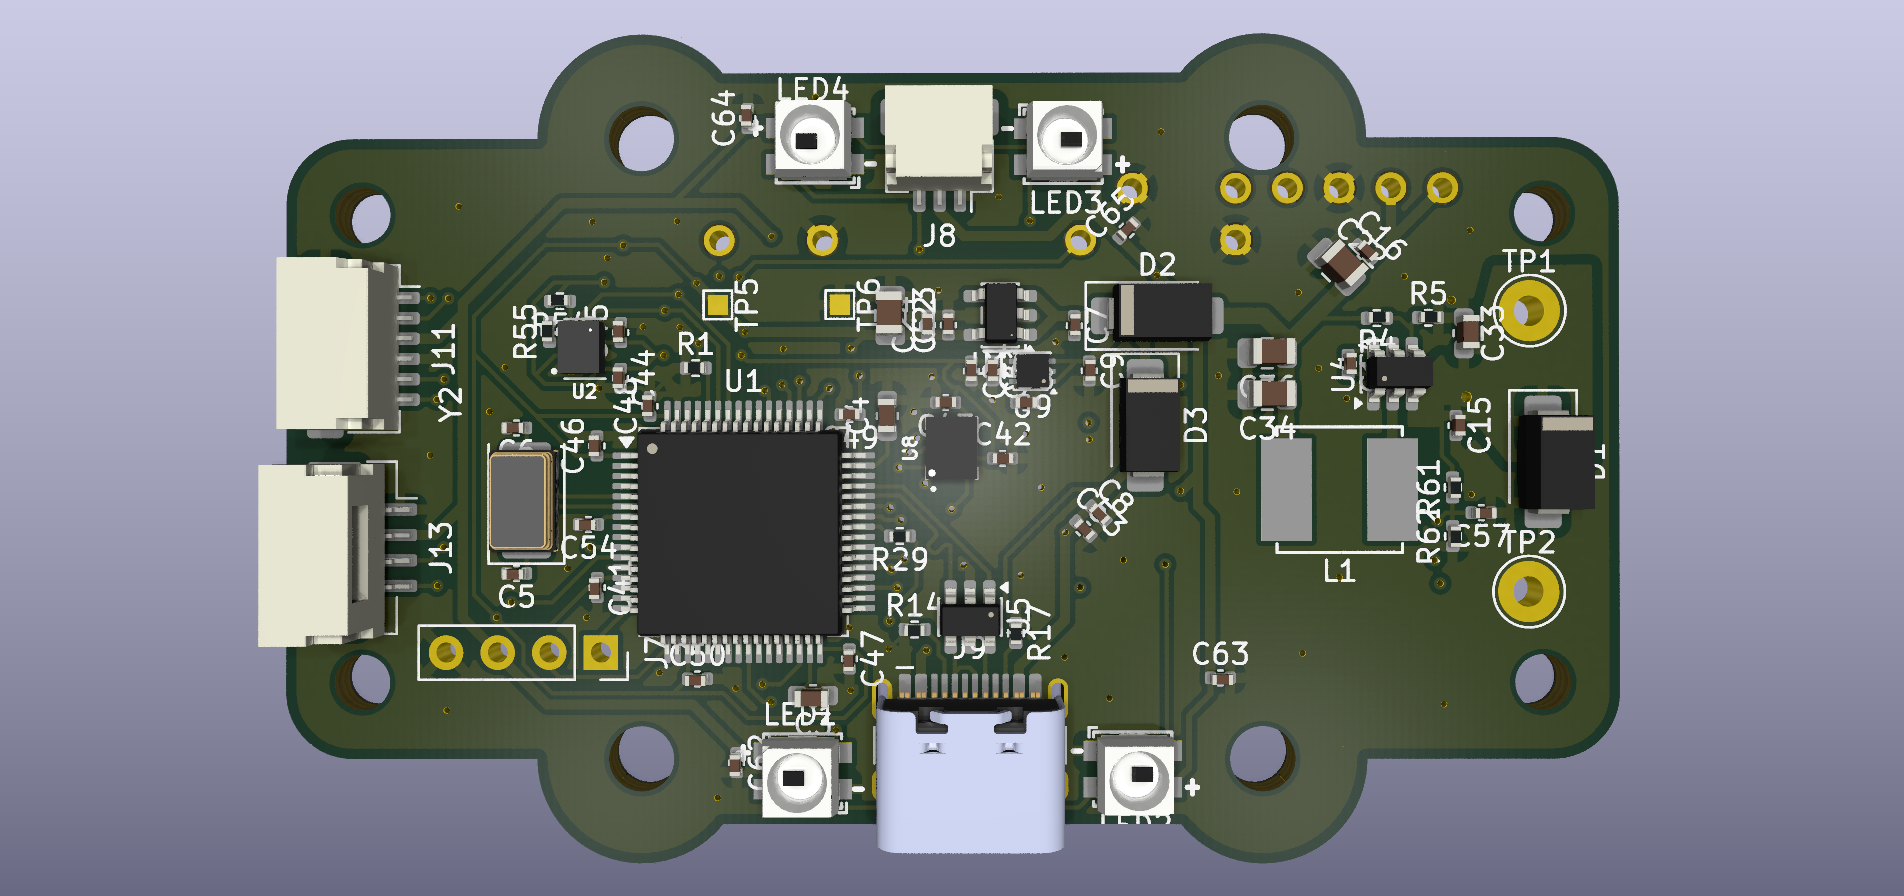
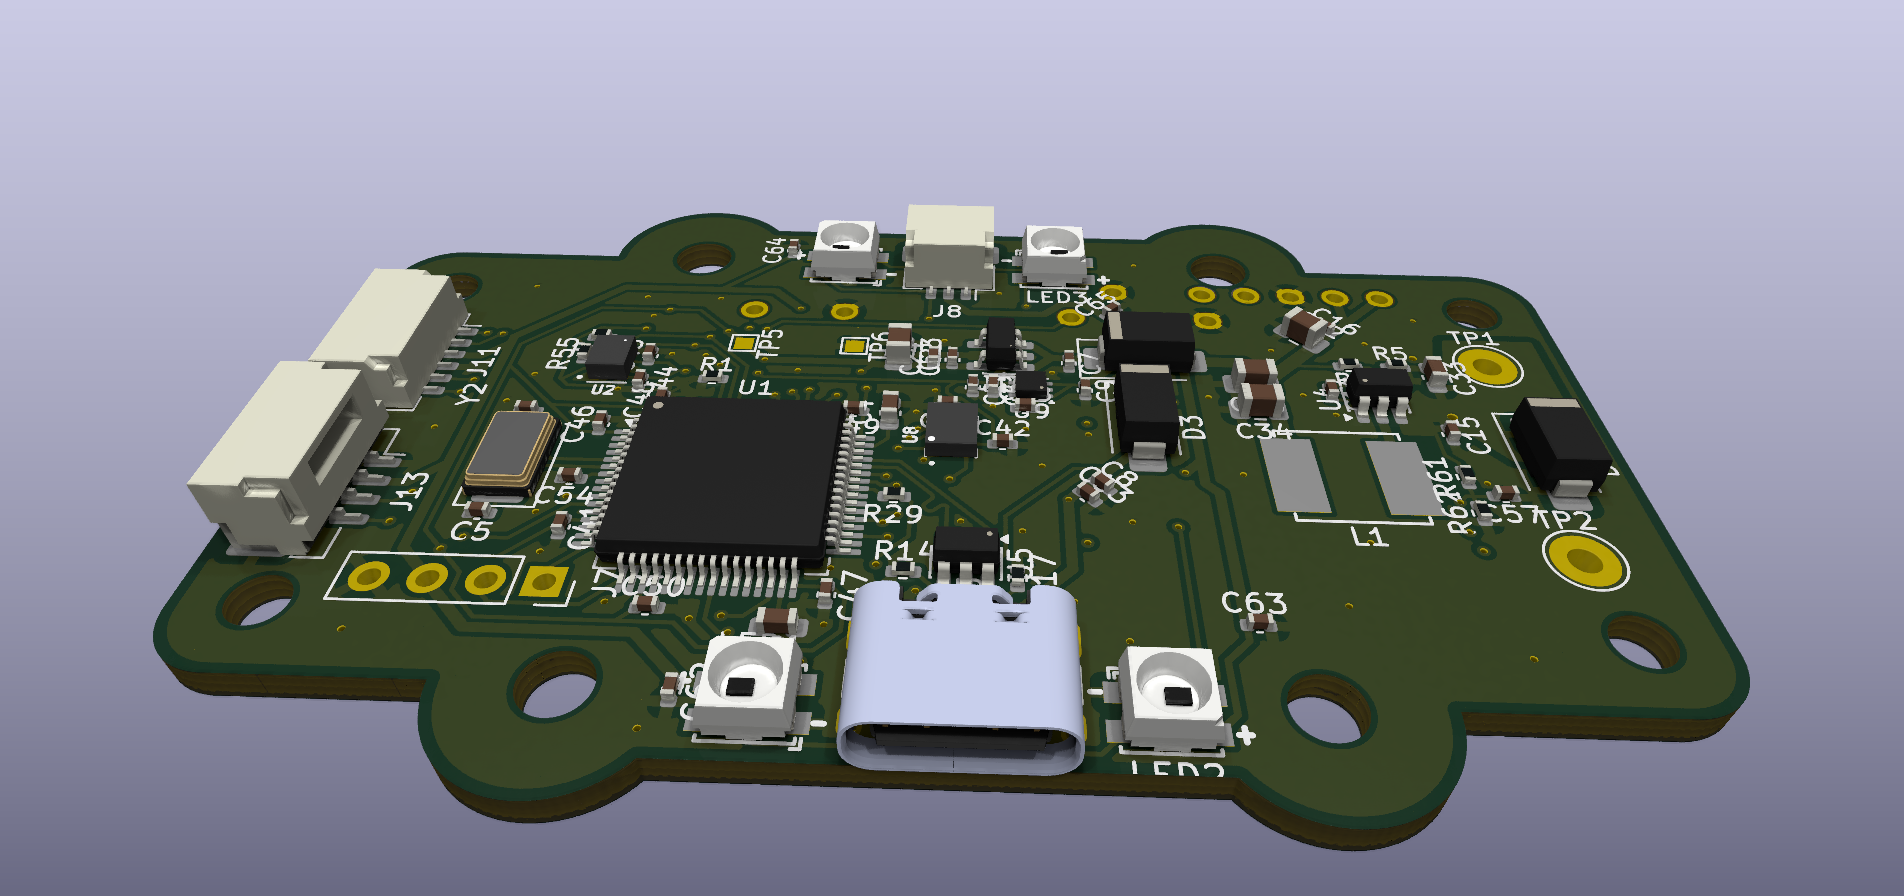
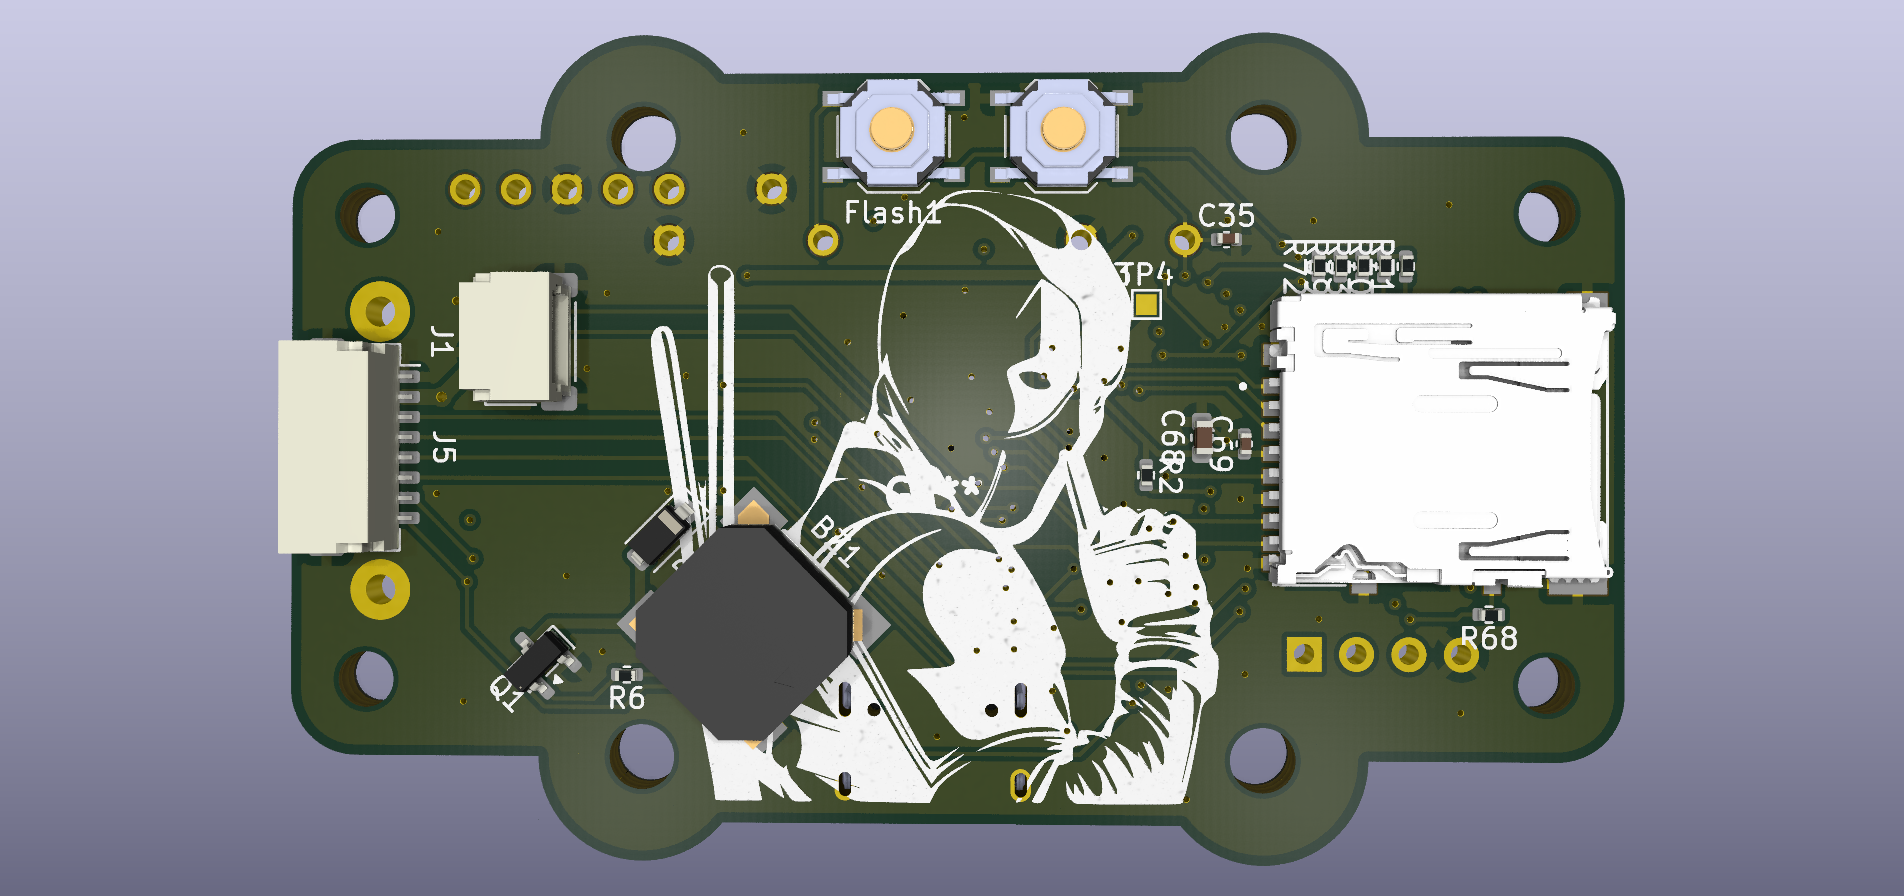
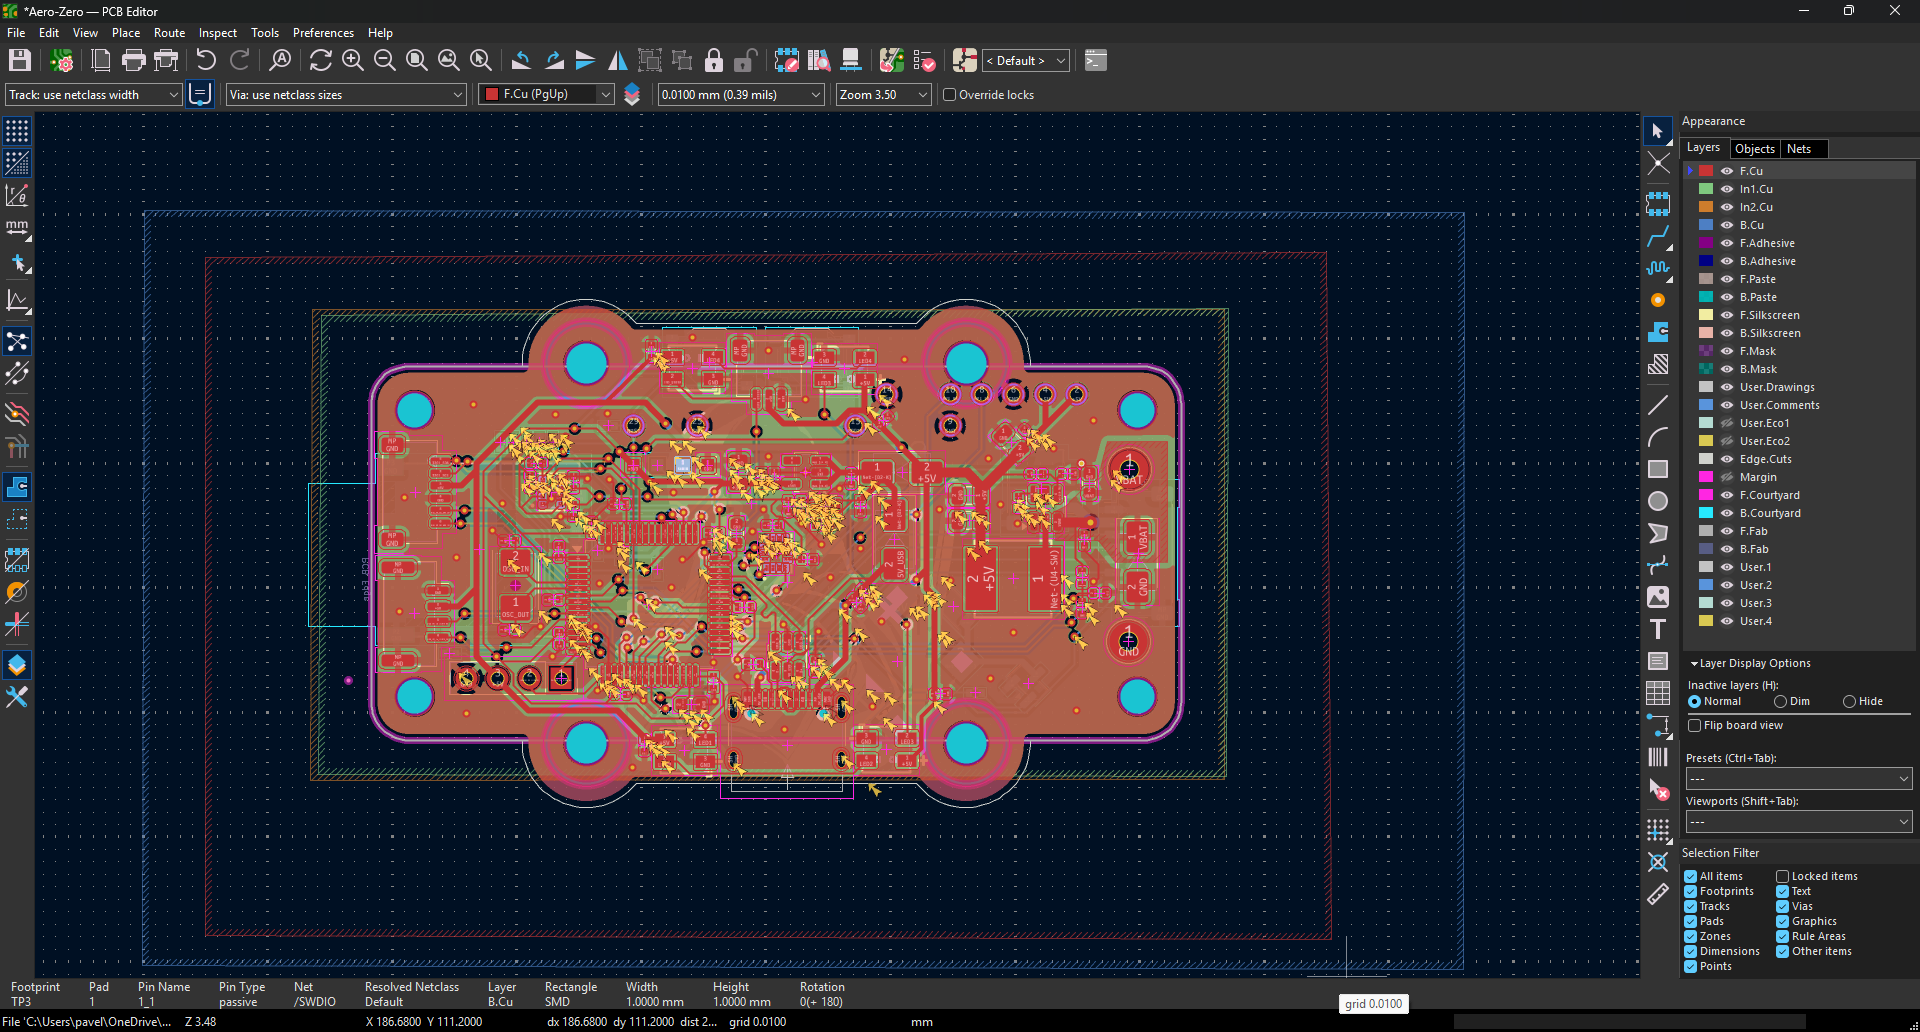
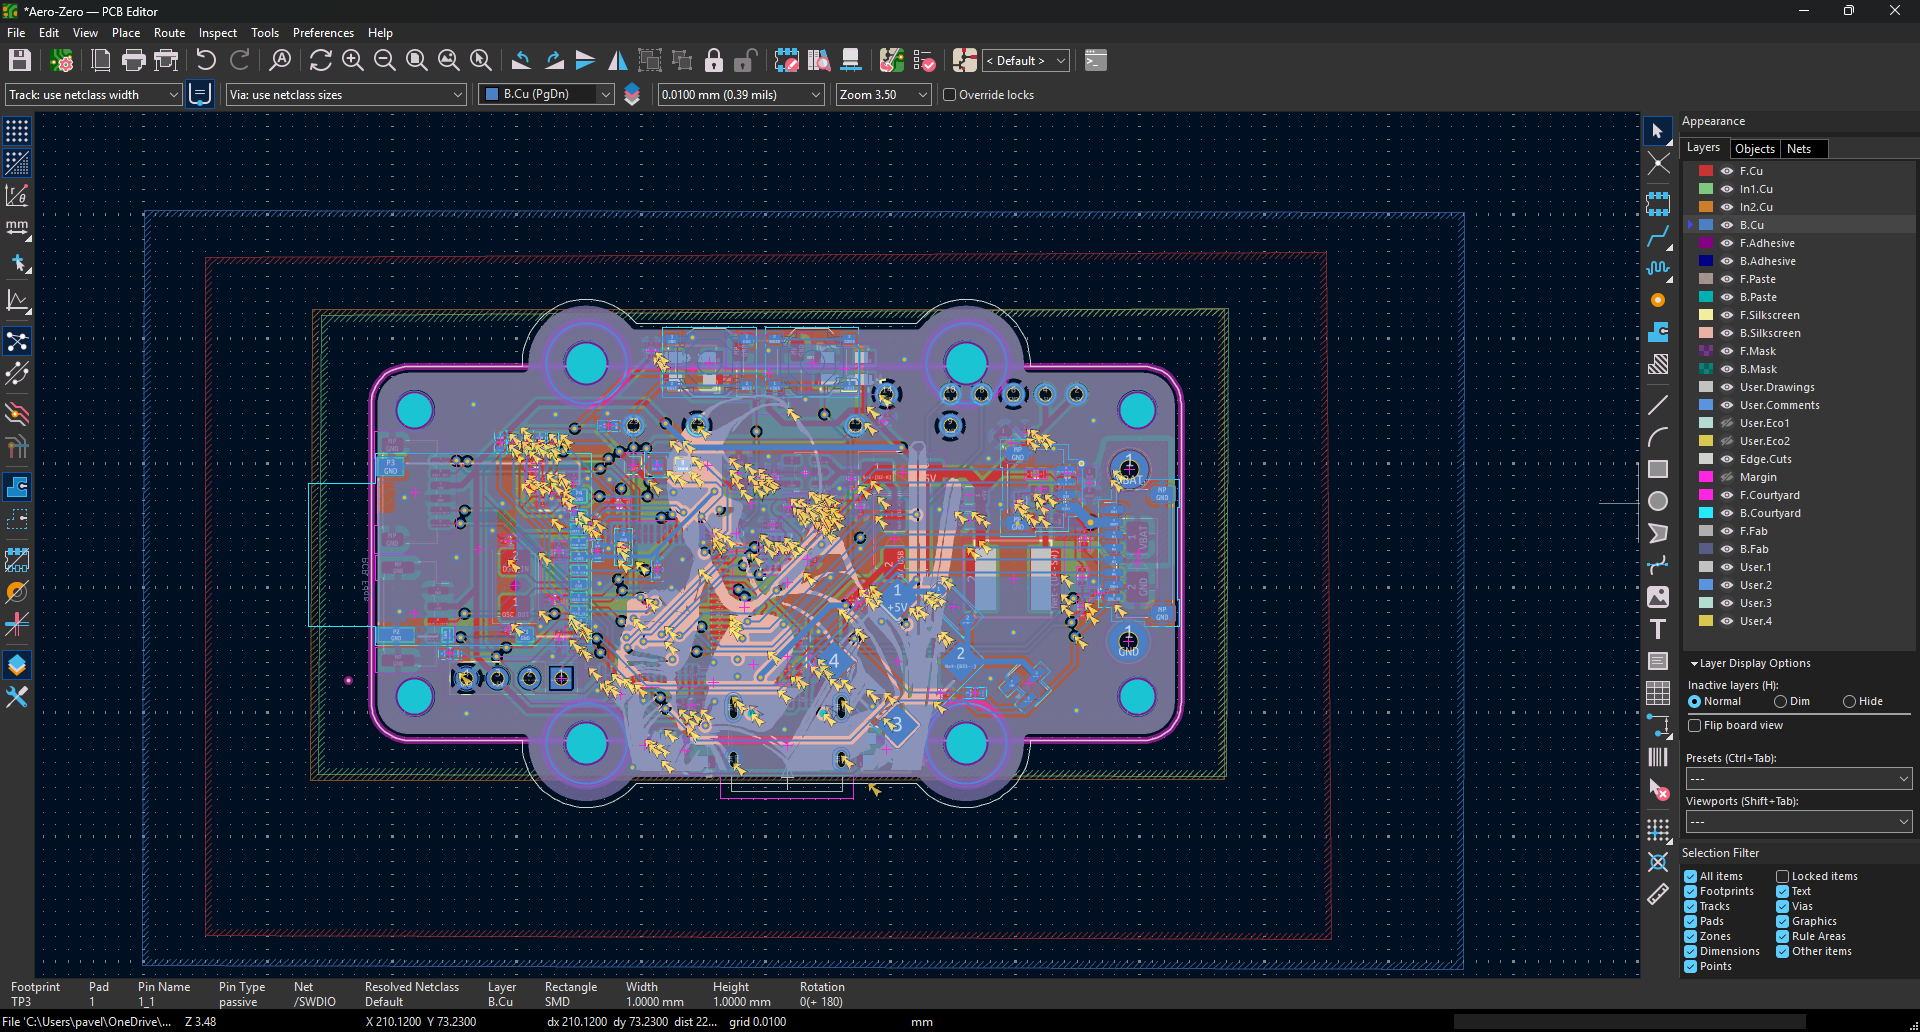
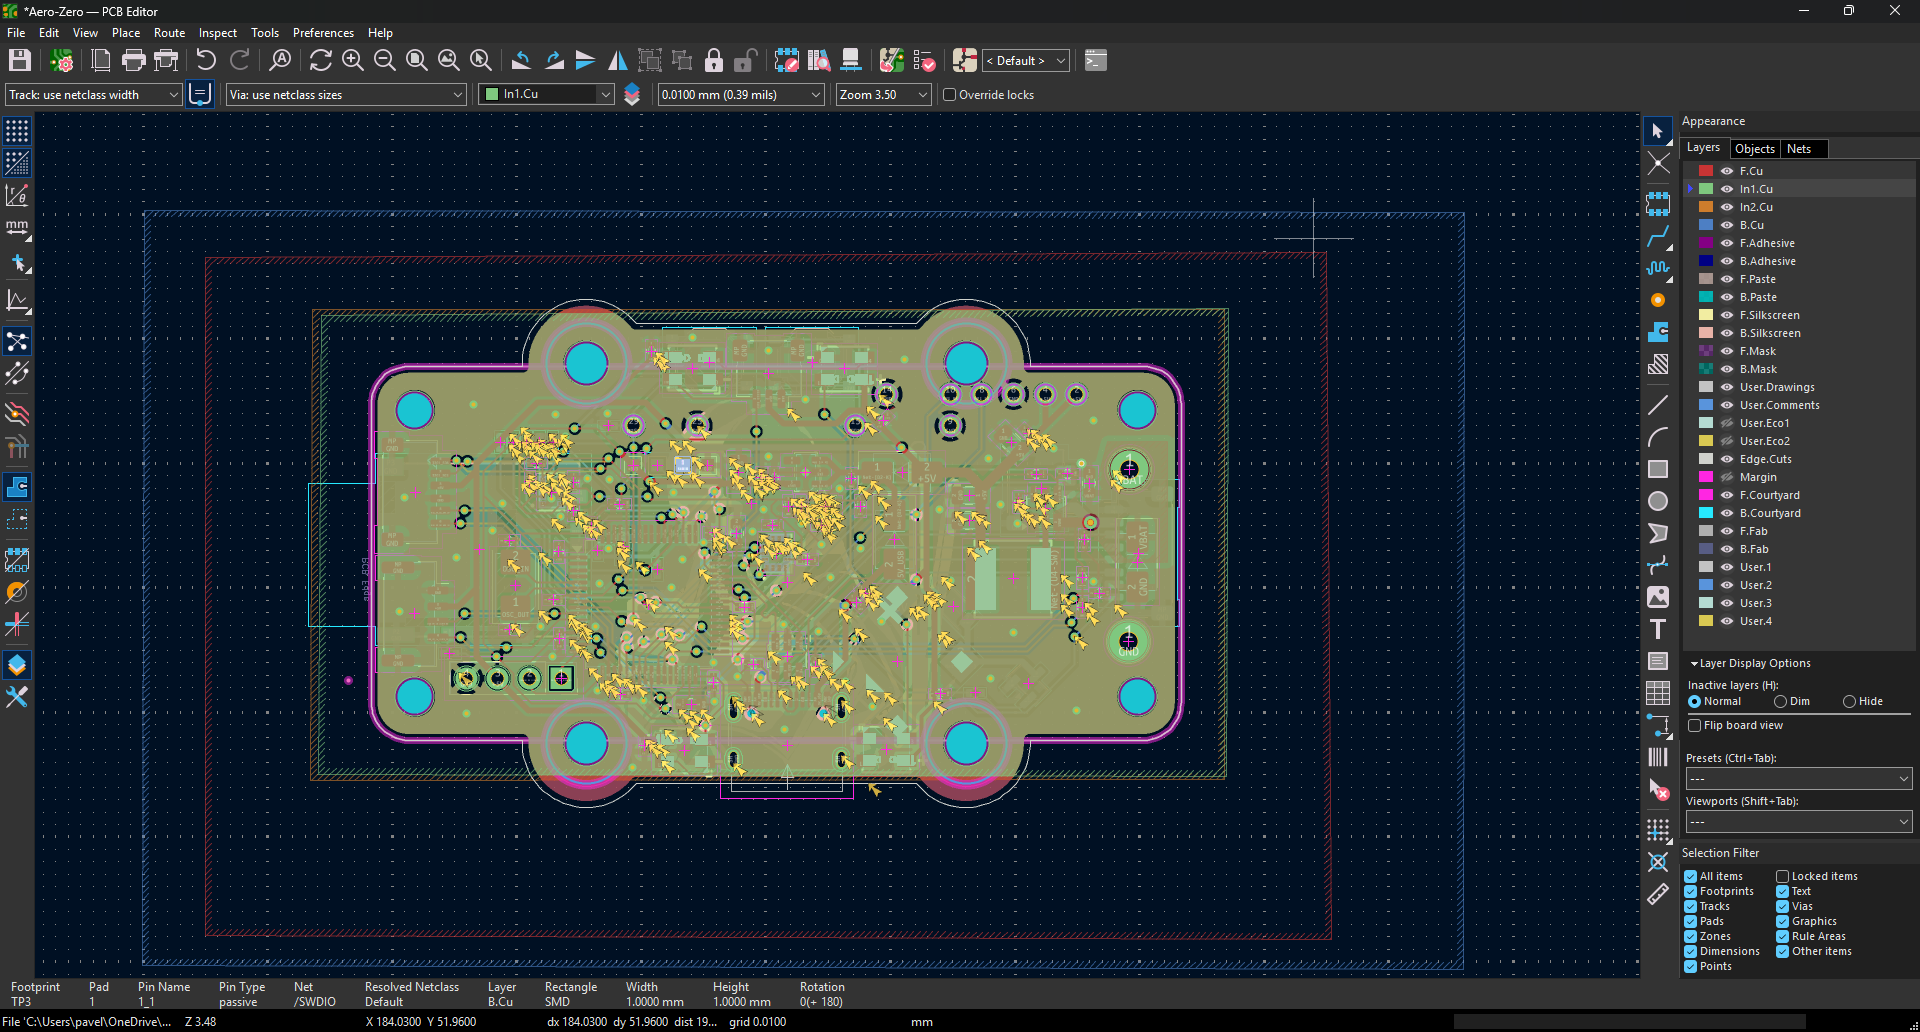
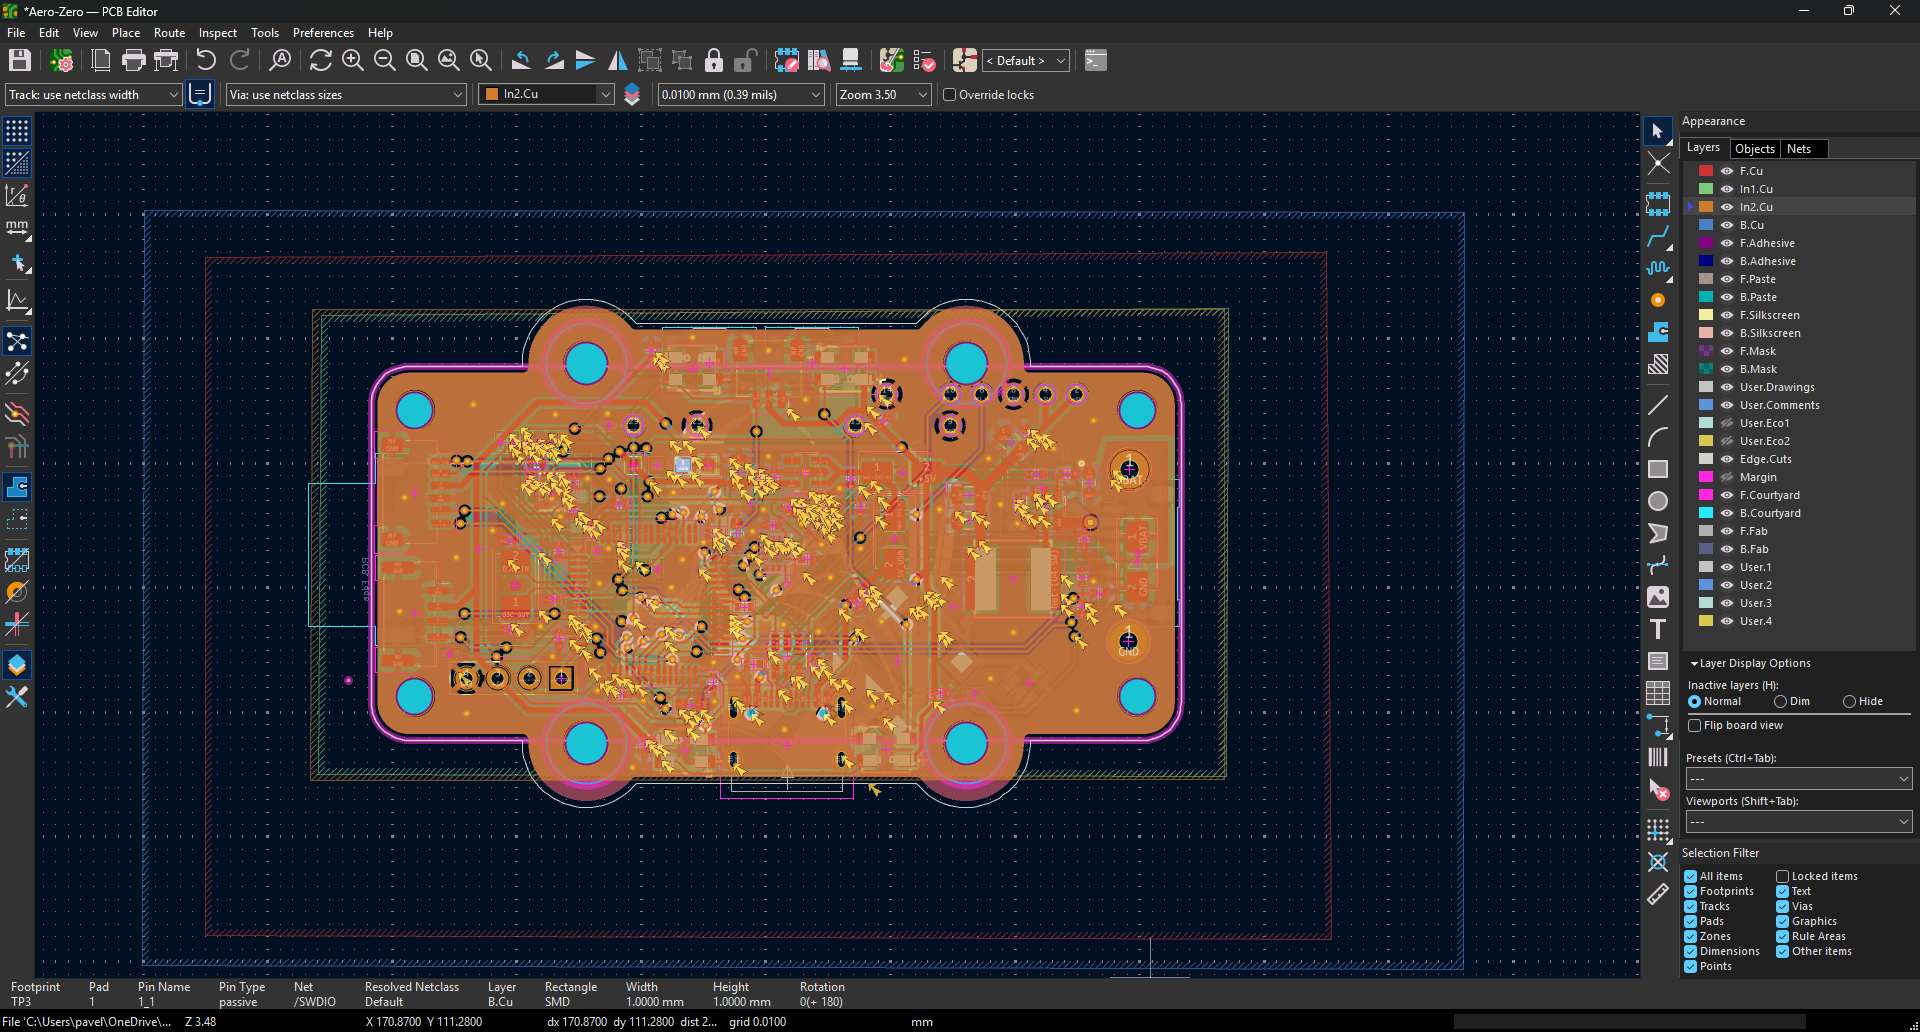
Aero Zero is an open-source printed circuit board by ChladpavPy, from the ChladpavPy/Aero-Zero repository on GitHub. It is a 4-layer board of 65 × 40.1 mm with 97 parts on 88 nets, routed with 818 tracks and 188 vias.
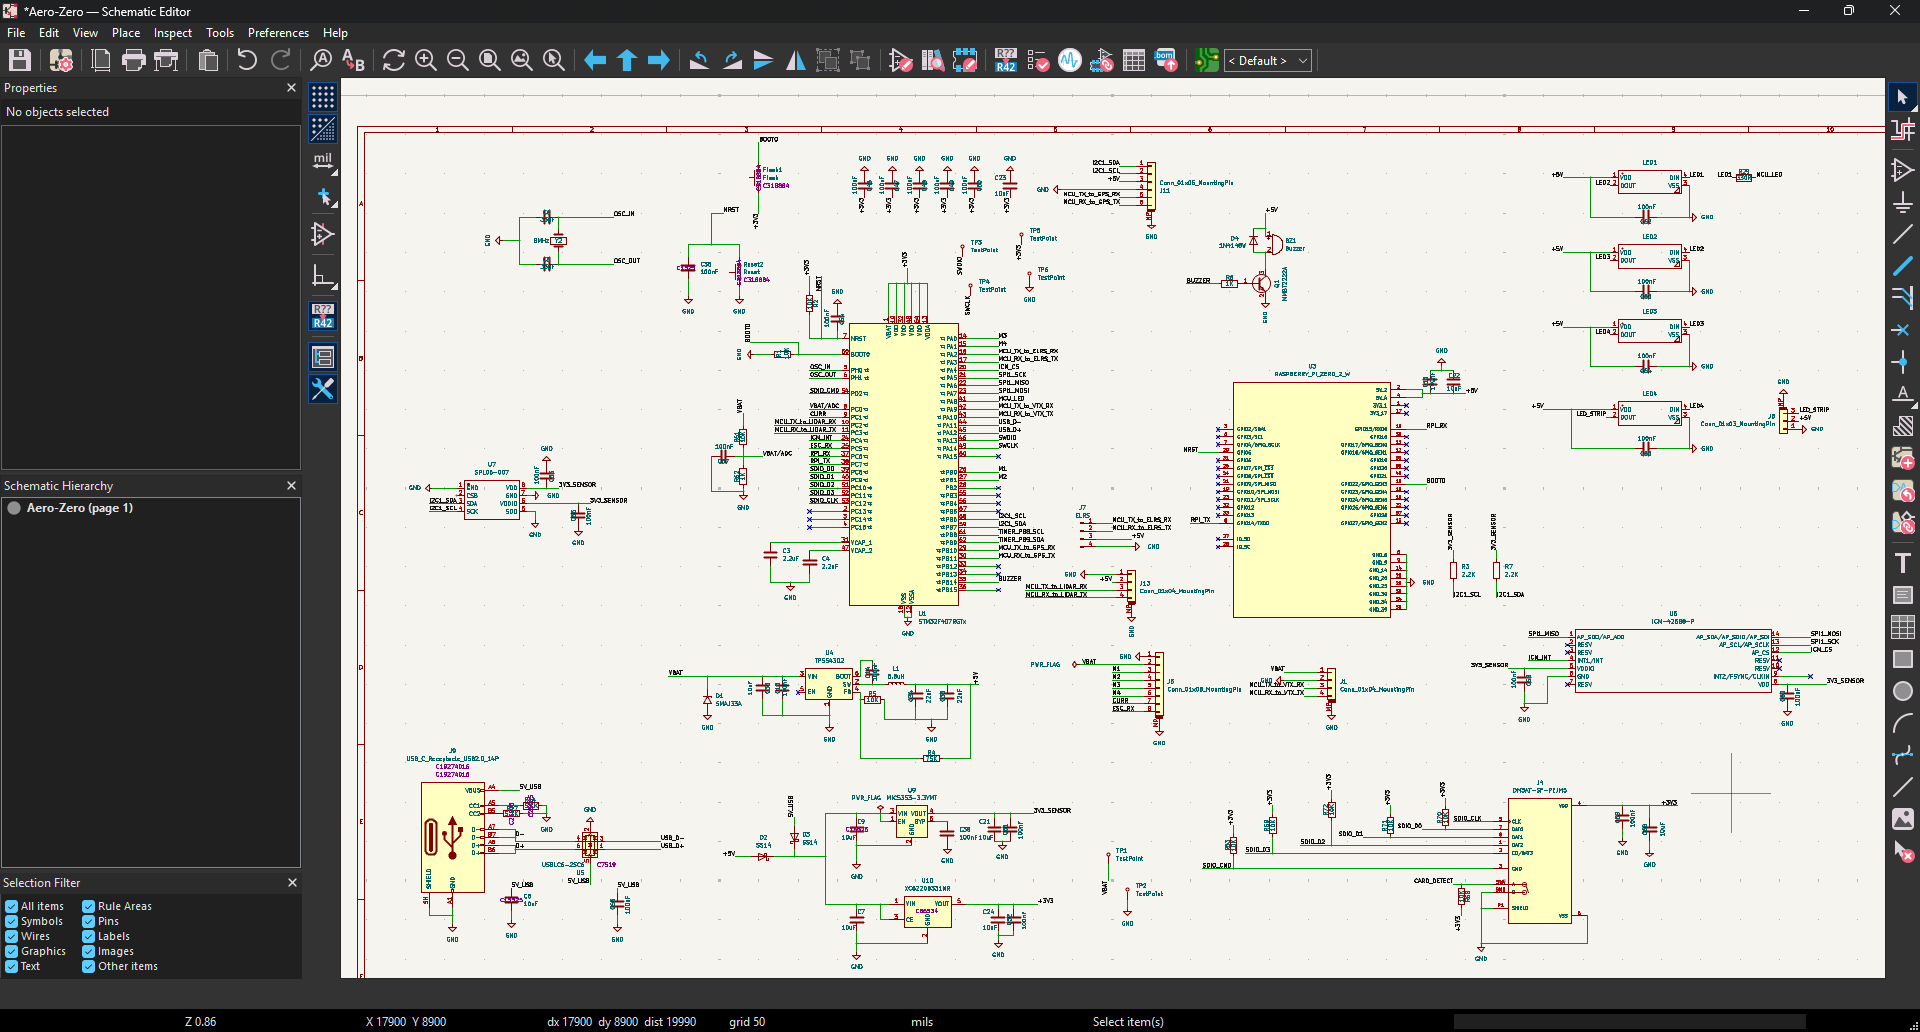
It is built around the SPL06-007, DM3AT-SF-PEJM5 and ICM-42688-P, with the MIC5353-3.3YMT-TR, RASPBERRY PI ZERO 2 W and TPS54302 among its other parts. Its parts include 40 capacitors, 20 resistors, 8 ICs, 8 diodes and 8 connectors. It belongs with the STM32 and Raspberry Pi (Linux) boards of this library.


I started this project, because I wanted to build fully autonomous ai drone. When I looked at the flight controllers available on the market, they were full of hardware that I just do not need or just that I could not add things that I want (for example the Rasberry pi zero 2w) . Most boards also waste a lot of space on powering analog OSD chips, which is completely useless for me because I am flying a purely digital HD system like Walksnail Avatar. Because the technology changed and digital is the standard now, I realized it is just a waste of space to keep the analog stuff and massive connectors.
I am using Raspberry Pi Zero 2W as the computer. Firstly I wanted to use something more powerful to be able to run ai smoother, like allwinner cubie a7z, but it is more expensive and the biggest issue is the firmware and gpio programming on this device. I have no idea, how I would programm this device, when there are basically no manuals or datasheets to this, so I am using the basic raspberry pi zero 2w. So the most interesting thing on this pcb is the pi zero 2w, which is connected to the board by set of pins and screw holes that can be mounted on the pcb by screws.
The drone itself would be able to lift off and fly to a location based on the gps, there is the barometer, from which the drone gets the current altitude and can get to ground. I am using walksnail camera and elrs, plus LIDAR. There is a jst connector for led strip, while at the same time there are built in leds on the drone chassis, esc unit connector and built in electromagnetic buzzer and boot and rst buttons.
The first stage was actually studying the STM32 pinouts and figuring out as much possible of how modern flight controllers handle gyro SPI communication and high speed SDIO routing.
A custom mainboard designed to replace standard generic flight controllers. Built to handle Betaflight high speed kinematics and communicate directly with a Raspberry Pi Zero 2W. Designed entirely from scratch in KiCad 10.
Since this board is built around a custom STM32F405 microcontroller, it runs on the open-source Betaflight firmware. Instead of writing custom flight control loops from scratch, the firmware setup uses a custom target configuration. You can find the complete pin-mapping and resource file (AeroZero_BF_Config.txt) ready in the Firmware folder.
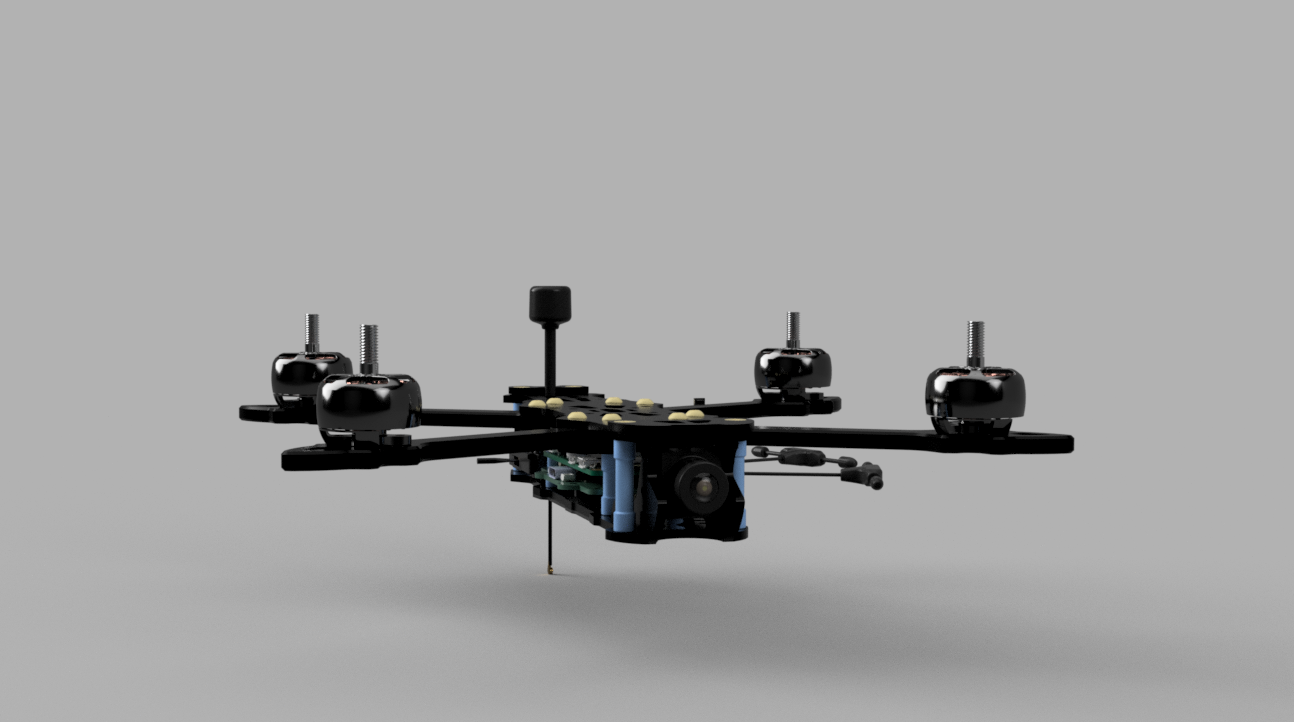
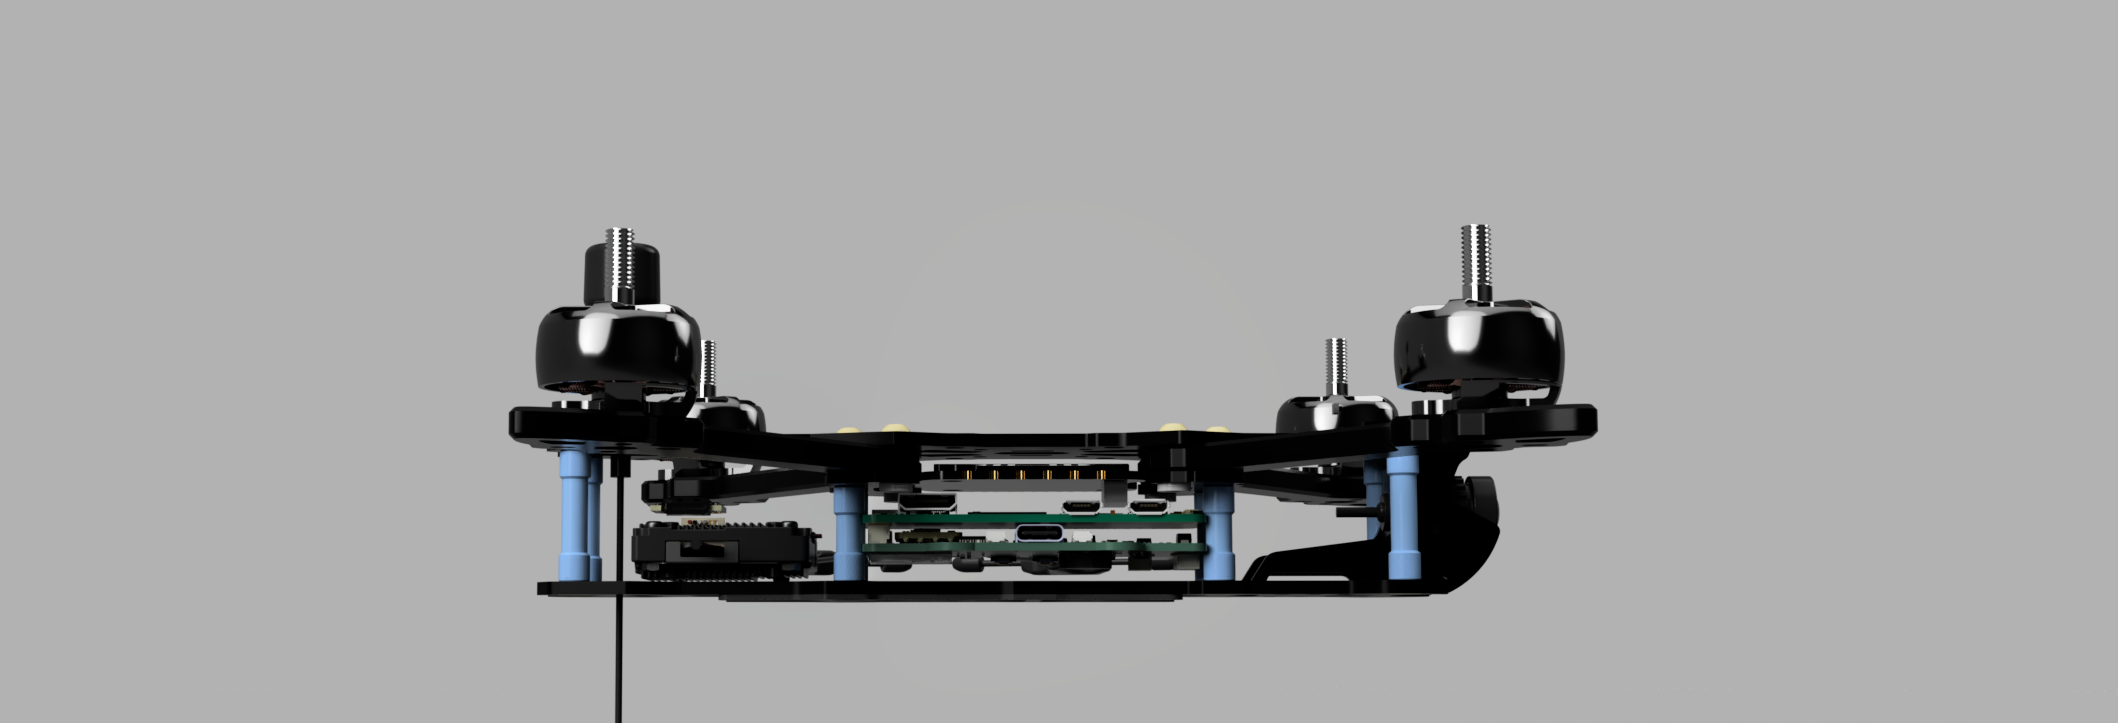
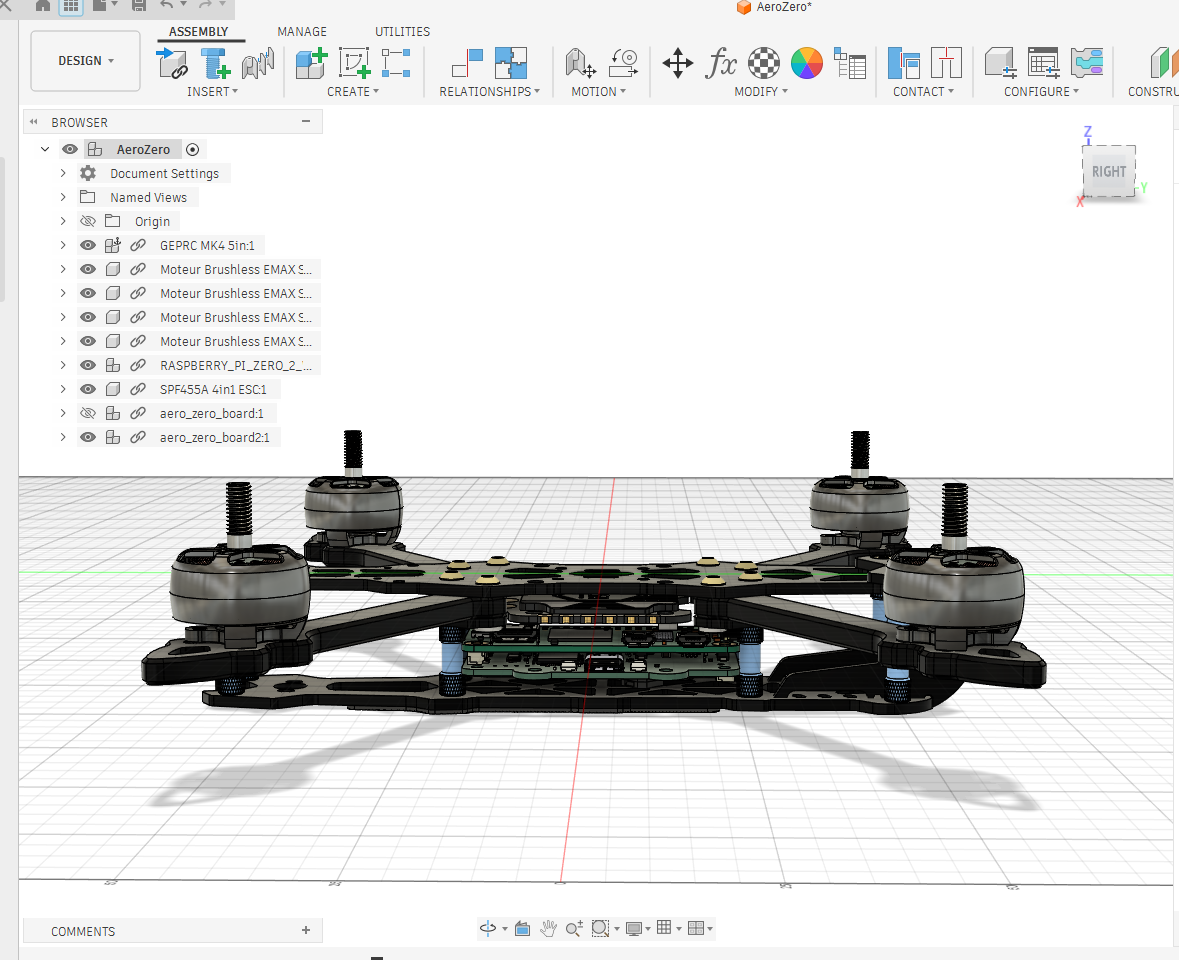
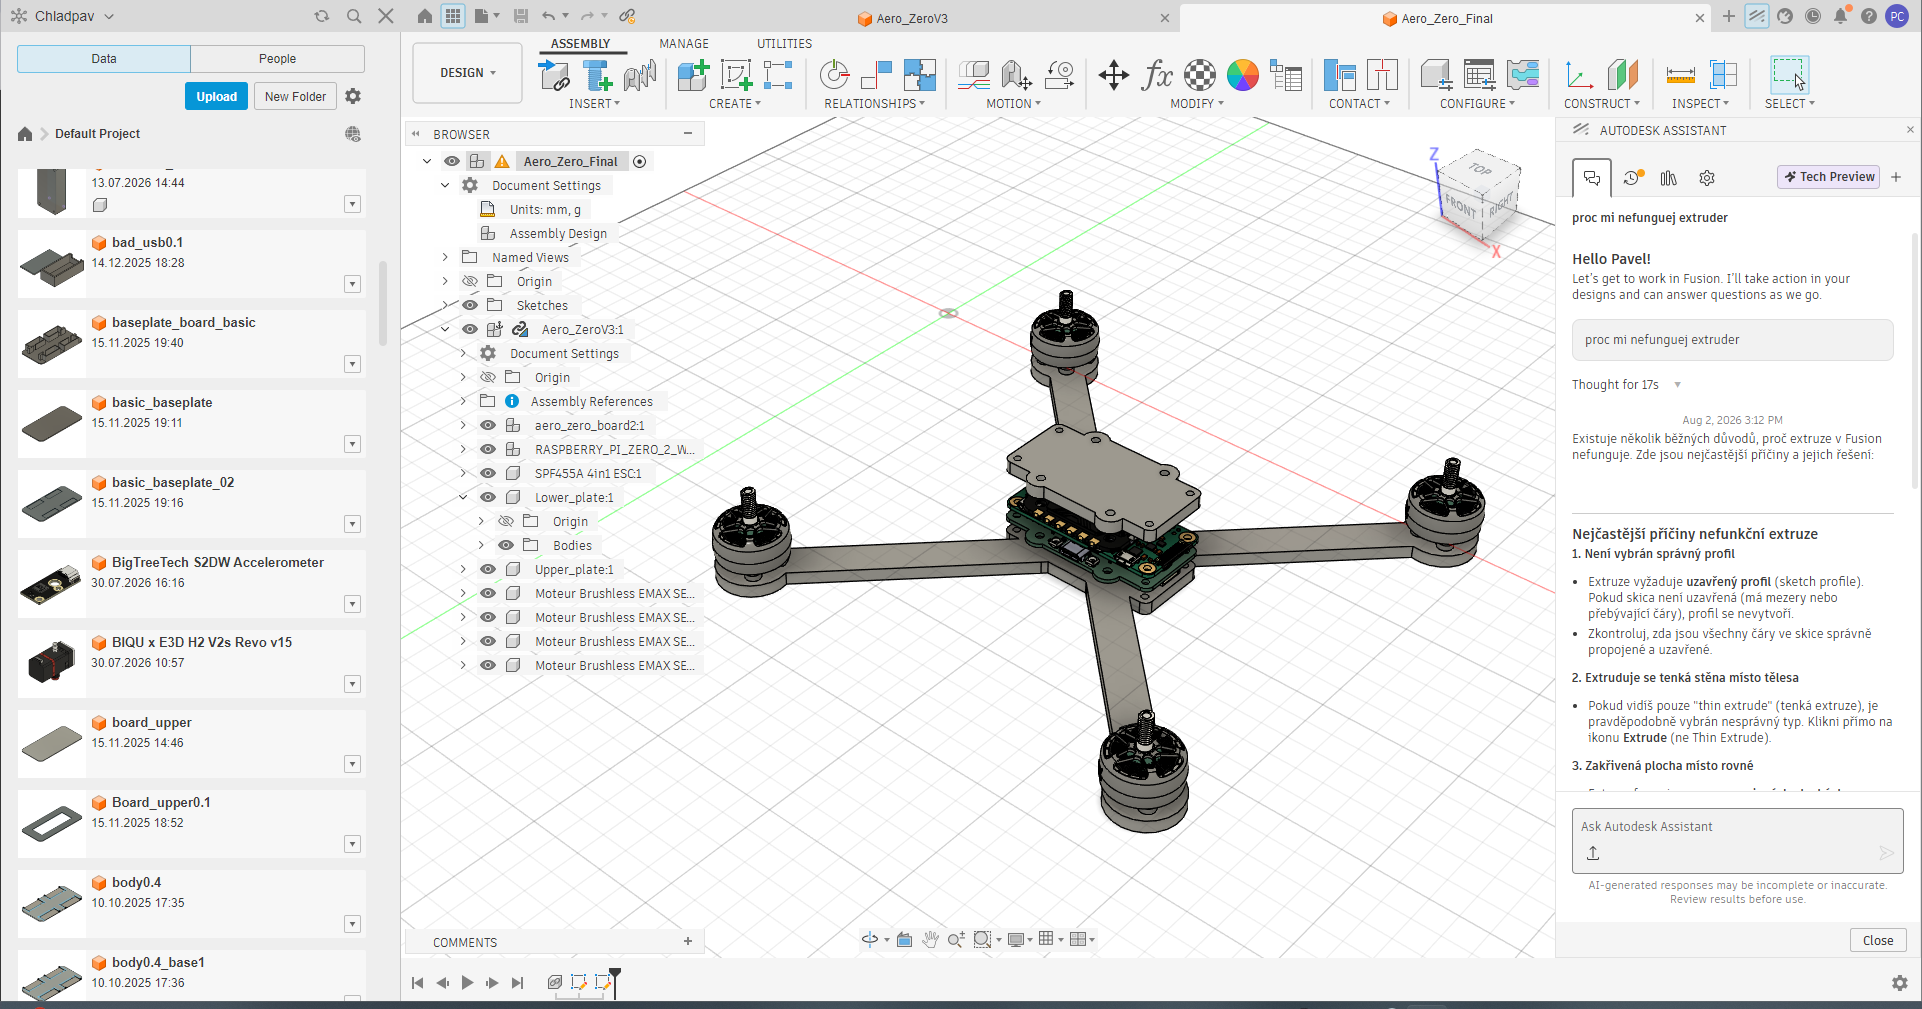
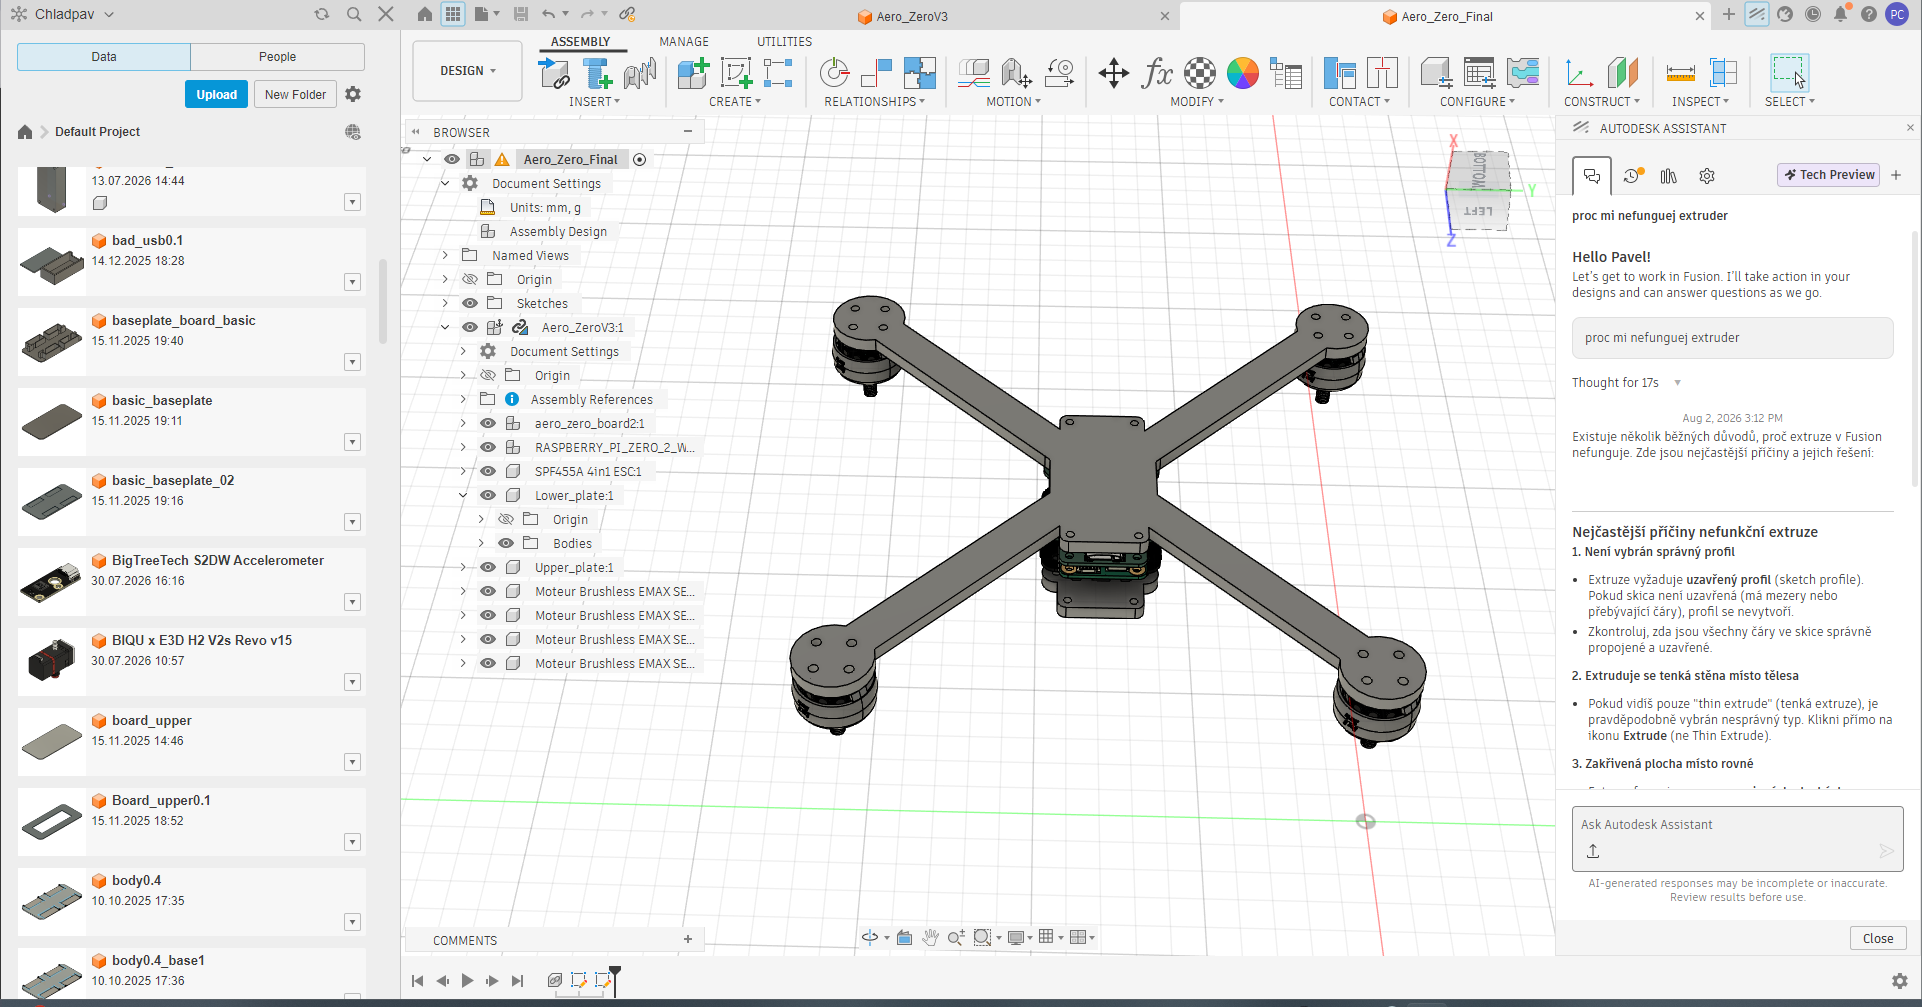
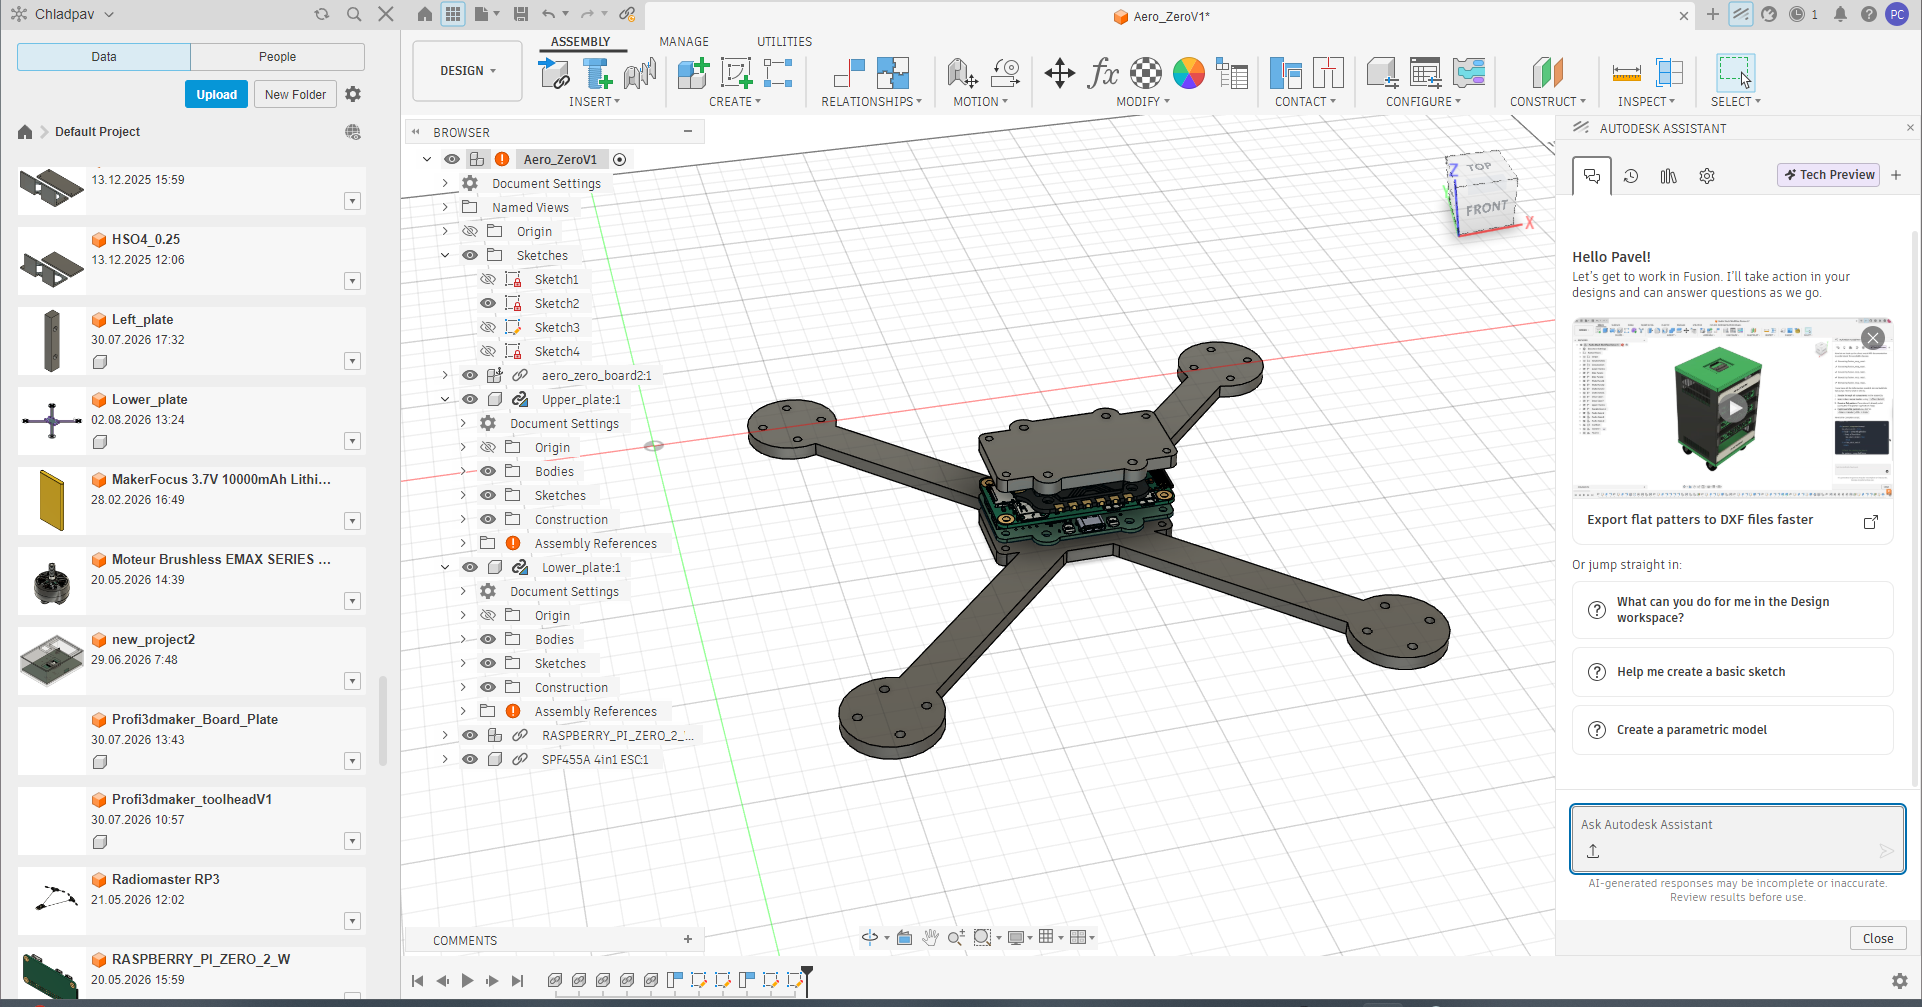
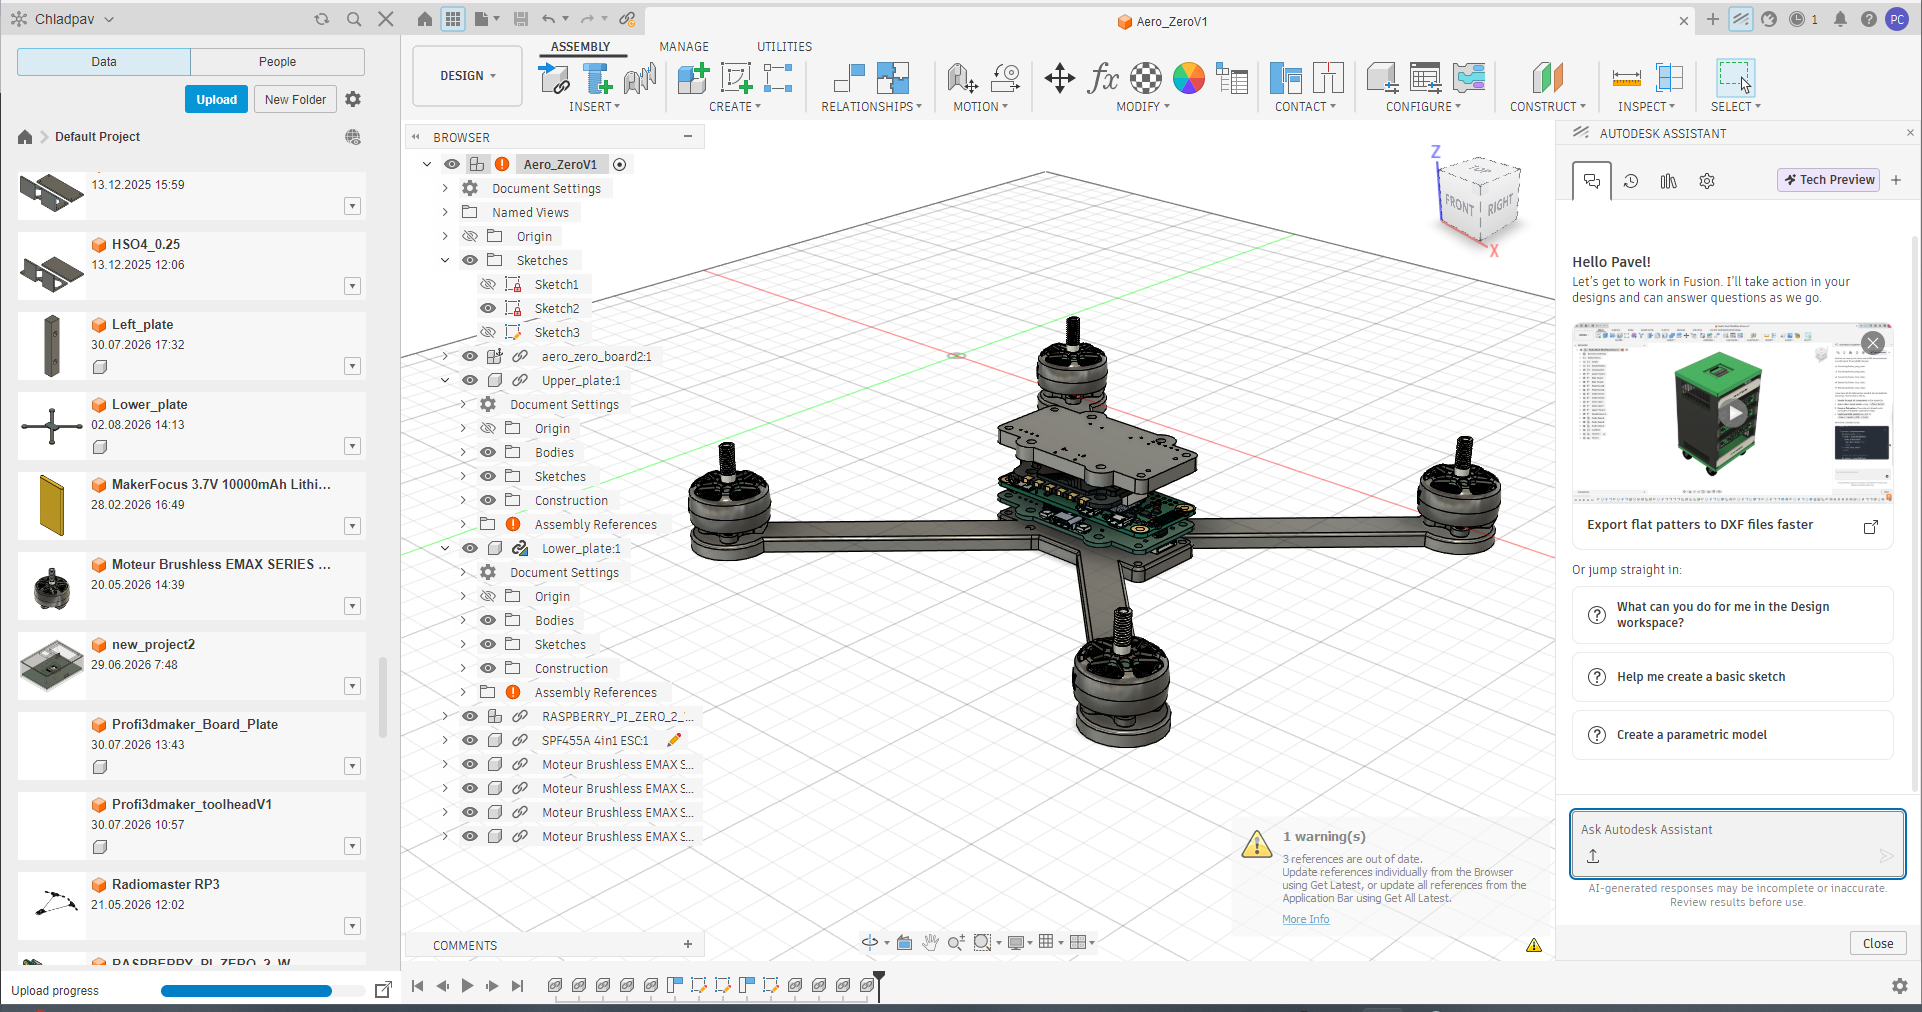
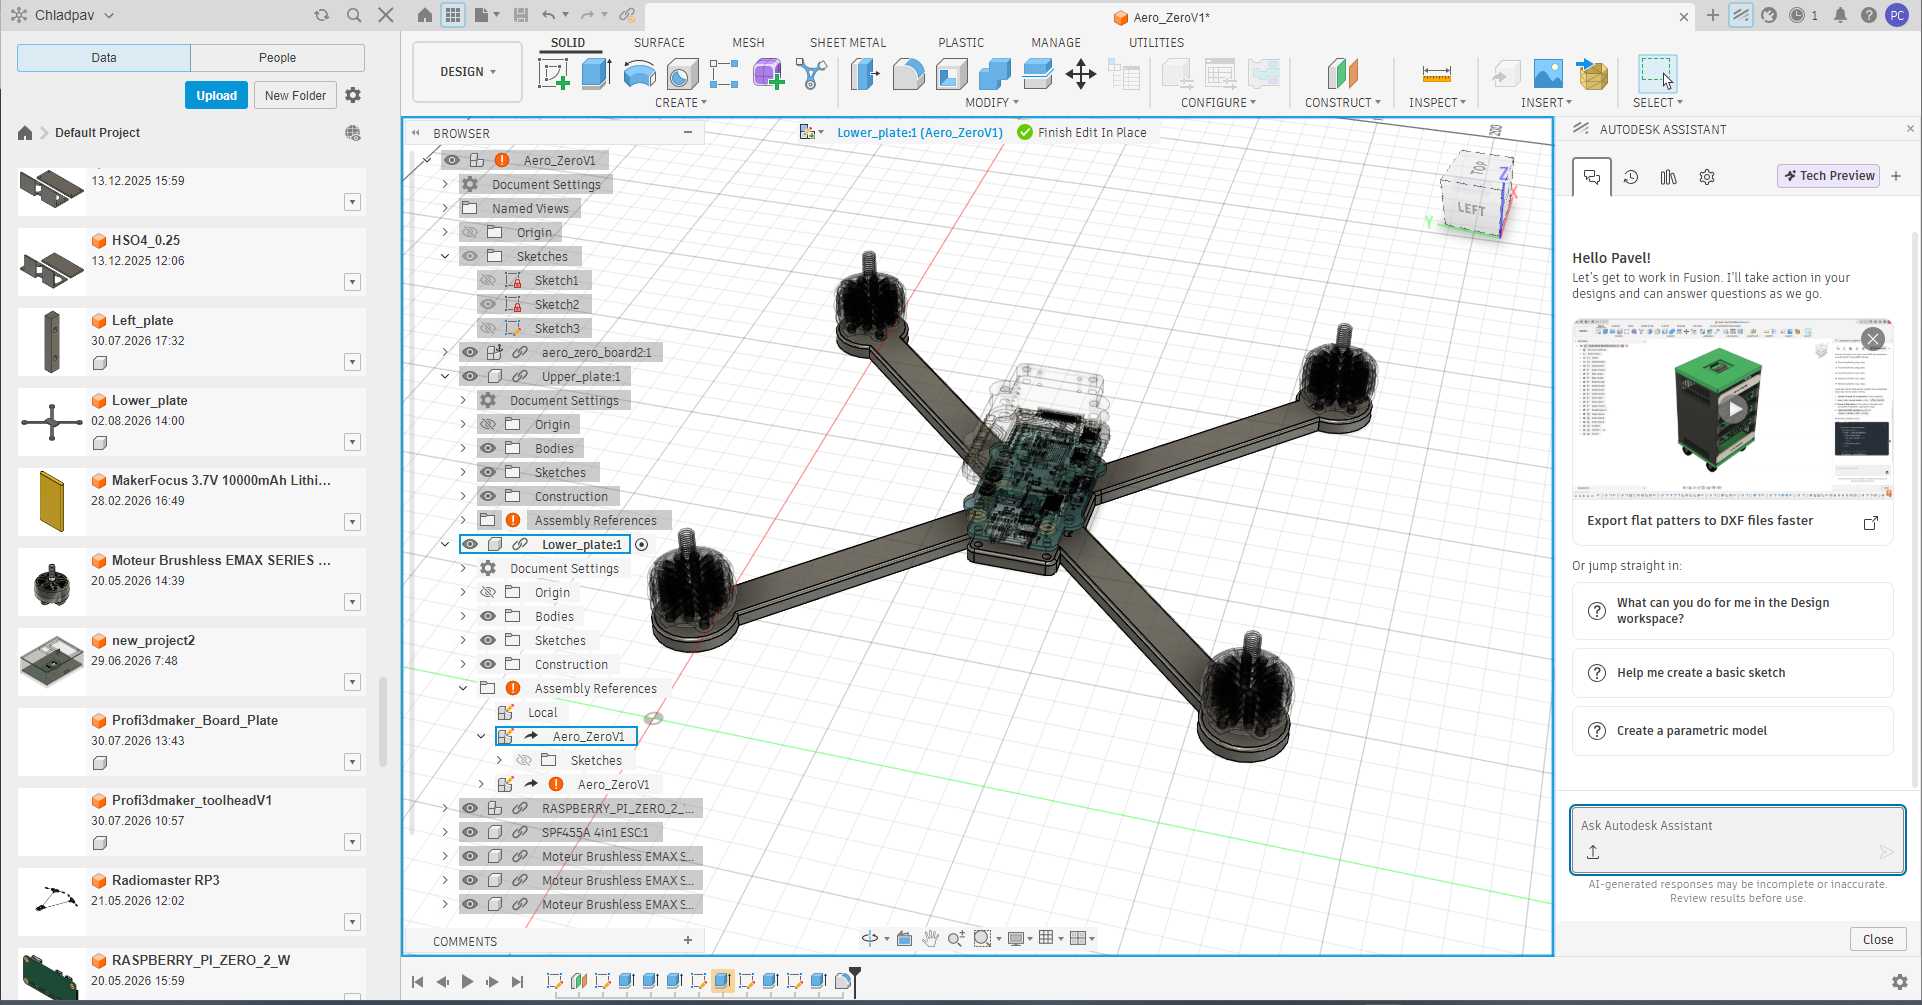
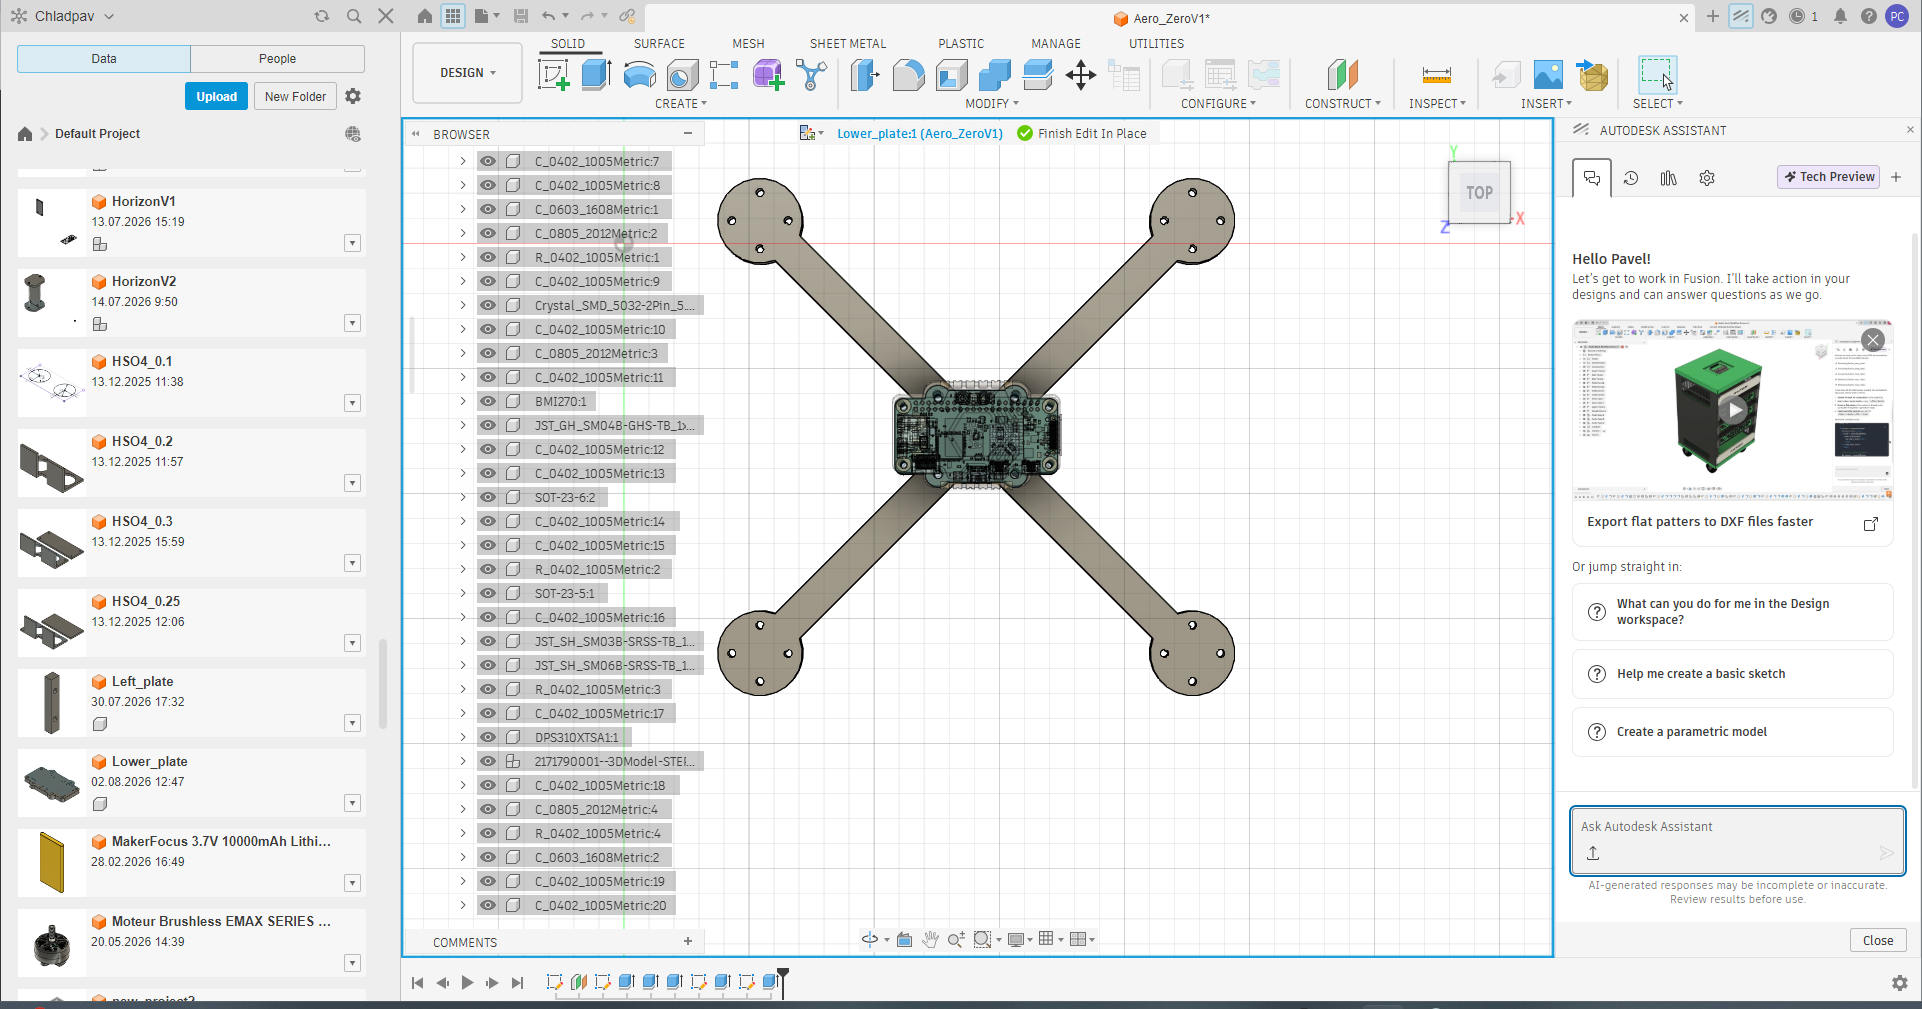
| Component | Qty | Purpose / Description | Price (USD) | Link / Distributor |
|---|---|---|---|---|
| Custom PCBA (Aero-Zero) | 2 | Custom designed 4-layer STM32 flight controller board. Fully assembled via JLCPCB SMT. | $131.50 | JLCPCB |
| GEPRC GEP-M1025-DQ GPS | 1 | High-precision positioning data (u-blox M10) with integrated QMC5883L compass and backup DPS310 barometer. | $19.80 | Banggood |
| SpeedyBee BLS 60A 30x30 4-in-1 ESC | 1 | Electronic Speed Controller (4-in-1) for driving the primary flight motors | $44.00 | AliExpress |
| EMAX ECO II 2207 1700KV Brushless Motor | 4 | Primary propulsion system providing lift and flight dynamics for the drone chassis | $59.00 | AliExpress |
| Raspberry Pi Zero 2 W | 1 | Secondary AI and computer vision processing unit for autonomous flight capabilities | $20.17 | RPiShop (Czech Republic) |
| BETAFPV Nano 2.4GHz ELRS | 1 | 2.4GHz ExpressLRS receiver with T-Type antenna for reliable, low-latency radio control link. | $9.07 | Aliexpress |
| LCSC Discrete Components | 1 | Bottom-side passive components (SD slot, buzzer, flyback diode, resistors/capacitors) for manual assembly. | $16.21 | lcsc.com |
| Qty | Value | Footprint | References |
|---|---|---|---|
| 23 | 100nF | Capacitor_SMD:C_0402_1005Metric | C14, C15, C16, C38, C41, C46, C47, C48, C49, C50, C51, C52, C53, C54, C55, C56 +7 |
| 6 | 10K | Resistor_SMD:R_0603_1608Metric | R53, R68, R69, R70, R71, R72 |
| 4 | 10uF | Capacitor_SMD:C_0603_1608Metric | C7, C9, C33, C68 |
| 4 | TestPoint | TestPoint:TestPoint_Pad_1.0x1.0mm | TP3, TP4, TP5, TP6 |
| 4 | ~ | AeroZero:LED-SMD_4P-L3.5-W3.5-TL_WS2812B | LED1, LED2, LED3, LED4 |
| 3 | 10K | Resistor_SMD:R_0402_1005Metric | R1, R5, R61 |
| 3 | 10uF | Capacitor_SMD:C_0402_1005Metric | C8, C21, C24 |
| 2 | 100nF | Capacitor_SMD:C_0603_1608Metric | C35, C69 |
| 2 | 10uF | Capacitor_SMD:C_0805_2012Metric | C22, C23 |
| 2 | 2,2K | Resistor_SMD:R_0402_1005Metric | R54, R55 |
| 2 | 2.2K | Resistor_SMD:R_0402_1005Metric | R3, R7 |
| 2 | 2.2uF | Capacitor_SMD:C_0603_1608Metric | C3, C4 |
| 2 | 22uF | Capacitor_SMD:C_0805_2012Metric | C34, C36 |
| 2 | 33pF | Capacitor_SMD:C_0402_1005Metric | C5, C6 |
| 2 | 5.1K | Resistor_SMD:R_0402_1005Metric | R14, R17 |
| 2 | SS14 | Diode_SMD:D_SMA | D2, D3 |
| 2 | TestPoint | TestPoint:TestPoint_THTPad_D3.0mm_Drill1.5mm | TP1, TP2 |
| 1 | 10K | Capacitor_SMD:C_0603_1608Metric | R2 |
| 1 | 1K | Resistor_SMD:R_0603_1608Metric | R6 |
| 1 | 1K | Resistor_SMD:R_0402_1005Metric | R62 |
| 1 | 1N4148W | Diode_SMD:D_SOD-123 | D4 |
| 1 | 330R | Resistor_SMD:R_0402_1005Metric | R29 |
| 1 | 6.8uH | AeroZero:IND-SMD_L6.0-W6.0_SWPA6045S | L1 |
| 1 | 75K | Resistor_SMD:R_0603_1608Metric | R4 |
| 1 | 8MHz | Crystal:Crystal_SMD_5032-2Pin_5.0x3.2mm | Y2 |
| 1 | Buzzer | AeroZero:BUZ-SMD_4P-L8.5-W8.5-TL | BZ1 |
| 1 | Conn_01x03_MountingPin | Connector_JST:JST_SH_SM03B-SRSS-TB_1x03-1MP_P1.00mm_Horizontal | J8 |
| 1 | Conn_01x04_MountingPin | Connector_JST:JST_SH_SM04B-SRSS-TB_1x04-1MP_P1.00mm_Horizontal | J1 |
| 1 | Conn_01x04_MountingPin | Connector_JST:JST_GH_SM04B-GHS-TB_1x04-1MP_P1.25mm_Horizontal | J13 |
| 1 | Conn_01x06_MountingPin | Connector_JST:JST_SH_SM06B-SRSS-TB_1x06-1MP_P1.00mm_Horizontal | J11 |
| 1 | Conn_01x08_MountingPin | Connector_JST:JST_SH_SM08B-SRSS-TB_1x08-1MP_P1.00mm_Horizontal | J5 |
| 1 | DM3AT-SF-PEJM5 | AeroZero:HRS_DM3AT-SF-PEJM5_card | J4 |
| 1 | ELRS | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | J7 |
| 1 | Flash | Button_Switch_SMD:SW_Push_1P1T_XKB_TS-1187A | Flash1 |
| 1 | ICM-42688-P | AeroZero:LGA-14_L3.0-W2.5-P0.50-TL | U6 |
| 1 | LOGO | LOGO | G*** |
| 1 | MIC5353-3.3YMT | Package_DFN_QFN:MLF-6-1EP_1.6x1.6mm_P0.5mm_EP0.5x1.26mm | U9 |
| 1 | MMBT2222A | Package_TO_SOT_SMD:SOT-23 | Q1 |
| 1 | RASPBERRY_PI_ZERO_2_W | AeroZero:RpiZero2W_Redukce_Final | U3 |
| 1 | Reset | Button_Switch_SMD:SW_Push_1P1T_XKB_TS-1187A | Reset2 |
| 1 | SMAJ33A | Diode_SMD:D_SMA | D1 |
| 1 | SPL06-007 | AeroZero:SENSOR-SMD_SPL06-007 | U7 |
| 1 | STM32F407RGTx | Package_QFP:LQFP-64_10x10mm_P0.5mm | U1 |
| 1 | TPS54302 | Package_TO_SOT_SMD:SOT-23-6 | U4 |
| 1 | USBLC6-2SC6 | Package_TO_SOT_SMD:SOT-23-6 | U5 |
| 1 | USB_C_Receptacle_USB2.0_14P | Connector_USB:USB_C_Receptacle_HCTL_HC-TYPE-C-16P-01A | J9 |
| 1 | XC6220B331MR | Package_TO_SOT_SMD:SOT-23-5 | U10 |
It measures 65 × 40.1 mm and has 4 copper layers, 1.6 mm thick.
97 parts, built around the SPL06-007, DM3AT-SF-PEJM5, ICM-42688-P and MIC5353-3.3YMT-TR. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the ChladpavPy/Aero-Zero repository on GitHub, at the commit this page was made from: the board is Kicad_Source2/Aero-Zero.kicad_pcb and its schematic Kicad_Source/Aero-Zero.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask ChladpavPy before reusing the design.

ukinori/flightcontroller
STM32H743 VTOL/fixed-wing flight-controller hardware in KiCad 10: routed 4-layer PCB, schematics, BOM notes, connector pinouts and verification reports. Experimental prototype; PX4 port planned.


Starman3787/btc-split-flap
Project to display the value of bitcoin on a split-flap display.

BenjaminJAnderson/CUBE
CUBE is a miniature, six-faced OLED display cube built from a stack of custom interconnected PCBs. The current design combines an ESP32-S2 motherboard, five further display boards, a magnet-held 3D-printed frame and…

HarkonenBade/onizuka
Psyduck (used in image on the ESP8266 board, due to the pun on ESP->ESP->Psychic) is Trademark & © of Nintendo 1996-2015

ishantmahatopro/Vayu-F722
Custom 42x42mm 4-layer STM32F722 FPV flight controller for 5in and 7in cinematic and telemetry quads.

nguyencanhanh/luckfox-rv1103-drone
AI quadcopter on one RV1103 (Luckfox Pico Mini B): Linux + RISC-V MCU flight loop, SITL with 3D pilot view, KiCad flight-controller board