Skip to the content

Boards by arthur-wirjo

5 boards

Open-source boards designed in KiCad by arthur-wirjo on GitHub, from 3 repositories. A board’s address here is its repository’s there.

  • 4 layers72.6 × 72.6 mmFOC V1 PCB, the printed circuit board in 3D

    FOC V1 PCB

    arthur-wirjo/FOC_v1_project

    A custom-designed, 60V 50A Field Oriented Control (FOC) BLDC motor controller built from scratch. Designed for high-performance robotics, featuring a 4-layer power PCB, isolated USB telemetry, and CAN bus communication.

    95 partsMIT
  • 2 layers70 × 56 mmLilithbot PCB v2, the printed circuit board in 3D

    Lilithbot PCB v2

    arthur-wirjo/lilybot_project

    A custom omnidirectional mobile robot combining ESP32-S3 firmware, micro-ROS, and ROS 2 Nav2 for autonomous indoor navigation.

    11 partsMIT
  • 4 layers60 × 70 mmControl board PCB, the printed circuit board in 3D

    Control board PCB

    arthur-wirjo/reaction-wheel-inverted-pendulum

    A custom-engineered Reaction Wheel Inverted Pendulum designed as a physical testbed for advanced modern control theory.

    77 partsMIT
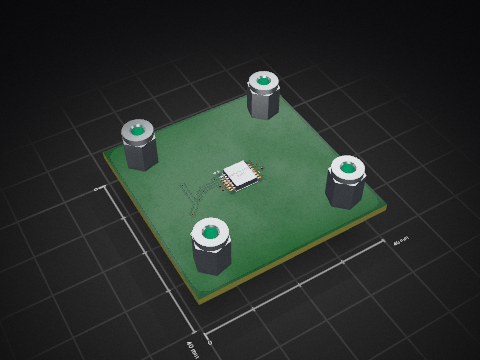
  • 2 layers40 × 40 mmEncoder Module PCB, the printed circuit board in 3D

    Encoder Module PCB

    arthur-wirjo/FOC_v1_project

    A custom-designed, 60V 50A Field Oriented Control (FOC) BLDC motor controller built from scratch. Designed for high-performance robotics, featuring a 4-layer power PCB, isolated USB telemetry, and CAN bus communication.

    8 partsMIT
  • 2 layers54 × 54 mmEncoder board PCB, the printed circuit board in 3D

    Encoder board PCB

    arthur-wirjo/reaction-wheel-inverted-pendulum

    A custom-engineered Reaction Wheel Inverted Pendulum designed as a physical testbed for advanced modern control theory.

    13 partsMIT