2 layers120 × 90 mm
 amstan/tr22
DeltaBot software
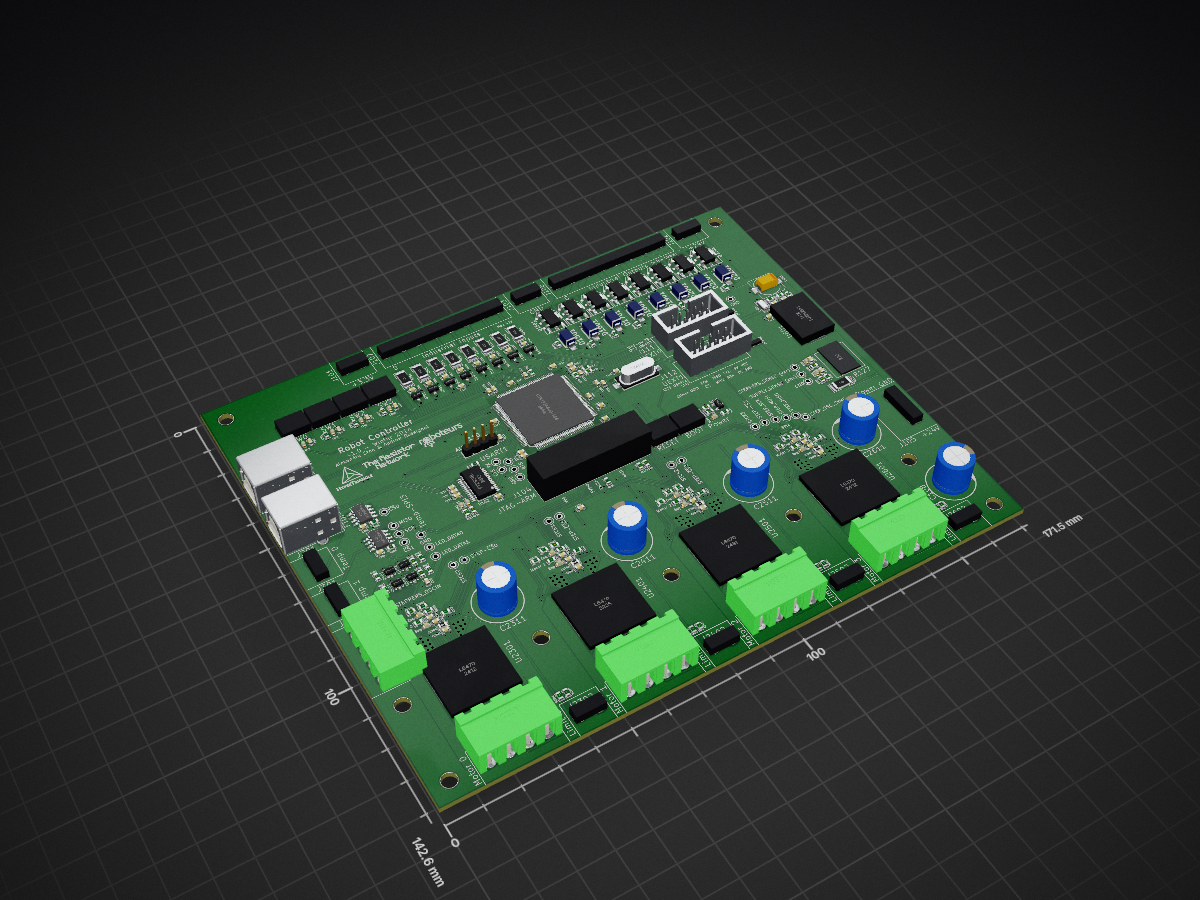
Robot controller is an open-source printed circuit board by amstan, from the amstan/tr2 repository on GitHub. It is a 2-layer board of 171.5 × 142.6 mm with 328 parts on 237 nets, routed with 3,848 tracks and 702 vias.
It is built around the LMZ14201HTZ, MAX6675ISA+ and FT232RL, with the 1SS295, NJT4031NT1G and RSX501L-20TE25 among its other parts. Its parts include 110 capacitors, 85 resistors, 34 diodes, 17 connectors and 13 transistors. It belongs with the robots and motor control boards of this library.


The goal of this project is to develop a hardware and accompanying software platform for controlling robots from a high level programming language such as Python.
The hardware will consist of a multi-axis motor control board, industrial strength GPIO for controlling alarms, incandescent lamps, driving fans and more.
The software will provide an abstract interface to the hardware platform. The first robot that will be tailored to this project will be a 3-axis Delta Robot.
Here is the folder structure for the project:
| Qty | Value | Footprint | References |
|---|---|---|---|
| 36 | 100nF | SMD_Packages:SM0603_Capa | C107, C110, C111, C112, C113, C114, C115, C116, C117, C118, C119, C120, C121, C122, C123, C124 +20 |
| 18 | 10k | SMD_Packages:SM0603_Resistor | R108, R109, R110, R111, R112, R113, R114, R115, R116, R117, R118, R119, R120, R124, R2306, R2406 +2 |
| 17 | 100nF | Capacitors_SMD:c_1808 | C109, C2307, C2308, C2309, C2310, C2407, C2408, C2409, C2410, C2507, C2508, C2509, C2510, C2607, C2608, C2609 +1 |
| 12 | 100pF | SMD_Packages:SM0603_Capa | C2312, C2313, C2314, C2412, C2413, C2414, C2512, C2513, C2514, C2612, C2613, C2614 |
| 12 | 39k | SMD_Packages:SM0603_Resistor | R2302, R2304, R2305, R2402, R2404, R2405, R2502, R2504, R2505, R2602, R2604, R2605 |
| 9 | 100 | SMD_Packages:SM0603_Resistor | R101, R102, R104, R106, R107, R2307, R2407, R2507, R2607 |
| 9 | 3.3k | SMD_Packages:SM2010 | R126, R701, R801, R901, R1001, R1101, R1201, R1301, R1401 |
| 9 | MountingHole_2-5mm_RevA_Date21Jun2010 | components:MountingHole_4mm | MH, MH, MH, MH, MH, MH, MH, MH, MH |
| 8 | 10uF | SMD_Packages:SM0603_Capa | C101, C102, C103, C104, C2304, C2404, C2504, C2604 |
| 8 | 1SS295 | components:SOT23-EXTRASPECIAL | D701, D801, D901, D1001, D1101, D1201, D1301, D1401 |
| 8 | 1nF | SMD_Packages:SM0603_Capa | C701, C801, C901, C1001, C1101, C1201, C1301, C1401 |
| 8 | 470 | SMD_Packages:SM0603_Resistor | R1501, R1601, R1701, R1801, R1901, R2001, R2101, R2201 |
| 8 | NJT4031NT1G | components:SOT223-EXTRASPECIAL | Q1501, Q1601, Q1701, Q1801, Q1901, Q2001, Q2101, Q2201 |
| 8 | RSX501L-20TE25 | Diodes_SMD:Diode-SMA_Handsoldering | D1501, D1601, D1701, D1801, D1901, D2001, D2101, D2201 |
| 6 | 1k | SMD_Packages:SM0603_Resistor | R103, R105, R402, R403, R502, R503 |
| 5 | 100uF | Capacitors:CP_13x21mm | C108, C2311, C2411, C2511, C2611 |
| 5 | 10nF | SMD_Packages:SM0603_Capa | C128, C2302, C2402, C2502, C2602 |
| 5 | 220 | SMD_Packages:SM0603_Resistor | R121, R2303, R2403, R2503, R2603 |
| 5 | 316 | SMD_Packages:SM0603_Resistor | R123, R2301, R2401, R2501, R2601 |
| 4 | 220nF | SMD_Packages:SM0805 | C2301, C2401, C2501, C2601 |
| 4 | 4.7k | SMD_Packages:SM0603_Resistor | R129, R130, R131, R132 |
| 4 | 47uF | SMD_Packages:SM0805 | C2306, C2406, C2506, C2606 |
| 4 | Busy | LEDs:LED-0603 | D2303, D2403, D2503, D2603 |
| 4 | DOUBLE_SCHOTTKY | SMD_Packages:SOT23-SPECIAL | D2301, D2401, D2501, D2601 |
| 4 | Error | LEDs:LED-0603 | D2302, D2402, D2502, D2602 |
| 4 | GND | components:MINI_TP | TP114, TP115, TP116, TP117 |
| 4 | L6470 | components:POWERSO-36 | U2301, U2401, U2501, U2601 |
| 4 | MMBT5962 | SMD_Packages:SOT23_INV | Q401, Q402, Q501, Q502 |
| 2 | 1.1k | SMD_Packages:SM0603_Resistor | R125, R603 |
| 2 | 18pF | SMD_Packages:SM0603_Capa | C105, C106 |
| 2 | 2.2uF | SMD_Packages:SM0603_Capa | C134, C135 |
| 2 | 200 | SMD_Packages:SM0603_Resistor | R401, R501 |
| 2 | 22nF | SMD_Packages:SM0603_Capa | C601, C604 |
| 2 | 3.3V | LEDs:LED-0603 | D108, D109 |
| 2 | JUMPER | components:SOLDER_BRIDGE | JP101, JP102 |
| 2 | MAX6675 | SOIC_Packages:SOIC-8_N | U201, U301 |
| 1 | +24V | components:SCONN_2 | J102 |
| 1 | +3.3V | components:SCONN_2 | J101 |
| 1 | 100uF | SMD_Packages:SM1206 | C602 |
| 1 | 100uH | SMD_Packages:SM0603 | L101 |
| 1 | 10uF | Capacitors_SMD:c_elec_8x10 | C603 |
| 1 | 15k | SMD_Packages:SM0603_Resistor | R122 |
| 1 | 1uF | SMD_Packages:SM0603_Capa | C127 |
| 1 | 22k | components:TRIMMER_POT | R127 |
| 1 | 3.3k | SMD_Packages:SM0603_Resistor | R601 |
| 1 | 33nF | SMD_Packages:SM0603_Capa | C136 |
| 1 | 4.7uF | SMD_Packages:SM0603_Capa | C130 |
| 1 | 62k | SMD_Packages:SM0603_Resistor | R602 |
| 1 | 820 | SMD_Packages:SM0603_Resistor | R128 |
| 1 | 8MHZ | Crystals:Crystal_HC49-SD_SMD | X101 |
| 1 | AUX-USART6 | Pin_Headers:Pin_Header_Straight_1x04 | J110 |
| 1 | BOOT | components:PB | SW106 |
| 1 | CTS | components:MINI_TP | TP120 |
| 1 | FT232RL | SSOP_Packages:SSOP-28 | U102 |
| 1 | FTDI-USB | components:USB_B | J106 |
| 1 | GND | components:SCONN_2 | J103 |
| 1 | Industrial Inputs | components:SCONN_8 | J107 |
| 1 | Industrial Outputs | components:SCONN_8 | J108 |
| 1 | JTAG-ARM | components:SHROUDED_20 | J104 |
| 1 | LED0 | LEDs:LED-0603 | D101 |
| 1 | LED1 | LEDs:LED-0603 | D102 |
| 1 | LED2 | LEDs:LED-0603 | D103 |
| 1 | LED3 | LEDs:LED-0603 | D104 |
| 1 | LED_DATA0 | components:MINI_TP | TP122 |
| 1 | LED_DATA1 | components:MINI_TP | TP123 |
| 1 | LMZ14201 | components:PFM7 | U601 |
| 1 | LOGO | components:resistornetwork | G*** |
| 1 | LOGO | components:roboteurs | G*** |
| 1 | LOGO | components:hypertriangle | G*** |
| 1 | Limit 0 | components:SCONN_2 | J2302 |
| 1 | Limit 1 | components:SCONN_2 | J2402 |
| 1 | Limit 2 | components:SCONN_2 | J2502 |
| 1 | Limit 3 | components:SCONN_2 | J2602 |
| 1 | MCU-USB | components:USB_B | J109 |
| 1 | MISO | components:MINI_TP | TP124 |
| 1 | Motor 0 | components:CONN_STEPPER | J2301 |
| 1 | Motor 1 | components:CONN_STEPPER | J2401 |
| 1 | Motor 2 | components:CONN_STEPPER | J2501 |
| 1 | Motor 3 | components:CONN_STEPPER | J2601 |
| 1 | PNP | components:SOT23-EXTRASPECIAL | Q101 |
The 292 most common of 328 parts.
It measures 171.5 × 142.6 mm and has 2 copper layers, 1.6 mm thick.
328 parts, built around the LMZ14201HTZ, MAX6675ISA+, FT232RL and 1SS295. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the amstan/tr2 repository on GitHub, at the commit this page was made from: the board is board/robot_controller.kicad_pcb and its schematic board/3v3_regulator.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask amstan before reusing the design.


jazzmonger/Traeger-PID-Controller
Traeger Smoker/Grill Controller based on an


FHafting/BREAD
This project is fully documented in the paper: Shane Oberloier, Nicholas G. Whisman, Finn Hafting, Joshua M. Pearce, Open Source Framework for a Broadly Expandable and Reconfigurable Data Acquisition and Automation…