4 layers33 × 81.8 mm
Active drag system minimal
RocketryVT/active-drag-system
Eigen Library, cmake, and arm-none-eabi-gcc tooling required for successful build.
86 parts6MIT
 RocketryVT/active-drag-system6
Eigen Library, cmake, and arm-none-eabi-gcc tooling required for successful build.
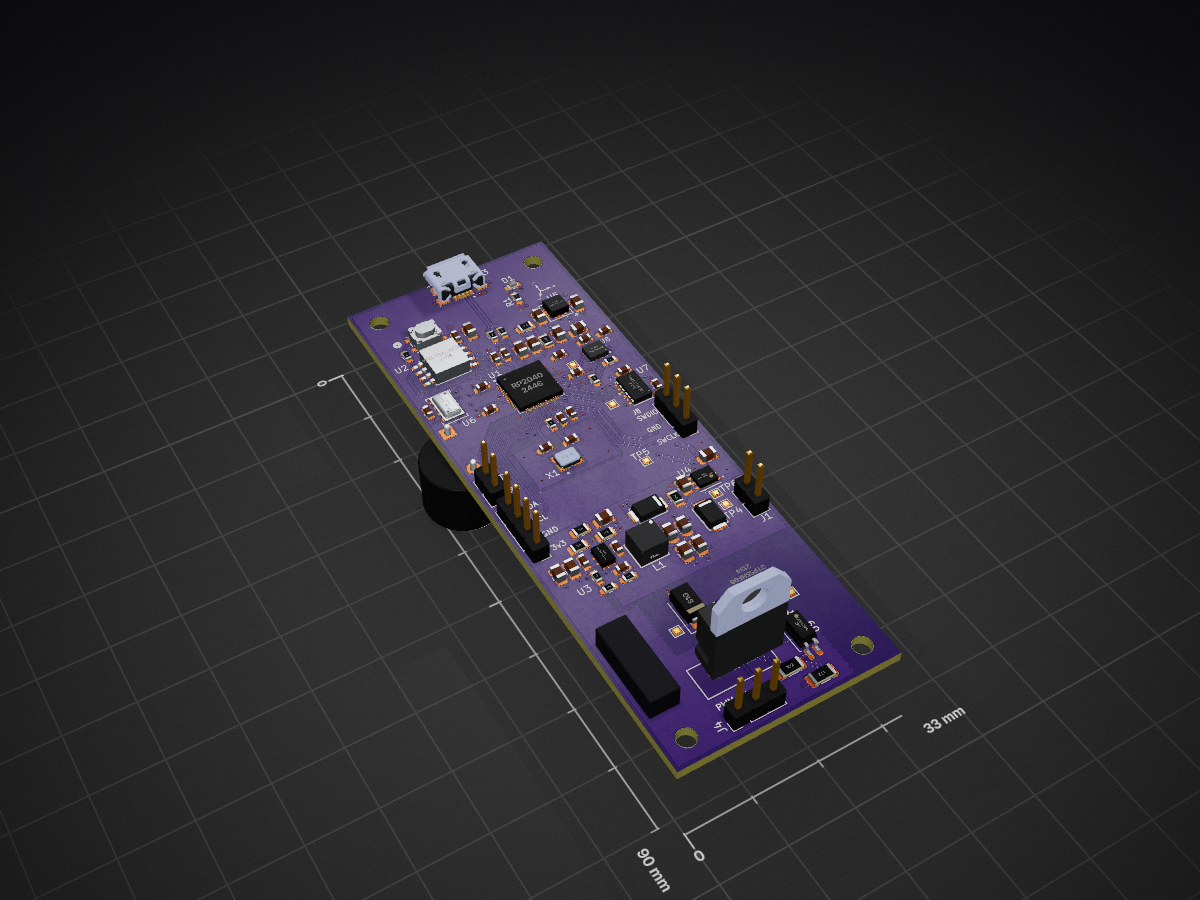
Active drag system is an open-source printed circuit board by RocketryVT, from the RocketryVT/active-drag-system repository on GitHub, published under the MIT licence. It is a 4-layer board of 33 × 90 mm with 100 parts on 91 nets, routed with 587 tracks and 104 vias.
It is built around the RP2040, MMC5983MA and MS560702BA03-50, with the TPS51386RJNR, W25Q128JVSIQ and ADXL375BCCZ among its other parts. Its parts include 35 capacitors, 20 resistors, 10 ICs, 7 connectors and 2 diodes. It belongs with the RP2040 boards of this library.


This is the main codebase for Rocketry at Virginia Tech's Active Drag System, also known colloquially as the ADS, for the 2023-2024 competition year. It runs primarily on a Raspberry Pi Pico, and its goal is to autonomously control the ADS' deployment during flight.
Eigen Library, cmake, and arm-none-eabi-gcc tooling required for successful build.
Note: You must initialize the git submodules prior to utilizing CMake for a proper build.
git clone https://github.com/RocketryVT/active-drag-system.git
cd active-drag-system/
git submodule update --init --recursivecmake -B build
cmake --build buildIn the event that your preferred IDE has trouble locating header files and/or is displaying incorrect errors, pass -DCMAKE_EXPORT_COMPILE_COMMANDS=true to the first CMake command above. Similarly, if you wish to compile the additional tools (e.g. reading flash, calibrating the IMU, etc.), pass -DCOMPILE_TOOLS=true to the first CMake command above as well.
Enable WSL2 in windows Install Ubuntu 22 LTS from Windows Store
sudo apt update && upgrade
sudo apt install build-essential cmake gcc-arm-none-eabiThen to actually build:
cmake -B build
cmake --build buildbrew install arm-none-eabi-gccTo check if installed correctly run:
ls /opt/homebrew/bin | grep "none"you should see a list including but not limited to:
arm-none-eabi-gcc
arm-none-eabi-g++Next:
cmake -B build
cmake --build buildBinary files should be located in build/src/*.uf2 after a successful build.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 15 | 100nF | Capacitor_SMD:C_0603_1608Metric | C1, C2, C6, C7, C8, C9, C12, C14, C15, C16, C19, C28, C32, C33, C35 |
| 5 | 10uF | Capacitor_SMD:C_0805_2012Metric | C17, C18, C26, C27, C30 |
| 5 | 2.2uF | Capacitor_SMD:C_0805_2012Metric | C3, C4, C5, C13, C34 |
| 4 | 100k | Resistor_SMD:R_0805_2012Metric | R10, R12, R13, R16 |
| 4 | 10k | Resistor_SMD:R_0603_1608Metric | R5, R6, R14, R15 |
| 4 | 22uF | Capacitor_SMD:C_0805_2012Metric | C20, C21, C22, C23 |
| 4 | MountingHole | MountingHole:MountingHole_2.7mm_M2.5 | H1, H2, H3, H4 |
| 2 | 15pF | Capacitor_SMD:C_0603_1608Metric | C10, C11 |
| 2 | 1k | Resistor_SMD:R_0603_1608Metric | R8, R9 |
| 2 | 1uF | Capacitor_SMD:C_0805_2012Metric | C25, C29 |
| 2 | 27 | Resistor_SMD:R_0603_1608Metric | R3, R4 |
| 2 | 4.7k | Resistor_SMD:R_1206_3216Metric | R17, R18 |
| 2 | Conn_01x02_Pin | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J1, J5 |
| 2 | Conn_01x03_Pin | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J4, J8 |
| 2 | PMEG3050EP_115 | active-drag-system:SDO_CFP5_SOD128_NEX | CR1, CR2 |
| 1 | 1 | Resistor_SMD:R_0805_2012Metric | R7 |
| 1 | 100 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R1 |
| 1 | 10118193-0001LF | active-drag-system:AMPHENOL_10118193-0001LF | J3 |
| 1 | 10nF | Capacitor_SMD:C_0603_1608Metric | C31 |
| 1 | 150k | Resistor_SMD:R_0603_1608Metric | R11 |
| 1 | 1k | Resistor_SMD:R_1206_3216Metric | R19 |
| 1 | 200 | Resistor_SMD:R_0805_2012Metric | R2 |
| 1 | 220 | Resistor_SMD:R_1206_3216Metric | R20 |
| 1 | 22pF | Capacitor_SMD:C_0603_1608Metric | C24 |
| 1 | 3V3 | TestPoint:TestPoint_Pad_1.0x1.0mm | TP5 |
| 1 | 5V | TestPoint:TestPoint_Pad_1.0x1.0mm | TP4 |
| 1 | ABM8AIG-12.000MHZ-12-2Z-T3 | active-drag-system:XTAL_ABM8AIG-12.000MHZ-12-2Z-T3 | X1 |
| 1 | ADXL375BCCZ | active-drag-system:LGA_CC-14-1_ADI | U7 |
| 1 | Buzzer | Buzzer_Beeper:Buzzer_12x9.5RM7.6 | BZ1 |
| 1 | CLKIN | TestPoint:TestPoint_Pad_1.0x1.0mm | TP17 |
| 1 | Conn_01x02_Socket | Connector_Wire:SolderWire-2sqmm_1x02_P7.8mm_D2mm_OD3.9mm | J2 |
| 1 | Conn_01x04_Pin | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J6 |
| 1 | FODM217A | Package_SO:SOP-4_4.4x2.6mm_P1.27mm | U9 |
| 1 | HGINT1 | TestPoint:TestPoint_Pad_1.0x1.0mm | TP20 |
| 1 | HGINT2 | TestPoint:TestPoint_Pad_1.0x1.0mm | TP21 |
| 1 | IIM-42653 | active-drag-system:PQFN50P250X300X97-14N | U8 |
| 1 | LD39200PU33R | active-drag-system:SON_DFN6_3X3_STM | U4 |
| 1 | LOGO | active-drag-system:rocketry_logo | G*** |
| 1 | LOGO | active-drag-system:cringe_cam | G*** |
| 1 | LOGO | active-drag-system:3_axis | G*** |
| 1 | MGINT | TestPoint:TestPoint_Pad_1.0x1.0mm | TP18 |
| 1 | MINT | TestPoint:TestPoint_Pad_1.0x1.0mm | TP19 |
| 1 | MMC5983MA | active-drag-system:MMC5983MA_MEM | U5 |
| 1 | MS560702BA03-50 | active-drag-system:SON8_MS5611_TEC | U6 |
| 1 | PTS815 SJM 250 SMTR LFS | active-drag-system:SW4_PTS815_SJM_250_SMTR_LFS_CNK | SW1 |
| 1 | RP2040 | active-drag-system:QFN-56-1EP_7x7mm_P0.4mm_EP3.2x3.2mm_ThermalVias | U1 |
| 1 | S1G | Diode_SMD:D_SMA | D2 |
| 1 | SCL0 | TestPoint:TestPoint_Pad_1.0x1.0mm | TP2 |
| 1 | SDA0 | TestPoint:TestPoint_Pad_1.0x1.0mm | TP3 |
| 1 | SERVO_ENABLE | TestPoint:TestPoint_Pad_1.0x1.0mm | TP7 |
| 1 | SERVO_PWM | TestPoint:TestPoint_Pad_1.0x1.0mm | TP8 |
| 1 | STP55NF06 | active-drag-system:STP55NF06 | U10 |
| 1 | TPS51386RJNR | active-drag-system:VQFN-HR12_RJN_TEX | U3 |
| 1 | VCORE | TestPoint:TestPoint_Pad_1.0x1.0mm | TP1 |
| 1 | VSYS | TestPoint:TestPoint_Pad_1.0x1.0mm | TP6 |
| 1 | W25Q128JVSIQ | active-drag-system:SOIC_128JVSIQ_WIN | U2 |
| 1 | WE-MAIA_4020 | active-drag-system:WE-MAIA_4020 | L1 |
| 1 | WL-SMCW_0603 | active-drag-system:WL-SMCW_0603 | D1 |
RocketryVT/active-drag-system
Eigen Library, cmake, and arm-none-eabi-gcc tooling required for successful build.


shorlee/TeleSTERN
The TeleSTERN Project is an Open Source Rocketry Flight Computer based on the TeleMega by Altus Metrum.

daedalus-ind/icarus-hardware
Hardware of the onboard flight computer for the Icarus rocket.

IlyaasAitSimmou/krakenbane_one_pcb
This GitHub Repository contains all kiCad files related to the SRAD data aqcuisition flight computer, KRAKENBANE I which was flown at Launch Canada on the Goldeneye rocket by the Turner Fenton Rocketry Association…


It measures 33 × 90 mm and has 4 copper layers, 1.54 mm thick.
100 parts, built around the RP2040, MMC5983MA, MS560702BA03-50 and TPS51386RJNR. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the RocketryVT/active-drag-system repository on GitHub, at the commit this page was made from: the board is hardware/active-drag-system.kicad_pcb and its schematic hardware/active-drag-system-minimal.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).