2 layers37 × 19 mm
Passive rpi hub75-adapter
hzeller/rpi-rgb-led-matrix
Controlling up to three chains of 64x64, 32x32, 16x32 or similar RGB LED displays using Raspberry Pi GPIO
2 parts4.4kGPL-2.0
 RoboticsUnion/Heavy-Core-MK12
Repo for our Version 1 robot arm.
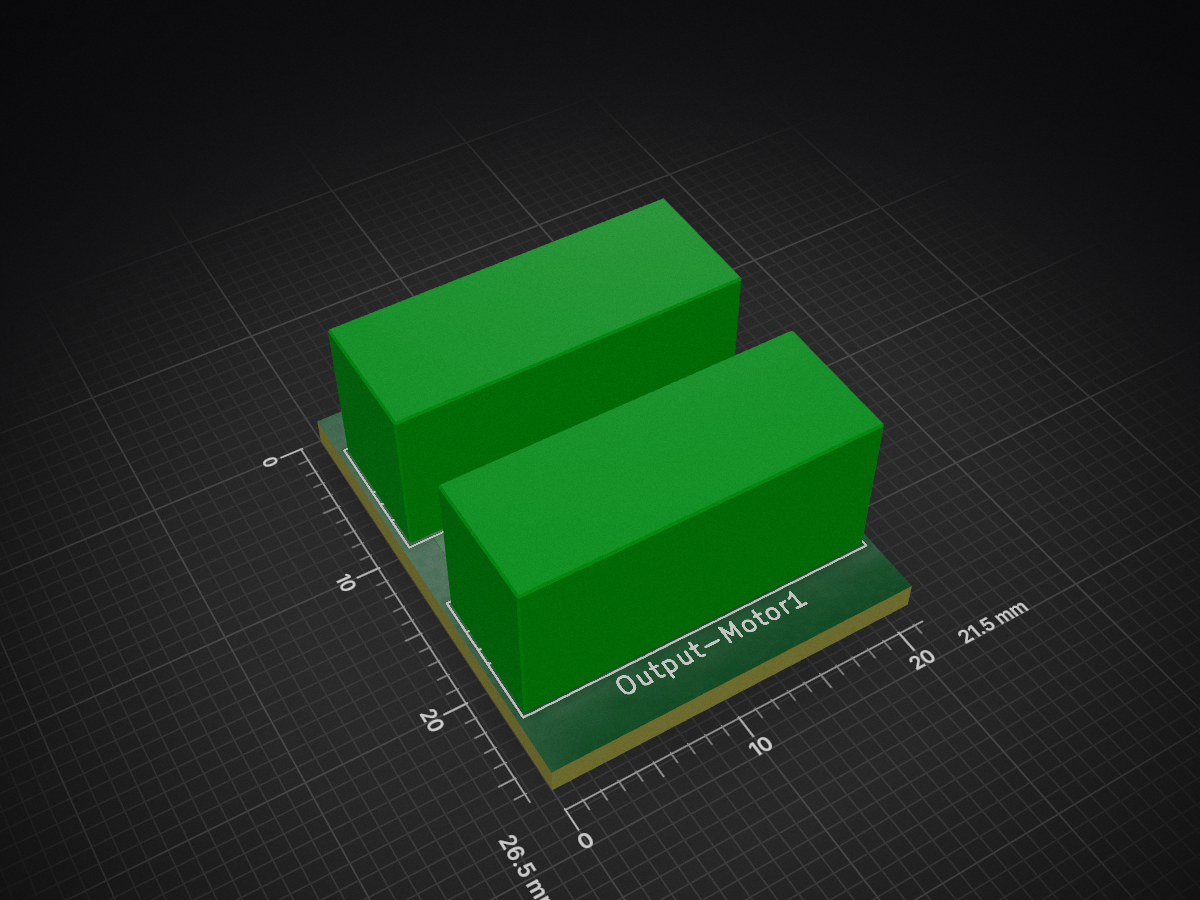
Heavy Core mk1 breakout bord is an open-source printed circuit board by RoboticsUnion, from the RoboticsUnion/Heavy-Core-MK1 repository on GitHub. It is a 2-layer board of 21.5 × 26.5 mm with 2 parts on 4 nets, routed with 8 tracks and 0 vias.
It belongs with the robots and motor control and interfaces and adapters boards and the NXP (LPC, Kinetis, i.MX RT) boards of this library.
Heavy-Core-MK1 is the development of a modular robotic arm platform. The goal is to create a scalable, affordable robotics ecosystem where hardware and software are engineered together from the ground up.
The first two axes have already been designed, printed, assembled, and successfully tested. In parallel, we are developing our own control software for precise motion control.
We aim to build a 6 DOF robitic arm that:
Our robotic arm will not rely solely on position control. We are developing a control application that will include:
Completed:
In Progress:
| Phase | Description | Target |
| MK1 Alpha | 2 DOF mechanical validation, first project showcase | Completed |
| MK1 Beta | 4-6 DOF mechanical prototype | Q4 2026 (estimated) |
| MK1 Software Alpha | Basic motion control & UI | Q4 2026 |
| MK1 Integrated Demo | Hardware + software functional for demonstration | Q1 2027 (January, HTL Open house) |
| MK1 Full Prototype | Fully functional 6 DOF with software improvements | Post Open House (future milestone) |
Heavy-Core is more than a 3D-printed robotic arm. It is the foundation for a modular robotics ecosystem that is mostly custom designed.
Mechanical engineering, electronics and software development are combined in one unified system, driven by the abition and passion of young engineers.
This complete robotic arm system is fully open source and available on GitHub, providing unrestricted access to all hardware designs, electronics, and software, enabling developers worldwide to customize, improve, and extend the platform.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 2 | Screw_Terminal_01x04 | TerminalBlock:TerminalBlock_MaiXu_MX126-5.0-04P_1x04_P5.00mm | Input-Controler1, Output-Motor1 |
hzeller/rpi-rgb-led-matrix
Controlling up to three chains of 64x64, 32x32, 16x32 or similar RGB LED displays using Raspberry Pi GPIO


adamws/kicad-kbplacer
KiCad plugin for automatic keyboard's key placement and routing

Luos-io/luos_engine
Open-source and real-time orchestrator for cyber-physical-systems, to easily design, test and deploy embedded applications and digital twins.

NVNTLabs/switch2-SDEX2M2
Micro SD Express to M.2 NVME Adapter for Nintendo Switch 2

BlueSCSI/BlueSCSI-v2
BlueSCSI v2/Ultra - an open source, open hardware, SCSI emulator using the Pi Pico PR2040 and Pico 2 RP2350

ohmtech-rdi/eurorack-blocks
Software to Hardware Prototyping for Eurorack using C++, Max/Gen~ or Faust

It measures 21.5 × 26.5 mm and has 2 copper layers, 1.6 mm thick.
2 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the RoboticsUnion/Heavy-Core-MK1 repository on GitHub, at the commit this page was made from: the board is electronic _engineering/Mainboard_engineering/Heavy_Core_mk1_breakout_bord/Heavy_Core_mk1_breakout_bord.kicad_pcb and its schematic electronic _engineering/Mainboard_engineering/Heavy_Core_mk1_breakout_bord/Heavy_Core_mk1_breakout_bord.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask RoboticsUnion before reusing the design.