Skip to the content
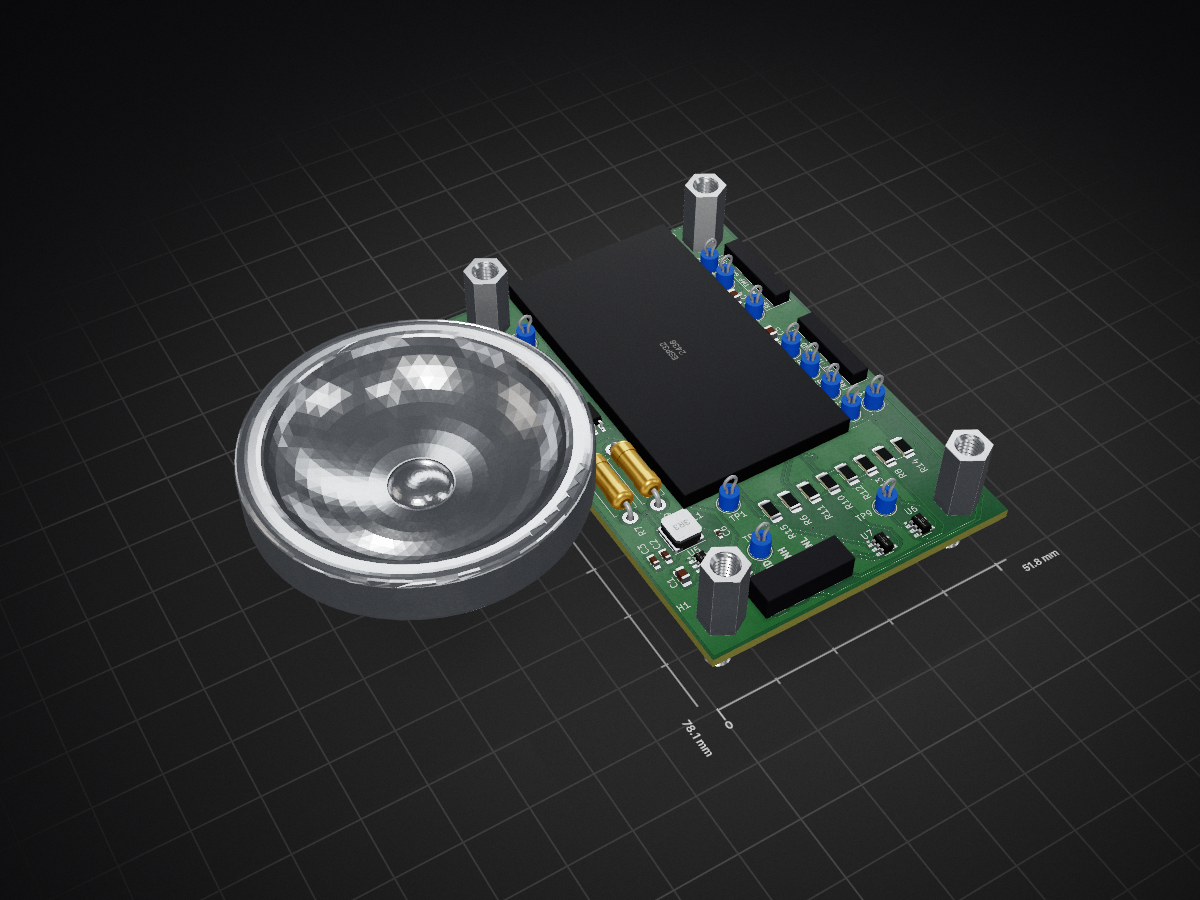
2 layers51.8 × 78.1 mmCVTPCB, the printed circuit board in 3D

A subsystem that measures the RPM of the primary and secondary on the CVT

Size
51.8 × 78.1 mm
Copper layers
2
Thickness
1.6 mm
Parts
46
Nets
45
Pads
131
Tracks, vias
333, 25
Pours
2
Routed
Yes
KiCad
KiCad 8.0 (file 20240108)
Created
30 Sep 2023
Updated
26 Apr 2026

Overview

CVTPCB is an open-source printed circuit board by NJIT-Highlander-Racing-Electrical, from the NJIT-Highlander-Racing-Electrical/CVT-Tachometer repository on GitHub. It is a 2-layer board of 51.8 × 78.1 mm with 46 parts on 45 nets, routed with 333 tracks and 25 vias.

It is built around the TJA1051T/3/1 and AP62301WU. Its parts include 13 resistors, 6 capacitors, 5 ICs, 3 connectors and 1 switch. It belongs with the ESP32 boards of this library.

Main components

2

README

README.md

CVT-Tachometer

A subsystem that measures the RPM of the primary and secondary on the CVT. This subsystem also has a temperature sensor to detect if the CVT is overheating.

2024-2025 Design Goals

  • Everything last year seemed to work well, but a few improvements to the existing system could be made:
    • Software
      • Improve program to do more analog reads and spend less time processing data
        • This may involve constants that are only calculated once during setup, faster math functions, fewer delays, etc
      • Use the analog reads for IR sensors on both ADC1 and ADC2 to prevent any issues.
    • Sensor Enclosures
      • the sensor housings should be made out of something other than PLA
      • they should be able to fit custom PCBs with connectors
      • the hood around the emitter and receiver should be enlarged to prevent anything else from reflecting other than what is directly in front
    • PCBs for sensors
      • the wiring from the sensors to the main electronics housing were tough to do
      • A small PCB for the electronics would be nicer than hand soldering wires
      • A connector would also be good so that they can be removed/swapped easily
        • Maybe 1x4 or 1x5 or 1x6 JST depending on how many conductors we need going to each board
    • Additional TMP36 Sensor
      • Another TMP36 temperature sensor can be added so that there is only one version of the sensor PCB, and we get a better idea of the temperature gradient within the CVT case (primary vs secondary).
    • Additional Note
      • On the IR receiver output, have it split to two GPIO. One leg has a potentiometer (0-10k?) between the output and the GPIO for finding the optimal resistance. Also make sure it has a small series resistor to prevent resistance from dropping completely to zero. The other GPIO has a fixed resistor that can be added after the fact that will be used in the long term.

Hardware Components:

  • IR Sensors that point at primary and secondary.
  • These can detect when a white stripe on the CVT passes by (one revolution)
  • Microcontroller to convert the number of revolutions per second into an RPM value for dashboard and DAS (via CAN-Bus)
    • Uses ESP32 and TJA1051T CAN-Bus transceiver
  • TMP36 Temperature Sensor to look at ambient temperature in the CVT case
  • Sends a bit via CAN-Bus to turn on an overheating status LED on the dashboard

Notes

  • Super-Bright IR LEDs support an output current of 100mA with a forward voltage of 1.6V. This means a voltage drop of 5V-1.6V = 3.4V across the 1W resistor. To achieve a current of roughly 75mA, we are using a 47 ohm resistor

    • 5V -> IR LED -> Resistor -> Ground
  • Using standard infrared photodiodes, we can simply power the IR leds without needing a 38kHz pulse rate

    • 5V -> IR Diode -> Resistor -> Ground (sample signal between diode and resistor voltage divider)
  • Temperature sensor is TMP36

    • 5V - > TMP36 VCC, GND -> TMP 36 GND, VOUT -> GPIO
  • Connections from the LEDs/sensors to the main body should be sealed/waterproof

  • The holes in the CVT case should be 20mm

  • The infrared diode appears to act like a variable resistor, but voltage polarity must be + on cathode (short negative leg) and - on anode (short positive leg)

  • The software utilizes the dual core functionality of the ESP32

    • Core 1 reads primaryRPM and deals with CAN-Bus communication
      • It is very important that all other processing is kept to a minimum to ensure primaryRPM is accurately read
    • Core 0 solely reads secondaryRPM

Previous Issues

  • One issue noticed during the testing phase was that the analog sensor readings were constantly peaking (4095). The resistor divider for the IR receivers needed to be adjusted to roughly 2700 ohms
  • It looked like the analog readings were having issues at comp too. It was either 0-3 ish mph or 41
    • This has been solved on 9/18/24 with dynamically adjusting analog thresholds
  • Analog reads are not ideal for this type of data acquisition. Fast readings are needed, and there should be no margin for error about whether a reading falls within a range
  • Digital readings with a hall sensor, engine spark plug with octocoupler, or some other digital signal could be implemented

Electrical Wiring Notes

Pins to sensor modules

  • Pin 1: +5V
  • Pin 2: GND
  • Pin 3: TMP36 Output
  • Pin 4: IR Emitter Return Line
  • Pin 5: IR Receiver Return Line

Parts

46
QtyValueFootprintReferences
12TestPointTestPoint:TestPoint_THTPad_D3.0mm_Drill1.5mmTP1, TP2, TP3, TP4, TP5, TP6, TP7, TP8, TP9, TP10, TP11, TP12
8RResistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolderR6, R8, R10, R11, R12, R13, R14, R15
4MountingHoleMountingHole:MountingHole_4.3mm_M4H1, H2, H3, H4
222uCapacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolderC2, C3
247Resistor_THT:R_Axial_DIN0411_L9.9mm_D3.6mm_P12.70mm_HorizontalR7, R9
2CCapacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolderC4, C5
2MCP6561-OTPackage_TO_SOT_SMD:SOT-23-5U6, U7
1100nCapacitor_SMD:C_0402_1005Metric_Pad0.74x0.62mm_HandSolderC6
110kResistor_SMD:R_0402_1005MetricR2
110uCapacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolderC1
1120Resistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolderR5
13.3uInductor_SMD:L_Taiyo-Yuden_NR-50xxL1
152.3kResistor_SMD:R_0402_1005MetricR1
1AP62301WUPackage_TO_SOT_SMD:TSOT-23-6U5
1ESP32NJIT-Baja-Footprints:ESP32U1
1Jumper_2_OpenJumper:SolderJumper-2_P1.3mm_Open_Pad1.0x1.5mmJP1
1PrimaryPadsCVT:Temp_IR_5_Pad_ComboJ5
1SW_SPDTButton_Switch_SMD:SW_SPDT_CK_JS102011SAQNSW3
1SecondaryPadsCVT:Temp_IR_5_Pad_ComboJ2
1TJA1051T-3Package_SO:SOIC-8_3.9x4.9mm_P1.27mmU2
1~NJIT-Baja-Footprints:Aviation Plug PadsJ6

More from NJIT-Highlander-Racing-Electrical/CVT-Tachometer

1
  • 2 layers16.3 × 18.5 mmSensorPCB, the printed circuit board in 3D

    SensorPCB

    NJIT-Highlander-Racing-Electrical/CVT-Tachometer

    A subsystem that measures the RPM of the primary and secondary on the CVT

    4 parts
Similar boards

  • 4 layers355 × 160 mmLiBCM, the printed circuit board in 3D

    LiBCM

    doppelhub/Honda_Insight_LiBCM

    Replacement BCM for G1 Honda Insight Lithium Conversion

    717 parts25CC-BY-SA-4.0
  • 6 layers95.9 × 90.2 mmCpb, the printed circuit board in 3D

    Cpb

    OakwoodEngineering/ObiWanKomputer

    The Obi Wan Komputer and Combined Payload Boards from the NyanSat project.

    251 parts10
  • 2 layers65 × 56 mmTitan 2022, the printed circuit board in 3D

    Titan 2022

    hpvdt/titan_2022

    TITAN Vision System going into WHPSC 2022

    73 parts1
  • 4 layers59 × 71 mmPEC Sensor, the printed circuit board in 3D

    PEC Sensor

    WAFFLE-Systems/PEC_Sensor

    Electrical schematics and PCB gerber files for the Pulsed Eddy Current Sensor

    98 parts1
  • 2 layers99 × 80 mmKit Altera rev0, the printed circuit board in 3D

    Kit Altera rev0

    Jonas-Chaves/Kit_MAX10_FPGA

    Kit didático FPGA baseado no Intel MAX 10

    115 partsMIT
  • 2 layers10 × 22 mm5v buck pt iii, the printed circuit board in 3D

    5v buck pt iii

    NJIT-Highlander-Racing-Electrical/Power

    This repository is meant to have all of the research relating to power systems for the vehicle.

    10 parts
  • 4 layers126 × 90 mmIncubator controller, the printed circuit board in 3D

    Incubator controller

    tanaes/OvoEasy_incubator_controller

    KiCad design for the OvoEasy incubator controller board

    169 parts
  • 2 layers34.3 × 42.2 mmRs485adapter, the printed circuit board in 3D

    Rs485adapter

    harrydshill/Base-Station

    44 parts

Questions

How big is the CVTPCB PCB?

It measures 51.8 × 78.1 mm and has 2 copper layers, 1.6 mm thick.

What parts does the CVTPCB use?

46 parts, built around the TJA1051T/3/1 and AP62301WU. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.

Where can I download the CVTPCB KiCad files?

From the NJIT-Highlander-Racing-Electrical/CVT-Tachometer repository on GitHub, at the commit this page was made from: the board is PCB/CVTPCB.kicad_pcb and its schematic PCB/CVTPCB.kicad_sch. PCBKit opens the board in the browser, with nothing to install.

Can I use the CVTPCB design in my own project?

Its repository states no licence, so its author keeps all rights: ask NJIT-Highlander-Racing-Electrical before reusing the design.