Skip to the content
PCBKitNew board
2 layers26.5 × 6.5 mmReflectiveSensor, the printed circuit board in 3D

ReflectiveSensor

satomm1/Robot

This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

Size
26.5 × 6.5 mm
Copper layers
2
Thickness
1.65 mm
Parts
7
Nets
5
Pads
16
Tracks, vias
22, 2
Routed
Yes
KiCad
KiCad 7 (file 20221018)
Created
8 Nov 2023
Updated
22 Oct 2026

Overview

ReflectiveSensor is an open-source printed circuit board by satomm1, from the satomm1/Robot repository on GitHub, published under the MIT licence. It is a 2-layer board of 26.5 × 6.5 mm with 7 parts on 5 nets, routed with 22 tracks and 2 vias.

It is built around the QRE1113GR. Its parts include 2 resistors, 1 capacitor, 1 connector and 1 switch. It belongs with the sensors and measurement boards of this library.

Main components

1

README

Electrical/IMU_Breakout/README.md

6-axis IMU

This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital temperature sensor.

This breakout board is designed so that the IMU can be placed anywhere that is convenient.

Soldering the IMU

This IMU is in a QFN package, which means the device should be reflow soldered. Alternatively, you can carefully apply solder to the PCB pads, put the IMU on top, and use a heat gun to solder the IMU.

Pin directions

The header pins should be soldered on the bottom of the PCB:
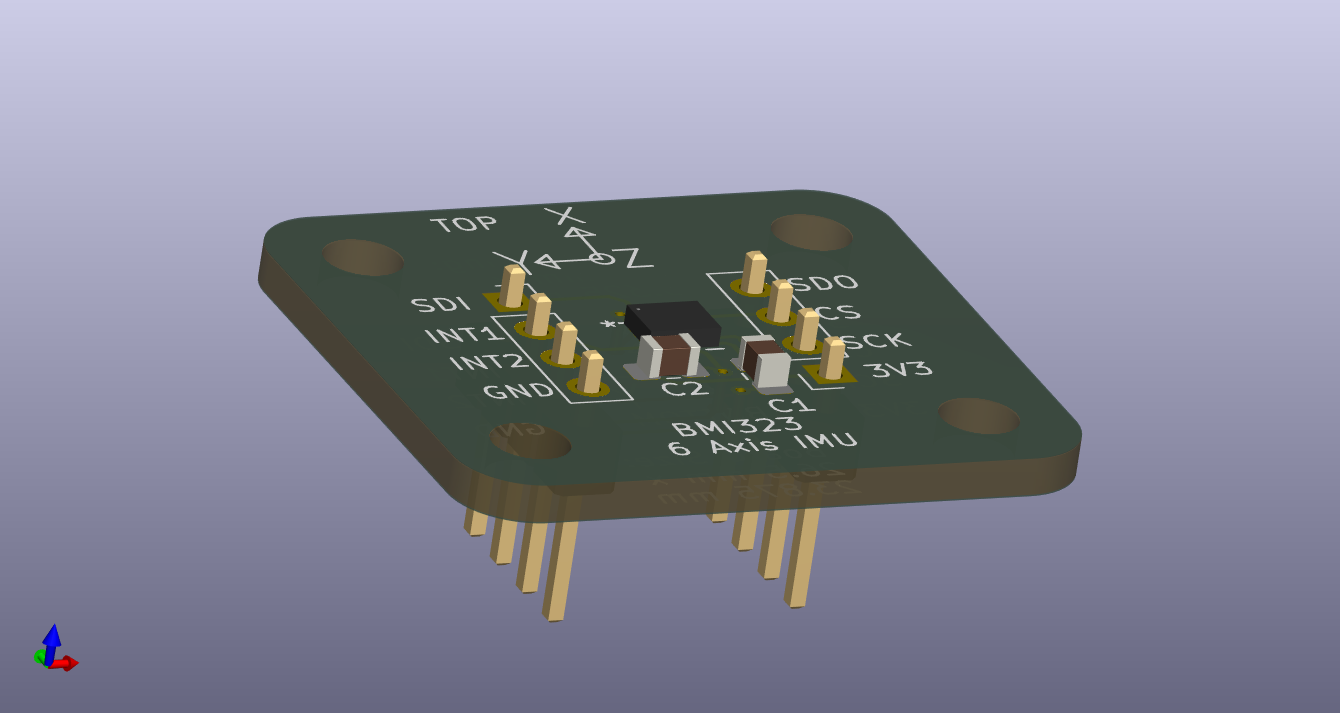
IMU Breakout Board

Installing the IMU

The assembly is meant to be installed on the robot with the IMU facing upwards. The positive X/Y/Z axes are designated on the board. The IMU should be connected via wire to the designated header on the main control board:

IMU Breakout PinMain Control Board Connection
3V33.3V
GNDGND
SCKSCK
CSCS
SDOSDI
SDISDO
INT1INT1 (Currently Unused)
INT2INT2 (Currently Unused)

The IMU connection on the main control board is indicated below:
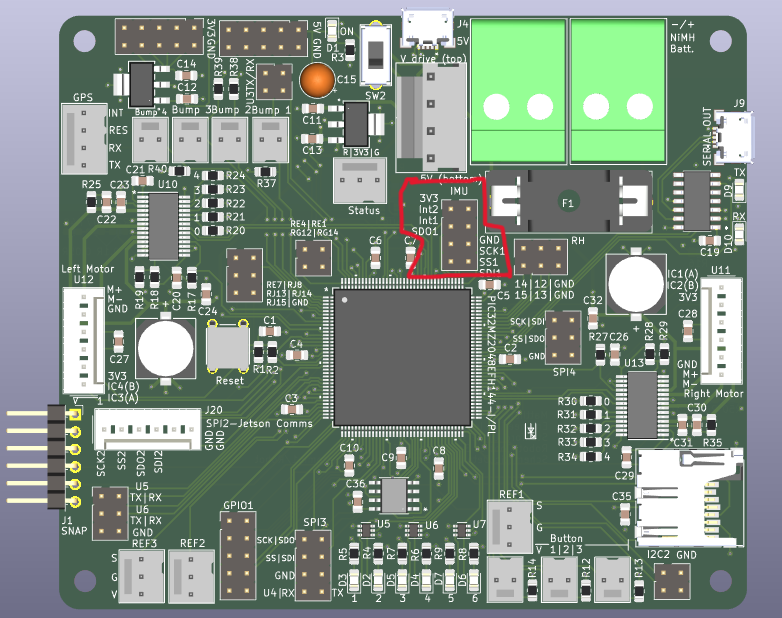
Main Board with IMU Pins Highlighted

Parts

7
QtyValueFootprintReferences
2MountingHoleMountingHole:MountingHole_2.2mm_M2H1, H2
10.1 uFCapacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolderC1
1100RResistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolderR1
110kResistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolderR2
1QRE1113GRReflectiveLibrary:ARUSM-313_100CY_FAS-MK1
1Refl_MountConnector_PinHeader_2.54mm:PinHeader_2x02_P2.54mm_VerticalJ1

Questions

How big is the ReflectiveSensor PCB?

It measures 26.5 × 6.5 mm and has 2 copper layers, 1.65 mm thick.

What parts does the ReflectiveSensor use?

7 parts, built around the QRE1113GR. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.

Where can I download the ReflectiveSensor KiCad files?

From the satomm1/Robot repository on GitHub, at the commit this page was made from: the board is Electrical/Archives/V0.1/ReflectiveSensor/ReflectiveSensor.kicad_pcb and its schematic Electrical/Archives/V0.1/MainBoard/Buttons.kicad_sch. PCBKit opens the board in the browser, with nothing to install.

Can I use the ReflectiveSensor design in my own project?

Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).

More from satomm1/Robot

8
  • 4 layers100 × 86.3 mmArchives, the printed circuit board in 3D

    Archives

    satomm1/Robot

    This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

    138 partsMIT
  • 4 layers100 × 86.3 mmArchives, the printed circuit board in 3D

    Archives

    satomm1/Robot

    This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

    137 partsMIT
  • 2 layers41.5 × 31.6 mmMCU DSP, the printed circuit board in 3D

    MCU DSP

    satomm1/Robot

    This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

    23 partsMIT
  • 2 layers27.3 × 29.4 mmCO Sensor, the printed circuit board in 3D

    CO Sensor

    satomm1/Robot

    This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

    16 partsMIT
  • 2 layers19.3 × 14.2 mmEnvironmentSensor2, the printed circuit board in 3D

    EnvironmentSensor2

    satomm1/Robot

    This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

    11 partsMIT
  • 2 layers26.5 × 23.9 mmIMU Breakout, the printed circuit board in 3D

    IMU Breakout

    satomm1/Robot

    This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

    7 partsMIT
  • 2 layers18.3 × 16.7 mmEnvironmentSensor, the printed circuit board in 3D

    EnvironmentSensor

    satomm1/Robot

    This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

    6 partsMIT
  • 2 layers20.8 × 15 mmMicrophone, the printed circuit board in 3D

    Microphone

    satomm1/Robot

    This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

    5 partsMIT

Similar boards

  • 2 layers94 × 85 mmSumoBot, the printed circuit board in 3D

    SumoBot

    ErichStyger/McuMiniSumoRobot

    Mini Sumo Robot

    86 parts25
  • 2 layers65 × 88.2 mmPanel eyes, the printed circuit board in 3D

    Panel eyes

    fwachsmuth/Synkino

    Allows sound playback synchronised to a running,jittery Super 8 projector

    348 parts7
  • 2 layers200 × 100 mmMobo, the printed circuit board in 3D

    Mobo

    opulo-inc/lumenpnp-archive

    This repository is a public archive of the LumenPnP Pick and Place (formerly Index) source material from the beginning in mid-2020 until May 2022. The current source can be found at https://github.com/opulo-inc/lumenpnp

    88 parts6GPL-3.0
  • 4 layers99.6 × 98.3 mmAnlog LFR, the printed circuit board in 3D

    Anlog LFR

    aaariyann/Analog-Line-Follower

    PID control with analog electronics

    148 parts2
  • 2 layers214 × 187.9 mmLine follower simple, the printed circuit board in 3D

    Line follower simple

    alientanya/line-follower-PCB

    A modular PCB platform for Fast Line Follower (FLF) robots, designed to prioritize sensor experimentation and component flexibility.

    259 parts2MIT
  • 4 layersSoccer bottom, the printed circuit board in 3D

    Soccer bottom

    class-ab/open-soccer

    Mindstormers' open soccer repo. contains code, pcbs, elec, diagrams, etc...

    76 parts2
  • 2 layers93 × 21.3 mmPCB QRE (8), the printed circuit board in 3D

    PCB QRE (8)

    falconecorp/BOBBY

    Robot triatlón : seguidor de linea , quita obstáculos, sumo. Este proyecto esta construido por el técnico físico Lautaro Lammers, el doctor en sistemas Lucas Chavez, el Ingeniero en informatico Dante Canale, El…

    30 parts2
  • 2 layers48.8 × 44 mmSensores, the printed circuit board in 3D

    Sensores

    AlisonTristao/mouse_robot

    Robo para experimentação de rede neural baseada no comportamento de roedores

    57 parts1