
Archives
satomm1/Robot
This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…
Microphone is an open-source printed circuit board by satomm1, from the satomm1/Robot repository on GitHub, published under the MIT licence. It is a 2-layer board of 20.8 × 15 mm with 5 parts on 6 nets, routed with 18 tracks and 0 vias.
It is built around the ICS-43434. Its parts include 1 capacitor and 1 connector. It belongs with the audio and music and sensors and measurement boards of this library.
This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital temperature sensor.
This breakout board is designed so that the IMU can be placed anywhere that is convenient.
This IMU is in a QFN package, which means the device should be reflow soldered. Alternatively, you can carefully apply solder to the PCB pads, put the IMU on top, and use a heat gun to solder the IMU.
The header pins should be soldered on the bottom of the PCB:
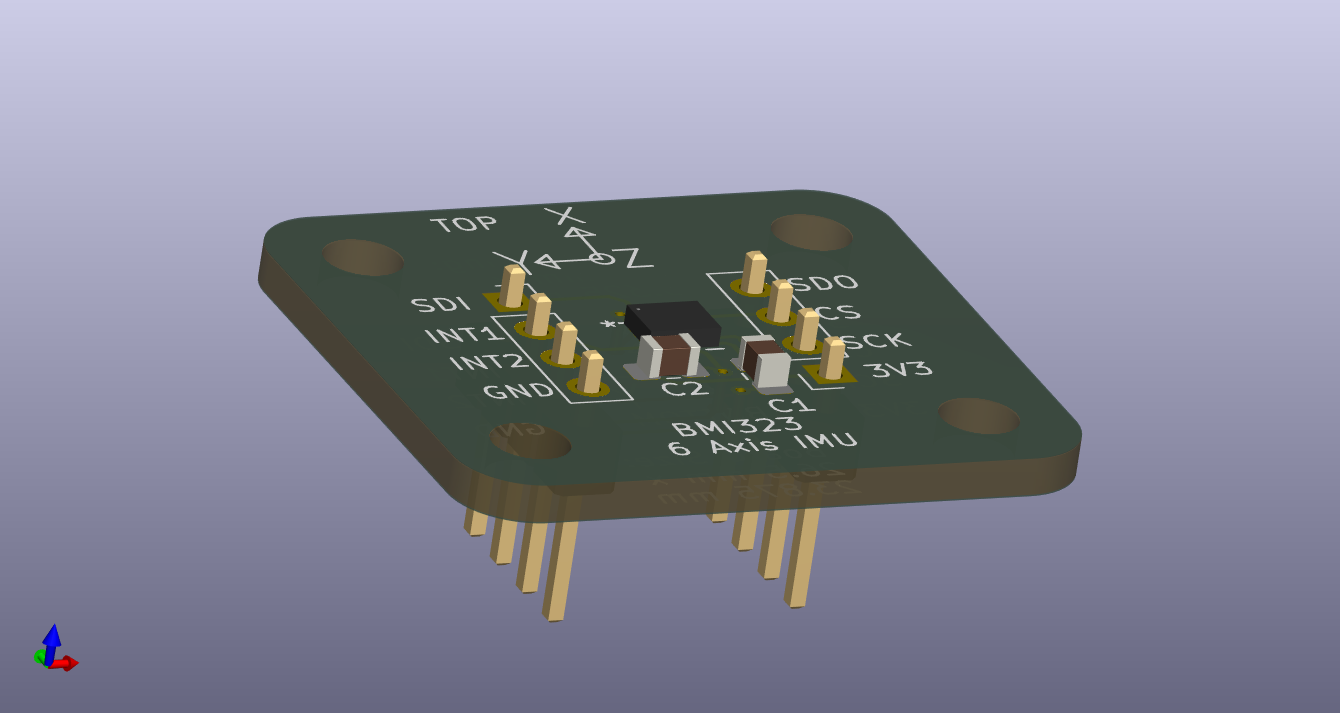
The assembly is meant to be installed on the robot with the IMU facing upwards. The positive X/Y/Z axes are designated on the board. The IMU should be connected via wire to the designated header on the main control board:
| IMU Breakout Pin | Main Control Board Connection |
|---|---|
| 3V3 | 3.3V |
| GND | GND |
| SCK | SCK |
| CS | CS |
| SDO | SDI |
| SDI | SDO |
| INT1 | INT1 (Currently Unused) |
| INT2 | INT2 (Currently Unused) |
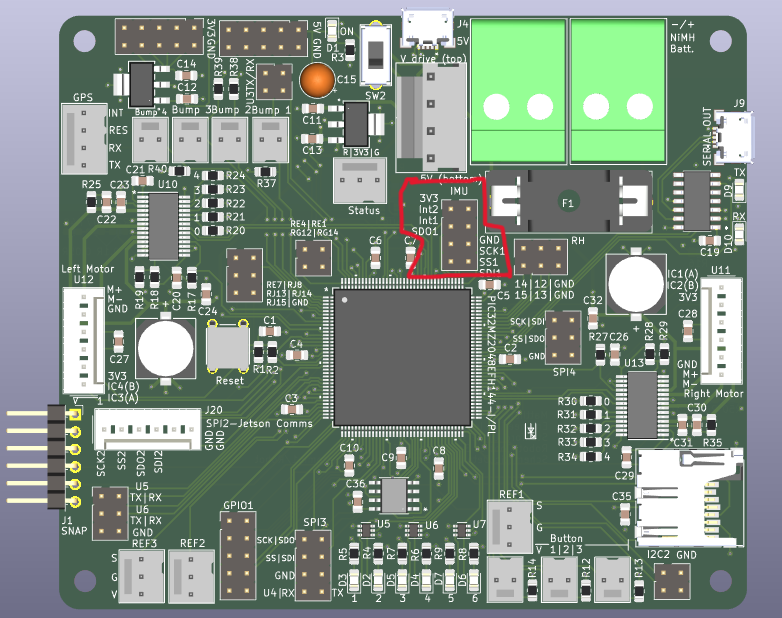
The IMU connection on the main control board is indicated below:
| Qty | Value | Footprint | References |
|---|---|---|---|
| 2 | MountingHole | MountingHole:MountingHole_3.2mm_M3 | H1, H2 |
| 1 | 0.1 uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1 |
| 1 | Conn2MCU | custom_footprints:CONN_22-05-3061_MOL | J1 |
| 1 | ICS-43434 | Library:MIC_ICS-43434 | MK1 |
It measures 20.8 × 15 mm and has 2 copper layers, 1.65 mm thick.
5 parts, built around the ICS-43434. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the satomm1/Robot repository on GitHub, at the commit this page was made from: the board is Electrical/Microphones/microphone/microphone.kicad_pcb and its schematic Electrical/Archives/V0.1/MainBoard/Buttons.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).

satomm1/Robot
This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

satomm1/Robot
This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

satomm1/Robot
This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

satomm1/Robot
This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

satomm1/Robot
This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

satomm1/Robot
This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

satomm1/Robot
This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

satomm1/Robot
This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…


DhamuVkl/ESP32S3-AI-Voice-Assistant
This project is a complete DIY AI voice assistant built around the ESP32-S3 microcontroller. It combines custom PCB design, advanced audio processing, and cloud-based AI to create a device that rivals commercial smart…

mikelawrence/esphome-indoor-multi-sensor-hardware
ESPHome Indoor Multi-Sensor hardware. This design supports Radar/PIR Presence, Temperature, Humidity, Pressure, Light, CO2, CO, VOC, NOX and PM sensors.

rowr111/blinky-badge-light
lighting badge with unique patterns and sound reactivity

DetectiveMittens/Cooee
An open-source phone that can operate without GSM or LTE coverage. Utilising LoRa modulation and mesh networking to enable long range "off-grid" communication

expoman/tdk_ics-43434_breakout
small breakout board for the TDK ICS-43434 microphone chip

leeyumsk/IRL-Subtitles
Using techniques similar to human perception to localize sounds and speakers.

Mowibox/chromapi_motherboard
Raspberry Pi control HAT dedicated to the quadruped robot Chromapi.