Skip to the content
2 layers41.5 × 31.6 mmMCU DSP, the printed circuit board in 3D

This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

Size
41.5 × 31.6 mm
Copper layers
2
Thickness
1.65 mm
Parts
23
Nets
45
Pads
110
Tracks, vias
235, 24
Routed
Yes
KiCad
KiCad 9.0 (file 20241229)
Created
8 Nov 2023
Updated
22 Oct 2026

Overview

MCU DSP is an open-source printed circuit board by satomm1, from the satomm1/Robot repository on GitHub, published under the MIT licence. It is a 2-layer board of 41.5 × 31.6 mm with 23 parts on 45 nets, routed with 235 tracks and 24 vias.

It is built around the GSF7002DW and B3F-1020. Its parts include 6 capacitors, 5 resistors, 4 connectors, 2 ICs and 2 diodes. It belongs with the sensors and measurement boards and the PIC boards of this library.

Main components

2

README

Electrical/IMU_Breakout/README.md

6-axis IMU

This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital temperature sensor.

This breakout board is designed so that the IMU can be placed anywhere that is convenient.

Soldering the IMU

This IMU is in a QFN package, which means the device should be reflow soldered. Alternatively, you can carefully apply solder to the PCB pads, put the IMU on top, and use a heat gun to solder the IMU.

Pin directions

The header pins should be soldered on the bottom of the PCB:
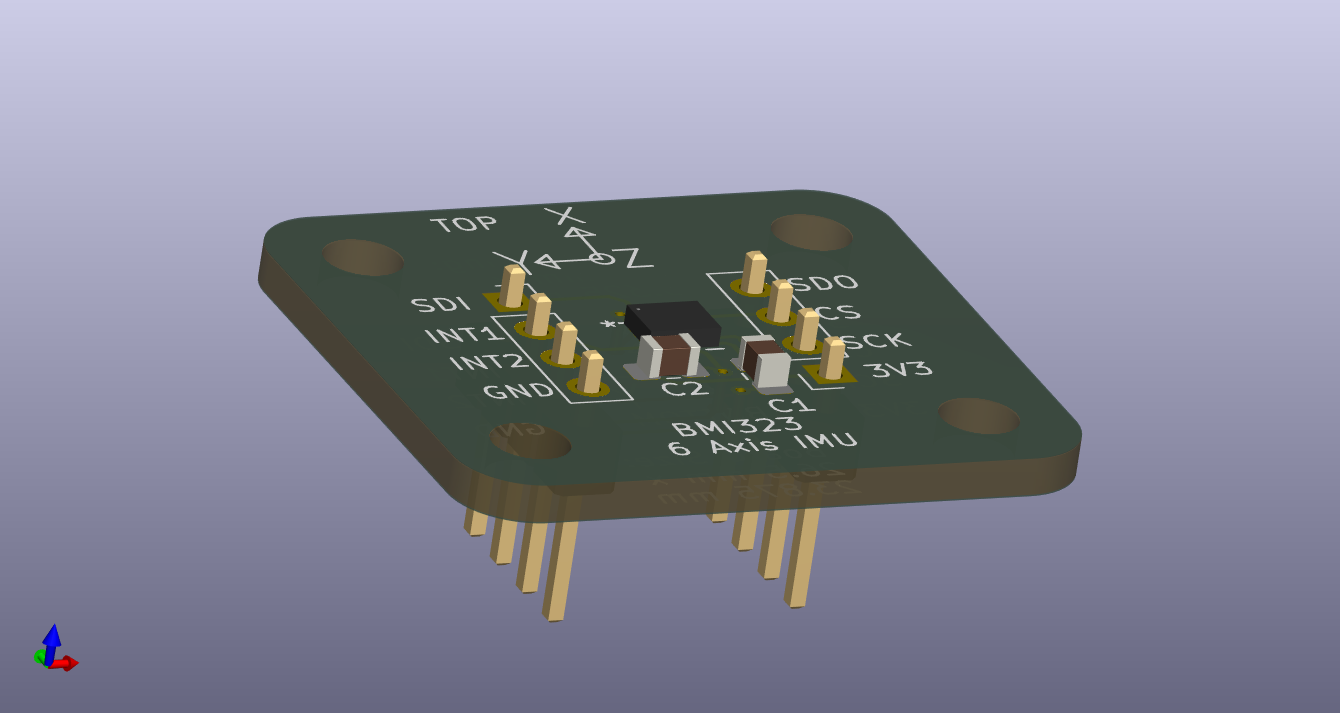
IMU Breakout Board

Installing the IMU

The assembly is meant to be installed on the robot with the IMU facing upwards. The positive X/Y/Z axes are designated on the board. The IMU should be connected via wire to the designated header on the main control board:

IMU Breakout PinMain Control Board Connection
3V33.3V
GNDGND
SCKSCK
CSCS
SDOSDI
SDISDO
INT1INT1 (Currently Unused)
INT2INT2 (Currently Unused)

The IMU connection on the main control board is indicated below:
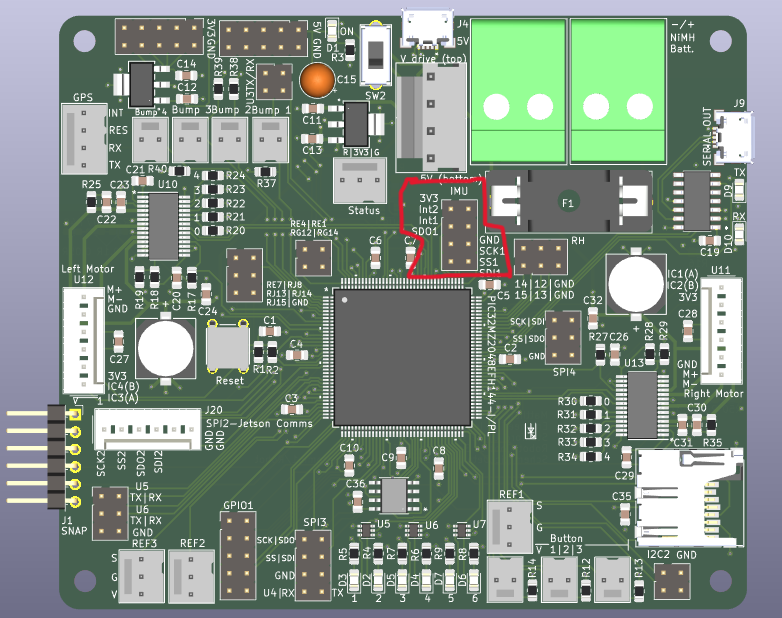
Main Board with IMU Pins Highlighted

Parts

23
QtyValueFootprintReferences
60.1 uFCapacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolderC1, C2, C3, C4, C5, C6
3Conn_01x06Connector_Molex:Molex_KK-254_AE-6410-06A_1x06_P2.54mm_VerticalJ2, J3, J5
3MountingHoleMountingHole:MountingHole_3.2mm_M3H1, H2, H3
2130RResistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolderR4, R5
2LEDLED_SMD:LED_0805_2012Metric_Pad1.15x1.40mm_HandSolderD1, D2
1100kResistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolderR3
110kResistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolderR1
11kResistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolderR2
1B3F-1020custom_footprints:SW_B3F-1000_OMRSW1
1Conn_01x05_PinConnector_PinHeader_2.54mm:PinHeader_1x05_P2.54mm_HorizontalJ1
1GSF7002DWPackage_TO_SOT_SMD:SOT-363_SC-70-6U1
1PIC32MK0128MCA048-I_Y8Xcustom_footprints:TQFP48_Y8X_MCH-MIC1

More from satomm1/Robot

8
  • 4 layers100 × 86.3 mmArchives, the printed circuit board in 3D

    Archives

    satomm1/Robot

    This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

    138 partsMIT
  • 4 layers100 × 86.3 mmArchives, the printed circuit board in 3D

    Archives

    satomm1/Robot

    This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

    137 partsMIT
  • 2 layers27.3 × 29.4 mmCO Sensor, the printed circuit board in 3D

    CO Sensor

    satomm1/Robot

    This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

    16 partsMIT
  • 2 layers19.3 × 14.2 mmEnvironmentSensor2, the printed circuit board in 3D

    EnvironmentSensor2

    satomm1/Robot

    This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

    11 partsMIT
  • 2 layers26.5 × 6.5 mmReflectiveSensor, the printed circuit board in 3D

    ReflectiveSensor

    satomm1/Robot

    This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

    7 partsMIT
  • 2 layers26.5 × 23.9 mmIMU Breakout, the printed circuit board in 3D

    IMU Breakout

    satomm1/Robot

    This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

    7 partsMIT
  • 2 layers18.3 × 16.7 mmEnvironmentSensor, the printed circuit board in 3D

    EnvironmentSensor

    satomm1/Robot

    This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

    6 partsMIT
  • 2 layers20.8 × 15 mmMicrophone, the printed circuit board in 3D

    Microphone

    satomm1/Robot

    This directory contains the electrical schematic for a breakout board for the Bosch BMI323 6-axis IMU. This IMU provides a 16 bit digital triaxial accelerometer, a 16 bit digital triaxial gyroscope, and a 16 bit digital…

    5 partsMIT

Similar boards

  • 10 layers30.6 × 65 mmEffectiveRangeHat simple, the printed circuit board in 3D

    EffectiveRangeHat simple

    EffectiveRange/pcb-mrhat

    PCB project for MrHAT RPi extension hat project

    117 parts2
  • 4 layers65 × 30 mmEffecitveRangeMic2, the printed circuit board in 3D

    EffecitveRangeMic2

    EffectiveRange/pcb-micdevice2

    PCB project for stereo mems microphone with RGB led and MCU

    42 parts
  • 2 layers127 × 153 mmRC2014Backplane wUART, the printed circuit board in 3D

    RC2014Backplane wUART

    dennisperry/RC2014_PCBs

    A group of RC2014 PCBs I've designed to expand my system

    54 parts
  • 2 layers50 × 70 mmTimeCapsule, the printed circuit board in 3D

    TimeCapsule

    jaxfry/TimeCapsule

    A usb time capsule!

    56 parts
  • 4 layers89.9 × 88.8 mmBigboard, the printed circuit board in 3D

    Bigboard

    mincrmatt12/MWatch

    pebble-style smartwatch os&hardware

    110 parts
  • 4 layers51 × 113 mmHardware password, the printed circuit board in 3D

    Hardware password

    riamahaj/Password_Manager_Bank

    This repository is for our ECE 411 Password Manager USB Stick project

    8 parts
  • 4 layers99 × 99.3 mmDeliverable4 schematics, the printed circuit board in 3D

    Deliverable4 schematics

    satomm1/EE256Project

    Project for EE256 at Stanford University, Autumn 2023

    114 partsMIT
  • 2 layersCounterContoller take1, the printed circuit board in 3D

    CounterContoller take1

    daniel-bornhorst/GVH-ALY-PM-InteractiveCounter

    GVH Alley Bar - Prime Materia - Interactive Cap Touch Countertop

    30 parts

Questions

How big is the MCU DSP PCB?

It measures 41.5 × 31.6 mm and has 2 copper layers, 1.65 mm thick.

What parts does the MCU DSP use?

23 parts, built around the GSF7002DW and B3F-1020. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.

Where can I download the MCU DSP KiCad files?

From the satomm1/Robot repository on GitHub, at the commit this page was made from: the board is Electrical/Microphones/pic32/MCU_DSP.kicad_pcb and its schematic Electrical/Archives/V0.1/MainBoard/Buttons.kicad_sch. PCBKit opens the board in the browser, with nothing to install.

Can I use the MCU DSP design in my own project?

Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).