

4 layers96.5 × 81.3 mm
Hexapod PCB KiCad Project
Aecert-Robotics/Hexapod
A hexapod powered by Arduino using hobby servos
48 parts15GPL-3.0
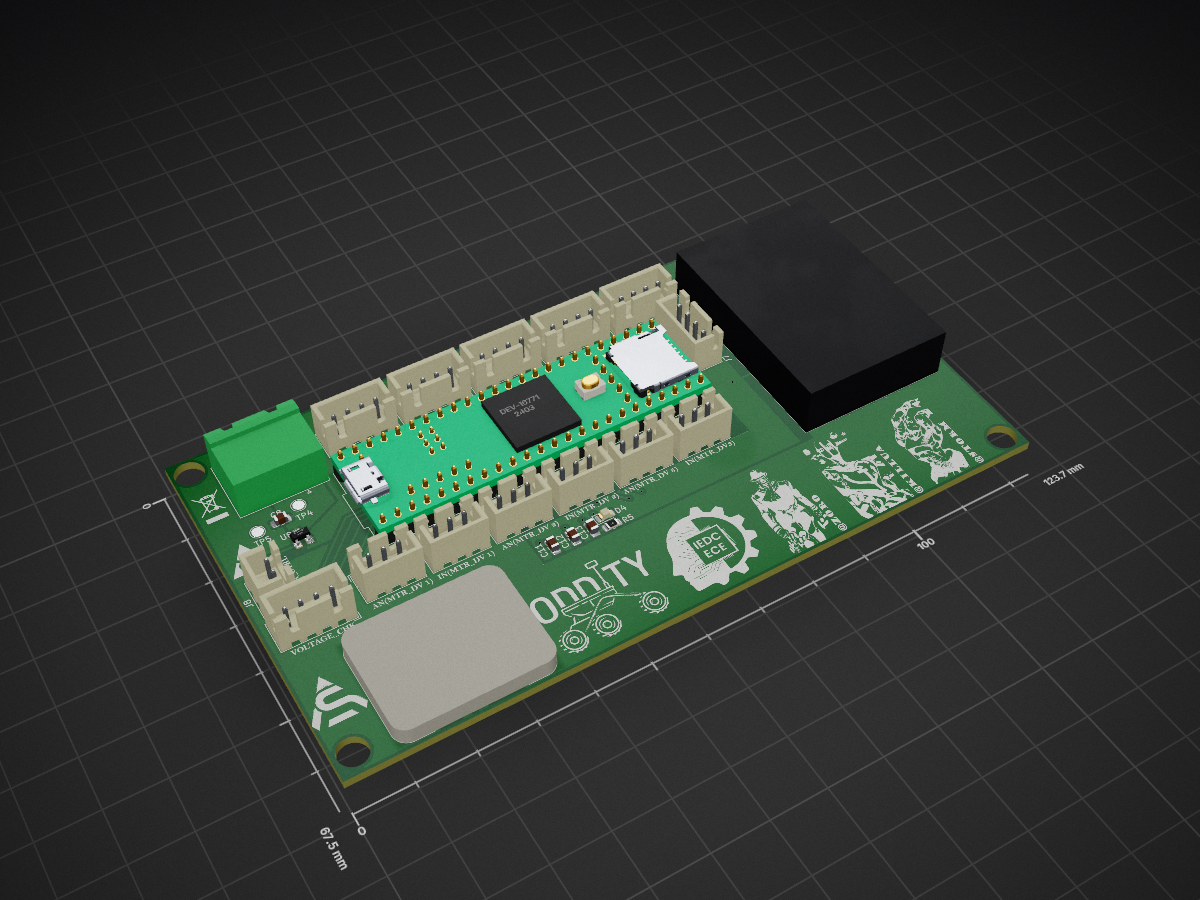
Designed a Autonomous Drive System PCB
DRIVE is an open-source printed circuit board by Sagnik-Tech, from the Sagnik-Tech/Drive-Subsystem-PCB-Design repository on GitHub. It is a 2-layer board of 123.7 × 67.5 mm with 35 parts on 69 nets, routed with 198 tracks and 10 vias.
It is built around the AO3401 and DEV-16771. Its parts include 16 connectors, 4 capacitors, 2 ICs, 1 resistor and 1 diode.
Designed a Drive Subsystem PCB containing Teensy 4.1 MCU which helps in smooth autonomous navigation with precision of Mars Rover in harsh terrains. Consists of BNO055 for monitoring the orientation of the rover. MCP2515 module is also present as the communication between the Drive Subsystem and NVIDIA Jetson Orin( the main on-board computer of our rover).
| Qty | Value | Footprint | References |
|---|---|---|---|
| 7 | Conn_01x04 | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J7, J9, J24, J25, J28, J29, J30 |
| 6 | Conn_01x03 | Connector_JST:JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J1, J2, J3, J4, J5, J6 |
| 2 | 0.1uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C12, C13 |
| 2 | TestPoint | TestPoint:TestPoint_Pad_D2.0mm | TP4, TP5 |
| 1 | 100n | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C8 |
| 1 | 10uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C11 |
| 1 | 220R | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R5 |
| 1 | AO3401 | AO3401:SOT23 | U8 |
| 1 | Conn_01x02 | Connector_Phoenix_GMSTB:PhoenixContact_GMSTBA_2,5_2-G-7,62_1x02_P7.62mm_Horizontal | J31 |
| 1 | Conn_01x02 | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J8 |
| 1 | Conn_01x07 | MCP2515:MCP2515 | e1 |
| 1 | Conn_01x10 | 2472:MODULE_2472 | J11 |
| 1 | DEV-16771 | DEV-16771:MODULE_DEV-16771 | U2 |
| 1 | LED | LED_SMD:LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D4 |
| 1 | LOGO | halo:sa | G*** |
| 1 | LOGO | halo:soft&wet | G*** |
| 1 | LOGO | halo:kharuscum | G*** |
| 1 | LOGO | halo:odd | G*** |
| 1 | LOGO | halo:iedc | G*** |
| 1 | LOGO | halo:u | G*** |
The 33 most common of 35 parts.
Aecert-Robotics/Hexapod
A hexapod powered by Arduino using hobby servos


rimuadmin/TeensyMaestro-Hardware
Hardware for the TeensyMaestro

ALTAIR-McGill-x-UVictoria/HAB-Control-Flight-Computer
ECSE Control Capstone Team- High Altitude Balloon Flight Computer

Big-Red-Sat/High-Altitude-Student-Platform
This repository contains the hardware designs, data, and analysis of perovskite solar cells on high altitude balloons

NeverNotJohn/CSUF-NASA-USLI-2026
California State University Fresno (CSUF) Github for the 2025-2026 NASA USLI Competition

IEEE-Robotics-Club/MSU-NASA-Minds-2023
The code repository for the 2023 MSU NASA Minds competition

letrend/UVen
UV irradiation system for enhanced photo-activation in living cells
It measures 123.7 × 67.5 mm and has 2 copper layers, 1.6 mm thick.
35 parts, built around the AO3401 and DEV-16771. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Sagnik-Tech/Drive-Subsystem-PCB-Design repository on GitHub, at the commit this page was made from: the board is DRIVE.kicad_pcb and its schematic DRIVE.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask Sagnik-Tech before reusing the design.