4 layers34 × 65 mm
 daniel360kim/OceanAI14
A robotic and software orientated ocean development.
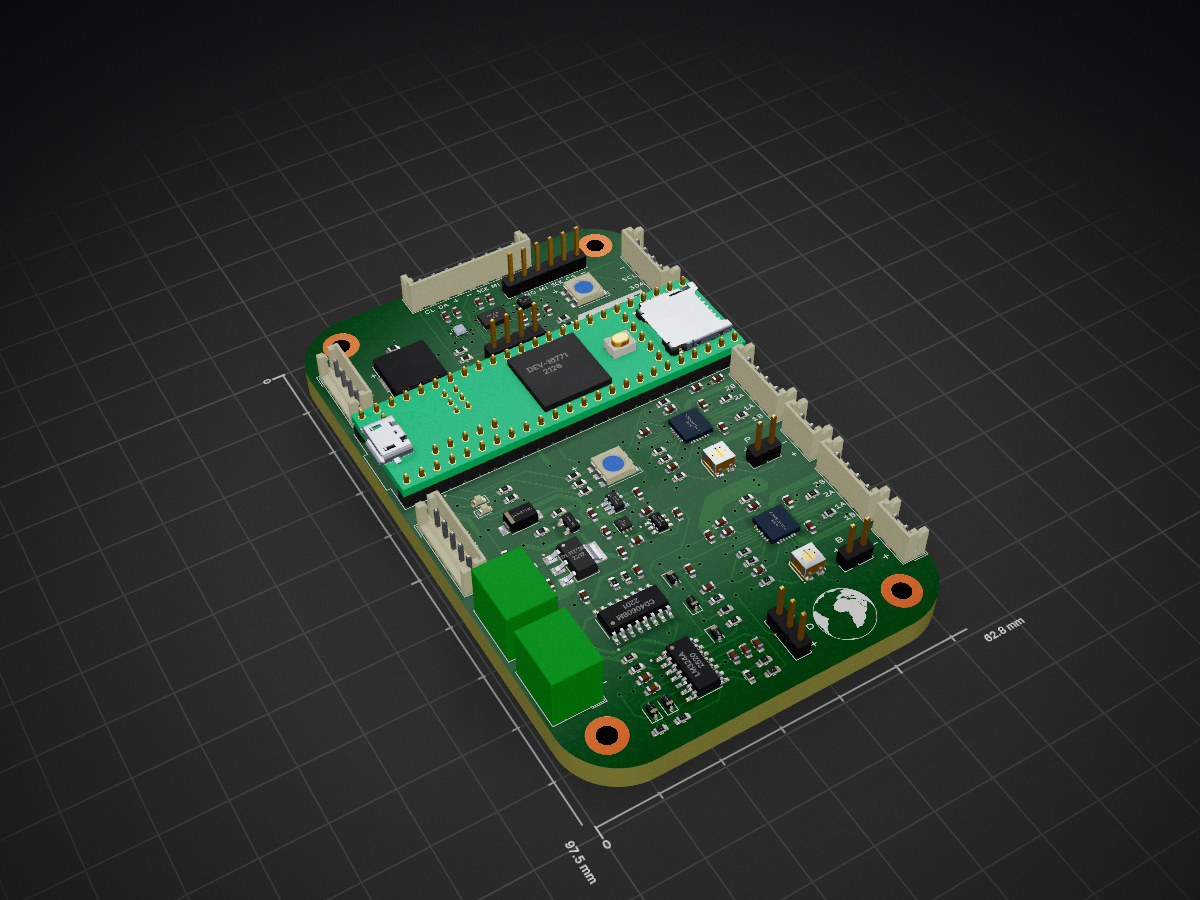
OceanAI is an open-source printed circuit board by daniel360kim, from the daniel360kim/OceanAI repository on GitHub, published under the MIT licence. It is a 4-layer board of 62.8 × 97.5 mm with 124 parts on 143 nets, routed with 1,021 tracks and 138 vias.
It is built around the LM324AD, NEO-6M and A4988SETTR-T, with the ADP1221, BMP388 and AP2112K-3.3 among its other parts. Its parts include 38 capacitors, 30 resistors, 15 connectors, 12 ICs and 10 diodes.


| Qty | Value | Footprint | References |
|---|---|---|---|
| 20 | 0.1uF | Capacitor_SMD:C_0603_1608Metric | C1, C2, C3, C4, C14, C15, C25, C27, C28, C29, C31, C32, C33, C34, C36, C37 +4 |
| 10 | 10K | Resistor_SMD:R_0603_1608Metric | locked, R7, R9, R10, R11, R12, R14, R15, R20, R21 |
| 9 | 1uF | Capacitor_SMD:C_0603_1608Metric | C10, C13, C16, C17, C18, C19, C21, C22, C24 |
| 6 | 100K | Resistor_SMD:R_0603_1608Metric | R6, R8, R22, R23, R26, R27 |
| 5 | 1N4148WS | Diode_SMD:D_SOD-323 | D1, D2, D3, D4, D5 |
| 5 | 4.7uF | Capacitor_SMD:C_0603_1608Metric | C11, C12, C20, C23, C26 |
| 4 | 0.05 | Resistor_SMD:R_0603_1608Metric | R24, R25, R28, R29 |
| 4 | 1K | Resistor_SMD:R_0603_1608Metric | R17, R18, R31, R41 |
| 4 | MountingHole_Pad | MountingHole:MountingHole_3mm_Pad | H1, H2, H3, H4 |
| 4 | R | Resistor_SMD:R_0603_1608Metric | R33, R35, R36, R38 |
| 3 | 4.7K | Resistor_SMD:R_0603_1608Metric | R2, R3, R39 |
| 2 | Resistor_SMD:R_0603_1608Metric | R34, R37 | |
| 2 | 0.22uF | Capacitor_SMD:C_0603_1608Metric | C30, C35 |
| 2 | 20K | Resistor_SMD:R_0603_1608Metric | R19, R30 |
| 2 | A4988SETTR-T | A4988SETTR-T:QFN50P500X500X100-29N | IC1, IC2 |
| 2 | Conn_01x02 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J13, J14 |
| 2 | LED | LED_SMD:LED_0603_1608Metric | D8, D9 |
| 2 | LED_RGB | LED_SMD:LED_RGB_5050-6 | D6, D7 |
| 2 | R_Potentiometer | 35WR10KLFTR:TRIM_35WR10KLFTR | RV1, RV2 |
| 1 | 1M | Resistor_SMD:R_0603_1608Metric | R1 |
| 1 | 1nF | Capacitor_SMD:C_0603_1608Metric | C7 |
| 1 | 2.5 | Resistor_SMD:R_0603_1608Metric | R16 |
| 1 | 470 | Resistor_SMD:R_0603_1608Metric | R40 |
| 1 | 5.6K | Resistor_SMD:R_0603_1608Metric | R4 |
| 1 | 6.8K | Resistor_SMD:R_0603_1608Metric | R5 |
| 1 | ADP122 | ADP122:SON65P200X200X65-7N | U9 |
| 1 | AP2112K-3.3 | AP2112K-3:SOT95P285X140-5N | U8 |
| 1 | BMI088 | BMI088:PQFN50P450X300X100-16N | U1 |
| 1 | BMP388 | BMP388:PQFN50P200X200X80-10N | U3 |
| 1 | Batt | TerminalBlock_MetzConnect:TerminalBlock_MetzConnect_Type101_RT01602HBWC_1x02_P5.08mm_Horizontal | J4 |
| 1 | Buzzer | Buzzer_Beeper:Buzzer_Murata_PKMCS0909E | BZ1 |
| 1 | CD4060BM | CD4060BM:SOIC127P600X175-16N | U6 |
| 1 | Conn_01x03 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J15 |
| 1 | DEV-16771 | DEV-16771:MODULE_DEV-16771 | U4 |
| 1 | DMP3098L-7 | DMP3098L-7:SOT91P240X110-3N | Q1 |
| 1 | D_Schottky | SS12:DIOM4427X270N | D10 |
| 1 | G*** | kibuzzard-629BEB6E | kibuzzard-1 |
| 1 | HC-12 | Connector_JST:JST_EH_B5B-EH-A_1x05_P2.50mm_Vertical | J9 |
| 1 | I2C | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J8 |
| 1 | I2C | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J2 |
| 1 | JST_B | Connector_JST:JST_EH_B4B-EH-A_1x04_P2.50mm_Vertical | J6 |
| 1 | JST_P | Connector_JST:JST_EH_B4B-EH-A_1x04_P2.50mm_Vertical | J7 |
| 1 | LDL1117S50R | SOT230P700X180-4N:SOT230P700X180-4N | U10 |
| 1 | LIS3MDLTR | LIS3MDLTR:XDCR_LIS3MDLTR | U2 |
| 1 | LM324A | LM324:SOIC127P600X175-14N | U5 |
| 1 | Limit_b | Connector_JST:JST_EH_B2B-EH-A_1x02_P2.50mm_Vertical | J11 |
| 1 | Limit_p | Connector_JST:JST_EH_B2B-EH-A_1x02_P2.50mm_Vertical | J12 |
| 1 | MAX1719 | MAX1719EUT_T:SOT95P280X145-6N | U7 |
| 1 | MS5803 | Connector_JST:JST_EH_B4B-EH-A_1x04_P2.50mm_Vertical | J1 |
| 1 | NEO-6M | Connector_JST:JST_EH_B4B-EH-A_1x04_P2.50mm_Vertical | J10 |
| 1 | OV5642 | Connector_JST:JST_EH_B8B-EH-A_1x08_P2.50mm_Vertical | J5 |
| 1 | PROBE | TerminalBlock_MetzConnect:TerminalBlock_MetzConnect_Type101_RT01602HBWC_1x02_P5.08mm_Horizontal | J3 |
| 1 | locked | Capacitor_SMD:C_0603_1608Metric | C8 |


Motasim-1/Wifi-quadcopter-pcb
Custom PCB design for a WiFi-controlled quadcopter based on the ESP32 microcontroller. The board was designed in KiCad, assembled using solder paste and a reflow oven, and tested with four motor outputs controlled…

alvarop/reloj
This project was inspired by my dad's university digital systems project from the late 1970's. I found the writeup and schematic and decided to try and re-create it.

KAVIRAJec/Smart-Water-Quaity-Measurement-Kit
🚰 Smart Water Quality Monitoring System Real-time insights into drinking water quality! This repository contains the code and documentation for our innovative water quality monitoring system.

Gloeidraad/AMFM-modulator-with-ESP32-module
This is an MP3 player, Web-radio player, Bluetooth player, and simple waveform generator, based on an ESP32 module. The output is connected to a simple FM/AM modulator.


ntnu-arl/embedded_rio-pcb
This is the PCB for the master thesis "Embedded Radar-Inertial Odometry". It is a carrier board built around a Teensy 4.0 that holds all the sensors and plugs into a Pixhawk flight controller.
It measures 62.8 × 97.5 mm and has 4 copper layers, 4.69 mm thick.
124 parts, built around the LM324AD, NEO-6M, A4988SETTR-T and ADP1221. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the daniel360kim/OceanAI repository on GitHub, at the commit this page was made from: the board is PCBs/main_board/main_board.kicad_pcb and its schematic PCBs/main_board/IMU.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).