
2 layers68 × 46 mm
Ardor IO
balazsbencs/ardor
This is a DIY multieffects project with a Raspberry Pi and and Codec Zero and a Raspberry Pi Display 2. With Full NAM A2 support.
81 parts18MIT
 pratham-cloud-ctrl/INDRBT
INDRBT: an original six-axis digital robot arm and gripper, with interactive CAD/PCB inspection, theory and reproducible engineering files.
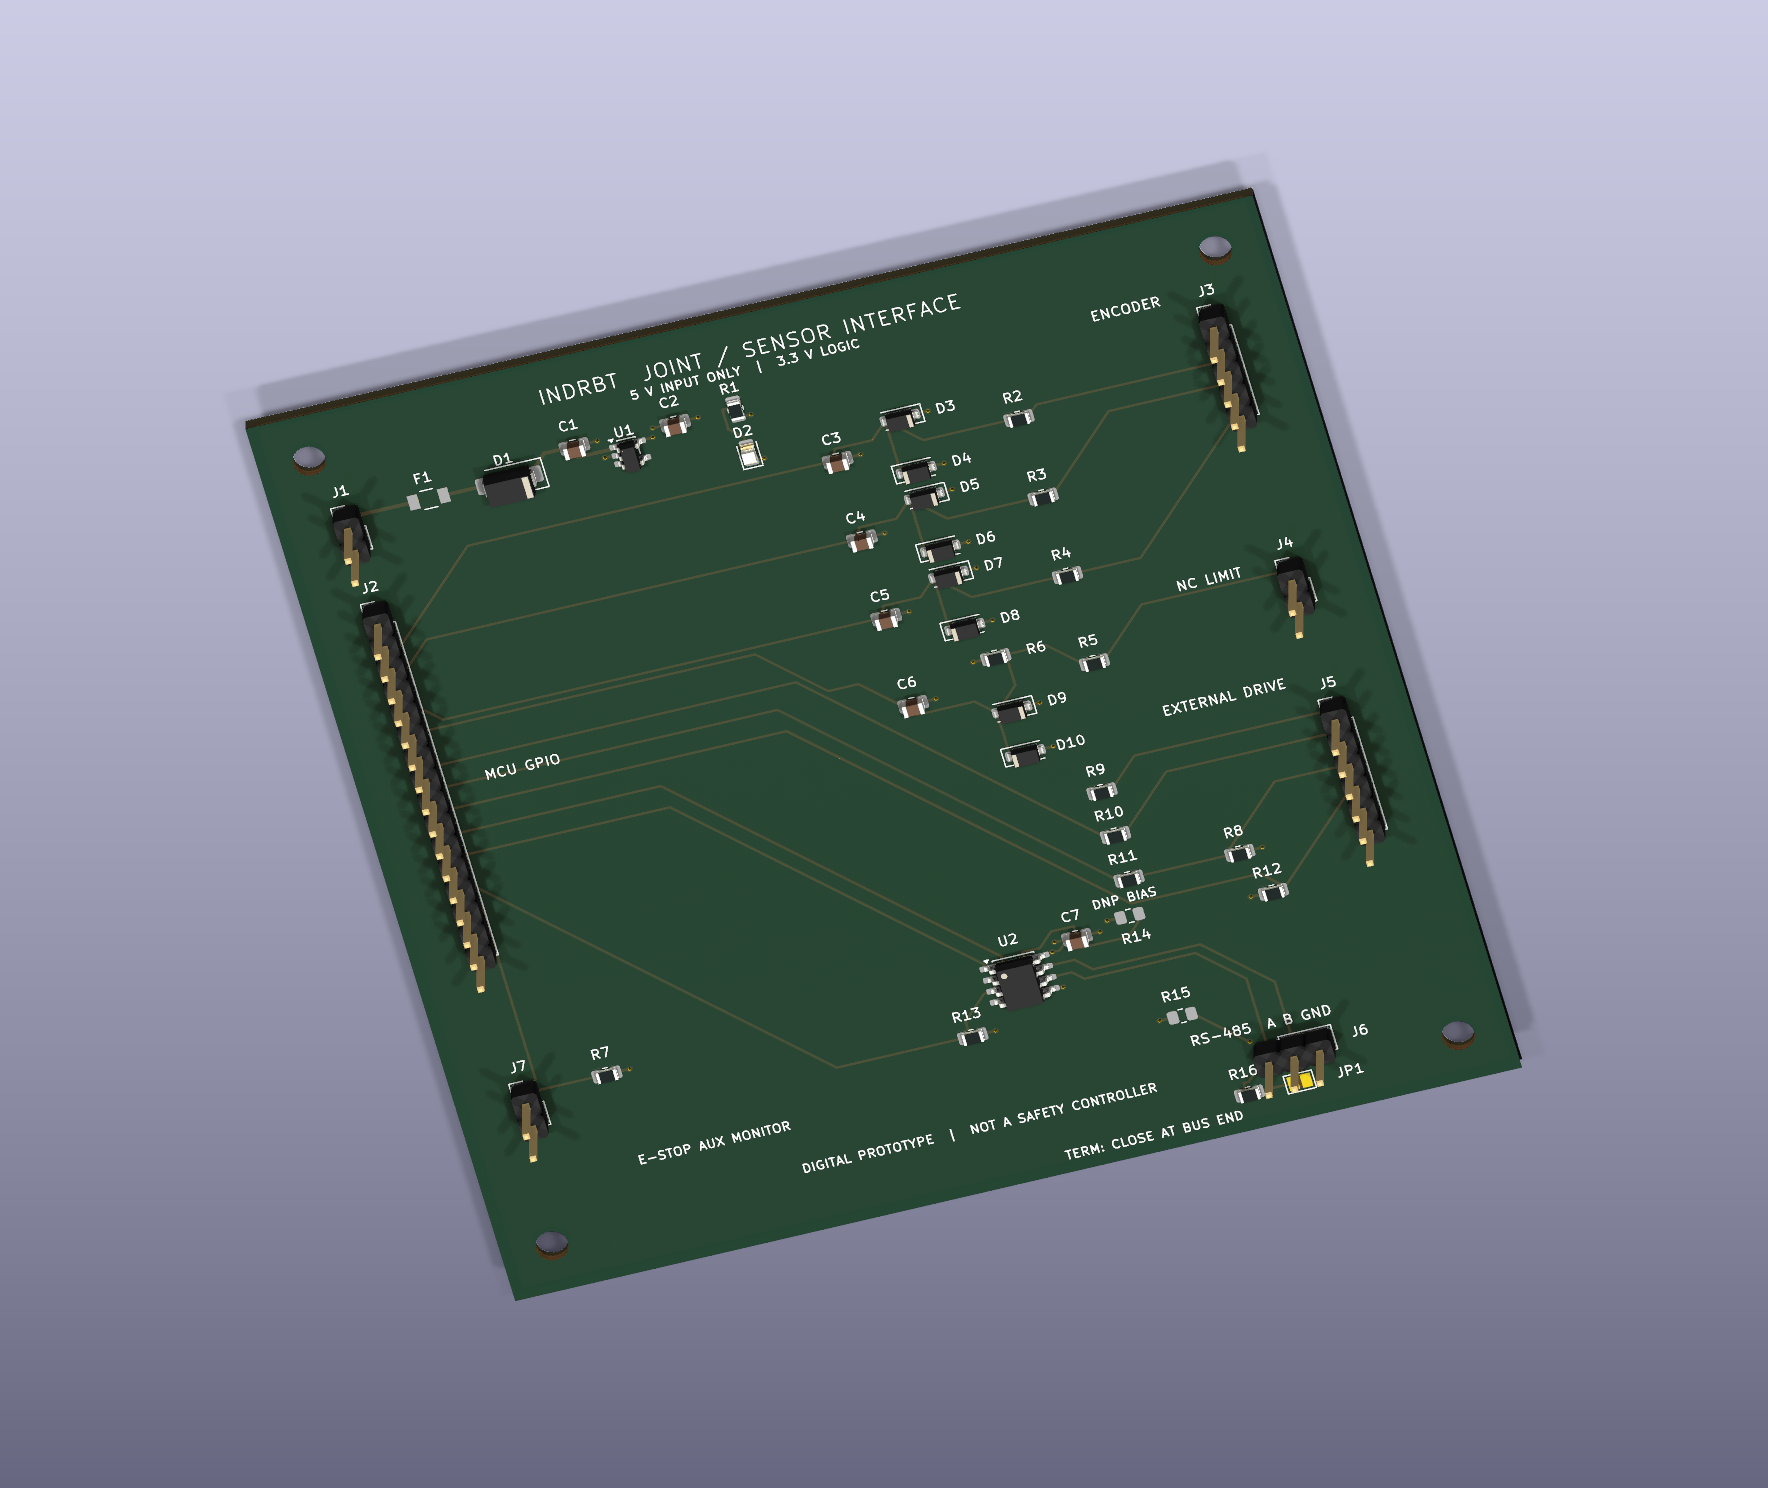
Joint interface is an open-source printed circuit board by pratham-cloud-ctrl, from the pratham-cloud-ctrl/INDRBT repository on GitHub, published under the MIT licence. It is a 4-layer board of 100 × 100 mm with 48 parts on 29 nets, routed with 265 tracks and 32 vias.
It is built around the LTC2850IS8#PBF, AP2112K-3.3 and BAT54H, with the MF-NSMF025X-2 and SS14 among its other parts. Its parts include 16 resistors, 10 diodes, 7 capacitors, 7 connectors and 2 ICs. It belongs with the robots and motor control and interfaces and adapters boards of this library.


Illustrated electronics tour · Project home · Engineering design chapter
This is the authoritative source for the 100 × 100 mm, four-layer joint/sensor interface: 44 schematic components and 48 PCB footprints, including four mounting holes. An external 3.3 V controller connects to encoder/limit inputs, a separate motor drive and RS-485. The PCB implements logic interfacing; the controller, motor power stage and embedded firmware are external to this design.
Inspect the PCB online, rotate the 3D board or zoom the schematic without installing KiCad or downloading files. The native project steps below are optional for offline editing.
Public electronics download release — download the KiCad project with its schematic, board and local footprint context, or choose the PCB STEP pack for mechanical CAD. The native-file guide explains opening the project. The published GitHub Pages showcase includes the browser viewers and download controls.
| Browse without KiCad | Open |
|---|---|
| Circuit | Schematic PDF |
| Layout | Top view and six-page layer PDF |
| Parts | BOM CSV and component guide |
| Manufacturing package | Gerber/drill/assembly ZIP |
| Checked evidence | Independent review, ERC, DRC and source/export hashes |
For optional offline editing, download and extract the complete repository using Code → Download ZIP, or clone it. With KiCad 10 and its standard libraries installed, open joint_interface.kicad_pro, then its schematic or PCB. GitHub shows native files as source; PDF/PNG links above provide readable previews.
Keep this folder intact. fp-lib-table resolves the project-local F1 footprint through ${KIPRJMOD}; sym-lib-table resolves stock symbols. Downloading a single native file omits this library context. On Windows, OPEN_PCB_LAYOUT.cmd at the repository root opens the downloaded layout.
Supply regulated 5 V, with 3.3 V GPIO and a shared 150 mA logic-load design budget. Read the tour for connector roles and the design chapter for complete pin contracts, calculations, assumptions and reproduction commands. Saved native rules/connectivity checks pass within their documented scope; no physical board was built or qualified.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | BAT54H | Diode_SMD:D_SOD-123F | D3, D4, D5, D6, D7, D8, D9, D10 |
| 5 | 10k | Resistor_SMD:R_0805_2012Metric | R6, R7, R8, R12, R13 |
| 5 | 1k | Resistor_SMD:R_0805_2012Metric | R1, R2, R3, R4, R5 |
| 5 | 330 | Resistor_SMD:R_0805_2012Metric | R9, R10, R11, R14, R15 |
| 4 | M3 mounting | MountingHole_3.2mm_M3 | H1, H2, H3, H4 |
| 3 | 100pF / 50V | Capacitor_SMD:C_0805_2012Metric | C3, C4, C5 |
| 2 | 100nF / 50V | Capacitor_SMD:C_0805_2012Metric | C6, C7 |
| 1 | 10uF / 10V | Capacitor_SMD:C_0805_2012Metric | C1 |
| 1 | 120 | Resistor_SMD:R_0805_2012Metric | R16 |
| 1 | 3V3 DRIVE I/O | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J5 |
| 1 | 4.7uF / 10V | Capacitor_SMD:C_0805_2012Metric | C2 |
| 1 | 5V INPUT | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J1 |
| 1 | AP2112K-3.3 | Package_TO_SOT_SMD:SOT-23-5 | U1 |
| 1 | E-STOP AUX NC | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J7 |
| 1 | ENCODER 3V3 | Connector_PinHeader_2.54mm:PinHeader_1x05_P2.54mm_Vertical | J3 |
| 1 | END TERM | Jumper:SolderJumper-2_P1.3mm_Open_Pad1.0x1.5mm | JP1 |
| 1 | GREEN | LED_SMD:LED_0805_2012Metric | D2 |
| 1 | LTC2850IS8 | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U2 |
| 1 | MCU 3V3 I/O | Connector_PinHeader_2.54mm:PinHeader_1x16_P2.54mm_Vertical | J2 |
| 1 | MF-NSMF025X-2 | INDRBT_Interface:PTC_Bourns_MF-NSMF025X_1206 | F1 |
| 1 | NC LIMIT | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J4 |
| 1 | RS485 BUS | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J6 |
| 1 | SS14 | Diode_SMD:D_SMA | D1 |
It measures 100 × 100 mm and has 4 copper layers, 1.6 mm thick.
48 parts, built around the LTC2850IS8#PBF, AP2112K-3.3, BAT54H and MF-NSMF025X-2. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the pratham-cloud-ctrl/INDRBT repository on GitHub, at the commit this page was made from: the board is 06_Complete_Project_Source/electronics/joint_interface.kicad_pcb and its schematic 04_Electronics/joint_interface.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
balazsbencs/ardor
This is a DIY multieffects project with a Raspberry Pi and and Codec Zero and a Raspberry Pi Display 2. With Full NAM A2 support.


EdmundLimBoEn/gps-maidenhead-device
Open-source portable GNSS Maidenhead grid locator with a 16x2 LCD

micthiesen/stillair
Production-intent KiCad 10 project for the 88 x 64 mm PCB-01 V2 controller. The schematic, footprints, exact ratsnest, four-layer board setup, placement, rule areas, copper zones, keepouts, fiducials, silkscreen, and…

ajisrawi/dronemagnav
Magnetic-anomaly navigation (MagNav) board + firmware for drones: ESP32-S3, BMI088, LIS3MDL, BMP280, u-blox GNSS, WDMAM map matching, particle filter, MAVLink, phone route planner. Proprietary - all rights reserved.

pushtiujeniya/esp32-c6-environmental-logger
This repository contains an Environmental Sensor Station and Data Logger powered by the ESP32-C6-WROOM-1 microcontroller.

MuffinByteLabs/esp32s3-plant-monitor
Portfolio PCB: ESP32-S3 Wi-Fi plant monitor. 4-layer KiCad 10 design, fabricated and assembled at JLCPCB — schematic, reviews and the frozen manufacturing package all readable in-browser.