2 layers57.3 × 79.5 mm

 kbumsik/WolfieMouse79
IEEE Reion 1 Micromouse competition.
Micromouse is an open-source printed circuit board by kbumsik, from the kbumsik/WolfieMouse repository on GitHub. It is a 2-layer board of 100 × 74 mm with 214 parts on 98 nets, routed with 1,115 tracks and 95 vias.
It is built around the MAX14871EUE+, HCMS-2901 and MPU-9250, with the TPS73633DBV, TPS76850QD and DMN3150LW among its other parts. Its parts include 8 transistors, 7 ICs, 4 connectors, 3 switches and 2 resistors. It belongs with the robots and motor control boards and the STM32 boards of this library.


WolfieMouse is a robotics project to build a micromouse. This project covers three parts:
This robot won:
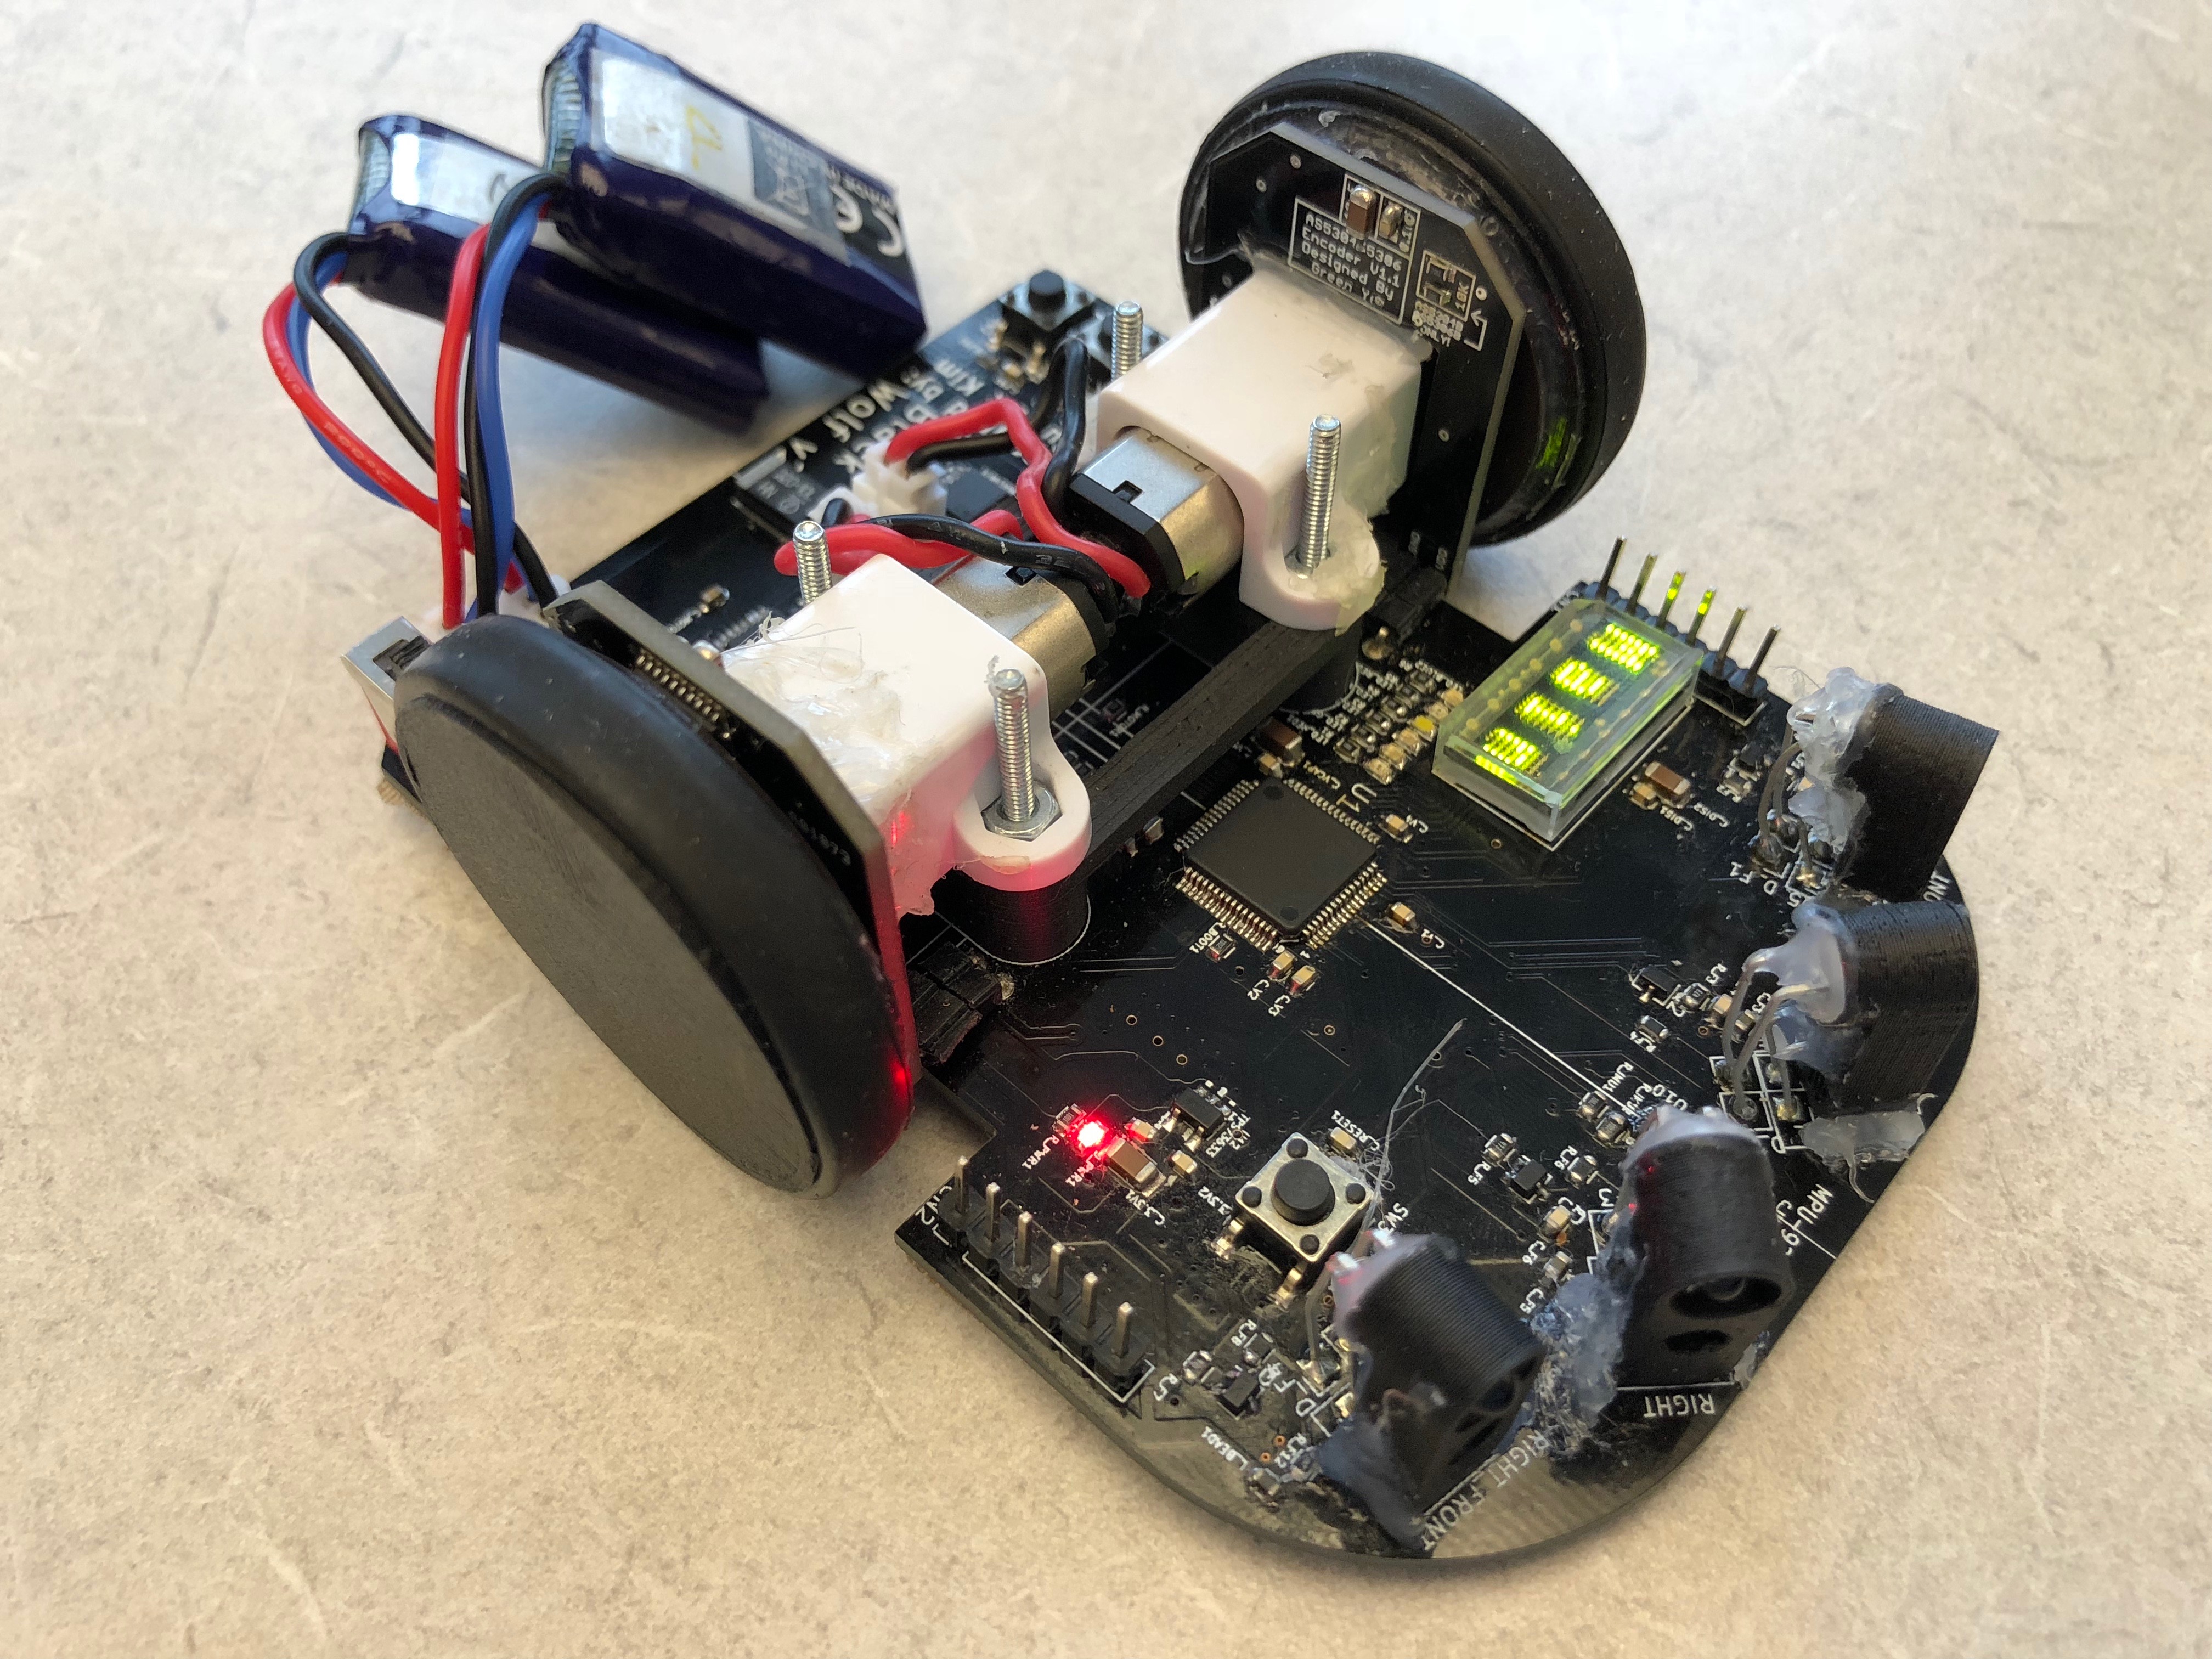
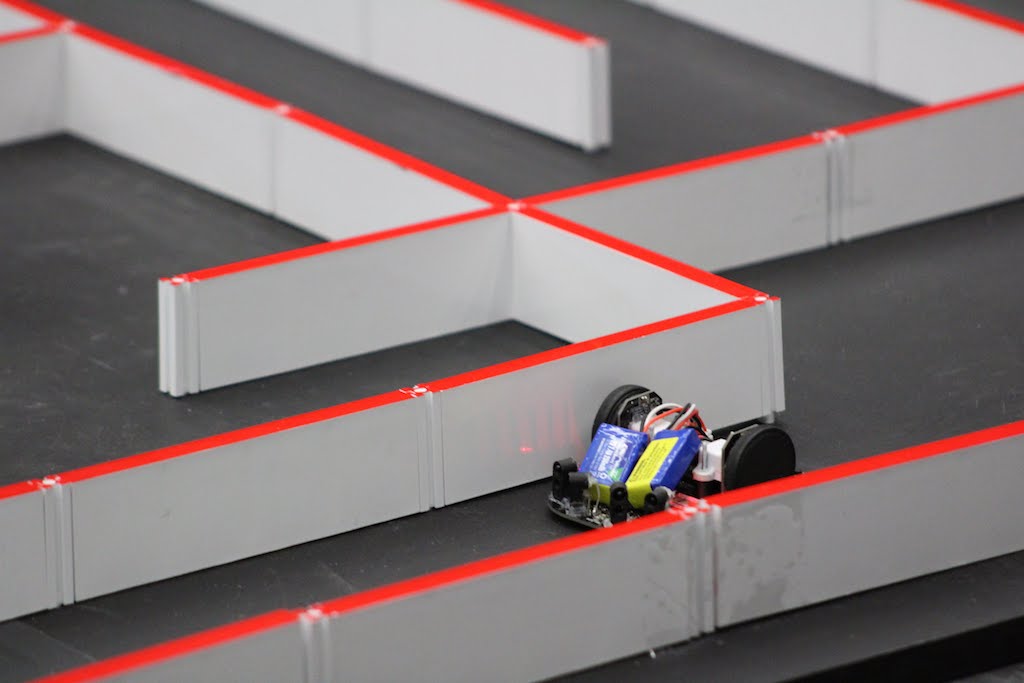
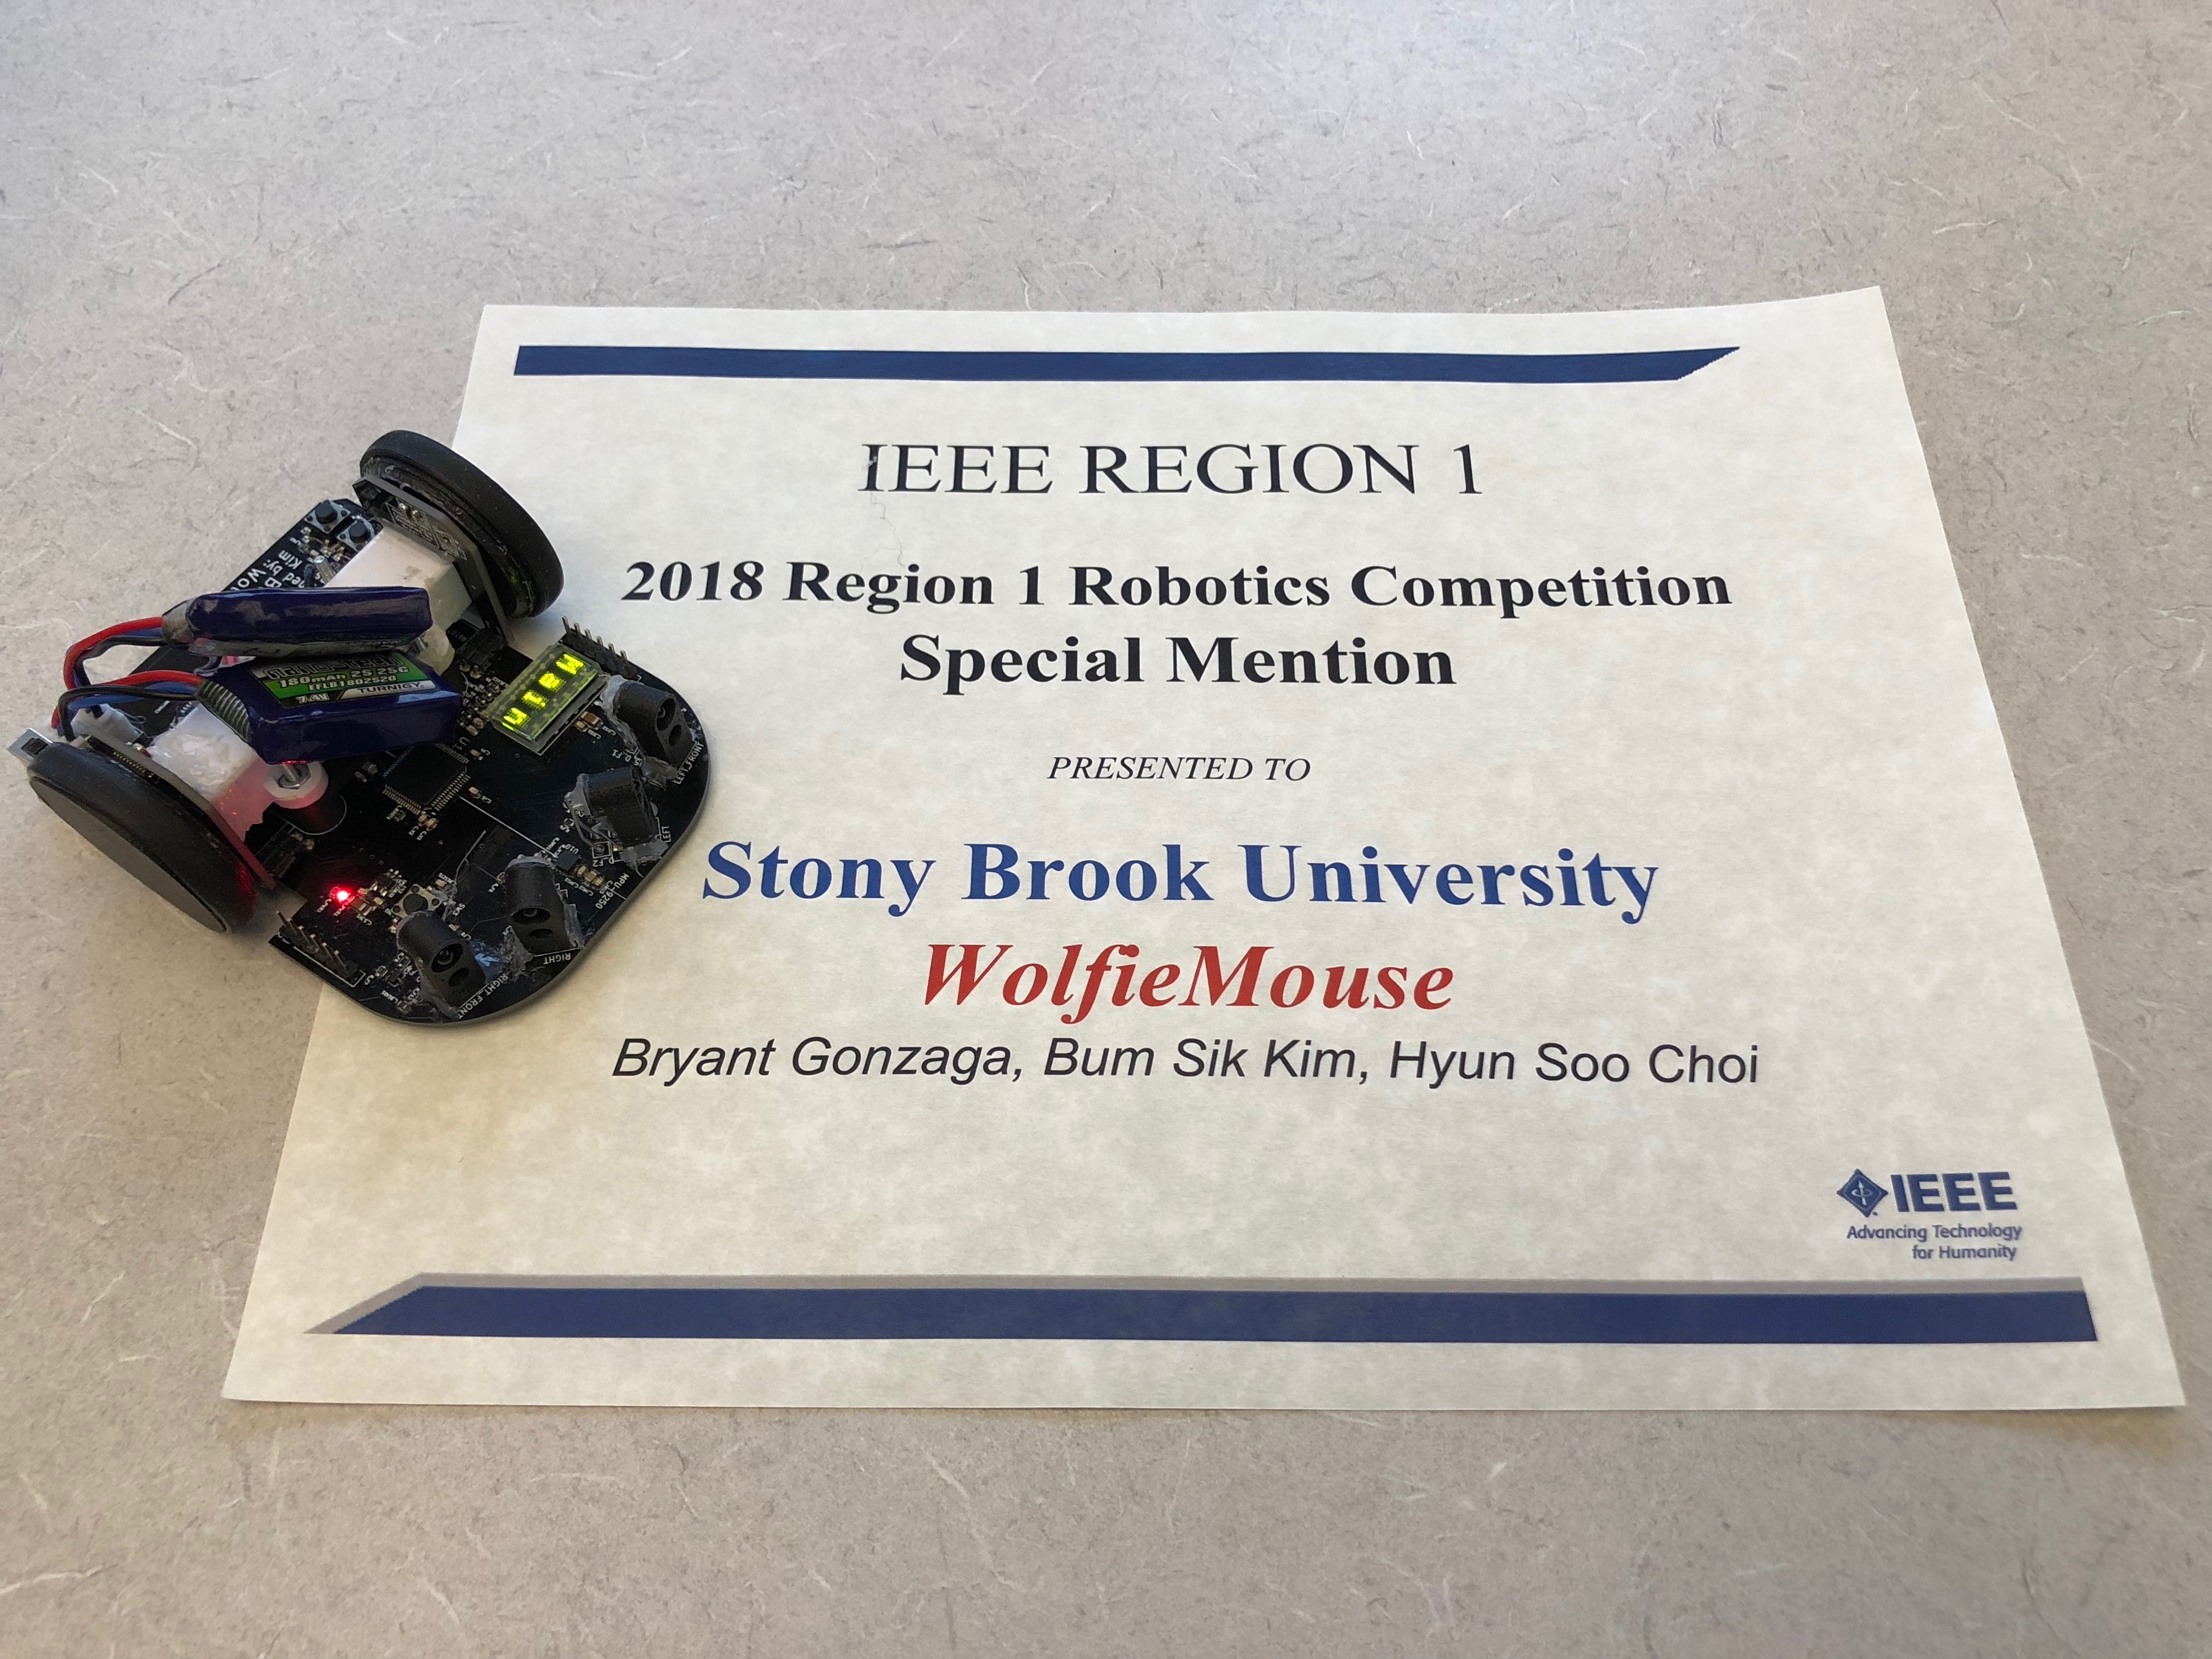
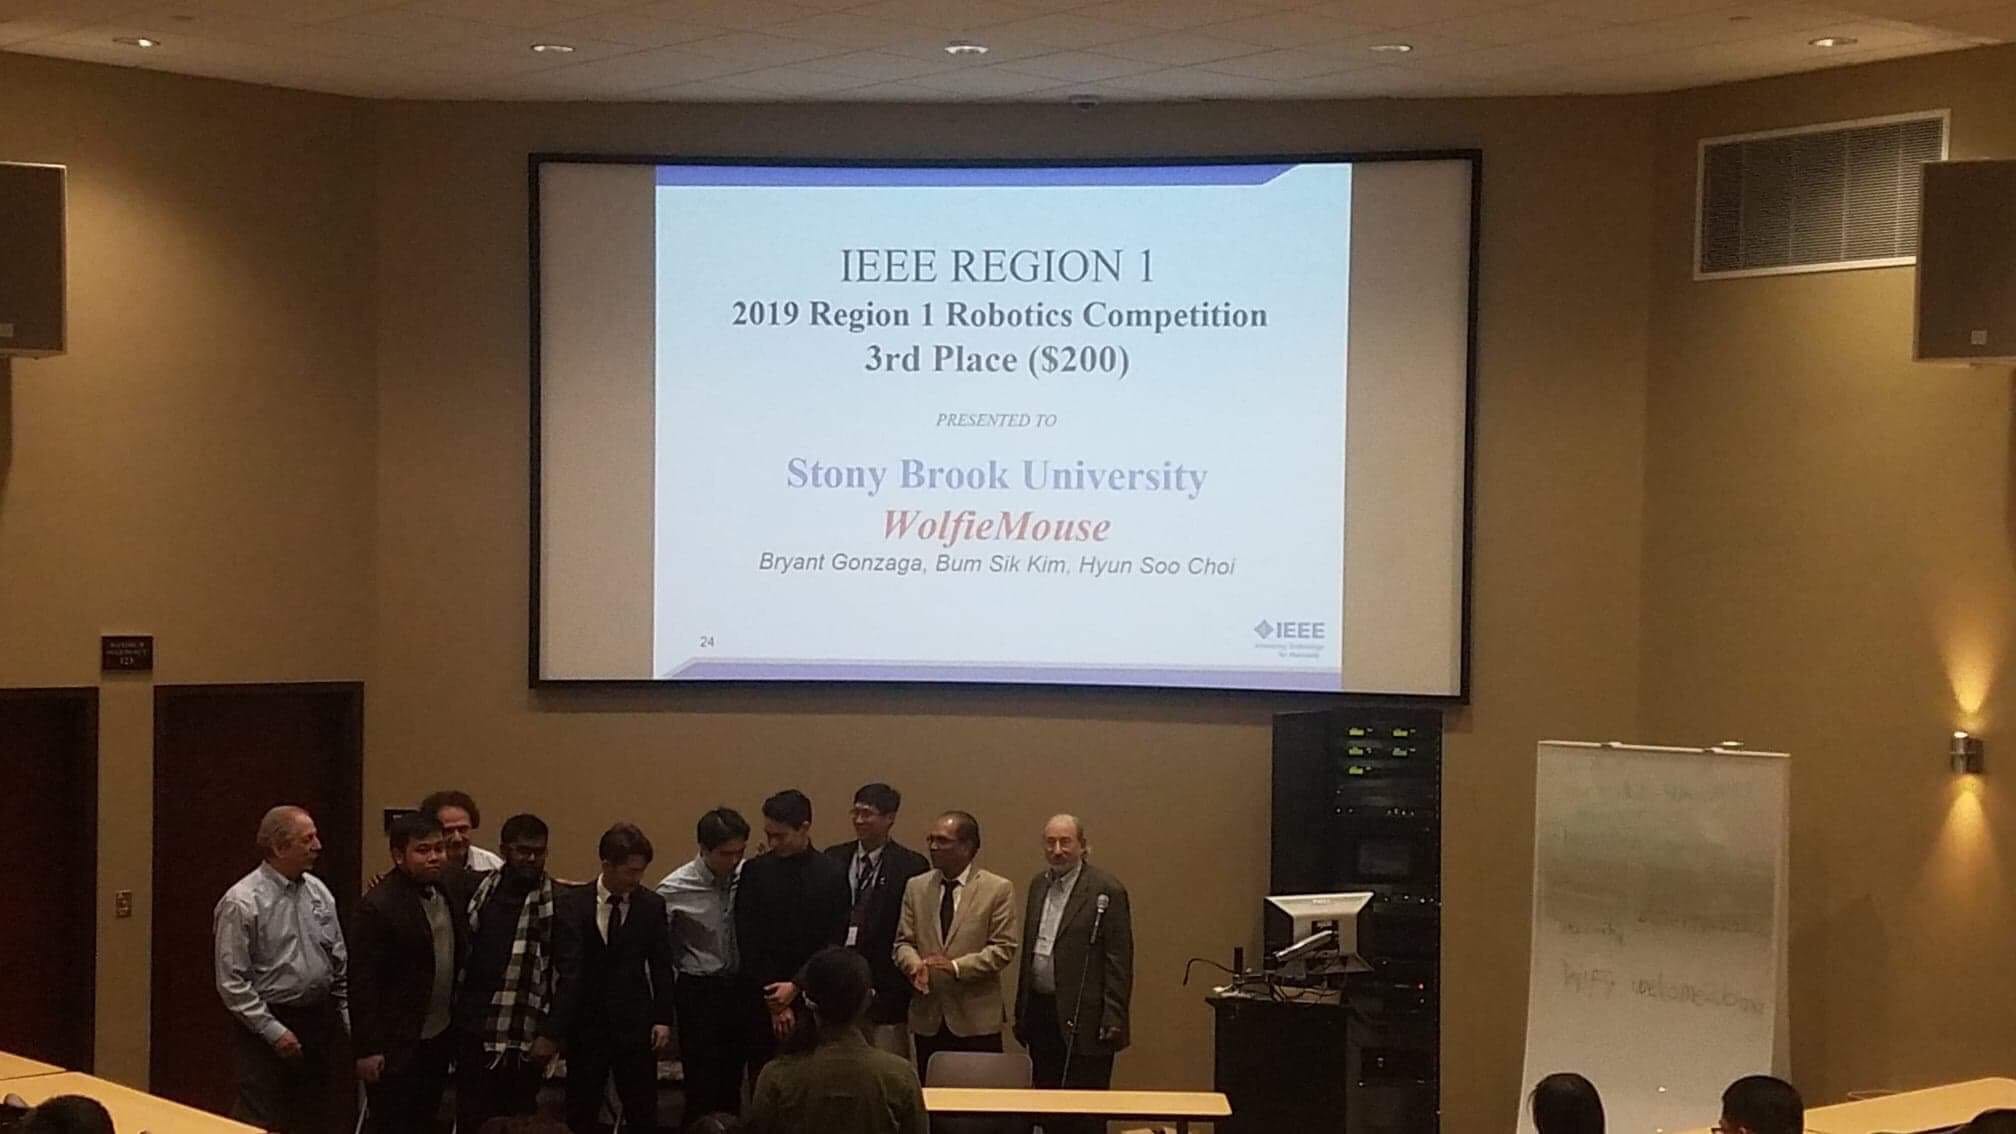
If you don't know what is micromouse competition, this document will help..
Requires tools:
Otherwise, a Vagrant virtual machine environment is provided to skip installing the above tools.
If you whish to start with this project, see get stared document.
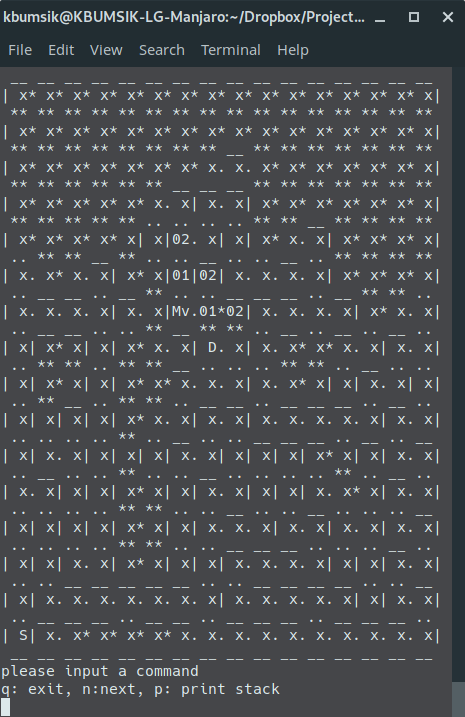
doc: Documentation folderfirmware: The robot's program folder, including robotics algorithms and hardware driverssimulation: Programs to test algorithms on a desktop computertools: Contains robot sensor data capturing tools and scripts for Vagrant machine.Terminal-based simulation program. M stands for the position of the robot, D stands for the position of the goal in the maze, and S stands for the starting position.
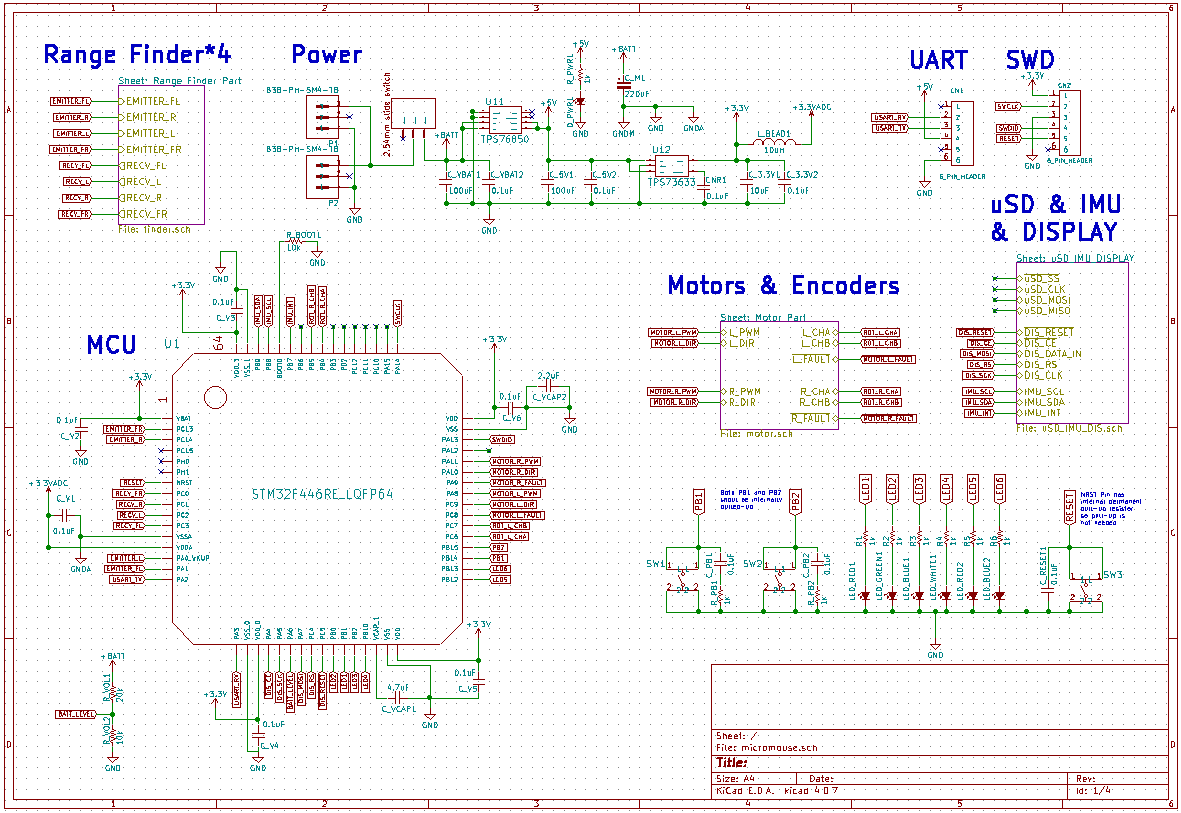
Schematic overview.
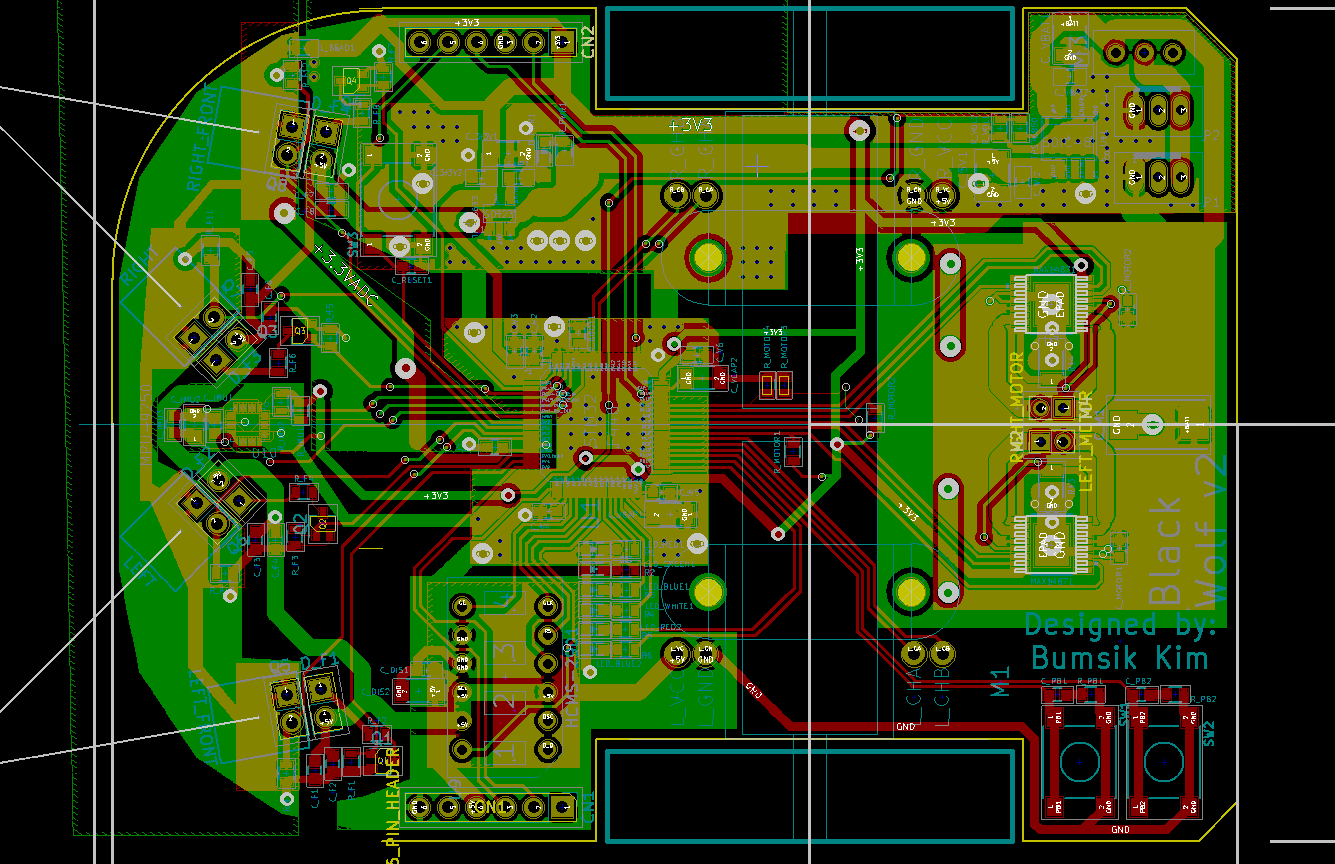
PCB Footprint overview.
Source code in firmware and simulation folders are licensed under GPLv2.1.
External libraries (FreeRTOS, CMSIS, STM32F4 HAL) under firmware/lib follow their own terms.
The fundamental hardware design is inspired by Project Futura by Green Ye.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 106 | VIA-0.6mm | footprints_micromouse:VIA-0.6mm | VIA_STICH, VIA_STICH, VIA_STICH, VIA_STICH, VIA_STICH, VIA_STICH, VIA_STICH, VIA_STICH, VIA_STICH, VIA_STICH, VIA_STICH, VIA_STICH, VIA_STICH, VIA_STICH, VIA_STICH, VIA_STICH +90 |
| 16 | 0.1uF | footprints_micromouse:C_0603 | C_3.3V2, C_5V2, C_DIS1, C_IMU1, C_IMU3, C_PB1, C_PB2, C_RESET1, C_V1, C_V2, C_V3, C_V4, C_V5, C_V6, C_VBAT2, CNR1 |
| 9 | 1k | footprints_micromouse:R_0603 | R_PB1, R_PB2, R_PWR1, R1, R2, R3, R4, R5, R6 |
| 7 | Led_Small | footprints_micromouse:LED_0603 | D_PWR1, LED_BLUE1, LED_BLUE2, LED_GREEN1, LED_RED1, LED_RED2, LED_WHITE1 |
| 6 | 10k | footprints_micromouse:R_0603 | R_BOOT1, R_IMU1, R_IMU2, R_MOTOR1, R_MOTOR2, R_VOL2 |
| 4 | 0.1u | footprints_micromouse:C_0603 | C_F2, C_F4, C_F6, C_F8 |
| 4 | 2.4k | footprints_micromouse:R_0603 | R_F9, R_F10, R_F11, R_F12 |
| 4 | 4.7u | footprints_micromouse:C_0603 | C_F1, C_F3, C_F5, C_F7 |
| 4 | 47k | footprints_micromouse:R_0603 | R_F1, R_F3, R_F5, R_F7 |
| 4 | DMN3150LW | TO_SOT_Packages_SMD:SOT-323_SC-70 | Q1, Q2, Q3, Q4 |
| 4 | RANGE_SENSOR_HOUSING | footprints_micromouse:RANGE_SENSOR_HOUSING | LEFT, LEFT_FRONT, RIGHT, RIGHT_FRONT |
| 4 | SFH 4545 | Pin_Headers:Pin_Header_Straight_1x02_Pitch2.54mm | D_F1, D_F2, D_F3, D_F4 |
| 4 | TEFT4300 | Pin_Headers:Pin_Header_Straight_1x02_Pitch2.54mm | Q5, Q6, Q7, Q8 |
| 3 | SWITCH_DPST | footprints_micromouse:SW_SPST_PTS645 | SW1, SW2, SW3 |
| 2 | 10 | footprints_micromouse:R_0603 | R_F2, R_F8 |
| 2 | 100uF | footprints_micromouse:C_1210 | C_5V1, C_VBAT1 |
| 2 | 10k | Resistors_SMD:R_0603 | R_MOTOR3, R_MOTOR4 |
| 2 | 10uF | footprints_micromouse:C_1206 | C_3.3V1, C_DIS2 |
| 2 | 1uF | footprints_micromouse:C_0603 | C_MOTOR1, C_MOTOR2 |
| 2 | 20 | footprints_micromouse:R_0603 | R_F4, R_F6 |
| 2 | 62.5m | footprints_micromouse:R_1206 | R13, R14 |
| 2 | 6_PIN_HEADER | Pin_Headers:Pin_Header_Straight_1x06_Pitch2.54mm | CN1, CN2 |
| 2 | B3B-PH-SM4-TB | footprints_micromouse:JST_B3B-PH_HEADER | P1, P2 |
| 2 | MAX14871 | footprints_micromouse:TSSOP-16_EP | U2, U3 |
| 1 | 10nF | footprints_micromouse:C_0805 | C_IMU2 |
| 1 | 10uH | footprints_micromouse:R_0603 | L_BEAD1 |
| 1 | 2.2uF | footprints_micromouse:C_1206 | C_VCAP2 |
| 1 | 2.54MM-SLIDE-SWITCH_TS02_SWITCH | footprints_micromouse:2.54MM-SLIDE-SWITCH_TS02_SWITCH | M3 |
| 1 | 20k | footprints_micromouse:R_0603 | R_VOL1 |
| 1 | 220uF | footprints_micromouse:TantalC_SizeD_EIA-7343_Reflow | C_M1 |
| 1 | 4.7uF | footprints_micromouse:C_1206 | C_VCAP1 |
| 1 | HCMS-2901 | footprints_micromouse:HCMS-2903 | U9 |
| 1 | LEFT_MOTOR | Pin_Headers:Pin_Header_Straight_1x02_Pitch2.00mm | M2 |
| 1 | MOTOR_MOUNTS_AND_ENCODERS | footprints_micromouse:FUTURA-1.0-MOTOR-MOUNT-TEMPLATE | M1 |
| 1 | MPU-9250 | MPU-9250:QFN-24%2f3MM | U10 |
| 1 | RIGHT_MOTOR | Pin_Headers:Pin_Header_Straight_1x02_Pitch2.00mm | M4 |
| 1 | STM32F446RE_LQFP64 | footprints_micromouse:STM32F446_LQFP64 | U1 |
| 1 | TPS73633 | footprints_micromouse:TPS73633_SOT-23 | U12 |
| 1 | TPS76850 | footprints_micromouse:TPS76850_SOIC-8 | U11 |
It measures 100 × 74 mm and has 2 copper layers, 1.6 mm thick.
214 parts, built around the MAX14871EUE+, HCMS-2901, MPU-9250 and TPS73633DBV. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the kbumsik/WolfieMouse repository on GitHub, at the commit this page was made from: the board is hardware/kicad_wolfiemouse/micromouse.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask kbumsik before reusing the design.

WheelchairSeniorDesign/PCBs
The PCB designs for the wheelchair for our senior design project

ninjatill/PCB-Capacitive-Touch-Synth
A Raspberry Pi-based synthesizer with capacitive touch keys directly on a PCB.

UBIEEE/FrankenMouse
FrankenMouse is a MicroMouse robot that was designed, built, and programmed from scratch by members of the University at Buffalo's IEEE Student Branch.


vorlaxen-labs/AratMicro
High-performance, open-source micromouse robot platform built for Robosam and MEB Robot (Ministry of National Education Robotics Competition, Turkey).

ChristopherAwomolo/Nova-Micromouse
Newer version based off the Futura Micromouse

ductomn/Swarm-robot
Bachelor Thesis - Design and implementation of a cooperative robotic platform with simple communication