2 layers50.5 × 128.5 mm

 Joanna610/Self-Balancing-Robot
This project is still in development !!!
Self Balancing Robot is an open-source printed circuit board by Joanna610, from the Joanna610/Self-Balancing-Robot repository on GitHub. It is a 2-layer board of 72.8 × 44.8 mm with 31 parts on 36 nets, routed with 1 track and 0 vias.
It is built around the ATMEGA328P-AU and LP2985-33DBV. Its parts include 11 capacitors, 9 connectors, 4 resistors, 3 ICs and 2 diodes. It belongs with the robots and motor control boards and the AVR (ATmega, ATtiny) boards of this library.


This project is still in development !!!
The projects include code for Arduino. It collects data from the acceleromiter MPU6050 and modifies them accordingly. The code also turn on and off the motors with PWM. It can do this thanks to H bridge - L293D. The robot try to stabilize itself due to implemented PID algorithm.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | 100nF | Capacitor_SMD:C_0805_2012Metric | C1, C2, C3, C4, C6, C7, C8, C14 |
| 2 | 4.7k | Resistor_SMD:R_0805_2012Metric | R4, R5 |
| 2 | 47uF | Capacitor_SMD:C_0805_2012Metric | C12, C13 |
| 1 | 10k | Resistor_SMD:R_0805_2012Metric | R1 |
| 1 | 1uF | Capacitor_SMD:C_0805_2012Metric | C5 |
| 1 | 330 | Resistor_SMD:R_0805_2012Metric | R3 |
| 1 | ATmega328P-A | Package_QFP:TQFP-32_7x7mm_P0.8mm | U1 |
| 1 | Analog | Connector_PinSocket_2.54mm:PinSocket_1x06_P2.54mm_Vertical | J2 |
| 1 | Crystal | Crystal:Crystal_HC49-4H_Vertical | Y1 |
| 1 | D_Schottky | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | D1 |
| 1 | I2C | Connector_PinSocket_2.54mm:PinSocket_1x05_P2.54mm_Vertical | J1 |
| 1 | L293D_left | Connector_PinSocket_2.54mm:PinSocket_1x08_P2.54mm_Vertical | J5 |
| 1 | L293D_right | Connector_PinSocket_2.54mm:PinSocket_1x08_P2.54mm_Vertical | J8 |
| 1 | LED | LED_SMD:LED_1206_3216Metric | D3 |
| 1 | LP2985-3.3 | Package_TO_SOT_SMD:SOT-23-5 | U4 |
| 1 | NCP1117-5.0_SOT223 | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U5 |
| 1 | SPI | Connector_PinSocket_2.54mm:PinSocket_1x07_P2.54mm_Vertical | J10 |
| 1 | SW_Push | Button_Switch_THT:SW_PUSH_1P1T_6x3.5mm_H5.0_APEM_MJTP1250 | SW1 |
| 1 | UART | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J7 |
| 1 | input_supply | Connector_TE-Connectivity:TE_826576-2_1x02_P3.96mm_Vertical | J9 |
| 1 | left_engine | Connector_TE-Connectivity:TE_826576-2_1x02_P3.96mm_Vertical | J3 |
| 1 | right_engine | Connector_TE-Connectivity:TE_826576-2_1x02_P3.96mm_Vertical | J4 |


adeboni/eurorack
This repository stores various eurorack module designs I've made

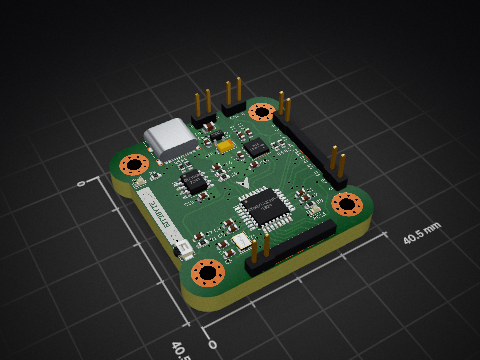

It measures 72.8 × 44.8 mm and has 2 copper layers, 1.6 mm thick.
31 parts, built around the ATMEGA328P-AU and LP2985-33DBV. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Joanna610/Self-Balancing-Robot repository on GitHub, at the commit this page was made from: the board is PCB design/self_balancing_robot.kicad_pcb and its schematic PCB design/self_balancing_robot.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask Joanna610 before reusing the design.