
2 layers178 × 145 mm
Ultra DB X51 v1
ExploreEmbedded/8051_DevelopmentBoard
Design files and sample code for 8051 development Ultra Boards
145 parts70

 itsjeanxx12/QuadMotorHAT
A custom Raspberry Pi HAT for controlling four DC motors with simple Python control.
QuadMotorHAT is an open-source printed circuit board by itsjeanxx12, from the itsjeanxx12/QuadMotorHAT repository on GitHub, published under the MIT licence. It is a 2-layer board of 65 × 56 mm with 17 parts on 41 nets, routed with 202 tracks and 5 vias.
It is built around the L293D. Its parts include 5 capacitors, 4 connectors, 2 ICs, 1 resistor and 1 diode. It belongs with the robots and motor control boards of this library.
A simple Raspberry Pi HAT for controlling four DC motors.
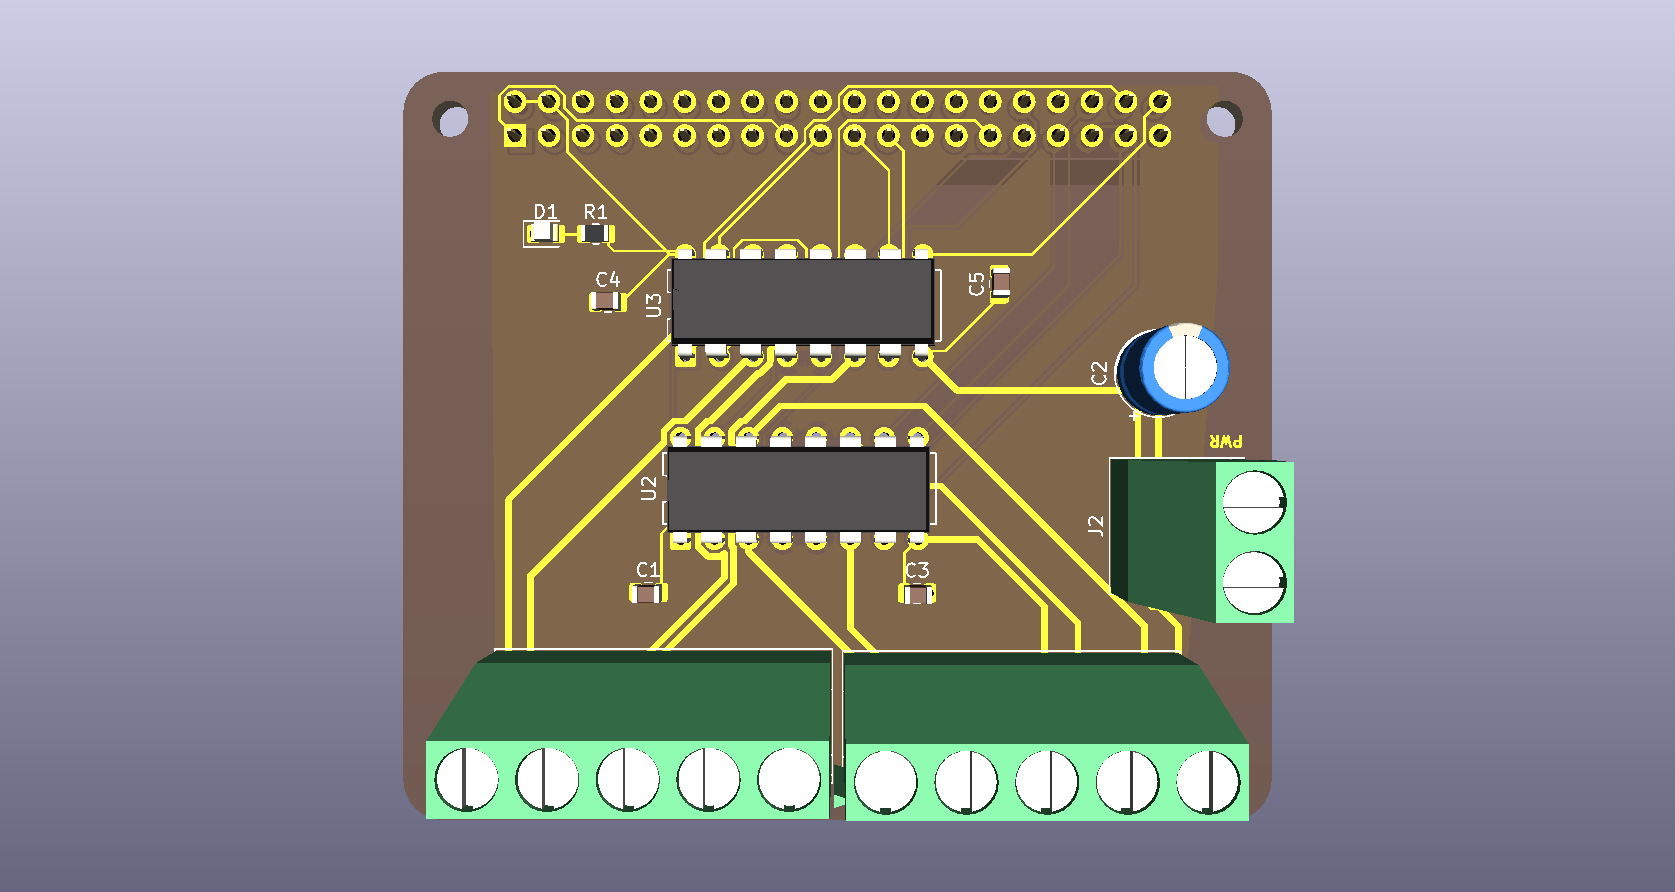
While making my WRO robot, I ran into a problem: I needed to control multiple motors from a Raspberry Pi without a mess of separate boards and wiring.
There are already plenty of motor HATs available, but I wanted something simple that fit what I needed. So I decided to design my own.
The repository includes quadmotorhat.py, which provides a simple interface for controlling the four motors.
First, install gpiozero:
pip install gpiozeroThen place quadmotorhat.py in the same directory as your Python program:
your_project/
├── quadmotorhat.py
└── main.py
Import the motor controls:
from quadmotorhat import M1, M2, M3, M4You can then use M1, M2, M3, and M4 to control the four motor outputs.
The full board design is included in the repository.
QuadMotorHAT.kicad_sch — SchematicQuadMotorHAT.kicad_pcb — PCB layoutQuadMotorHAT.kicad_pro — KiCad projectYou can open these files in KiCad to inspect or modify the design.
This project is licensed under the terms of the license included in this repository.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | 0.1uF | Capacitor_SMD:C_0805_2012Metric | C1, C3, C4, C5 |
| 4 | MountingHole_2.7mm_M2.5 | MountingHole:MountingHole_2.7mm_M2.5 | MH1, MH2, MH3, MH4 |
| 2 | L293D | Package_DIP:DIP-16_W7.62mm | U2, U3 |
| 1 | 100uF 35V | Capacitor_THT:CP_Radial_D6.3mm_P2.50mm | C2 |
| 1 | 330 | Resistor_SMD:R_0805_2012Metric | R1 |
| 1 | GPIO | Connector_PinSocket_2.54mm:PinSocket_2x20_P2.54mm_Vertical | J1 |
| 1 | LED | LED_SMD:LED_0805_2012Metric | D1 |
| 1 | M1/GND/M2 | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-5_1x05_P5.00mm_Horizontal | J4 |
| 1 | M3/GND/M4 | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-5_1x05_P5.00mm_Horizontal | J3 |
| 1 | MPWR | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-2_1x02_P5.00mm_Horizontal | J2 |
ExploreEmbedded/8051_DevelopmentBoard
Design files and sample code for 8051 development Ultra Boards

NikodemBartnik/Small-Projects
All of smaller projects (Arduino, PCBs, electronics, code)

geno543/Redropi_highway
the project aims to detect asteroids and meteor movement using high-quality cameras and radar detection methods using an AI model for accurate analysis, and it classifies bodies be in three categories: non-meteor…


harrislab-brown/DropGen
DropGen uses a fluid reservoir and a piezoelectric buzzer to precisely and repeatably dispense small droplets on demand.


It measures 65 × 56 mm and has 2 copper layers, 1.6 mm thick.
17 parts, built around the L293D. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the itsjeanxx12/QuadMotorHAT repository on GitHub, at the commit this page was made from: the board is QuadMotorHAT.kicad_pcb and its schematic QuadMotorHAT.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).