Skip to the content
PCBKitNew board
4 layers36 × 56 mmDynamixel control, the printed circuit board in 3D

Dynamixel control

introlab/t-top20

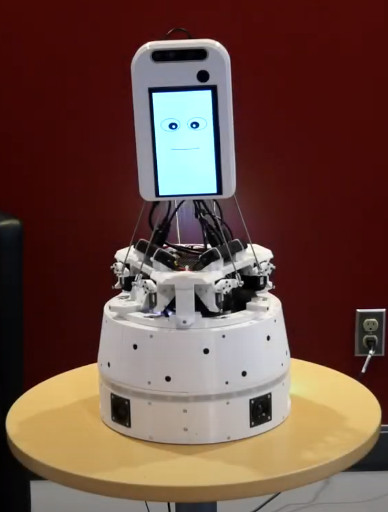
T-Top is a tabletop robot designed with advanced audio and vision sensors, deep learning perceptual processing and telecommunication capabilities to provide richer interaction modalities and develop higher cognitive abilities from interacting with people.

Size
36 × 56 mm
Copper layers
4
Thickness
1.6 mm
Parts
55
Nets
53
Pads
184
Tracks, vias
346, 53
Pours
17
Routed
Yes
KiCad
KiCad 6 (file 20211014)
Created
21 Sep 2021
Updated
26 Oct 2026

Overview

Dynamixel control is an open-source printed circuit board by introlab, from the introlab/t-top repository on GitHub. It is a 4-layer board of 36 × 56 mm with 55 parts on 53 nets, routed with 346 tracks and 53 vias.

It is built around the R-78E5.0-0.5, SN65C3221EPW and SN74LV1T34DBV, with the SN74LVC2G241DCU, ICM-40627 and SN74AHC1G14DBV among its other parts. Its parts include 20 capacitors, 15 resistors, 7 ICs, 6 connectors and 2 transistors. It belongs with the robots and motor control and audio and music boards and the NXP (LPC, Kinetis, i.MX RT) boards of this library.

Main components

8

README

README.md

T-Top

T-Top is a tabletop robot designed with advanced audio and vision sensors, deep learning perceptual processing and telecommunication capabilities to provide richer interaction modalities and develop higher cognitive abilities from interacting with people.

T-Top

T-Top

Authors

  • Marc-Antoine Maheux (@mamaheux)
  • Dominic Létourneau (@doumdi)
  • Philippe Warren (@philippewarren)
  • Mariam Fdil (@MariamFdil)
  • François Michaud, ing., Ph.D.

Contributors

  • Ian-Mathieu Joly (@joli-1801)
  • Charles Caya (@chcaya)
  • Alexandre Filion (@alexfilion)

Licensing

Features

CategoryTypeDescription
PowerPower Adapter19 V
Battery1x RRC2054-2
Battery Charger1x RRC-PMM240
SensorsMicrophone Array16x xSoundsMicrophones, 1x 16SoundsUSB
RGB-D Camera1x Intel RealSense D435i
Wide Angle Camera1x Arducam AR0230
Touchscreen1x 7 inch 1024x600 capacitive touchscreen
Current/VoltageINA220
Light Sensors4x Adafruit ALS-PT19
Buttons4x buttons
ActuatorsStewart PlatformDisplacement range: ±3 cm (x, y and z), ±20° (x and y), ±30° (z). Motor: Dynamixel XL430-W250
Rotating BaseDisplacement range: illimited. Motor: Dynamixel XL430-W250
Speakers4x Dayton Audio DMA45-8, 2x MAX9744
Cooling2x Noctua NF-A4x20 5V
Touchscreen1x 7 inch 1024x600 capacitive touchscreen
LEDBattery status, volume level, led strip
NetworkWiFiIntel Dual Band Wireless-AC 8265 NGW
Ethernet100 Mbps
ProcessingComputerNVIDIA Jetson AGX Xavier Developer Kit or NVIDIA Jetson AGX Xavier Orin Developer Kit
Motor MCUTeensy 4.0
Battery MCUTeensy LC
PerceptionsSLAM, object detection, person pose estimation, face recognition, sound classification, speaker identification, robot name detection, speech to text, person identification, music beat detection, source source localization, ego noise reduction, vad
BehaviorsTelepresence, emotions, talking, greeting, face following, dancing, exploring, sound following

Repository Structure

  • The documentation folder contains the documentation to build and configure T-Top.
  • The CAD folder contains the SolidWorks files of the robot. Il also contains the DXF and STL files to cut and print custom parts.
  • The firmwares folder contains the firmware for the MCUs.
  • The PCB folder contains the KiCad files of the custom PCBs. Il also contains the Gerber files to manufacture the PCBs.
  • The ros folder contains the ROS packages to use the robot.
  • The tools folder contains the tools to develop and use the robot.

Development Computer Setup

See 01_COMPUTER_CONFIGURATION.md

Papers

Sponsor

IntRoLab

IntRoLab - Intelligent / Interactive / Integrated / Interdisciplinary Robot Lab

Parts

55
QtyValueFootprintReferences
130.1µF/25VCapacitor_SMD:C_0805_2012MetricC4, C5, C7, C8, C9, C10, C11, C13, C15, C18, C19, C22, C23
410kResistor_SMD:R_0805_2012MetricR1, R2, R3, R12
30Resistor_SMD:R_0805_2012MetricR4, R10, R11
3100kResistor_SMD:R_0805_2012MetricR15, R16, R18
310µF/25VCapacitor_SMD:C_0805_2012MetricC1, C3, C14
3Dynamixel TTLt-top:25SH-C-03-TSJ8, J11, J12
212µH (RLS-126)Inductor_SMD:L_1812_4532MetricL1, L2
22.2kResistor_SMD:R_0805_2012MetricR7, R8
22.2µF/25VCapacitor_SMD:C_0805_2012MetricC12, C25
110nF/25VCapacitor_SMD:C_0805_2012MetricC6
112Vt-top:t-connectorJ1
14.7µF/25VCapacitor_SMD:C_0805_2012MetricC2
147Resistor_SMD:R_0805_2012MetricR14
1825Resistor_SMD:R_0805_2012MetricR17
1Debug UartConnector_PinHeader_1.27mm:PinHeader_1x03_P1.27mm_VerticalJ6
1ICM-40627t-top:ICM-40627U6
1IPD068P03L3GATMA1Package_TO_SOT_SMD:TO-252-2Q2
1LIMIT_SWITCHConnector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_VerticalSW1
1MountingHole_3.2mm_M3MountingHole:MountingHole_3.2mm_M3MH1
1NIResistor_SMD:R_0805_2012MetricR9
1R-78E5.0-0.5t-top:R-78E-0.5U1
1RS232Connector_JST:JST_PH_S3B-PH-K_1x03_P2.00mm_HorizontalJ2
1SN65C3221EPackage_SO:TSSOP-16_4.4x5mm_P0.65mmU5
1SN74AHC1G14Package_TO_SOT_SMD:SOT-23-5U2
1SN74LV1T34Package_TO_SOT_SMD:SOT-23-5U7
1SN74LVC2G241Package_SO:VSSOP-8_2.3x2mm_P0.5mmU8
1T2N7002AKPackage_TO_SOT_SMD:SOT-23Q3
1Teensy_4.0t-top:Teensy_4.0U4

The 54 most common of 55 parts.

Questions

How big is the Dynamixel control PCB?

It measures 36 × 56 mm and has 4 copper layers, 1.6 mm thick.

What parts does the Dynamixel control use?

55 parts, built around the R-78E5.0-0.5, SN65C3221EPW, SN74LV1T34DBV and SN74LVC2G241DCU. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.

Where can I download the Dynamixel control KiCad files?

From the introlab/t-top repository on GitHub, at the commit this page was made from: the board is PCB/dynamixel_control/dynamixel_control.kicad_pcb and its schematic PCB/buck_boost/buck_boost.kicad_sch. PCBKit opens the board in the browser, with nothing to install.

Can I use the Dynamixel control design in my own project?

Its repository states no licence, so its author keeps all rights: ask introlab before reusing the design.

More from introlab/t-top

2
  • 4 layers100 × 70 mmPsu control, the printed circuit board in 3D

    Psu control

    introlab/t-top

    T-Top is a tabletop robot designed with advanced audio and vision sensors, deep learning perceptual processing and telecommunication capabilities to provide richer interaction modalities and develop higher cognitive…

    122 parts20
  • 4 layers80 × 70 mmBuck boost, the printed circuit board in 3D

    Buck boost

    introlab/t-top

    T-Top is a tabletop robot designed with advanced audio and vision sensors, deep learning perceptual processing and telecommunication capabilities to provide richer interaction modalities and develop higher cognitive…

    61 parts20

Similar boards

  • 4 layers85 × 85 mmHv pulse controller, the printed circuit board in 3D

    Hv pulse controller

    wenzel-lab/high-voltage-pulse-generator

    Custom electronics solution for microfluidic droplet sorting pulses

    117 parts3
  • 2 layers110 × 90 mmMAFSK, the printed circuit board in 3D

    MAFSK

    dolson14/k7arx

    Circuit and PCB Designs, anything else related to radio and electronics

    76 parts
  • 6 layers122 × 61.5 mmGc20140203 v2, the printed circuit board in 3D

    Gc20140203 v2

    masahirosuzuka/GameChanger

    Open Source Hardware Tablet PC

    173 parts1
  • 4 layers74 × 52 mmMIsBkit Rev3, the printed circuit board in 3D

    MIsBkit Rev3

    alvarohub/workshop_MattersOfBehaviour

    88 parts
  • 4 layers160 × 80 mmAmos, the printed circuit board in 3D

    Amos

    des256/pcbs

    Making electronics as well

    401 parts
  • 4 layers27.7 × 63.5 mmEsp header 4 Layers, the printed circuit board in 3D

    Esp header 4 Layers

    snakebot-tohoku/esp_header_4_Layers

    4-layer PCB board designed as header for ESP32-S3 developer board to interface up to 15 motors and 15 analog sensors.

    28 parts
  • 2 layers76 × 228 mmRampedFetCoil, the printed circuit board in 3D

    RampedFetCoil

    flyingperson23/RampedFetCoil

    112 parts2