4 layers40 × 40 mm
Esptof
sikaxn/FRC-Custom-CAN-Sensor
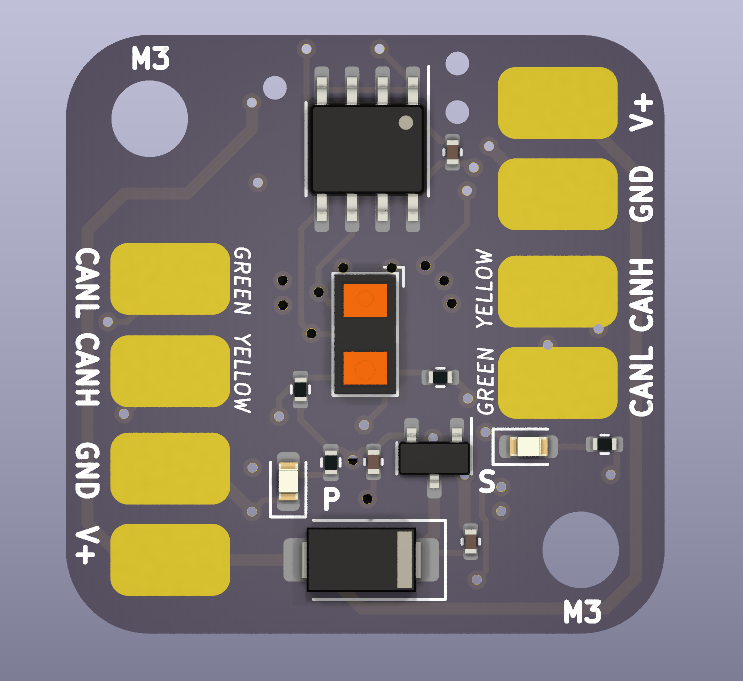
If you are looking for IronMaple ESP32‐FRC‐devkit resources, please switch branch to dev-board.
43 parts12GPL-3.0

 GrappleRobotics/LaserCAN3
LaserCAN Board is an open-source printed circuit board by GrappleRobotics, from the GrappleRobotics/LaserCAN repository on GitHub, published under the GPL-3.0 licence. It is a 4-layer board of 25 × 25 mm with 59 parts on 62 nets, routed with 360 tracks and 138 vias.
It is built around the SN65HVD230D, TPS54202DDC and M24C64-RMN6TP, with the TPS7A2033PDBVR-TP, ESDCAN24-2BLY and SMF15CA among its other parts. Its parts include 21 capacitors, 9 connectors, 7 resistors, 6 ICs and 5 diodes. It belongs with the STM32 boards of this library.


Welcome to the open-source repository for the Grapple LaserCAN! That's right, everything's open source from the board files to the firmware.
If you want to load your own firmware onto the LaserCAN, clone this repository and make your changes to lasercan-firmware. You can flash this image to the board by running python build.py firmware and flashing the target/lasercan-firmware-update-VERSION.grplfw file using GrappleHook.
NOTE: Be careful about what firmware you flash - custom firmware may brick the firmware update process if you don't have a ST-Link probe handy.
If you for whatever reason need to flash a new bootloader, or if a custom firmware has crashed and the watchdog hasn't picked it up, you can flash a new bootloader and firmware by running python build.py flash. This requires an ST-Link v2 compatible probe and a TagConnect TC-2050-NL cable to connect to the debug pads on the bottom of the LaserCAN.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 10 | 100n | Capacitor_SMD:C_0402_1005Metric | C2, C4, C5, C6, C7, C8, C9, C14, C15, C18 |
| 8 | ~ | Pad:Pad | J1, J3, J4, J5, J6, J7, J8, J9 |
| 6 | 10uF | Capacitor_SMD:C_0603_1608Metric | C1, C3, C12, C16, C17, C19 |
| 2 | 10k | Resistor_SMD:R_0402_1005Metric | R1, R10 |
| 2 | 20pF | Capacitor_SMD:C_0402_1005Metric | C20, C21 |
| 2 | 220 | Resistor_SMD:R_0402_1005Metric | R6, R7 |
| 2 | 22uF | Capacitor_SMD:C_0603_1608Metric | C10, C11 |
| 2 | LOGO | LOGO | G***, G*** |
| 2 | MountingHole | MountingHole:MountingHole_3.2mm_M3_Pad_TopBottom | H1, H2 |
| 1 | 100k | Resistor_SMD:R_0402_1005Metric | R2 |
| 1 | 12V | Diode_SMD:D_SOD-523 | D1 |
| 1 | 18.2k | Resistor_SMD:R_0402_1005Metric | R8 |
| 1 | 22uH | Inductor_SMD:L_1008_2520Metric | L2 |
| 1 | 33pF | Capacitor_SMD:C_0402_1005Metric | C13 |
| 1 | 4.7 | Resistor_SMD:R_0603_1608Metric | R9 |
| 1 | 8MHz 12pF | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | BLM18AG102SN1D | Inductor_SMD:L_0603_1608Metric | FB1 |
| 1 | ESDCAN24-2BLY | Package_TO_SOT_SMD:SOT-23 | D4 |
| 1 | LED GREEN | LED_SMD:LED_0603_1608Metric | D3 |
| 1 | LED_ORANGE | LED_SMD:LED_0603_1608Metric | D2 |
| 1 | M24C64-RMN6TP | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U3 |
| 1 | NetTie_2 | NetTie:NetTie-2_SMD_Pad2.0mm | NT2 |
| 1 | NetTie_2 | NetTie:NetTie-2_SMD_Pad0.5mm | NT1 |
| 1 | SMF15CA | Diode_SMD:D_SMF | D6 |
| 1 | SN65HVD230 | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U6 |
| 1 | STM32F103C8Tx | Package_QFP:LQFP-48_7x7mm_P0.5mm | U4 |
| 1 | Si2309CDS-T1-GE3 | SI2309CDS-T1-GE3:SOT-23_L2.9-W1.3-P1.90-LS2.4-BR | Q1 |
| 1 | TC2050-IDC-NL | Project:TAG-CONNECT_TC2050-IDC-NL | J2 |
| 1 | TPS54202DDC | Package_TO_SOT_SMD:SOT-23-6 | U9 |
| 1 | TPS7A2033PDBVR | Package_TO_SOT_SMD:SOT-23-5 | U1 |
| 1 | VL53L1CXV0FY1 | Sensor_Distance:ST_VL53L1x | U2 |
| 1 | YC164-JR-074K7L | Resistor_SMD:R_Array_Convex_4x0603 | RN1 |
It measures 25 × 25 mm and has 4 copper layers, 1.6 mm thick.
59 parts, built around the SN65HVD230D, TPS54202DDC, M24C64-RMN6TP and TPS7A2033PDBVR-TP. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the GrappleRobotics/LaserCAN repository on GitHub, at the commit this page was made from: the board is LaserCAN-Board/LaserCAN-Board.kicad_pcb and its schematic LaserCAN-Board/LaserCAN-Board.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
sikaxn/FRC-Custom-CAN-Sensor
If you are looking for IronMaple ESP32‐FRC‐devkit resources, please switch branch to dev-board.

fkontiebo/flight-controller
Contrôleur de vol 4 layers basé sur STM32F405RGT6, conçu comme plateforme de navigation autonome avec bus CAN.


generationmake/CyphalPicoBase-CAN
Board for the Raspberry Pi Pico to connect via CAN using OpenCyphal and UCANPHY Micro


Vtechcode/stm32f303_sim7600
This is a device that is suitable for IoT and machine-to-machine communication. SIM7600E is an industrial-grade LTE Cat 1 module designed for global IoT and M2M applications.