
2 layers43.8 × 58 mm
Pi hat
fodorbalint/OneWayLabyrinth
Program aiming to solve the one-way labyrinth generation riddle.
53 parts1

 fodorbalint/OneWayLabyrinth1
Program aiming to solve the one-way labyrinth generation riddle.
Speed limiter is an open-source printed circuit board by fodorbalint, from the fodorbalint/OneWayLabyrinth repository on GitHub. It is a 2-layer board of 54 × 33 mm with 26 parts on 18 nets, routed with 163 tracks and 3 vias.
It is built around the MCP6022-I/P. Its parts include 8 resistors, 4 capacitors, 4 connectors, 3 ICs and 1 transistor.
This research aims to solve the following problem:
"Draw a line that goes through an n x n grid (where n is an odd number), passing through each field once. The line has to start from the field at the upper left corner (1,1) and end at (n,n). At any time it is allowed to move left, right, up or down, and it has to randomly choose between the available fields."
At first sight it may look easy. But look at the following example:

Based on the black line's movement, blue fragments were drawn to indicate a path we have to go through in the future in order to fill the board.
Do you see why the situation is impossible from now on?
The question is, is there a single rule or a set of rules that will guarantee you can draw a labyrinth of any size? Or do the rules get infinitely complex?
To assist with the research, I have written a computer program. In the beginning, I let it run on a 21 x 21 field, and whenever I noticed a trouble, I coded the solution into it. While you can discover many patterns this way, they will be random and do not help in gaining a fundemental understanding. At one point you will find things get too complex, and you are still far from solving the 21 x 21 board.
That's where a gradual approach comes in.
Due to the length of the study, it cannot be displayed on this one page. To continue reading, download the PDF files for screen reading or to be printed out.)
The project contains the source code for use with Visual Studio. To start the program, run OneWayLabyrinth.exe in the folder "bin/Debug/net6.0-windows".
Screenshots:
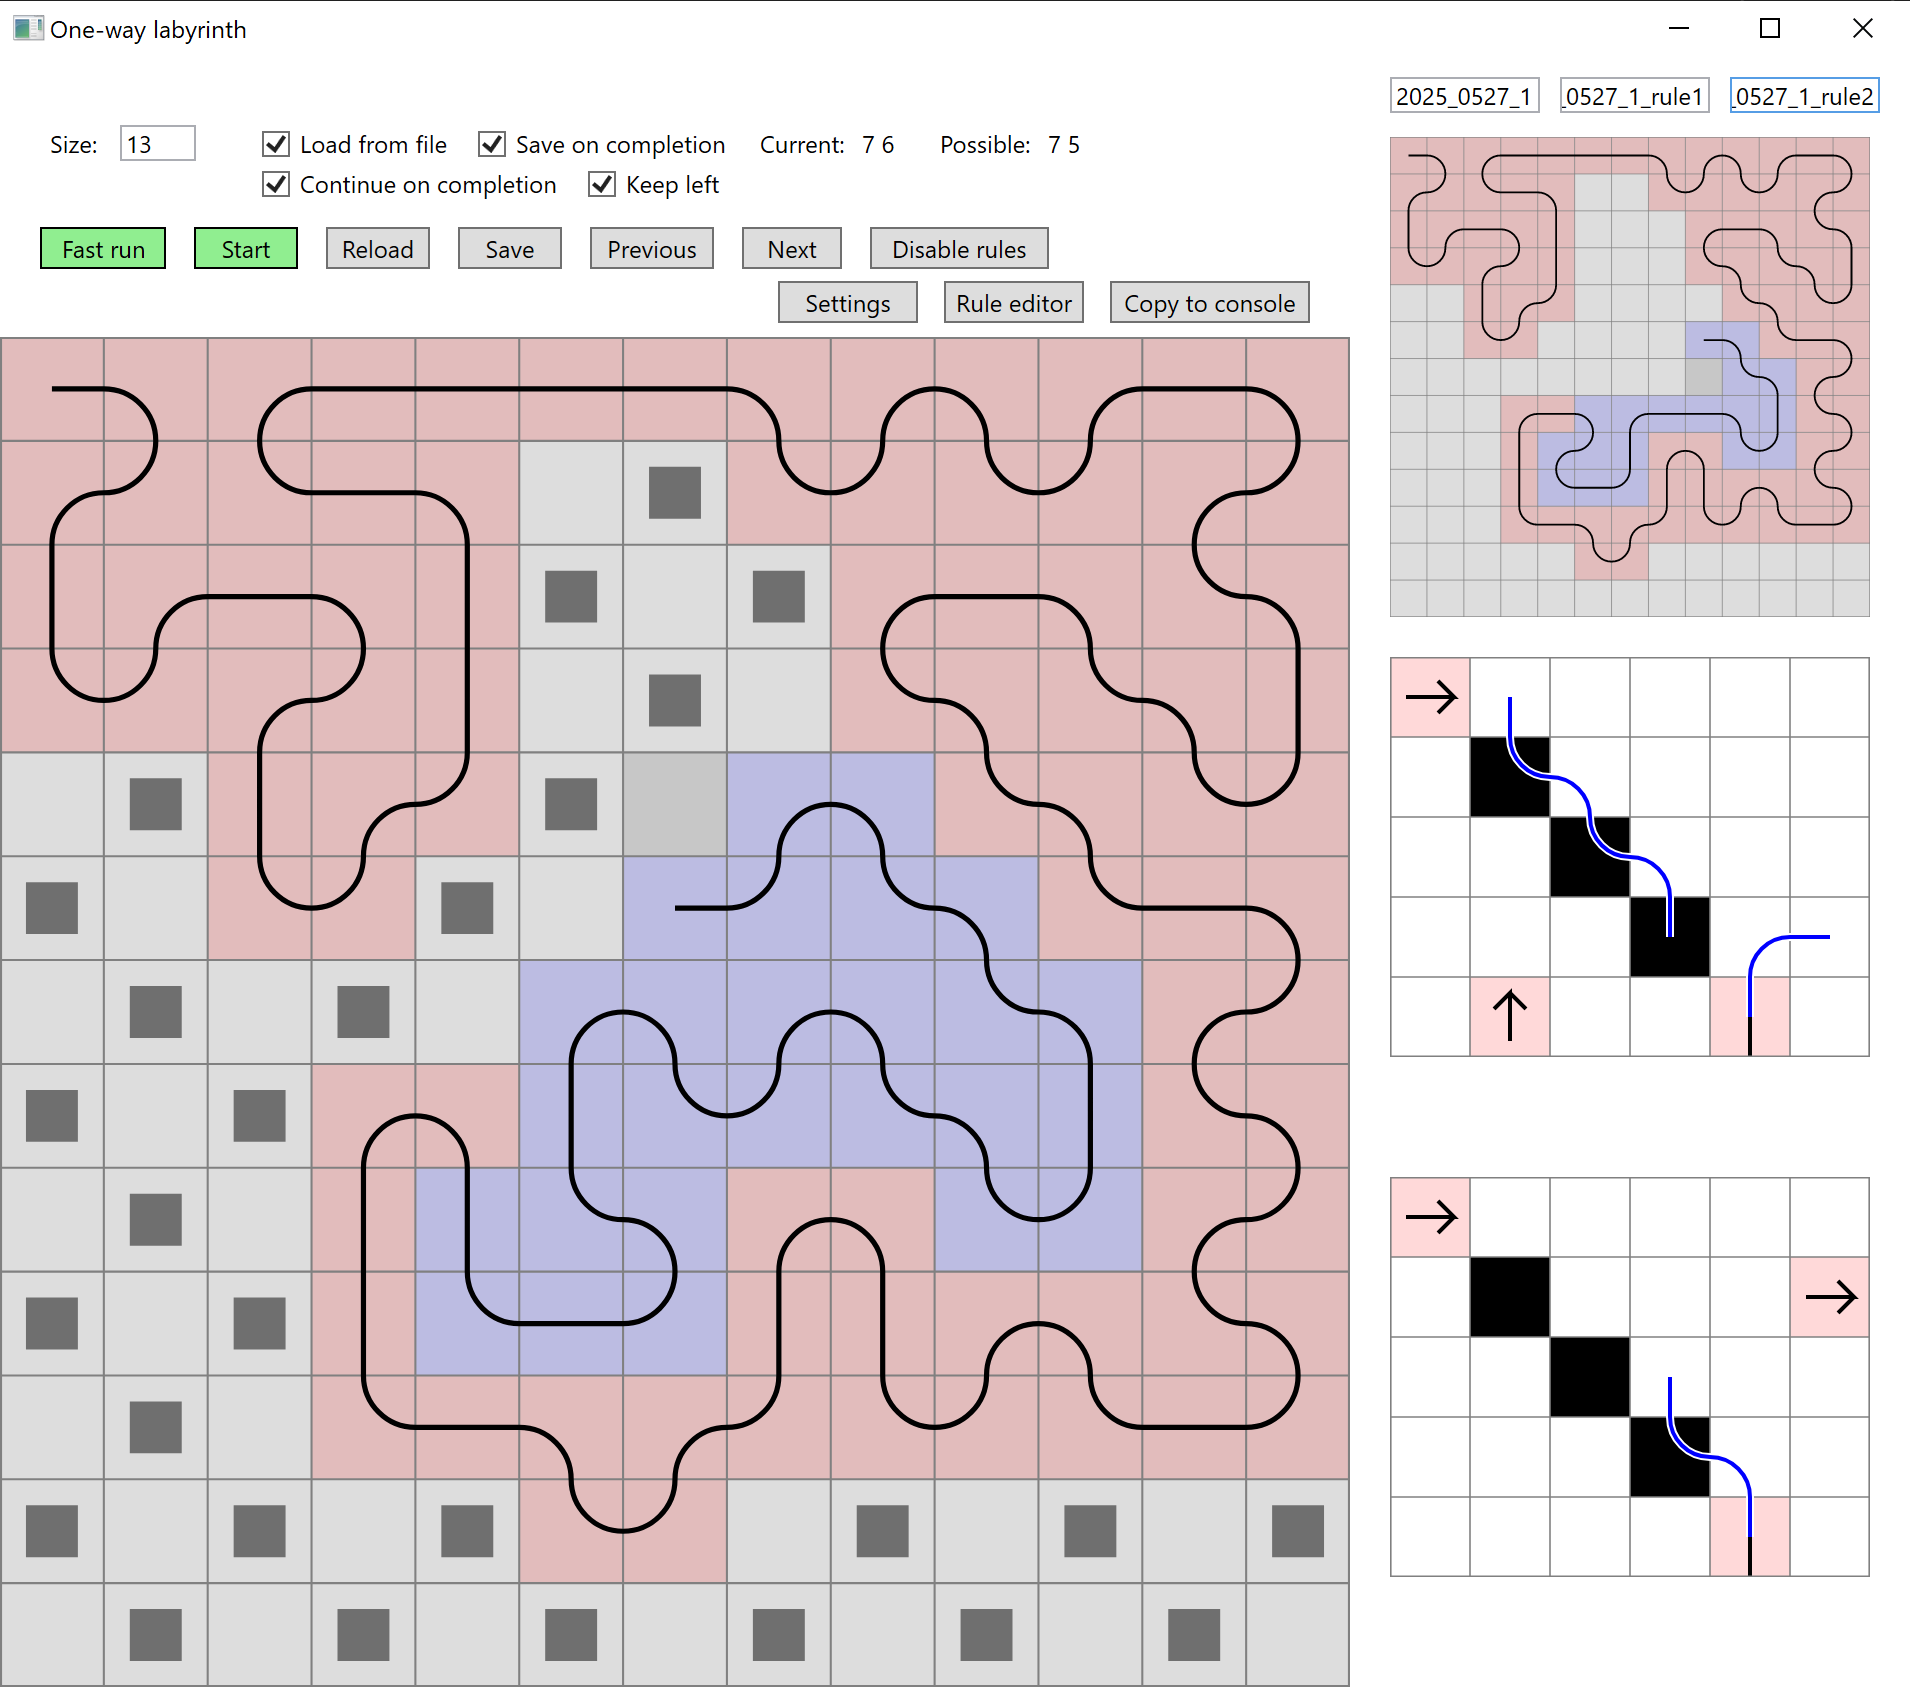

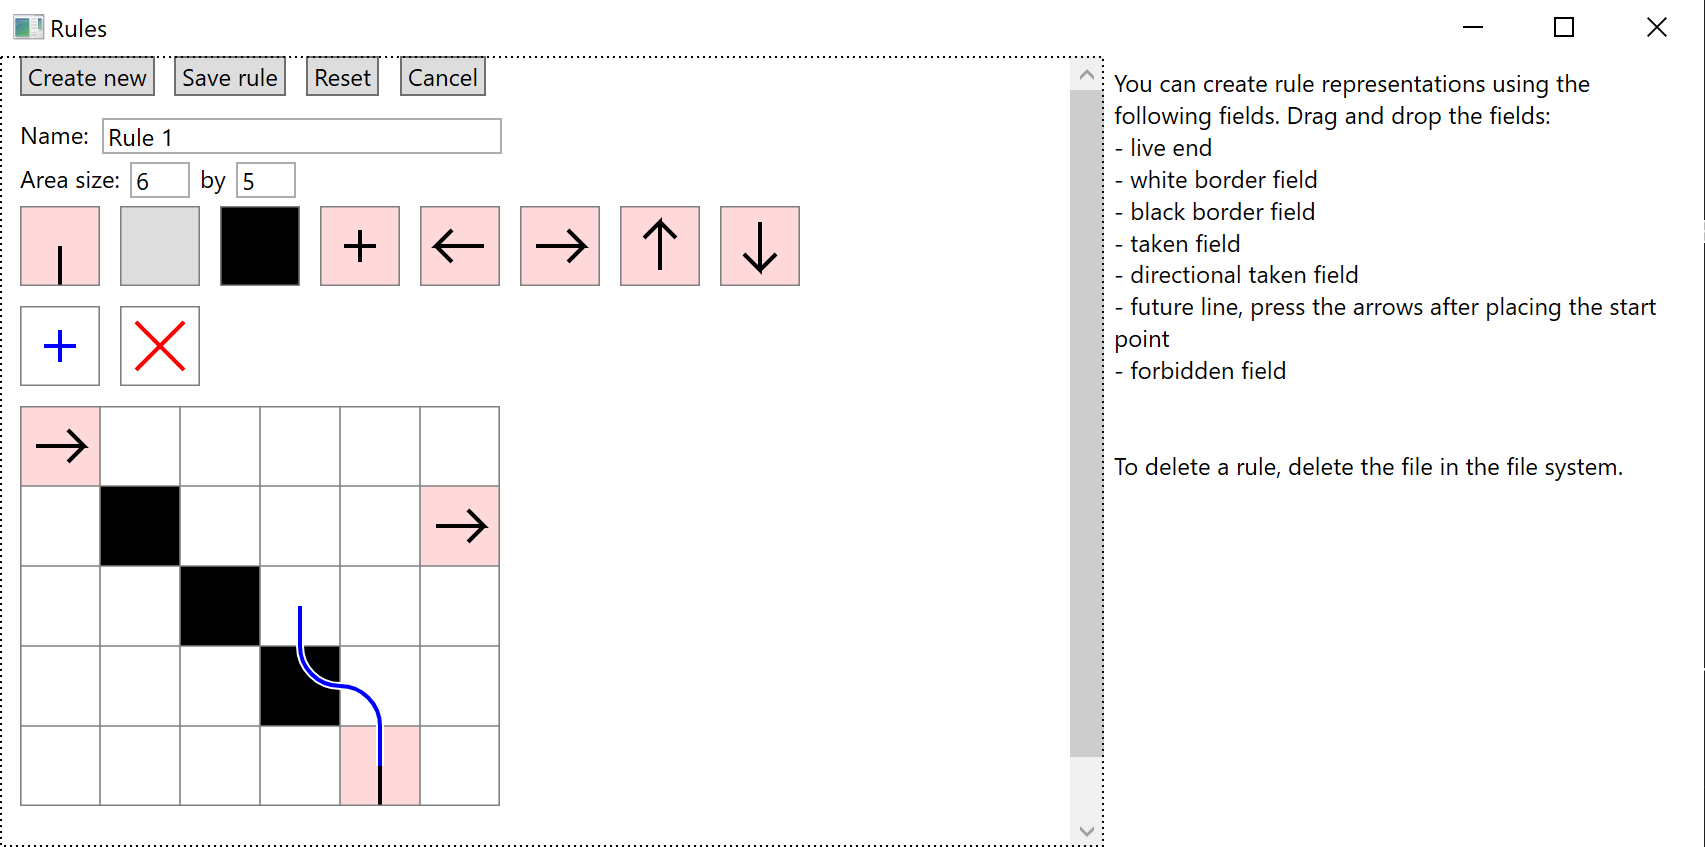
Hotkeys:
Enter: Reload or Close error message
Ctrl + S: Save path
Right arrow: Step forward
Left arrow: Step back
Ctrl/Shift + arrows: step in direction if possible. If CapsLock is on, pressing the Ctrl or Shift keys is not necessary.
Space: Run automatically / Stop automatic running
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | 56k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R2, R3, R4, R8 |
| 4 | MountingHole | MountingHole:MountingHole_3.2mm_M3 | H1, H2, H3, H4 |
| 2 | 100nF | Capacitor_THT:C_Rect_L7.0mm_W2.0mm_P5.00mm | C1, C2 |
| 2 | 10k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R1, R5 |
| 2 | Conn_01x03_Pin | Connector_JST:JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J2, J3 |
| 1 | 14.13k | Potentiometer_THT:Potentiometer_Bourns_3386W_Horizontal | RV1 |
| 1 | 15k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R6 |
| 1 | 2.7k | Potentiometer_THT:Potentiometer_Bourns_3386W_Horizontal | RV2 |
| 1 | 22-33 uF | Capacitor_THT:C_Rect_L7.0mm_W2.0mm_P5.00mm | C4 |
| 1 | 24 -> 5 V | Custom:Buck_converter | U2 |
| 1 | 2N7000 | Package_TO_SOT_THT:TO-92_HandSolder | Q1 |
| 1 | 470 | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R7 |
| 1 | Conn_01x02_Pin | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J4 |
| 1 | Conn_01x05_Pin | Connector_JST:JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | J1 |
| 1 | LM2917N-14 | Package_DIP:DIP-14_W7.62mm_LongPads | U1 |
| 1 | MCP6022 | Package_DIP:DIP-8_W7.62mm_LongPads | U3 |
| 1 | ~ | Capacitor_THT:C_Rect_L7.0mm_W2.0mm_P5.00mm | C3 |
fodorbalint/OneWayLabyrinth
Program aiming to solve the one-way labyrinth generation riddle.

fodorbalint/OneWayLabyrinth
Program aiming to solve the one-way labyrinth generation riddle.


rheslip/2HPico-Eurorack-Module-Hardware
2HP Eurorack module based on Raspberry Pi Pico 2

arcoslab/open-coroco-legacy
COmpliant RObot COntroller is a free software project aiming to create an impedance controller based on a stm32 microcontroller using bldc motors and strain gauges.

botanicfields/KiCad6-Environment
My symbols, my footprints, my templates, etc. of KiCad6

Th3Link/tanklevel
This project provides a solution for measuring the liquid level in tanks, such as rainwater tanks, using the TL-136 pressure sensor.

abhinav937/SiC-Based-Bi-Directional-Circuit-breaker
KiCad 7 PCB design files for E_Fuse


re3Dev/Extrusion-Metrology
PCB with a main purpose of a low-cost, dedicated 1D metrology sensor specifically for a Klipper printer, use controlled illumination to get a high-resolution bead cross-section without running full machine vision, and…
It measures 54 × 33 mm and has 2 copper layers, 1.6 mm thick.
26 parts, built around the MCP6022-I/P. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the fodorbalint/OneWayLabyrinth repository on GitHub, at the commit this page was made from: the board is Legacy/KiCad/speed limiter/speed limiter.kicad_pcb and its schematic Legacy/KiCad/capacity tester/capacity tester.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask fodorbalint before reusing the design.