
4 layers95 × 95 mm
Cube motherboard
willem-pennings/balancing-cube
A cube that balances itself in a corner or edge using reaction wheels
52 parts1.1kGPL-3.0
 Ber-dotcom/cartesianbot
Design of a cyberphysical cartesian robot with HIL.
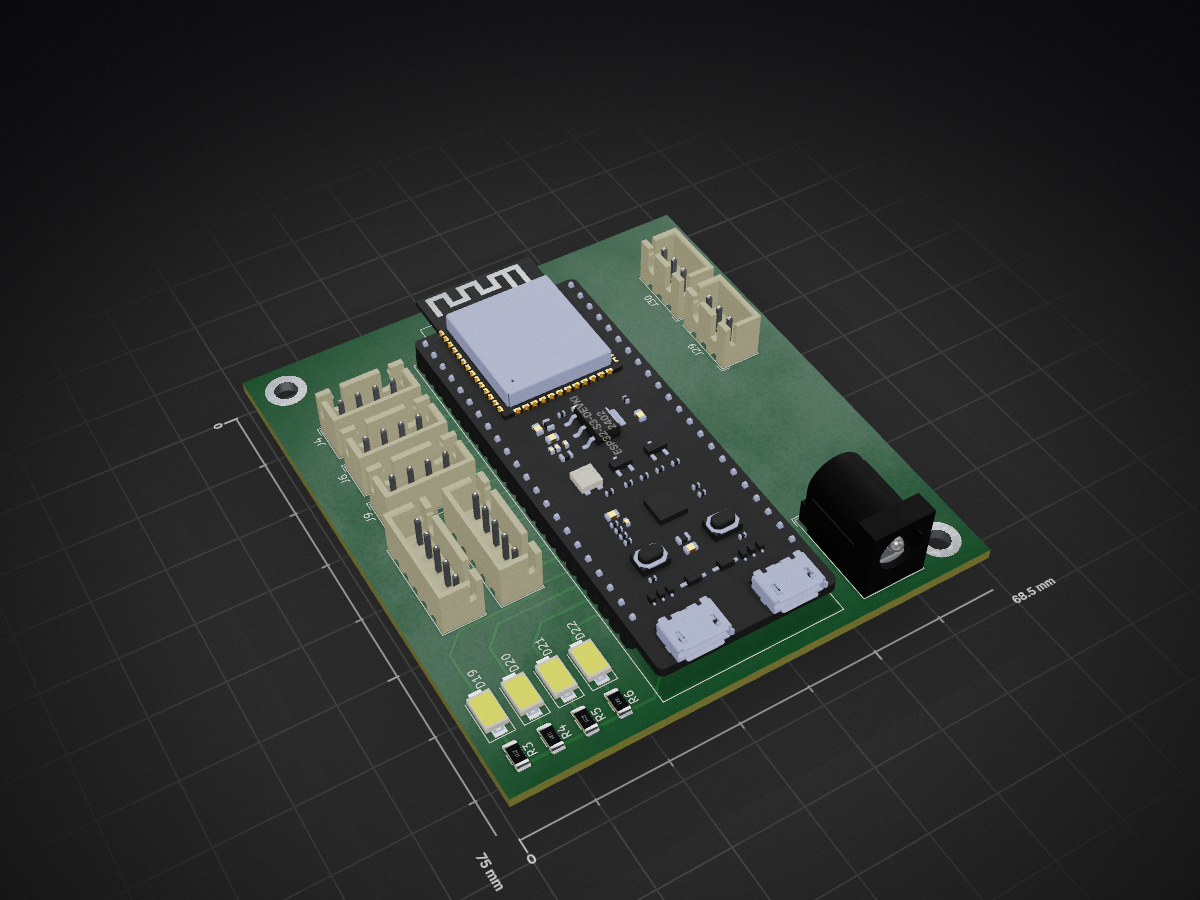
Electronic is an open-source printed circuit board by Ber-dotcom, from the Ber-dotcom/cartesianbot repository on GitHub, published under the GPL-3.0 licence. It is a 2-layer board of 68.5 × 75 mm with 19 parts on 48 nets, routed with 108 tracks and 0 vias.
It is built around the ESP32-S3-DEVKITC-1-N8. Its parts include 8 connectors, 4 resistors, 4 diodes and 1 IC. It belongs with the ESP32 boards of this library.
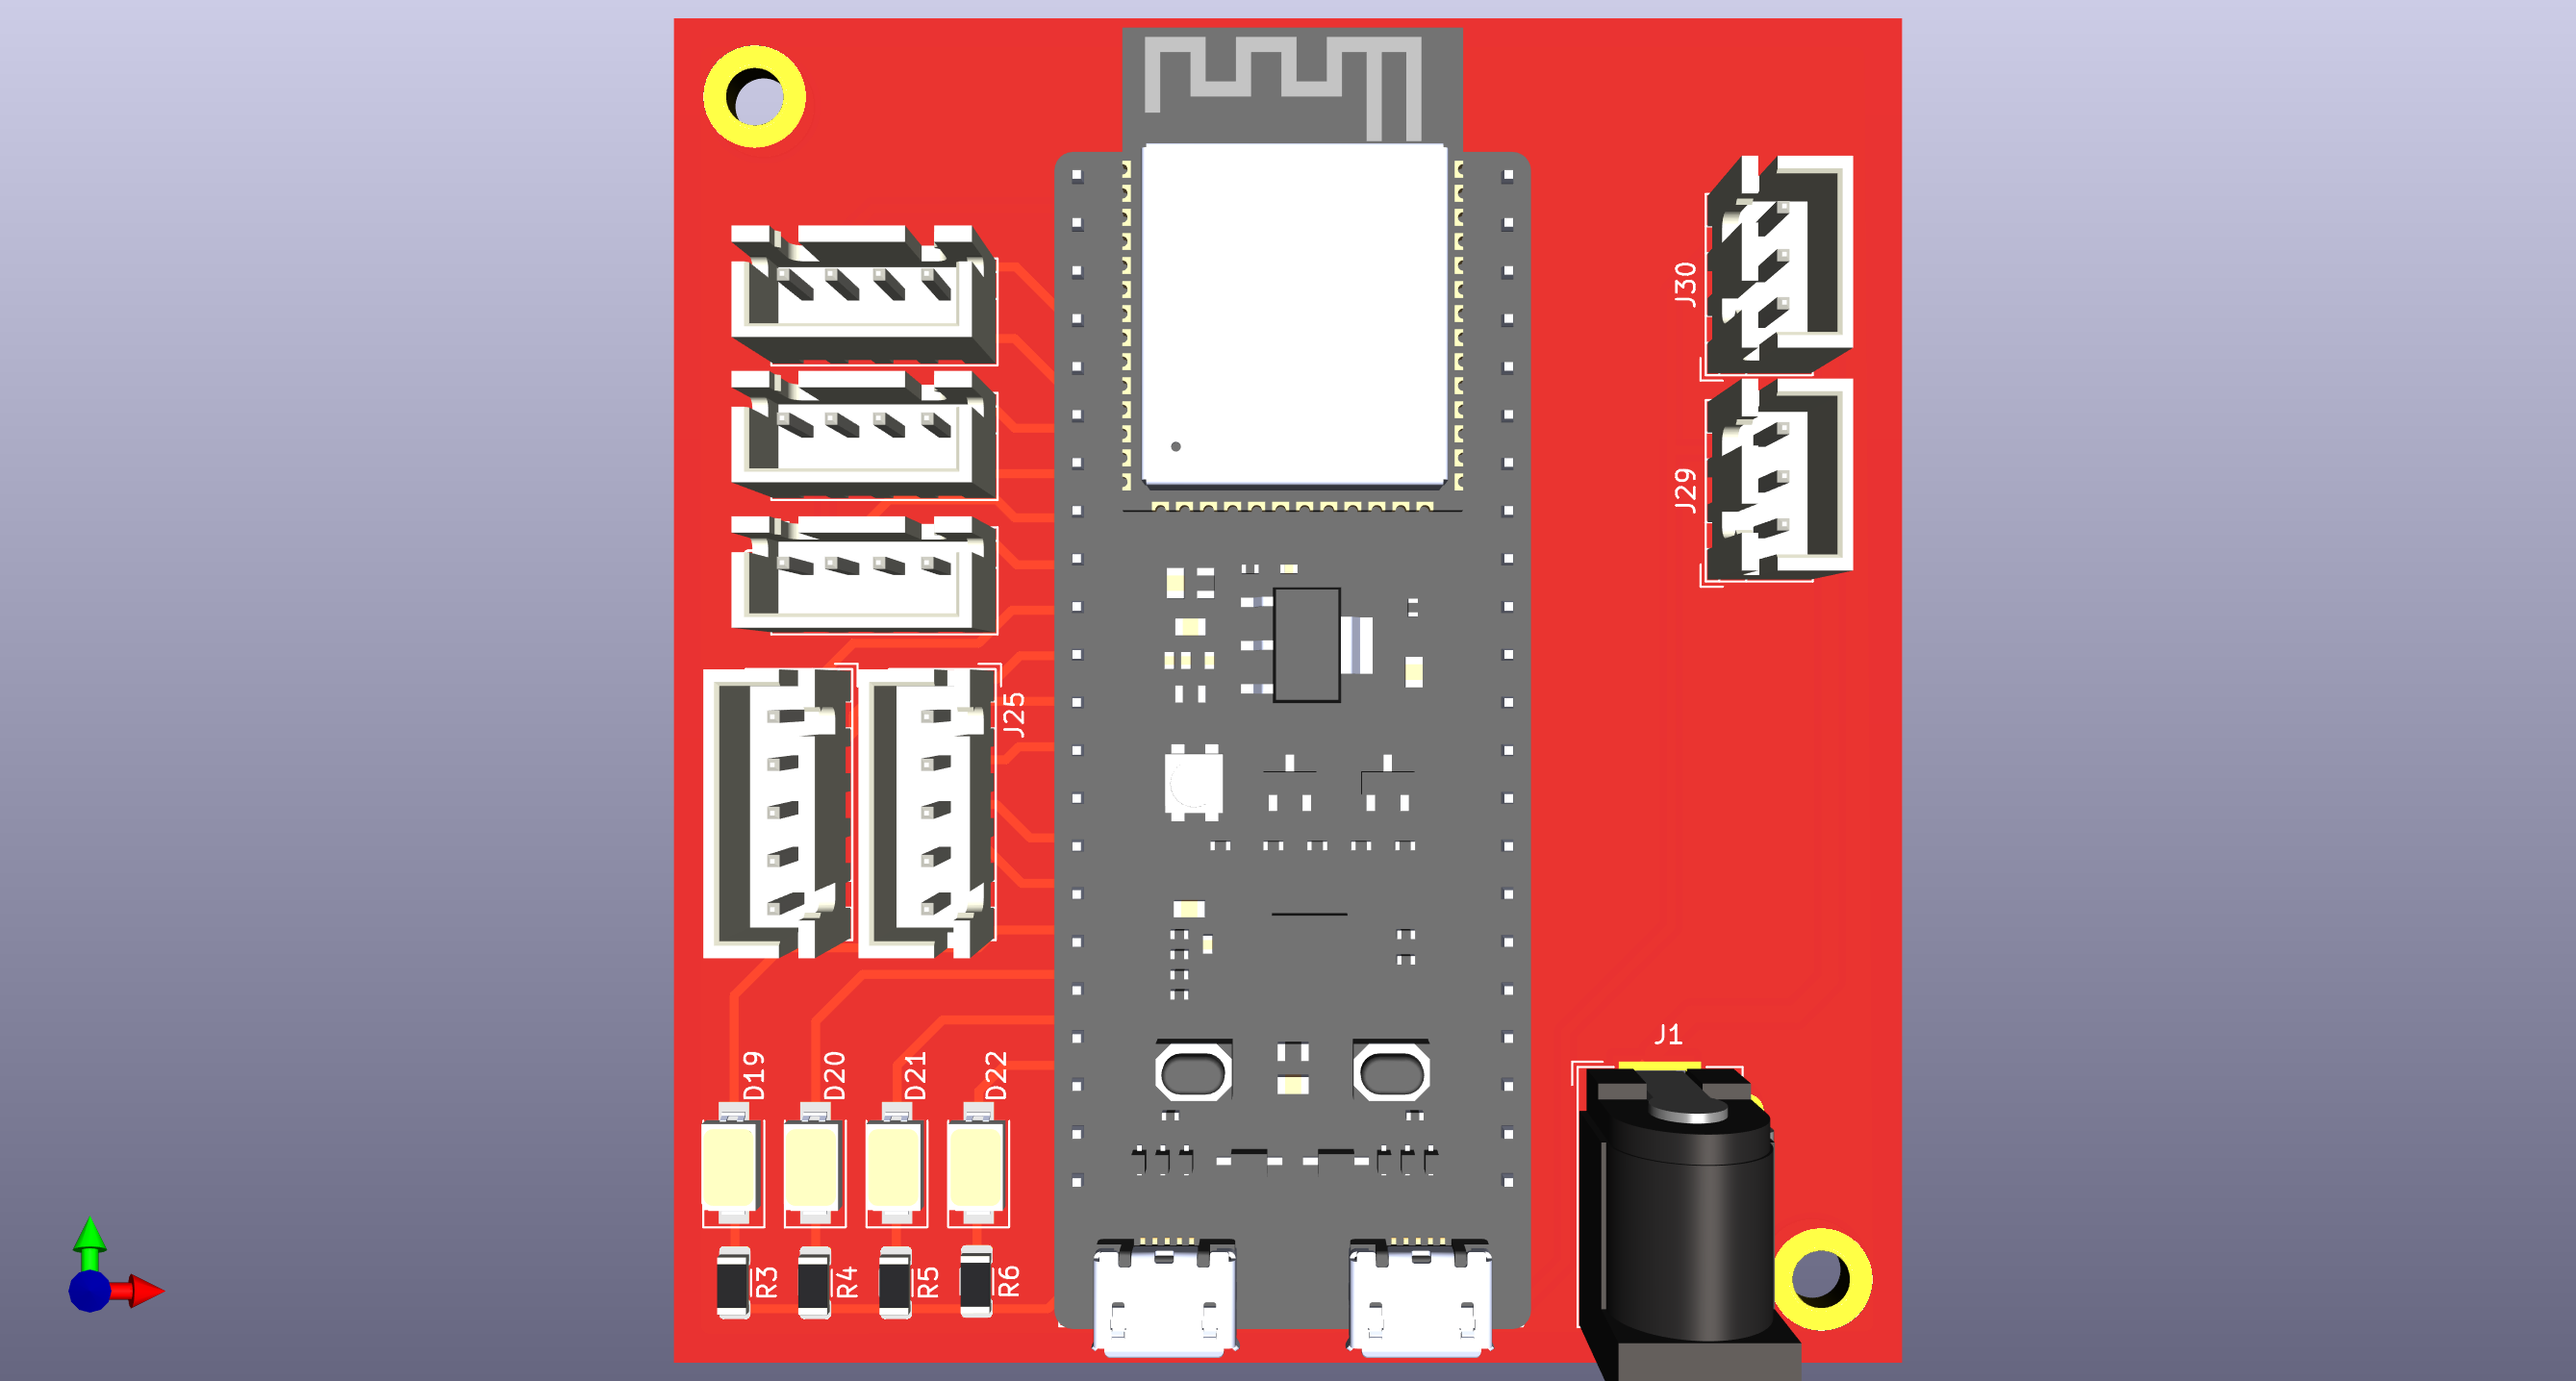
El proyecto se desarrolló usando KiCAD. (electronic.kicad_pro) se desarrollo para conectar una placa de ESP32 con 2 controladores de motores L298 y encoders de 3 motores JGA25-371. Los componentes utilizados en el proyecto son:
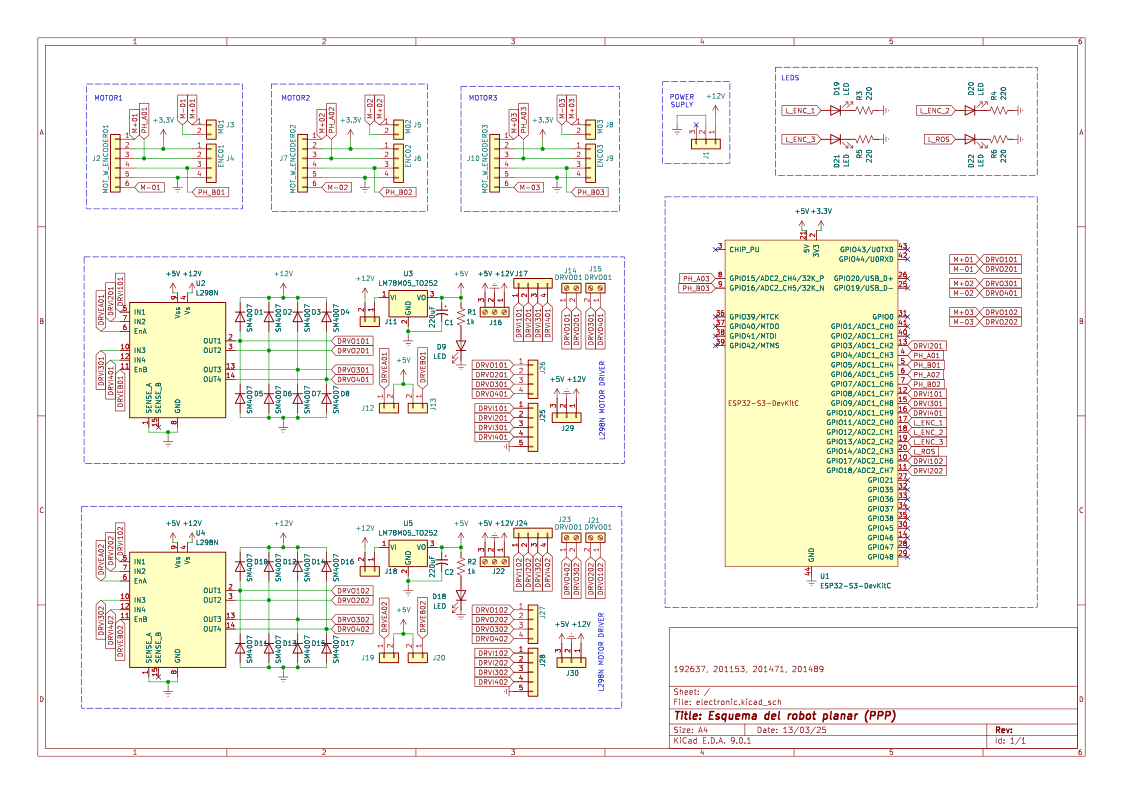
El esquema eléctrico se encuentra dividido en ocho partes:
En esta sección se encuentran los motores con encoder JGA25-371.
En esta sección se encuentran los módulos de controladores de motores L298N.
En esta sección se encuentra el microcontrolador ESP32 S3 y las etiquetas de los pines que se utilizan para la comunicación con el resto de los componentes.
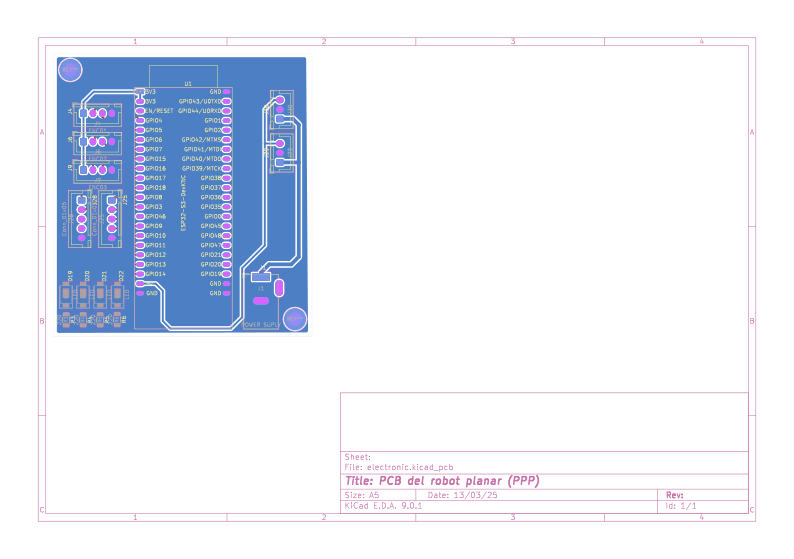
La PCB fue diseñada para conectar todos los componentes del circuito. La PCB tiene un tamaño de 68.5x75 mm y fue diseñada para ser fabricada en dos capas. El diseño se encuentra en la carpeta electronic (PCB.kicad_pcb). Para la PCB se usan los siguientes componentes:
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | 220 | Resistor_SMD:R_1206_3216Metric | R3, R4, R5, R6 |
| 4 | LED | LED_SMD:LED_Yuji_5730 | D19, D20, D21, D22 |
| 2 | Conn_01x05 | Connector_JST:JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | J25, J28 |
| 2 | Screw_Terminal_01x03 | Connector_JST:JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J29, J30 |
| 1 | ENC01 | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J4 |
| 1 | ENC02 | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J6 |
| 1 | ENC03 | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J9 |
| 1 | ESP32-S3-DevKitC | PCM_Espressif:ESP32-S3-DevKitC | U1 |
| 1 | POWER SUPLY | Connector_BarrelJack:BarrelJack_GCT_DCJ200-10-A_Horizontal | J1 |
The 17 most common of 19 parts.
It measures 68.5 × 75 mm and has 2 copper layers, 1.6 mm thick.
19 parts, built around the ESP32-S3-DEVKITC-1-N8. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Ber-dotcom/cartesianbot repository on GitHub, at the commit this page was made from: the board is electronic/electronic.kicad_pcb and its schematic electronic/electronic.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
willem-pennings/balancing-cube
A cube that balances itself in a corner or edge using reaction wheels

jazzmonger/Traeger-PID-Controller
Traeger Smoker/Grill Controller based on an

ohasanov-hbrw/tribit32-advanced
A tri-microcontroller, overengineered GameBoy Advance clone. More value was given to the controls and the exterior look, which is cool!


FIPATECH/CDFR26_PAMI
Open source firmware and PCB for a differential mobile robot (PAMI) based on ESP32-S3 - Coupe de France de Robotique

dnhutchins/ETC_Express_Reverse_Eng
The ultimate goal of this work is to develop an interface to use the control surface from a legacy ETC Express 24/48 lighting controller as a modern EOSNomad compatible programming and fader wing.

heckler/esphome-device-configs
Configuration definitions for local ESPHome files