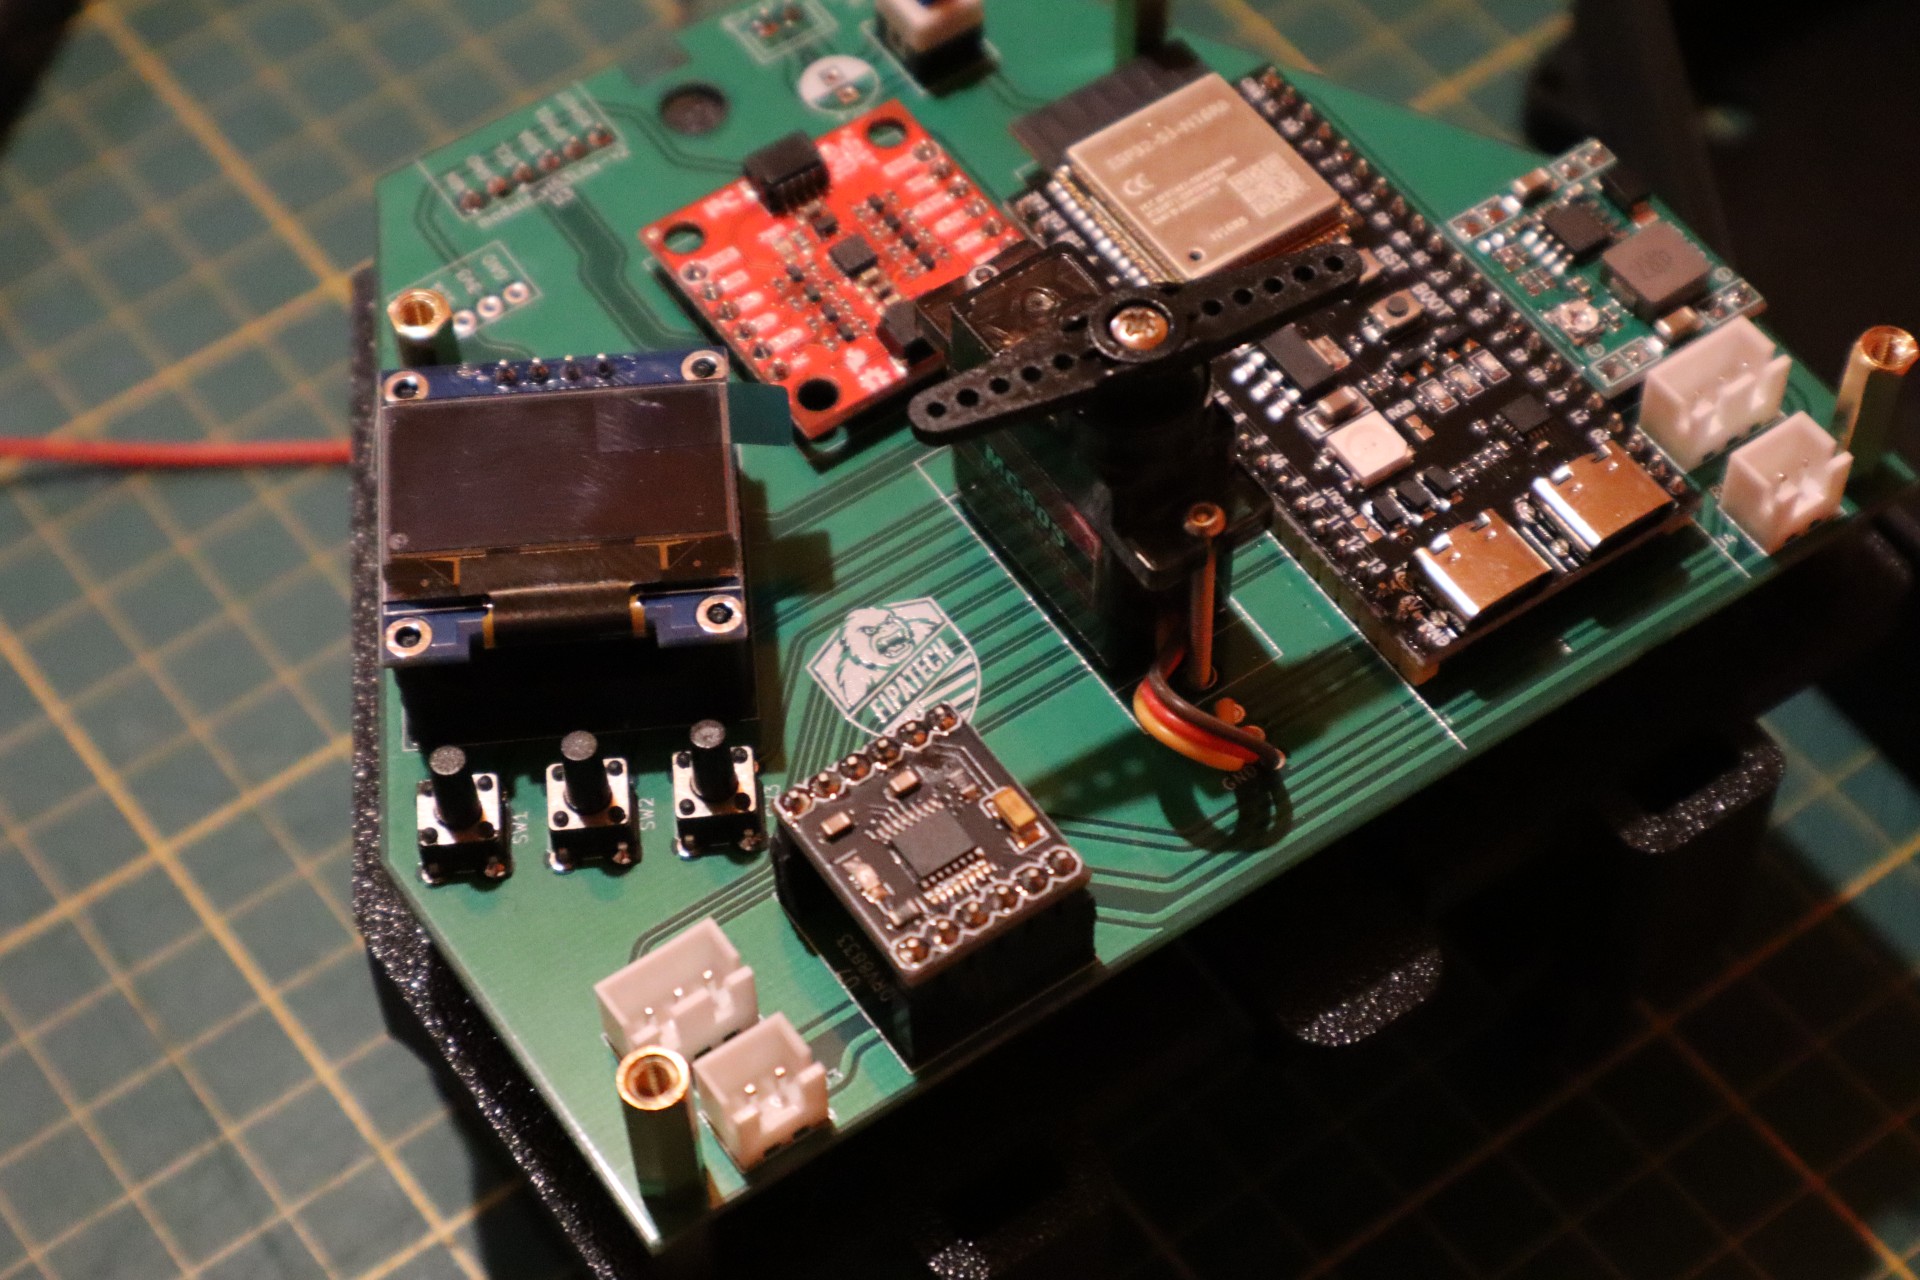
PCB Pami is an open-source printed circuit board by FIPATECH, from the FIPATECH/CDFR26_PAMI repository on GitHub. It is a 2-layer board of 119.4 × 98.9 mm with 25 parts on 59 nets, routed with 214 tracks and 0 vias.
It is built around the ESP32-S3-DEVKITC-1-N8, DRV8833PW and MP1584EN, with the SG90 among its other parts. Its parts include 7 ICs, 5 connectors, 4 resistors, 4 switches and 2 capacitors. It belongs with the robots and motor control boards and the ESP32 boards of this library.
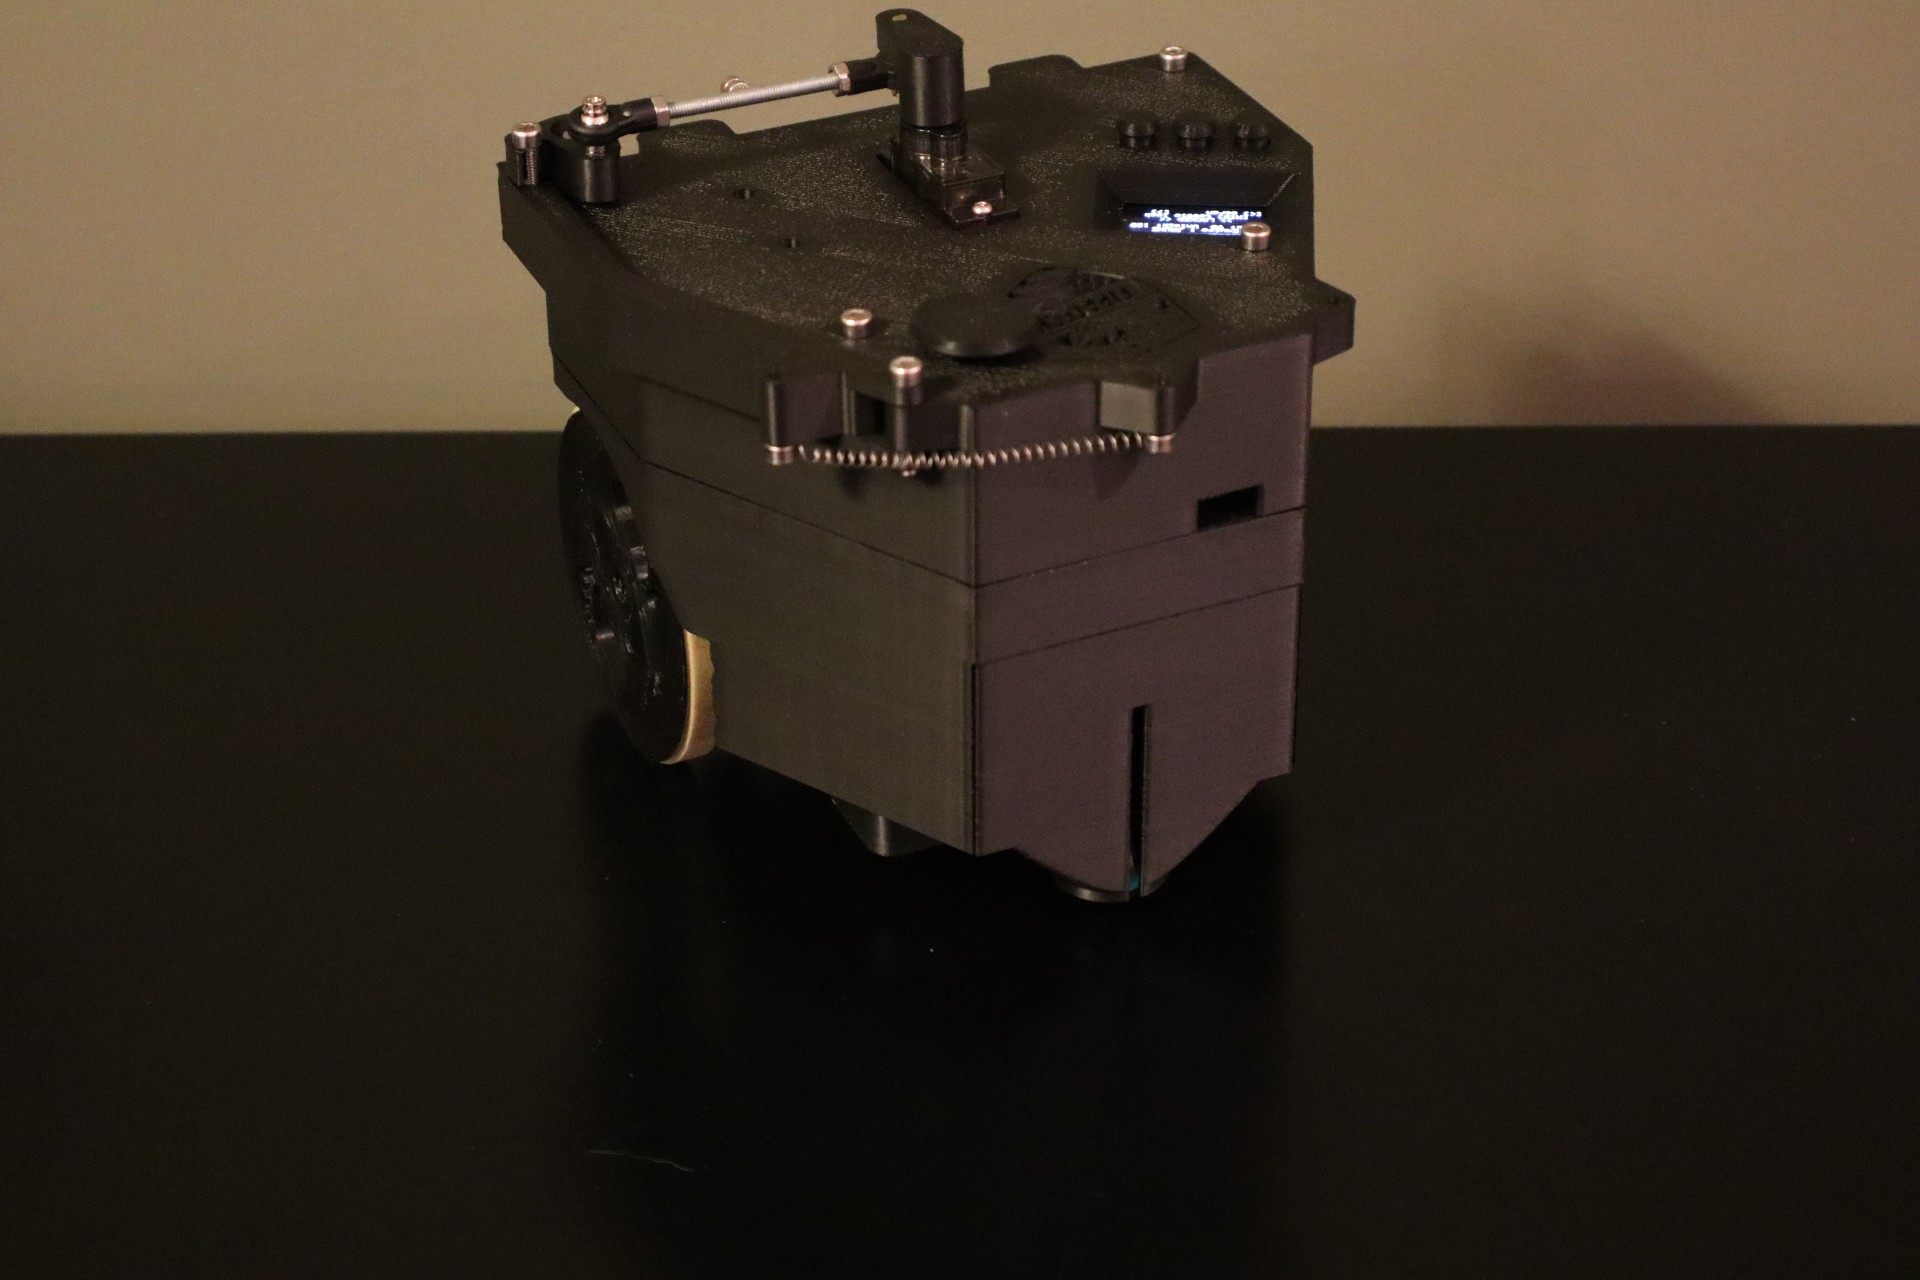
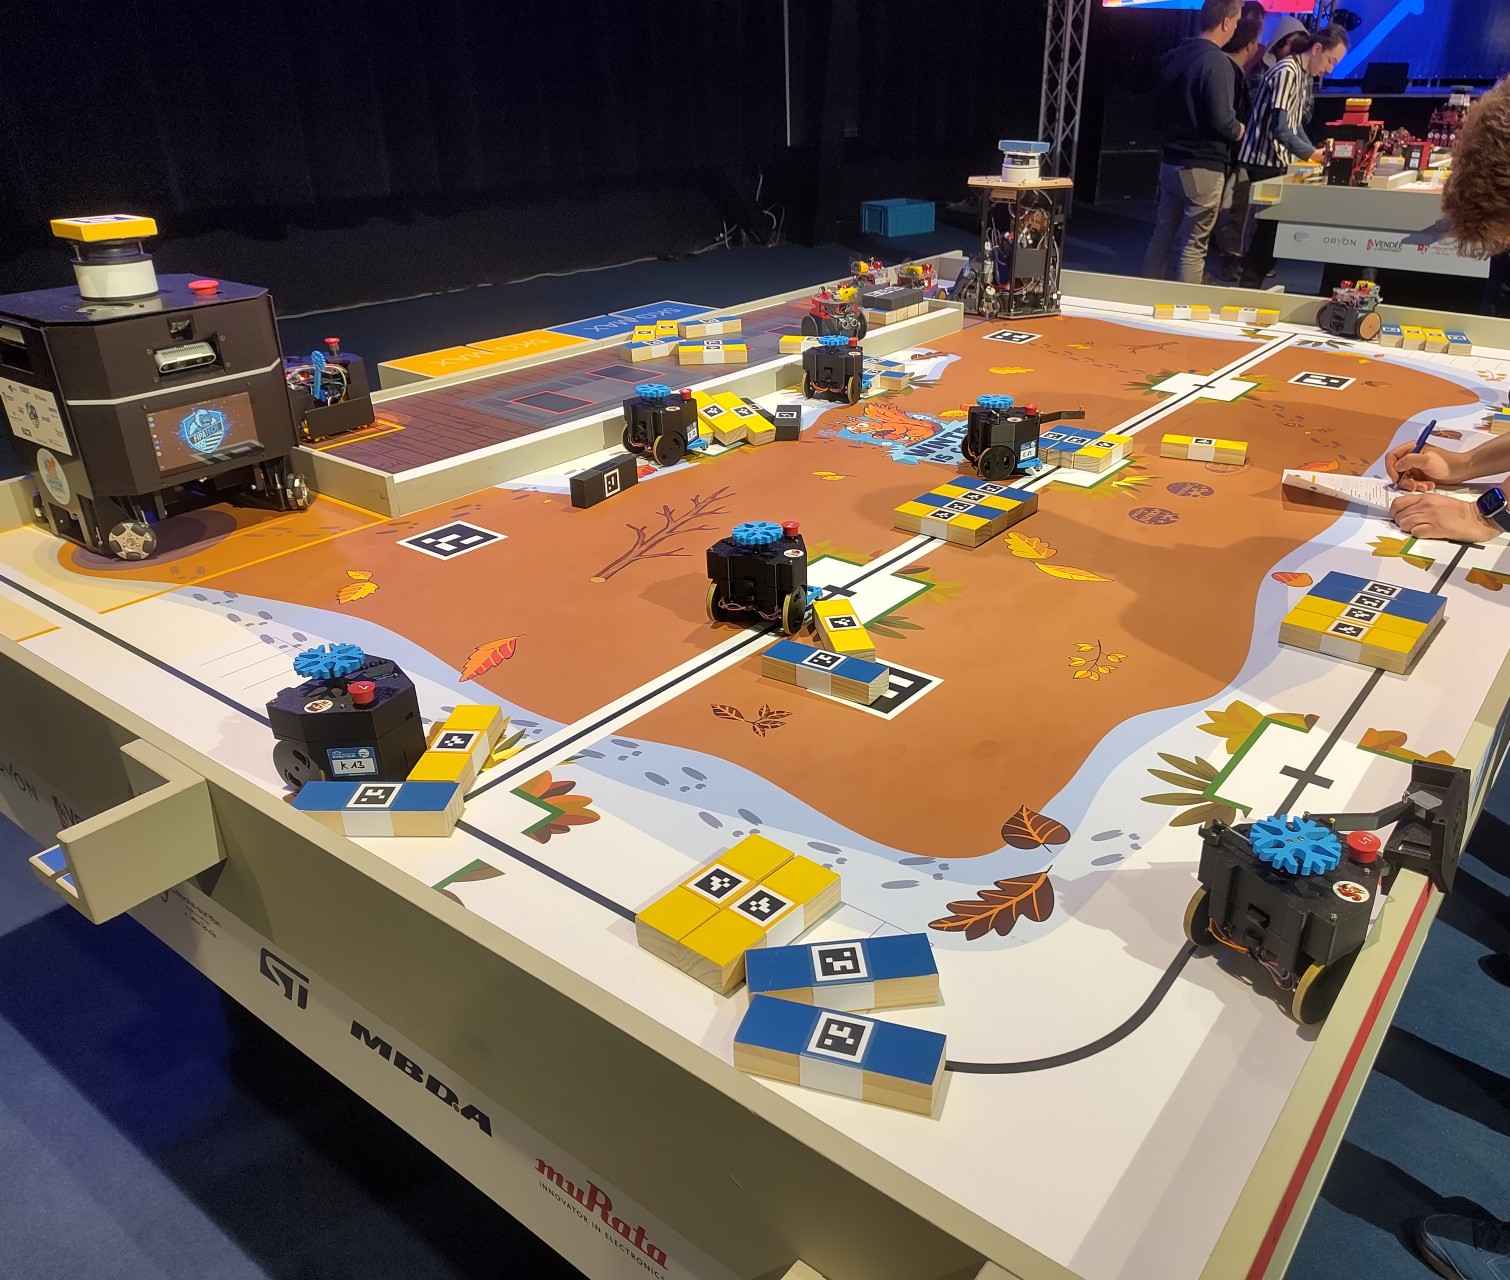
Firmware et PCB open source pour robot mobile différentiel basé sur ESP32-S3. Conçu pour la Coupe de France de Robotique (PAMI — Petit actionneur mobile independant).
Aperçu
Firmware : ESP-IDF, FreeRTOS, contrôle différentiel, odométrie, navigation par waypoints
Interface : API REST + WebSocket, GUI Python, éditeur de waypoints visuel
Le dossier hardware/PCB_Pami_V2/ est auto-suffisant : toutes les empreintes et symboles non-standard sont inclus. Ouvrir directement PCB_Pami.kicad_pro dans KiCad 9.
Hardware
Composants principaux
Composant
Rôle
ESP32-S3-DevKitC
Microcontrôleur principal (dual-core, WiFi)
DRV8833
Driver moteurs DC (2 canaux)
ICM-20948
IMU 9 axes (gyro + accéléro + magnéto)
VL53L0X
Capteur distance ToF (détection obstacles)
TCS34725
Capteur couleur (détection ligne/zone)
SSD1306
Afficheur OLED 128x64
MP1584EN
Convertisseur DC-DC 5V → 3.3V
SG90
Servomoteur (mécanisme de jeu)
Broches ESP32-S3
Signal
GPIO
MOTOR_LEFT_IN1
2
MOTOR_LEFT_IN2
1
MOTOR_RIGHT_IN3
9
MOTOR_RIGHT_IN4
8
ENCODER_LEFT_A/B
11/10
ENCODER_RIGHT_A/B
13/12
I2C SDA/SCL
7/6
API REST
Base URL : http://192.168.4.1/api/v1
Endpoint
Méthode
Description
/cmd_vel
POST
Commande vitesse {v, w, timeout_ms}
/motion/stop
POST
Arrêt immédiat
/pose
GET
Pose courante {x, y, theta}
/pose/reset
POST
Réinitialise la pose
/imu/calibrate
POST
Calibration gyroscope
/ota/update
POST
Mise à jour firmware OTA
/ws/telemetry
WS
Télémétrie temps réel (stub, non implémenté)
/ws/logs
WS
Logs temps réel (stub, non implémenté)
Dev Container
Un environnement de développement Docker est disponible dans .devcontainer/ avec ESP-IDF pré-installé. Compatible VS Code (extension Dev Containers).
Licence
Ce projet est distribué sous licence GNU GPL v3 — les modifications et améliorations doivent rester open source.
Voir LICENSE pour les détails.
It measures 119.4 × 98.9 mm and has 2 copper layers, 1.6 mm thick.
What parts does the PCB Pami use?
25 parts, built around the ESP32-S3-DEVKITC-1-N8, DRV8833PW, MP1584EN and SG90. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
Where can I download the PCB Pami KiCad files?
From the FIPATECH/CDFR26_PAMI repository on GitHub, at the commit this page was made from: the board is hardware/PCB_Pami_V2/PCB_Pami.kicad_pcb and its schematic hardware/PCB_Pami_V2/PCB_Pami.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Can I use the PCB Pami design in my own project?
Its repository states no licence, so its author keeps all rights: ask FIPATECH before reusing the design.
Robůtek je robotická platforma založená na čipu ESP32-S3. Je velice rozšitiřelný, ale ze základu umí jezdit, kreslit fixou, jezdit po čáře, pohybovat se bludištěm. Programování je přes Jaculus.
Designed two custom PCBs (remote and car) for a wirelessly-controlled RC car. Implemented wireless communication between two STM32 microcontrollers using embedded firmware.
“Robotic Arm” es un brazo robotico el cual cuenta con un modelo dummy de menores dimensiones. Este modelo copia tendrá una conexión entre sus potenciómetros y los servomotores ubicados en el modelo principal.