2 layers113 × 113 mm
LIS3DH array
Aightech/e-skin
A bioinspired electronic skin system for robotic applications, combining FSR (force-sensing resistor) arrays and accelerometer arrays.
146 parts2GPL-3.0
 Aightech/e-skin2
A bioinspired electronic skin system for robotic applications, combining FSR (force-sensing resistor) arrays and accelerometer arrays.
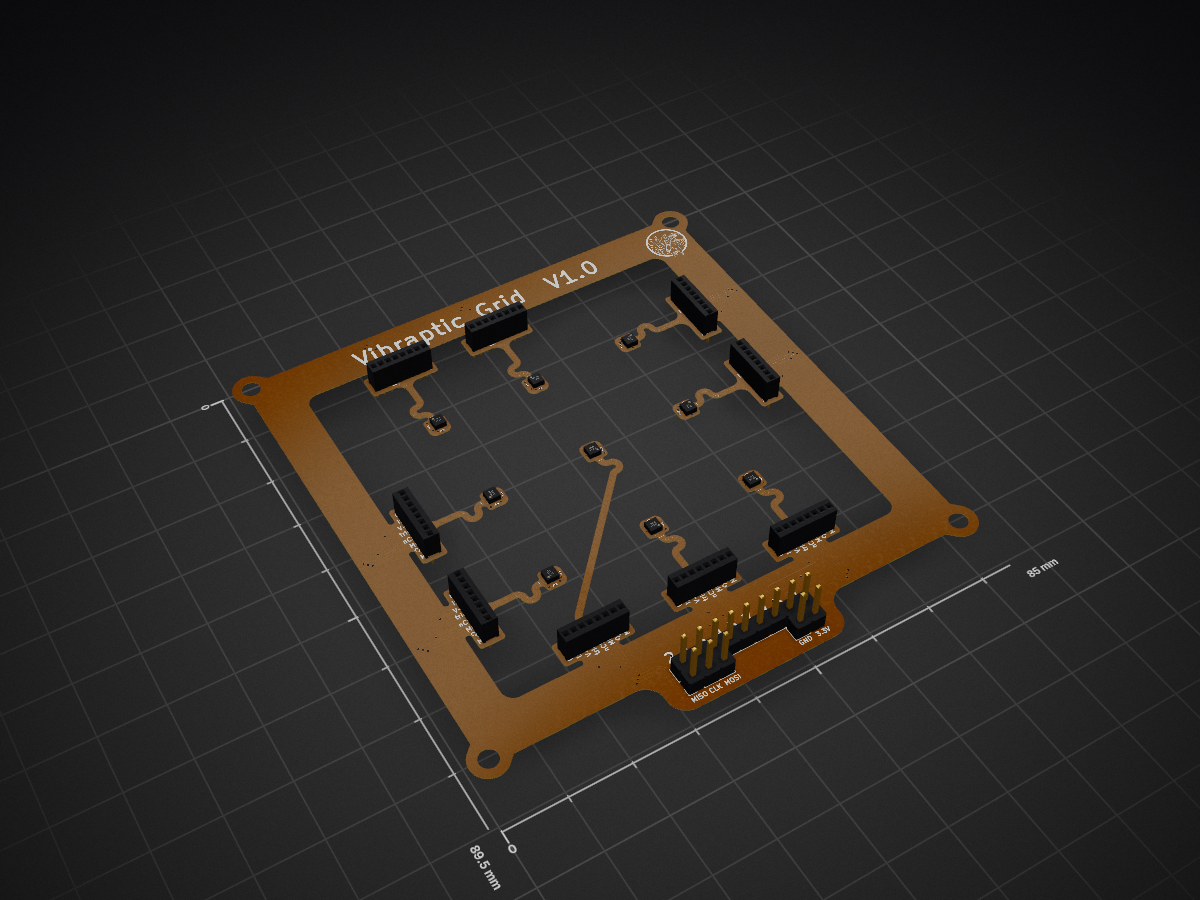
KX134 array is an open-source printed circuit board by Aightech, from the Aightech/e-skin repository on GitHub, published under the GPL-3.0 licence. It is a 2-layer board of 83.2 × 88.6 mm with 40 parts on 41 nets, routed with 1,047 tracks and 97 vias.
Its parts include 18 capacitors, 12 connectors and 9 ICs.
A bioinspired electronic skin system for robotic applications, combining FSR (force-sensing resistor) arrays and accelerometer arrays.
The electronic board uses two multiplexers and two 16-channel ADCs to read the FSRs. The multiplexers select the row or column of the FSR array, while the ADCs read the sensor values. A Teensy 4.1 controls the multiplexers and ADCs and sends data to the computer via USB or Ethernet.
Operation modes:
Sampling rate: ~400 KHz/channel (1562.5 Hz for a 16x16 array)
e-skin/
├── host/           # C++/Qt host application
│   ├── src/        # Source code (main.cpp)
│   └── lib/        # Git submodules (com_client, built_lsl)
├── src/            # Teensy firmware
│   └── Eskin/      # Main production firmware
├── models/         # KiCAD PCB designs
│   ├── KiCAD/              # Main control board (MUX + ADC)
│   ├── customSquare16x16/  # 16x16 FSR array
│   ├── customSquare8x8/    # 8x8 FSR array
│   ├── LIS2DH_array/       # LIS2DH accelerometer array
│   ├── KX134_array/        # KX134 accelerometer array
│   └── inskinacc/          # In-skin accelerometer
└── script/ # Python/MATLAB data acquisition scriptspip install -r script/requirements.txtcd host
mkdir build && cd build
cmake .. && make
./FSR_array -h # Show usageUpload src/Eskin/Eskin.ino to Teensy 4.1 using Arduino IDE or PlatformIO.
/dev/ttyACM0 (Linux) or COMx (Windows)pip install -r script/requirements.txt
python script/record.py <port> <array_size>
# Example: python script/record.py /dev/ttyACM0 16Initialize submodules:
git submodule update --init --recursiveSee main.cpp for an example of how to use the communication library.
See CONTRIBUTING.md for details on our code of conduct and the process for submitting pull requests.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 9 | 100n | Capacitor_SMD:C_01005_0402Metric | C1, C3, C5, C7, C9, C11, C13, C15, C17 |
| 9 | 1u | Capacitor_SMD:C_01005_0402Metric | C2, C4, C6, C8, C10, C12, C14, C16, C18 |
| 9 | Conn_01x08_Socket | Connector_PinSocket_1.27mm:PinSocket_1x08_P1.27mm_Vertical | J1, J2, J3, J4, J5, J6, J7, J8, J9 |
| 9 | kx134 | 00_custom-footprints:KX134-1211 | U1, U2, U3, U4, U5, U6, U7, U8, U9 |
| 1 | Conn_01x02_Socket | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J12 |
| 1 | Conn_01x03_Socket | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J11 |
| 1 | Conn_01x09_Socket | Connector_PinHeader_2.54mm:PinHeader_1x09_P2.54mm_Vertical | J10 |
| 1 | LOGO | LOGO | G*** |
It measures 83.2 × 88.6 mm and has 2 copper layers, 0.08 mm thick.
40 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Aightech/e-skin repository on GitHub, at the commit this page was made from: the board is models/KX134_array/KX134_array.kicad_pcb and its schematic models/FSRray/FSRray.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
Aightech/e-skin
A bioinspired electronic skin system for robotic applications, combining FSR (force-sensing resistor) arrays and accelerometer arrays.

Aightech/e-skin
A bioinspired electronic skin system for robotic applications, combining FSR (force-sensing resistor) arrays and accelerometer arrays.

Aightech/e-skin
A bioinspired electronic skin system for robotic applications, combining FSR (force-sensing resistor) arrays and accelerometer arrays.

Aightech/e-skin
A bioinspired electronic skin system for robotic applications, combining FSR (force-sensing resistor) arrays and accelerometer arrays.

Aightech/e-skin
A bioinspired electronic skin system for robotic applications, combining FSR (force-sensing resistor) arrays and accelerometer arrays.

Aightech/e-skin
A bioinspired electronic skin system for robotic applications, combining FSR (force-sensing resistor) arrays and accelerometer arrays.

Aightech/e-skin
A bioinspired electronic skin system for robotic applications, combining FSR (force-sensing resistor) arrays and accelerometer arrays.

Aightech/e-skin
A bioinspired electronic skin system for robotic applications, combining FSR (force-sensing resistor) arrays and accelerometer arrays.

Aightech/e-skin
A bioinspired electronic skin system for robotic applications, combining FSR (force-sensing resistor) arrays and accelerometer arrays.

Aightech/e-skin
A bioinspired electronic skin system for robotic applications, combining FSR (force-sensing resistor) arrays and accelerometer arrays.

Aightech/e-skin
A bioinspired electronic skin system for robotic applications, combining FSR (force-sensing resistor) arrays and accelerometer arrays.


hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!

Chrismettal/EleLab_v2
Cheap DIY lab system for hobbyists and the tinkering folk

Chrismettal/flipper-zero-backpacks
Backpack-style addon boards for the Flipper Zero!


ohmtech-rdi/eurorack-blocks
Software to Hardware Prototyping for Eurorack using C++, Max/Gen~ or Faust
