Skip to the content
4 layers70 × 45 mmHand main, the printed circuit board in 3D

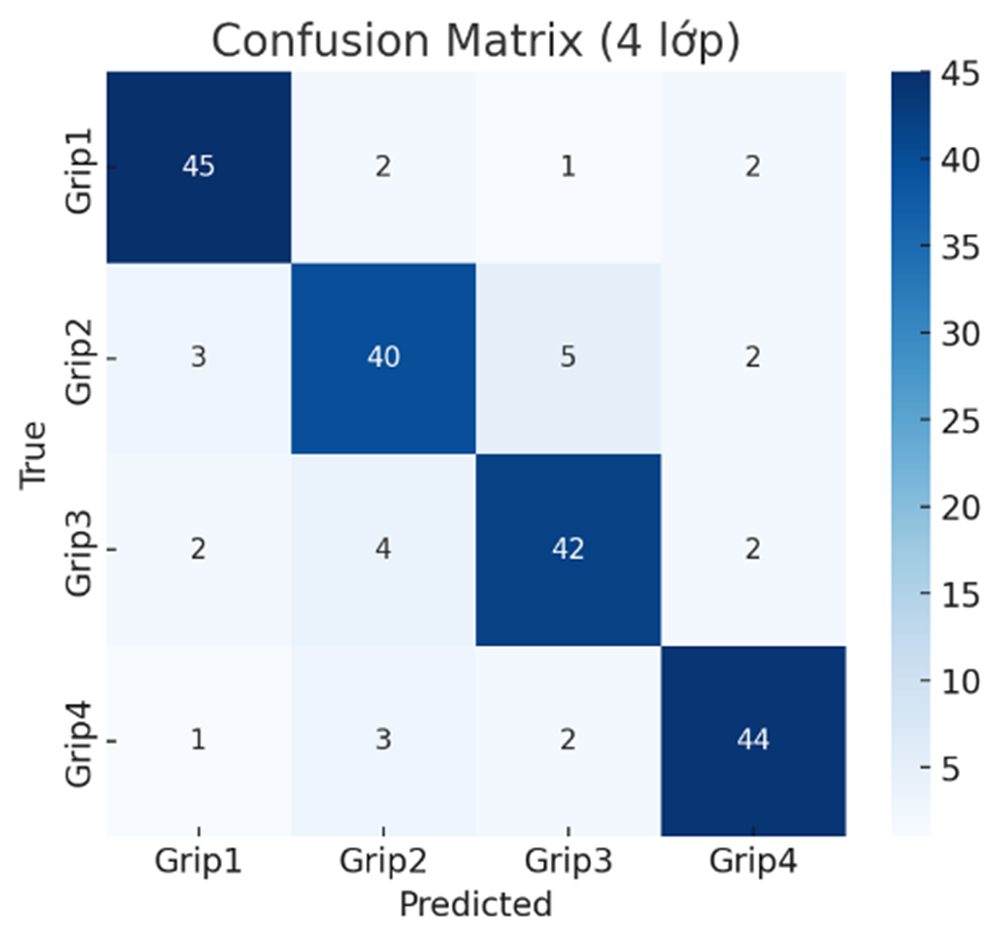
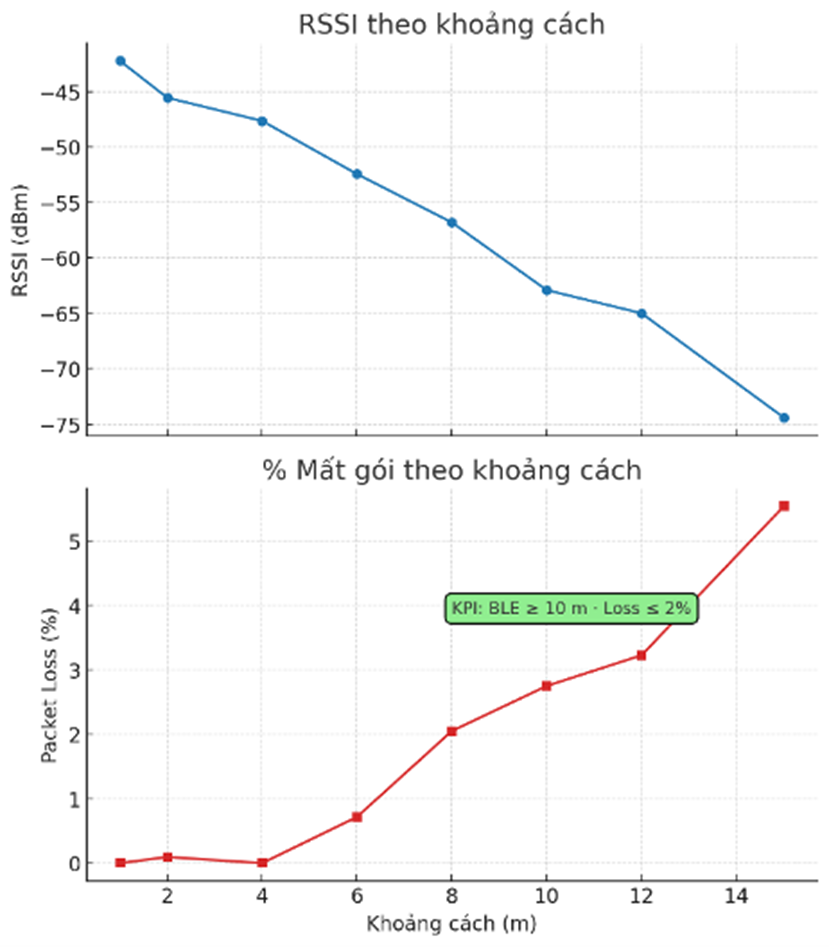
Full-stack 6-ch dry-electrode sEMG wearable (ESP32/BLE, 1 kHz/ch, JSON presets) with DC removal + HPF/LPF + Kalman DSP and dual-path gesture control (Amplitude thresholds + 6-ch Radar-shape matching) + Flutter app; SNR>=8 dB, latency<=80-100 ms, >=85% online (4 grips)

Size
70 × 45 mm
Copper layers
4
Thickness
1.6 mm
Parts
105
Nets
113
Pads
391
Tracks, vias
530, 143
Pours
2
Routed
Yes
KiCad
KiCad 9.0 (file 20241229)
Created
3 Dec 2025
Updated
20 Dec 2025

Overview

Hand main is an open-source printed circuit board by SonDinh23, from the SonDinh23/EMGBand-HandBionic repository on GitHub, published under the GPL-3.0 licence. It is a 4-layer board of 70 × 45 mm with 105 parts on 113 nets, routed with 530 tracks and 143 vias.

It is built around the ESP32-WROOM-32D-N4, TPS54620RGYR and XC6220B331MR, with the SS8050, WS2812B-2020-V6 and SPM10040T-3R3M-HZ among its other parts. Its parts include 44 resistors, 38 capacitors, 12 ICs, 5 diodes and 2 transistors. It belongs with the radio and wireless and robots and motor control boards and the ESP32 boards of this library.

Main components

6

README

README.md

✋ EMGBand - Hand Bionic
EMGBand logo
Muscle intent in → bionic motion out.

License: GPL 3.0   LinkedIn: dinhsonn

EMGBand / Hand Bionic is a full-stack, open hardware kit that turns forearm muscle signals into predictable, servo-safe hand motion. It is built to be hackable, reproducible, and fast to demo: one bill of materials, one firmware pair (ring + hand), one Flutter app to calibrate and ship.

Designed for makers, researchers, and product teams, EMGBand focuses on reliability, safety, and repeatability. The repo bundles manufacturing-ready assets (Gerbers, BOMs), production photos, a tested ESP32 firmware pair, and a Flutter app that makes calibration and demos straightforward.

Table of Contents

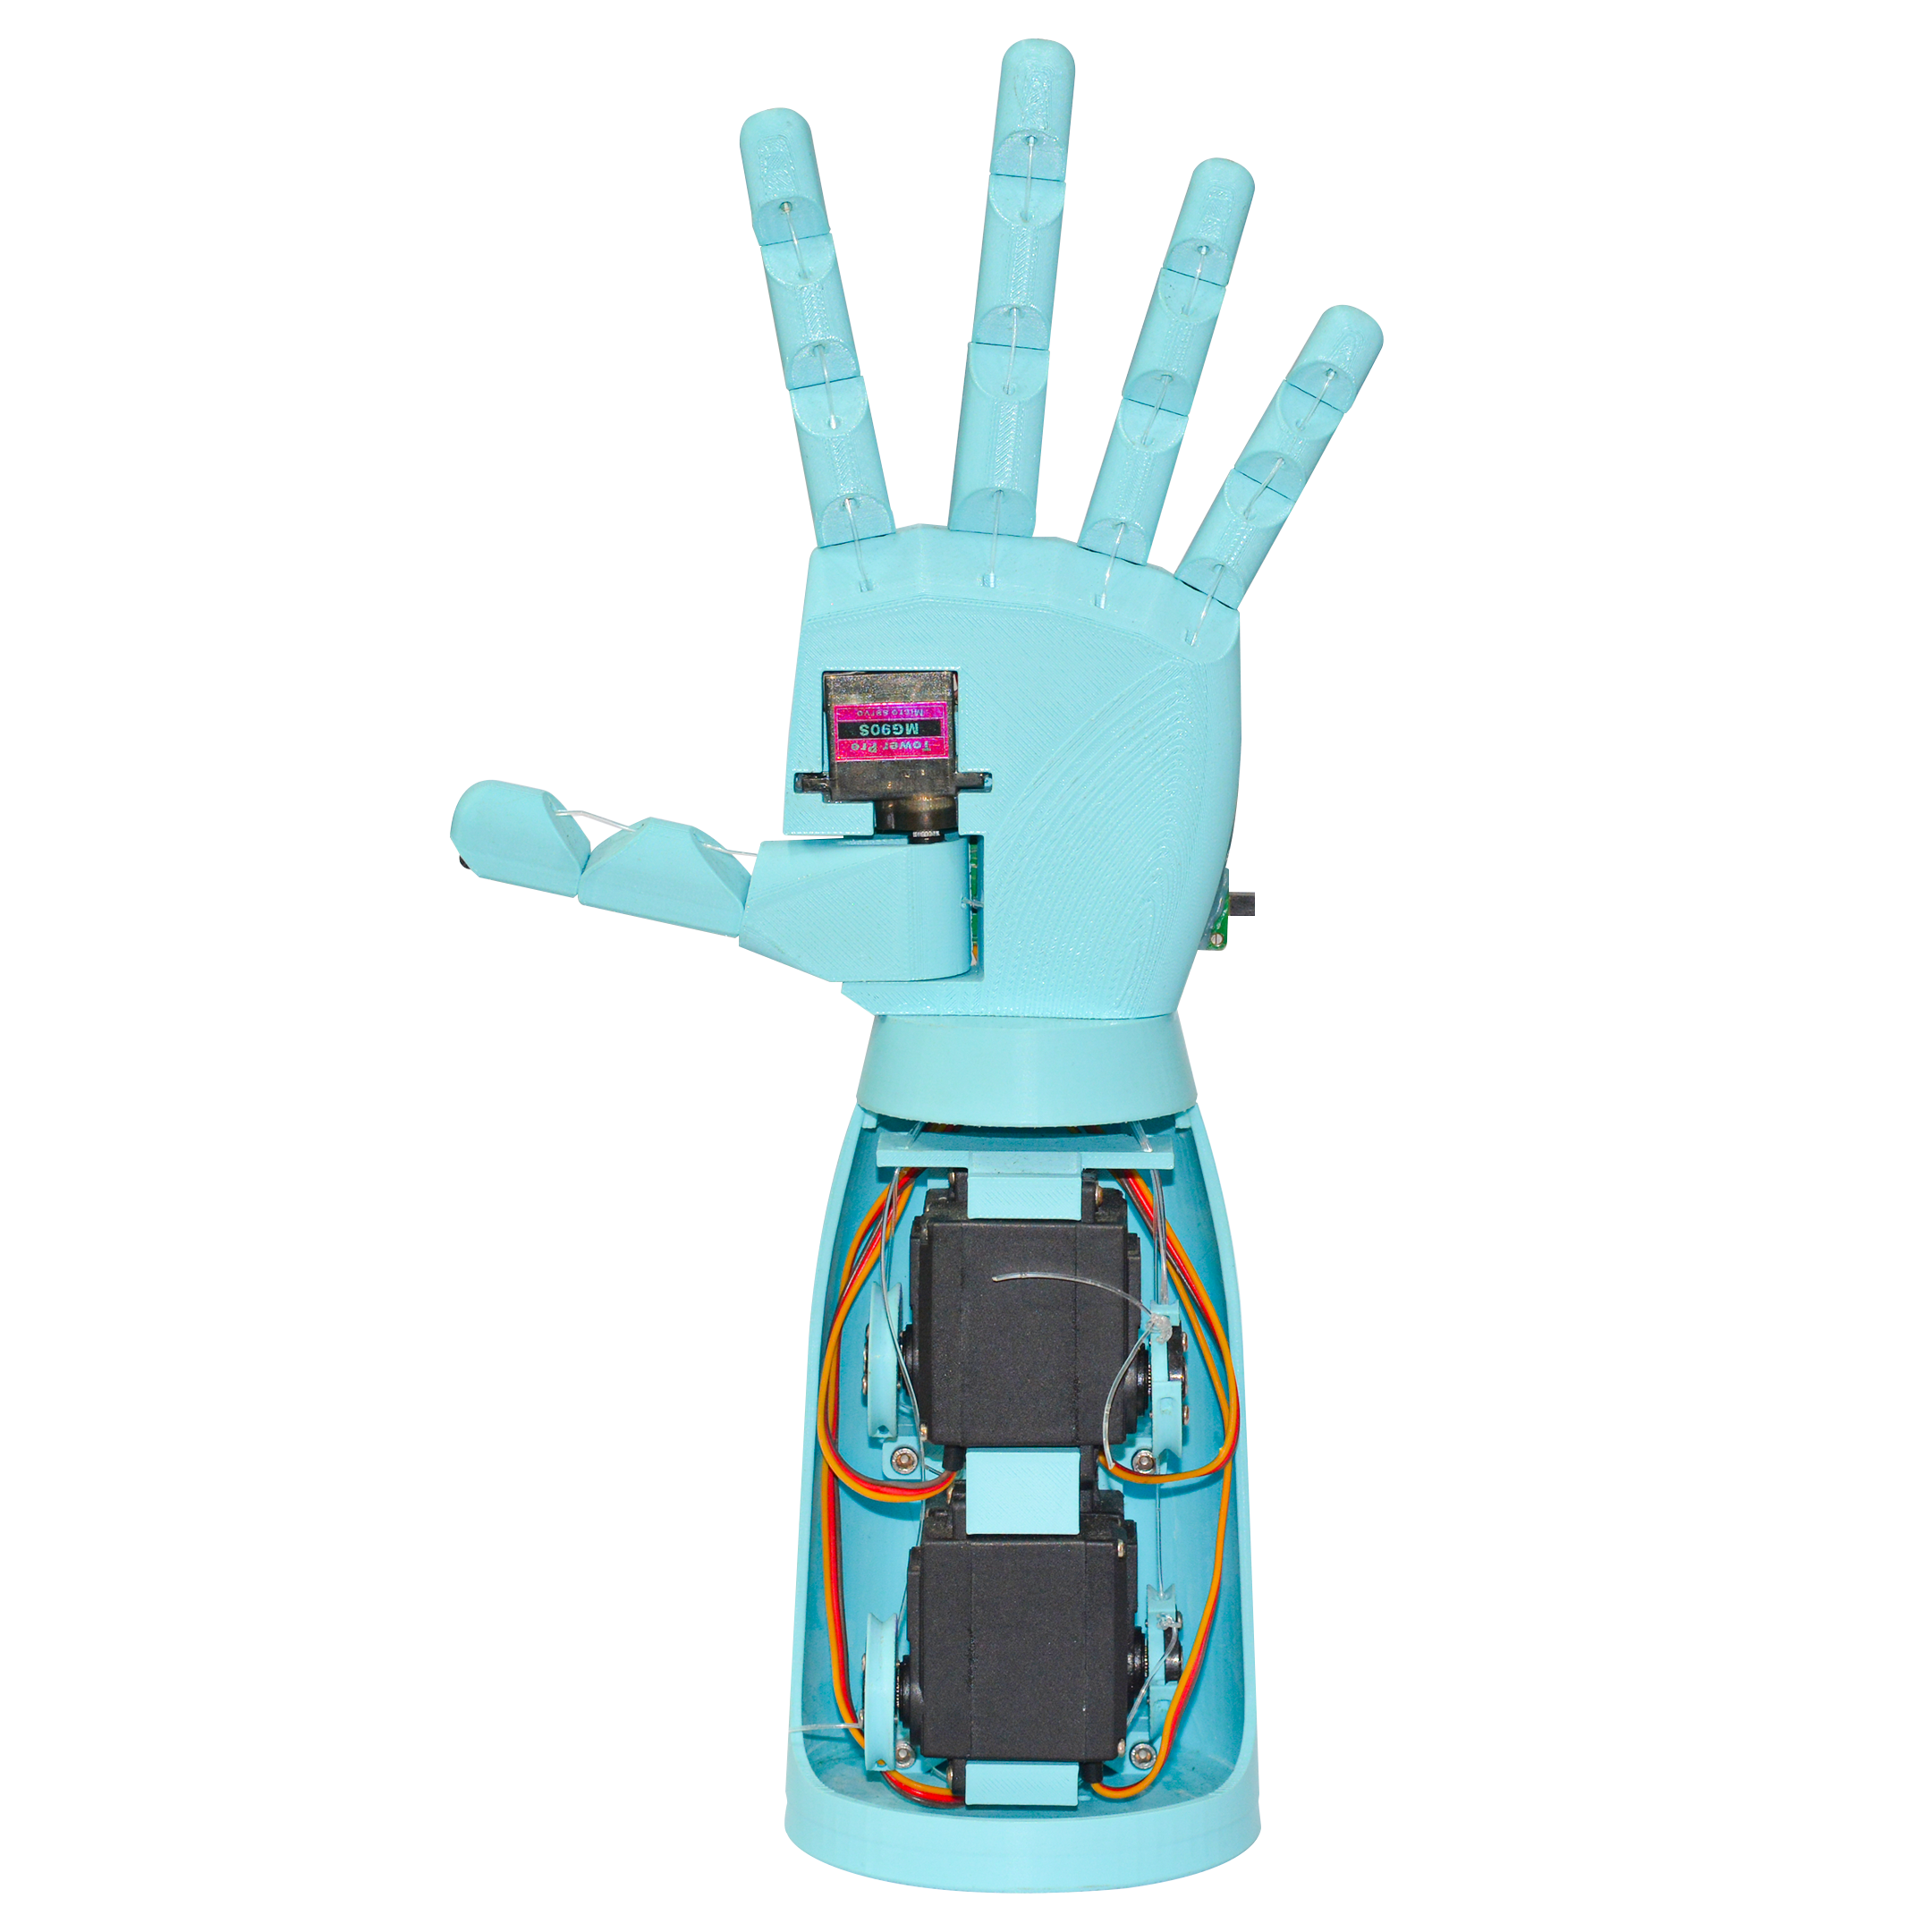
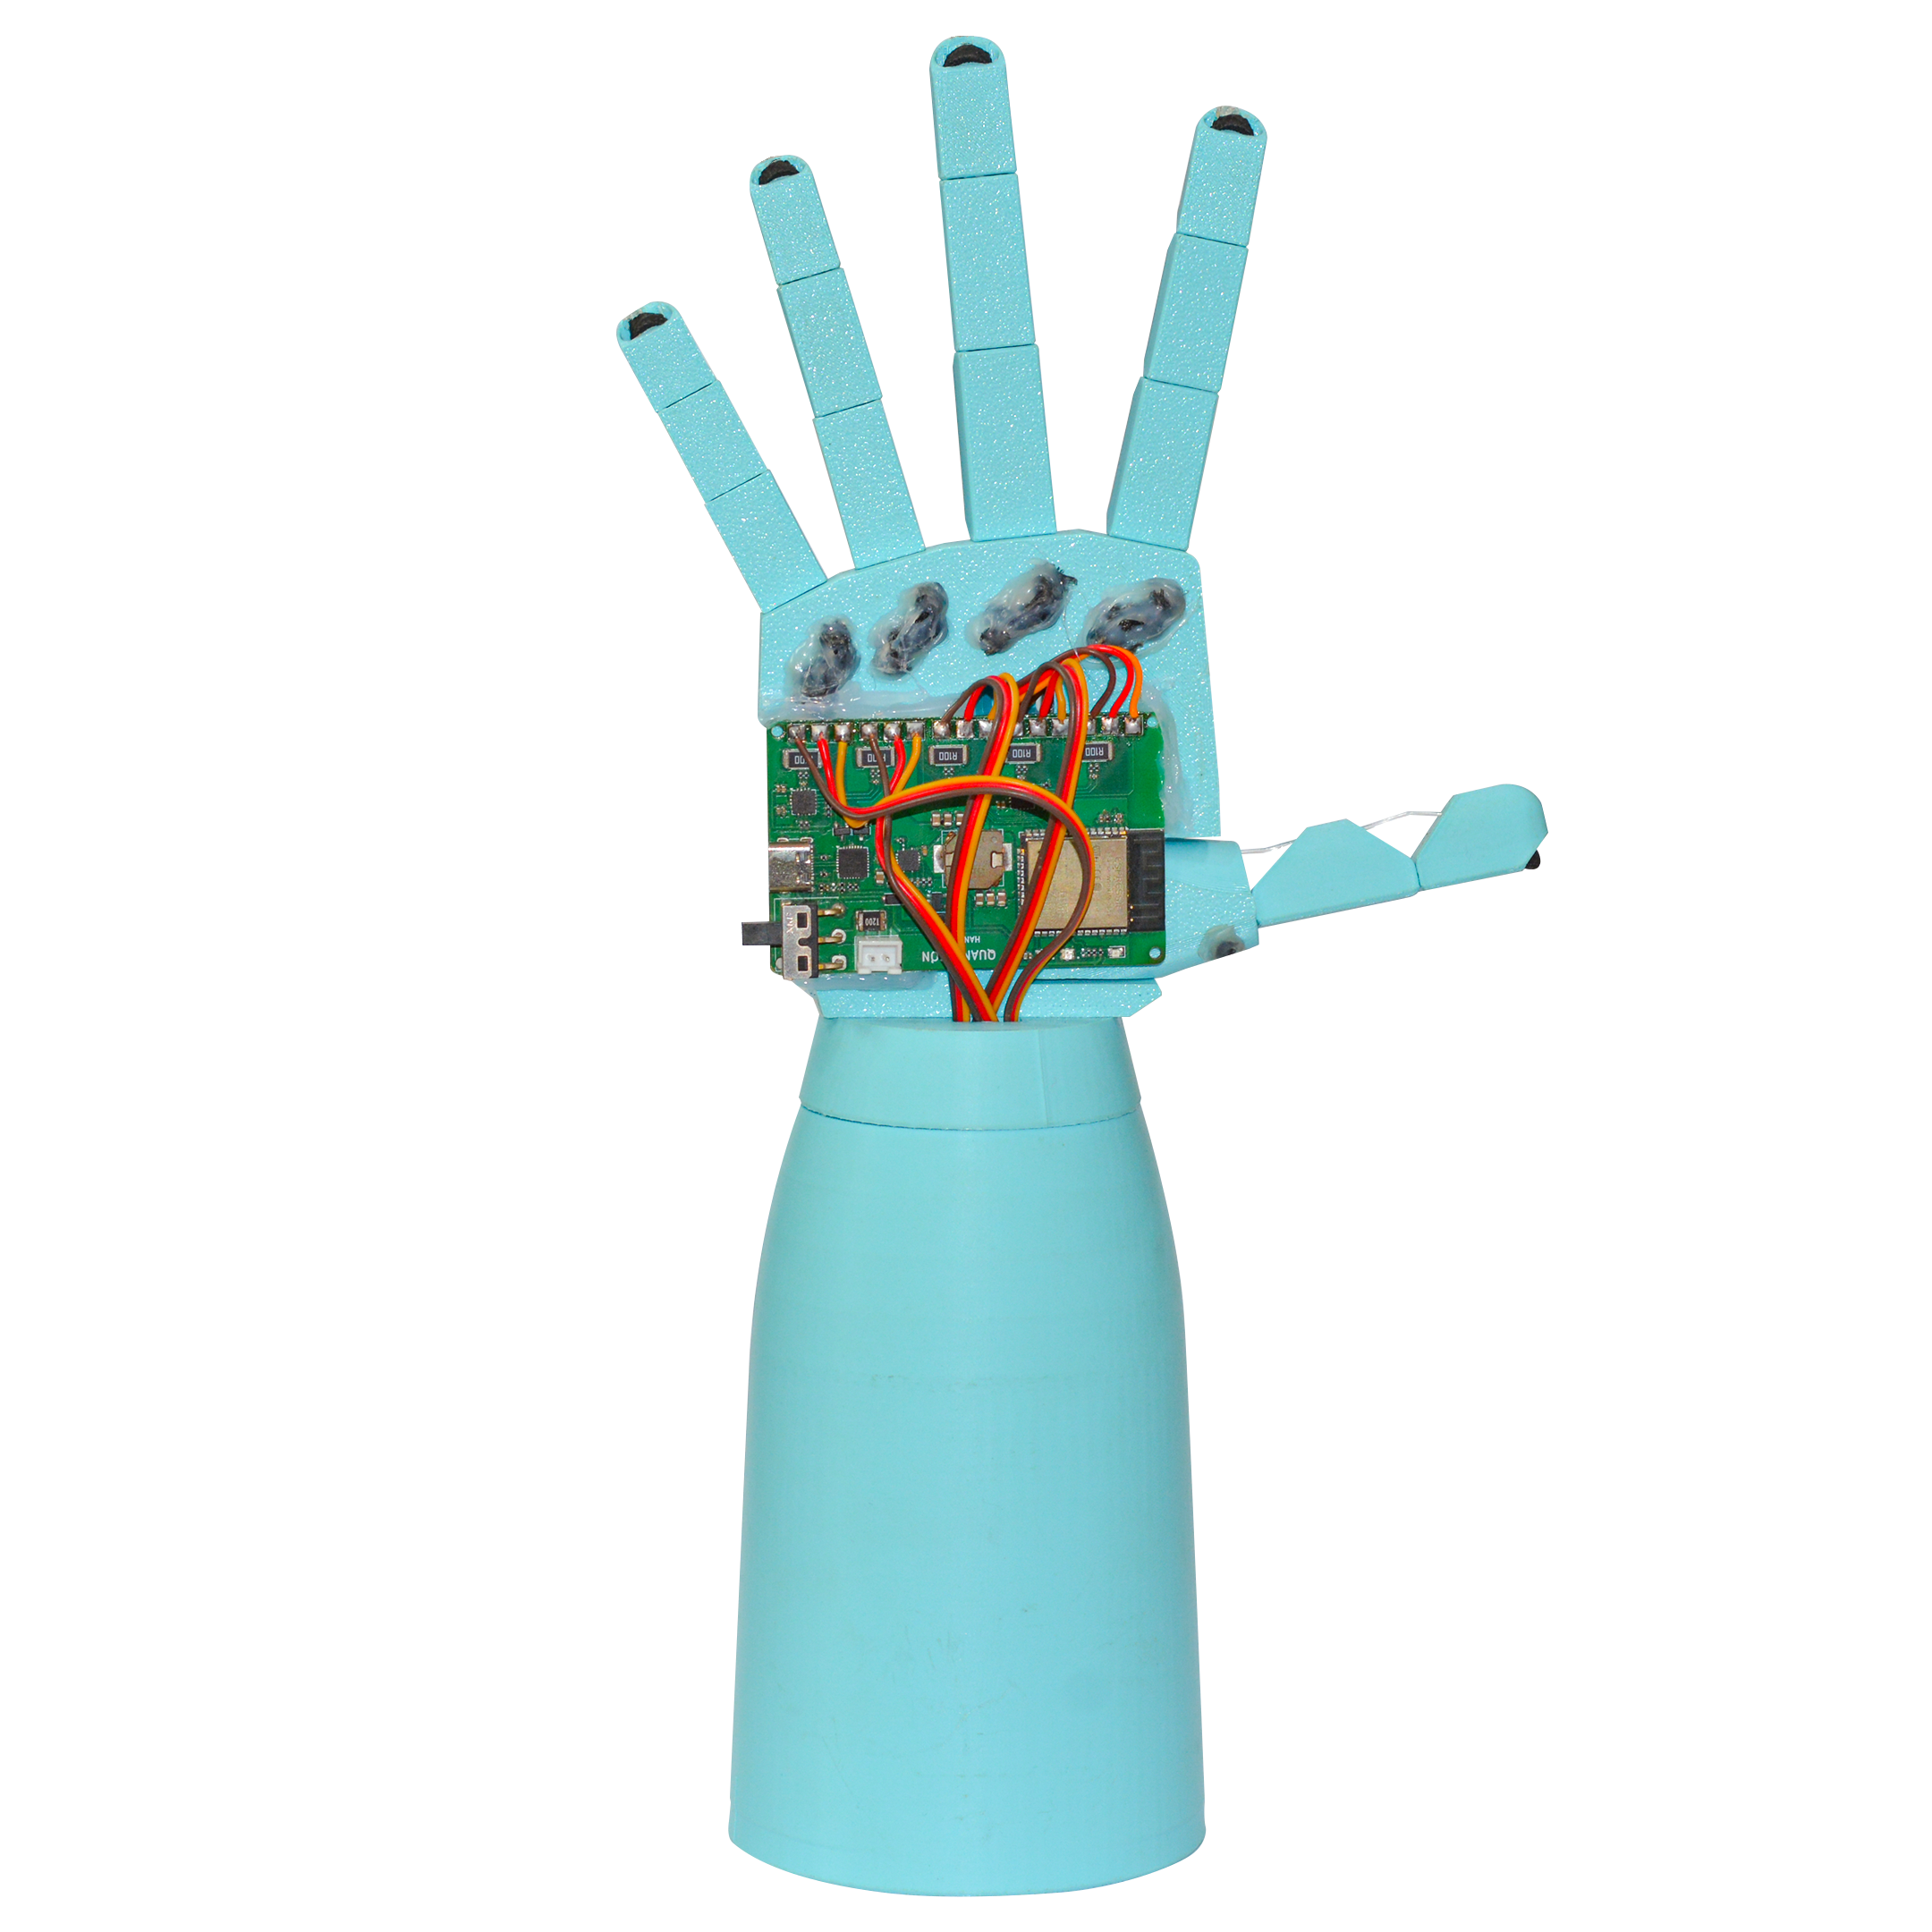
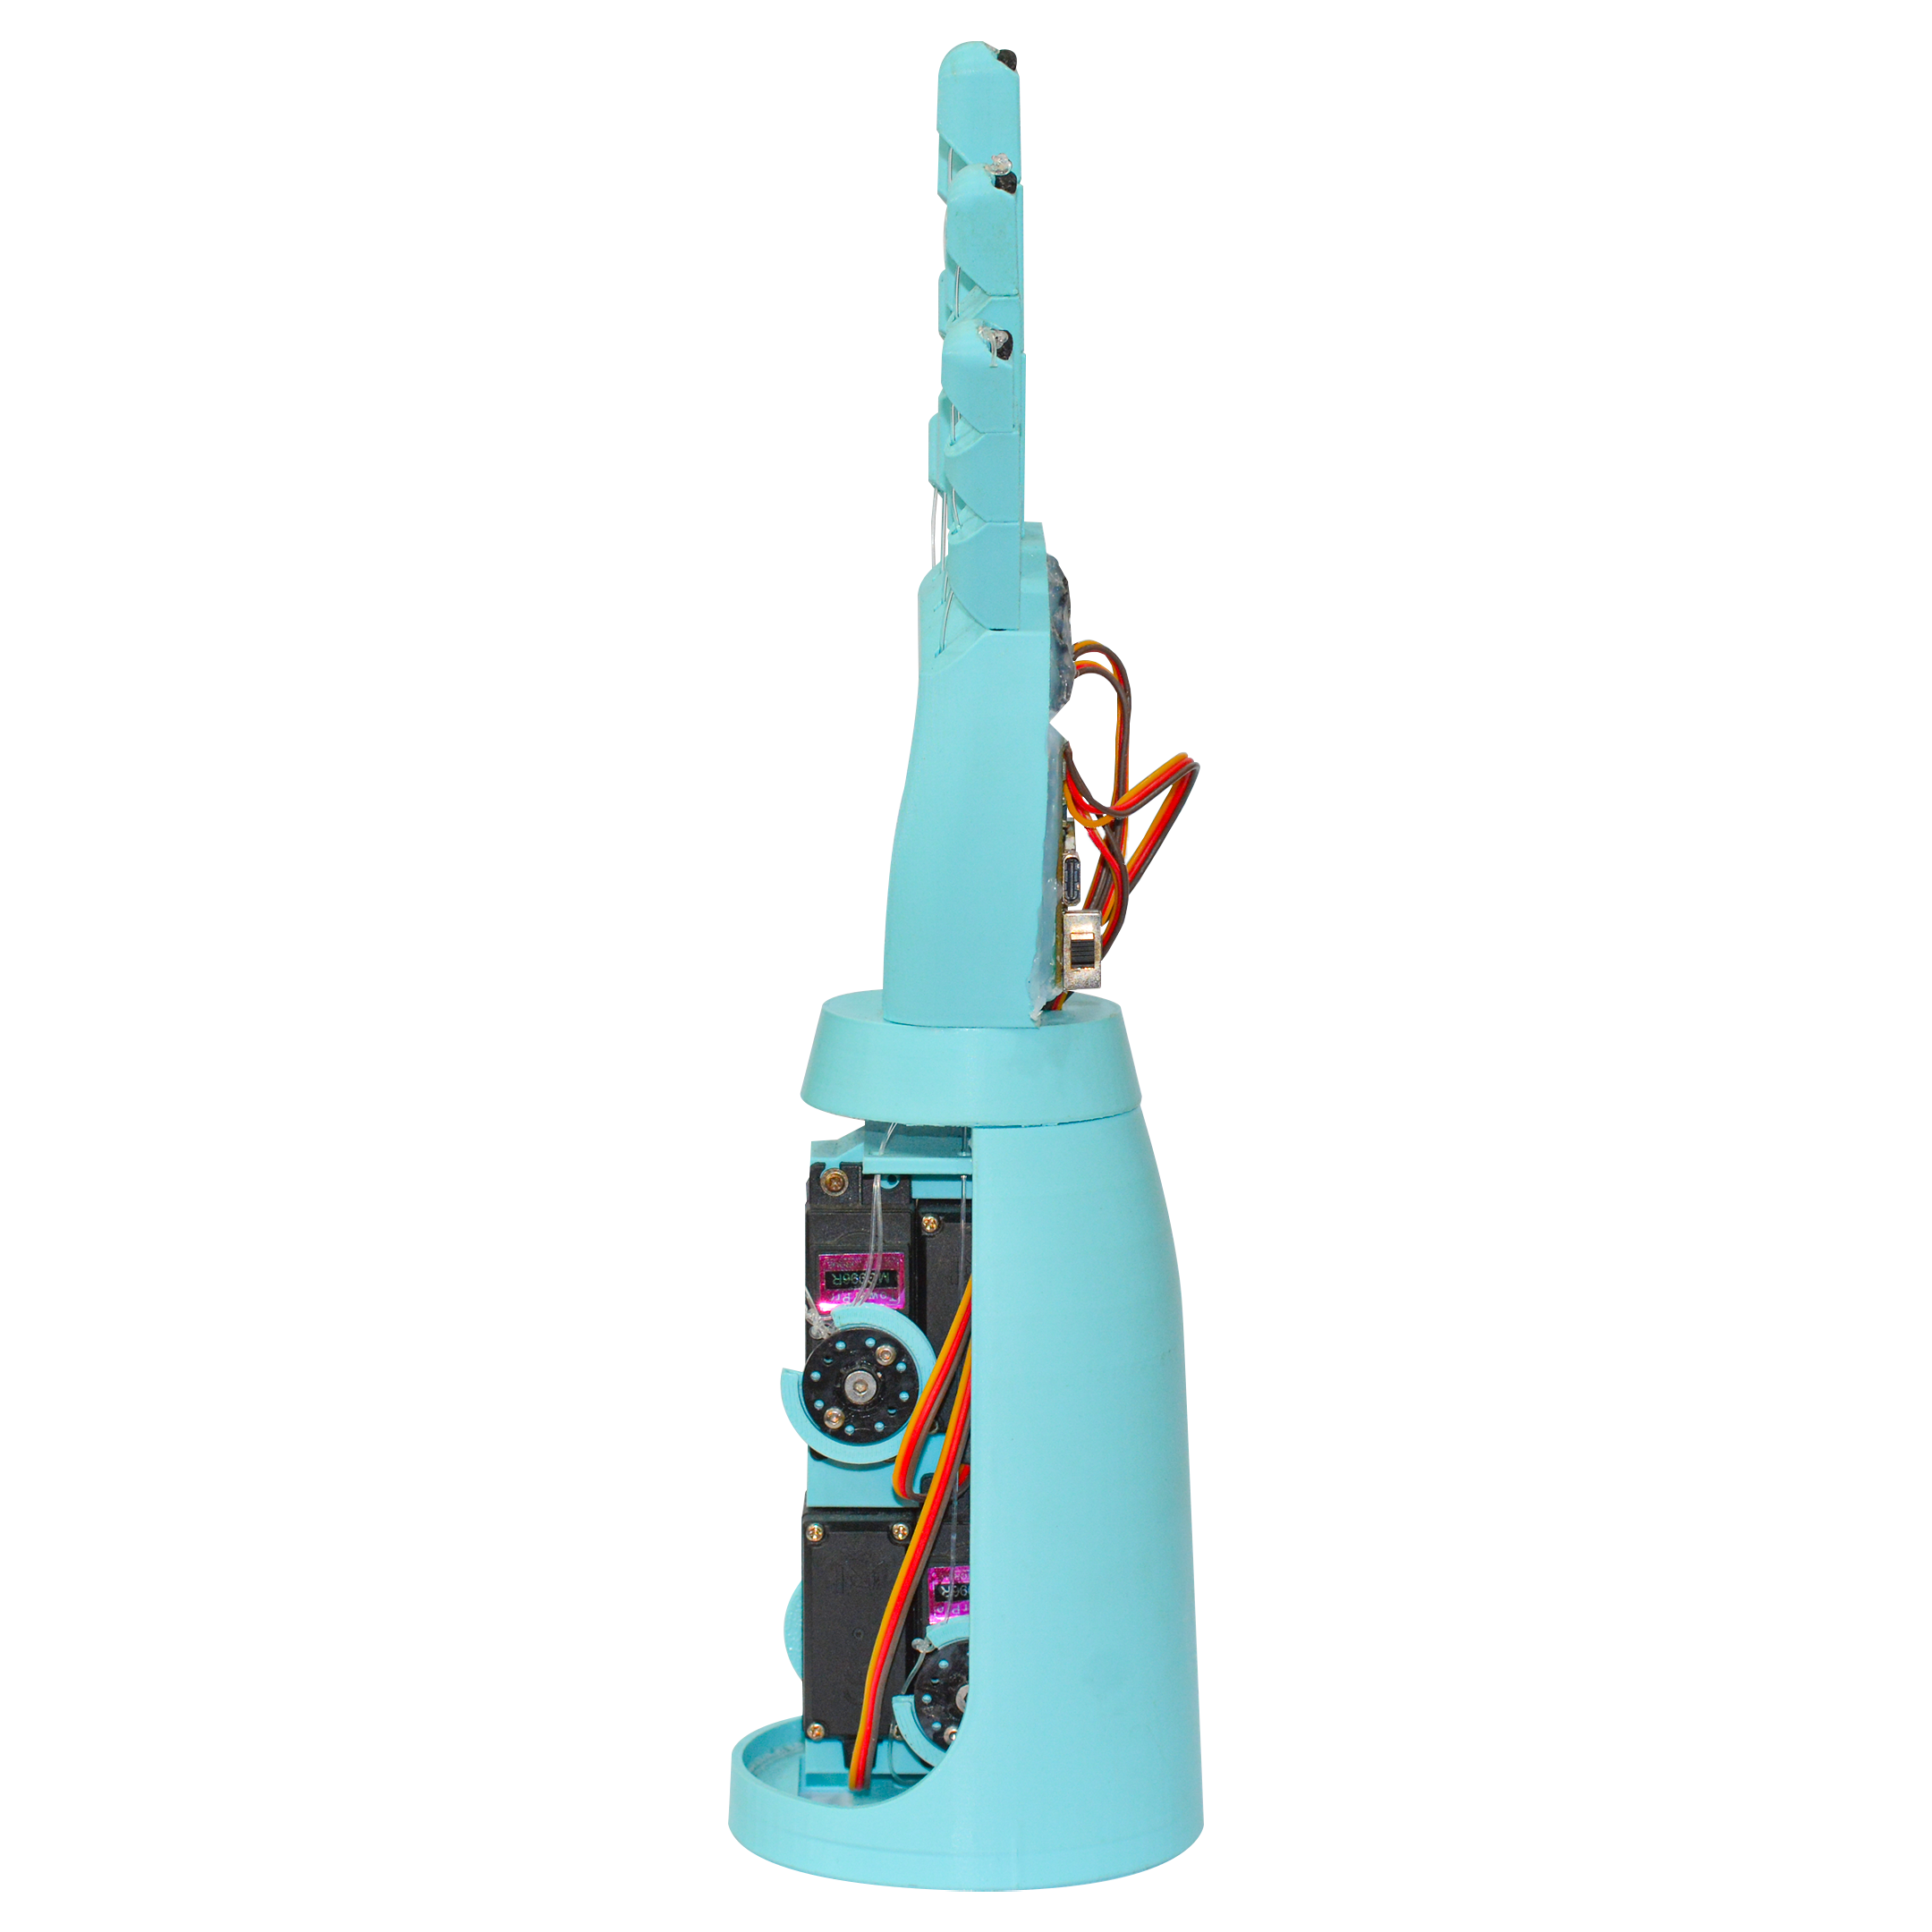
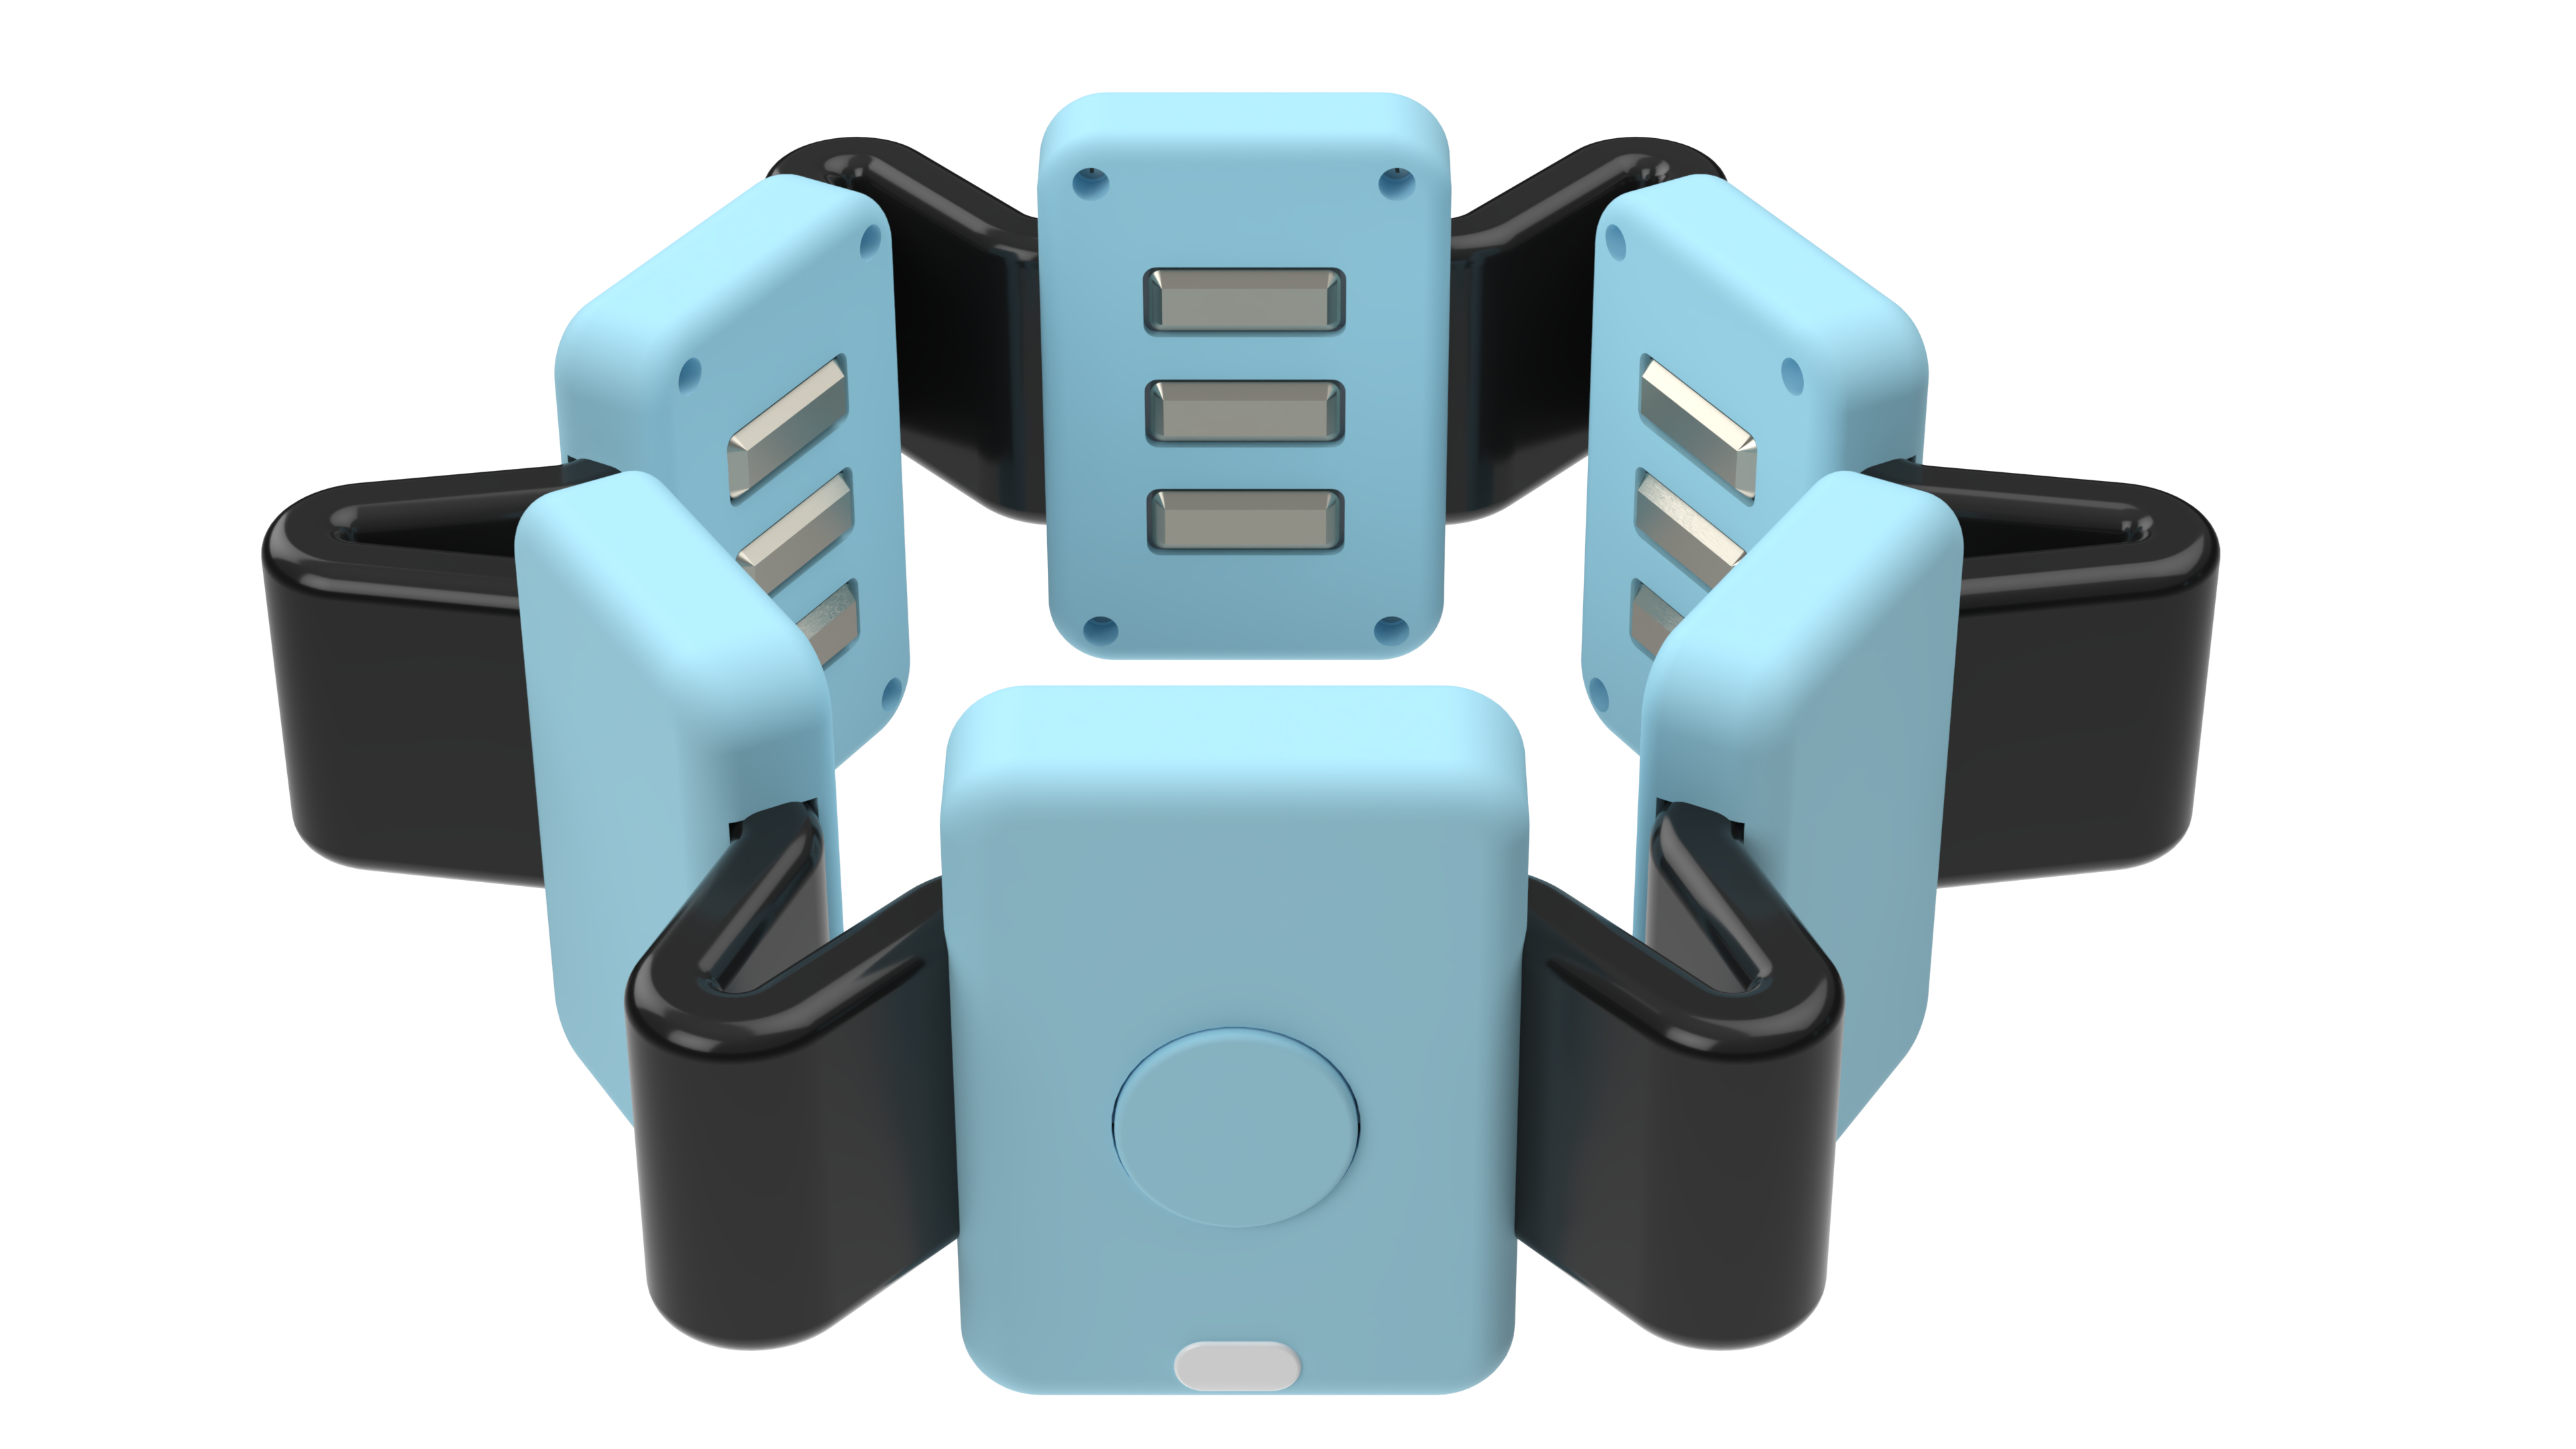
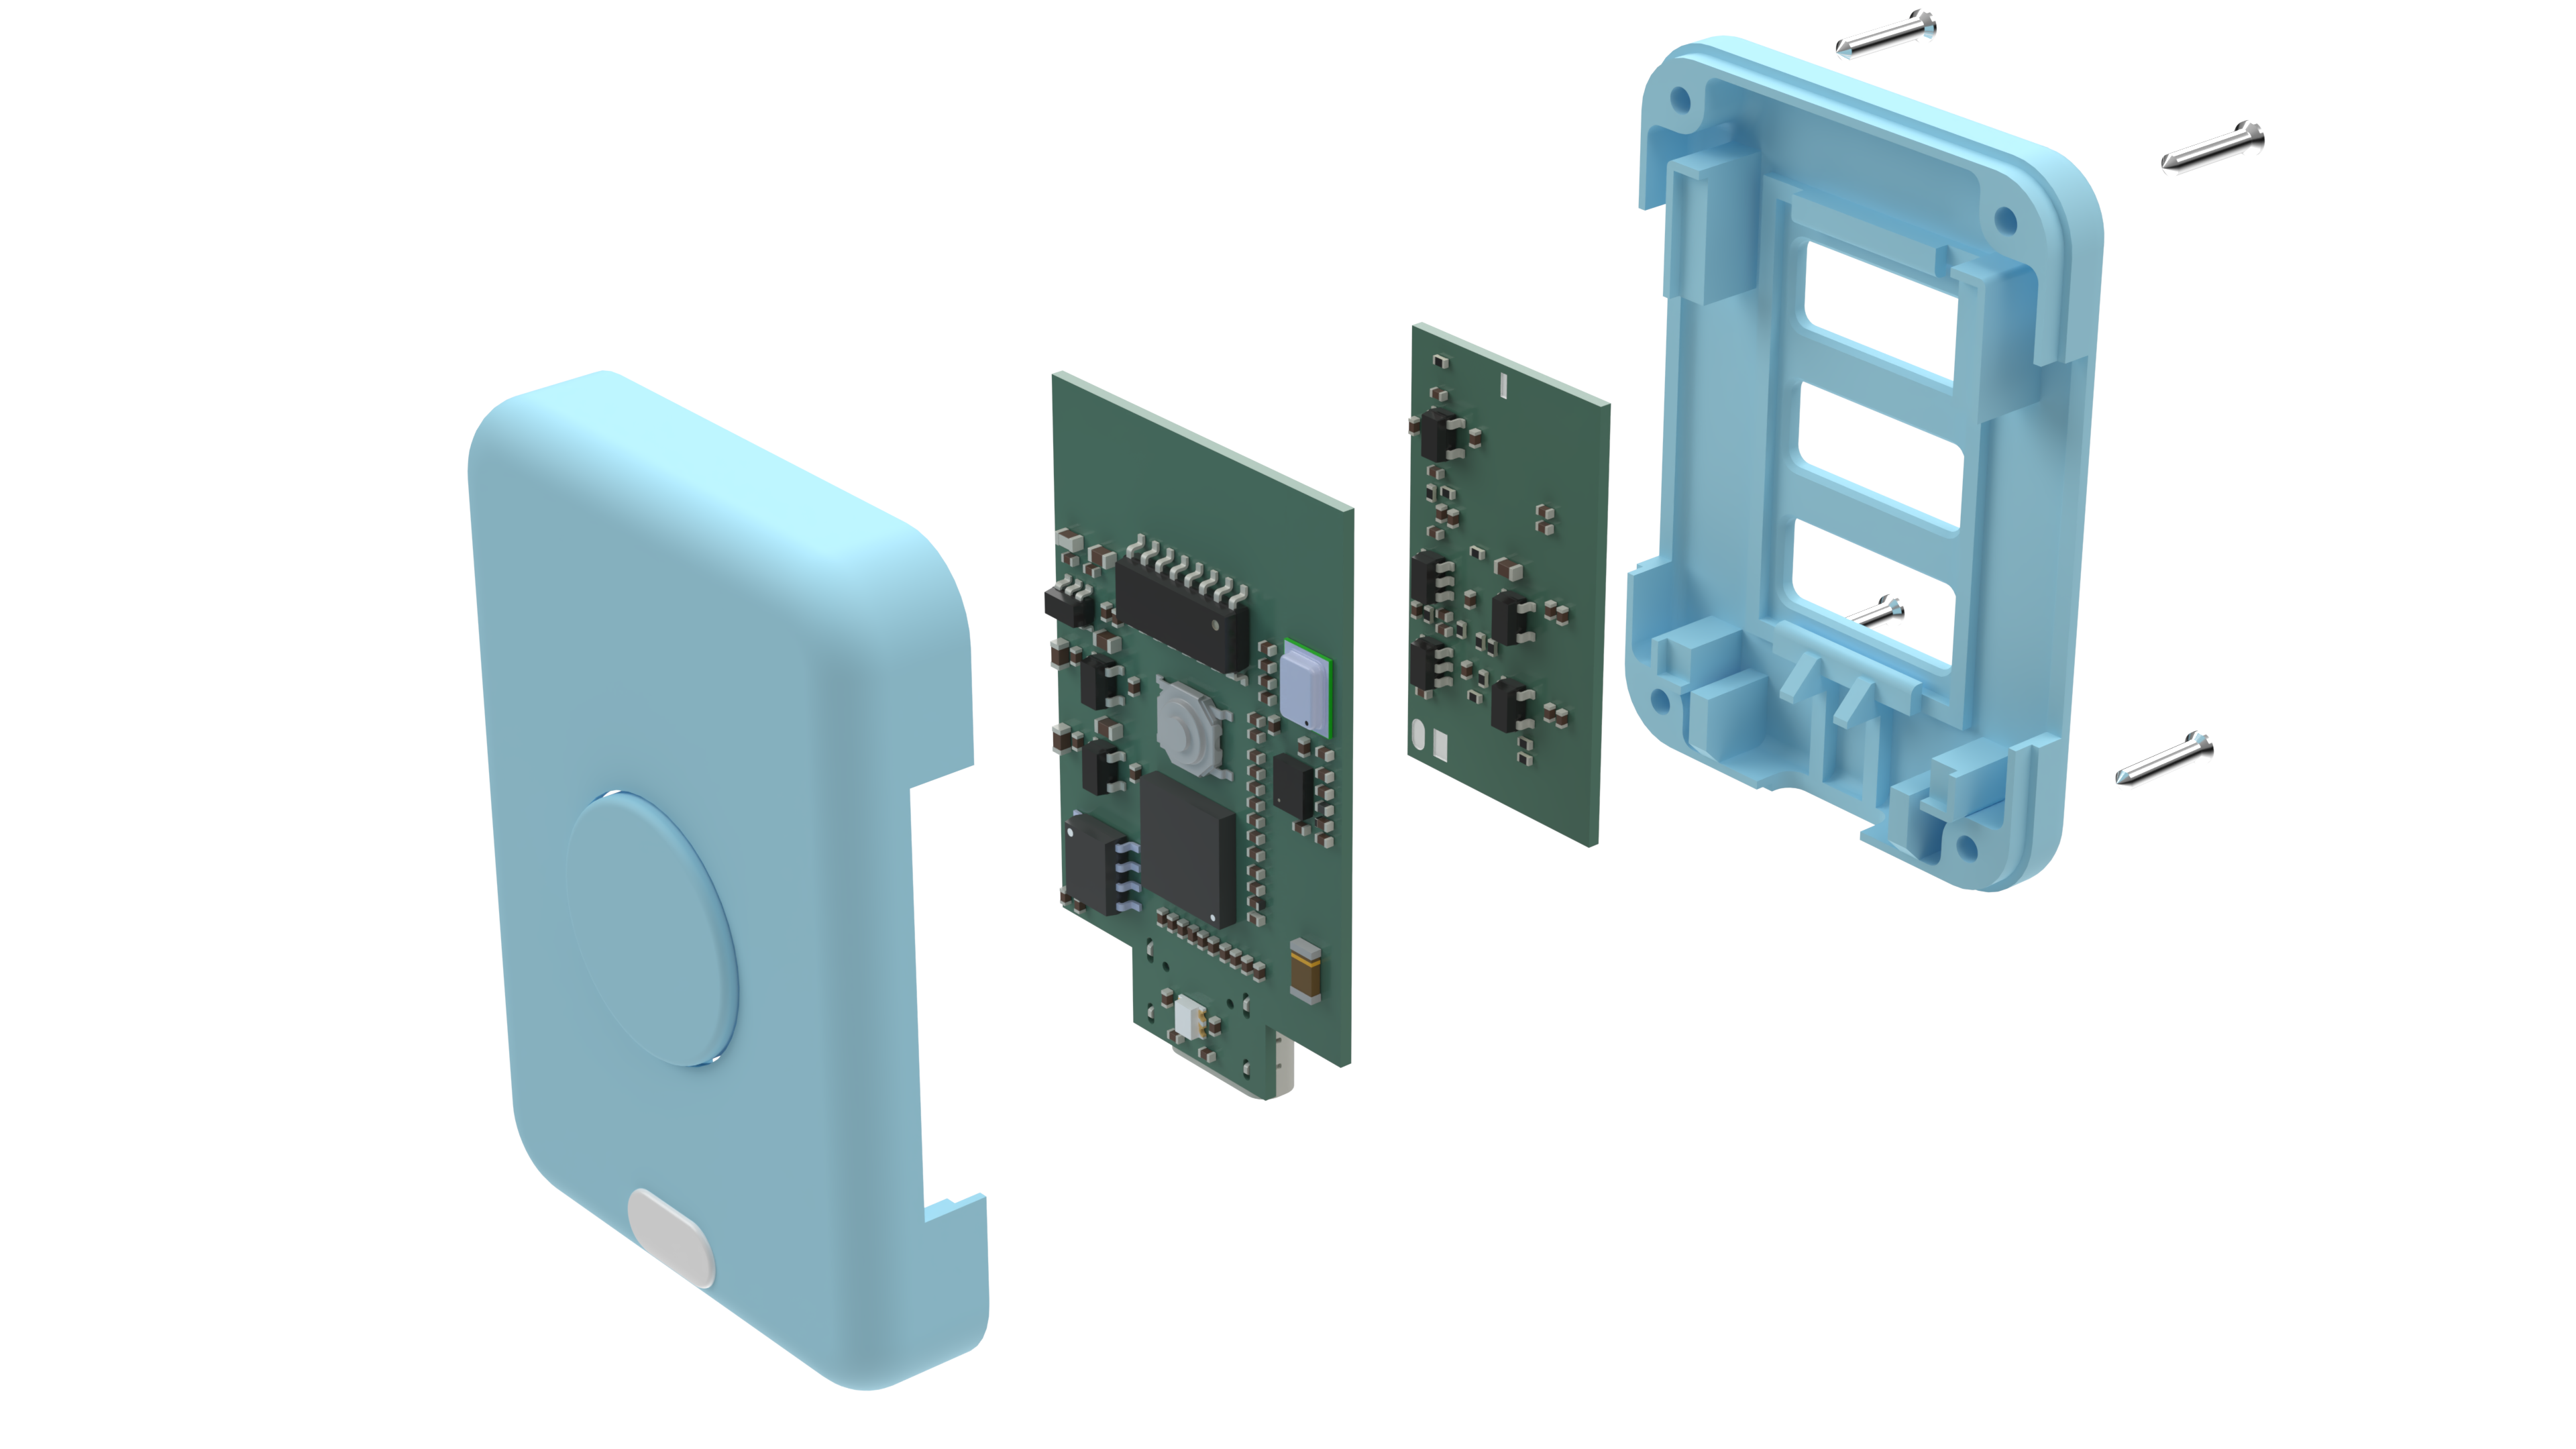
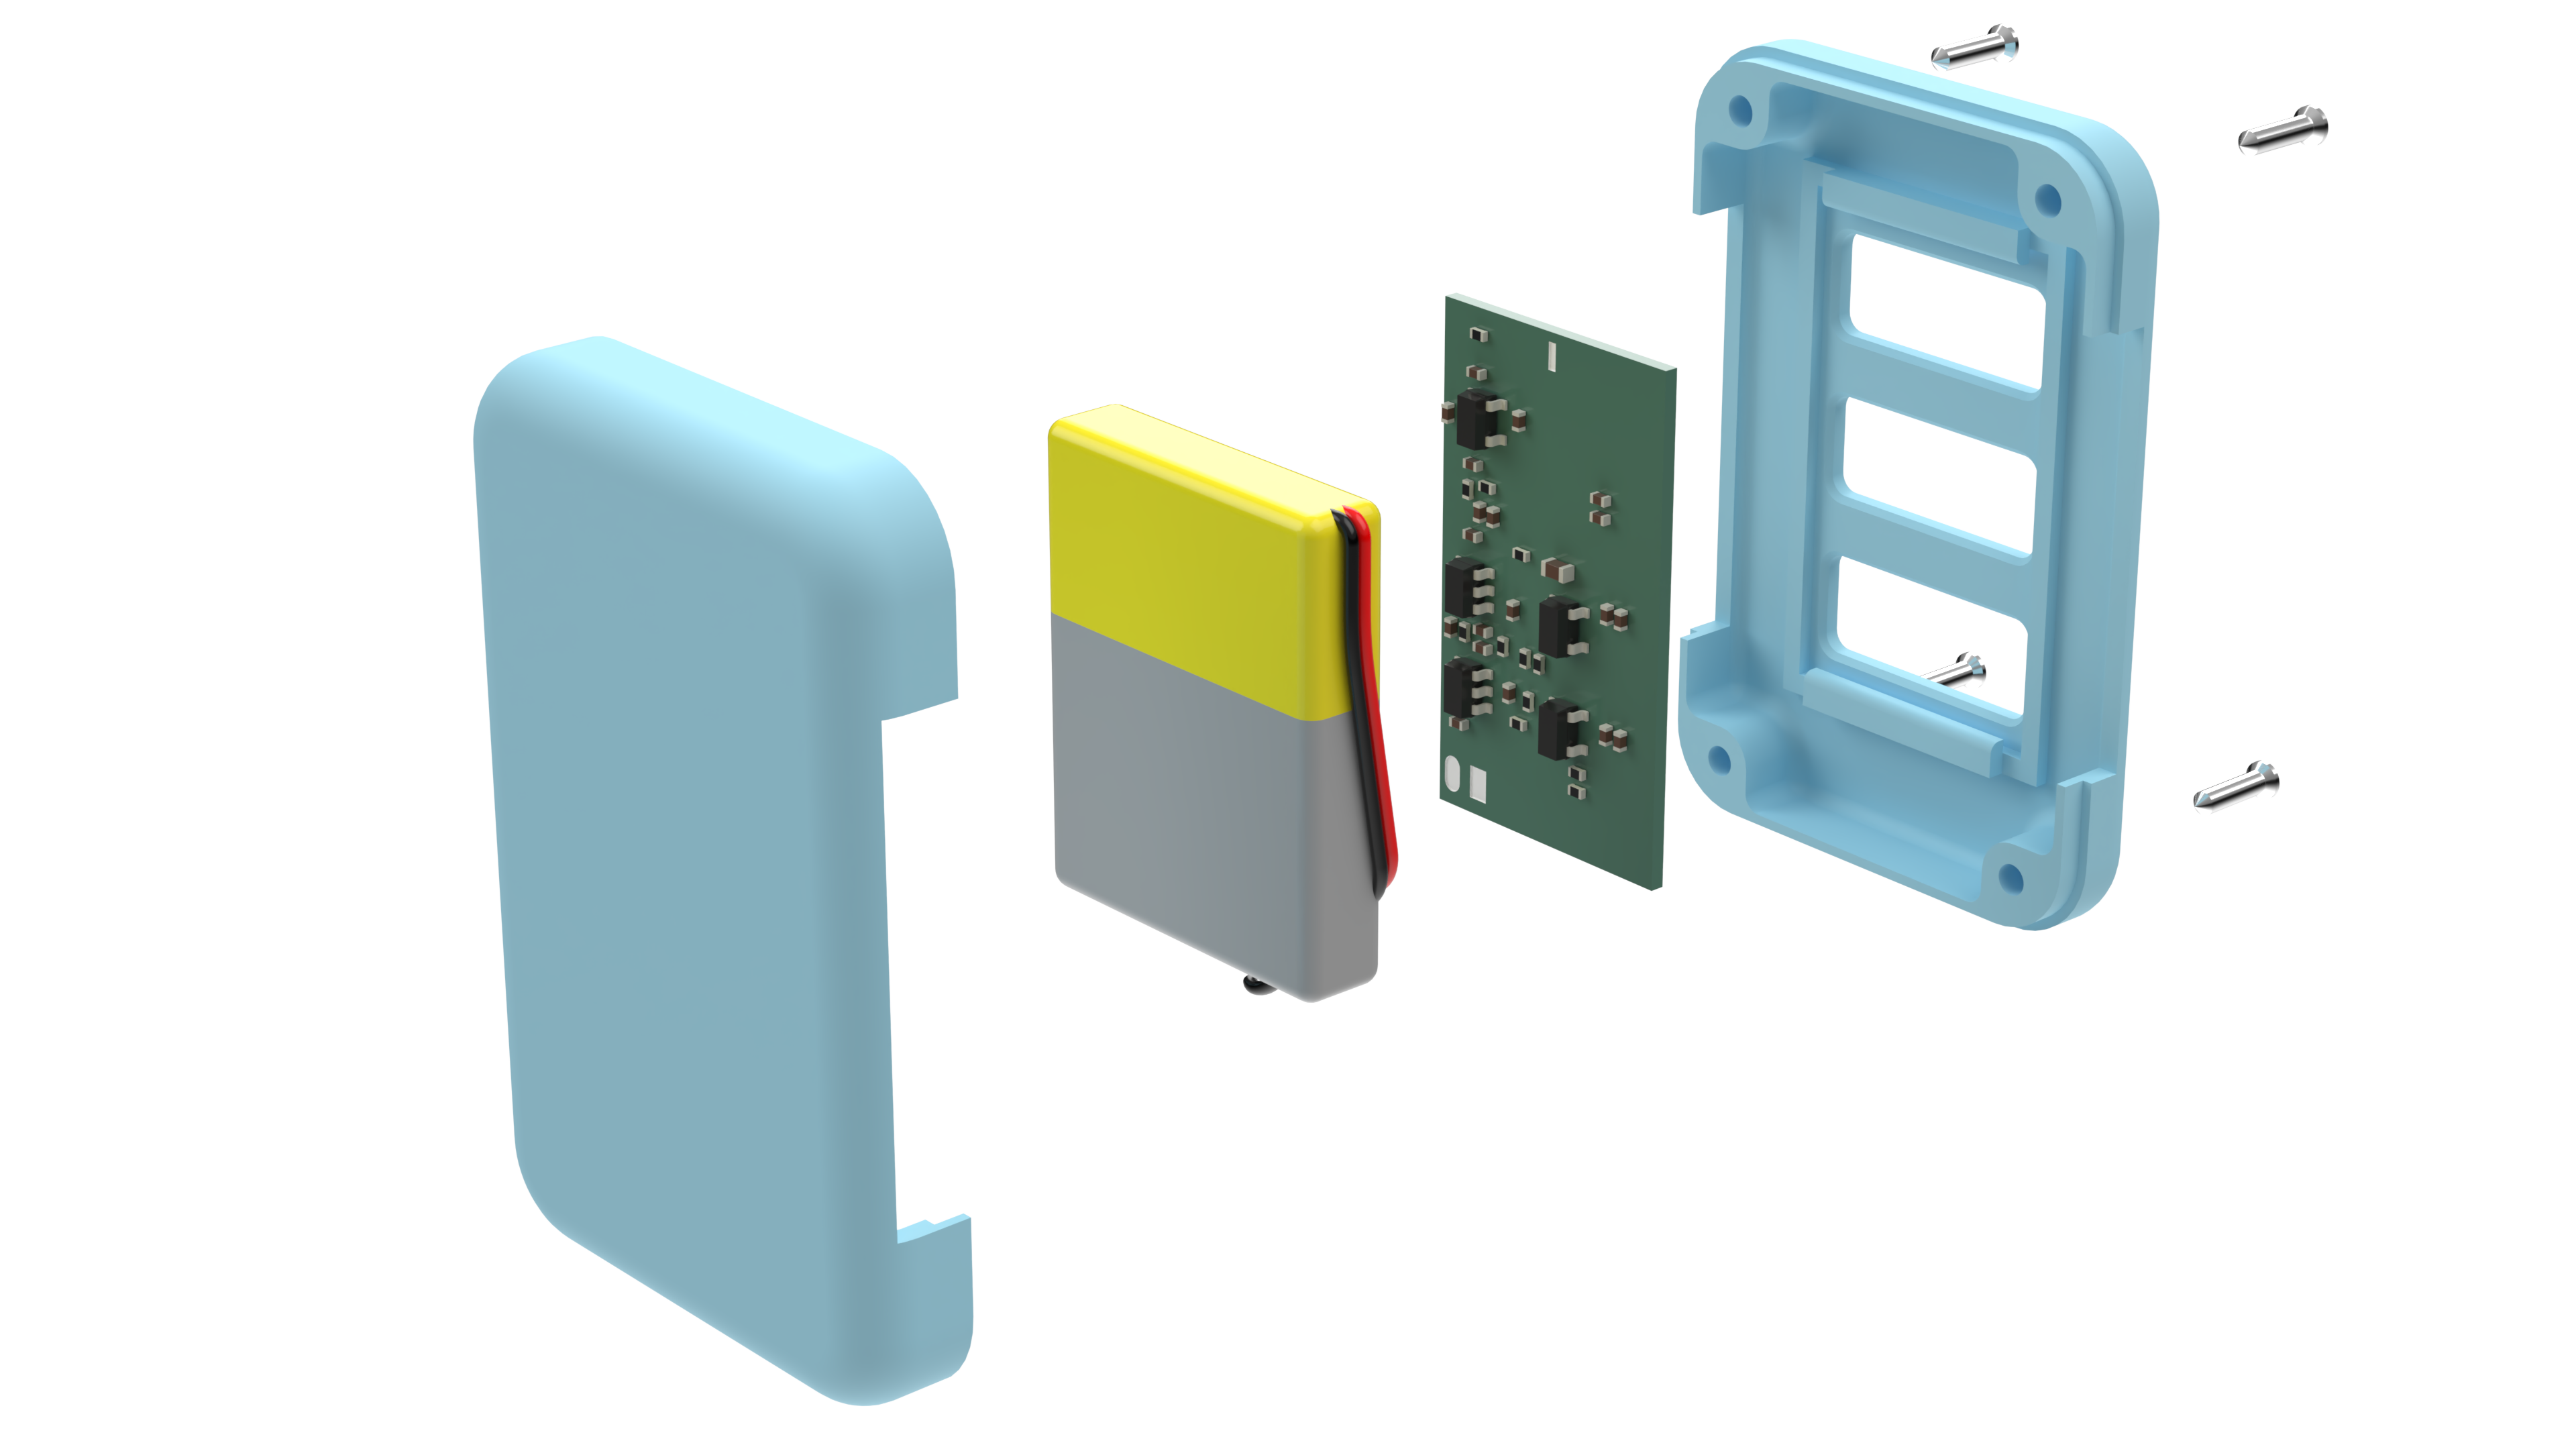
MyoBand frontMain blockSensor block

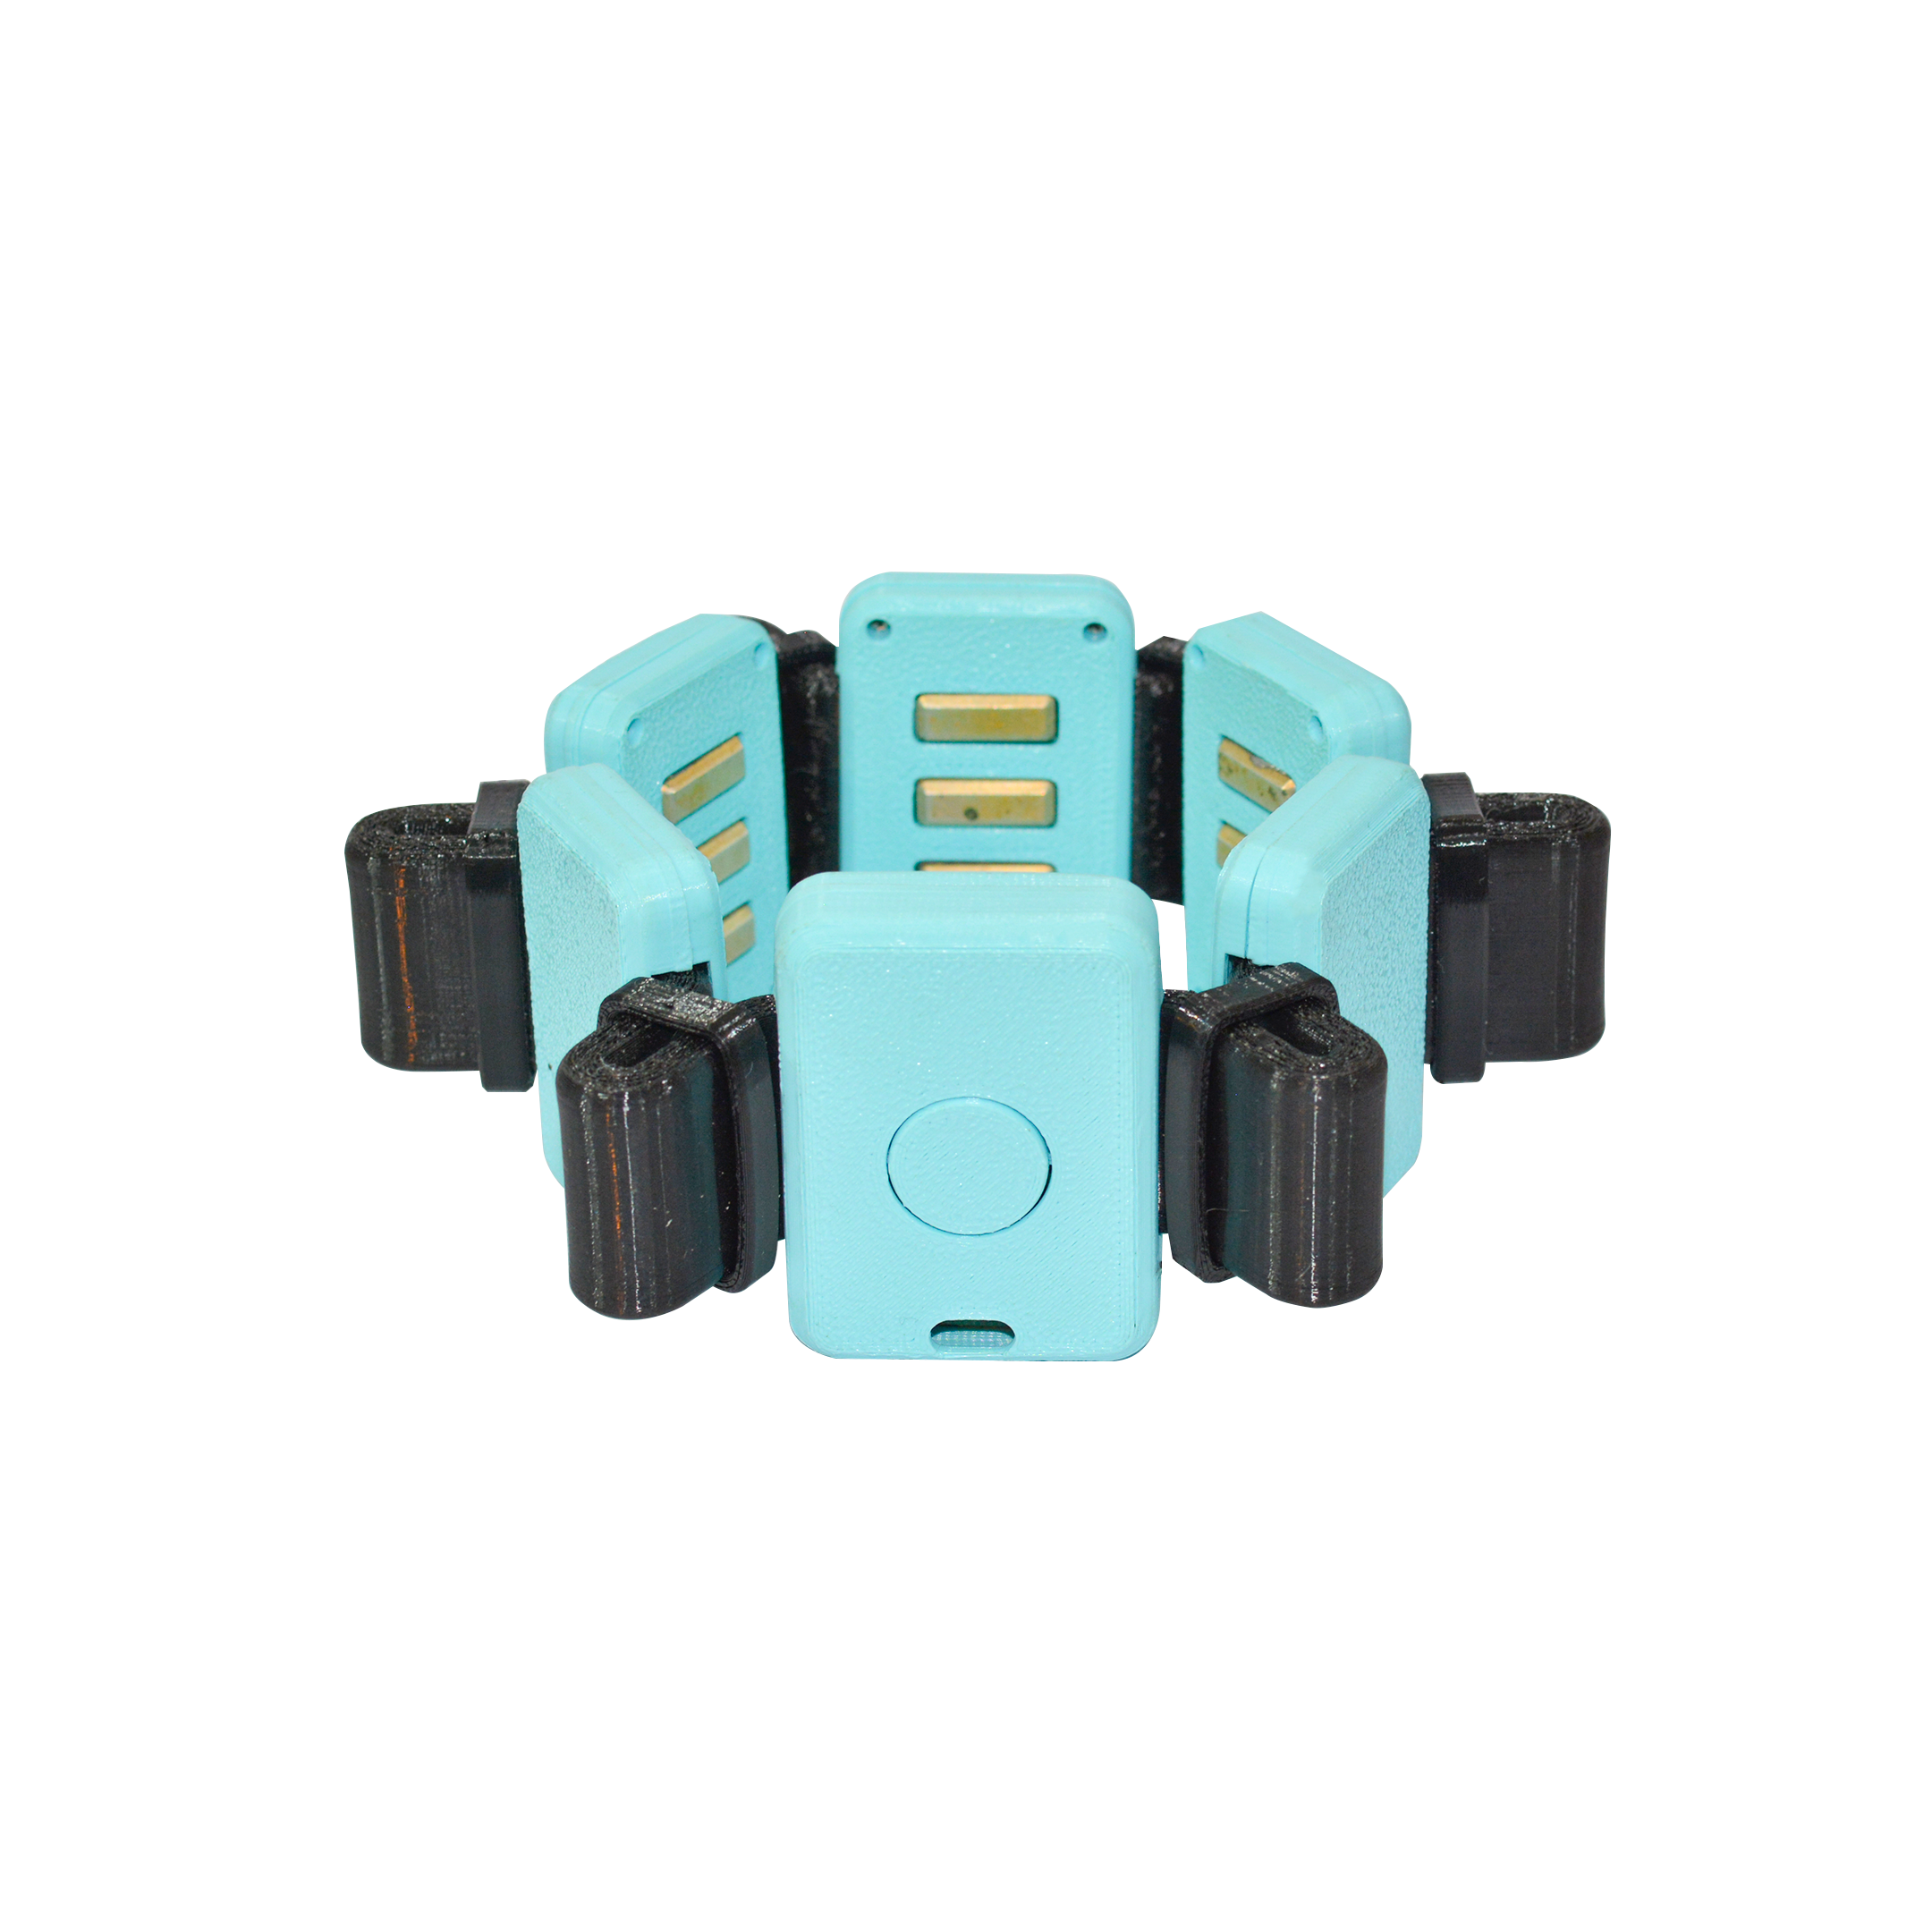
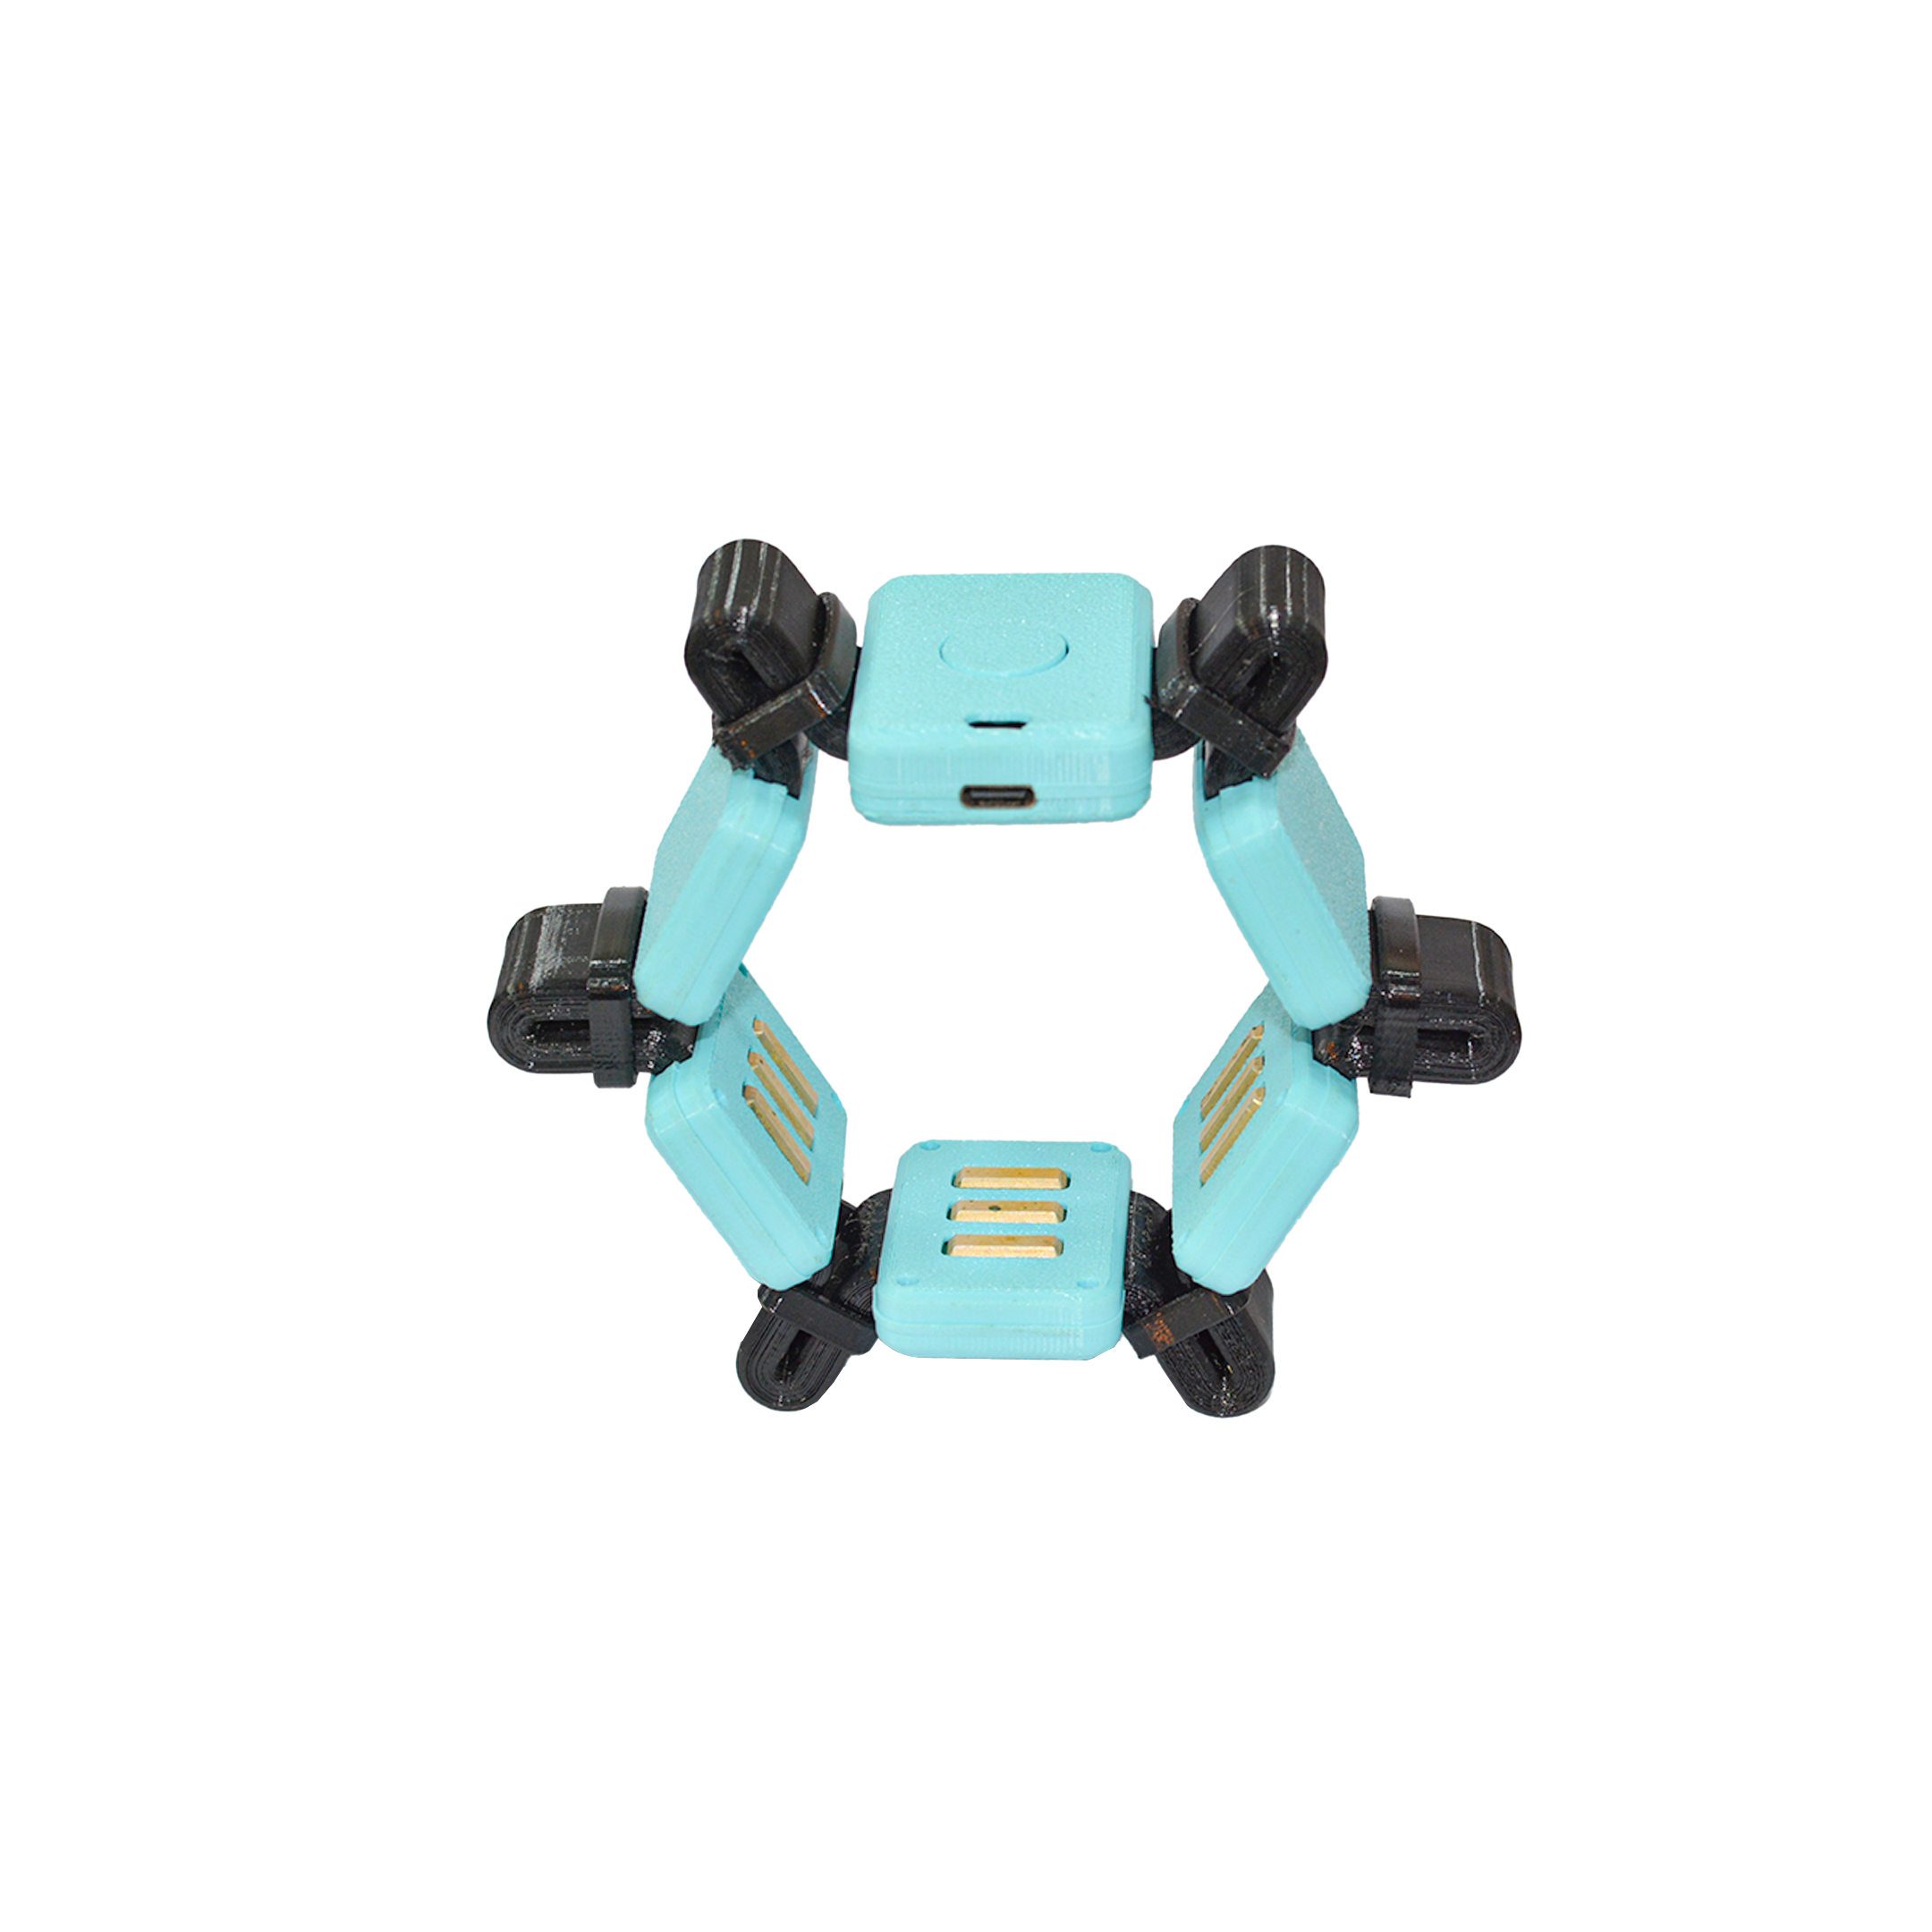
Wearable EMG ring + controller blocks from the latest build.

What this repo delivers

  • Hardware you can fabricate: KiCad projects for the MyoBand EMG front-end, hand controller, and modular sensor blocks. Gerbers, pick-and-place, and reference photos are ready for a quick manufacturing turn.
  • Firmware that guards the hardware: ESP32 (ring + hand) stack with EMG filtering, intent classification, BLE services, OTA hooks, and stall-safe servo control so experiments stay repeatable and safe.
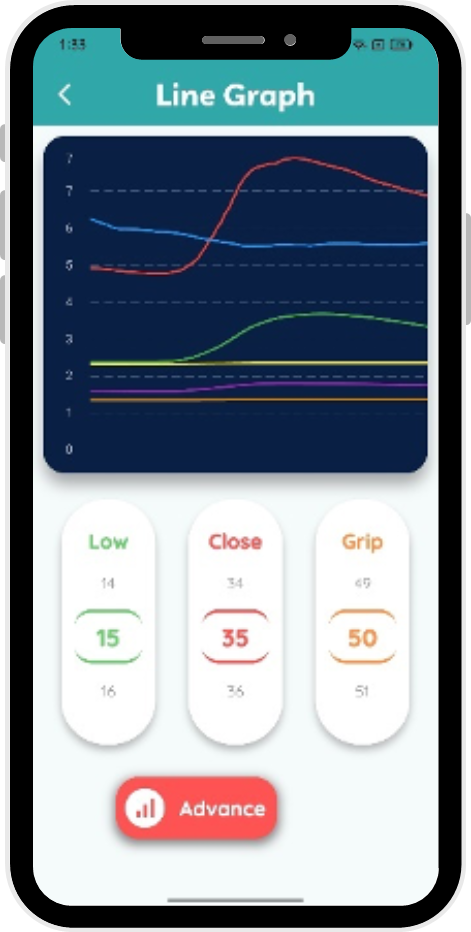
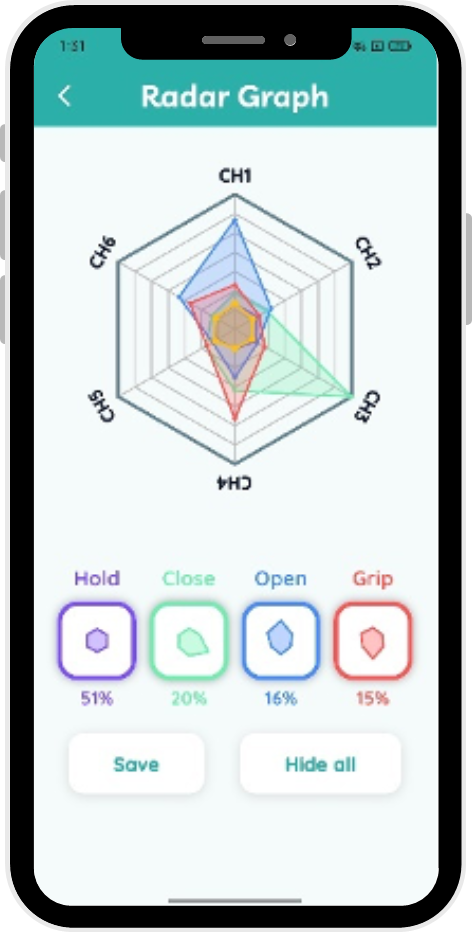
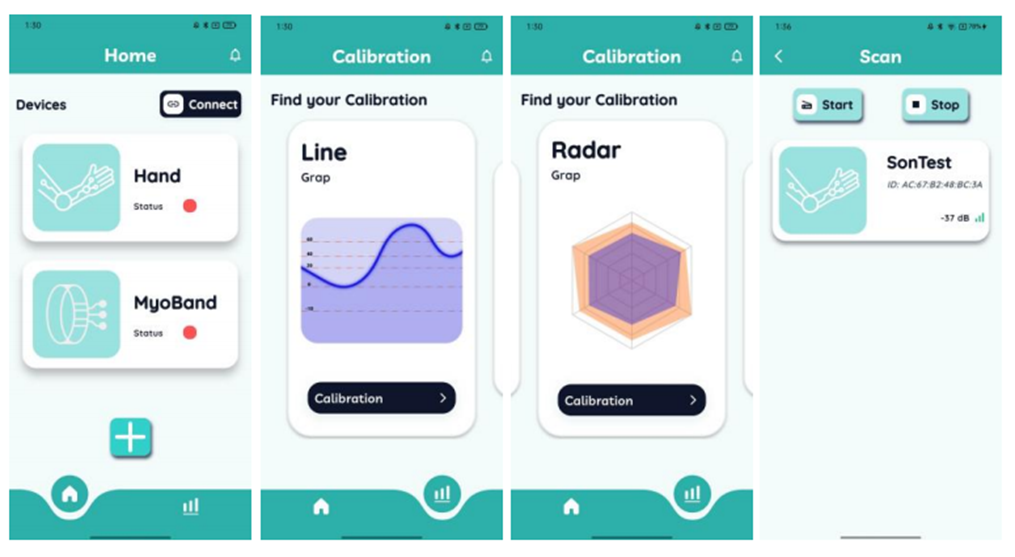
  • App that closes the loop: Flutter client to scan, pair, stream EMG, calibrate thresholds (Line/Radar), push configs, and swap control modes without reflashing.
  • Media to build confidence: Photos and demo videos to set assembly expectations before you order or solder.

Quick gallery

See how the wearable comes together before diving into schematics or code.

Real build 1
📸 Assembled unit 1
Real build 2
📸 Assembled unit 2
Real build 3
📸 Assembled unit 3
Real build 4
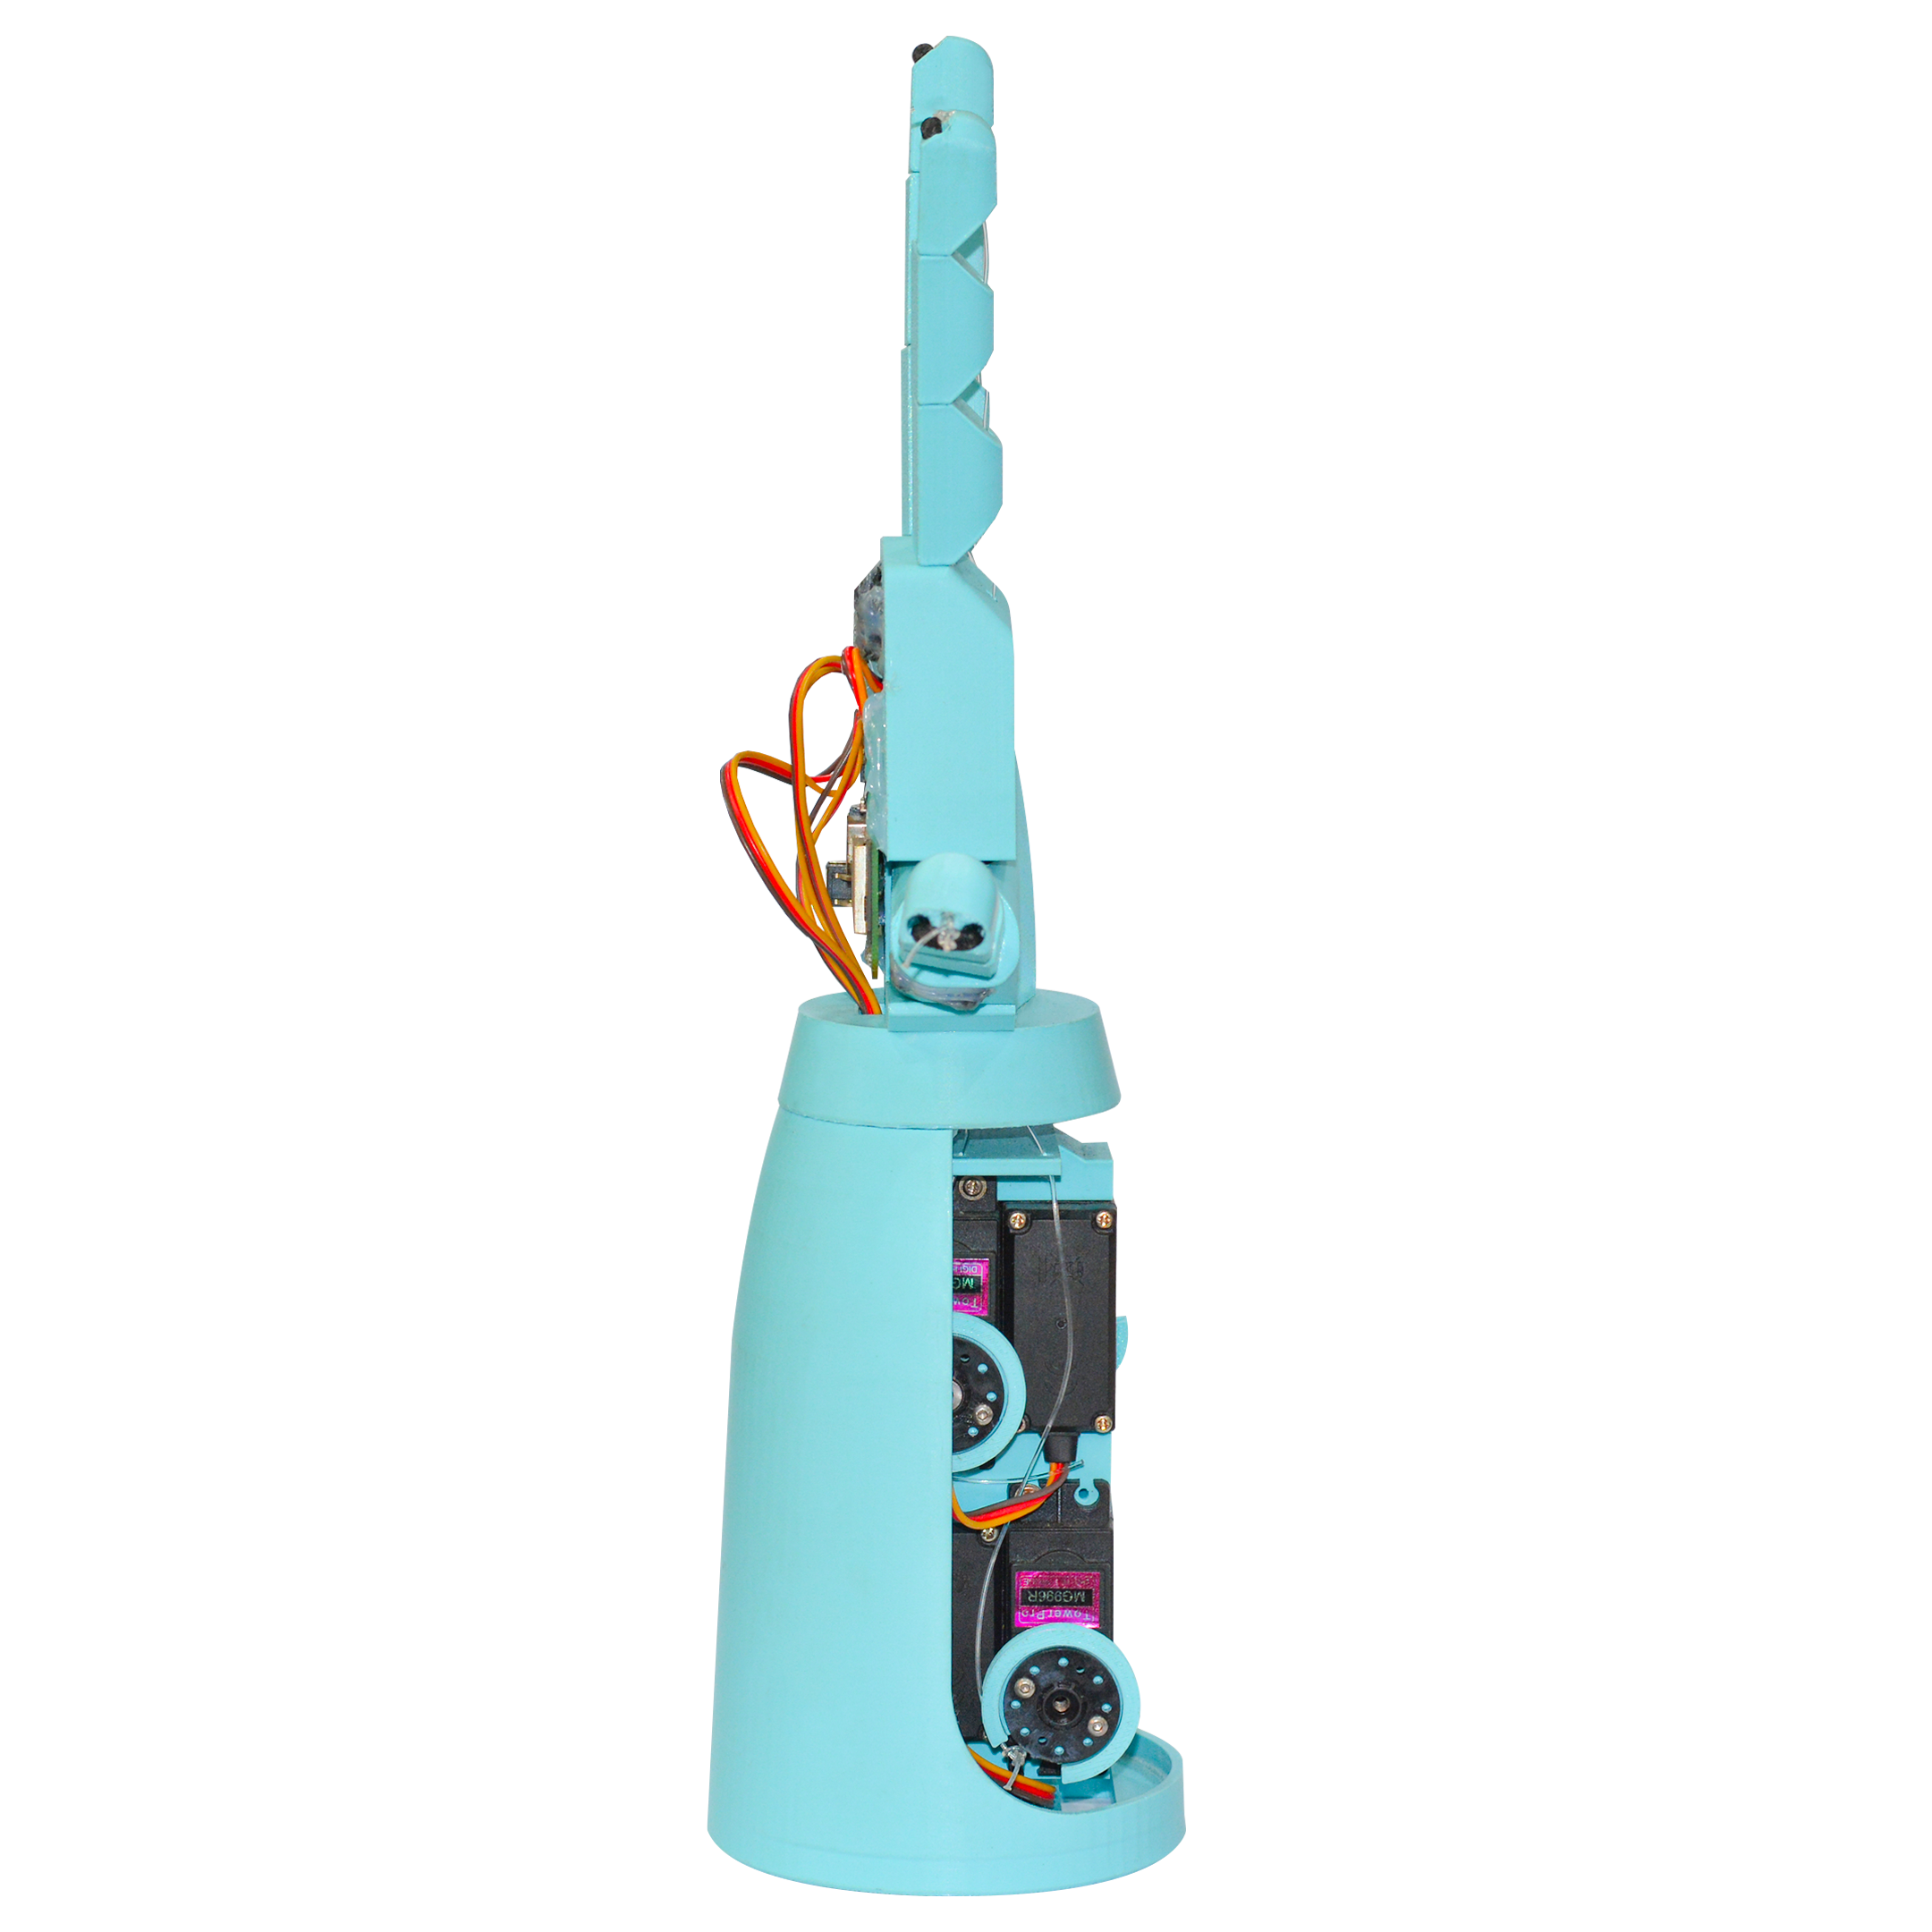
🖼️ Side profile
Real build 5
🔬 Sensor block close-up
Real build 6
🔗 Strap view

Live demo videos

If embeds do not autoplay in your viewer, use the direct links: Demo1.mp4 · Demo2.mp4.

Platform at a glance

LayerHighlights
🛠️ HardwareLow-noise EMG front-end, modular controller blocks, ready-to-manufacture assets, BOMs aligned to the photos you see.
🧠 FirmwareESP32 (ring + hand), FreeRTOS, NimBLE, OTA-ready, Line/Radar classifiers, servo current and motion guards to avoid stalls.
📱 AppFlutter UX for BLE JSON control, half-float EMG streaming, auto pair/connect, per-user calibration, and live plots.

Architecture snapshot

Signal path in two stages: capture and clean EMG on the ring, classify intent and drive actuators on the hand controller. Calibration data lives in the app and syncs over BLE when you change modes.
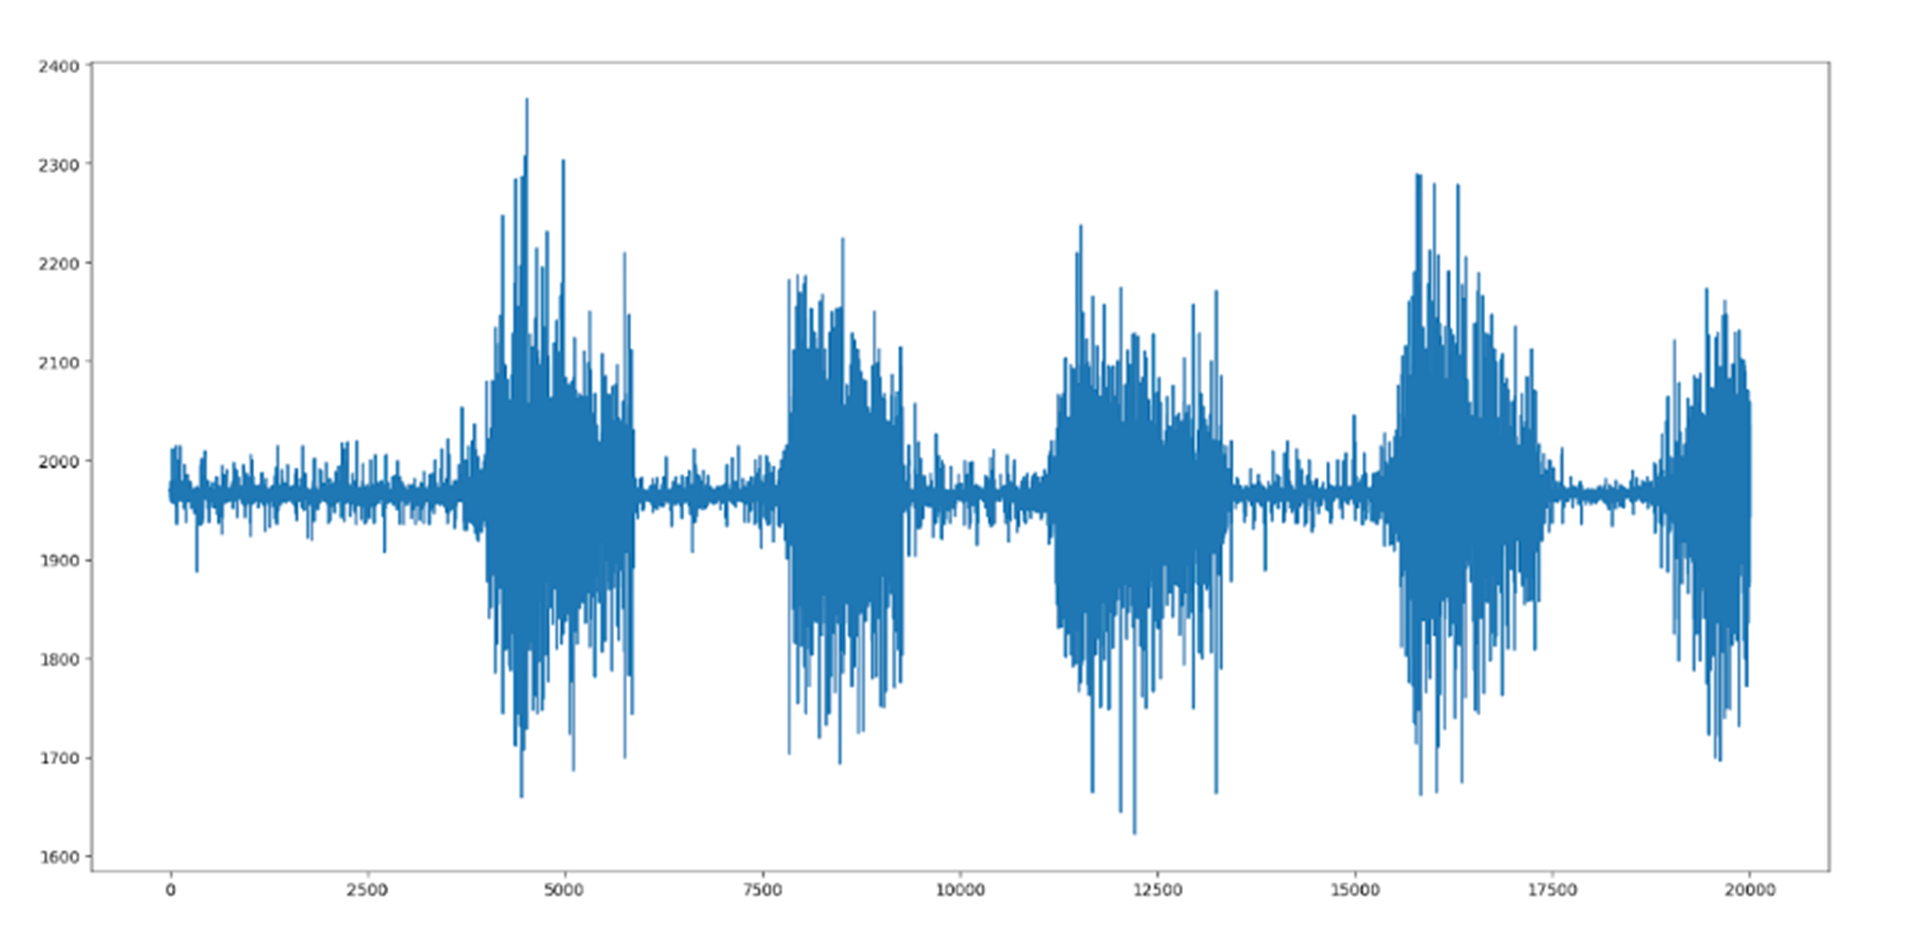
Raw EMG
⚡ Raw EMG capture
Line mode
🔎 Line thresholds
Radar mode
🔁 Radar/Spider matching
Detection percent
✅ Match confidence
Distance metric
➖ Similarity metric
App UI
📱 Flutter app in action

Deep dives

Fast start

  1. Fabricate / assemble: pick your board set from hardware; use the included Gerbers and assembly files to keep builds consistent with the photos.
  2. Flash firmware: open firmware/Embedded in VS Code + PlatformIO, select the target (ring/hand), and run pio run -t upload.
  3. Pair with the app: run the Flutter app (see app/README.md), scan and save Hand + MyoBand, then start EMG streaming.
  4. Calibrate deliberately: choose Line or Radar, adjust thresholds/templates, push to devices, and watch the live plots to confirm stability.
  5. Demo safely: use the stall/over-activity protections while you tune grip strength or motion ranges.

Tech highlights

  • Half-precision EMG streaming keeps BLE lean; float32 reconstruction happens in the app for analysis.
  • Dual control modes: Line (summed thresholds for fast response) and Radar/Spider (template similarity, ≥70% match) for finer intent mapping.
  • Safety nets: relax-before-use gating, over-activity clamps, current-based stall detection on servos, watchdog-backed tasks, and OTA hooks for quick fixes.
  • UX polish: LED/buzzer cues, auto reconnect, smoothed charts, per-grip calibration profiles, and JSON-based control that is easy to script.

Licence

This project is licensed under the GNU GPLv3.
Compared to permissive licences like MIT, GPLv3 requires that if you modify this code and distribute your version (including in commercial products), you must also release your changes under the same GPLv3 licence and provide the corresponding source code.

This way, everyone can benefit from improvements built on top of this project.
If this licence causes issues for your intended use, feel free to contact me – I’m open to discussing alternatives.

Thanks

Huge thanks to contributors, early testers, and the open-source toolchains that made this build possible. Enjoy hacking, and share what you build.

Parts

105
QtyValueFootprintReferences
1510KCapacitor_SMD:C_0402_1005MetricR9, R10, R11, R18, R31, R32, R33, R34, R35, R36, R44, R46, R47, R48, R49
13100nFCapacitor_SMD:C_0402_1005MetricC1, C4, C22, C30, C38, C39, C40, C42, C44, C45, C46, C49, C51
1010RCapacitor_SMD:C_0402_1005MetricR22, R23, R26, R27, R29, R30, R40, R41, R42, R43
74.7uFCapacitor_SMD:C_0402_1005MetricC2, C3, C23, C41, C43, C48, C50
747uFCapacitor_SMD:C_0805_2012MetricC5, C6, C7, C8, C31, C32, C36
50.1Resistor_SMD:R_2512_6332MetricR24, R25, R28, R37, R38
5Pad 3Pad:Pad 3U1, U8, U9, U10, U12
21uFCapacitor_SMD:C_0603_1608MetricC21, C25
222uFCapacitor_SMD:C_0603_1608MetricC20, C24
25.1KCapacitor_SMD:C_0402_1005MetricR3, R4
2D_SchottkyDiode_SMD:D_SOD-123D4, D5
2INA3221Package_DFN_QFN:Texas_RGV0016A_VQFN-16-1EP_4x4mm_P0.65mm_EP2.1x2.1mmU3, U4
2SS8050Package_TO_SOT_SMD:SOT-23Q2, Q3
2WS2812B2020WS2812B2020:LED_WS2812B2020D1, D2
10RCapacitor_SMD:C_0402_1005MetricR8
1100KCapacitor_SMD:C_0402_1005MetricR21
1102KCapacitor_SMD:C_0402_1005MetricR13
110nFCapacitor_SMD:C_0402_1005MetricC37
110uFCapacitor_SMD:C_0603_1608MetricC26
11uFCapacitor_SMD:C_0402_1005MetricC69
12.2nFCapacitor_SMD:C_0402_1005MetricC33
124KCapacitor_SMD:C_0402_1005MetricR5
128.7KCapacitor_SMD:C_0402_1005MetricR19
13.92KCapacitor_SMD:C_0402_1005MetricR16
1300KCapacitor_SMD:C_0402_1005MetricR20
1330RCapacitor_SMD:C_0402_1005MetricR12
136.5KCapacitor_SMD:C_0402_1005MetricR15
14.7KCapacitor_SMD:C_0402_1005MetricR7
14.7uFCapacitor_SMD:C_0603_1608MetricC27
147KCapacitor_SMD:C_0402_1005MetricR6
15.6nFCapacitor_SMD:C_0402_1005MetricC28
150KCapacitor_SMD:C_0402_1005MetricR17
182pFCapacitor_SMD:C_0402_1005MetricC29
1CP2102N-Axx-xQFN28Package_DFN_QFN:QFN-28-1EP_5x5mm_P0.5mm_EP3.35x3.35mmU2
1ESP32-WROOM-32D-N4RF_Module:ESP32-WROOM-32DU14
1FuseFuse:Fuse_1812_4532MetricF1
1LEDLED_SMD:LED_0805_2012MetricD3
1Pad_BatteryConnector_JST:JST_XH_B2B-XH-AM_1x02_P2.50mm_VerticalU7
1SPM10040T-3R3M-HZSPM10040T-3R3M-HZ:IND_SPM10040T-3R3M-HZL1
1SW_SPDTSamacSys:SS-12D06G5SW1
1TPS54620RGYRTPS54620RGYR:QFN50P350X350X100-15NU5
1USB_C_Receptacle_USB2.0_16PConnector_USB:USB_C_Receptacle_GCT_USB4105-xx-A_16P_TopMnt_HorizontalJ1
1XC6220B331MRPackage_TO_SOT_SMD:SOT-23-5U6

More from SonDinh23/EMGBand-HandBionic

2
  • 4 layers25 × 39 mmMyoband main, the printed circuit board in 3D

    Myoband main

    SonDinh23/EMGBand-HandBionic

    Full-stack 6-ch dry-electrode sEMG wearable (ESP32/BLE, 1 kHz/ch, JSON presets) with DC removal + HPF/LPF + Kalman DSP and dual-path gesture control (Amplitude thresholds + 6-ch Radar-shape matching) + Flutter app…

    92 parts5GPL-3.0
  • 4 layers16 × 28 mmEMG SENSOR, the printed circuit board in 3D

    EMG SENSOR

    SonDinh23/EMGBand-HandBionic

    Full-stack 6-ch dry-electrode sEMG wearable (ESP32/BLE, 1 kHz/ch, JSON presets) with DC removal + HPF/LPF + Kalman DSP and dual-path gesture control (Amplitude thresholds + 6-ch Radar-shape matching) + Flutter app…

    43 parts5GPL-3.0

Similar boards

  • 6 layers120.8 × 123.8 mmSocket370-motherboard, the printed circuit board in 3D

    Socket370-motherboard

    alphaonex86/FPGAmotherboard

    KiCad files of motherboards for original x86 CPUs, where an FPGA is the whole chipset: network-virtualised hard disk, NIC, a BIOS, no VGA.

    358 partsGPL-3.0
  • 2 layers43.6 × 43.6 mmEsp32 dron, the printed circuit board in 3D

    Esp32 dron

    Sagaz0501/esp32-drone

    PCB ESP32 quadcopter: KiCad hardware + Madgwick IMU firmware + WiFi web UI

    75 parts1MIT
  • 2 layers95 × 54 mmEsp smart clock, the printed circuit board in 3D

    Esp smart clock

    martinsram3k/Node-Smart-Clock

    The project blends modern electronics with premium natural materials:

    96 parts
  • 2 layers100 × 41 mmChessbot, the printed circuit board in 3D

    Chessbot

    vuktacic/chessler

    51 partsMIT
  • 2 layers160 × 110 mmPumpengruppe rs485, the printed circuit board in 3D

    Pumpengruppe rs485

    freezweb/de.freezweb.heizungssteuerung

    Dieses Verzeichnis enthaelt den KiCad-Startentwurf fuer die dezentrale Pumpengruppen-Platine:

    112 parts
  • 4 layers62 × 46.9 mm4LayerLabProject, the printed circuit board in 3D

    4LayerLabProject

    ZharbolatDinmukhamed/Haptic-Glove-PCB

    A wrist-mounted PCB for a haptic feedback glove, developed as part of my Research Assistantship at the Tactile Laboratory, Nazarbayev University.

    122 parts
  • 6 layers84 × 98 mmFujiNet-5200-Rev0, the printed circuit board in 3D

    FujiNet-5200-Rev0

    FujiNetWIFI/fujinet-hardware

    Schematics and design files for FujiNet hardware

    145 parts142
  • 2 layers34 × 96 mmGem solder, the printed circuit board in 3D

    Gem solder

    arlenko/gem-solder

    💎 DIY soldering iron controller

    114 parts12CERN-OHL-S-2.0

Questions

How big is the Hand main PCB?

It measures 70 × 45 mm and has 4 copper layers, 1.6 mm thick.

What parts does the Hand main use?

105 parts, built around the ESP32-WROOM-32D-N4, TPS54620RGYR, XC6220B331MR and SS8050. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.

Where can I download the Hand main KiCad files?

From the SonDinh23/EMGBand-HandBionic repository on GitHub, at the commit this page was made from: the board is hardware/Hand_main/Hand_main.kicad_pcb and its schematic hardware/Hand_main/Hand_main.kicad_sch. PCBKit opens the board in the browser, with nothing to install.

Can I use the Hand main design in my own project?

Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).