4 layers77.9 × 67.1 mm
R2-Dev Backplane
Manuvr/Digitabulum-Hardware
KiCAD source files for Manuvr's motion capture glove.
38 parts4
 Manuvr/Digitabulum-Hardware4
KiCAD source files for Manuvr's motion capture glove.
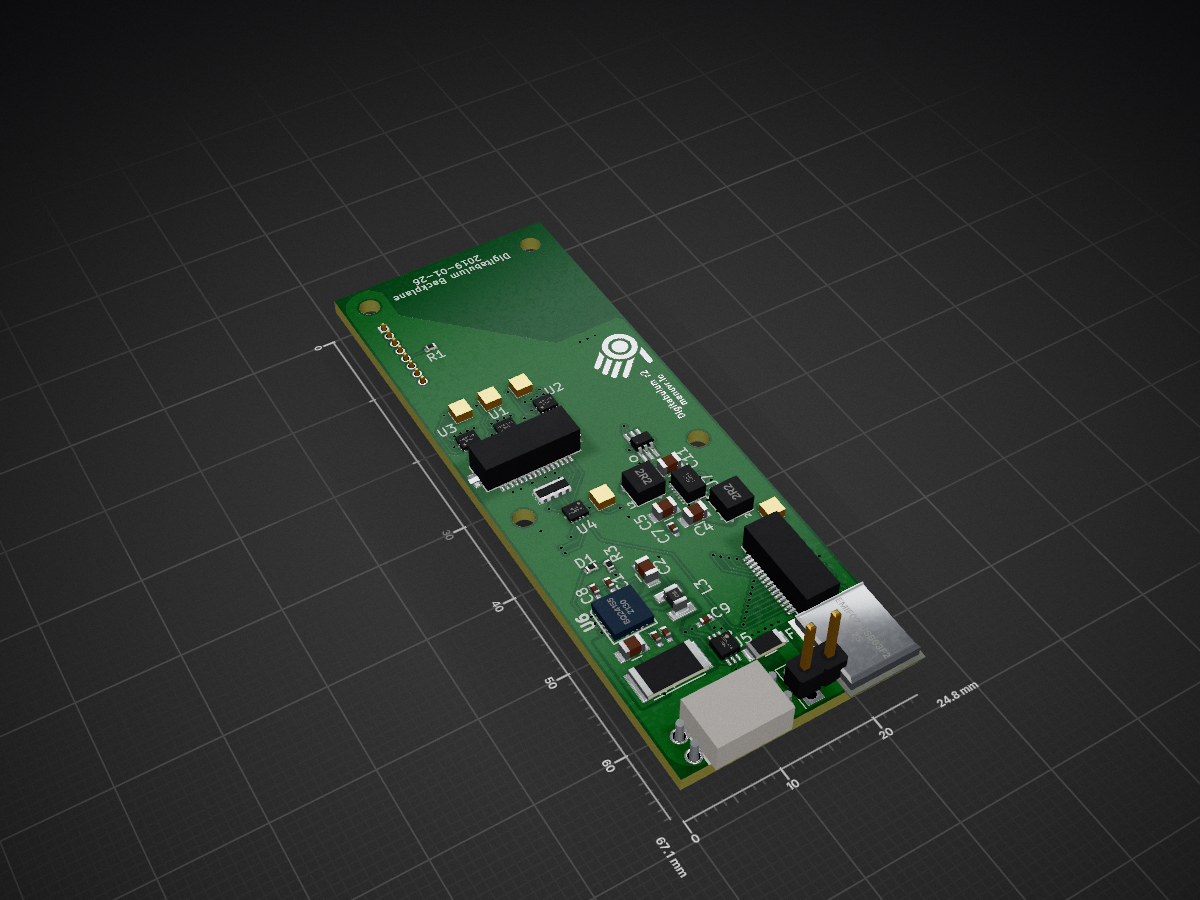
R2-Backplane is an open-source printed circuit board by Manuvr, from the Manuvr/Digitabulum-Hardware repository on GitHub. It is a 4-layer board of 24.8 × 67.1 mm with 47 parts on 72 nets, routed with 792 tracks and 137 vias.
It is built around the BQ24155RGY and EMIF02-USB03F2. Its parts include 12 capacitors, 8 ICs, 7 connectors, 3 resistors and 3 inductors.


This is a backplane PCB for Digitabulum. When combined with the PowerPlant, it has the same schematic as the r2-Backplane.
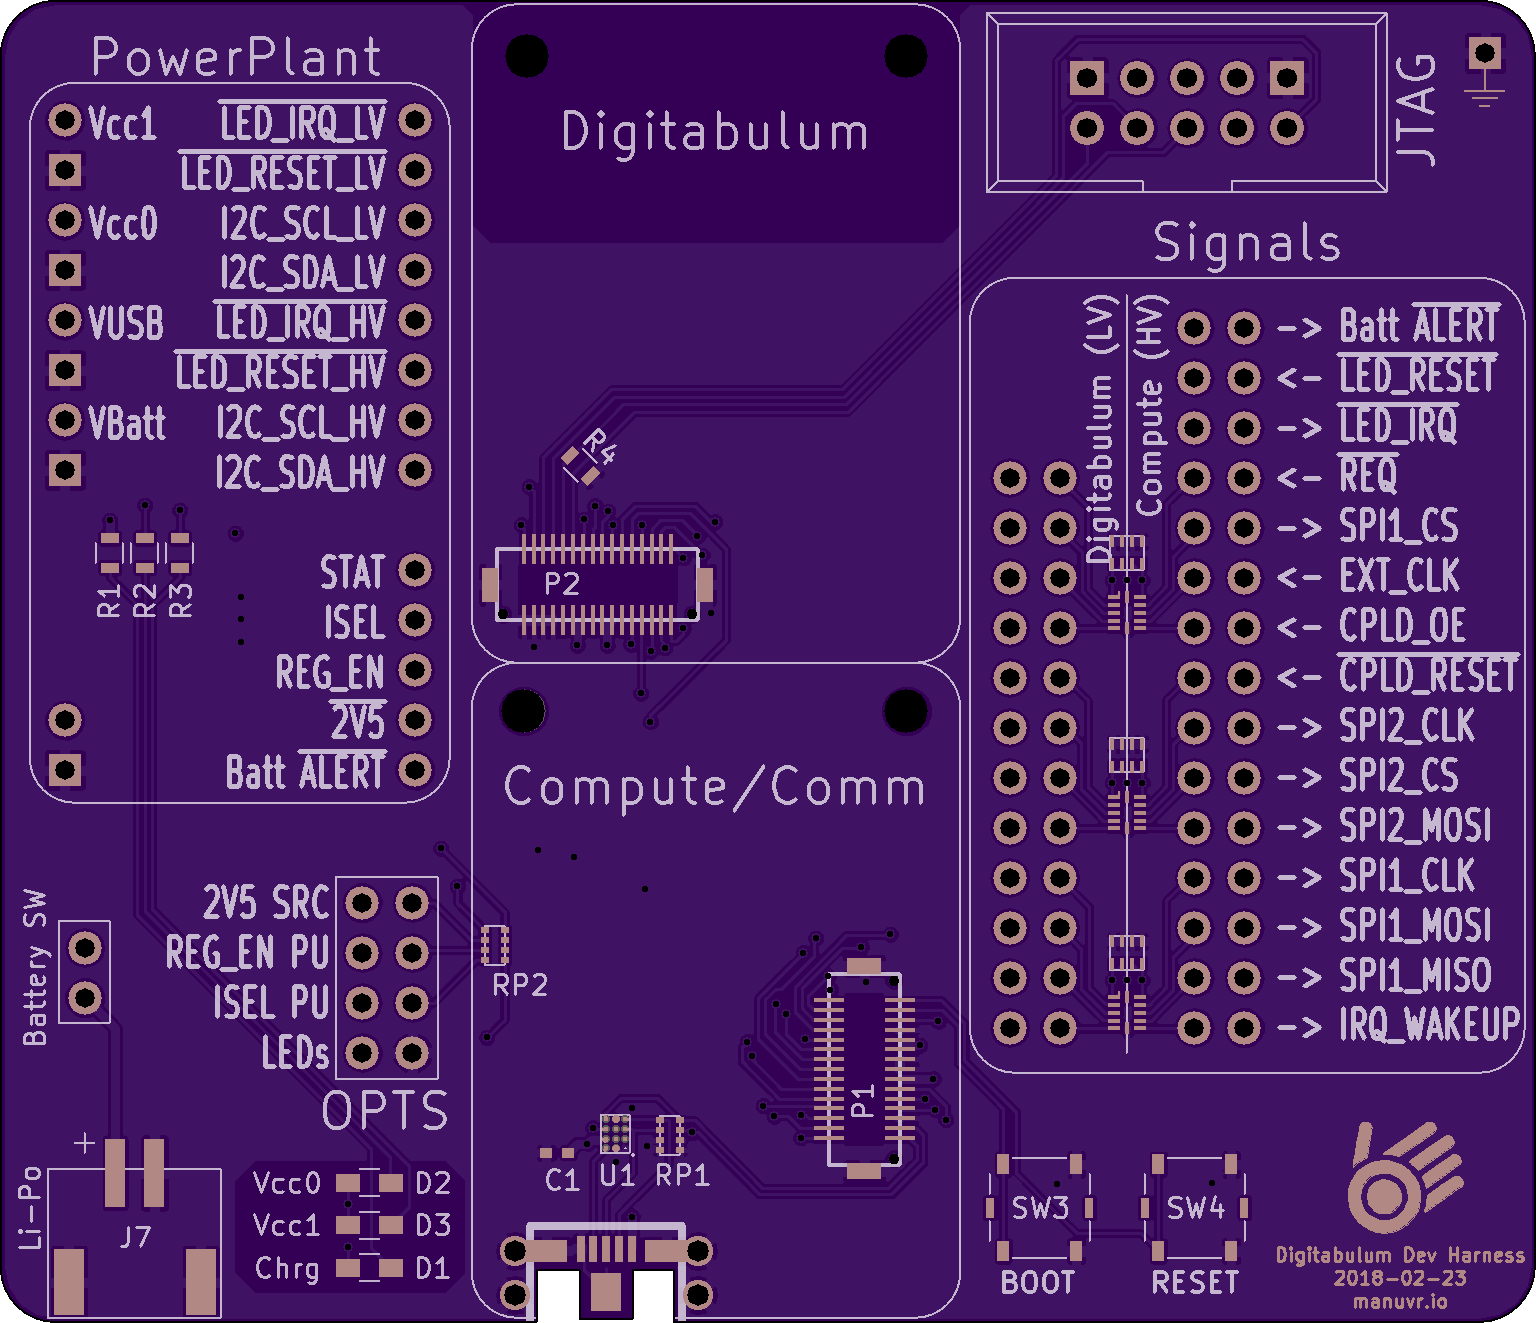
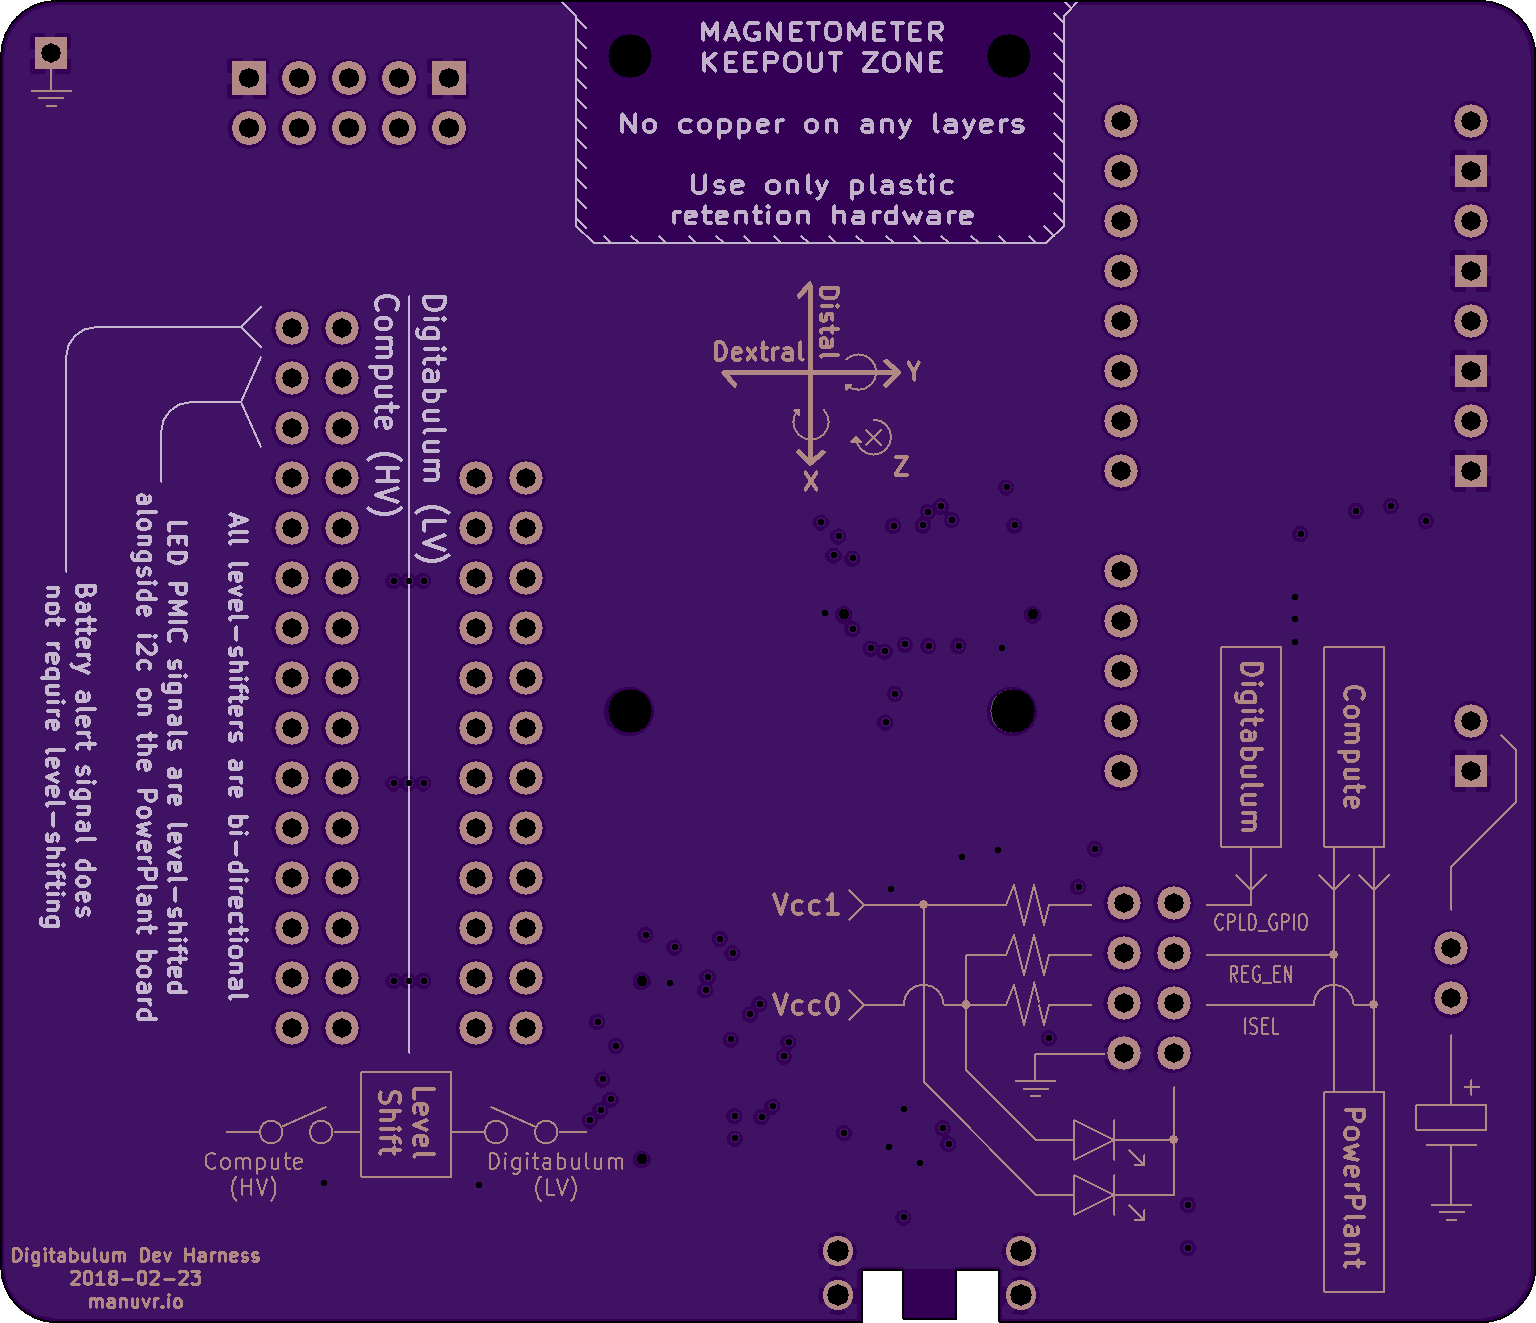
This board is intended as a testing harness for functional subunits designed for use with the Digitabulum sensor package. This would be the board you would want for prototyping new CPLD designs, power supplies, or compute modules.
If you do not want to do those things, but just want a working glove, you should use the r2-Backplane instead.
The CPLD GPIO pin has been routed to the 2v5/3v3 selection signal.
| Front | Back |
|---|---|
 |  |
| Qty | Value | Footprint | References |
|---|---|---|---|
| 5 | 100nF | r2Parts:CapArray_CKCL44 | CARY1, CARY2, CARY3, CARY4, CARY5 |
| 4 | LSF0204x | r2Parts:R-PUQFN-N12 | U1, U2, U3, U4 |
| 3 | 1uF | Capacitors_SMD:C_0402_NoSilk | C1, C3, C7 |
| 2 | 10uF | Capacitors_SMD:C_0805 | C5, C10 |
| 2 | 10uF | Capacitors_SMD:C_0402_NoSilk | C6, C9 |
| 2 | 1k | Resistors_SMD:R_0402_NoSilk | R1, R3 |
| 2 | 2.2uH | r2Parts:L-SMD | L1, L2 |
| 2 | 22uF | Capacitors_SMD:C_0805 | C4, C11 |
| 2 | CONN_01X01 | r2Parts:ManuvrLogo | P1, P1 |
| 2 | MountingHole_2.2mm_M2_DIN965 | Mounting_Holes:MountingHole_2.2mm_M2_DIN965 | MH2, MH3 |
| 1 | 0.1uF | Capacitors_SMD:C_0402_NoSilk | C12 |
| 1 | 10k | r2Parts:RES_4_EXBN8V | RP2 |
| 1 | 10nF | Capacitors_SMD:C_0402_NoSilk | C8 |
| 1 | 1A | Resistors_SMD:R_0805_HandSoldering | F1 |
| 1 | 1uH | Inductors_NEOSID:Neosid_Inductor_SM-NE29_SMD1008 | L3 |
| 1 | 22 | r2Parts:RES_4_EXBN8V | RP1 |
| 1 | 4.7uF | Capacitors_SMD:C_0805 | C2 |
| 1 | 68mOhm | Resistors_SMD:R_2512 | R4 |
| 1 | BQ24155 | r2Parts:BQ24155 | U6 |
| 1 | CONN_01X02 | Pin_Headers:Pin_Header_Straight_1x02_Pitch2.54mm | P2 |
| 1 | CONN_02X16 | r2Parts:DF12(3.0)-32DS-0.5V(86) | P3 |
| 1 | Charge | Resistors_SMD:R_0402_NoSilk | D1 |
| 1 | DEBUG | Pin_Headers:Pin_Header_Straight_1x08_Pitch1.27mm | P6 |
| 1 | EMIF02-USB03F2 | r2Parts:FCBGA12 | U8 |
| 1 | HiRose-02X15 | r2Parts:DF12(4.0)-30DS-0.5V(86) | P4 |
| 1 | LTC2942-1 | r2Parts:DFN-6-1EP_2x3mm_Pitch0.5mm | U5 |
| 1 | MH0 | Mounting_Holes:MountingHole_2.2mm_M2_DIN965 | MH0 |
| 1 | MH1 | Mounting_Holes:MountingHole_2.2mm_M2_DIN965 | MH1 |
| 1 | QA_NPN | TO_SOT_Packages_SMD:SOT-363_SC-70-6_Handsoldering | QA_NPN1 |
| 1 | SC283 | r2Parts:MLPQ-W18 (2mmx3mm) | U7 |
| 1 | USB-MICRO-B | iansModules:USB_ZX62WRD-B-5PC | CON1 |
Manuvr/Digitabulum-Hardware
KiCAD source files for Manuvr's motion capture glove.

Manuvr/Digitabulum-Hardware
KiCAD source files for Manuvr's motion capture glove.

Manuvr/Digitabulum-Hardware
KiCAD source files for Manuvr's motion capture glove.

Manuvr/Digitabulum-Hardware
KiCAD source files for Manuvr's motion capture glove.

Manuvr/Digitabulum-Hardware
KiCAD source files for Manuvr's motion capture glove.


Manuvr/Digitabulum-Hardware
KiCAD source files for Manuvr's motion capture glove.

EPFLXplore/XRE_LeggedRobot_HW
PCB designs for Xplore Research's robot dog project


loudifier/OpenRefMic
open hardware design for a high-performance low-cost measurement microphone


rjwalters/kicad-tools
Standalone Python tools for parsing and manipulating KiCad schematic and PCB files

It measures 24.8 × 67.1 mm and has 4 copper layers, 1.6 mm thick.
47 parts, built around the BQ24155RGY and EMIF02-USB03F2. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Manuvr/Digitabulum-Hardware repository on GitHub, at the commit this page was made from: the board is r2-Backplane/r2-Backplane.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask Manuvr before reusing the design.