2 layers101.6 × 53.3 mm
MegaShield
LukeZhang0826/RescueRobot
Autonomous line-following rescue robot built for a competition at Waterloo's IDEAS Clinic. Raspberry Pi Pico and Arduino Mega, Pixy2 vision, custom KiCad PCBs.
24 parts

 LukeZhang0826/RescueRobot
Autonomous line-following rescue robot built for a competition at Waterloo's IDEAS Clinic. Raspberry Pi Pico and Arduino Mega, Pixy2 vision, custom KiCad PCBs.
PCBA Board is an open-source printed circuit board by LukeZhang0826, from the LukeZhang0826/RescueRobot repository on GitHub. It is a 2-layer board of 52 × 57.8 mm with 33 parts on 54 nets, routed with 171 tracks and 45 vias.
It is built around the DRV8833RTYR, TPS54331D and AO3400A, with the SS24 among its other parts. Its parts include 12 capacitors, 7 resistors, 7 connectors, 2 ICs and 2 transistors. It belongs with the robots and motor control boards and the RP2040 boards of this library.


An autonomous line-following rescue robot, built for a competition at the University of Waterloo's IDEAS Clinic. It follows a track, finds a coloured target, picks it up with a servo claw, carries it to a safe zone, drops it, then finds the line again and drives back.
We called it Hamster, which is why the robot code lives in Hamster/.
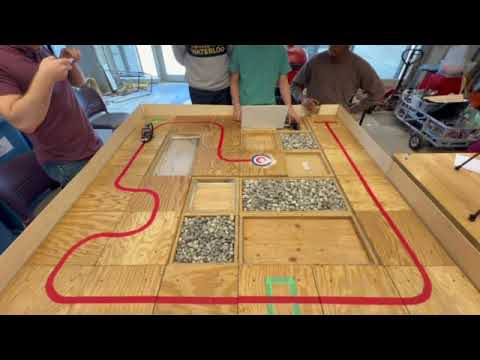
Built by Josh Lobe, Koketso Gaborekwe, Luke Zhang, Winters Xia, and Griffin Wilson.
Hamster/robot_mission.py is a flat state machine. A button press starts it, and every
stage either advances or drops into an error state.
idle -> search_line_follow -> approach_target -> pickup -> holding_object
     -> turn_around -> rescue_line_follow -> approach_safe_zone -> release
     -> find_line -> return_line_follow -> done
Three separate line followers exist because each leg of the run has different exit
conditions. search_line_follower stops when the target is large enough in frame,
rescue_line_follower stops on the safe zone signature, and return_line_follow runs
the trip home. All three share a PD steering loop over the Pixy2 line centroid, with a
recovery state that turns back toward the side the line was last seen on.
| Part | Notes |
|---|---|
| Raspberry Pi Pico | Runs the MicroPython mission code in Hamster/ |
| Arduino Mega 2560 | PlatformIO firmware in firmware/, used for board bring-up |
| Pixy2 camera | Line tracking and colour connected component detection, 7 signatures |
| DRV8833 | Dual motor driver, signed speed from -100 to +100 |
| Servo claw | Pickup and release |
| Custom PCBs | An Arduino Mega shield and a base board, KiCad sources in Electrical/ |
Both PCBs were manufactured through JLCPCB. Gerbers, BOM, and pick-and-place files are
committed under Electrical/KiCad/BasePCB/jlcpcb/.
| Path | What it is |
|---|---|
Hamster/ | MicroPython mission code for the Pico |
Hamster/archive/ | Superseded scripts kept from earlier milestones |
Hamster/pixycamParams/ | Saved Pixy2 tuning, including the values used on the day |
firmware/ | PlatformIO project for the Arduino Mega |
Electrical/KiCad/ | KiCad projects, gerbers, and production files |
The Pico code is deployed with the MicroPico VS Code extension. Copy the contents of
Hamster/ to the board and reset it. Hamster/main.py wires up the hardware objects and
hands control to RobotMission.run_once(), which waits for the start button.
Everything the robot is tuned by lives in Hamster/config.py, including the PI gains per
wheel, the PD steering constants, base speeds in RPM, and the Pixy2 area thresholds that
decide when a target is close enough to stop. The competition values are the ones
currently committed.
For the Arduino side, cd firmware && pio run -t upload.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 2 | 100k | Resistor_SMD:R_0805_2012Metric | R2, R7 |
| 2 | 4.7uF | Capacitor_SMD:C_1210_3225Metric | C1, C2 |
| 2 | 47u | Capacitor_SMD:C_1210_3225Metric | C8, C9 |
| 2 | AO3400A | Package_TO_SOT_SMD:SOT-23 | Q1, Q2 |
| 1 | 0.01u | Capacitor_SMD:C_0402_1005Metric | C10 |
| 1 | 0.01uF | Capacitor_SMD:C_0805_2012Metric | C3 |
| 1 | 1.96k | Resistor_SMD:R_0603_1608Metric | R4 |
| 1 | 10.2k | Resistor_SMD:R_0603_1608Metric | R3 |
| 1 | 100nF | Capacitor_SMD:C_0805_2012Metric | C5 |
| 1 | 10pF | Capacitor_SMD:C_0805_2012Metric | C7 |
| 1 | 10u | Capacitor_SMD:C_1210_3225Metric | C11 |
| 1 | 1nF | Capacitor_SMD:C_0603_1608Metric | C6 |
| 1 | 2.2u | Capacitor_SMD:C_0402_1005Metric | C12 |
| 1 | 330K | Resistor_SMD:R_0603_1608Metric | R6 |
| 1 | 4.7u | Inductor_SMD:L_APV_ANR6028 | L1 |
| 1 | 570K | Resistor_SMD:R_0603_1608Metric | R5 |
| 1 | 66.5k | Resistor_SMD:R_0603_1608Metric | R1 |
| 1 | 8.2nF | Capacitor_SMD:C_0603_1608Metric | C4 |
| 1 | Batt_1 | Connector_JST:JST_PH_B2B-PH-SM4-TB_1x02-1MP_P2.00mm_Vertical | J1 |
| 1 | Batt_2 | Connector_JST:JST_PH_B2B-PH-SM4-TB_1x02-1MP_P2.00mm_Vertical | J2 |
| 1 | DRV8833RTY | Package_DFN_QFN:Texas_RTY_WQFN-16-1EP_4x4mm_P0.65mm_EP2.1x2.1mm_ThermalVias | U1 |
| 1 | MotorA | Connector_JST:JST_SH_BM06B-SRSS-TB_1x06-1MP_P1.00mm_Vertical | J3 |
| 1 | MotorB | Connector_JST:JST_SH_BM06B-SRSS-TB_1x06-1MP_P1.00mm_Vertical | J4 |
| 1 | Pixy SPI Connection | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J5 |
| 1 | RaspberryPi_Pico_W | Module:RaspberryPi_Pico_W_SMD_HandSolder | A1 |
| 1 | SS24 | Diode_SMD:D_SMA | D2 |
| 1 | ServoA | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J6 |
| 1 | ServoB | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J7 |
| 1 | TPS54331 | Package_SO:TI_SO-PowerPAD-8_ThermalVias | U2 |
LukeZhang0826/RescueRobot
Autonomous line-following rescue robot built for a competition at Waterloo's IDEAS Clinic. Raspberry Pi Pico and Arduino Mega, Pixy2 vision, custom KiCad PCBs.

LukeZhang0826/RescueRobot
Autonomous line-following rescue robot built for a competition at Waterloo's IDEAS Clinic. Raspberry Pi Pico and Arduino Mega, Pixy2 vision, custom KiCad PCBs.

phonght32/OpenDrone_HW_Transmitter_F103
OpenDrone Project - Transmitter hardware using STM32F103.

henrikssn/TurboCAN
This is the official repository for the TurboCAN controller board, designed specifically for the Voron AfterBurner toolhead but can also be used on similar toolheads using NEMA17 steppers.


m47812/Custom-3D-Printer-Controller
A fully custom 3D Printer controller board based on an stm32f7 controller with TMC2209 stepper drivers


punkfab/pcb-corpus
235 real KiCad boards from open-source hardware repositories, prepared as a placement and routing benchmark


It measures 52 × 57.8 mm and has 2 copper layers, 1.6 mm thick.
33 parts, built around the DRV8833RTYR, TPS54331D, AO3400A and SS24. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the LukeZhang0826/RescueRobot repository on GitHub, at the commit this page was made from: the board is Electrical/KiCad/PCBA_Board/PCBA_Board.kicad_pcb and its schematic Electrical/KiCad/Arduino Mega Shield/Arduino Mega Shield.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask LukeZhang0826 before reusing the design.