

2 layers62.9 × 32.4 mm
Volume AlpsRK16814MG
mithat/Volume-AlpsRK16814MG
Alps RK16814MG motorized potentiometer with H-bridge motor drive.
12 parts6

Motor drivers for F^3RC.
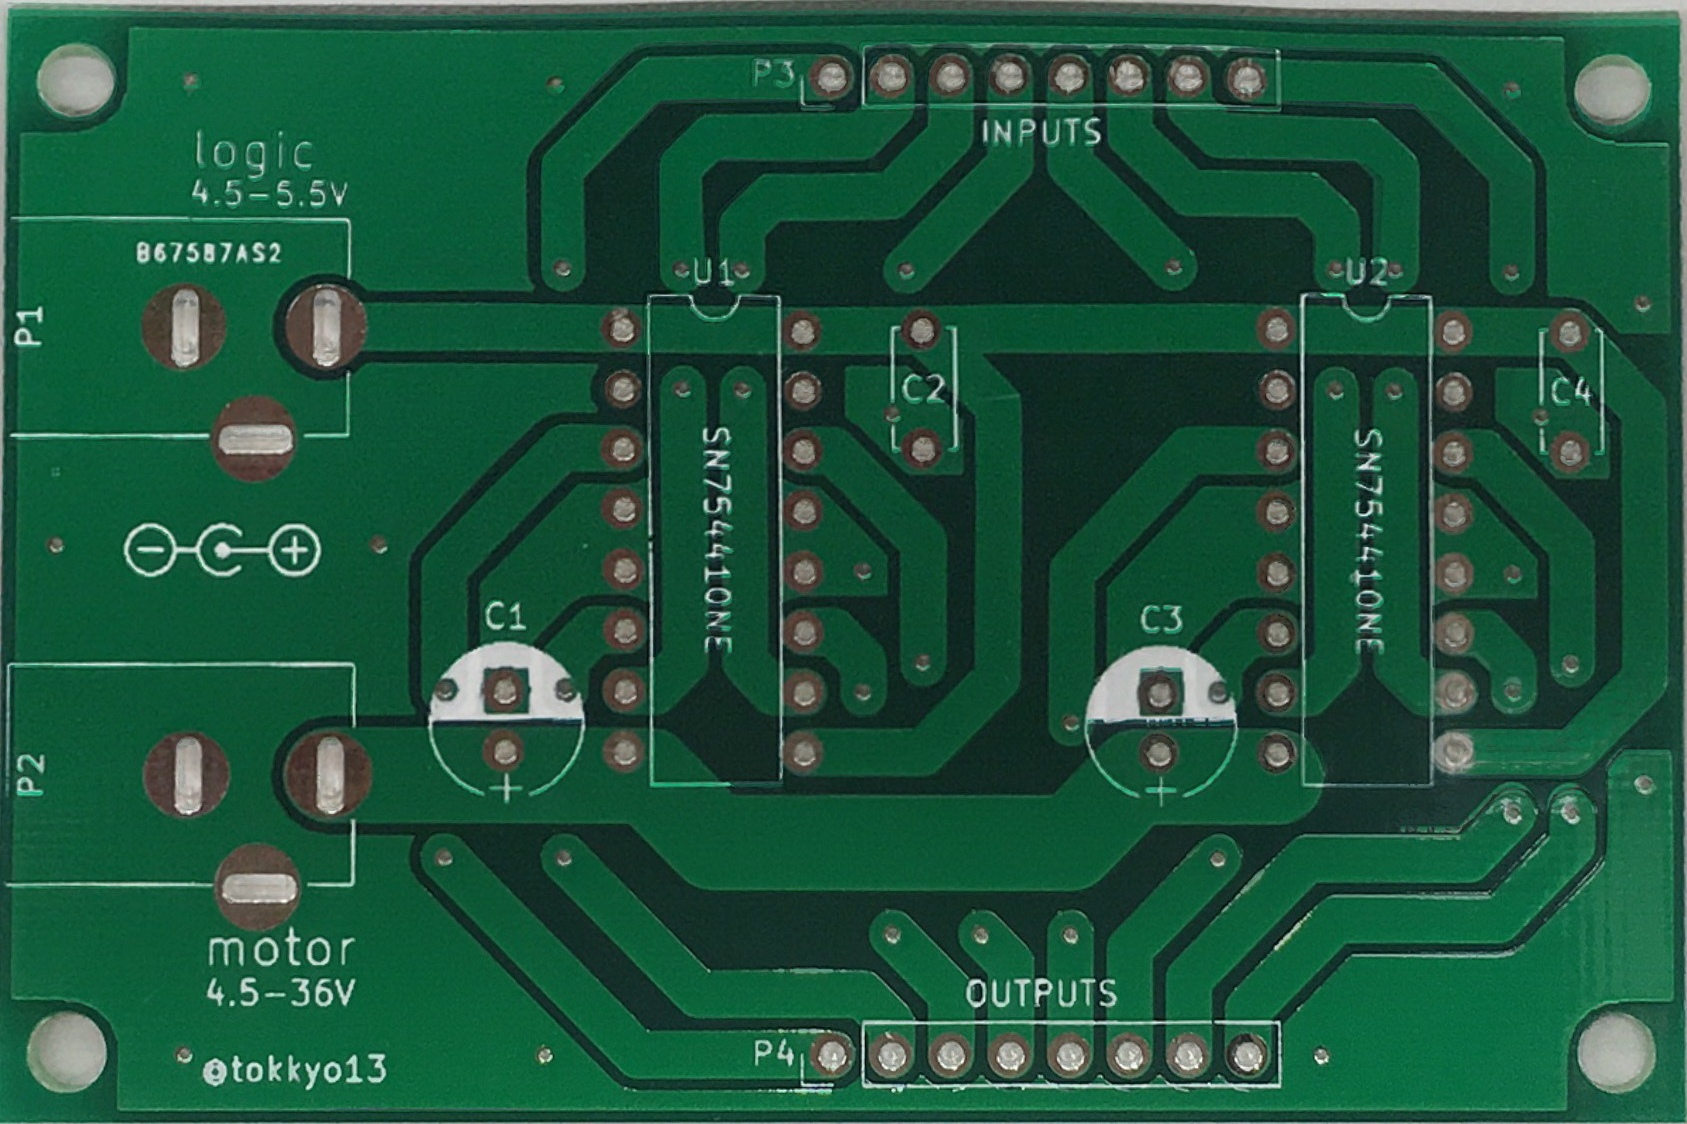
Mtdr S is an open-source printed circuit board by KeioRoboticsAssociation, from the KeioRoboticsAssociation/F-3RC_MD repository on GitHub. It is a 2-layer board of 72 × 47 mm with 14 parts on 19 nets, routed with 177 tracks and 42 vias.
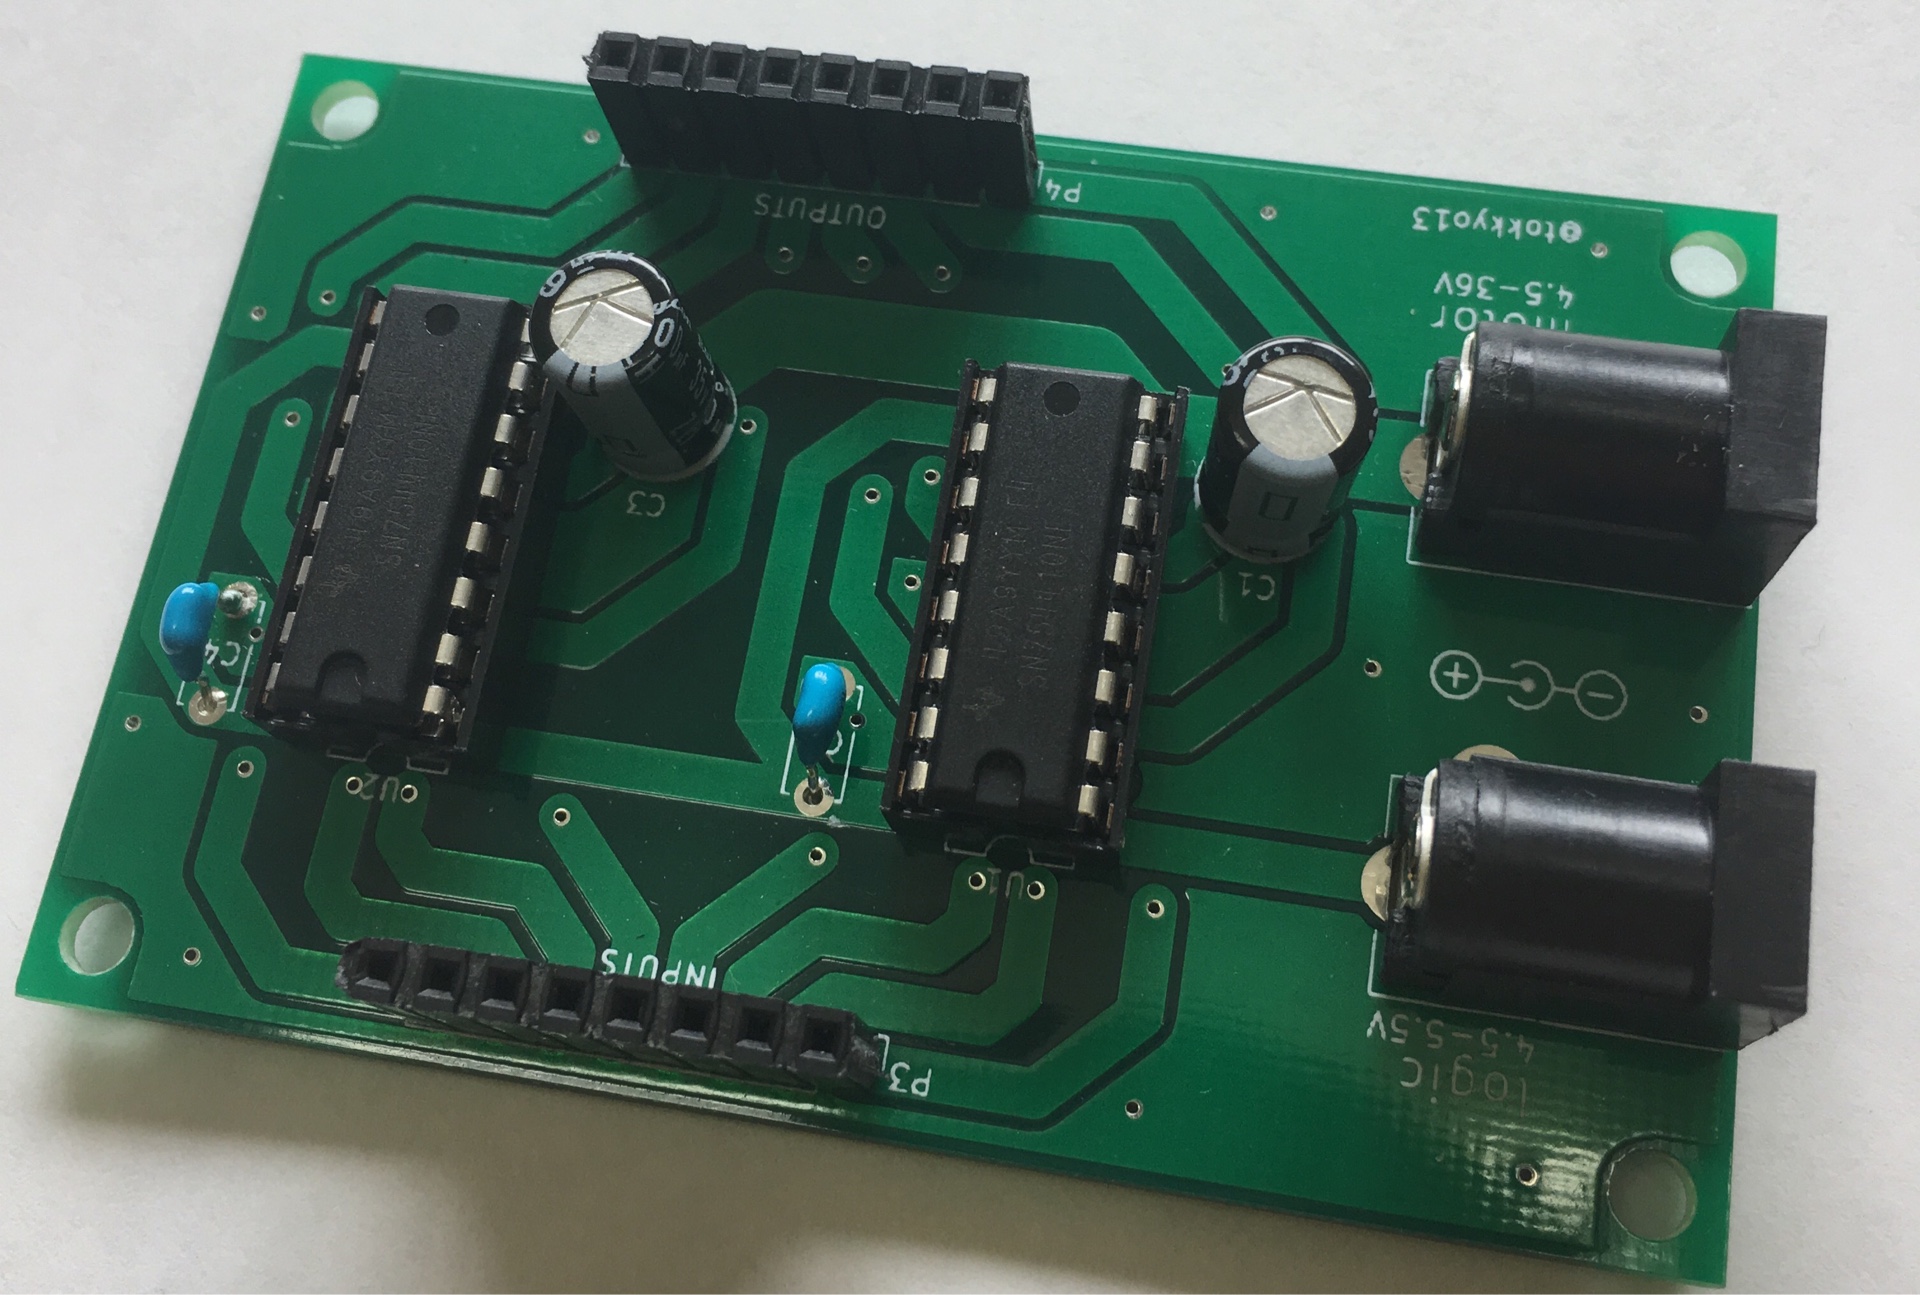
It is built around the SN754410NE. Its parts include 4 capacitors, 4 connectors and 2 ICs. It belongs with the robots and motor control boards of this library.
モータードライバは壊れやすい。そのたびにユニバーサル基板で作りなおすと 結構キツい。それに大会間近に故障で試験走行ができない時間ができると 超もったいない。どうせ同じものを複数個作るなら、プリント基板でキット化して、 ドライバ故障→交換までのストレスを減らそう!ってこと。それだけ。 一応、1年生が参加することになってるF^RC用に使うことを考えて始めた計画だけど、 あとに書くスペックを見て、自分の要求を満たしているならなんでも使えると思う。
詳しいことはデータシートを読んだ方がいいと思うので、使う上で必要そうなこと だけをまとめておく。
| 場所 | 特性 |
|---|---|
| ロジック電源 | 4.5〜5.5V(2.1mm標準DCコネクタ) |
| モーター電源 | 4.5〜36V(2.1mm標準DCコネクタ) |
| 出力 | ピンヘッダ or ピンソケット1x8 |
| 入力 | デジタル入力・PWM(High=2〜5.5V、Low=-0.3〜0.8V、ピンソケット) |
ICひとつにハーフブリッジ回路が4つ入っている。モーターを正転・逆転させたい、 またはブレーキをかけたい場合はICひとつでモーター2個駆動できる。また、モーターを 一方向にしか回さない、かつブレーキはいらない場合はICひとつで モーター4個駆動できる。ここで注意してほしいのは、 「ブレーキがかけられない≠止まらない」だということ (モーターの電源を切ればしばらく走って止まる)。
INPUTピンの番号は、左(DCコネクタがある方)から順にA1, A2, A3, A4, A1, A2, A3, A4 になっている。同様にOUTPUTピンの番号はY1, Y2, Y3, Y4, Y1, Y2, Y3, Y4になっている。 AピンとYピンは1対1対応してる。入力AがHighなら向かい合う出力YもHigh。 Lowの場合も同じ。詳しくはデータシートの図を見てほしい。
ちなみにENピンはICに含まれる回路の半分だけ電源を切りたいときとかに使える ようだが、このプリント基板では常にHighになるよう設計されている。
| 番号(基板に書いてある) | 部品名(秋月のホームページとかで調べて) | 個数 | 備考 |
|---|---|---|---|
| P1, P2 | 基板取り付け用DCジャック | 2 | センタープラス(中心の棒プラス)だよ。 |
| P3, P4 | ピンヘッダ or ピンソケット1x8 | 2 | 挿す方でも挿される方でもご自由に。 |
| C1, C3 | 電解コンデンサ(100μF 35V) | 2 | 直径6.3mm以上のコンデンサだと周りの部品に干渉するかも。足の長い方がプラスに繋がる。 |
| C2, C4 | 積層セラミックコンデンサ(0.4μF 50V) | 2 | |
| U1, U2 | モータードライバIC(SN754410NE) | 2 | 実際はんだ付けするのはICソケット(16P)にした方がいいよ。 |
| Qty | Value | Footprint | References |
|---|---|---|---|
| 3 | MountingHole_3.2mm_M3 | Mounting_Holes:MountingHole_3.2mm_M3 | , , |
| 2 | 0.1uF | Capacitors_ThroughHole:C_Disc_D5.0mm_W2.5mm_P5.00mm | C2, C4 |
| 2 | 100uF | Capacitors_ThroughHole:CP_Radial_D6.3mm_P2.50mm | C1, C3 |
| 2 | SN754410NE | Housings_DIP:DIP-16_W7.62mm | U1, U2 |
| 1 | Connect:BARREL_JACK | P1 | |
| 1 | Mounting_Holes:MountingHole_3.2mm_M3 | ||
| 1 | INPUTS | Pin_Headers:Pin_Header_Straight_1x08_Pitch2.54mm | P3 |
| 1 | OUTPUTS | Pin_Headers:Pin_Header_Straight_1x08_Pitch2.54mm | P4 |
| 1 | Vmtr | Connect:BARREL_JACK | P2 |
mithat/Volume-AlpsRK16814MG
Alps RK16814MG motorized potentiometer with H-bridge motor drive.


PatriceG/ArduiBodet
Horloge mère pour Horloge de type Bodet pilotée par Arduino

anorimaki/selfbalancing-robot
A buck converter to generate the 5V power rail would have been a better choice because it would be more efficient (extending battery life) and eliminate the need of a second battery (the circuit could be plugged with…


kashishkebab9/omni-mapper
Omni-Wheeled Robot with custom PCB All Mechanical Assemblies, PCBs, Firmware, and Software designed, architected and programmed by Kashish Garg

losonczylab/Hardware
Includes AutoDesk Inventor projects used for lab rigs and other miscellaneous CAD files.

It measures 72 × 47 mm and has 2 copper layers, 1.6 mm thick.
14 parts, built around the SN754410NE. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the KeioRoboticsAssociation/F-3RC_MD repository on GitHub, at the commit this page was made from: the board is mtdr_S/mtdr_S.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask KeioRoboticsAssociation before reusing the design.