
2 layers132.3 × 94.9 mm

 DrJonEA/RexP1-Drive-Wheel1
Drive wheel for my RexP1 Astro Droid Project based on a RP2040Zero board
RexP1-Wheel is an open-source printed circuit board by DrJonEA, from the DrJonEA/RexP1-Drive-Wheel repository on GitHub, published under the MIT licence. It is a 4-layer board of 42.9 × 42.7 mm with 15 parts on 32 nets, routed with 165 tracks and 1 via.
It is built around the RP2040-ZERO. Its parts include 2 connectors, 1 capacitor, 1 resistor and 1 switch. It belongs with the RP2040 boards of this library.
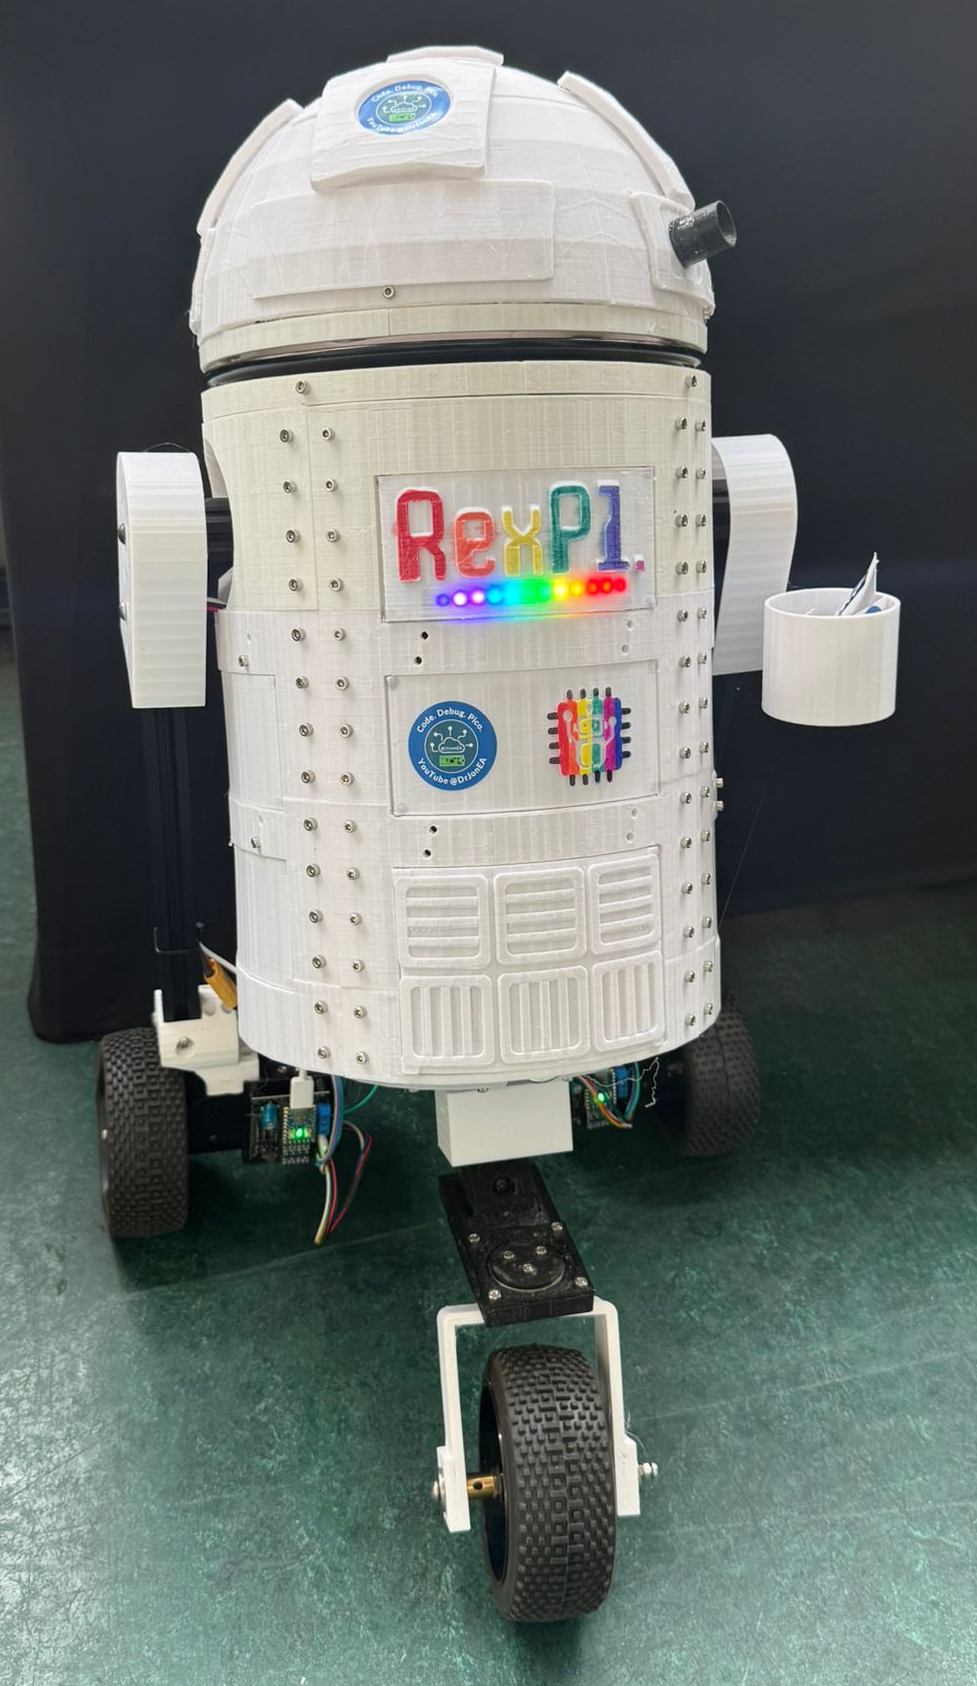 Drive wheel for my RexP1 Astro Droid Project based on a RP2040Zero board. This Repo repreents the drive wheel subsystem for RexP1.
Checkout the videos guides to the project over on my YouTube Channel DrJonEA.
RexP1 is a reimagined Star War's inspired Astro Droid based on the R series Droids. It is based on Raspberry PI 5, RP2040 and RP2350 boards. It's control system is a distributed net based on ROS2 and MicroROS frameworks.
All my work on RexP1 is available to my sponsors. That includes not just this submodule but all the submodules, the build instructions, PCB designs, STL files, CAD designs and most important acess to me to ask questions. Take a look at the sponsorship button on the github repo.
This repo includes the PCB design for the drive wheels and assoicated documentation. It also includes the firmware for a RP2040Zero which acts as a ROS2 Node to control the Wheel and some other sensors.
Note libraries have not been included as submodules in this repo. That is because I wanted just a single copy of the libraries in the master repo for RexP1. So take note of the lib documentation.
The firmware should build like most complex Pico SDK firmware projects. Normal procedure:
mkdir build
cd build
cmake ..
make
If you have ninja use that instead of make for Windows. Just make sure you update the CMakelists.txt to point to your libraries and that the environment variable PICO_SDK_PATH is defined to point to the SDK.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 6 | Conn_01x04_Pin | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | HCSR04-1, HCSR04-2, HCSR04-3, L298N1, WS2812B-1, WS2812B-2 |
| 1 | 220R | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R1 |
| 1 | 470uF | Capacitor_THT:CP_Radial_D10.0mm_P5.00mm | C1 |
| 1 | Conn_01x04_Socket | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | ADT1 |
| 1 | Conn_01x06_Pin | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | Motor1 |
| 1 | RP2040-Zero | RP2040-Zero-Kicad:RP2040-Zero | RZ1 |
| 1 | SPARKFUN_LOGIC_LEVEL_CONVERTER | SparkFunBoards:SPARKFUN_LOGIC_LEVEL_CONVERTER | B1 |
| 1 | SW_SPST | Button_Switch_THT:SW_PUSH_6mm_H8.5mm | SW1 |
| 1 | Screw_Terminal_01x03 | SparkFunConnectors:SCREWTERMINAL-5MM-3 | J2 |
| 1 | Uart0 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J3 |


beekeeb/zerosprey42
Zerosprey42 Keyboard is a wired, beginner friendly, choc hotswap, MonoBlockSplit (Unibody), column-staggered, DIY mechanical keyboard.


ravinrabbid/DonCon2040
RP2040 based firmware and hardware for DIY Taiko no Tatsujin Drum Controllers
nmur/RP2040-TestPatternGenerator
A simple test pattern generator running on the RP2040 microcontroller

ChrisChrisLoLo/bunchiez40
A pocket keyboard that makes use of mouse switches to achieve a miniscule size

It measures 42.9 × 42.7 mm and has 4 copper layers, 1.6 mm thick.
15 parts, built around the RP2040-ZERO. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the DrJonEA/RexP1-Drive-Wheel repository on GitHub, at the commit this page was made from: the board is pcb/RexP1-Wheel/RexP1-Wheel.kicad_pcb and its schematic pcb/RexP1-Wheel/RexP1-Wheel.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).