2 layers59.1 × 99.9 mm
Cheap FOCer 2 60mm
shamansystems/Cheap-FOCer-2
Low-Cost Motor Controller based on the VESC 6
193 parts407

 zischl/ZAIR
MicroMouse Build !
ZAIR is an open-source printed circuit board by zischl, from the zischl/ZAIR repository on GitHub. It is a 2-layer board of 77 × 115 mm with 68 parts on 82 nets, routed with 781 tracks and 87 vias.
It is built around the STM32F405RGT6 and AMS1117-3.3. Its parts include 23 resistors, 13 capacitors, 10 transistors, 8 diodes and 7 ICs. It belongs with the STM32 boards of this library.


A custom 4WD vacuum micromouse built for the Sri Lanka IIT Micro Maze 3.0 competition (IEEE 16×16).
The PCB also serves as the robot's structural chassis, with cutouts for the drive wheels and a central aperture for a 1020 coreless motor suction fan.
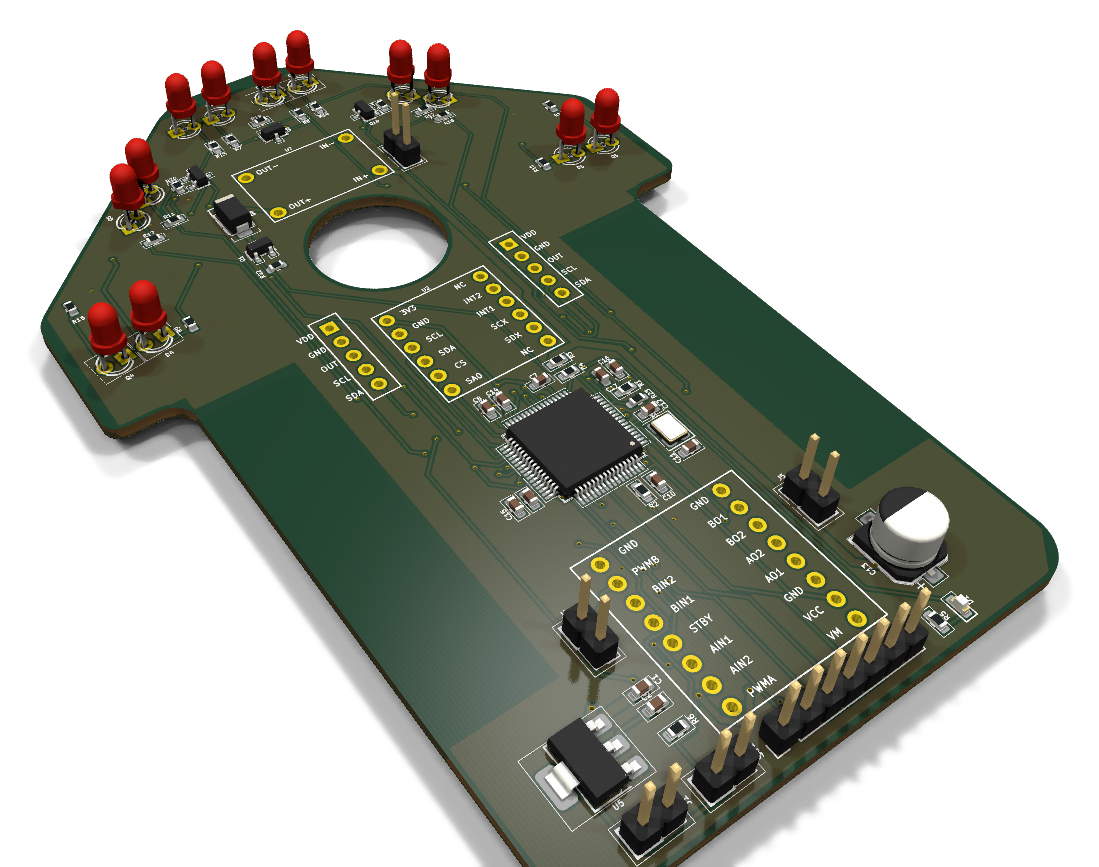
| Top (Components) | Bottom |
|---|---|
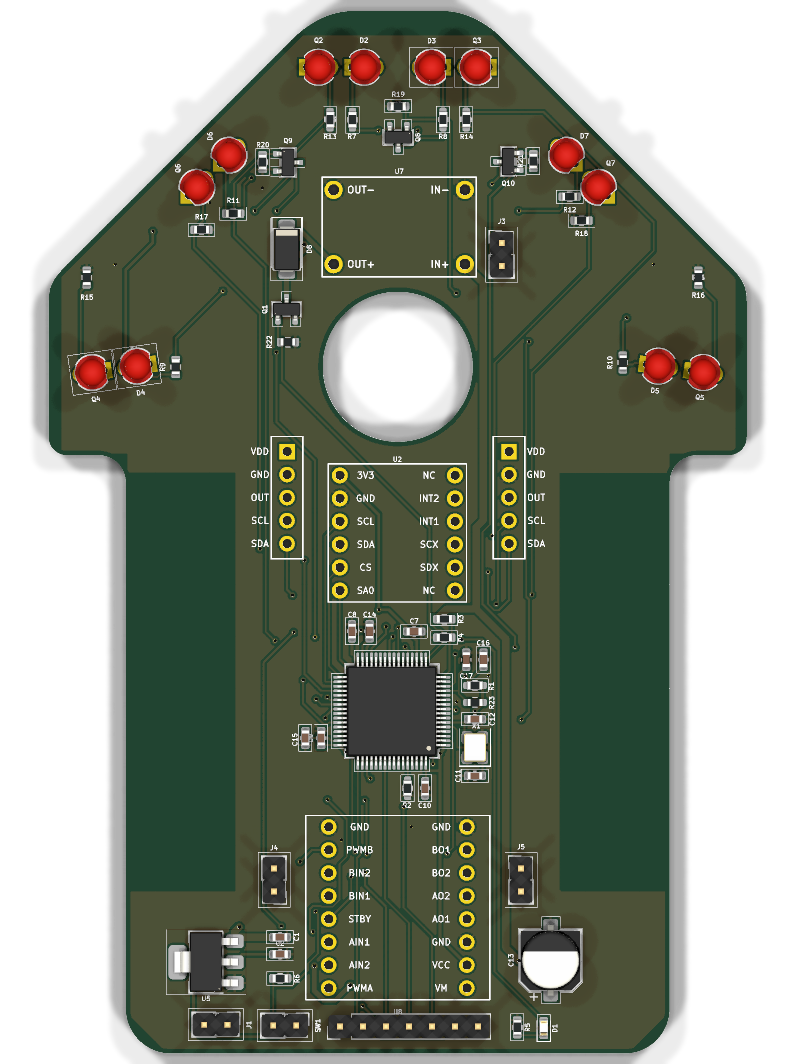 | 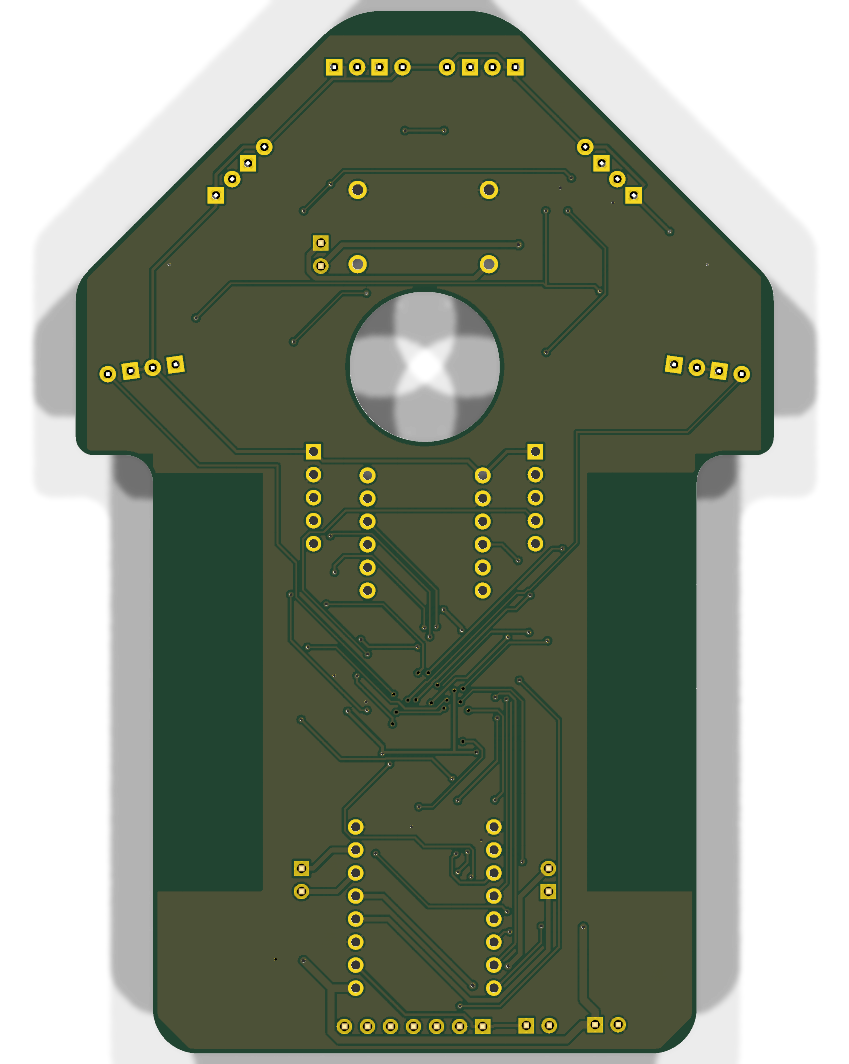 |
| Traces / Silkscreen | Outline & Cutouts |
|---|---|
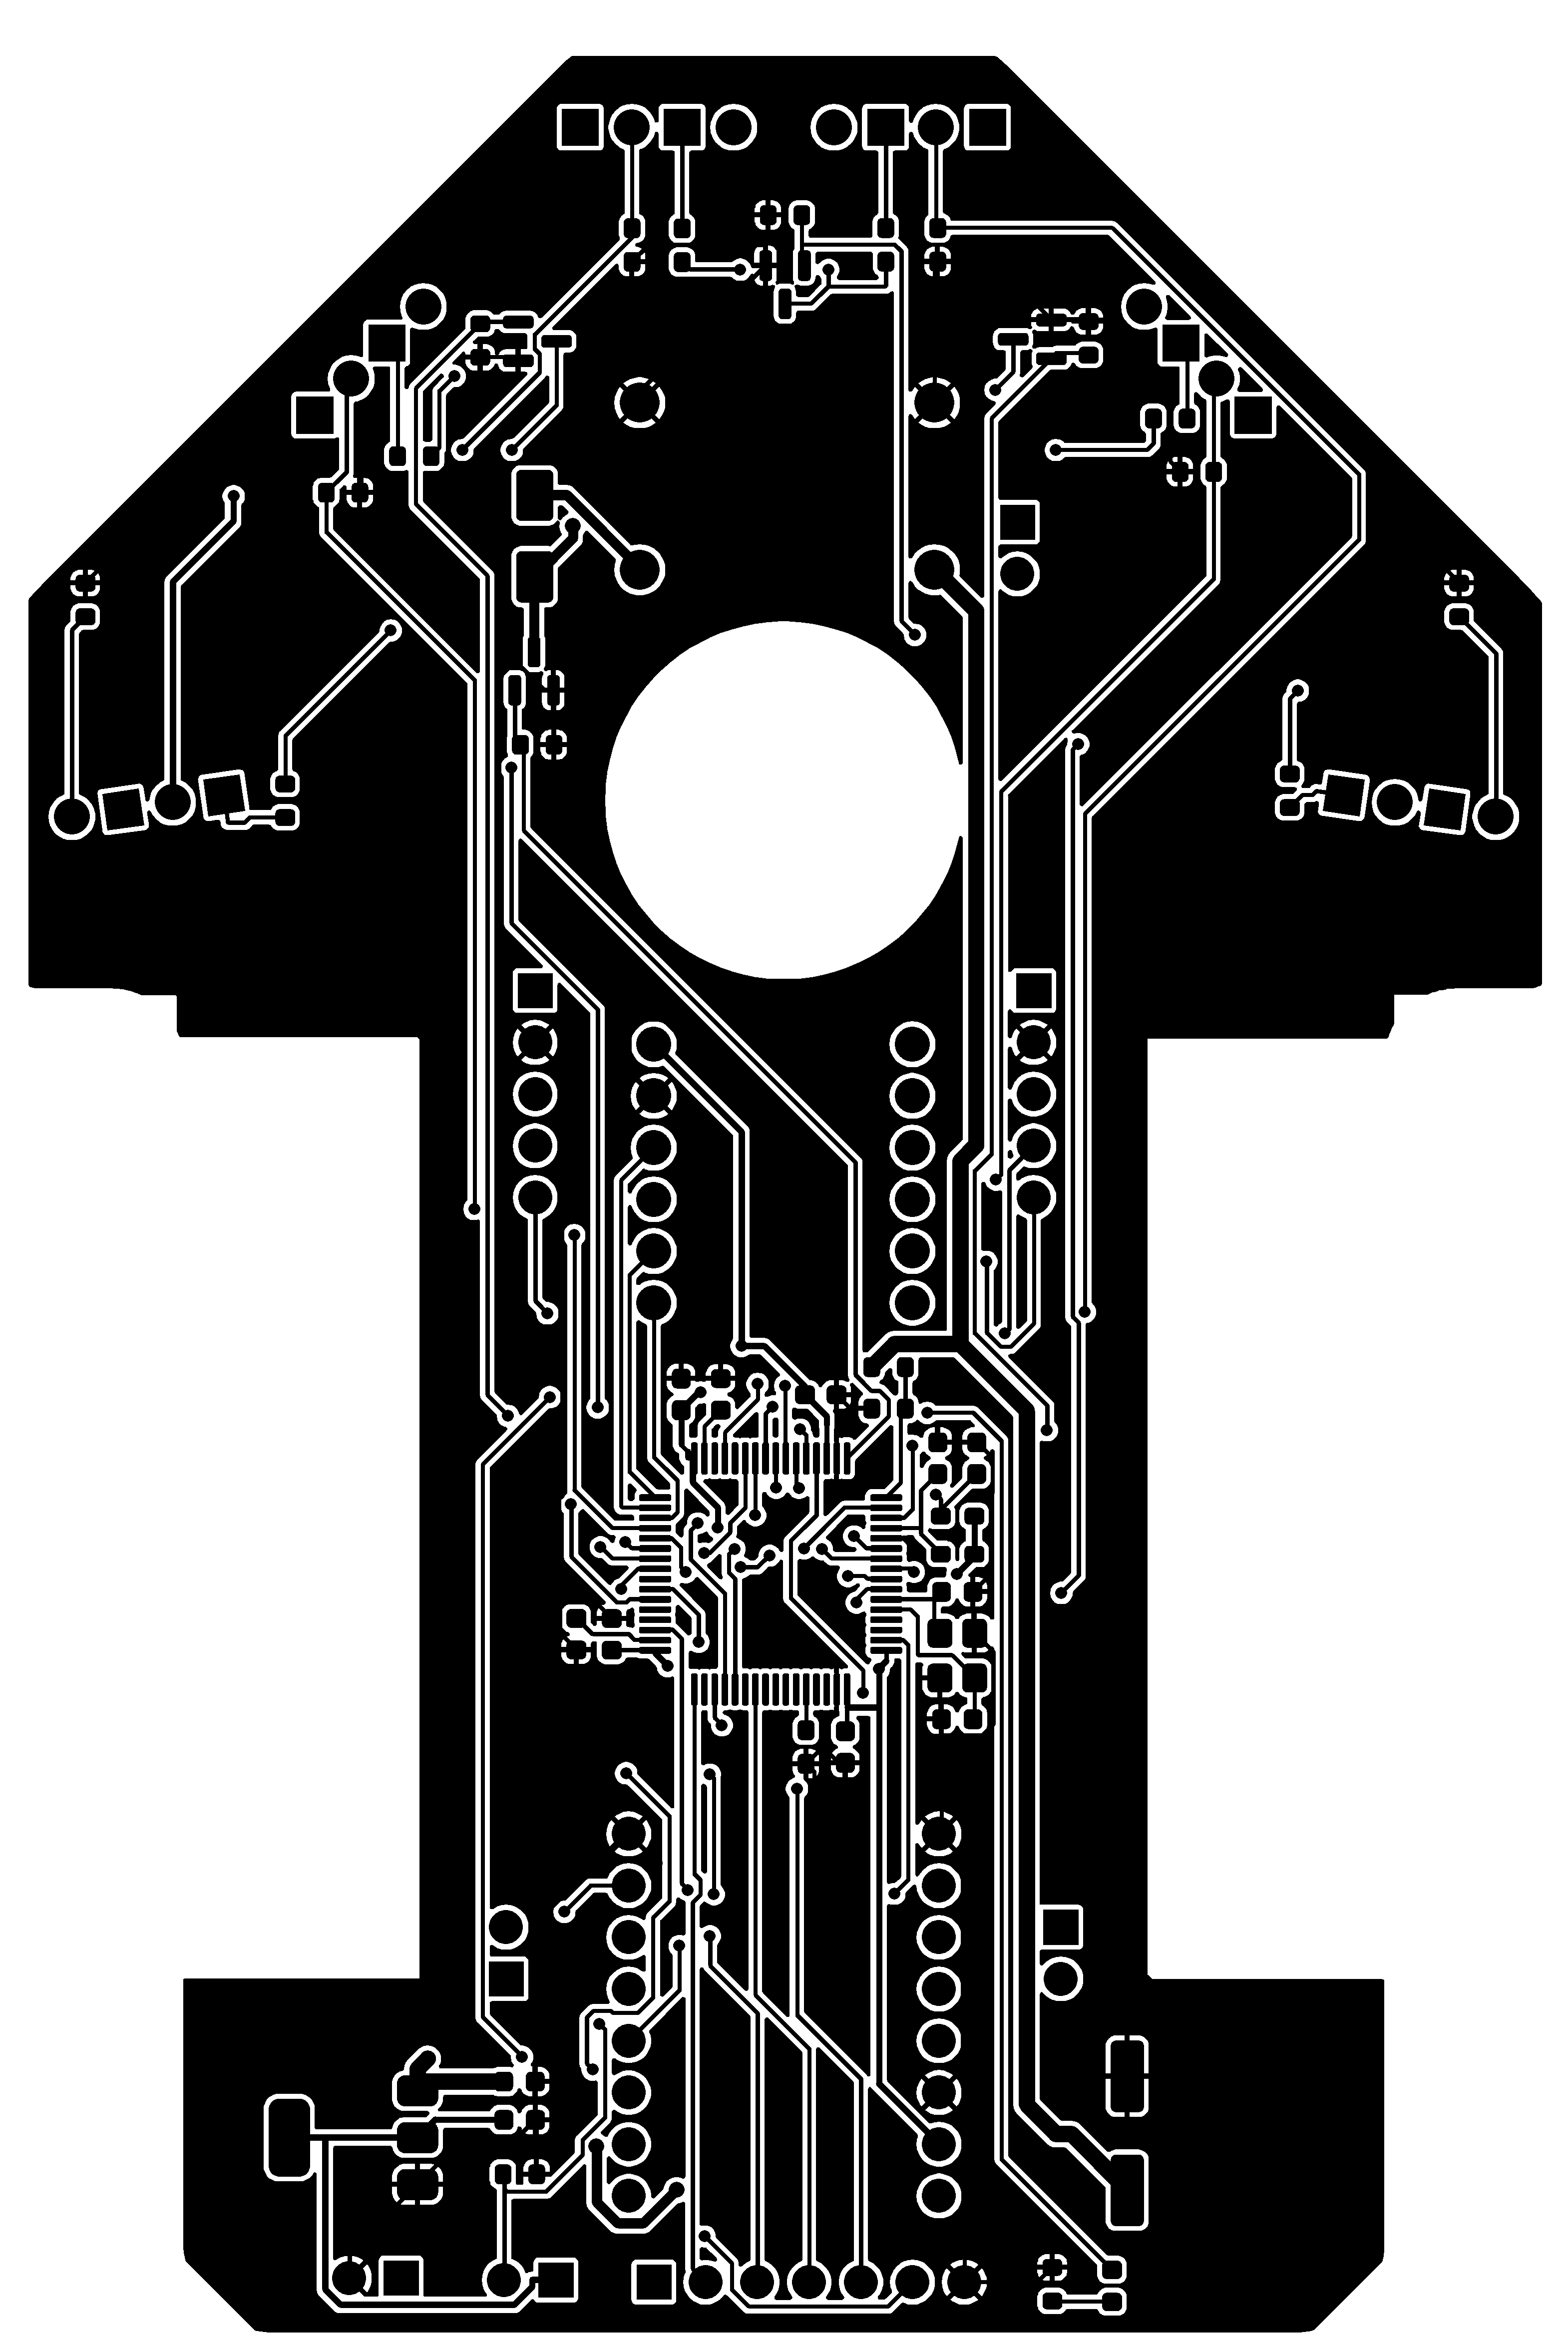 | 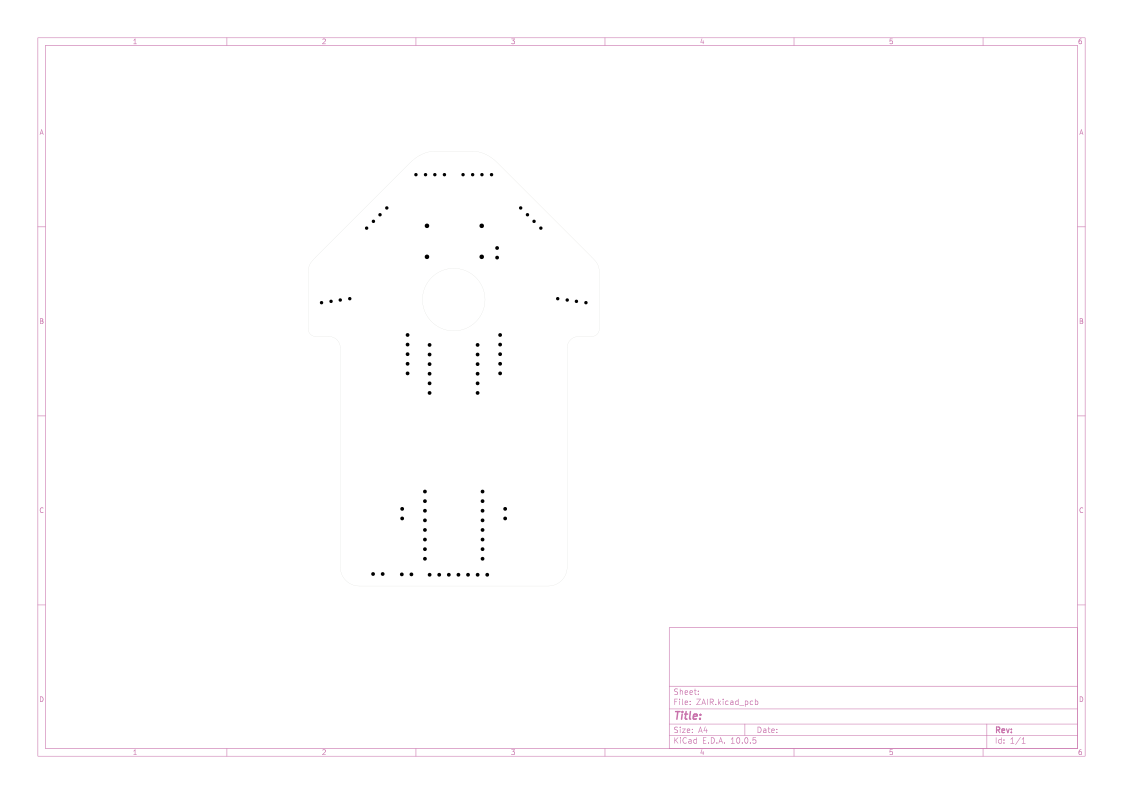 |
SWDIO, SWDCK, SWO) and USART1 (TX, RX)Designed in KiCad.
hardware/schematic/ZAIR/hardware/schematic/ZAIR/ZAIR_Schematic.pdfhardware/schematic/ZAIR/gerbers/hardware/schematic/ZAIR/ZAIR.csvDesigned in Onshape. A 3-gear direct-drive setup where the central Coreless 1718 motor pinion meshes simultaneously with both geared wheels.
| 3-Gear Mesh | Drivetrain Assembly |
|---|---|
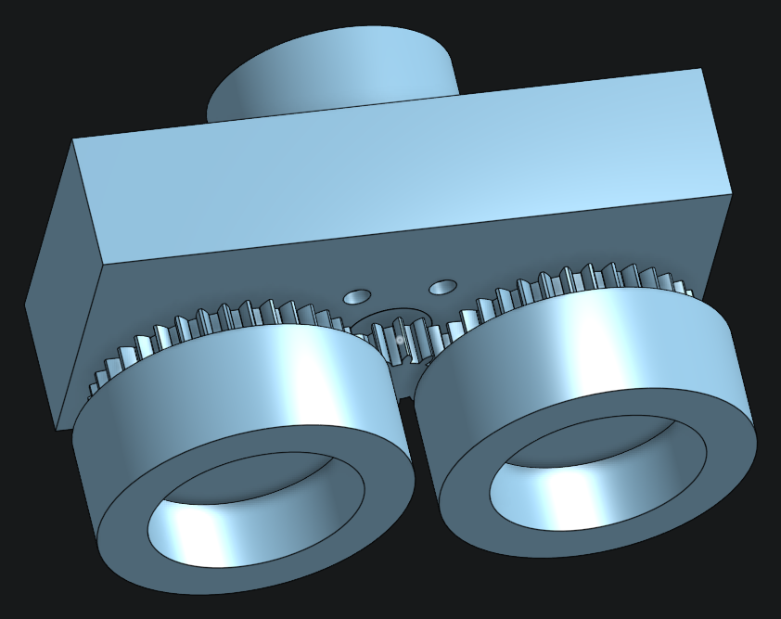 | 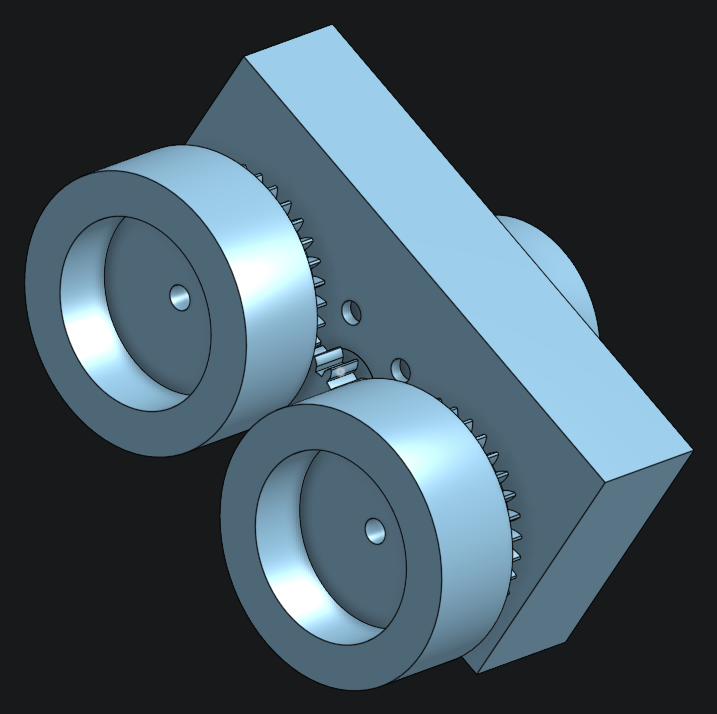 |
hardware/cad/)hardware/cad/motor_1718.step)hardware/cad/geared_wheel.step)hardware/cad/drivetrain_mount.step)| Qty | Value | Footprint | References |
|---|---|---|---|
| 14 | 10k | Resistor_SMD:R_0603_1608Metric | R1, R2, R4, R6, R13, R14, R15, R16, R17, R18, R19, R20, R21, R22 |
| 6 | 33 | Resistor_SMD:R_0603_1608Metric | R7, R8, R9, R10, R11, R12 |
| 5 | 100nF | Capacitor_SMD:C_0603_1608Metric | C7, C8, C9, C10, C16 |
| 2 | 10uF | Capacitor_SMD:C_0603_1608Metric | C1, C2 |
| 2 | 2.2uF | Capacitor_SMD:C_0603_1608Metric | C14, C15 |
| 2 | 20pF | Capacitor_SMD:C_0603_1608Metric | C11, C12 |
| 1 | 0R/10R | Resistor_SMD:R_0603_1608Metric | R23 |
| 1 | 100uF | Capacitor_SMD:CP_Elec_6.3x5.4 | C13 |
| 1 | 1uF | Capacitor_SMD:C_0603_1608Metric | C17 |
| 1 | 22k | Resistor_SMD:R_0603_1608Metric | R3 |
| 1 | 330 | Resistor_SMD:R_0603_1608Metric | R5 |
| 1 | 8MHz | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | X1 |
| 1 | AMS1117-3.3 | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U5 |
| 1 | AO3400_DIAG | Package_TO_SOT_SMD:SOT-23 | Q10 |
| 1 | AO3400_FRONT | Package_TO_SOT_SMD:SOT-23 | Q8 |
| 1 | AO3400_SIDE | Package_TO_SOT_SMD:SOT-23 | Q9 |
| 1 | AO3400_VAC | Package_TO_SOT_SMD:SOT-23 | Q1 |
| 1 | LED_BLUE | LED_SMD:LED_0603_1608Metric | D1 |
| 1 | LSM6DSV-BREAKOUT | ZAIR:LSM6DSV_Breakout | U2 |
| 1 | MOT_LEFT | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J4 |
| 1 | MOT_RIGHT | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J5 |
| 1 | MP2307-MINI360-MODULE | ZAIR:MP2307_Mini360_Buck | U7 |
| 1 | MT6701-L-01355 | ZAIR:MT6701_Breakout | U3 |
| 1 | MT6701-R-01355 | ZAIR:MT6701_Breakout | U4 |
| 1 | SFH4545_DL | LED_THT:LED_D3.0mm | D6 |
| 1 | SFH4545_DR | LED_THT:LED_D3.0mm | D7 |
| 1 | SFH4545_FL | LED_THT:LED_D3.0mm | D2 |
| 1 | SFH4545_FR | LED_THT:LED_D3.0mm | D3 |
| 1 | SFH4545_L | LED_THT:LED_D3.0mm | D4 |
| 1 | SFH4545_R | LED_THT:LED_D3.0mm | D5 |
| 1 | SS14_FLYBACK | Diode_SMD:D_SMA | D8 |
| 1 | STM32F405RGT6 | Package_QFP:LQFP-64_10x10mm_P0.5mm | U1 |
| 1 | SWD_UART_SWO | Connector_PinHeader_2.54mm:PinHeader_1x07_P2.54mm_Vertical | J7 |
| 1 | TB6612FNG-BREAKOUT | ZAIR:TB6612FNG_Breakout_Red | U8 |
| 1 | TEFT4300_DL | LED_THT:LED_D3.0mm | Q6 |
| 1 | TEFT4300_DR | LED_THT:LED_D3.0mm | Q7 |
| 1 | TEFT4300_FL | LED_THT:LED_D3.0mm | Q2 |
| 1 | TEFT4300_FR | LED_THT:LED_D3.0mm | Q3 |
| 1 | TEFT4300_L | LED_THT:LED_D3.0mm | Q4 |
| 1 | TEFT4300_R | LED_THT:LED_D3.0mm | Q5 |
| 1 | USER_BTN | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | SW1 |
| 1 | VAC_MOTOR | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J3 |
| 1 | VBAT_IN | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J1 |
shamansystems/Cheap-FOCer-2
Low-Cost Motor Controller based on the VESC 6

nordstream3/FOC
Date | Manufacturer | amount | includes | shipping & tax | price | -------- | -------- | -------- | -------- | -------- | -------- | 2024-01-17 | JLCPCB | 10 boards | All assembled excl fets and caps | YES, to EU |…


JoshCrouch/HEXCORE
HEXCORE is a Hexapod-type robot that includes both a custom remote as well as vision system making use of 2.4GHz RF and WiFi respectively.

PhilCarPi/STM32F4_Breakout_Board
4 layer PCB that serves as a breakout board to an STM32F405 chip with an additional IMU chip just for fun. The breakout is for serial ports SPI, USART, I2C, and SWD.

GoTouchGra55/J.O.L.T
12 degrees of freedom, 1 custom devboard, and 0 off-the-shelf solutions. JOLT is a quadruped robot built entirely from scratch.

MURPHYENGINEERING/STM32F405RGT6-Breakout
Following along with Phil's Lab: https://www.youtube.com/watch?v=t5phi3nT8OU

It measures 77 × 115 mm and has 2 copper layers, 1.6 mm thick.
68 parts, built around the STM32F405RGT6 and AMS1117-3.3. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the zischl/ZAIR repository on GitHub, at the commit this page was made from: the board is hardware/schematic/ZAIR/ZAIR.kicad_pcb and its schematic hardware/schematic/ZAIR/ZAIR.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask zischl before reusing the design.