4 layers76.3 × 54.3 mm
CM4
ybabs/PorpDAQ
Design Files for a STM32-Based Underwater Acoustics data acquisition board for harbour porpoises
113 parts6MIT

 ybabs/PorpDAQ6
Design Files for a STM32-Based Underwater Acoustics data acquisition board for harbour porpoises
Preamp is an open-source printed circuit board by ybabs, from the ybabs/PorpDAQ repository on GitHub, published under the MIT licence. It is a 2-layer board with 42 parts on 25 nets, routed with 330 tracks and 13 vias.
It is built around the LMH6643MA, LT1528CQ#PBF and SMA-J-P-H-ST-EM1. Its parts include 15 resistors, 14 capacitors, 5 ICs and 3 connectors. It belongs with the audio and music boards of this library.


STM32 Based design data acquisition recorder for harbour porpoises. The system is based on a 40dB bandpass preamplifier (90Khz - 150kHz). Records WAV file at a sampling rate of 400 KHz (V1) and 500 KHz (V2) and stores them to a microSD card. The preamplifier was designed using TI's filter designer tool. Preamp output is passed to a summing amplifier to keep signals within 0 - 3.3V with a 1.65V bias. There's a few iterations of the DAQ from the initial prototypes to improved designs.
PorpDAQ has been designed to fit within a small multirotor UAV so current design weighs only 18g. PorpDAQ computes a 1024 point RFFT of incoming hydrophone signals and transmits signals within 90 - 150KHz over a UART Interface
The initial version of the DAQ was based on a STM32F746 chip and had a 400 KHz sample rate and a 12-bit ADC with a SD card write speed of about 20mbps.
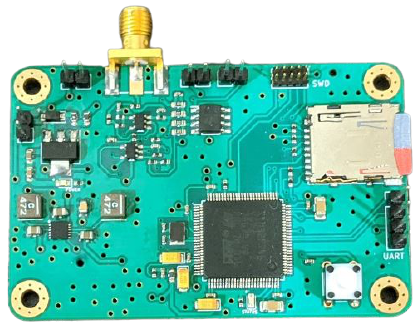
Rev 2 board comes with some improvements namely the the use of the STM32H743 chip, USB-C for power with the addition of a full speed interface. 500 KHz sample rate, SD Card write speed of ~35 Mbps with a 16-bit ADC and better SNR. Also slightly smaller footprint
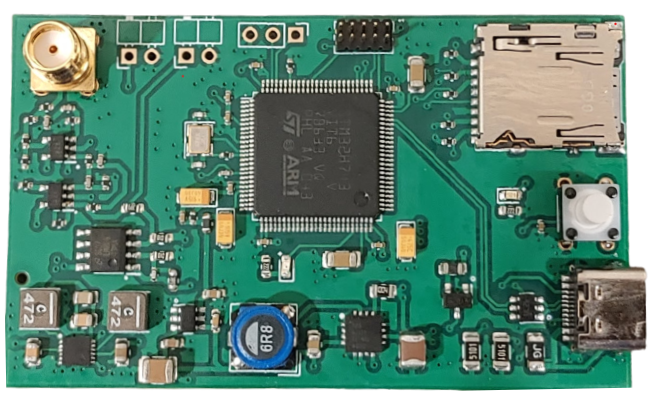
This repository mostly contains :
board_100pin while Rev 2 design is named h7_board. @article{Babatunde2020, doi = {10.3390/s20216064}, url = {https://doi.org/10.3390/s20216064}, year = {2020}, month = oct, publisher = {{MDPI} {AG}}, volume = {20}, number = {21}, pages = {6064}, author = {Daniel Babatunde and Simon Pomeroy and Paul Lepper and Ben Clark and Rebecca Walker}, title = {Autonomous Deployment of Underwater Acoustic Monitoring Devices Using an Unmanned Aerial Vehicle: The Flying Hydrophone}, journal = {Sensors} }
MIT License Copyright 2020 Daniel Babatunde
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | 100pF | Capacitor_SMD:C_0603_1608Metric | C5, C6, C7, C8 |
| 4 | MountingHole_2.2mm_M2 | MountingHole:MountingHole_2.2mm_M2 | REF1, REF2, REF3, REF4 |
| 3 | 47uF | Capacitor_Tantalum_SMD:CP_EIA-2012-15_AVX-P | C11, C12, C13 |
| 2 | 100k | Resistor_SMD:R_0603_1608Metric | R12, R13 |
| 2 | 100nf | Capacitor_SMD:C_0603_1608Metric | C3, C4 |
| 2 | 187 | Resistor_SMD:R_0603_1608Metric | R4, R9 |
| 2 | 2.49k | Resistor_SMD:R_0603_1608Metric | R5, R10 |
| 2 | 50k | Resistor_SMD:R_0603_1608Metric | R11, R14 |
| 2 | Conn_01x02_Male | Connector_PinHeader_1.00mm:PinHeader_1x02_P1.00mm_Vertical | J2, J3 |
| 2 | OPA659IDBVR | OPA659IDBVR:SOT95P280X145-5N | U2, U3 |
| 1 | 100nF | Capacitor_SMD:C_0603_1608Metric | C14 |
| 1 | 10k | Resistor_SMD:R_0603_1608Metric | R3 |
| 1 | 10pF | Capacitor_SMD:C_0603_1608Metric | C9 |
| 1 | 1uf | Capacitor_SMD:C_0603_1608Metric | C1 |
| 1 | 220uF | Capacitor_Tantalum_SMD:CP_EIA-2012-15_AVX-P | C2 |
| 1 | 330 | Resistor_SMD:R_0603_1608Metric | R15 |
| 1 | 34.8k | Resistor_SMD:R_0603_1608Metric | R6 |
| 1 | 35.7k | Resistor_SMD:R_0603_1608Metric | R1 |
| 1 | 44.2k | Resistor_SMD:R_0603_1608Metric | R7 |
| 1 | 47uf | Capacitor_Tantalum_SMD:CP_EIA-2012-15_AVX-P | C10 |
| 1 | 6.34k | Resistor_SMD:R_0603_1608Metric | R8 |
| 1 | 66.5k | Resistor_SMD:R_0603_1608Metric | R2 |
| 1 | LMH6643MA | LMH6643MA:SOIC127P600X175-8N | U4 |
| 1 | LT1528CQ | LT1528CQ:DDPAK-5_Q | U5 |
| 1 | SMA-J-P-H-ST-EM1 | SMA-J-P-H-ST-EM1:SMA-J-P-H-ST-EM1 | J1 |
| 1 | Screw_Terminal_01x02 | Connector_AMASS:AMASS_XT30PW-M_1x02_P2.50mm_Horizontal | Battery1 |
| 1 | TLE2426xD | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U1 |
ybabs/PorpDAQ
Design Files for a STM32-Based Underwater Acoustics data acquisition board for harbour porpoises

ybabs/PorpDAQ
Design Files for a STM32-Based Underwater Acoustics data acquisition board for harbour porpoises

ybabs/PorpDAQ
Design Files for a STM32-Based Underwater Acoustics data acquisition board for harbour porpoises

ybabs/PorpDAQ
Design Files for a STM32-Based Underwater Acoustics data acquisition board for harbour porpoises

ybabs/PorpDAQ
Design Files for a STM32-Based Underwater Acoustics data acquisition board for harbour porpoises

ybabs/PorpDAQ
Design Files for a STM32-Based Underwater Acoustics data acquisition board for harbour porpoises

thingsat/tinygs_2g4station
HW and FW of a TinyGS 2.4 GHz LoRa ground station https://tinygs.com/


ckuhtz/picise
Prototype for a time / location GNSS accessory for a Raspberry Pi 40-pin GPIO.

EvoLuvDaP/Expansion_board_RFM95
A single-layer PCB design suitable for educational testing purposes.

42 parts, built around the LMH6643MA, LT1528CQ#PBF and SMA-J-P-H-ST-EM1. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the ybabs/PorpDAQ repository on GitHub, at the commit this page was made from: the board is Hardware/preamp_v2/preamp.kicad_pcb and its schematic CM4 Design/CM4/CM4.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).