Acquedotto test v4 finale
igorilla666/water-controller
Scheda di controllo basata sul modulo Waveshare ESP32-S3-ETH, con ingressi sensore, RS-485, pilotaggio rele, buzzer e alimentazione/protezioni dedicate.

OpenMower is an open-source project that upgrades off-the-shelf robotic mowers into modern, smart lawn mowing robots with RTK GPS technology. For more details, check out the OpenMower project.
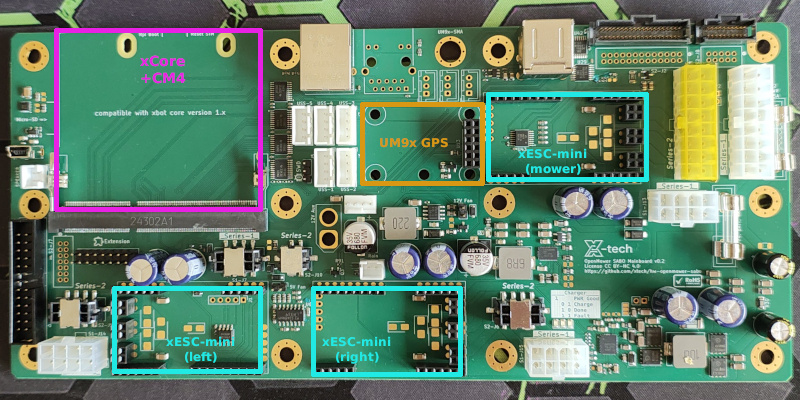
Hw openmower sabo is an open-source printed circuit board by xtech, from the xtech/hw-openmower-sabo repository on GitHub. It is a 6-layer board of 254 × 115 mm with 356 parts on 426 nets, routed with 2,730 tracks and 1,177 vias.
It is built around the LM2903DR, TPS2065CDBVR-2 and 1.25-6PLTDK, with the AO3400A, AON7246E and SMCJ30A among its other parts. Its parts include 110 resistors, 102 capacitors, 33 ICs, 14 diodes and 10 transistors.

OpenMower is an open-source project that upgrades off-the-shelf robotic mowers into modern, smart lawn mowing robots with RTK GPS technology. For more details, check out the OpenMower project.
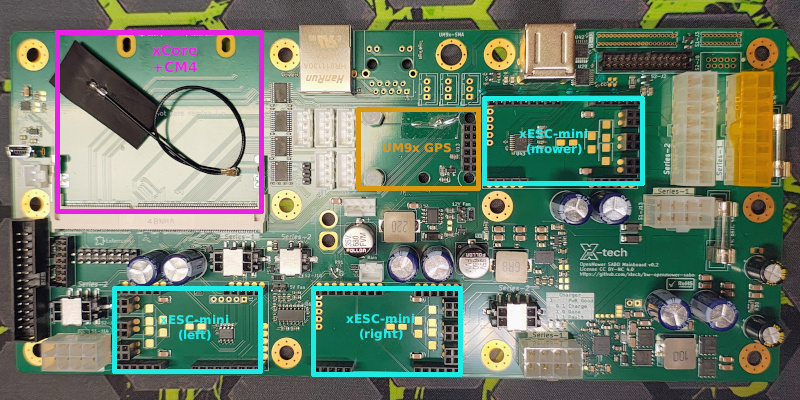
This repository contains the design files for a custom carrierboard specifically designed for converting SABO based mowers to OpenMower V2.
For more info or questions, please visit Discord
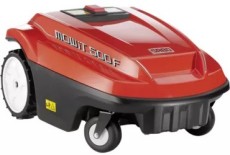
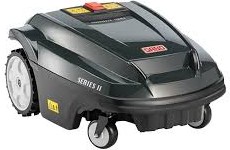
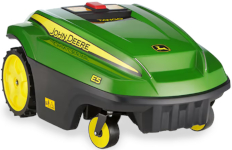
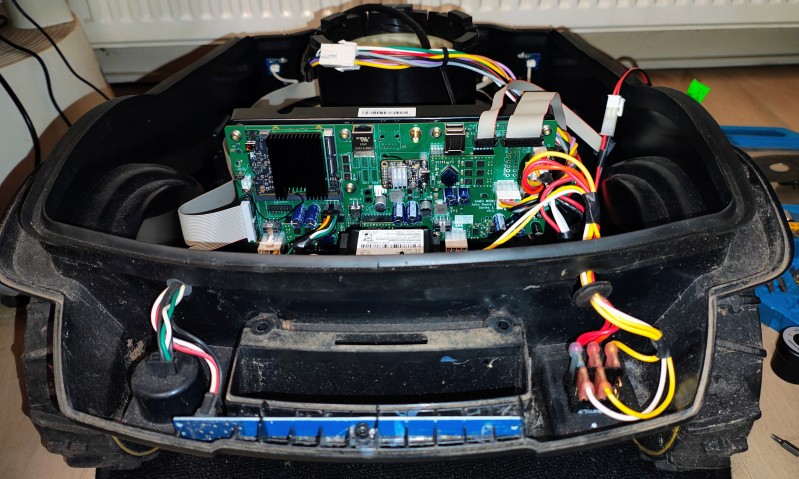
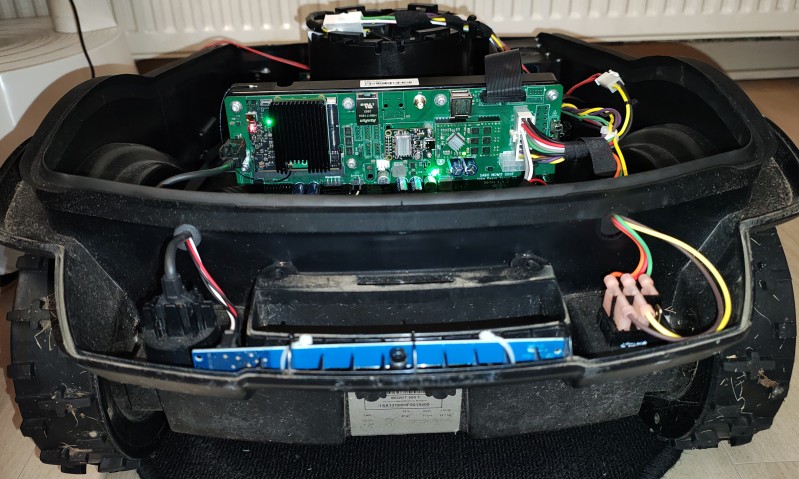
This Carrierboard is compatible with the following mower models:
| Series-I Carrierboard (v0.2) | Series-II Carrierboard (v0.2) |
|---|---|
![]() | ![]() |
| Series-I (v0.1) @ John Deere Tango E5 | Series-II (v0.1) @ Sabo MOWiT 500F |
![]() | ![]() |
To build a complete OpenMower-V2 system, you will need the following additional components beyond this Carrierboard:
See Robot Specific Guide in the official docs.
The old instructions are still here: INSTALL-HARDWARE-AND-SOFTWARE-PREP.md.
Click the button above to watch the Sabo LCD demonstration video
| LED | Meaning |
|---|---|
| Auto | In autonomous mode, "Hanging around" indicator due to pause or error |
| Driving/Mowing | Mowing or navigating, Paused |
| House/Home | Navigating to dock/home |
| Start/Play | Emergency, Waiting for ROS Docked & charging finished, Docked & charging, Docked but no or faulty battery |
The meaning of the buttons is context driven
| Button | Series-I | Series-II | Short Press | Long (≥0.5s) Press |
|---|---|---|---|---|
| Auto | :x: | :white_check_mark: | ||
| Driving/Mowing | :x: | :white_check_mark: | Start mowing | |
| House/Home | :x: | :white_check_mark: | ||
| Select (left) | :white_check_mark: | :x: | ||
| Start/Play | :white_check_mark: | :white_check_mark: | Start mowing | Clear emergency |
| Button | Series-I | Series-II | Short Press | Long (≥0.5s) Press |
|---|---|---|---|---|
| Auto | :x: | :white_check_mark: | ||
| Driving/Mowing | :x: | :white_check_mark: | Skip path | Skip area |
| House/Home | :x: | :white_check_mark: | Go back home/dock | |
| Select (left) | :white_check_mark: | :x: | Skip path | Skip area |
| Start/Play | :white_check_mark: | :white_check_mark: | Pause/Continue mowing | Clear emergency |
This Carrierboard includes more features than actually required to build an OpenMower robot. Additional features include a gigabit Ethernet switch, LiPo charger, and a 12V auxiliary power supply for extensions.
| Version | Date | Info |
|---|---|---|
| v0.6.0 | 2026/12 | In Development - Add motor backflow protection - Move SWD plug to a more comfortable position and change to SW_4 plug (JST-XH 4 pin) - Slightly increase charger VFB to a target of VBAT = 28.9V - Increase GPS pigtail cable hole to fit also for MMCX plug - Minor routing and part improvements - Changed some GPIOs for better IRQ/Timer support - Change optional USS plugs - Change level shifter - Switch to quicker charger FETs - Reduce ADC noise - Optimize I2C and SPI signalling |
| v0.5.0 | 2026/06 | - Add Mow-ESC-Fuse for power ESCs - Slightly improve power traces - Improve mow-phases to 9A - Lower chargers FB divider to target a VBAT of 28.28V - Add BMS-I2C swapper via solder jumper - Custom BMS plugs for DALY or JBD (UART7) - Optional 6-9A charge current when changed to Fsw 200kHz via solder jumper |
| v0.4.0 | 2026/05 | - Fix and improve v0.3.0 issues - Skip one GPIO expander and switch to smaller footprint - Rearrange LAN and USB Plug as well as skip 2nd optional LAN in favor of more space for Series-I plugs |
| v0.3.0 | 2025/11 | Internal Prototype - Fix Series-I/II emergency incompatibilities - Improve CoverUI circuit - Improve Series-I CoverUI plug accessibility |
| v0.2.1 | 2025/06 | - Add DCDC-In current sense and allow charge currents up to 2.8A - BMS data support |
| v0.2.0 | 2025/06 | - Fix Series-II emergency oscillation issues - Support Series-I LEDs and Buttons - Support LCD |
| v0.1.0 | 2025/03 | Initial Prototype |
Before building a robot based on the designs published here, please make sure that you are allowed to do so in your specific regions. There may be patents and / or laws prohibiting you of doing so.
The code/schematics/PCB files are distributed in the hope that it will be useful, but WITHOUT ANY WARRANTY; without even the implied warranty of MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE.
This basically means: I'm just documenting a project of mine here for free and I don't have the time and resources to check that devices built using this information will be safe to use, legal to use or even work as intended. You will need technical know-how to use this project and I'm not liable for any damages your devices do to anyone or anything.
The RoHS mark on the PCB indicates presumed compliance based on supplier declarations. No third-party testing or certification has been conducted.

This work is licensed under a Creative Commons Attribution-NonCommercial 4.0 International License.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 43 | 10k | Resistor_SMD:R_0402_1005Metric | R1, R2, R3, R19, R29, R31, R34, R35, R38, R39, R100, R101, R102, R103, R104, R105 +27 |
| 28 | 100nF | Capacitor_SMD:C_0402_1005Metric | C1, C2, C5, C10, C15, C17, C19, C21, C23, C36, C37, C48, C52, C53, C54, C57 +12 |
| 13 | 4.7uF@50V | Capacitor_SMD:C_1206_3216Metric | C22, C38, C39, C40, C41, C43, C44, C45, C46, C55, C56, C58, C59 |
| 12 | 4.7uF@50V | Capacitor_SMD:C_1210_3225Metric | C66, C67, C70, C71, C74, C75, C94, C100, C101, C102, C103, C104 |
| 12 | MountingHole_Pad | MountingHole:MountingHole_5mm_Pad_Via | H1, H2, H3, H4, H5, H6, H7, H8, H9, H10, H11, H12 |
| 10 | 220uF@80V | Capacitor_THT:CP_Radial_D10.0mm_P5.00mm | C42, C47, C50, C61, C64, C65, C68, C69, C72, C73 |
| 9 | 2.54mm 2x2 socket | xtech:Dummy_xESC_2x2PH | U18, U19, U20, U21, U22, U23, U24, U25, U26 |
| 9 | 470nF@25V | Capacitor_SMD:C_0603_1608Metric | C3, C4, C6, C7, C29, C35, C83, C105, C106 |
| 6 | 2.54mm 1x6 socket | xtech:Dummy_xESC_6PH | U30, U31, U32, U33, U34, U35 |
| 6 | Fuse Holder | xtech:Dummy | FH1, FH2, FH3, FH4, FH5, FH6 |
| 5 | 100nF@100V | Capacitor_SMD:C_0805_2012Metric | C62, C77, C79, C81, C82 |
| 5 | 100uF@6.3V | Capacitor_SMD:C_1206_3216Metric | C9, C31, C32, C33, C34 |
| 5 | 1k | Resistor_SMD:R_0402_1005Metric | R58, R84, R85, R87, R108 |
| 5 | 3k3 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R23, R43, R90, R113, R114 |
| 4 | 10k | Resistor_SMD:R_0603_1608Metric | R9, R41, R42, R49 |
| 4 | 10uF@50V | Capacitor_SMD:C_1206_3216Metric | C11, C16, C24, C25 |
| 4 | 150 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R59, R61, R63, R64 |
| 4 | 1uF@50V | Capacitor_SMD:C_0805_2012Metric | C51, C80, C89, C90 |
| 4 | 2R2 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R109, R110, R111, R112 |
| 4 | AO3400A | Package_TO_SOT_SMD:SOT-23 | Q1, Q4, Q5, Q11 |
| 4 | AON7246E | nlbn:AON7246E_C3277811 | Q6, Q7, Q8, Q9 |
| 4 | LED GREEN | LED_SMD:LED_0805_2012Metric | D1, D5, D6, D29 |
| 3 | 0R | Resistor_SMD:R_0805_2012Metric | R8, R26, R66 |
| 3 | 10k | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R24, R52, R60 |
| 3 | 120 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R10, R27, R28 |
| 3 | 150 | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R25, R53, R65 |
| 3 | 1M | Resistor_SMD:R_0805_2012Metric | R5, R6, R7 |
| 3 | 2.54mm 1x5 socket | xtech:Dummy_xESC_5PH | U39, U40, U41 |
| 3 | 2.54mm 1x9 socket | xtech:Dummy_xESC_9PH | U36, U37, U38 |
| 3 | Conn_01x02 | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J17, J18, J19 |
| 3 | Conn_02x04_Top_Bottom | local_Connectors:Molex_Mini-Fit_Jr_5566-08A_2x04_P4.20mm_Vertical | S1-J13, S1-J14, S1-J15 |
| 3 | Conn_02x04_Top_Bottom_MountingPin | local_Connectors:Molex_Micro-Fit_3.0_43045-0818_2x04-1MP_P3.00mm_Vertical | S1-J7, S2-J5, S2-J6 |
| 3 | SMCJ30A | Diode_SMD:D_SMC | D7, D11, D17 |
| 3 | SN74LVC07ADBR | nlbn:SN74LVC07ADBR_C2676799 | U11, U12, U14 |
| 3 | SS54 | Diode_SMD:D_SMA | D15, D16, D28 |
| 3 | xESC2 | xtech:xESC2-mini | U8, U9, U10 |
| 2 | 10R | Resistor_SMD:R_0603_1608Metric | R78, R79 |
| 2 | 10R | Resistor_SMD:R_0402_1005Metric | R68, R69 |
| 2 | 300 | Resistor_SMD:R_0603_1608Metric | R13, R14 |
| 2 | 33Ω | PCM_JLCPCB:R_0805 | R11, R12 |
| 2 | 4.7uF | Capacitor_SMD:C_0805_2012Metric | C78, C84 |
| 2 | 470nF@50V | Capacitor_SMD:C_0805_2012Metric | C26, C85 |
| 2 | 4k7 | Resistor_SMD:R_0402_1005Metric | R106, R107 |
| 2 | 5m | Resistor_SMD:R_2512_6332Metric | R30, R67 |
| 2 | 680uF | Capacitor_SMD:CP_Elec_10x12.5 | C13, C14 |
| 2 | BSS138 | Package_TO_SOT_SMD:SOT-23 | Q3, Q10 |
| 2 | C | Capacitor_SMD:C_0805_2012Metric | C27, C30 |
| 2 | Conn_02x08_Top_Bottom | local_Connectors:Molex_Mini-Fit_Jr_5566-16A_2x08_P4.20mm_Vertical | S1-J17, S2-J1 |
| 2 | D_Schottky | Diode_SMD:D_SOD-123F | D22, D25 |
| 2 | Fan | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | M1, M2 |
| 2 | LM2903DR | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U49, U50 |
| 2 | TPS2065CDBVR | Package_TO_SOT_SMD:SOT-23-5 | U1, U2 |
| 2 | V1FM10-M3/H | Diode_SMD:D_SMF | D2, D26 |
| 1 | 0.05 | Resistor_SMD:R_2512_6332Metric | R36 |
| 1 | 1.25-6PLTDK | easyeda2kicad:CONN-SMD_6P-P1.25_SHOU_1.25-6PLTDK | U6 |
| 1 | 100k | Resistor_SMD:R_0402_1005Metric | R21 |
| 1 | 100k | Resistor_SMD:R_0805_2012Metric | R16 |
| 1 | 100k 0.1% | Resistor_SMD:R_0805_2012Metric | R17 |
| 1 | 100nF | Capacitor_SMD:C_0603_1608Metric | C96 |
| 1 | 100pF | Capacitor_SMD:C_0603_1608Metric | C60 |
| 1 | 10k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R89 |
| 1 | 10nF | Capacitor_SMD:C_0805_2012Metric | C12 |
| 1 | 10uH | Inductor_SMD:L_Sunlord_MWSA1005S | L4 |
| 1 | 133k | Resistor_SMD:R_0603_1608Metric | R74 |
| 1 | 14k 0.1% | Resistor_SMD:R_0603_1608Metric | R71 |
| 1 | 2.2k | Resistor_SMD:R_0805_2012Metric | R45 |
| 1 | 2.2uF | Capacitor_SMD:C_0805_2012Metric | C28 |
| 1 | 2.54mm 2x6 socket | xtech:Dummy_GPS_2x6PH | U46 |
| 1 | 20k | Resistor_SMD:R_0805_2012Metric | R44 |
| 1 | 22uH | Inductor_SMD:L_Sunlord_MWSA1004S | L3 |
| 1 | 249k 0.1% | Resistor_SMD:R_0603_1608Metric | R33 |
| 1 | 250k/200k | Jumper:SolderJumper-2_P1.3mm_Bridged_RoundedPad1.0x1.5mm | JP5 |
| 1 | 25k 0.1% | Resistor_SMD:R_0805_2012Metric | R18 |
| 1 | 25k5 | Resistor_SMD:R_0603_1608Metric | R20 |
| 1 | 270 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R62 |
| 1 | 2k7 0.1% | Resistor_SMD:R_0603_1608Metric | R55 |
| 1 | 30k | Resistor_SMD:R_0603_1608Metric | R73 |
| 1 | 32k4 0.1% | Resistor_SMD:R_0603_1608Metric | R22 |
| 1 | 330 | Resistor_SMD:R_0603_1608Metric | R32 |
| 1 | 33k 0.1% | Resistor_SMD:R_0603_1608Metric | R54 |
The 303 most common of 356 parts.
It measures 254 × 115 mm and has 6 copper layers, 1.6 mm thick.
356 parts, built around the LM2903DR, TPS2065CDBVR-2, 1.25-6PLTDK and AO3400A. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the xtech/hw-openmower-sabo repository on GitHub, at the commit this page was made from: the board is hw-openmower-sabo.kicad_pcb and its schematic Amplifier.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask xtech before reusing the design.

igorilla666/water-controller
Scheda di controllo basata sul modulo Waveshare ESP32-S3-ETH, con ingressi sensore, RS-485, pilotaggio rele, buzzer e alimentazione/protezioni dedicate.

levdan159/abx-motion
ABX-Motion 12V-32V ESP32-S3 4-Layer Robotics Controller (Dual 100W DC Servo H-Bridges, Dual Steppers, Dual Relays, CAN, RS-485, USB-C)

danchouzhou/NuDAC
A USB sound card based on Nuvoton M482ZGCAE MCU and NAU88L25 I2S audio codec

herraa1/msx-joyduke-v1
Use original Xbox joysticks with your MSX computer

lightsource-nz/crossfire_mk5
crossfire: USB-MIDI forwarding agent for embedded USB-MIDI smart hubs

StarGate01/max3421e-rpi-uhat
A uHAT for the Rapberry Pi (Zero), which adds a second USB 2.0 controller over SPI, using the MAX3421E chip.

dario0603/power_supply
Progetto universitario per la realizzazione e simulazione di un Alimentatore da Banco Stabilizzato , completo di schemi elettrici KiCad, simulazioni LTspice, documentazione tecnica e file Gerber per la produzione del…

Meo98/picostack
Stackable, contract-driven module system for the Raspberry Pi Pico — open hardware, built by code