2 layers85 × 125 mm
 levdan159/abx-motion
ABX-Motion 12V-32V ESP32-S3 4-Layer Robotics Controller (Dual 100W DC Servo H-Bridges, Dual Steppers, Dual Relays, CAN, RS-485, USB-C)
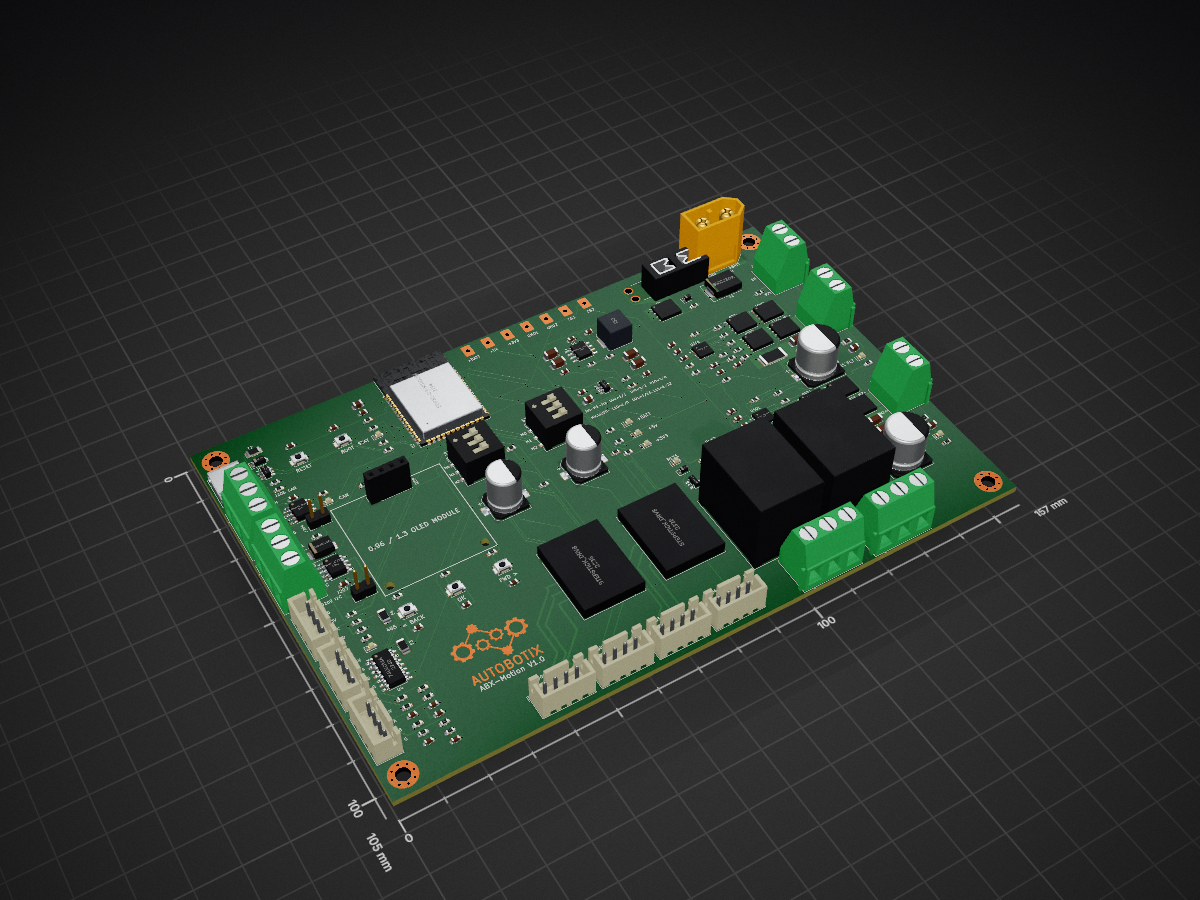
Abx motion is an open-source printed circuit board by levdan159, from the levdan159/abx-motion repository on GitHub. It is a 4-layer board of 157 × 105 mm with 203 parts on 159 nets, routed with 1,773 tracks and 352 vias.
It is built around the ESP32-S3-WROOM-1-N8R2, THVD1450DRBR and DRV8701ERGER, with the LMR36520FADDA, 74LVC14AD and AP2112K-3.3 among its other parts. Its parts include 71 resistors, 46 capacitors, 17 connectors, 14 diodes and 11 transistors. It belongs with the robots and motor control and interfaces and adapters boards and the ESP32 boards of this library.


12V–32V Battery-Powered ESP32-S3 Industrial & Mobile Robotics Motherboard
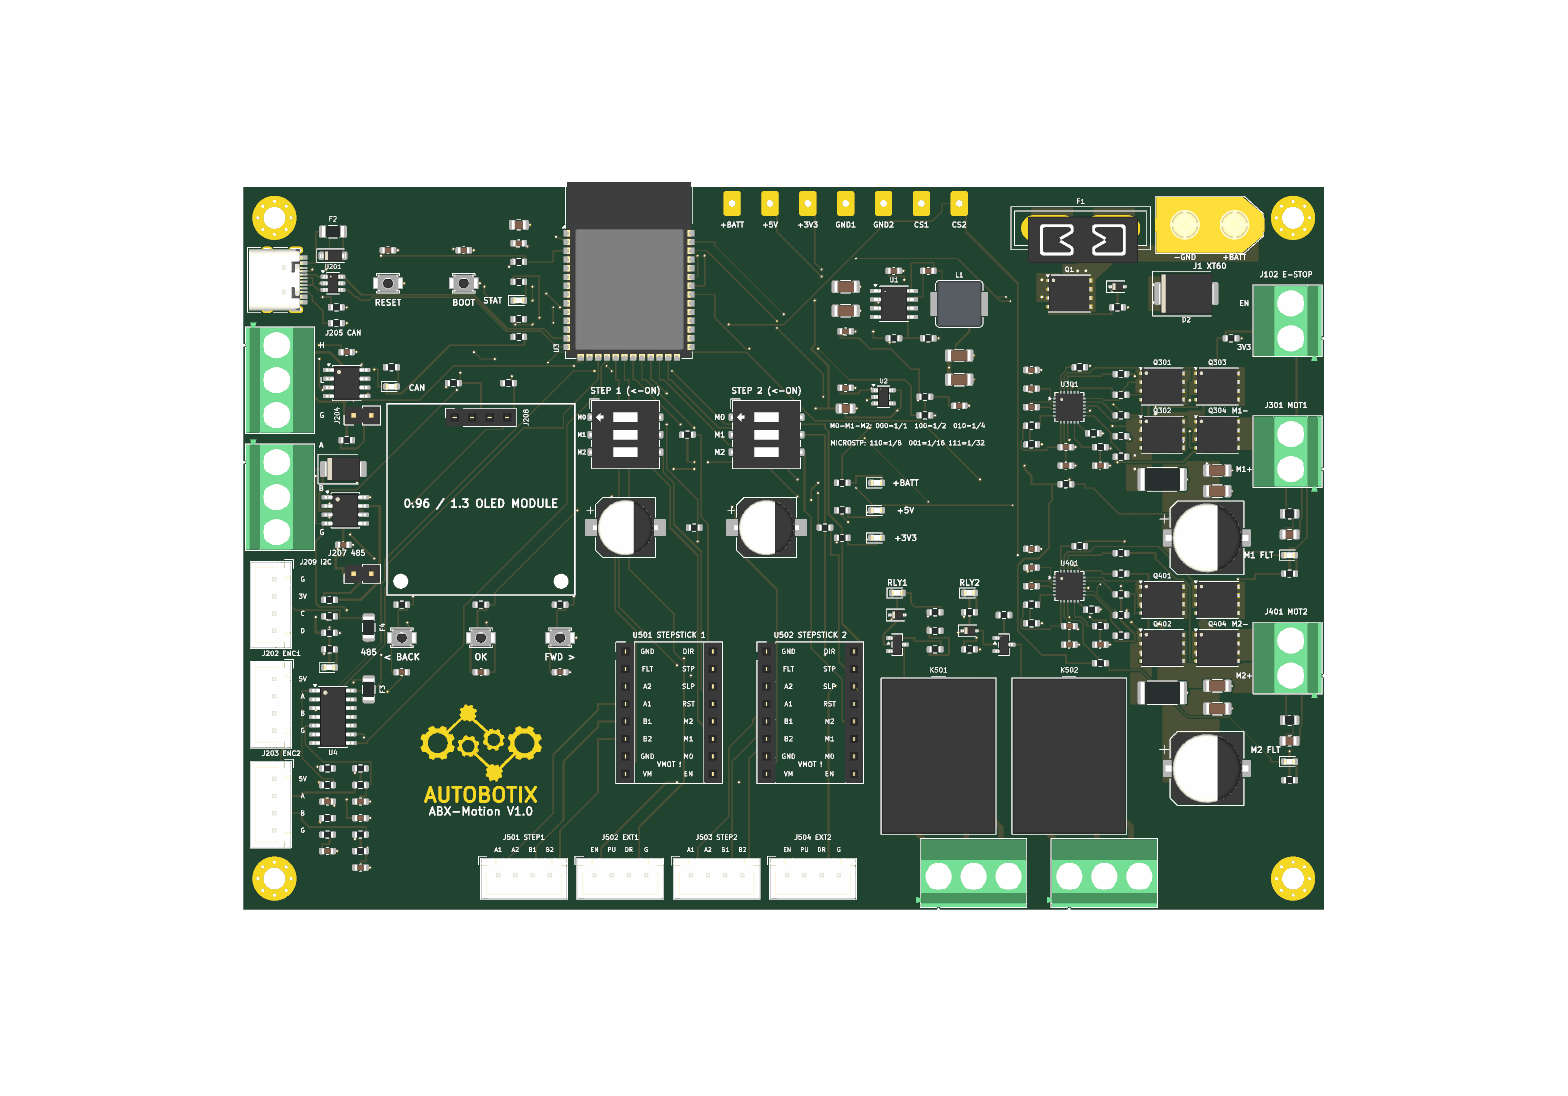
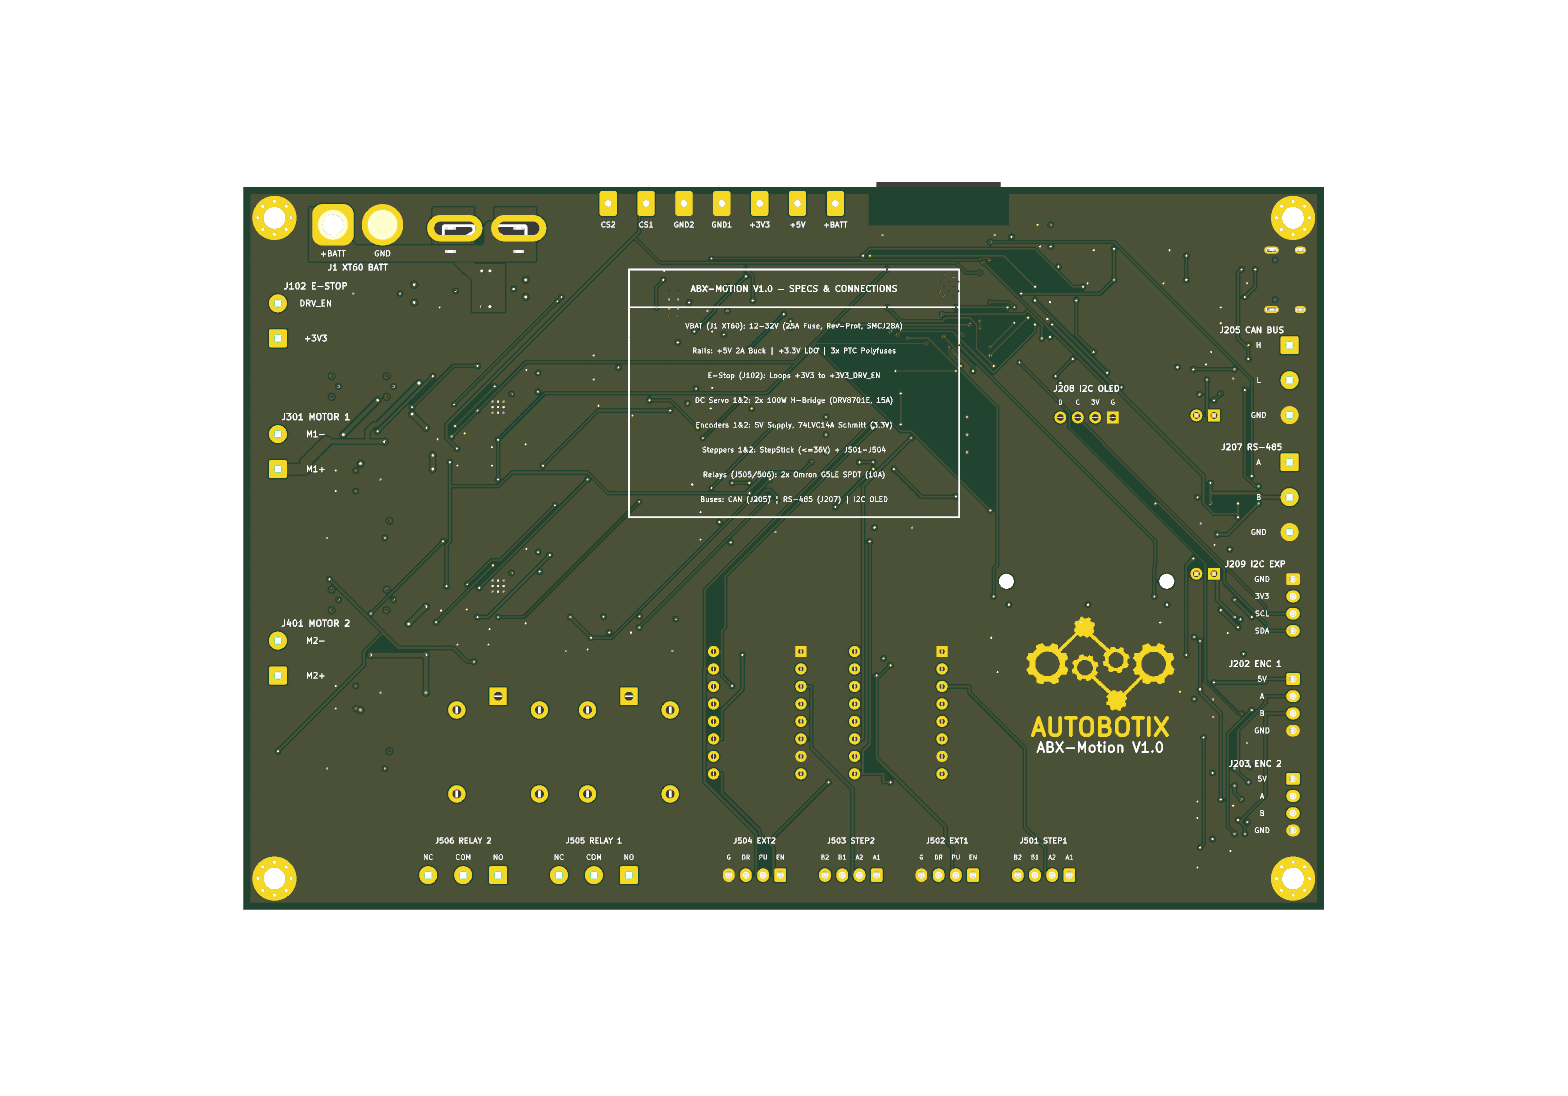
ESP32-S3-WROOM-1-N8R2 with USB-C (USBLC6-2SC6 ESD + tightly-coupled 90Ω differential pair), isolated-ready CAN 2.0B (TCAN1042HGVDRQ1), RS-485 (THVD1450DR with SMBJ6.5CA TVS & 330Ω fail-safe bias), and 0.96" I2C OLED (ER-OLEDM0.96-1B-I2C) + 3-button UI (BACK, NEXT, HOME).DRV8701ERGER full-bridge gate drivers + 8x CSD18540Q5B (60V, 1.8mΩ N-MOSFETs), 10mΩ 3W (CRA2512) Kelvin current shunts, configurable IDRIVE (200kΩ), RC phase snubbers, and 2x 5V quadrature encoder inputs with 1kΩ/1nF low-pass filters + SN74LVC14ADR Schmitt-trigger conditioning.DRV8825 / TMC2209 / TMC5160) with 3-channel microstep DIP switches + parallel 4-pin external industrial stepper driver headers.G5LE-14-DC5 (5V SPDT 10A relays) with AO3400A MOSFET drivers, 1N4148WS flyback diodes, and status LEDs.XT60 battery input, 25A automotive blade fuse, SQJ459EP-T1_GE3 (-60V, 52A P-MOSFET) reverse-polarity protection, SMCJ28A (1500W TVS), LMR36520FADDAR (65V -> 5V 2A synchronous buck), and AP2112K-3.3 LDO.160 x 110 mm): F.Cu (Signals + High-Current Power Pours), In1.Cu (100% Unbroken Solid GND Reference Plane), In2.Cu (+BATT / +5V / +3V3 Power Planes), B.Cu (Signals + Input Power Pours).abx-motion.kicad_pro, abx-motion.kicad_sch, abx-motion.kicad_pcb: Main KiCad 10.0 project, hierarchical schematics (Power.kicad_sch, MCU.kicad_sch, Motor_Channel.kicad_sch, Steppers_Relays.kicad_sch), and routed 4-layer PCB (0 DRC errors, 0 ERC errors).production/: Ready-to-manufacture Gerbers, Excellon drill files, JLCPCB BOM (100% verified in-stock LCSC C-numbers), Pick-and-Place (CPL), and PDFs.renders/: High-resolution 2D/3D board and schematic renders.| Qty | Value | Footprint | References |
|---|---|---|---|
| 20 | 10k | Resistor_SMD:R_0603_1608Metric | R3, R203, R204, R205, R206, R207, R208, R209, R210, R227, R228, R229, R231, R232, R303, R403 +4 |
| 16 | 100nF | Capacitor_SMD:C_0603_1608Metric | C1, C4, C6, C202, C203, C204, C209, C210, C211, C212, C213, C214, C302, C309, C402, C409 |
| 15 | 1k | Resistor_SMD:R_0603_1608Metric | R7, R8, R212, R214, R216, R218, R220, R224, R230, R304, R311, R404, R411, R502, R504 |
| 8 | 10 | Resistor_SMD:R_0603_1608Metric | R305, R306, R307, R308, R405, R406, R407, R408 |
| 8 | 1uF | Capacitor_SMD:C_0603_1608Metric | C5, C9, C301, C303, C304, C401, C403, C404 |
| 8 | CSD18540Q5B | Package_TO_SOT_SMD:TDSON-8-1 | Q301, Q302, Q303, Q304, Q401, Q402, Q403, Q404 |
| 6 | 4.7k | Resistor_SMD:R_0603_1608Metric | R211, R213, R215, R217, R225, R226 |
| 6 | 4.7uF | Capacitor_SMD:C_1206_3216Metric | C2, C3, C307, C308, C407, C408 |
| 5 | LED_GRN | LED_SMD:LED_0603_1608Metric | D502, D504, LED_PWR_3V3_1, LED_PWR_5V1, LED_PWR_BATT1 |
| 4 | 1nF | Capacitor_SMD:C_0603_1608Metric | C205, C206, C207, C208 |
| 4 | M3_Mount | MountingHole:MountingHole_3.2mm_M3_Pad_Via | H1, H2, H3, H4 |
| 2 | 10 | Resistor_SMD:R_0805_2012Metric | R310, R410 |
| 2 | 100 | Resistor_SMD:R_0603_1608Metric | R501, R503 |
| 2 | 100k | Resistor_SMD:R_0603_1608Metric | R2, R4 |
| 2 | 100uF | Capacitor_SMD:CP_Elec_8x10.5 | C501, C502 |
| 2 | 10mR_3W | Resistor_SMD:R_2512_6332Metric | R309, R409 |
| 2 | 10nF | Capacitor_SMD:C_0603_1608Metric | C305, C405 |
| 2 | 10uF | Capacitor_SMD:C_0805_2012Metric | C10, C201 |
| 2 | 120 | Resistor_SMD:R_0603_1608Metric | R219, R221 |
| 2 | 18k | Resistor_SMD:R_0603_1608Metric | R301, R401 |
| 2 | 1N4148WS | Diode_SMD:D_SOD-323 | D501, D503 |
| 2 | 2.2nF | Capacitor_SMD:C_0805_2012Metric | C310, C410 |
| 2 | 200k | Resistor_SMD:R_0603_1608Metric | R312, R412 |
| 2 | 220uF | Capacitor_SMD:CP_Elec_10x10.5 | C306, C406 |
| 2 | 22uF | Capacitor_SMD:C_1206_3216Metric | C7, C8 |
| 2 | 30k | Resistor_SMD:R_0603_1608Metric | R302, R402 |
| 2 | 330R | Resistor_SMD:R_0603_1608Metric | R222, R223 |
| 2 | 5.1k | Resistor_SMD:R_0603_1608Metric | R201, R202 |
| 2 | 500mA_PTC | Fuse:Fuse_1206_3216Metric | F2, F3 |
| 2 | AO3400A | Package_TO_SOT_SMD:SOT-23 | Q501, Q502 |
| 2 | DRV8701ERGER | Package_DFN_QFN:Texas_RGE0024C_VQFN-24-1EP_4x4mm_P0.5mm_EP2.1x2.1mm_ThermalVias | U301, U401 |
| 2 | G5LE-14-DC5 | Relay_THT:Relay_SPDT_Omron-G5LE-1 | K501, K502 |
| 2 | LED_RED_FLT | LED_SMD:LED_0603_1608Metric | LED_FLT1, LED_FLT2 |
| 2 | M2_OLED | MountingHole:MountingHole_2.2mm_M2 | H5, H6 |
| 2 | MICROSTEP_CFG | Button_Switch_SMD:SW_DIP_SPSTx03_Slide_9.78x9.8mm_W8.61mm_P2.54mm | SW501, SW502 |
| 2 | MOTOR_OUT | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | J301, J401 |
| 2 | StepStick_DRV8825 | Module:Pololu_Breakout-16_15.2x20.3mm | U501, U502 |
| 2 | TP_CS | TestPoint:TestPoint_Pad_D1.5mm | TP_CS1, TP_CS2 |
| 1 | 15uH | Inductor_SMD:L_Bourns_SRP7028A_7.3x6.6mm | L1 |
| 1 | 24.9k | Resistor_SMD:R_0603_1608Metric | R5 |
| 1 | 250mA_PTC | Fuse:Fuse_1206_3216Metric | F4 |
| 1 | 25A | Fuse:Fuse_Blade_ATO_directSolder | F1 |
| 1 | 47k | Resistor_SMD:R_0603_1608Metric | R1 |
| 1 | 74LVC14A | Package_SO:SOIC-14_3.9x8.7mm_P1.27mm | U4 |
| 1 | ABX_Logo_Gears_Gold | abx-footprints:ABX_Logo_Gears_Gold | LOGO1 |
| 1 | ABX_Text_Gold | abx-footprints:ABX_Text_Gold | LOGO2 |
| 1 | AP2112K-3.3 | Package_TO_SOT_SMD:SOT-23-5 | U2 |
| 1 | B5819W | Diode_SMD:D_SOD-123 | D202 |
| 1 | BOOT | Button_Switch_SMD:SW_SPST_B3U-1000P | SW202 |
| 1 | BTN_BACK | Button_Switch_SMD:SW_SPST_B3U-1000P | SW203 |
| 1 | BTN_HOME | Button_Switch_SMD:SW_SPST_B3U-1000P | SW205 |
| 1 | BTN_NEXT | Button_Switch_SMD:SW_SPST_B3U-1000P | SW204 |
| 1 | BZT52C12S | Diode_SMD:D_SOD-323 | D1 |
| 1 | CAN_BUS | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-3-5.08_1x03_P5.08mm_Horizontal | J205 |
| 1 | CAN_TERM | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J204 |
| 1 | ENC1_CONN | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J202 |
| 1 | ENC2_CONN | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J203 |
| 1 | ESP32-S3-WROOM-1-N8R2 | RF_Module:ESP32-S3-WROOM-1 | U3 |
| 1 | E_STOP | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | J102 |
| 1 | I2C_EXP | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J209 |
| 1 | LED_BLU_STAT | LED_SMD:LED_0603_1608Metric | LED203 |
| 1 | LED_YEL_485 | LED_SMD:LED_0603_1608Metric | LED202 |
| 1 | LED_YEL_CAN | LED_SMD:LED_0603_1608Metric | LED201 |
| 1 | LMR36520FADDA | Package_SO:Texas_HSOP-8-1EP_3.9x4.9mm_P1.27mm_ThermalVias | U1 |
| 1 | OLED_I2C | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | J208 |
| 1 | RELAY1_OUT | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-3-5.08_1x03_P5.08mm_Horizontal | J505 |
| 1 | RELAY2_OUT | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-3-5.08_1x03_P5.08mm_Horizontal | J506 |
| 1 | RESET | Button_Switch_SMD:SW_SPST_B3U-1000P | SW201 |
| 1 | RS485_BUS | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-3-5.08_1x03_P5.08mm_Horizontal | J207 |
| 1 | RS485_TERM | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J206 |
| 1 | SMBJ6.5CA | Diode_SMD:D_SMB | D201 |
| 1 | SMCJ30A | Diode_SMD:D_SMC | D2 |
| 1 | SQJ459EP-T1_GE3 | Package_TO_SOT_SMD:TDSON-8-1 | Q1 |
| 1 | STEP1_EXT | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J502 |
| 1 | STEP1_MOTOR | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J501 |
| 1 | STEP2_EXT | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J504 |
| 1 | STEP2_MOTOR | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J503 |
| 1 | TCAN1042V-Q1 | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U202 |
| 1 | THVD1450DR | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U203 |
| 1 | TP_3V3_1 | TestPoint:TestPoint_Pad_D1.5mm | TP_3V3_1 |
The 196 most common of 203 parts.
It measures 157 × 105 mm and has 4 copper layers, 1.6 mm thick.
203 parts, built around the ESP32-S3-WROOM-1-N8R2, THVD1450DRBR, DRV8701ERGER and LMR36520FADDA. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the levdan159/abx-motion repository on GitHub, at the commit this page was made from: the board is abx-motion.kicad_pcb and its schematic MCU.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask levdan159 before reusing the design.

ayaamghi/4C
4 Channel motor controller board for high voltage high amperage solutions. Integrated PID.

lachlanhurst/dukki
Bipedal robot based on Microduck, rebuilt around Unitree J288 servos and a Radxa CM4.

xtech/hw-openmower-sabo
OpenMower is an open-source project that upgrades off-the-shelf robotic mowers into modern, smart lawn mowing robots with RTK GPS technology. For more details, check out the OpenMower project.

dario0603/power_supply
Progetto universitario per la realizzazione e simulazione di un Alimentatore da Banco Stabilizzato , completo di schemi elettrici KiCad, simulazioni LTspice, documentazione tecnica e file Gerber per la produzione del…

Meo98/picostack
Stackable, contract-driven module system for the Raspberry Pi Pico — open hardware, built by code


Tinkerbug-Robotics/TinkerRocket
Model rocket flight computer, ground station, iOS app, and simulation