4 layers100.1 × 60.2 mm
Hades
pms67/HadesFCS
Complete flight control system designed from scratch. Hardware designed with KiCad.
215 parts1kBSD-3-Clause
 VedantC2307/PiPowerBridge
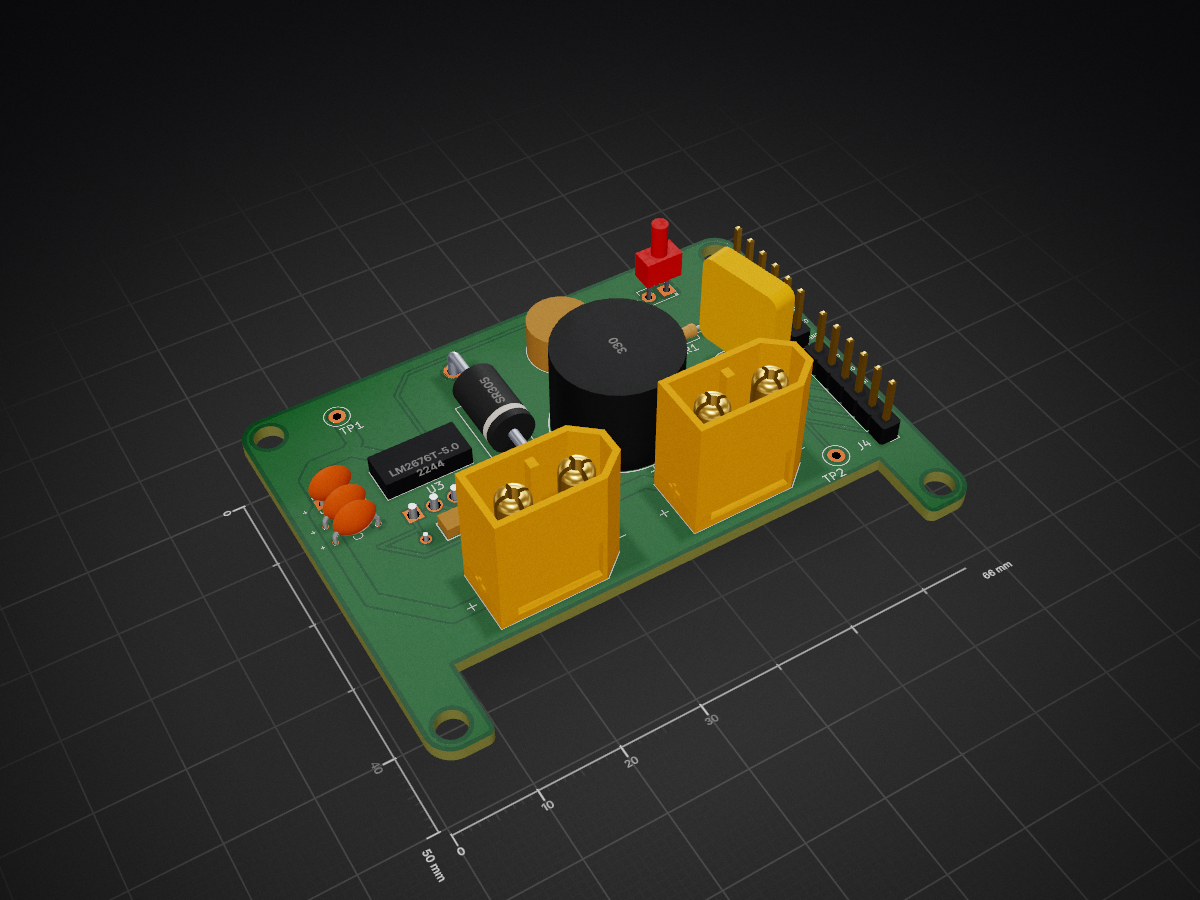
A power distribution PCB designed to manage power delivery for a Raspberry Pi and ODrive motor controller. The board is specifically optimized to mount directly on top of the ODrive controller for a compact and…
Step down converter odrive rpi is an open-source printed circuit board by VedantC2307, from the VedantC2307/PiPowerBridge repository on GitHub. It is a 2-layer board of 66 × 50 mm with 17 parts on 13 nets, routed with 77 tracks and 0 vias.
It is built around the LM2676T-5.0 and XT60-M. Its parts include 5 capacitors, 4 connectors, 2 diodes, 1 resistor and 1 IC.
A power distribution PCB designed to manage power delivery for a Raspberry Pi and ODrive motor controller. The board is specifically optimized to mount directly on top of the ODrive controller for a compact and integrated solution.
This PCB converts 33V input from a LiPo battery to 5V to power for the Raspberry Pi, while also directly powering the ODrive motor controller. It’s designed to stack directly on top of the controller, saving space and keeping the setup tidy. It includes an additional SPI interface pins for easily connecting external sensors like encoder.
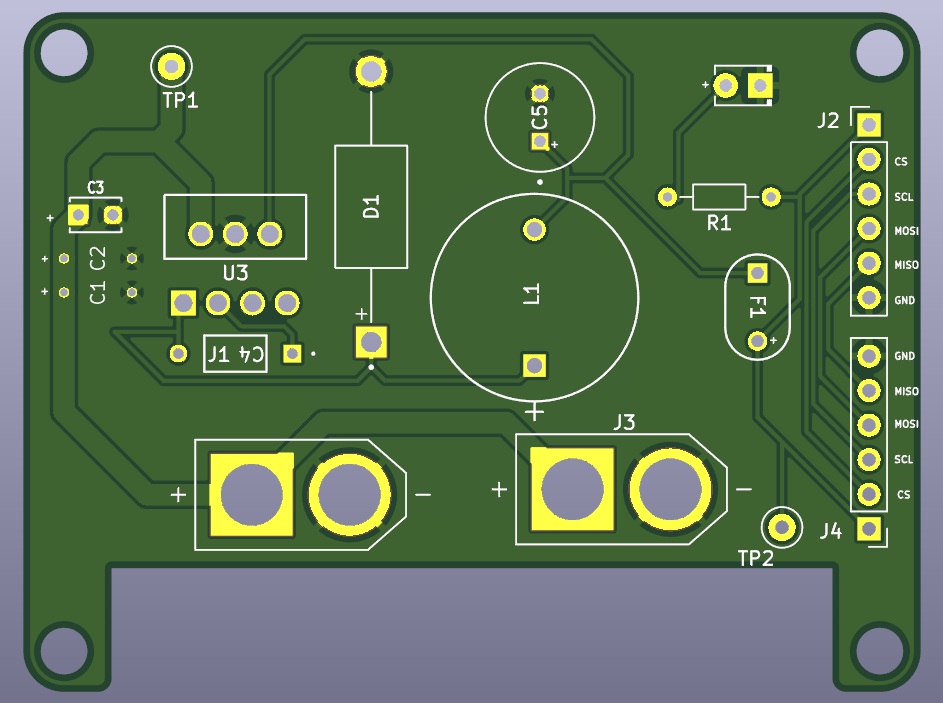
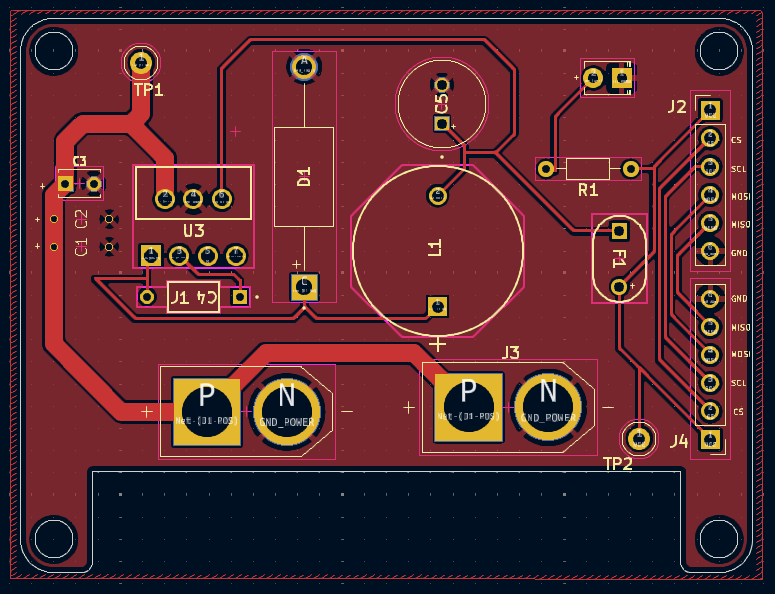
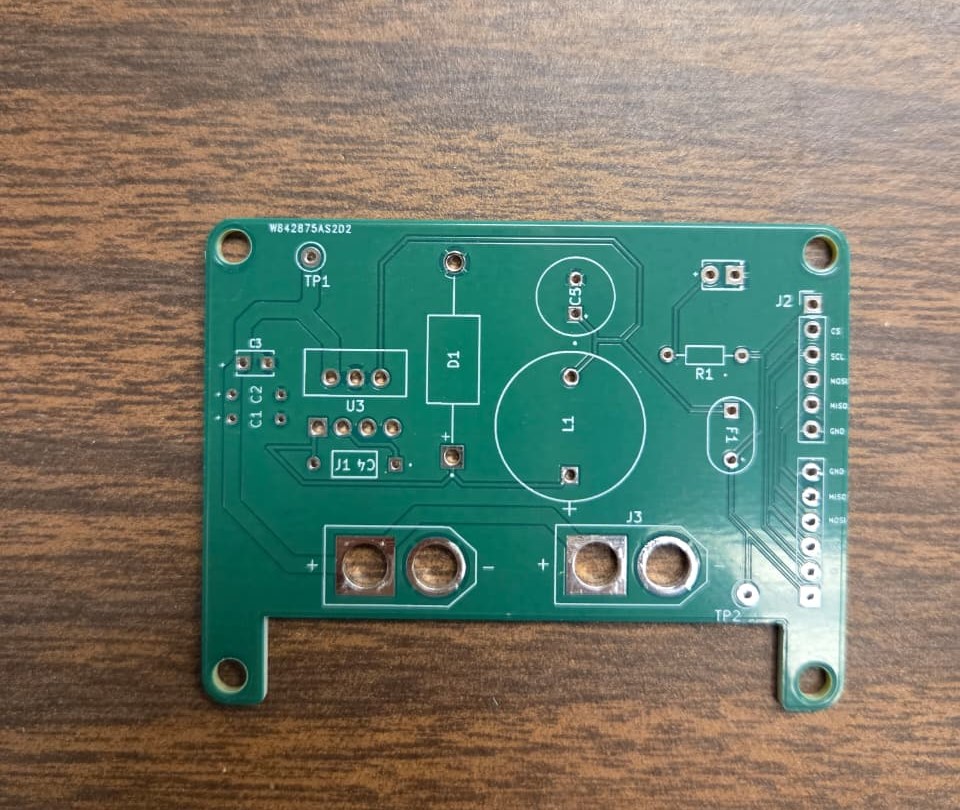
| Qty | Value | Footprint | References |
|---|---|---|---|
| 2 | 15µF | power_distribution_board:PCB capacitor 15uF | C1, C2 |
| 2 | TestPoint | TestPoint:TestPoint_Loop_D2.50mm_Drill1.0mm_LowProfile | TP1, TP2 |
| 2 | XT60-M | XT60-M:AMASS_XT60-M | J1, J3 |
| 2 | ~ | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J2, J4 |
| 1 | 0.01µF | 0.01uF capacitor:CAP_C410C_AX_Z5U_U5TA_KEM | C4 |
| 1 | 0.47µF | Capacitor 0.47uF:CAPRR254W54L381T254H466 | C3 |
| 1 | 180µF/16V | 180uF Capacitor:CAPPRD350W60D800H1200 | C5 |
| 1 | 33µH | 33µH Inductor Inductor:IND_SBC8-330-452_KEM | L1 |
| 1 | Fuse (3A) | Polyfuse 3A:FUSE_CMF-RL50A-0_BRN | F1 |
| 1 | LED | LED_THT:LED_D2.0mm_W4.0mm_H2.8mm_FlatTop | D2 |
| 1 | LM2676T-5.0 | LM2676T_5_0_NOPB:TA07B | U3 |
| 1 | R | Resistor_THT:R_Axial_DIN0204_L3.6mm_D1.6mm_P7.62mm_Horizontal | R1 |
| 1 | SR305 | SR305 - Diode:DIOAD1990W125L900D530 | D1 |
pms67/HadesFCS
Complete flight control system designed from scratch. Hardware designed with KiCad.

GonzaCerv/noah-hardware
This repo contains all the hardware description for the Noah project. Here lies 3D models, electronics PCB and Firmware software of the robot.


edromufu/edromufu
Repositório da EDROM-UFU destinado ao desenvolvimento do projeto humanoide para participação nas competições LARC e ROBOCUP.


kairobyte/bipedal_self_balance
A bipedal self balancing robot with 2DOF in each leg. Built from scratch.


KIIT-Robotic-Society/Dharma_RoboFest4.0
Dharma Bot is a quadruped robotic dog featuring 12-DOF locomotion, real-time sensing, and a modular subsystem design.
It measures 66 × 50 mm and has 2 copper layers, 1.6 mm thick.
17 parts, built around the LM2676T-5.0 and XT60-M. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the VedantC2307/PiPowerBridge repository on GitHub, at the commit this page was made from: the board is Step_down_converter_odrive_rpi/Step_down_converter_odrive_rpi.kicad_pcb and its schematic Step_down_converter_odrive_rpi/Step_down_converter_odrive_rpi.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask VedantC2307 before reusing the design.