
2 layers150 × 60 mm
GPSDOMonitor
sergeyvfx/GPSDOMonitor
A tiny module which is connecting to a databus of GPSDO modules with the goal to visualize when the PLL is locked, GPS time is stabilized and things like this.
49 parts1MIT

This repo contains all the hardware description for the Noah project. Here lies 3D models, electronics PCB and Firmware software of the robot.
Root is an open-source printed circuit board by GonzaCerv, from the GonzaCerv/noah-hardware repository on GitHub, published under the MIT licence. It is a 2-layer board of 120 × 100 mm with 127 parts on 143 nets, routed with 1,351 tracks and 102 vias.
It is built around the ESP-07, MCP2551-I/SN-HG and ROB-14450, with the XL4015E1, MCP16301T-I/CHY-MS and STC3100IST among its other parts. Its parts include 33 resistors, 30 capacitors, 23 connectors, 15 ICs and 15 diodes. It belongs with the robots and motor control boards and the ESP8266 and STM32 boards of this library.


 [blocked]
 [blocked]

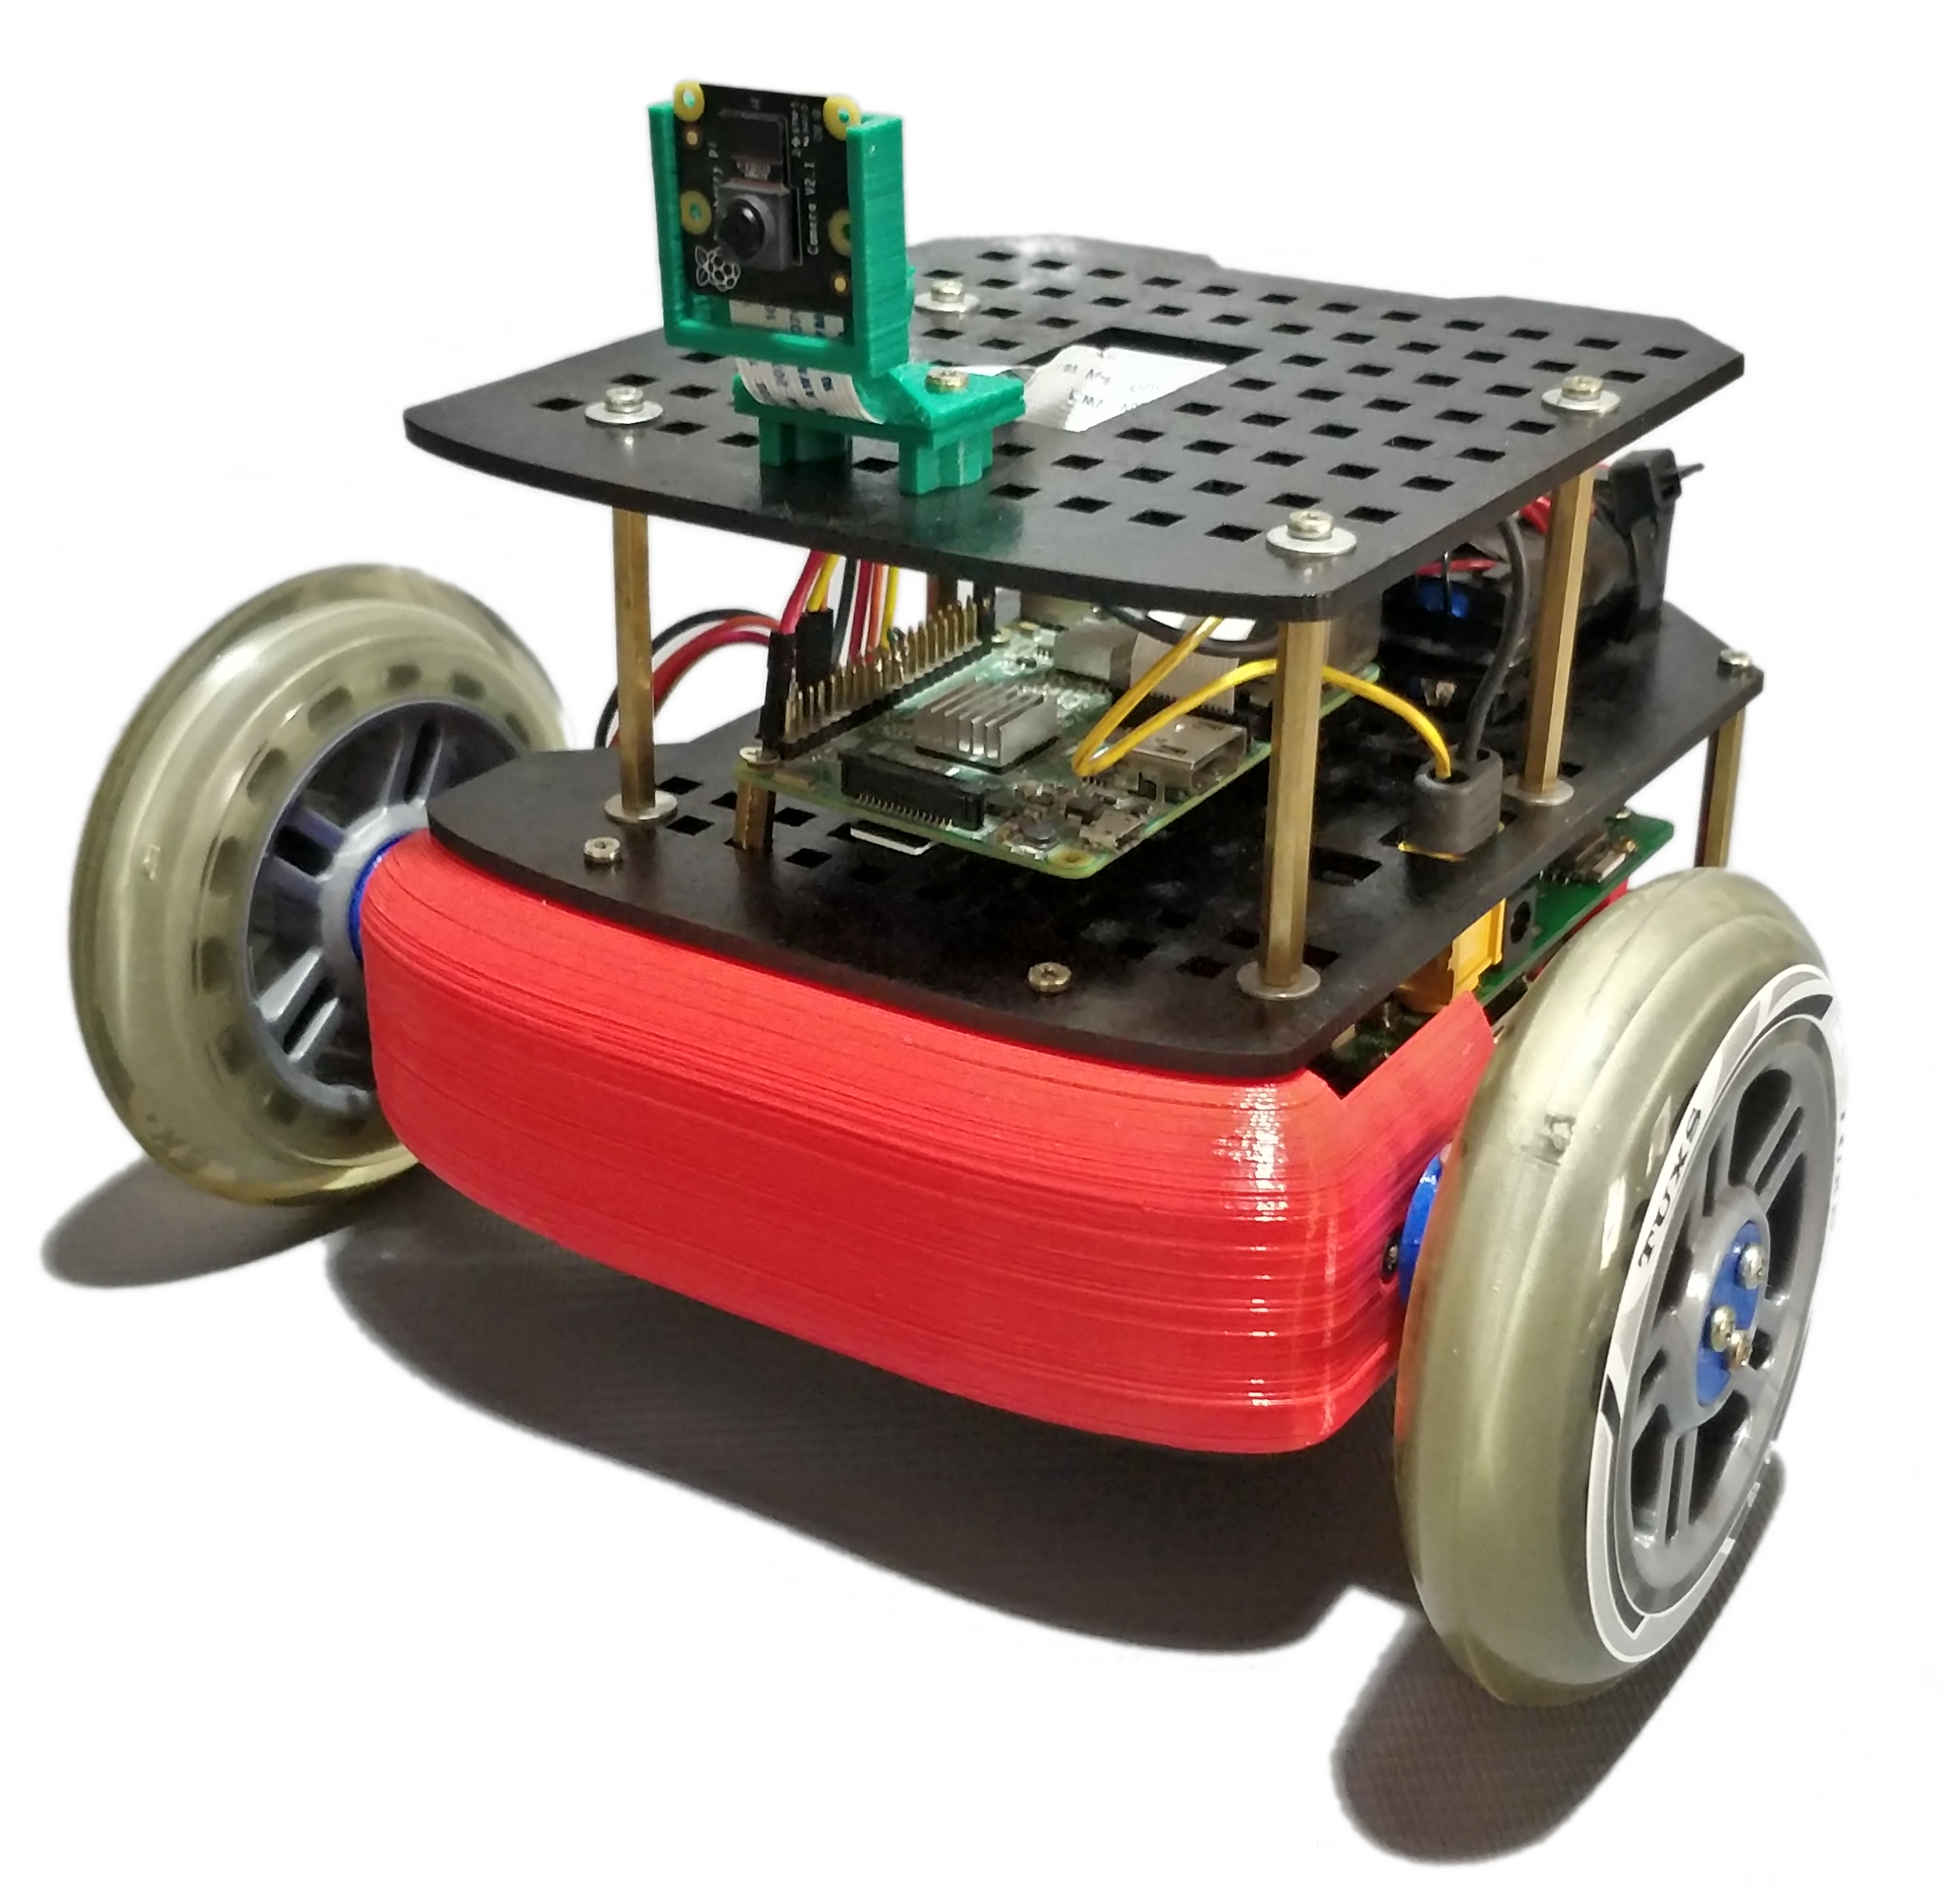
This repo contains all the necessary hardware for noah-robot.
As a final thesis project of Electronics engineering, I decided to build a robot from scratch. All the design was made in order to build the robot with parts that can be bought in Argentina.
Take a look to the other repos related to this project:
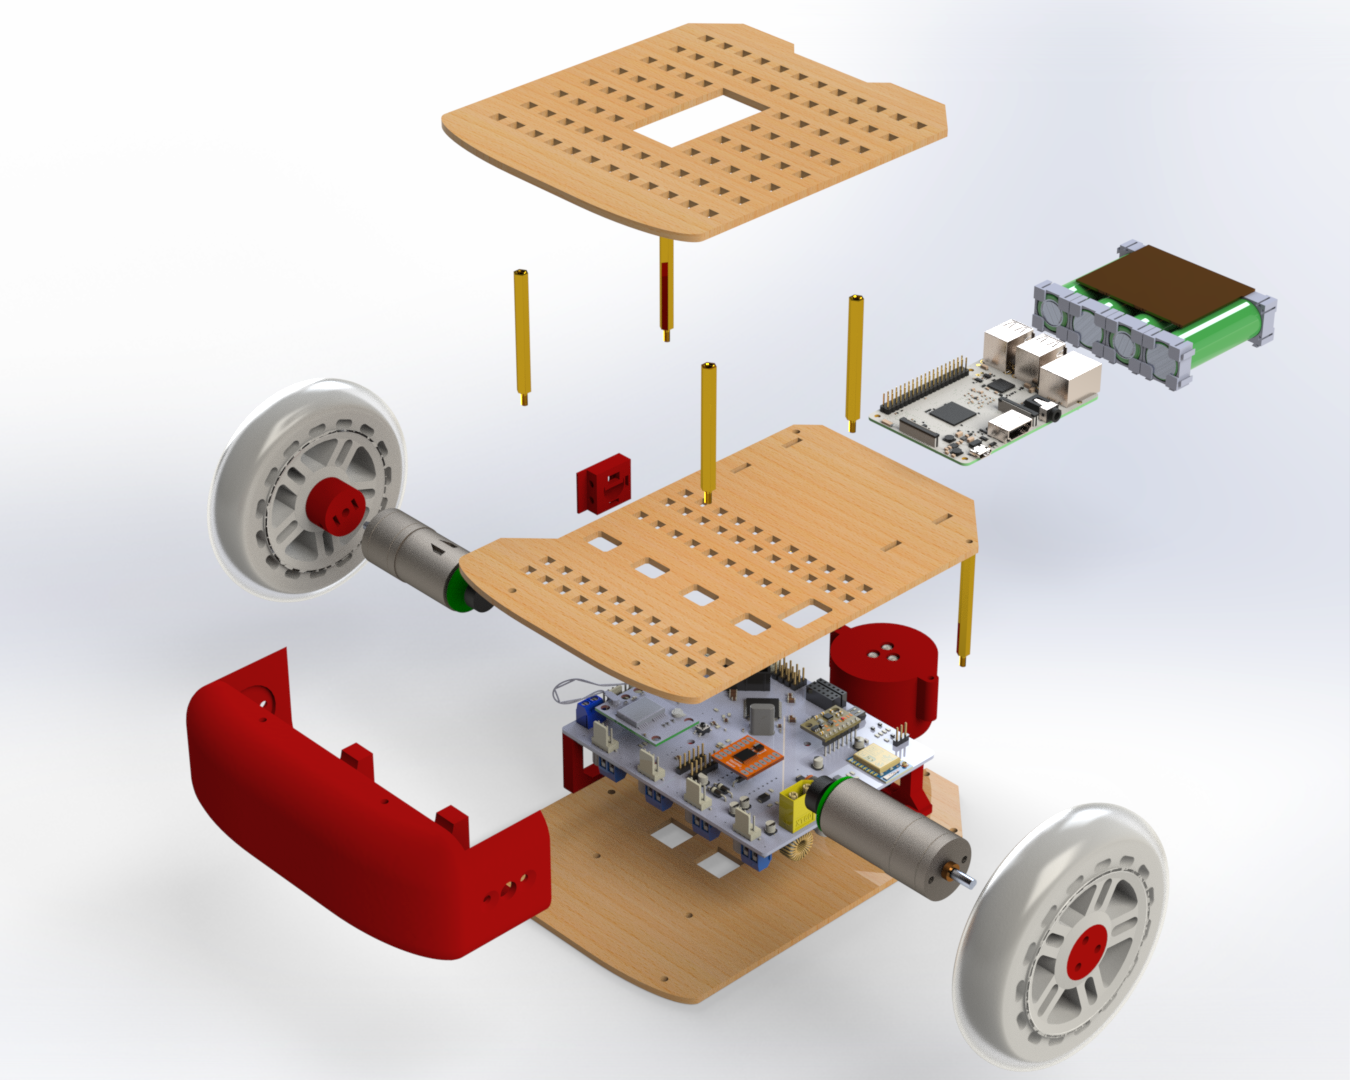
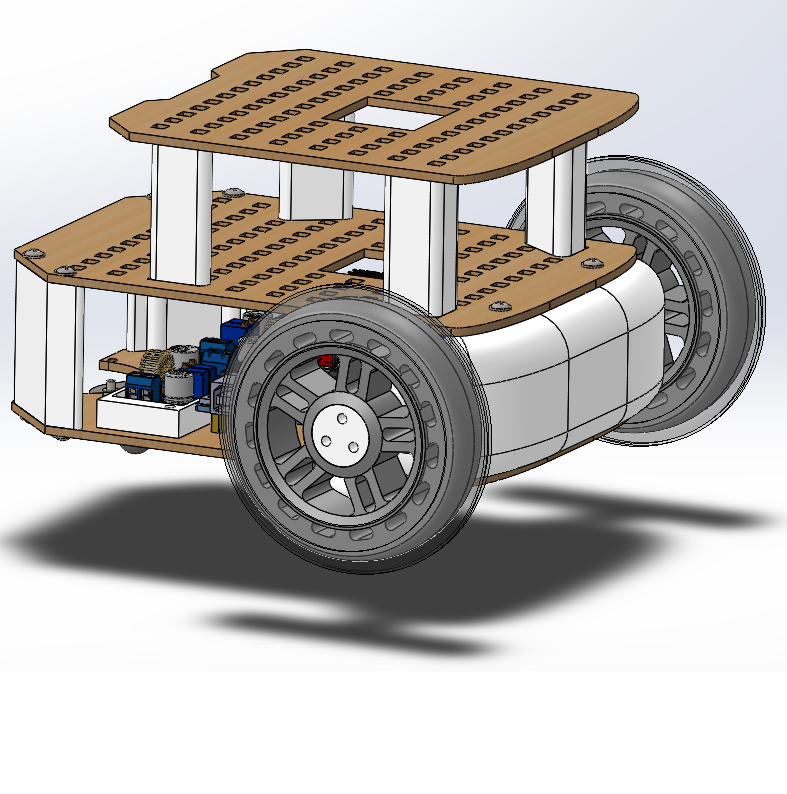
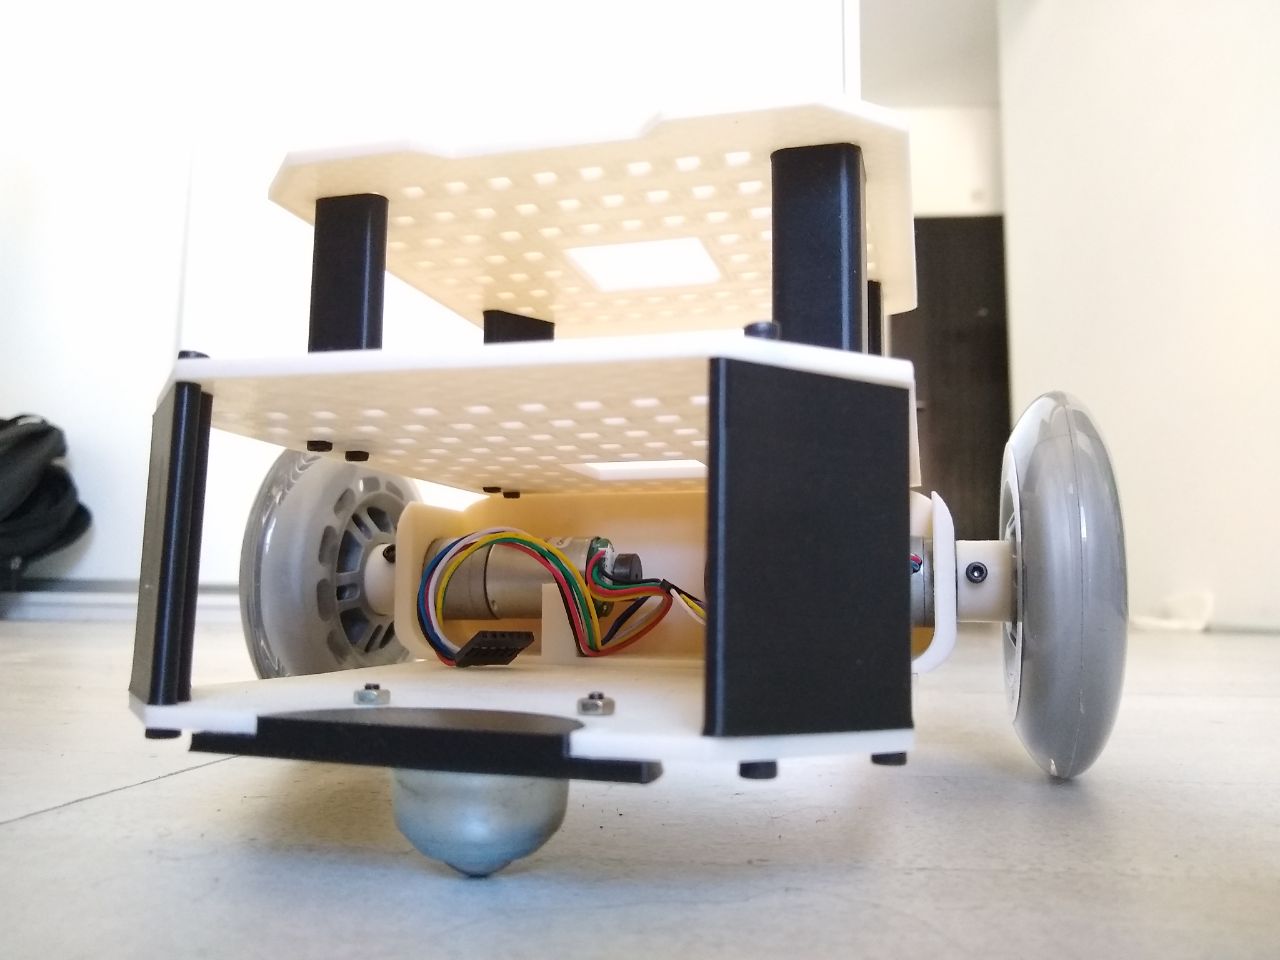
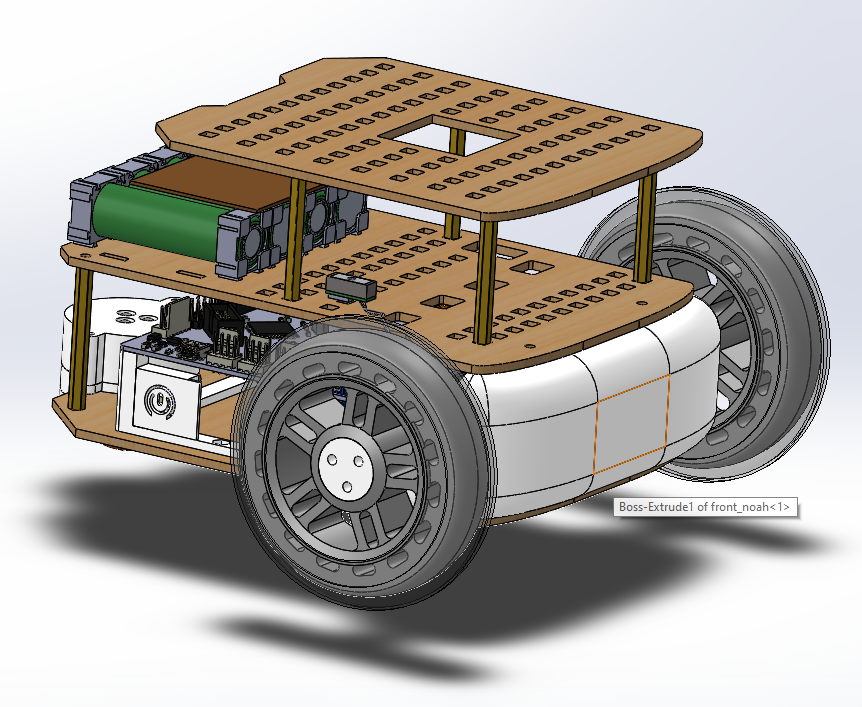
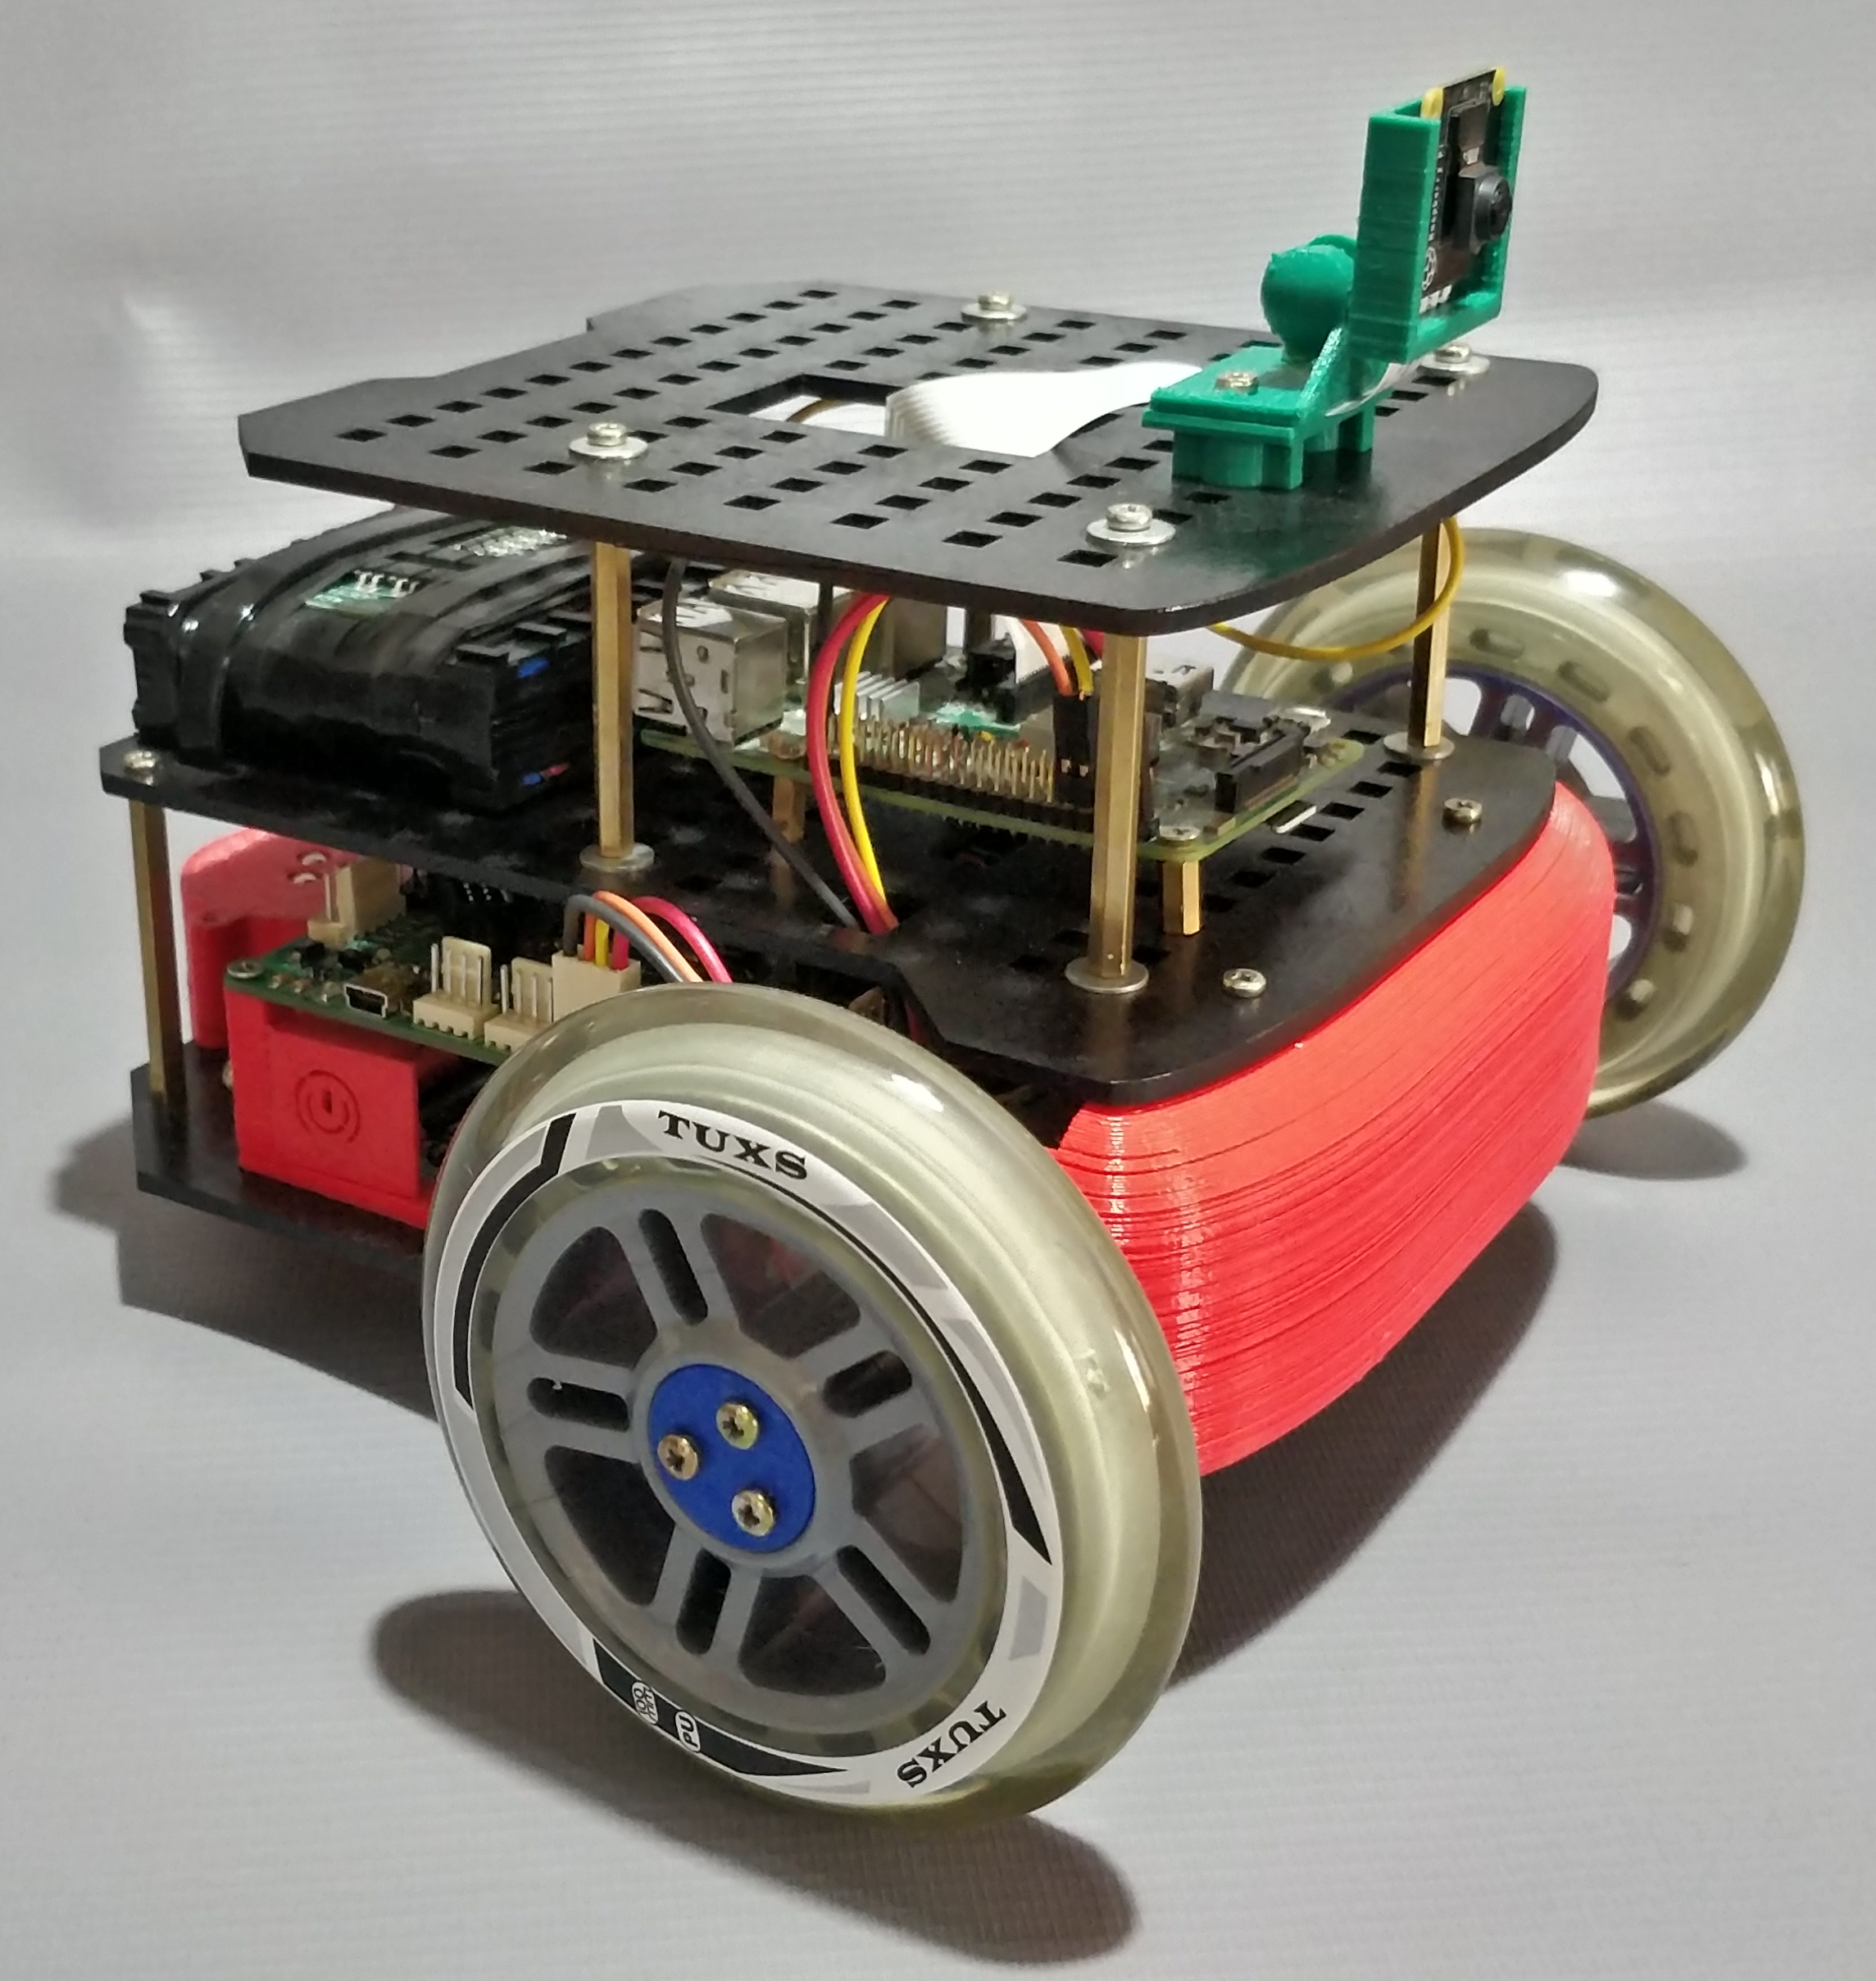
The robot is made out of 3D printed parts, some parts made with 3mm laser cut and vitamins. All the parts were designed with Solidworks. You can find those parts as well as files for construction in the 3D model section.
There are 2 versions of the robot. The Noah version which uses the noah main controller board. If you want to implement your own circuit a generic version was also designed.
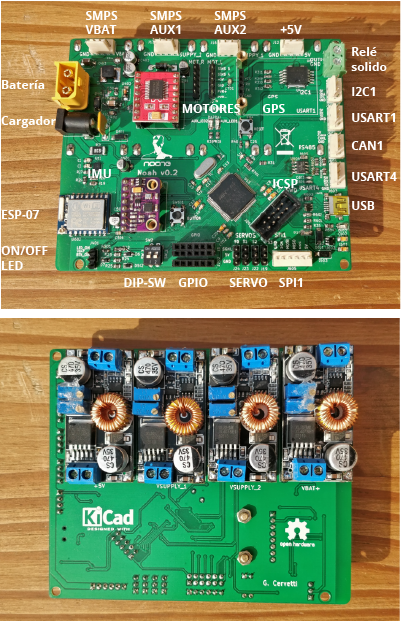
The main PCB is in charge of controlling all the peripherals of the robot. You can see in the pictures a all the connectors available. Several modules were provided:
At the bottom there are 4 SMPS modules installed. They are capable of delivering up to 5A per channel.
The PCB was designed with Kicad. Take a look to the PCB section.
The STM32F407VG was choseen as the main controller of this board. It runs at 72Mhz, enough to manage the 4 main FreeRTOS tasks that are currently coded:
This project uses STM32CubeIde.
Install LFS in your machine:
git lfs installclone the repo:
git clone git@github.com:GonzaCerv/noah-hardware.git| Qty | Value | Footprint | References |
|---|---|---|---|
| 14 | 100nF | Capacitor_SMD:C_0805_2012Metric_Pad1.15x1.40mm_HandSolder | C2, C3, C8, C9, C10, C11, C13, C15, C17, C25, C402, C504, C701, C702 |
| 11 | 1K-1% | Resistor_SMD:R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R1, R22, R23, R24, R25, R27, R31, R34, R40, R605, R701 |
| 9 | 120 | Resistor_SMD:R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R35, R38, R39, R501, R604, R606, R607, R608, R609 |
| 8 | Conn_01x04 | Connector_Molex:Molex_KK-254_AE-6410-04A_1x04_P2.54mm_Vertical | J12, J13, J16, J17, J602, J603, J604, J606 |
| 6 | 10uF | Capacitor_SMD:CP_Elec_4x4.5 | C4, C201, C401, C403, C501, C503 |
| 6 | 2.2uF | Capacitor_SMD:C_1206_3216Metric_Pad1.42x1.75mm_HandSolder | C12, C20, C21, C23, C601, C602 |
| 5 | B140-E3 | Diode_SMD:D_SMA | D401, D402, D501, D503, D601 |
| 5 | Conn_01x03_Male | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J19, J22, J23, J24, J401 |
| 4 | 22pF | Capacitor_SMD:C_0603_1608Metric_Pad1.05x0.95mm_HandSolder | C18, C19, C603, C604 |
| 4 | LED | LED_SMD:LED_1206_3216Metric_Pad1.42x1.75mm_HandSolder | D10, D11, D12, D602 |
| 4 | XL4015 | noah_footprint:XL4015_Converter | U7, U8, U9, U10 |
| 3 | 100K-0.1% | Resistor_SMD:R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R19, R20, R603 |
| 3 | 1N4007 | Diode_THT:D_DO-41_SOD81_P10.16mm_Horizontal | D1, D2, D3 |
| 3 | 3K3 | Resistor_SMD:R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R311, R312, R601 |
| 3 | 5K6 | Resistor_SMD:R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R309, R310, R602 |
| 3 | MM3Z3V3B | Diode_SMD:D_SOD-323_HandSoldering | D6, D7, D502 |
| 2 | 10K-1% | Resistor_SMD:R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R26, R29 |
| 2 | Conn_01x06 | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J1, J2 |
| 2 | SW_DPST_x2 | Button_Switch_SMD:SW_SPST_EVPBF | SW1, SW601 |
| 1 | 0.03Ohm-1% | Resistor_SMD:R_2512_6332Metric | R21 |
| 1 | 22uH | Inductor_SMD:L_Bourns_SRN8040TA | L1 |
| 1 | 31.6K-1% | Resistor_SMD:R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R30 |
| 1 | 3v3 Low Power | TestPoint:TestPoint_Pad_D3.0mm | TP4 |
| 1 | 8Mhz | Crystal:Crystal_HC49-U_Vertical | Y1 |
| 1 | Barrel_Jack_Switch | Connector_BarrelJack:BarrelJack_Wuerth_6941xx301002 | J11 |
| 1 | Conn_01x06 | Connector_PinSocket_2.54mm:PinSocket_1x06_P2.54mm_Vertical | J702 |
| 1 | Conn_01x06 | Connector_Molex:Molex_KK-254_AE-6410-06A_1x06_P2.54mm_Vertical | J605 |
| 1 | Conn_02x05_Odd_Even | Connector_IDC:IDC-Header_2x05_P2.54mm_Vertical | J20 |
| 1 | Conn_02x06_Odd_Even | Connector_PinSocket_2.54mm:PinSocket_2x06_P2.54mm_Vertical | J3 |
| 1 | ESP-07 | RF_Module:ESP-07 | U602 |
| 1 | GY-91 | noah_footprint:GY-91 | U2 |
| 1 | GY-NEO6MV2 | noah_footprint:GY-NEO6MV2 | U6 |
| 1 | LOGO | noah_footprint:Noone | G*** |
| 1 | MCP16301T-I_CHY | noah_footprint:SOT95P270X145-6N | U401 |
| 1 | MCP2551-I-SN | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U604 |
| 1 | Polyfuse | Capacitor_THT:C_Disc_D7.5mm_W2.5mm_P5.00mm | F501 |
| 1 | ROB-14450 | noah_footprint:ROB14450 | U1 |
| 1 | STC3100IST | Package_DFN_QFN:DFN-8-1EP_3x3mm_P0.5mm_EP1.66x2.38mm | U11 |
| 1 | STM32F407VGTx | Package_QFP:LQFP-100_14x14mm_P0.5mm | U13 |
| 1 | SW_DIP_x02 | Button_Switch_THT:SW_DIP_SPSTx02_Slide_6.7x6.64mm_W7.62mm_P2.54mm_LowProfile | SW2 |
| 1 | Screw_Terminal_01x02 | TerminalBlock:TerminalBlock_bornier-2_P5.08mm | J7 |
| 1 | TLV75533PDBV | Package_TO_SOT_SMD:SOT-23-5 | U603 |
| 1 | USBLC6-2SC6 | Package_TO_SOT_SMD:SOT-23-6 | U601 |
| 1 | USB_B_Mini | Connector_USB:USB_Mini-B_Lumberg_2486_01_Horizontal | J601 |
| 1 | VND830SPTR-E | noah_footprint:VND830SPTR-E | U4 |
| 1 | XT60-M | noah_footprint:AMASS_XT60-M | J15 |
The 124 most common of 127 parts.
sergeyvfx/GPSDOMonitor
A tiny module which is connecting to a databus of GPSDO modules with the goal to visualize when the PLL is locked, GPS time is stabilized and things like this.

SunDevilRocketry/Flight-Computer
General purpose flight computer for high powered rocketry projects.


svcguy/LoRaWAN-Feather-Hardware
Schematic and PCB for a Feather-compatible, LoRaWAN-compatible board

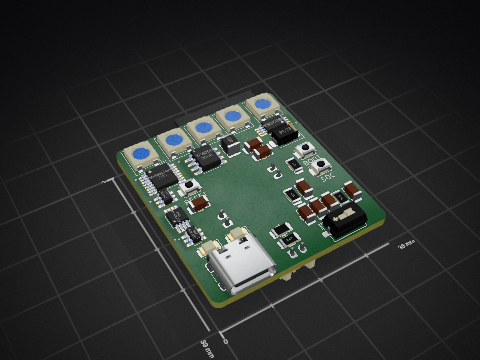


It measures 120 × 100 mm and has 2 copper layers, 1.6 mm thick.
127 parts, built around the ESP-07, MCP2551-I/SN-HG, ROB-14450 and XL4015E1. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the GonzaCerv/noah-hardware repository on GitHub, at the commit this page was made from: the board is PCB/root.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).